
Five reversing operation of the reverse brake circuit
#reverse brake
#plug braking
#limit switch
#automation
#safety circuit
#motor driver
#control system
#electrical safety
#industrial circuit
#round-trip operation
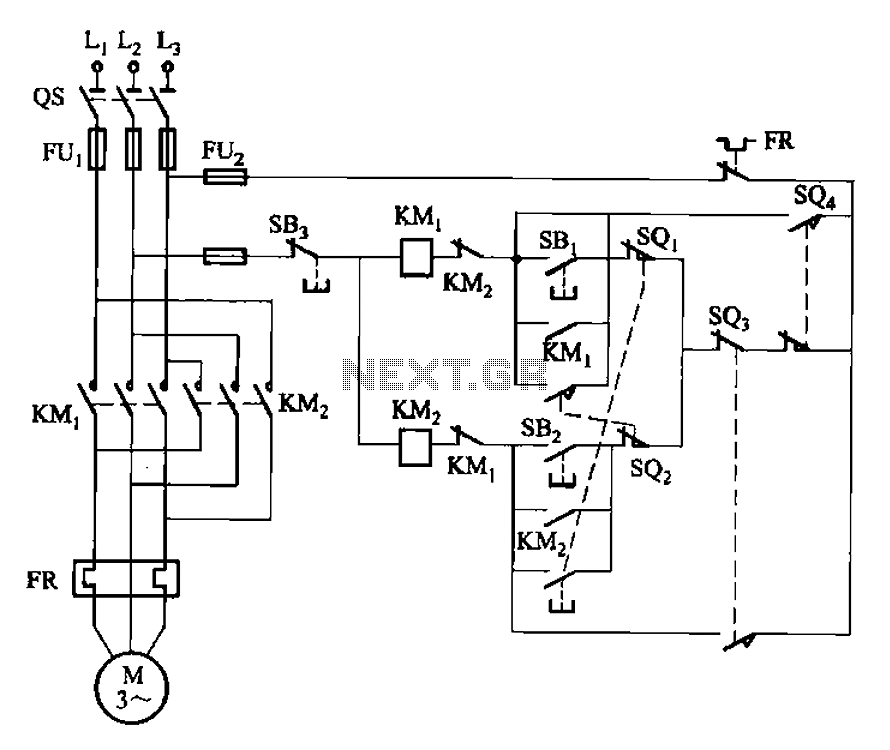
Description: The circuit illustrated in Figure 3-132 represents an automatic round-trip plug braking circuit. To prevent or limit malfunctions of switch SQ1 and switch SQ2 that could lead to accidents, two additional protection limit switches, S03 and S04, have been incorporated.
The automatic round-trip plug braking circuit is designed to enhance safety and reliability in applications where precise control of electrical devices is essential. This circuit ensures that the operation of the primary switches (SQ1 and SQ2) is safeguarded against unintended disconnections or faults that may arise during operation.
In this design, the primary switches are critical for controlling the flow of electrical current. However, to mitigate the risk of accidental activation or failure, the inclusion of limit switches S03 and S04 serves as an additional layer of protection. These limit switches are strategically positioned to monitor the operational state of the primary switches. If either switch SQ1 or SQ2 experiences a fault condition, the limit switches will activate and interrupt the circuit, thereby preventing potential hazards.
The circuit operates by using a combination of relays and limit switches that are interconnected in a manner that allows for automatic resetting after a fault condition has been cleared. This functionality is crucial in applications where continuous operation is necessary, and any downtime must be minimized.
The overall design emphasizes robustness and safety, ensuring that the circuit can handle unexpected conditions without compromising the integrity of the system. The use of additional protection limit switches not only enhances the reliability of the circuit but also increases the overall lifespan of the components involved, making it a suitable choice for various industrial applications. Circuit shown in Figure 3-132. The line is automatically round-trip, plug braking circuit. In order to prevent or limit switch SQl offside SQz malfunction caused the accident, two increased protection limit switches s03 and s04.

Electrical_Subsystem
The following data and mapping pertain to the 2-D shift mapping algorithm that the controller will utilize to determine when and if a shift should occur. The solid lines on the graph indicate up-shift boundaries, while the dashed lines represent...
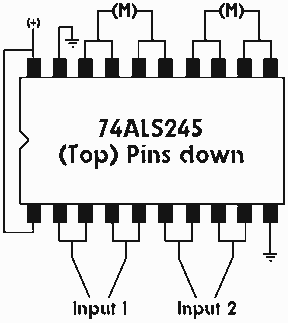
Single IC chip Motor Driver for robots
A motor driver is required in pretty much all walkers including all of my CW series walkers. You need to use it any time you need to supply more current to the motors because the circuit can't supply enough. This...
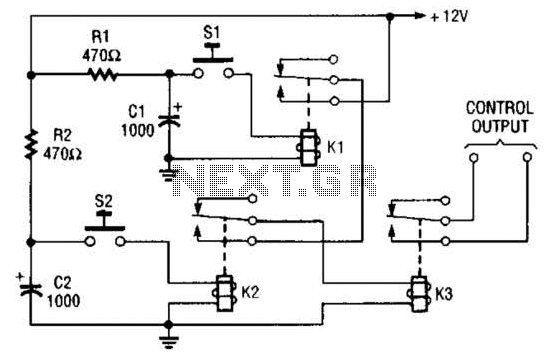
Safety Circuit Circuit
Due to the limited hold-on time of the delay circuits R1/C1 and R2/C2, both switches S1 and S2 must be activated simultaneously to energize the load.
The circuit in question involves a delay mechanism governed by the time constants associated with...
Process-Control
The Measured Value and the Setpoint are two inputs to a control system. The Measured Value is the amplified input from a transducer or sensor that monitors a parameter requiring control, such as pressure or temperature. The Setpoint is the...
automatic pet feeder
An automatic feeder dispenses food based on the activation of a series of buttons, which interface with a system controller and a food dispenser. The system is designed for intelligent processing of inputs and outputs, allowing dynamic configuration of button...
Four-way operation of the reverse brake circuit
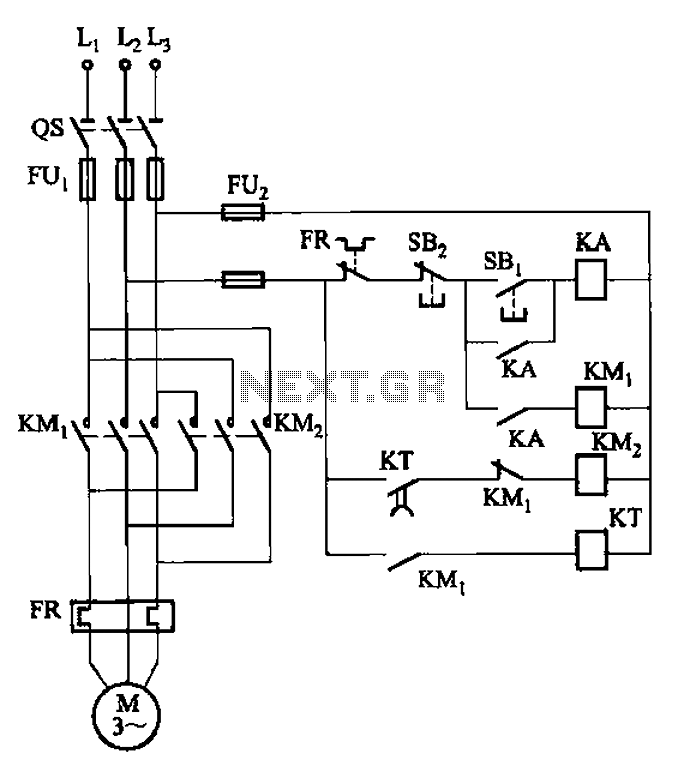
The circuit illustrated in Figure 3-127 utilizes a time relay (KT) in place of a speed relay. The timing duration is adjustable and typically set between 1 to 2 seconds. This circuit is designed to operate effectively in dusty environments...
Objects in Flux
The Open Source Automation project is a free automation software that operates on Windows and does not require programming for setup. It features a user-friendly graphical interface and includes unique functionalities that are not typically found in high-end security and...
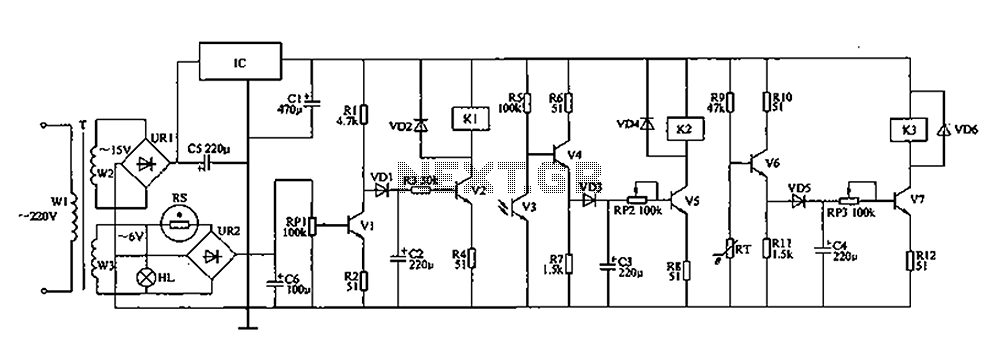
Coop automatic controller circuit diagram
The automatic controller for a chicken coop is designed to automatically regulate light, temperature, and humidity, thereby enhancing egg production and survival rates of chickens. This device is intended for specialized poultry households in rural areas. The circuit operates through...
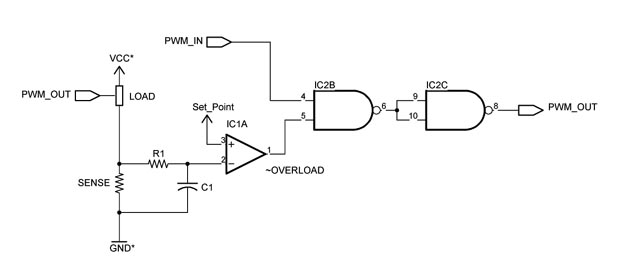
Custom Motor Driver
This chapter was removed from Applied Robotics 2 due to space constraints. It addresses general motor control issues and details the construction of a 5-amp motor driver. The principles discussed can be applied to larger motor controllers. Although commercially available...