


automatic pet feeder
#automation
#food dispenser
#system controller
#buttons
#home appliance
#pet care
#input/output processing
#dynamic configuration
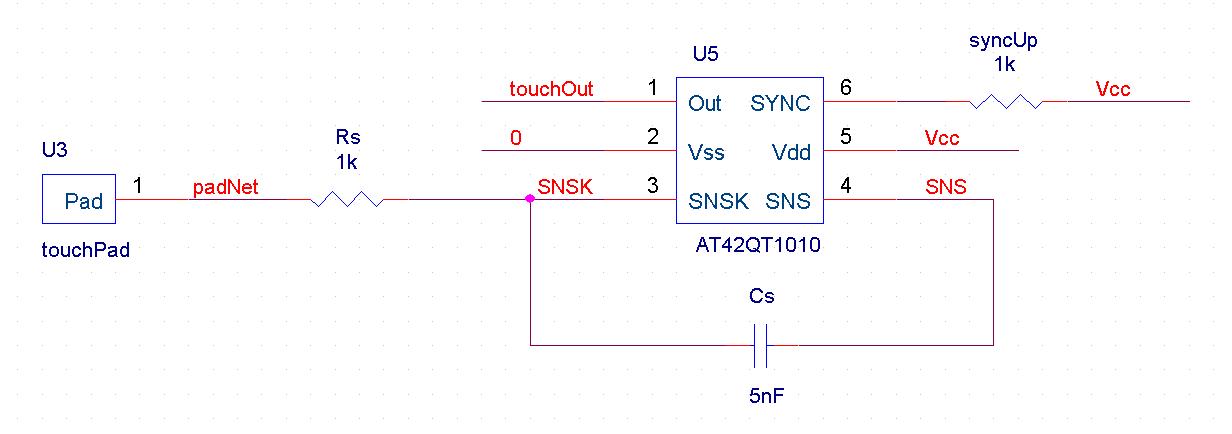
Description: An automatic feeder dispenses food based on the activation of a series of buttons, which interface with a system controller and a food dispenser. The system is designed for intelligent processing of inputs and outputs, allowing dynamic configuration of button activation effects on food dispensing without hardware modifications. Initially, any button activation dispenses food to help the cat learn the system. As the cat becomes more comfortable, constraints can be placed on button activations, such as only allowing the button with a light to dispense food. The system also records which buttons are pressed and whether the choices are correct, enabling data collection on the cat's learning curve. The feeder ensures the cat always receives twice daily feedings of canned food, while the dispenser controls access to a secondary supply of dry food. An interface mechanism was developed for the cat to interact with the system, ultimately choosing discrete capacitive touch buttons to minimize mechanical housing and supporting electronics. Three buttons, each with a dual-color LED for signaling, were mounted in a simple plexiglass holder to protect the electronics. The active button portion of the board consists of a large copper pour connected to an AT42QT1010 IC, which detects capacitance changes on the copper pad. The circuit includes a syncUp resistor for fast mode operation, a capacitor for sensitivity, and a resistor for EMC purposes.
The automatic feeder system consists of several key components: a series of capacitive touch buttons, a microcontroller, and a food dispensing mechanism. The capacitive touch buttons are designed to detect the presence of the cat's paw or other objects through changes in capacitance on the copper pads. The AT42QT1010 integrated circuit (IC) serves as the heart of this sensing mechanism, providing a reliable and efficient way to detect button presses without the need for mechanical movement.
The microcontroller processes the inputs from the buttons and controls the food dispenser accordingly. It is programmed to allow for flexible configurations, enabling the user to set rules for how button presses will result in food dispensing. Initially, the system is set to dispense food for any button press, allowing the cat to explore and learn the interaction. As the cat becomes more adept, the microcontroller can be reconfigured to implement more complex rules, such as only dispensing food when a specific button is pressed or requiring a sequence of button presses.
Data collection is a crucial aspect of this system. The microcontroller logs each button press along with timestamps, allowing for analysis of the cat's learning behavior over time. This data can be invaluable for understanding how the cat adapts to the feeding system and can be used to refine the interaction rules further.
The physical design of the buttons is optimized for both durability and ease of use. The capacitive touch buttons eliminate the need for mechanical components that can wear out over time, reducing maintenance requirements. The use of a plexiglass holder not only protects the sensitive electronics from potential damage but also provides a visually appealing interface for the cat.
The circuit schematic for the capacitive touch button system is straightforward, featuring minimal components. The syncUp resistor is critical for enabling fast mode operation, which enhances the responsiveness of the touch detection. The Cs capacitor's value can be adjusted to modify the sensitivity of the touch detection, allowing for customization based on the specific needs of the environment or the cat's behavior. The Rs resistor serves an important role in ensuring electromagnetic compatibility (EMC), thereby minimizing interference with other electronic devices.
Overall, this automatic feeder system represents an innovative approach to pet feeding, integrating technology to enhance the feeding experience for both the pet and the owner. The ability to adapt the interaction rules and collect data on the cat's learning process offers a unique opportunity to understand animal behavior and improve the feeding system over time.An automatic feeder that would dispense food based on the activation of a series of buttons. The buttons, the system controller, and the food dispenser. The buttons and food dispenser interfaced with the system controller to allow for intelligent processing of inputs and outputs. I wanted to be able to dynamically configure how the activation of the buttons affected the dispensing of food without needing to modify any hardware. For instance, while the cat was still learning how to use the system, I wanted the activation of any button to dispense food. As the cat grew more comfortable with the new arrangement I would begin to place additional constraints on how the button activation would lead to the food.
For instance, perhaps only the button with a light on would dispense food, touching any other button would lead to no response. I also wanted to record which buttons were pressed and if it was a correct choice. If the cat was truly learning there should be some sort of learning curve and I wanted to be sure I collected enough data to show such a response.
The intent of this post is to describe the overall system. The data collection process is still on going and once I collect enough data, I hope to post the results. I should mention, that at no time did the cat ever run the risk of not getting food. She always receives twice daily canned, wet food feedings. This dispenser only controlled the access to a secondary supply of dry food. In order for the cat to interact with the system, she needed some sort of interface mechanism. I debated what form this mechanism should take, I thought about using everything from large push-buttons to a touch screen monitor.
I eventually settled on using discrete, capacitive touch buttons. This setup minimized both the mechanical housing necessary to mount the buttons, as well as the associated supporting electronics. A mechanical push button would have required some sort of rigid mounting holder to position the buttons in an easy to use manner.
A touch screen monitor would have required a computer to drive and control the display. The capacitive touch button allowed me to create a single PCB with all the electronics compactly contained on one board. I decided to use three separate buttons, each button containing a dual-color LED for signaling purposes.
I used a relatively inexpensive, rapid manufacturing company, Big Blue Saw to create a simple plexiglass holder to mount the buttons as well as protect the electronics from any curious felines. The setup for the buttons is shown below. The active button portion of the board is the circular region at the bottom. This is a large copper pour below the silkscreen that connects, thru a small trace, to a AT42QT1010 IC.
This is a very simple to use Atmel IC that automatically detects the a capacitance change on the copper pad due to a nearby object. This IC requires only a few bypass capacitors and resistors. The circuit schematic I used is shown below. As you can see, the circuit is not very complicated. The syncUp resistor sets the device into the so-called fast mode which has the fastest speed response but also the highest operating power.
The Cs capacitor sets the sensitivity of the detector and the Rs resistor is used for EMC purposes. In addition to the capacitive touch IC, there is a du
The automatic feeder system consists of several key components: a series of capacitive touch buttons, a microcontroller, and a food dispensing mechanism. The capacitive touch buttons are designed to detect the presence of the cat's paw or other objects through changes in capacitance on the copper pads. The AT42QT1010 integrated circuit (IC) serves as the heart of this sensing mechanism, providing a reliable and efficient way to detect button presses without the need for mechanical movement.
The microcontroller processes the inputs from the buttons and controls the food dispenser accordingly. It is programmed to allow for flexible configurations, enabling the user to set rules for how button presses will result in food dispensing. Initially, the system is set to dispense food for any button press, allowing the cat to explore and learn the interaction. As the cat becomes more adept, the microcontroller can be reconfigured to implement more complex rules, such as only dispensing food when a specific button is pressed or requiring a sequence of button presses.
Data collection is a crucial aspect of this system. The microcontroller logs each button press along with timestamps, allowing for analysis of the cat's learning behavior over time. This data can be invaluable for understanding how the cat adapts to the feeding system and can be used to refine the interaction rules further.
The physical design of the buttons is optimized for both durability and ease of use. The capacitive touch buttons eliminate the need for mechanical components that can wear out over time, reducing maintenance requirements. The use of a plexiglass holder not only protects the sensitive electronics from potential damage but also provides a visually appealing interface for the cat.
The circuit schematic for the capacitive touch button system is straightforward, featuring minimal components. The syncUp resistor is critical for enabling fast mode operation, which enhances the responsiveness of the touch detection. The Cs capacitor's value can be adjusted to modify the sensitivity of the touch detection, allowing for customization based on the specific needs of the environment or the cat's behavior. The Rs resistor serves an important role in ensuring electromagnetic compatibility (EMC), thereby minimizing interference with other electronic devices.
Overall, this automatic feeder system represents an innovative approach to pet feeding, integrating technology to enhance the feeding experience for both the pet and the owner. The ability to adapt the interaction rules and collect data on the cat's learning process offers a unique opportunity to understand animal behavior and improve the feeding system over time.An automatic feeder that would dispense food based on the activation of a series of buttons. The buttons, the system controller, and the food dispenser. The buttons and food dispenser interfaced with the system controller to allow for intelligent processing of inputs and outputs. I wanted to be able to dynamically configure how the activation of the buttons affected the dispensing of food without needing to modify any hardware. For instance, while the cat was still learning how to use the system, I wanted the activation of any button to dispense food. As the cat grew more comfortable with the new arrangement I would begin to place additional constraints on how the button activation would lead to the food.
For instance, perhaps only the button with a light on would dispense food, touching any other button would lead to no response. I also wanted to record which buttons were pressed and if it was a correct choice. If the cat was truly learning there should be some sort of learning curve and I wanted to be sure I collected enough data to show such a response.
The intent of this post is to describe the overall system. The data collection process is still on going and once I collect enough data, I hope to post the results. I should mention, that at no time did the cat ever run the risk of not getting food. She always receives twice daily canned, wet food feedings. This dispenser only controlled the access to a secondary supply of dry food. In order for the cat to interact with the system, she needed some sort of interface mechanism. I debated what form this mechanism should take, I thought about using everything from large push-buttons to a touch screen monitor.
I eventually settled on using discrete, capacitive touch buttons. This setup minimized both the mechanical housing necessary to mount the buttons, as well as the associated supporting electronics. A mechanical push button would have required some sort of rigid mounting holder to position the buttons in an easy to use manner.
A touch screen monitor would have required a computer to drive and control the display. The capacitive touch button allowed me to create a single PCB with all the electronics compactly contained on one board. I decided to use three separate buttons, each button containing a dual-color LED for signaling purposes.
I used a relatively inexpensive, rapid manufacturing company, Big Blue Saw to create a simple plexiglass holder to mount the buttons as well as protect the electronics from any curious felines. The setup for the buttons is shown below. The active button portion of the board is the circular region at the bottom. This is a large copper pour below the silkscreen that connects, thru a small trace, to a AT42QT1010 IC.
This is a very simple to use Atmel IC that automatically detects the a capacitance change on the copper pad due to a nearby object. This IC requires only a few bypass capacitors and resistors. The circuit schematic I used is shown below. As you can see, the circuit is not very complicated. The syncUp resistor sets the device into the so-called fast mode which has the fastest speed response but also the highest operating power.
The Cs capacitor sets the sensitivity of the detector and the Rs resistor is used for EMC purposes. In addition to the capacitive touch IC, there is a du
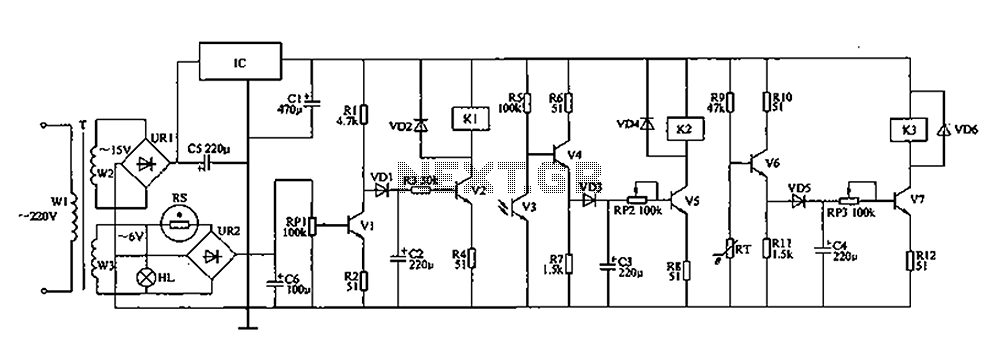
Coop automatic controller circuit diagram
The automatic controller for a chicken coop is designed to automatically regulate light, temperature, and humidity, thereby enhancing egg production and survival rates of chickens. This device is intended for specialized poultry households in rural areas. The circuit operates through...
Objects in Flux
The Open Source Automation project is a free automation software that operates on Windows and does not require programming for setup. It features a user-friendly graphical interface and includes unique functionalities that are not typically found in high-end security and...