


Process-Control
#control system
#measured value
#setpoint
#transducer
#pressure
#temperature
#potentiometer
#user input
#feedback loop
Description: The Measured Value and the Setpoint are two inputs to a control system. The Measured Value is the amplified input from a transducer or sensor that monitors a parameter requiring control, such as pressure or temperature. The Setpoint is the user-defined input, which can be set using a potentiometer, thumbwheel, EPROM, or flash value. This represents the target value that the process should maintain for that parameter. The difference between these two values is termed the Error, which serves as the input for the PID analog computation stage. Three operational amplifiers (op-amps) are configured as proportional, integrator, and differentiator amplifiers. The summation of these values yields the PID control output. Nowadays, this computation is often handled in firmware on microcontrollers (MCUs), digital signal processors (DSPs), or software applications in SCADA systems. The analog PID control output can be converted to a 4-20 mA control signal, corresponding to 0-100% power to the actuator, which may include components such as heaters, pumps, fans, or motors using AC/DC drives. Actuators can also include steam valves or motorized solenoids in pneumatic or hydraulic systems. It is crucial to select the correct actuator size and array for the process; for instance, a small fan is inadequate for cooling a large furnace, and a tiny solenoid valve will not effectively fill a large tank. Effective proportional or PID control relies on careful selection or design of the sensor, actuator, and system environment. Auto-reset functionality is essential to prevent the integrator from excessively damping the process, which could hinder the ability to reach the desired process value promptly. In the proportional band, the integrator is active. For example, if the setpoint is 1000 °C, the proportional band may be set at 10%. The temperature will rise to 950 °C without damping, after which the integrator is activated by a window comparator composed of two op-amps, preventing overshoot, undershoot, ringing, and oscillations. The PID control output can also be a time-proportional output, such as pulse-width modulation (PWM), with extended cycle times of 20 seconds or more, such as 2 seconds on and 18 seconds off for 10% control. Shorter cycle times may be necessary for smaller systems with reduced inertia. Three controls must be adjusted for optimal performance of a proportional flow controller: 1. Set Point (SP) - the desired flow rate for the fluid; 2. Process Value (PV) - the actual flow rate measured by the flow sensor in the system.
The design of a sequential timer using the ICM7217 from Intersil was attempted; although it functioned well, it did not progress beyond the prototype stage. Product development typically clarifies and streamlines documentation and designs. The PCB and circuit remain incomplete but may provide valuable insights. During that period, the ICM7217 was among the few large CMOS devices available, while 8080, 8085, and Z80 devices were power-intensive and required substantial boards and power supplies.
Additionally, a 4-20 mA input/output analog multiplexer (MUX) with cascade options was designed as part of an automation system within a budget. This circuit takes a 4-20 mA signal from multiple transmitters and outputs a single 4-20 mA signal. The MUX is implemented using a digital byte or word, functioning as a slow scanner suitable for processes that operate at a slower pace. In near real-time systems, a faster multiplexer could be utilized, or multiplexing could be entirely avoided. This design was produced in quantity, resulting in a completed PCB.
Furthermore, the circuit addresses errors indicated in the previous current source design. The LM336-2.5V component eliminates minor errors from the regulated supply and resistors, thereby enhancing precision. An operational amplifier mirrors the stable 2.5V across a potentiometer (P3) and resistor (R13), with P3 being a Bourns 10-turn trimpot, allowing for fine adjustments to achieve the desired output voltage with increased accuracy.The Measured Value and The Setpoint are two inputs to a Control System. The Measured Value is the Amplified input of a Transducer or Sensor for some Parameter that needs to be controlled. It could be Pressure or Temperature etc. The Setpoint is the User Defined Input using a Potentiometer, Thumbwheel, EPROM or Flash Value. This is the value at w hich the process has to be maintained for that parameter. The difference of these two is the Error, this is the input for this PID Analog Computation Stage. The three Opamps are configured as Proportional, Integrator and Differentiator Amps. The Addition or Summation of these Values is the PID Control Output. (These days it is Math in the Firmware on a MCU, DSP or Software Application in SCADA) This Analog PID Control Output can now be translated to a 4-20 mA Control Signal, that means 0-100% of power to the Actuator, which could be a Heater, Pump, Fan, Motor using AC/DC Drives. It could be a Steam Valve, Pneumatic or Hydraulic Motorized/Solenoids. The Actuator Size/Array must be right for the Process, a tiny fan cannot cool a Large Furnace, a small solenoid valve cannot fill a Big Tank.
An effective Proportional or PID control depends on choosing or designing the Sensor, Actuator and System Environment prudently. The Auto Reset is needed to ensure the Integrator does not dampen the Process so much that it fails to even raise to the Process value fast enough (Diffrentiator).
So in the Proportional Band the Integrator is Active. If the Setpoint is 1000 deg C, the proportional band is 10%. The Raise of temperature till 950 deg is Undampended. After that Integrator is called in by the Window Comparator made of two opamps, the integrator prevents OverShoot, Undershoot, Ringing and Oscillations. The PID control output can also be a Time Proportional Output like PWM. With a large cycle time of 20 or More seconds. Like 2 Seconds on and 18 Seconds off for 10% Control. Fast Cycle times may be needed for small systems with less inertia. There are three Controls to be Adjusted to make a Proportional Flow Controller Perform Properly. This method has to be practiced and experience gained from it can be used to get very good and stable Control of the Flow or Velocity of a Fluid.
1. Set Point. (SP) This is the Flow Rate at which you require the Fluid to be controlled at. Adjust the rate at which the fluid flow is expected to be controlled. 2. Process Value. (PV) This is the Actual Flow Rate of the fluid in the flow sensor or its path. It is very Read More This was a attempt to make a Sequential Timer with ICM7217 of Intersil, even though it worked well, it was not developed beyond the prototype stage or first iteration. Only when a product is made in some numbers, the documentation and designs become clear, streamlined and seasoned.
The PCB and Circuit are not complete. It may give ideas. During this time, as far as i can remember, these were the only large CMOS devices. 8080-85 and Z80 devices consumed lot of power and needed big boards and supplies. ICM7217 4-Digit, Presettable, LED Up/Down Counter Maxim Study this, if you are Read More Here is a 4-20 mA In/Out Analog Mux with Cascade option. This is a simple circuit i designed to make a Automation System within a budget. This takes 4-20mA from many Transmitters and gives out just one 4-20 mA output. The Mux is done with a digital byte or word. This is a slow scanner as process is slow, that way many analog inputs can be multiplexed and sent into one analog input of a D/A.
In near real time systems a faster mux could be used or mux totally avoided. This was made in some numbers, so the pcb Read More In this circuit we tackle the error indicated in the earlier Current Source. The LM336-2. 5V eliminates the tiny error of the regulated supply and resistors. Thereby increasing Precision to a higher degree. The opamp mirrors the stable 2. 5V across P3 + R13. With P3 Bourns 10 Turn Trimpot
The design of a sequential timer using the ICM7217 from Intersil was attempted; although it functioned well, it did not progress beyond the prototype stage. Product development typically clarifies and streamlines documentation and designs. The PCB and circuit remain incomplete but may provide valuable insights. During that period, the ICM7217 was among the few large CMOS devices available, while 8080, 8085, and Z80 devices were power-intensive and required substantial boards and power supplies.
Additionally, a 4-20 mA input/output analog multiplexer (MUX) with cascade options was designed as part of an automation system within a budget. This circuit takes a 4-20 mA signal from multiple transmitters and outputs a single 4-20 mA signal. The MUX is implemented using a digital byte or word, functioning as a slow scanner suitable for processes that operate at a slower pace. In near real-time systems, a faster multiplexer could be utilized, or multiplexing could be entirely avoided. This design was produced in quantity, resulting in a completed PCB.
Furthermore, the circuit addresses errors indicated in the previous current source design. The LM336-2.5V component eliminates minor errors from the regulated supply and resistors, thereby enhancing precision. An operational amplifier mirrors the stable 2.5V across a potentiometer (P3) and resistor (R13), with P3 being a Bourns 10-turn trimpot, allowing for fine adjustments to achieve the desired output voltage with increased accuracy.The Measured Value and The Setpoint are two inputs to a Control System. The Measured Value is the Amplified input of a Transducer or Sensor for some Parameter that needs to be controlled. It could be Pressure or Temperature etc. The Setpoint is the User Defined Input using a Potentiometer, Thumbwheel, EPROM or Flash Value. This is the value at w hich the process has to be maintained for that parameter. The difference of these two is the Error, this is the input for this PID Analog Computation Stage. The three Opamps are configured as Proportional, Integrator and Differentiator Amps. The Addition or Summation of these Values is the PID Control Output. (These days it is Math in the Firmware on a MCU, DSP or Software Application in SCADA) This Analog PID Control Output can now be translated to a 4-20 mA Control Signal, that means 0-100% of power to the Actuator, which could be a Heater, Pump, Fan, Motor using AC/DC Drives. It could be a Steam Valve, Pneumatic or Hydraulic Motorized/Solenoids. The Actuator Size/Array must be right for the Process, a tiny fan cannot cool a Large Furnace, a small solenoid valve cannot fill a Big Tank.
An effective Proportional or PID control depends on choosing or designing the Sensor, Actuator and System Environment prudently. The Auto Reset is needed to ensure the Integrator does not dampen the Process so much that it fails to even raise to the Process value fast enough (Diffrentiator).
So in the Proportional Band the Integrator is Active. If the Setpoint is 1000 deg C, the proportional band is 10%. The Raise of temperature till 950 deg is Undampended. After that Integrator is called in by the Window Comparator made of two opamps, the integrator prevents OverShoot, Undershoot, Ringing and Oscillations. The PID control output can also be a Time Proportional Output like PWM. With a large cycle time of 20 or More seconds. Like 2 Seconds on and 18 Seconds off for 10% Control. Fast Cycle times may be needed for small systems with less inertia. There are three Controls to be Adjusted to make a Proportional Flow Controller Perform Properly. This method has to be practiced and experience gained from it can be used to get very good and stable Control of the Flow or Velocity of a Fluid.
1. Set Point. (SP) This is the Flow Rate at which you require the Fluid to be controlled at. Adjust the rate at which the fluid flow is expected to be controlled. 2. Process Value. (PV) This is the Actual Flow Rate of the fluid in the flow sensor or its path. It is very Read More This was a attempt to make a Sequential Timer with ICM7217 of Intersil, even though it worked well, it was not developed beyond the prototype stage or first iteration. Only when a product is made in some numbers, the documentation and designs become clear, streamlined and seasoned.
The PCB and Circuit are not complete. It may give ideas. During this time, as far as i can remember, these were the only large CMOS devices. 8080-85 and Z80 devices consumed lot of power and needed big boards and supplies. ICM7217 4-Digit, Presettable, LED Up/Down Counter Maxim Study this, if you are Read More Here is a 4-20 mA In/Out Analog Mux with Cascade option. This is a simple circuit i designed to make a Automation System within a budget. This takes 4-20mA from many Transmitters and gives out just one 4-20 mA output. The Mux is done with a digital byte or word. This is a slow scanner as process is slow, that way many analog inputs can be multiplexed and sent into one analog input of a D/A.
In near real time systems a faster mux could be used or mux totally avoided. This was made in some numbers, so the pcb Read More In this circuit we tackle the error indicated in the earlier Current Source. The LM336-2. 5V eliminates the tiny error of the regulated supply and resistors. Thereby increasing Precision to a higher degree. The opamp mirrors the stable 2. 5V across P3 + R13. With P3 Bourns 10 Turn Trimpot
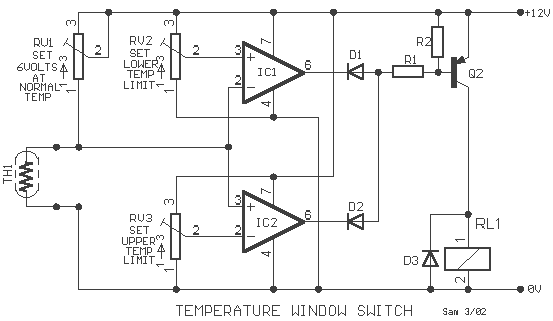
Temperature limit Relay
This circuit is basically a resistance sensing window switch, except that the resistor takes the form of an NTC thermistor and the circuit thus responds to temperature. TH1 must have a resistance in the range 500 ohm - 9 K...
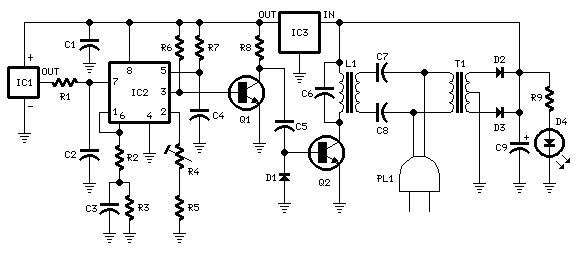
Remote Thermometer circuit
This circuit is intended for precision centigrade temperature measurement, with a transmitter section converting to frequency the sensor's output voltage, which is proportional to the measured temperature. The output frequency bursts are conveyed into the mains supply cables. The receiver...
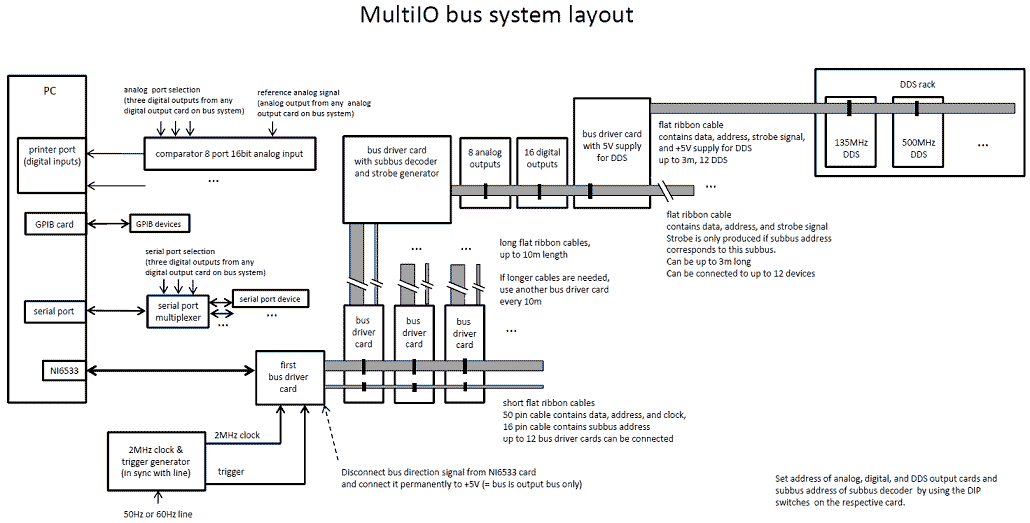
Control System for Cold Atom Experiments
We have developed a powerful yet inexpensive and easy to construct experiment control system. The construction of the system together with the control software is described here. All circuits and software are free to download and use for nonprofit. The...
Temperature Relay Circuit
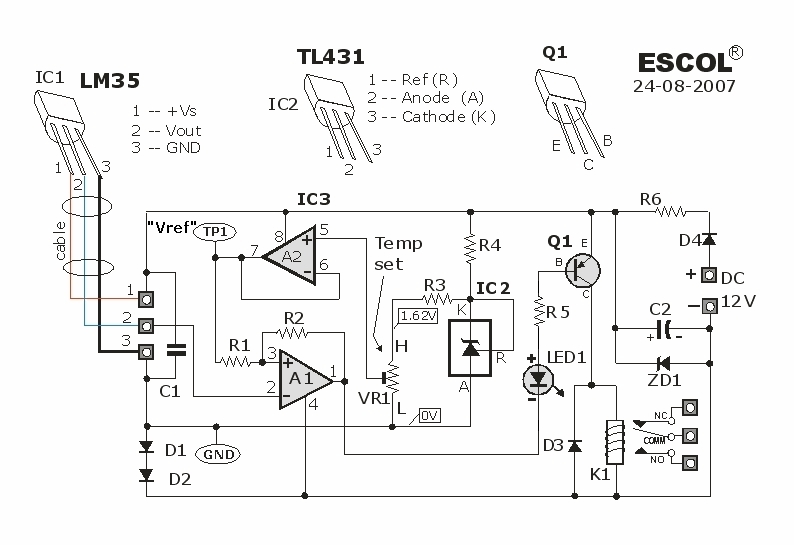
This simple temperature relay circuit can be used to signal a fire or setpoint for temperature monitoring function. You need to adjust P1 so that T1's base.
The temperature relay circuit operates by monitoring the temperature in a designated area and...
potentiometer Making an adjustable resistance
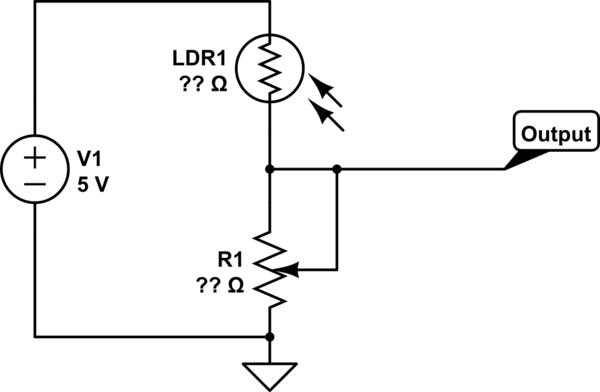
This part of the circuit is isolated from any other component, except for the 5V and ground connections. It includes LEDs and a shift register, which may not interact significantly. The LDR (Light Dependent Resistor) is utilized solely as a...
Differential-thermometer
The differential thermometer utilizes two probes to display the temperature difference between them instead of indicating the precise temperature. It employs a conventional meter as an indicator and has a total range of -10°C to 20°C.
The differential thermometer operates on...
Over-Temperature Switch
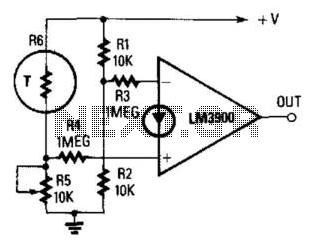
The output becomes high when a predetermined temperature is surpassed. A fixed half-supply reference voltage provides a reference current to the inverting input, while a variable current is supplied to the non-inverting input. Resistor R6 functions as a negative-temperature-coefficient (NTC)...
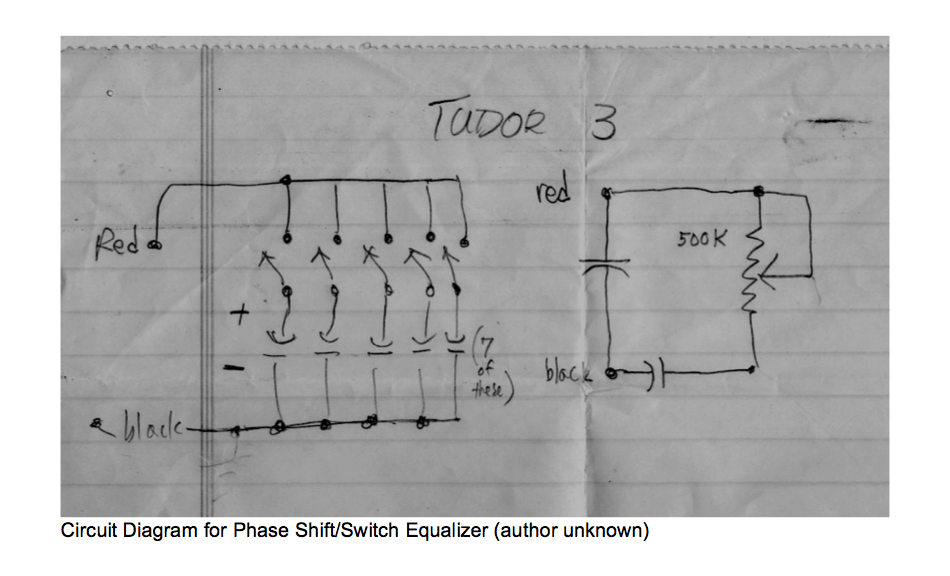
music circuit
This circuit allows for the adjustment of resistance using a potentiometer and the adjustment of capacitance by opening or closing switches. By manipulating the configuration of these switches, various combinations can be achieved to obtain different effective capacitance values. It...
Remote Thermometer circuit
This circuit is intended for precision centigrade temperature measurement, with a transmitter section converting to frequency the sensor's output voltage, which is proportional to the measured temperature. The output frequency bursts are conveyed into the mains supply cables. The receiver...