


Single IC chip Motor Driver for robots
#motor driver
#robotics
#IC chip
#current supply
#walker robots
#motor control
#DIY electronics
#hobby projects
#power management
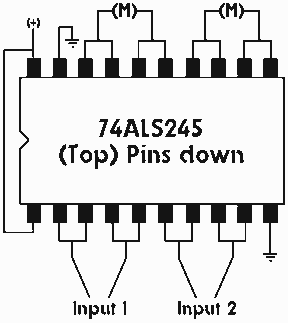
Description: A motor driver is required in pretty much all walkers including all of my CW series walkers. You need to use it any time you need to supply more current to the motors because the circuit can't supply enough. This one is very easy to build and pretty flexible on what you can do with it. Just find the (M) and take the two connections going to it and hook them to the inputs of the driver. Each driver supplies 50mA and since they are already doubled up you have 100mA which in most cases is not enough. The answer, stack 'em. You can see in the image on the right that all you have to do is stick another ALS245 on top and solder it on. You can stack as many as you need but you shouldn't need more than 3 and 2 should be plenty.
A motor driver is an essential component in robotic applications, particularly in mobile robots such as walkers. The primary function of a motor driver is to control the power supplied to the motors, enabling precise movement and control. In this context, the motor driver allows for the amplification of current, which is crucial when the existing circuit cannot provide sufficient power to drive the motors effectively.
The described motor driver circuit utilizes the ALS245 integrated circuit, which is a dual-channel, high-speed, bidirectional level shifter and buffer. Each ALS245 can supply a maximum output current of 50mA, which may be inadequate for applications requiring higher power. Therefore, to achieve the necessary current levels for driving motors, multiple ALS245 units can be stacked together. By stacking two ALS245 chips, the total output current is effectively increased to 100mA. However, for most applications, this may still fall short of the required power, necessitating the stacking of additional drivers. It is generally recommended not to exceed three stacked units, as this provides a balance between power requirements and circuit complexity.
In practical implementation, the motor driver connections are straightforward. The user is instructed to identify the motor connections, denoted as (M), and connect them to the input terminals of the motor driver. This configuration allows for direct control of the motor's operation through the driver, thus facilitating enhanced performance.
When designing a circuit with this motor driver, it is crucial to ensure that the power supply can accommodate the total current drawn by the stacked drivers and the motors. Additionally, proper thermal management should be considered, as increased current can lead to heating in the drivers, which may affect performance and reliability. Overall, this motor driver setup provides a flexible and effective solution for driving motors in robotic applications, particularly when higher current levels are required.A motor driver! I'm sure you knew that already but that's what it is. A motor driver is required in pretty much all walkers including all of my CW series walkers. You need to use it any time you need to supply more current to the motors because the circuit can't supply enough. I like this one because it's very easy to build and pretty flexible on what you can do with it. Just find the (M) and take the two connections going to it and hook them to the inputs of the driver.
Stack 'em up Q - When I hook my motor directly to the battery it has lots of power but when I hook it to the motor driver it doesn't and can't even move my walkers leg. A - Each driver supplies 50mA and since they are already doubled up you have 100mA which in most cases is not enough. The answer, stack 'em. You can see in the image on the right that all you have to do is stick another ALS245 on top and solder it on.
It's that easy. You can stack as many as you need but you shouldn't need more than 3 and 2 should be plenty.
A motor driver is an essential component in robotic applications, particularly in mobile robots such as walkers. The primary function of a motor driver is to control the power supplied to the motors, enabling precise movement and control. In this context, the motor driver allows for the amplification of current, which is crucial when the existing circuit cannot provide sufficient power to drive the motors effectively.
The described motor driver circuit utilizes the ALS245 integrated circuit, which is a dual-channel, high-speed, bidirectional level shifter and buffer. Each ALS245 can supply a maximum output current of 50mA, which may be inadequate for applications requiring higher power. Therefore, to achieve the necessary current levels for driving motors, multiple ALS245 units can be stacked together. By stacking two ALS245 chips, the total output current is effectively increased to 100mA. However, for most applications, this may still fall short of the required power, necessitating the stacking of additional drivers. It is generally recommended not to exceed three stacked units, as this provides a balance between power requirements and circuit complexity.
In practical implementation, the motor driver connections are straightforward. The user is instructed to identify the motor connections, denoted as (M), and connect them to the input terminals of the motor driver. This configuration allows for direct control of the motor's operation through the driver, thus facilitating enhanced performance.
When designing a circuit with this motor driver, it is crucial to ensure that the power supply can accommodate the total current drawn by the stacked drivers and the motors. Additionally, proper thermal management should be considered, as increased current can lead to heating in the drivers, which may affect performance and reliability. Overall, this motor driver setup provides a flexible and effective solution for driving motors in robotic applications, particularly when higher current levels are required.A motor driver! I'm sure you knew that already but that's what it is. A motor driver is required in pretty much all walkers including all of my CW series walkers. You need to use it any time you need to supply more current to the motors because the circuit can't supply enough. I like this one because it's very easy to build and pretty flexible on what you can do with it. Just find the (M) and take the two connections going to it and hook them to the inputs of the driver.
Stack 'em up Q - When I hook my motor directly to the battery it has lots of power but when I hook it to the motor driver it doesn't and can't even move my walkers leg. A - Each driver supplies 50mA and since they are already doubled up you have 100mA which in most cases is not enough. The answer, stack 'em. You can see in the image on the right that all you have to do is stick another ALS245 on top and solder it on.
It's that easy. You can stack as many as you need but you shouldn't need more than 3 and 2 should be plenty.
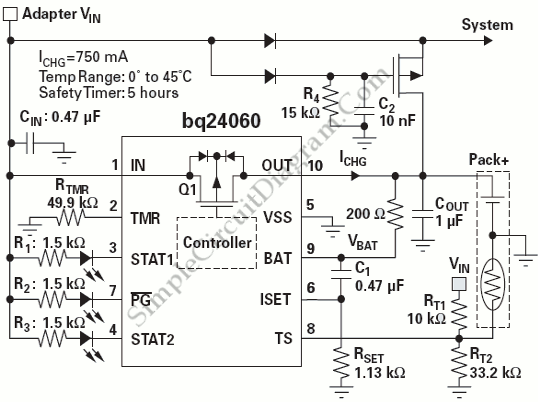
Power Path Management Battery Charger
Powering the system is required by many applications while charging the battery simultaneously. Interaction between the system and charger may result in a...
Power management in electronic systems is critical, particularly in applications that necessitate simultaneous operation and battery charging. This...
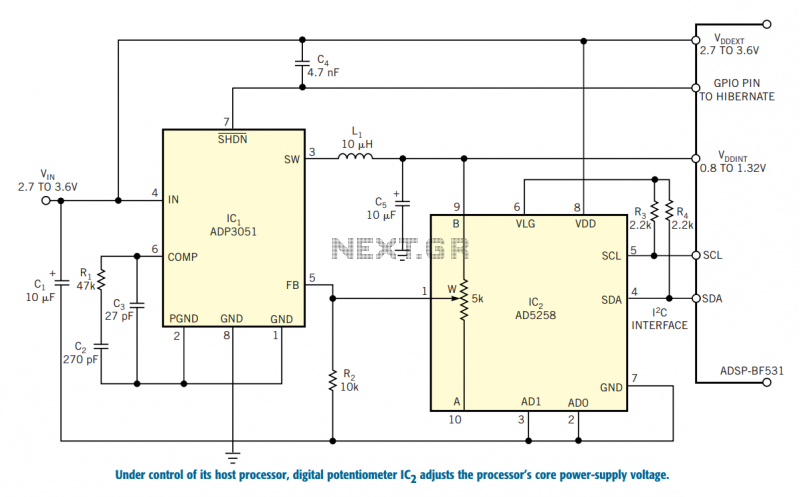
Control a processor`s power supply in real time
In battery-powered applications in which power management is key, a microprocessor may adjust its core voltage corresponding to an increase or a decrease in clock speed, allowing full processing power when necessary but not wasting excess power when idle. The...
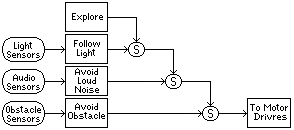
Subsumption Architecture
This term refers to a robotic control concept developed by Rodney Brooks, closely associated with behavior-based robotics, which incorporates modular behavior-based artificial intelligence. Unlike traditional artificial intelligence that relies on a centralized, top-down planning, execution, and monitoring structure, subsumption architecture...
motor timer
The primary concept is to rotate the motor slightly every 15 seconds. A monofilament line conveys the motion to the ornament, which is wound by the motor and gradually unwinds as the ornament turns. The charging circuit includes a 1...
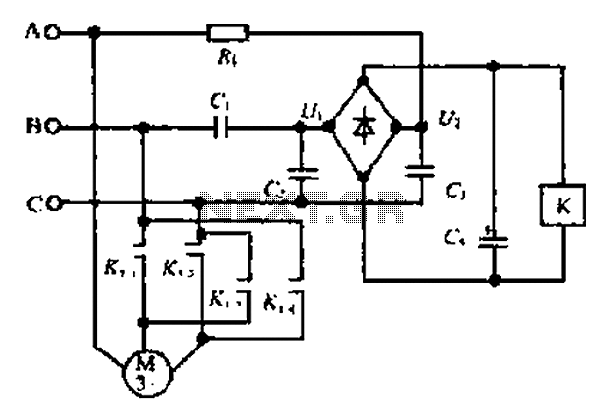
A motor reversing automatic adjustment circuit
Composition ratio circuit. The circuit consists of resistors and capacitors that form a shift register circuit with diodes VD1 to VD4, creating a bridge for electric current. Capacitor C4 is utilized for filtering applications and for eliminating instantaneous relay energization...
Power Path Management Battery Charger
Powering the system is required by many applications while charging the battery simultaneously. Interaction between the system and charger may result in a...
Power management in electronic systems is critical, particularly in applications that necessitate simultaneous operation and battery charging. This...
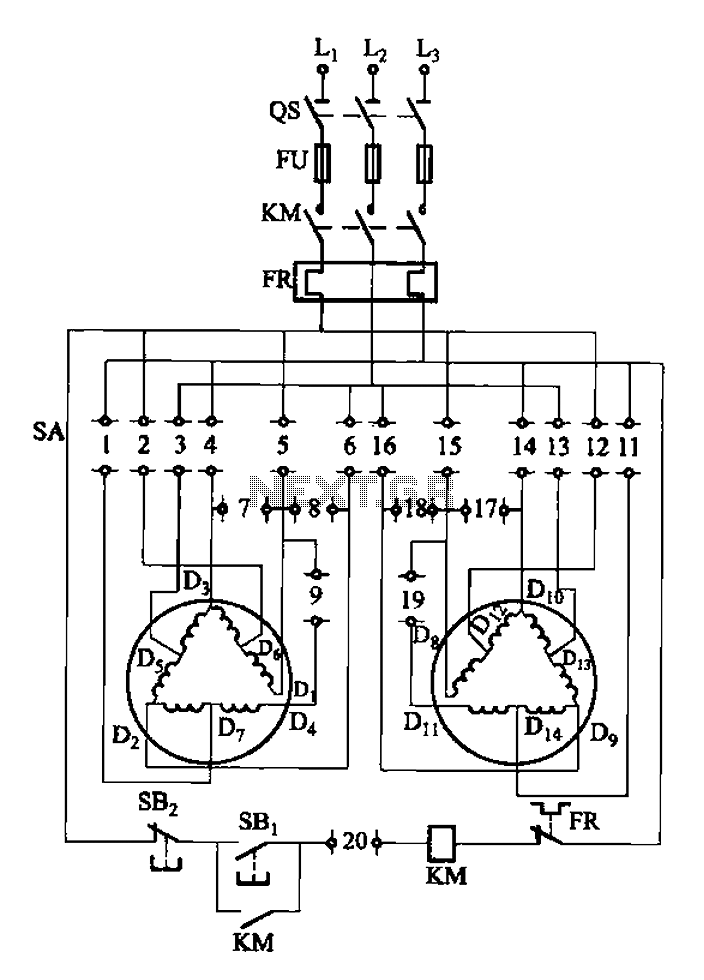
2Y-Y-2 - connection four-speed motor switch control circuit
The 3-119 circuit shown in the figure combines switch SA to realize the stator windings, specifically the 2, Y, and 2Y connections, which correspond to the motor speed n1.
The 3-119 circuit is designed to facilitate the control of motor speed...
Gray Projects
After learning to operate the device, it became evident that inertia posed a significant challenge. The constructed system is notably heavy, making it difficult to initiate motor operation at full speed. Despite having some understanding of physics, practical experience is...
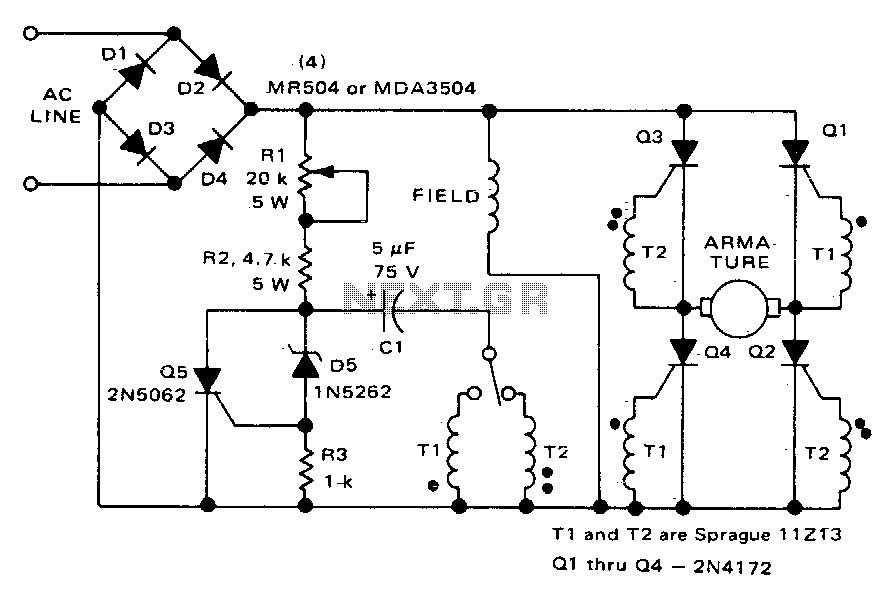
Direction and speed control
This circuit functions similarly to the one depicted in Fig. 57-4. The key differences include the placement of the field across the rectified supply and the armature being positioned within the SCR bridge. Therefore, the field current is unidirectional while...