


Custom Motor Driver
#motor driver
#motor control
#ESC
#robotics
#5-amp
#speed control
#applied robotics
#h-bridge
#PWM
#power electronics
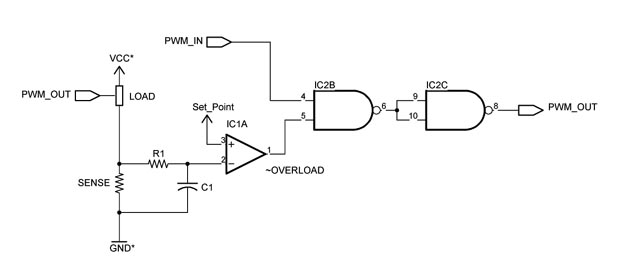
Description: This chapter was removed from Applied Robotics 2 due to space constraints. It addresses general motor control issues and details the construction of a 5-amp motor driver. The principles discussed can be applied to larger motor controllers. Although commercially available Electronic Speed Control (ESC) systems may be more cost-effective and convenient, a custom-built ESC offers theoretical advantages in terms of control over specifications. Customization can include power ratings, PWM frequency, braking and regeneration features, acceleration curves, and other nuanced parameters. Many microcontrollers can generate PWM signals using hardware timers, while R/C control signals typically require software generation, consuming valuable microcontroller cycles.
In motor control, two variables exist in the state space: the actual motion of the motor and the direction of the applied torque. When the motor is stationary or moving forward with forward torque, the control is classified as Quadrant 1 (Q1), indicating forward acceleration. A motor controller supporting only Q1 may consist of a single switch (transistor, IGBT, or MOSFET) and a clamp diode for protection. Conversely, when the motor is at rest or moving in reverse with reverse torque, it operates in Quadrant 3 (Q3), indicating reverse acceleration. A basic two-quadrant motor controller operates in Q1 and Q3 and typically utilizes four switches arranged in an H-Bridge configuration, which will be discussed in more detail later.
When the motor moves forward with reverse torque, it enters Quadrant 2 (Q2), indicating reverse braking, while reverse motion with forward torque corresponds to Quadrant 4 (Q4), indicating forward braking. Controllers that facilitate active braking in Q2 and Q4 must manage significantly higher current loads due to the opposing back EMF from the motor. While small motors can be driven directly from digital buffers, operational amplifiers, or transistors, larger motors are more efficiently driven using IGBT (Insulated Gate Bipolar Transistor) or MOSFET (Metal Oxide Semiconductor Field Effect Transistor) technologies. Prior to the introduction of MOSFETs in the 1970s, bipolar transistors were the primary choice for power applications. However, bipolar transistors necessitate a relatively large base current compared to the switched current, exhibit slower turn-off times, and are susceptible to thermal runaway due to their negative temperature coefficient.
MOSFETs, being based on field-effect transistor technology, are voltage-controlled rather than current-controlled and exhibit capacitive behavior towards their controlling circuit. They feature faster turn-off times, lower on-resistance, and a positive temperature coefficient, which mitigates thermal runaway and simplifies parallel wiring. In contrast, IGBTs possess characteristics similar to bipolar transistors. Due to their negative thermal coefficient, IGBTs are more challenging to connect in parallel compared to MOSFETs, but they can handle higher currents and voltages. While IGBTs are typically favored for applications exceeding 1,000 volts, 5 kW output power, or low-frequency operations, MOSFETs are preferred for high-frequency operations, voltages below 250 volts, or output power below 500 watts. There exists a transitional range where either device may be suitable. Notably, advancements in MOSFET technology continue to expand their capabilities into higher power domains, encroaching on the territory traditionally held by IGBTs.
MOSFETs are available in two configurations: P-Channel and N-Channel. Within these configurations, options include the standard MOSFET with a 10-volt turn-on gate voltage, or "digital" MOSFETs with a 5-volt turn-on voltage. An N-channel MOSFET begins to activate when the gate voltage exceeds the source voltage, allowing current to flow from the positive drain to the source. As the gate-source voltage (VGS) increases, the MOSFET transitions from the off state to the on state, enabling effective control over motor operations.This is a chapter that was cut from Applied Robotics 2 because of space issues. It discusses motor control issues in general and then moves on to build a 5-amp motor driver. The principles involved can be applied to much larger motor controllers. Though it is probably cheaper and easier to use the readily available Electronic Speed Control (ESC) s ystems on the market, a home-built ESC gives us (in theory) more control over the specifications. We can control the power rating (within reason), the PWM frequency, braking and regeneration features, acceleration curves, and other fine details. Also, many microcontrollers provide a nice PWM signal generated by hardware timers while the R/C control signal typically has to be created in software, using precious MCU cycles.
There are two variables in the motor control state space - the actual motion of the motor, and the direction of the applied torque (from power applied to the motor). When the motor is stopped or moving forward and the power across the motor is in the forward direction (forward torque), then the control is said to be in Quadrant 1 (Q1), forward acceleration.
A motor controller that only supports Q1 may consist of a single switch (transistor, IGBT, or MOSFET) and a clamp diode to protect it. When the motor is stopped or moving in reverse and the torque is in reverse, it is being driven in Quadrant 3 (Q3), reverse acceleration.
A simple two-quadrant motor controller will operate in Q1 and Q3 and will consist of four switches in an H-Bridge configuration. This will be explored in more detail later. The motor moving forward with a reverse applied torque puts the control into Quadrant 2, reverse braking.
Reverse motor motion with forward torque is Quadrant 4, forward braking. Motor controllers that support the active braking of Q2 and Q4 need to handle much higher current loads since they are fighting the back EMF of the motor. Although you can drive small motors directly from digital buffers, op-amps, or transistors, larger motors are more efficiently driven by IGBT (Insulated Gate Bipolar Transistor) or MOSFET (Metal Oxide Semiconductor, Field Effect Transistor) technology.
Until the MOSFET reached the market in the `1970s, the bipolar transistor was the only real choice for power applications. Unfortunately, the transistor requires a relatively large base current (relative to the switched current), has a fairly slow turn-off time, and is prone to thermal runaway (due to its negative temperature coefficient).
MOSFETs are based on the field-effect transistor. They are voltage controlled instead of current controlled and look like a capacitor to their controlling circuit. MOSFETs have a faster turn-off time, low on-resistance, and a positive temperature coefficient eliminating thermal runaway (and making them easier to wire in parallel).
The IGBT has most of the characteristics of the bipolar transistor. With their negative thermal coefficient IGBTs are harder to wire in parallel than MOSFETs, but they are capable of handling larger currents and voltages than MOSFETs. Though IGBTs and MOSFETs are very similar in operation, IGBTs are the preferred choice for use above 1, 000 volts, above 5kW output power, or for low-frequency operation.
MOSFETs are generally preferred for high-frequency operation, voltages below 250 volts, or output power below 500 watts. Then there is the grey area where either device may work. Of course, MOSFETs continue to improve as a technology, reaching into the higher power areas and infringing into more IGBT territory.
MOSFETs come in two flavors: P-Channel and N-Channel. Within these flavors you can select the G¬standardG® MOSFET with a 10-volt turn-on gate voltage, or the "digital" MOSFETs with a 5-volt on voltage. An N-channel MOSFET begins to turn on when the gate voltage is raised above the source voltage (with current flow from positive drain to source).
As this voltage, VGS, appr
In motor control, two variables exist in the state space: the actual motion of the motor and the direction of the applied torque. When the motor is stationary or moving forward with forward torque, the control is classified as Quadrant 1 (Q1), indicating forward acceleration. A motor controller supporting only Q1 may consist of a single switch (transistor, IGBT, or MOSFET) and a clamp diode for protection. Conversely, when the motor is at rest or moving in reverse with reverse torque, it operates in Quadrant 3 (Q3), indicating reverse acceleration. A basic two-quadrant motor controller operates in Q1 and Q3 and typically utilizes four switches arranged in an H-Bridge configuration, which will be discussed in more detail later.
When the motor moves forward with reverse torque, it enters Quadrant 2 (Q2), indicating reverse braking, while reverse motion with forward torque corresponds to Quadrant 4 (Q4), indicating forward braking. Controllers that facilitate active braking in Q2 and Q4 must manage significantly higher current loads due to the opposing back EMF from the motor. While small motors can be driven directly from digital buffers, operational amplifiers, or transistors, larger motors are more efficiently driven using IGBT (Insulated Gate Bipolar Transistor) or MOSFET (Metal Oxide Semiconductor Field Effect Transistor) technologies. Prior to the introduction of MOSFETs in the 1970s, bipolar transistors were the primary choice for power applications. However, bipolar transistors necessitate a relatively large base current compared to the switched current, exhibit slower turn-off times, and are susceptible to thermal runaway due to their negative temperature coefficient.
MOSFETs, being based on field-effect transistor technology, are voltage-controlled rather than current-controlled and exhibit capacitive behavior towards their controlling circuit. They feature faster turn-off times, lower on-resistance, and a positive temperature coefficient, which mitigates thermal runaway and simplifies parallel wiring. In contrast, IGBTs possess characteristics similar to bipolar transistors. Due to their negative thermal coefficient, IGBTs are more challenging to connect in parallel compared to MOSFETs, but they can handle higher currents and voltages. While IGBTs are typically favored for applications exceeding 1,000 volts, 5 kW output power, or low-frequency operations, MOSFETs are preferred for high-frequency operations, voltages below 250 volts, or output power below 500 watts. There exists a transitional range where either device may be suitable. Notably, advancements in MOSFET technology continue to expand their capabilities into higher power domains, encroaching on the territory traditionally held by IGBTs.
MOSFETs are available in two configurations: P-Channel and N-Channel. Within these configurations, options include the standard MOSFET with a 10-volt turn-on gate voltage, or "digital" MOSFETs with a 5-volt turn-on voltage. An N-channel MOSFET begins to activate when the gate voltage exceeds the source voltage, allowing current to flow from the positive drain to the source. As the gate-source voltage (VGS) increases, the MOSFET transitions from the off state to the on state, enabling effective control over motor operations.This is a chapter that was cut from Applied Robotics 2 because of space issues. It discusses motor control issues in general and then moves on to build a 5-amp motor driver. The principles involved can be applied to much larger motor controllers. Though it is probably cheaper and easier to use the readily available Electronic Speed Control (ESC) s ystems on the market, a home-built ESC gives us (in theory) more control over the specifications. We can control the power rating (within reason), the PWM frequency, braking and regeneration features, acceleration curves, and other fine details. Also, many microcontrollers provide a nice PWM signal generated by hardware timers while the R/C control signal typically has to be created in software, using precious MCU cycles.
There are two variables in the motor control state space - the actual motion of the motor, and the direction of the applied torque (from power applied to the motor). When the motor is stopped or moving forward and the power across the motor is in the forward direction (forward torque), then the control is said to be in Quadrant 1 (Q1), forward acceleration.
A motor controller that only supports Q1 may consist of a single switch (transistor, IGBT, or MOSFET) and a clamp diode to protect it. When the motor is stopped or moving in reverse and the torque is in reverse, it is being driven in Quadrant 3 (Q3), reverse acceleration.
A simple two-quadrant motor controller will operate in Q1 and Q3 and will consist of four switches in an H-Bridge configuration. This will be explored in more detail later. The motor moving forward with a reverse applied torque puts the control into Quadrant 2, reverse braking.
Reverse motor motion with forward torque is Quadrant 4, forward braking. Motor controllers that support the active braking of Q2 and Q4 need to handle much higher current loads since they are fighting the back EMF of the motor. Although you can drive small motors directly from digital buffers, op-amps, or transistors, larger motors are more efficiently driven by IGBT (Insulated Gate Bipolar Transistor) or MOSFET (Metal Oxide Semiconductor, Field Effect Transistor) technology.
Until the MOSFET reached the market in the `1970s, the bipolar transistor was the only real choice for power applications. Unfortunately, the transistor requires a relatively large base current (relative to the switched current), has a fairly slow turn-off time, and is prone to thermal runaway (due to its negative temperature coefficient).
MOSFETs are based on the field-effect transistor. They are voltage controlled instead of current controlled and look like a capacitor to their controlling circuit. MOSFETs have a faster turn-off time, low on-resistance, and a positive temperature coefficient eliminating thermal runaway (and making them easier to wire in parallel).
The IGBT has most of the characteristics of the bipolar transistor. With their negative thermal coefficient IGBTs are harder to wire in parallel than MOSFETs, but they are capable of handling larger currents and voltages than MOSFETs. Though IGBTs and MOSFETs are very similar in operation, IGBTs are the preferred choice for use above 1, 000 volts, above 5kW output power, or for low-frequency operation.
MOSFETs are generally preferred for high-frequency operation, voltages below 250 volts, or output power below 500 watts. Then there is the grey area where either device may work. Of course, MOSFETs continue to improve as a technology, reaching into the higher power areas and infringing into more IGBT territory.
MOSFETs come in two flavors: P-Channel and N-Channel. Within these flavors you can select the G¬standardG® MOSFET with a 10-volt turn-on gate voltage, or the "digital" MOSFETs with a 5-volt on voltage. An N-channel MOSFET begins to turn on when the gate voltage is raised above the source voltage (with current flow from positive drain to source).
As this voltage, VGS, appr
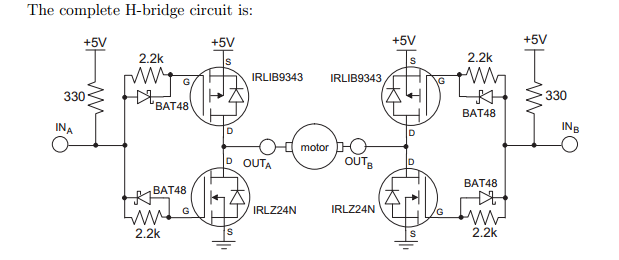
bi directional motor control
In project 2.S994, a custom "H-bridge" motor controller was developed using MOSFETs to manage motor operation. Subsequently, a commercial bi-directional motor controller was tested with the same motor. Images of the setup are available. Additional schematics and details regarding the...
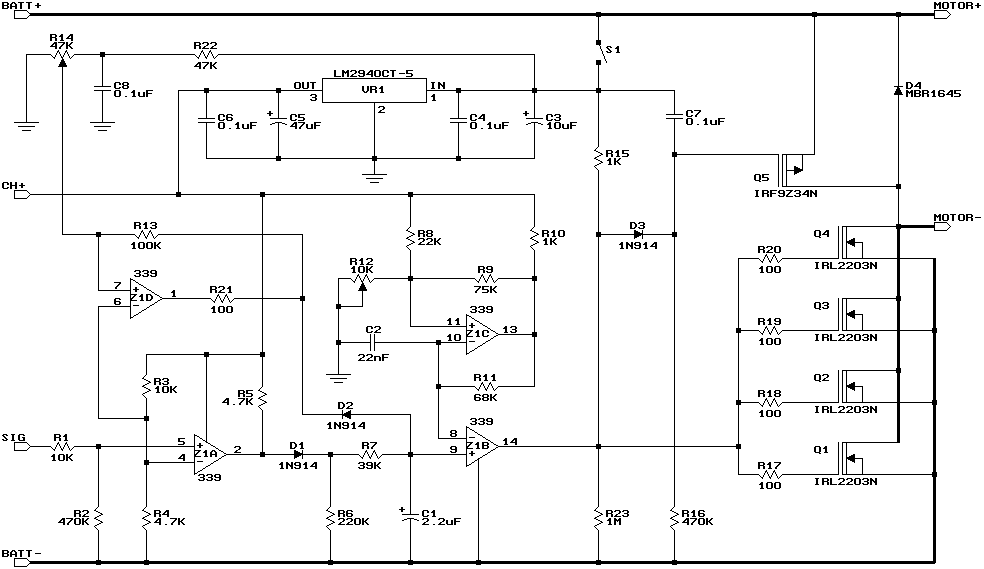
Miniature High-Rate ESC with BEC and Brake
This electronic speed control (ESC) for brushed motors combines the features of two of my earlier designs. One was a high-rate 30A ESC with a brake, and the other a high-rate 12A ESC with a BEC (receiver battery eliminator circuit)....
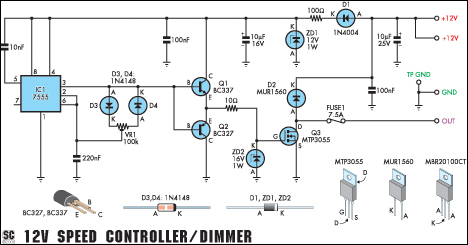
12V Speed Controller/Dimmer
This circuit functions as a speed controller for a 12V motor with a continuous rating of up to 5A or as a dimmer for a 12V halogen or incandescent lamp rated up to 50W. It adjusts the power to the...
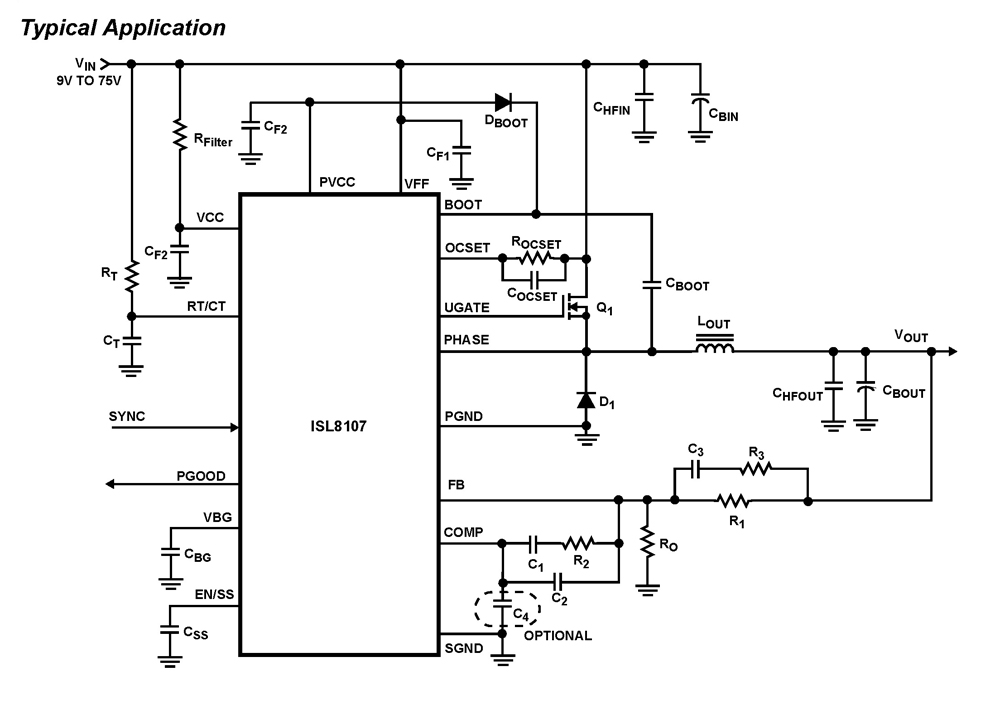
ISL8107 Single-Phase Pulse-Width Modulation (PWM) Controller with Wide (9V-75V) V
The ISL8107 is a single-phase, non-synchronous buck controller equipped with an integrated high-side MOSFET driver. It operates within an input voltage range of 9V to 75V. The internal reference voltage is 1.192V with a tolerance of ±1% across the industrial...
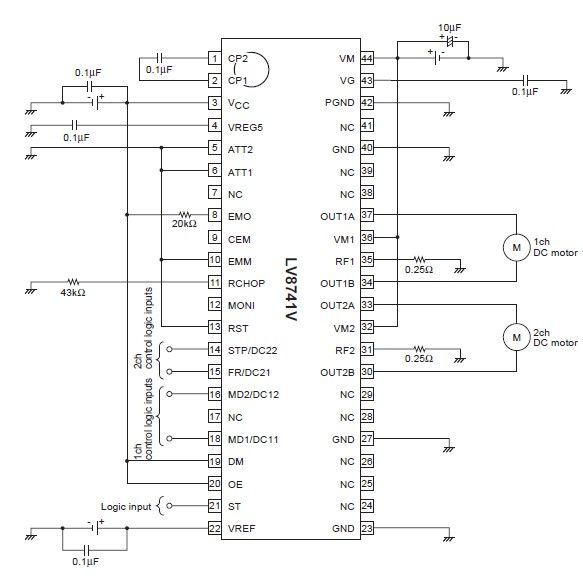
LV8741V PWM stepping motor driver electronic project circuit design
The circuit diagram illustrates an electronic project that requires a few external electronic components. The PWM current-control stepping motor driver IC can provide a maximum output current of up to 1.5 amperes. The configuration settings for the PWM current-control DC...
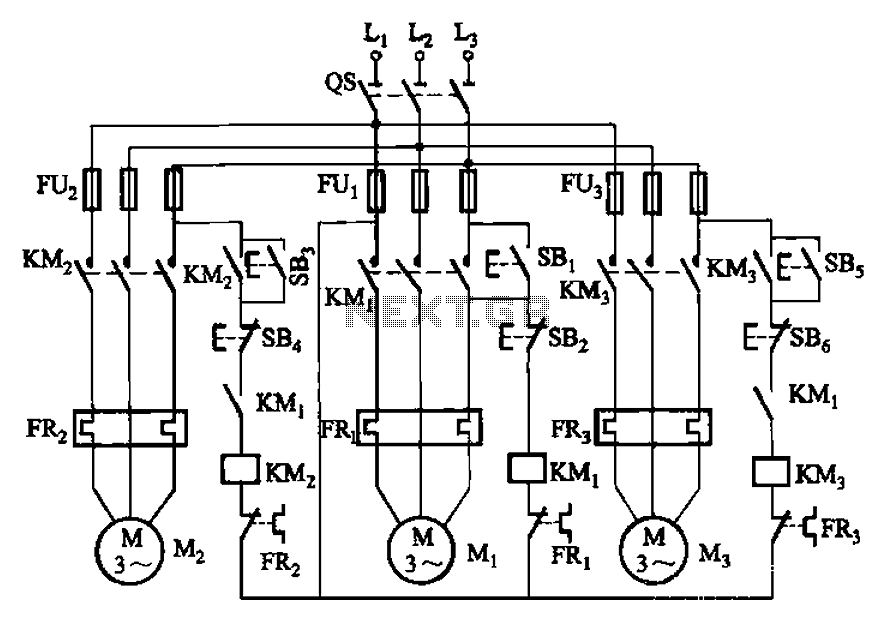
Three motor control circuit start and stop sequence requirements
The circuit shown in Figure 3-89 illustrates a system where starting motor M1 allows motors M2 and M3 to initiate operation. Upon shutdown, motor Mz can be stopped first; however, once motor M1 is stopped (by pressing switch SB2), motors...
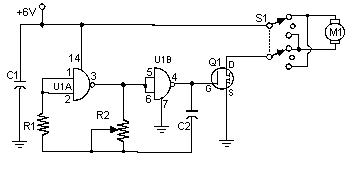
Pulse Width Modulation DC Motor Controls
This simple pulse width modulation (PWM) DC motor control addresses common issues by regulating motor speed through the application of short pulses. The duration of these pulses is varied to adjust the motor speed; longer pulses result in faster motor...
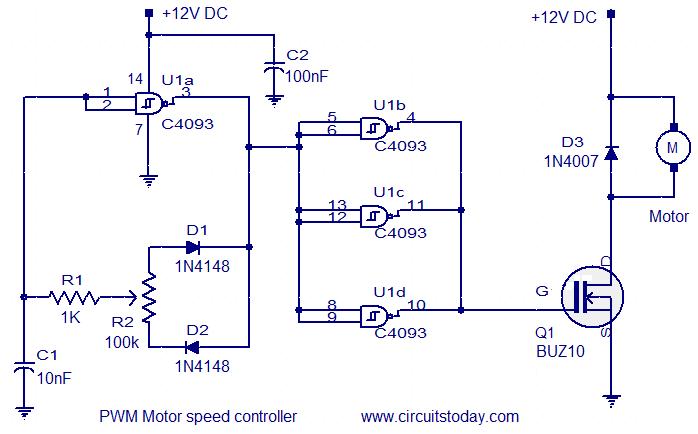
PWM motor speed controller
This circuit is designed based on a request from Mr. Vinoth in India. The requirement is for a 12V/5A DC fan motor controller. The circuit utilizes the quad 2-input Schmitt trigger IC CD4093 as its core component. Among the four...
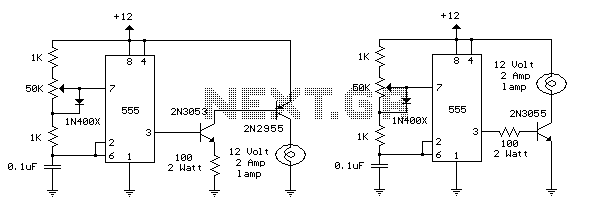
PWM Lamp or Motor Controller
This design is intended as a dimmer for a 12V reading lamp, but it can also function as a motor speed controller for devices like drills. The circuit modulates the voltage supplied to the load, allowing for variable pulse width...