


Electrical_Subsystem
#control system
#shift mapping
#automotive
#data analysis
#testing
#preliminary data
#2-D mapping
#algorithm

Description: The following data and mapping pertain to the 2-D shift mapping algorithm that the controller will utilize to determine when and if a shift should occur. The solid lines on the graph indicate up-shift boundaries, while the dashed lines represent down-shift boundaries. This data is preliminary, and extensive testing is necessary once the control system is operational on the ATV. Consequently, these points must be adjustable in the code to facilitate necessary modifications during testing. Both a linear interpolation scheme and an equation will later be employed to represent these boundary lines in the control software. Linear interpolation will provide more precise definitions of the points, although it will require more processing time than a simple equation. After the testing phase with linear interpolation, an equation will be more suitable. One of the primary reasons for selecting the electric cylinder over the pneumatic system was the total energy consumption. The calculations consider duty cycle, which is the percentage of time that the specific component draws power from the electrical system. Therefore, an intermittent system draw can be perceived as a lower, steady current draw. The energy supply for the system is the stator, which the Polaris manual specifies to provide 200 W at 3000 rpm. This value will serve as a minimum and worst-case scenario. The maximum energy consumption for the entire ATV, excluding any shifting systems, is calculated at 108 W. The pneumatic system assumes that the air pump operates continuously, allowing approximately five shifts every 20 seconds, requiring a constant 120 W. In contrast, the electric solenoid cylinder is actuated once for 0.2 seconds every second, ensuring a shift every second, with a requirement of 38 A, equivalent to a constant 91 W. Due to its lower energy requirements and higher shifts-per-second capability, the electric solenoid was selected. Feasibility testing of using a high-current electric cylinder was conducted on the running ATV. The OEM ATV electrical system could supply 36 A (and likely more) for brief periods. Current measurements were taken by connecting a 0.33-ohm power resistor across the battery leads and measuring the voltage across the resistor. The only limitation of this system is the dependency on the battery within the electrical system. This raised concerns among Polaris ATV racers, as the battery is often removed to reduce weight, along with most other "extra" electrical components.
The 2-D shift mapping algorithm is integral to optimizing the shifting strategy for the ATV's control system. The up-shift and down-shift boundaries, represented graphically, provide a visual representation of the operational limits within which the shifting mechanism must function. The requirement for these boundaries to be adjustable in the code allows for real-time tuning and optimization based on testing feedback, ensuring that the control system can adapt to varying operational conditions.
The use of linear interpolation for defining the boundary lines enhances the accuracy of the control software, allowing for a more refined control mechanism. However, this method's increased processing demands must be balanced against the need for rapid response times in the shifting process. The transition to a mathematical equation post-testing will streamline the computational requirements, enabling quicker decision-making by the control system during operation.
Energy efficiency is a critical factor in the design decision to implement an electric solenoid cylinder over a pneumatic system. The duty cycle calculations provide insight into the operational efficiency of the shifting system, with the electric solenoid's intermittent draw resulting in lower average power consumption compared to the continuous draw of the pneumatic system. The specifications provided by the Polaris manual regarding the stator's output are crucial for ensuring that the electric solenoid operates within safe and effective limits, particularly under worst-case scenarios.
The feasibility testing conducted on the high-current electric cylinder demonstrates the robustness of the ATV's electrical system, confirming its capability to handle the necessary current for effective operation. The measurement method using a power resistor offers a practical approach to assessing current draw, ensuring that the system's power requirements are met without exceeding the limits of the electrical components.
Concerns regarding battery dependency highlight the importance of weight management in ATV racing scenarios. The potential need for battery removal to reduce weight emphasizes the need for a reliable and efficient power management strategy within the ATV's electrical system, ensuring that performance is not compromised during competitive use. The integration of these considerations into the design and testing phases will contribute to the overall success of the shifting system in the ATV.The following data and mapping are for the 2-D shift mapping algorithm that the controller will use to determine when and if to shift. The solid lines on the graph represent up-shift boundaries, and the dashed lines represent down-shift boundaries.
This data is very preliminary, and much testing is required once the control system is working on th e ATV. As such, these points must be movable in the code so as to allow the tweaking that is necessary during testing. Both a linear interpolation scheme and then later an equation will be used to represent these boundary lines in the control software.
Linear interpolation will define the points more accurately, though will require more time in processing than a simple equation. Once the testing phase is done with linear interpolation, an equation will be best suited. One of the main reasons for selecting the electric cylinder over the pneumatic system was the total energy usage.
The calculations make use of duty-cycle, the percentage of time that the particular item draws its power from the electrical system. Thus, an intermittent system draw can be thought of as a lower, steady current draw. The system supply of energy is the stator, which is specified in the Polaris manual to provide 200 W at 3000 rpm.
This value will be used as a minimum and worst-case. The worst-case energy usage for the entire ATV, minus any shifting systems, is calculated at 108 W. The pneumatic system assumes that the air pump is constantly, allowing about 5 shifts per 20 seconds. This system requires a constant 120 W. The electric solenoid cylinder is only actuated once for 0. 2 seconds every second, thus guaranteeing a shift every second. This system requires 38 A, or similar to a constant 91 W. Because of the lower energy requirements and higher shifts-per-second, the electric solenoid was chosen.
Feasibility testing of using a high current electric cylinder was performed on the running ATV. The OEM ATV electrical system could provide 36A (and probably more) for a few seconds. Current was measured by connecting a 0. 33 ohm power resistor across the battery leads and measuring the voltage across the resistor. The only drawback of this system is the required use of the battery in the electrical system. This was a concern for Polaris ATV racers, as the battery is often removed to reduce weight (as well as most of the other "extra" electrical components).
The 2-D shift mapping algorithm is integral to optimizing the shifting strategy for the ATV's control system. The up-shift and down-shift boundaries, represented graphically, provide a visual representation of the operational limits within which the shifting mechanism must function. The requirement for these boundaries to be adjustable in the code allows for real-time tuning and optimization based on testing feedback, ensuring that the control system can adapt to varying operational conditions.
The use of linear interpolation for defining the boundary lines enhances the accuracy of the control software, allowing for a more refined control mechanism. However, this method's increased processing demands must be balanced against the need for rapid response times in the shifting process. The transition to a mathematical equation post-testing will streamline the computational requirements, enabling quicker decision-making by the control system during operation.
Energy efficiency is a critical factor in the design decision to implement an electric solenoid cylinder over a pneumatic system. The duty cycle calculations provide insight into the operational efficiency of the shifting system, with the electric solenoid's intermittent draw resulting in lower average power consumption compared to the continuous draw of the pneumatic system. The specifications provided by the Polaris manual regarding the stator's output are crucial for ensuring that the electric solenoid operates within safe and effective limits, particularly under worst-case scenarios.
The feasibility testing conducted on the high-current electric cylinder demonstrates the robustness of the ATV's electrical system, confirming its capability to handle the necessary current for effective operation. The measurement method using a power resistor offers a practical approach to assessing current draw, ensuring that the system's power requirements are met without exceeding the limits of the electrical components.
Concerns regarding battery dependency highlight the importance of weight management in ATV racing scenarios. The potential need for battery removal to reduce weight emphasizes the need for a reliable and efficient power management strategy within the ATV's electrical system, ensuring that performance is not compromised during competitive use. The integration of these considerations into the design and testing phases will contribute to the overall success of the shifting system in the ATV.The following data and mapping are for the 2-D shift mapping algorithm that the controller will use to determine when and if to shift. The solid lines on the graph represent up-shift boundaries, and the dashed lines represent down-shift boundaries.
This data is very preliminary, and much testing is required once the control system is working on th e ATV. As such, these points must be movable in the code so as to allow the tweaking that is necessary during testing. Both a linear interpolation scheme and then later an equation will be used to represent these boundary lines in the control software.
Linear interpolation will define the points more accurately, though will require more time in processing than a simple equation. Once the testing phase is done with linear interpolation, an equation will be best suited. One of the main reasons for selecting the electric cylinder over the pneumatic system was the total energy usage.
The calculations make use of duty-cycle, the percentage of time that the particular item draws its power from the electrical system. Thus, an intermittent system draw can be thought of as a lower, steady current draw. The system supply of energy is the stator, which is specified in the Polaris manual to provide 200 W at 3000 rpm.
This value will be used as a minimum and worst-case. The worst-case energy usage for the entire ATV, minus any shifting systems, is calculated at 108 W. The pneumatic system assumes that the air pump is constantly, allowing about 5 shifts per 20 seconds. This system requires a constant 120 W. The electric solenoid cylinder is only actuated once for 0. 2 seconds every second, thus guaranteeing a shift every second. This system requires 38 A, or similar to a constant 91 W. Because of the lower energy requirements and higher shifts-per-second, the electric solenoid was chosen.
Feasibility testing of using a high current electric cylinder was performed on the running ATV. The OEM ATV electrical system could provide 36A (and probably more) for a few seconds. Current was measured by connecting a 0. 33 ohm power resistor across the battery leads and measuring the voltage across the resistor. The only drawback of this system is the required use of the battery in the electrical system. This was a concern for Polaris ATV racers, as the battery is often removed to reduce weight (as well as most of the other "extra" electrical components).
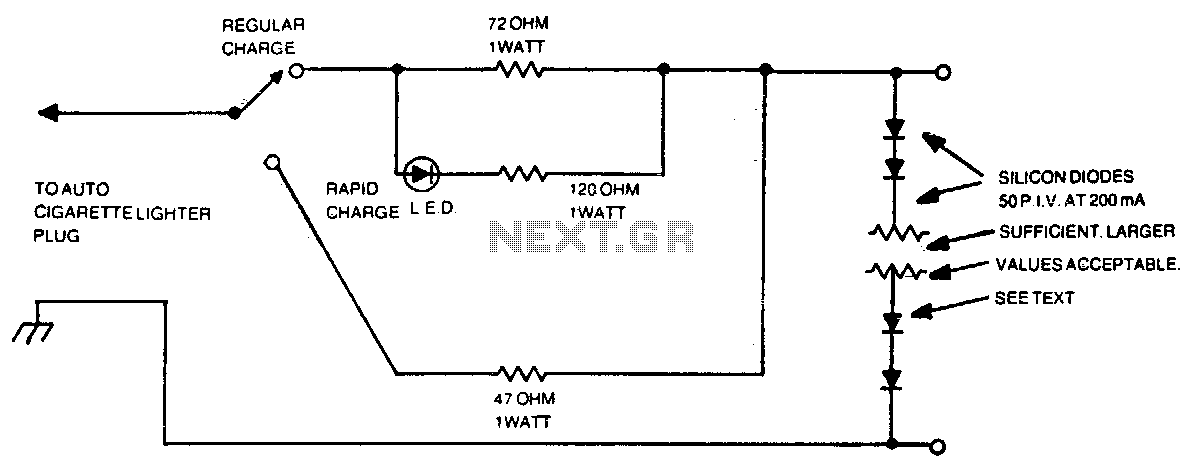
Automotive charger for ni-cad battery packs
The number of silicon diodes across the output is determined by the voltage of the battery pack. Each diode is considered at 0 volts. For example, a 10-volt pack would require 10/0 = 157, or 16 diodes.
In the context of...
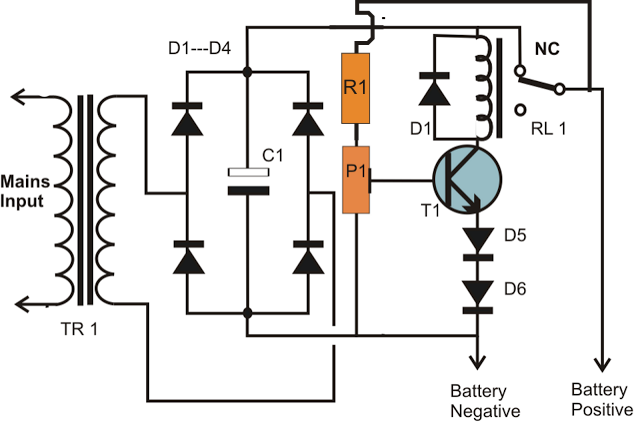
simplest smf automotive battery charger
A simple battery charger circuit is described, utilizing a single transistor for voltage detection and automatically disconnecting the battery from the supply when fully charged. The circuit's high voltage trip point is set to switch off the charging voltage when...
Cold Atom Control System for PC
We have developed a powerful yet inexpensive and easy to construct experiment control system. The construction of the system together with the control software is described here. All circuits and software are free to download and use for nonprofit. The...
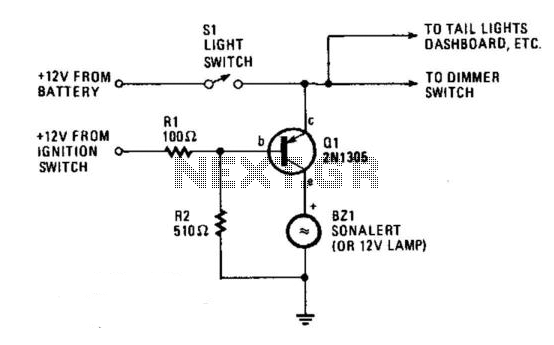
Automobile Lights-On Reminder
The circuit provides a visible or audible warning when the headlights are on. It utilizes a 2N1305 transistor as a switch to activate either a Sonalert tone generator or a small 12-V lamp. The operating current for the transistor is...
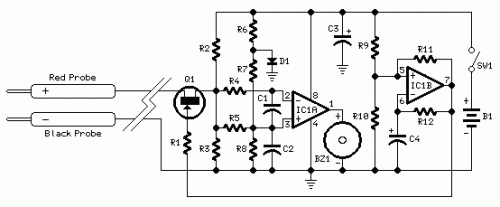
Quick On-Board Junction Tester
Short circuits or broken PCB tracks can be easily identified using a multimeter. However, this tool may yield inaccurate results when assessing the efficiency of a transistor or diode unless the component is unsoldered and removed from the PCB. Additionally,...
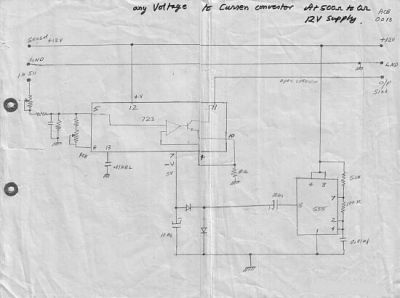
Process-Control
The Measured Value and the Setpoint are two inputs to a control system. The Measured Value is the amplified input from a transducer or sensor that monitors a parameter requiring control, such as pressure or temperature. The Setpoint is the...
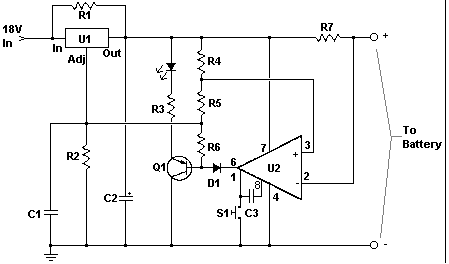
Car battery charger Automative car and motorcycle schematics
The circuit is designed to operate with an external power supply, which is why it does not include a transformer, rectifier, or filter capacitors in the schematic. However, these components can be added if desired. To utilize the circuit, connect...
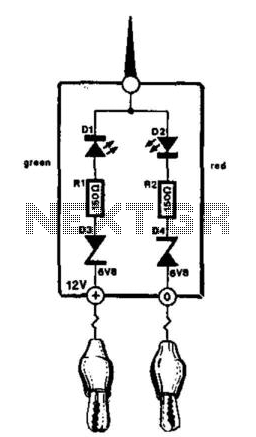
Automotive Electrical Tester
This compact tester is designed for checking vehicle electrical circuits. Two LEDs indicate whether one of the clips is connected to the positive supply line (red) or to ground (green). The unit is powered by the vehicle battery. It is...
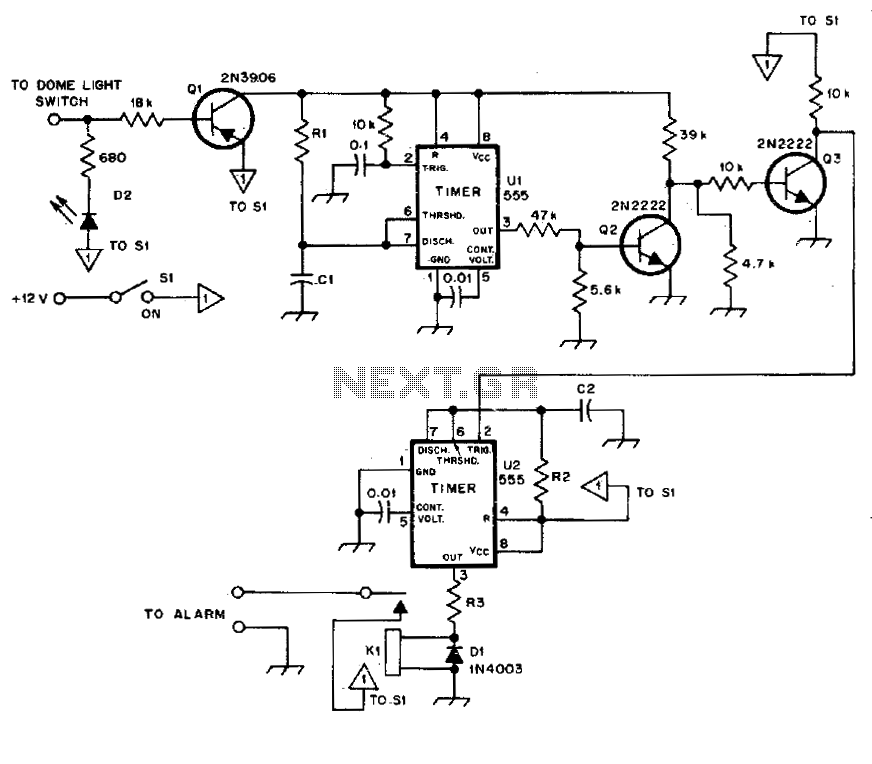
Automotive burglar alarm
The alarm activates after a 13-second delay and remains active for 1 to 1.5 minutes before automatically resetting. It can also be deactivated and reset by opening and reclosing switch SI.
The described circuit functions as a delay-triggered alarm system, incorporating...