


Bipolar stepper motor driver module circuit
#stepper motor
#bipolar
#motor driver
#L297
#controller
#rotation direction
#cw/ccw
#dedicated controller
#module circuit
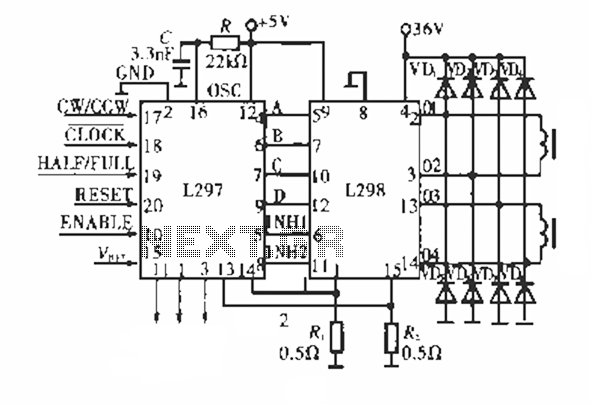
Description: The circuit operates using a dedicated stepping motor controller, the L297. Pin 17 (CW/CCW) is utilized to control the rotation direction of the stepper motor. Pin 18 (CLOCK) regulates the speed of the stepper motor, while pin 19 (HALF/FULL) allows for the selection between full-step and half-step operation. Pin 20 (RESET) is set low to return to the initial state upon power restoration, with the output configuration ABCD = 0101. Pin 10 (ENABLE) functions as the chip reset terminal; when low, it sets ABCD = 0000, ensuring that each phase of the stepper motor remains de-energized for manual adjustments. Pin 15 (VREF) serves as the reference voltage terminal, determining the current through the stepper motor coils, with Vref defined as Rs1 (Rs2), typically with Rs1 and Rs2 equal to 0.5 Ohm. Pin 16 (OSC) requires an external RC network that influences the chopping frequency of the chopper circuit, calculated as f = I / (0.7RC), where R must exceed 10 kΩ. A typical chopping frequency of 20 kHz is illustrated. This circuit is designed to drive a stepper motor with a rated voltage of 36 V and a current of 2 A across all four lines, accommodating both permanent magnet and hybrid stepping motors with six leads.
The L297 stepping motor controller is an integrated circuit designed to facilitate the control of stepping motors, allowing precise operation in various applications. The controller is capable of handling both full-step and half-step driving modes, which can optimize torque and resolution based on the application's requirements. The CW/CCW pin configuration enables straightforward direction control, making it suitable for applications requiring bidirectional movement.
The CLOCK input is essential for speed regulation; by adjusting the frequency of the clock signal, the user can control the step rate of the motor, which directly influences the speed. The RESET functionality ensures that the system can return to a known state after power interruptions, which is critical for maintaining operational integrity in automated systems.
The ENABLE pin serves an important role in power management, allowing the motor phases to be disabled when not in use, thus conserving energy and preventing overheating. The reference voltage at VREF is crucial for setting the current through the motor coils, which affects the motor's performance characteristics such as torque and responsiveness.
The OSC pin's external RC network is vital for determining the chopping frequency of the drive circuit, which is essential for efficient operation of the stepping motor. The choice of resistor and capacitor values directly impacts the performance, and the specified minimum resistance helps prevent excessive current draw, ensuring safe operation.
Overall, the L297 controller provides a robust solution for driving stepping motors, offering flexibility in speed, direction, and operational modes, making it an excellent choice for various applications in robotics, CNC machinery, and precision positioning systems.Circuit works: Figure shows a dedicated stepping motor controller L297 key pin, 17 feet (cw / ccw) is used to control the stepper motor rotation direction 18 feet (CLOCK) used to control the speed of the stepping motor speed ; 19 feet (HALF / FULL) for stepper motor full-step, half-step selection; 20 feet (rESET) is low, to the initial state when power is restored, ABCD = 0101; 10 feet (ENABLE) for the chip reset terminal when the terminal is low, ABCD = 0000, that is, each phase stepping motor is not energized in the workplace in order to manually adjust some tuning work location; 15 feet (VREF) as a reference voltage terminal of the voltage determines the step electric motive coil current is, Vvef = is Rs1 (Rs2), general Rs1 - Rs2 - 0.5 Omega; 16 feet (Osc) external RC value depends on the frequency of the chopping frequency of the chopper circuit is f = I / ( 0. 7R C), R must be greater than 10 k , 20 kHz shown in the figure is typical chopping frequency. Use this line to drive the following rated voltage 36 V, 2 A similar within all four lines, six lines of permanent magnet or hybrid stepping motor.
The L297 stepping motor controller is an integrated circuit designed to facilitate the control of stepping motors, allowing precise operation in various applications. The controller is capable of handling both full-step and half-step driving modes, which can optimize torque and resolution based on the application's requirements. The CW/CCW pin configuration enables straightforward direction control, making it suitable for applications requiring bidirectional movement.
The CLOCK input is essential for speed regulation; by adjusting the frequency of the clock signal, the user can control the step rate of the motor, which directly influences the speed. The RESET functionality ensures that the system can return to a known state after power interruptions, which is critical for maintaining operational integrity in automated systems.
The ENABLE pin serves an important role in power management, allowing the motor phases to be disabled when not in use, thus conserving energy and preventing overheating. The reference voltage at VREF is crucial for setting the current through the motor coils, which affects the motor's performance characteristics such as torque and responsiveness.
The OSC pin's external RC network is vital for determining the chopping frequency of the drive circuit, which is essential for efficient operation of the stepping motor. The choice of resistor and capacitor values directly impacts the performance, and the specified minimum resistance helps prevent excessive current draw, ensuring safe operation.
Overall, the L297 controller provides a robust solution for driving stepping motors, offering flexibility in speed, direction, and operational modes, making it an excellent choice for various applications in robotics, CNC machinery, and precision positioning systems.Circuit works: Figure shows a dedicated stepping motor controller L297 key pin, 17 feet (cw / ccw) is used to control the stepper motor rotation direction 18 feet (CLOCK) used to control the speed of the stepping motor speed ; 19 feet (HALF / FULL) for stepper motor full-step, half-step selection; 20 feet (rESET) is low, to the initial state when power is restored, ABCD = 0101; 10 feet (ENABLE) for the chip reset terminal when the terminal is low, ABCD = 0000, that is, each phase stepping motor is not energized in the workplace in order to manually adjust some tuning work location; 15 feet (VREF) as a reference voltage terminal of the voltage determines the step electric motive coil current is, Vvef = is Rs1 (Rs2), general Rs1 - Rs2 - 0.5 Omega; 16 feet (Osc) external RC value depends on the frequency of the chopping frequency of the chopper circuit is f = I / ( 0. 7R C), R must be greater than 10 k , 20 kHz shown in the figure is typical chopping frequency. Use this line to drive the following rated voltage 36 V, 2 A similar within all four lines, six lines of permanent magnet or hybrid stepping motor.
driving stepper motor using uln2003
The simplest method to drive a stepper motor with a lower current rating is by utilizing the ULN2003. The ULN2003 consists of seven Darlington transistors and can handle up to 500mA per channel, with an internal voltage drop of approximately...
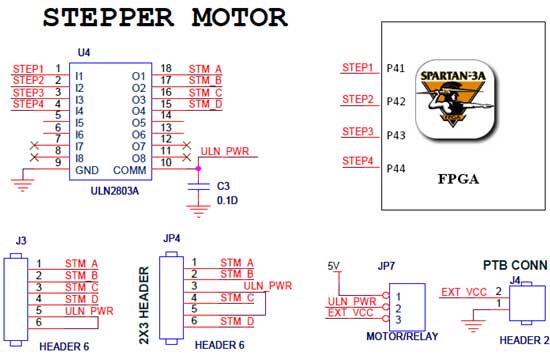
stepper motor interfacing with spartan 3an fpga
The Spartan-3an board features external interfacing for stepper motors, as illustrated in the accompanying figure. The stepper motor is driven by the ULN2803A, which is a high-voltage, high-current Darlington transistor array. The ULN2803 serves as a driver for the port...
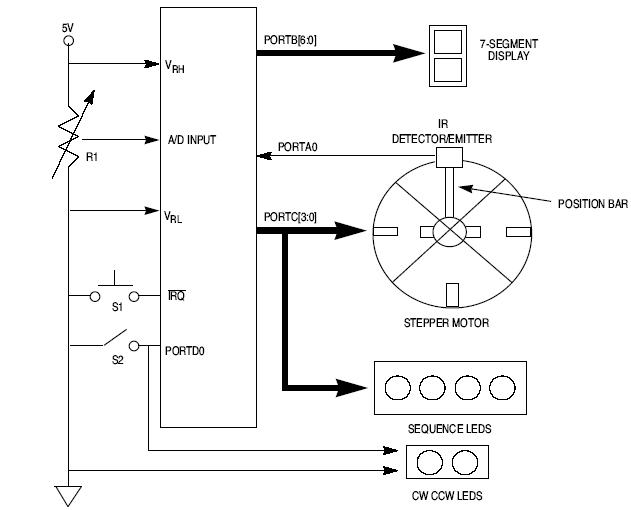
Howto Design a Stepper Motor System Using an 8-bit Freescale microcontroller MCU - MC68HC11E9
This article explains how to design a stepper motor system using an 8-bit Freescale microcontroller - MC68HC11E9.
The design of a stepper motor system utilizing the 8-bit Freescale microcontroller MC68HC11E9 involves several key components and considerations to ensure effective control and...
RS 422 Compatible Indicator
The design involves creating a circuit and programming for a stepper motor controller, developing a speed-controlled DC motor circuit for the propulsion system of the project, and designing a navigation system using a MEMS accelerometer circuit. This section deviates slightly...
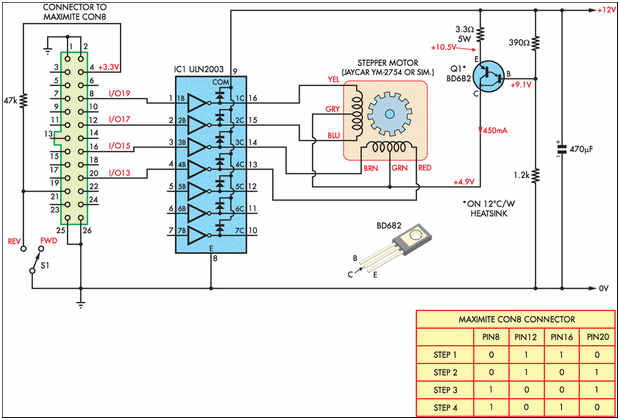
Rotate a stepper motor using a computer
Designing and implementing this circuit was an exciting endeavor. The design of the interface involved learning how to control a device from a computer. A parallel port cable was utilized for this purpose, enabling instant control of the stepper motor....
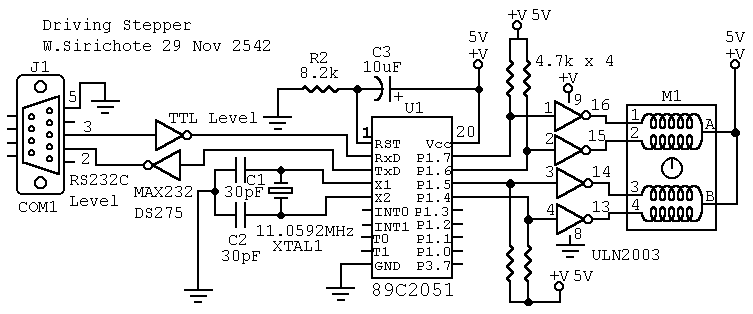
Driving Stepper
M1 is a stepper taken from an old disk drive. There are five pins, i.e., common, coil 1, 2, 3 and 4. Resistance measured between common pin and each coil is about 75 Ohms. Driving current for each coil is...
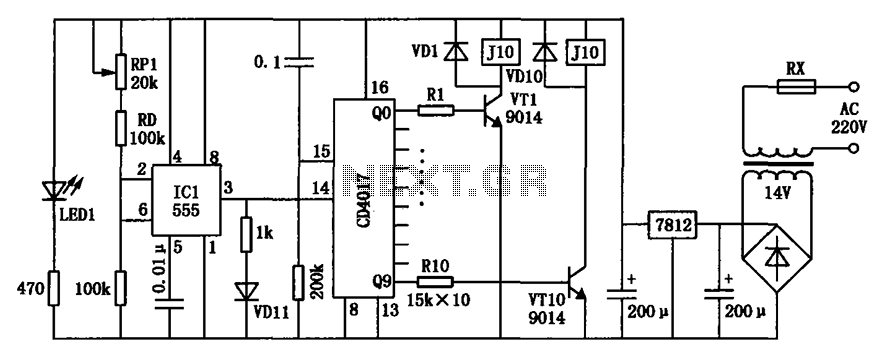
Synchronous controller circuit diagram of a recording transcript
Modern exhibitions utilize extensive sound, light, and electrical technologies for advertising, promotion, and propaganda. This involves various electrical diagrams and control models. Commonly used is an automatic program circuit with pre-recorded commentary, which requires synchronization of two mating times. A...
Custom Motor Driver
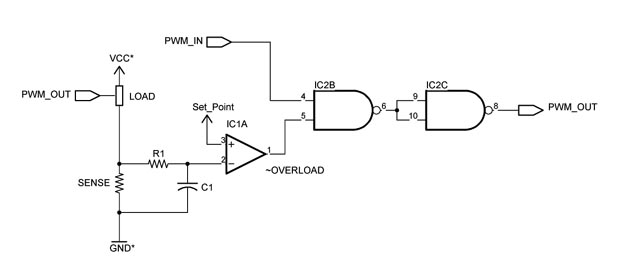
This chapter was removed from Applied Robotics 2 due to space constraints. It addresses general motor control issues and details the construction of a 5-amp motor driver. The principles discussed can be applied to larger motor controllers. Although commercially available...
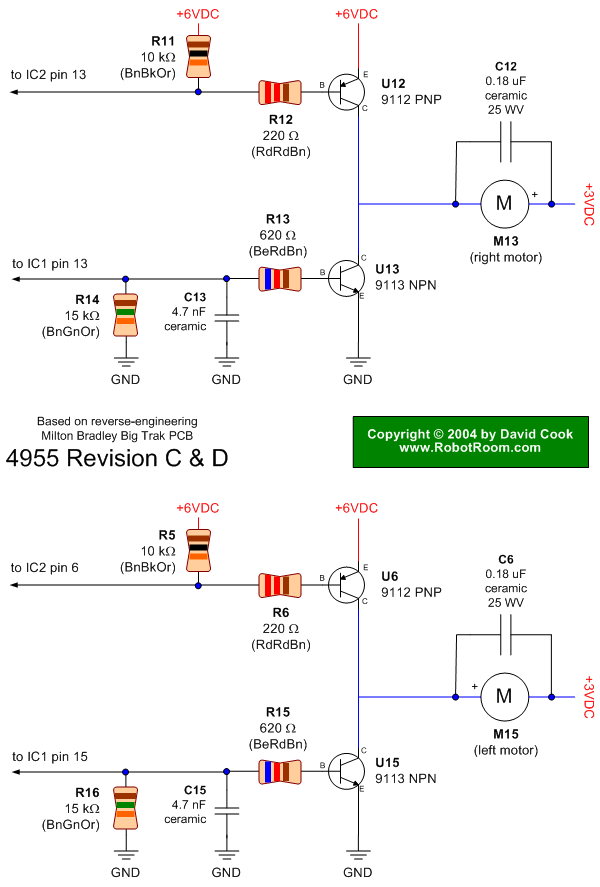
Big Trak Motor Driver Schematic
Schematic of Big Trak's motor driver circuit. The toy includes 9112 and 9113 transistors (and sometimes 2N6715) because the 75494 chip cannot supply enough current to run the Big Trak's motors by itself.
The motor driver circuit for the Big Trak...