


Driving Stepper
#stepper motor
#ULN2003
#darlington transistor
#AT89C2051
#microcontroller
#current driver
#5V supply
#coil driver
#disk drive motor
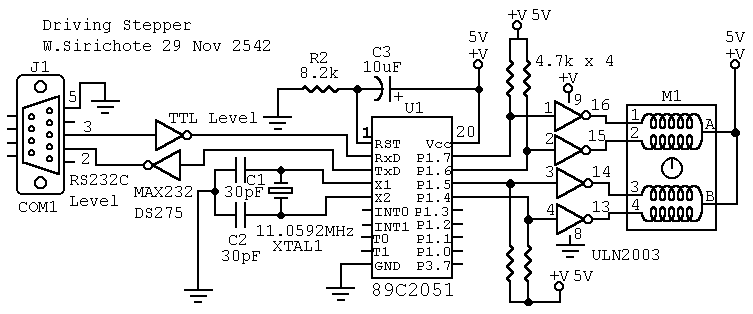
Description: M1 is a stepper taken from an old disk drive. There are five pins, i.e., common, coil 1, 2, 3 and 4. Resistance measured between common pin and each coil is about 75 Ohms. Driving current for each coil is then needed about 60mA at +5V supply. A darlington transistor array, ULN2003 is used to increase driving capacity of the 2051 chip. Each output provides 500mA max at 50V. P1.4 to P1.7, four output pins are connected to the input of the ULN2003 as shown in the circuit. Four 4.7k resistors help the 2051 to provide more sourcing current from the +5V supply. The serial port is optional for your exercises. Many have provided useful technical, and application of using stepper, see the links below.
The M1 stepper motor, sourced from an obsolete disk drive, features a configuration of five pins: one common pin and four coil pins. The measured resistance between the common pin and each coil pin is approximately 75 Ohms, indicating a relatively low impedance, which is typical for stepper motors. To operate each coil effectively, a driving current of about 60mA is required when powered by a +5V supply.
To facilitate the increased driving capacity necessary for controlling the stepper motor, a Darlington transistor array, specifically the ULN2003, is employed. This component is designed to handle higher current loads, with each output capable of supplying a maximum of 500mA at voltages up to 50V. The arrangement of the circuit involves connecting four output pins from the control chip (noted as P1.4 to P1.7) to the inputs of the ULN2003. This configuration allows for efficient control of the motor coils.
Additionally, four 4.7kΩ resistors are incorporated into the design to enhance the current sourcing capabilities from the +5V supply, thereby ensuring that the 2051 chip can drive the ULN2003 effectively. This resistor setup serves to limit the current flowing into the inputs of the ULN2003, protecting the control logic while still providing sufficient drive for the transistor array.
An optional serial port interface is mentioned for further exercises, allowing for additional control and communication with the stepper motor system. The integration of the stepper motor in various applications has been widely documented, providing a wealth of technical insights and practical implementations for users interested in harnessing stepper motor technology.M1 is a stepper taken from an old disk drive. There are five pins, i.e., common, coil 1, 2, 3 and 4. Resistance measured between common pin and each coil is about 75 Ohms. Driving current for each coil is then needed about 60mA at +5V supply. A darlington transistor array, ULN2003 is used to increase driving capacity of the 2051 chip. Each output provides 500mA max at 50V. P1.4 to P1.7, four output pins are connected to the input of the ULN2003 as shown in the circuit. Four 4.7k resistors help the 2051 to provide more sourcing current from the +5V supply. The serial port is optional for your exercises. Many have provided useful technical, and application of using stepper, see the links below.
The M1 stepper motor, sourced from an obsolete disk drive, features a configuration of five pins: one common pin and four coil pins. The measured resistance between the common pin and each coil pin is approximately 75 Ohms, indicating a relatively low impedance, which is typical for stepper motors. To operate each coil effectively, a driving current of about 60mA is required when powered by a +5V supply.
To facilitate the increased driving capacity necessary for controlling the stepper motor, a Darlington transistor array, specifically the ULN2003, is employed. This component is designed to handle higher current loads, with each output capable of supplying a maximum of 500mA at voltages up to 50V. The arrangement of the circuit involves connecting four output pins from the control chip (noted as P1.4 to P1.7) to the inputs of the ULN2003. This configuration allows for efficient control of the motor coils.
Additionally, four 4.7kΩ resistors are incorporated into the design to enhance the current sourcing capabilities from the +5V supply, thereby ensuring that the 2051 chip can drive the ULN2003 effectively. This resistor setup serves to limit the current flowing into the inputs of the ULN2003, protecting the control logic while still providing sufficient drive for the transistor array.
An optional serial port interface is mentioned for further exercises, allowing for additional control and communication with the stepper motor system. The integration of the stepper motor in various applications has been widely documented, providing a wealth of technical insights and practical implementations for users interested in harnessing stepper motor technology.M1 is a stepper taken from an old disk drive. There are five pins, i.e., common, coil 1, 2, 3 and 4. Resistance measured between common pin and each coil is about 75 Ohms. Driving current for each coil is then needed about 60mA at +5V supply. A darlington transistor array, ULN2003 is used to increase driving capacity of the 2051 chip. Each output provides 500mA max at 50V. P1.4 to P1.7, four output pins are connected to the input of the ULN2003 as shown in the circuit. Four 4.7k resistors help the 2051 to provide more sourcing current from the +5V supply. The serial port is optional for your exercises. Many have provided useful technical, and application of using stepper, see the links below.
Stepper Motor Project
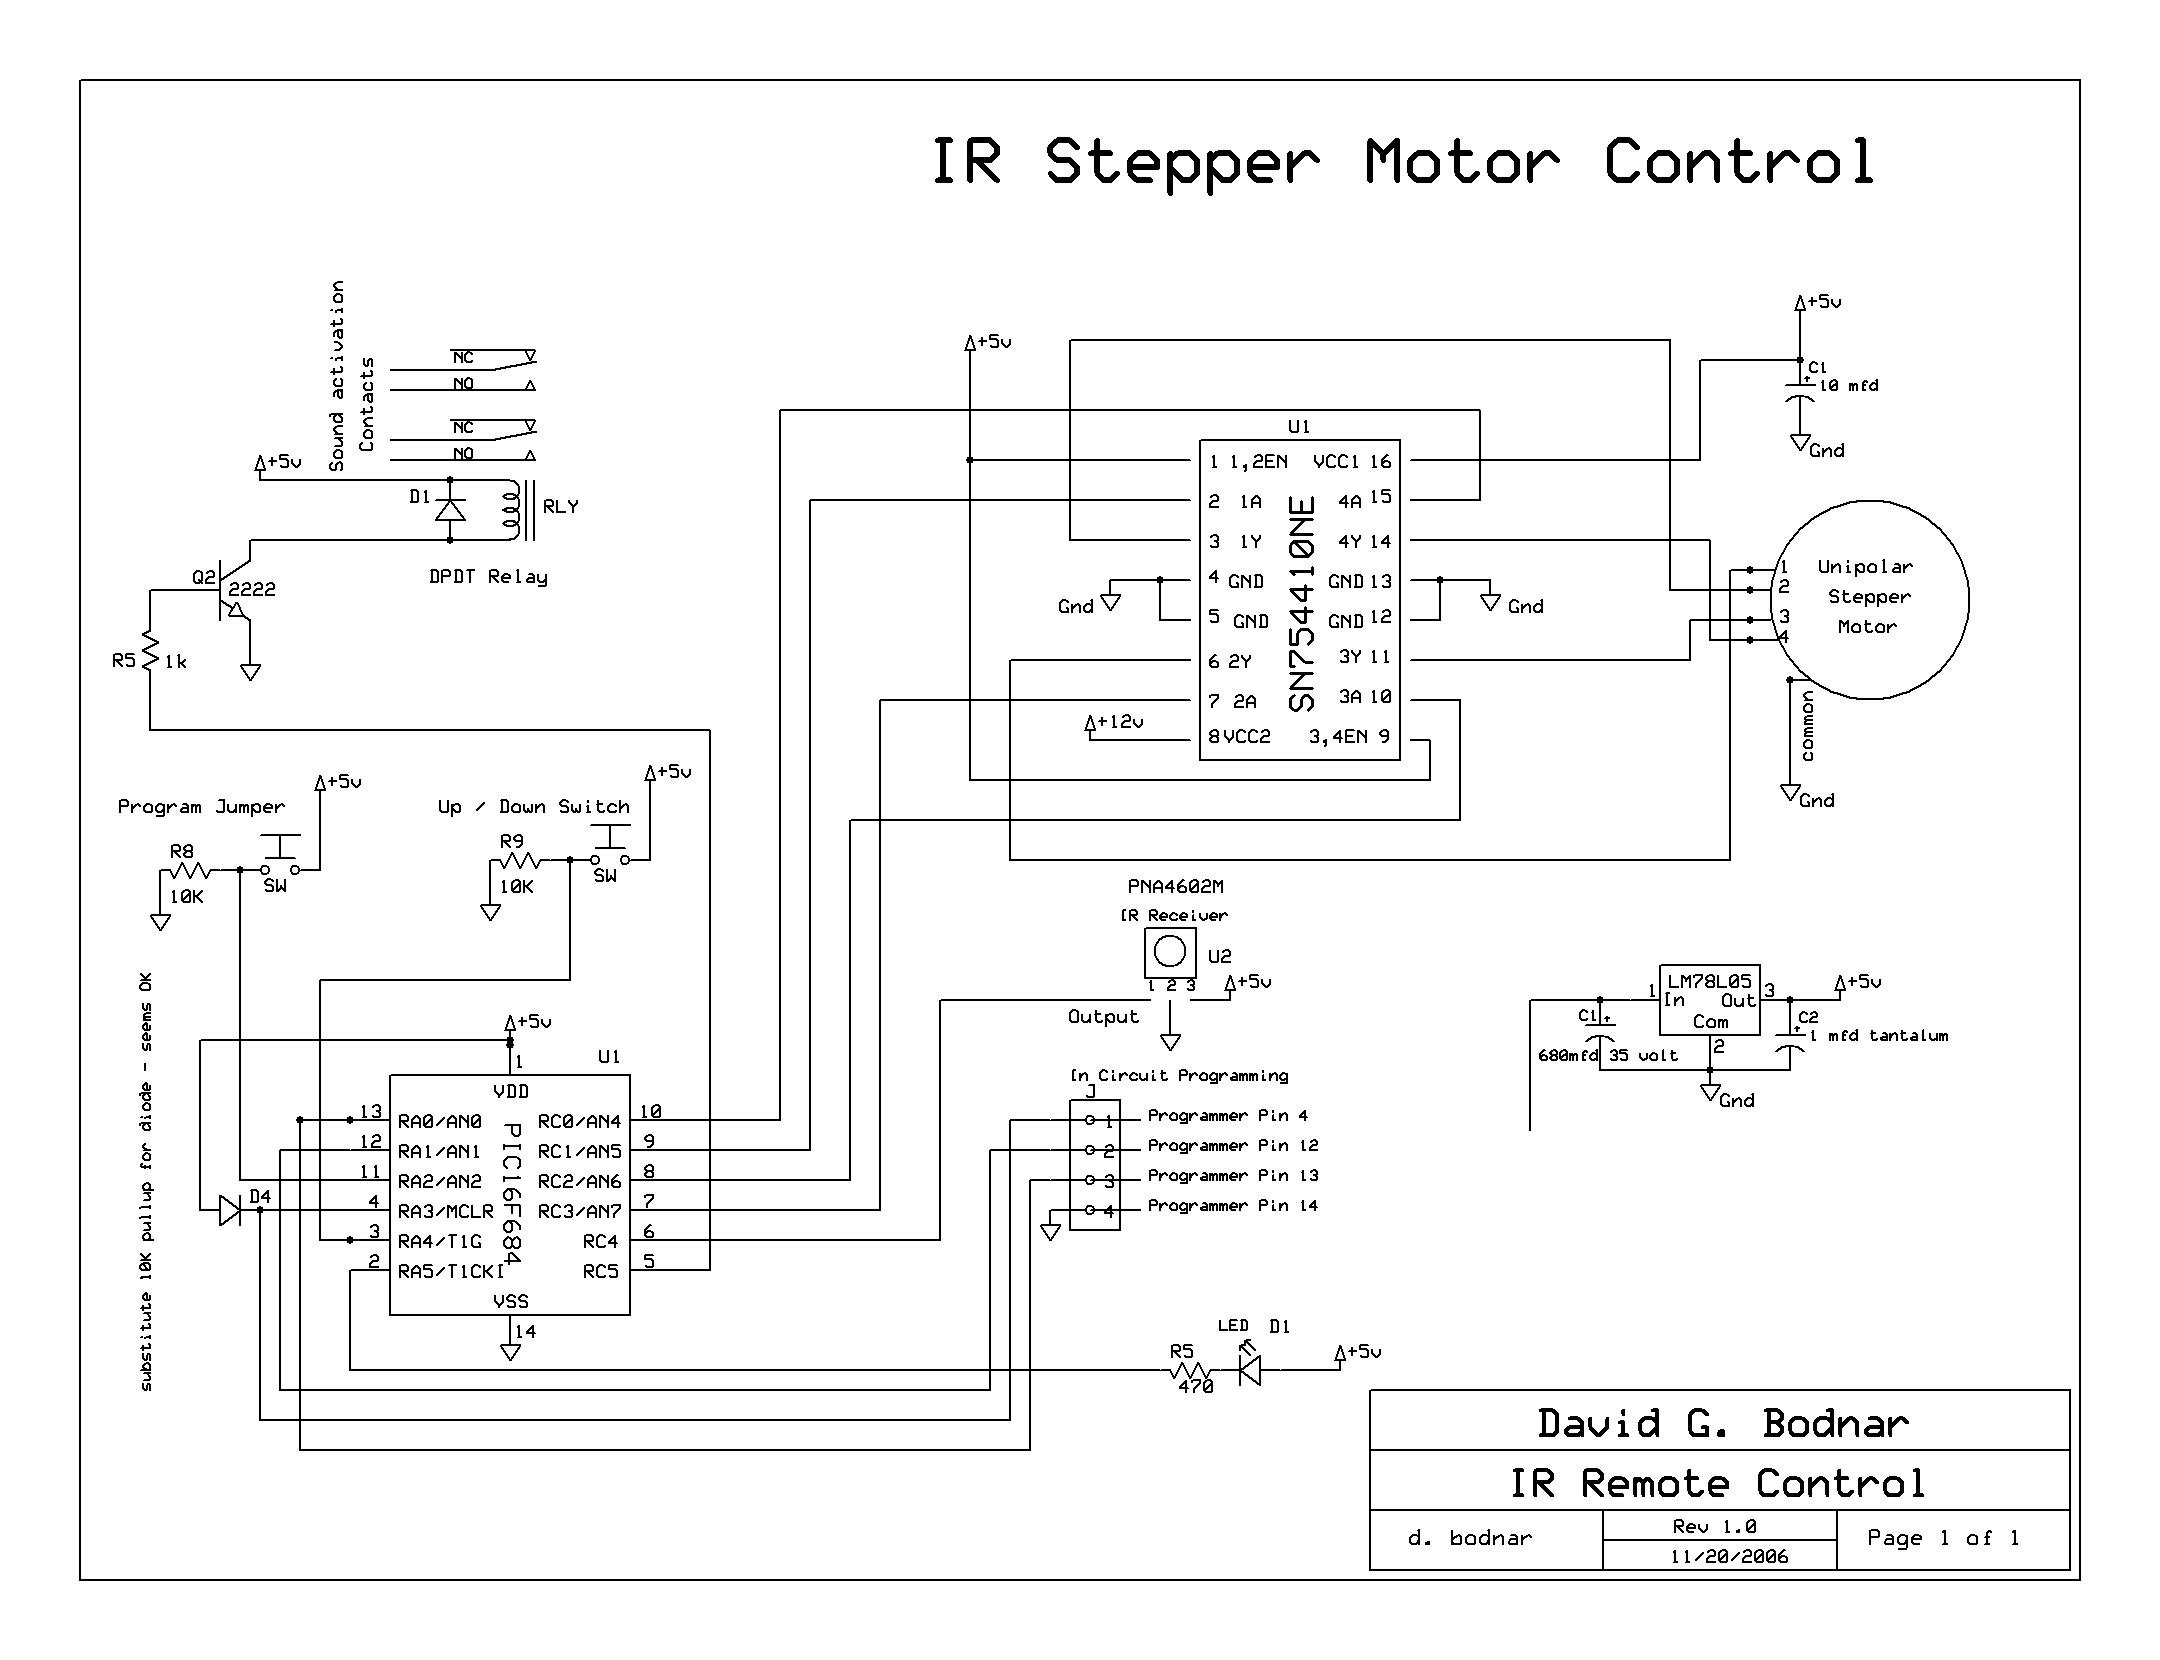
The microcontroller board is displayed (top left/green board) alongside the auxiliary board (bottom left/brown board) and two geared Hurst stepper motors. In this view, the programming jumper is located in the upper right area of the microcontroller board, while power...
graphical LCDs with a microcontroller
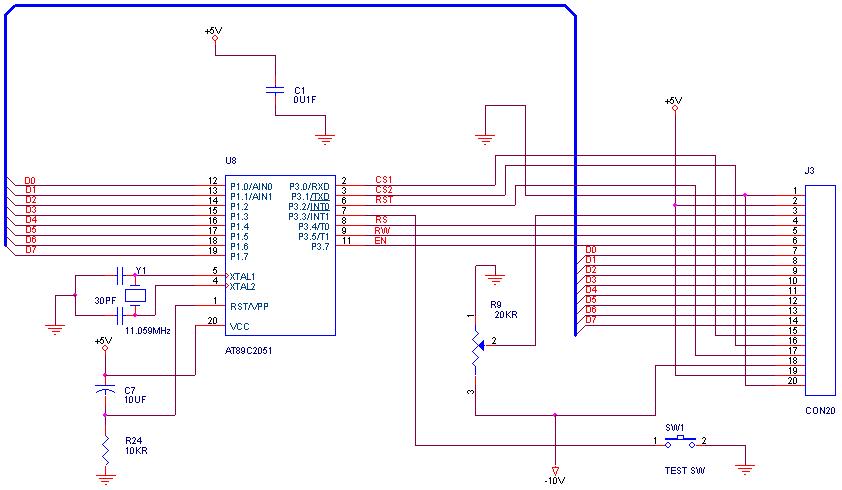
How can graphical LCDs be controlled using a microcontroller? Is there any datasheet available?
Graphical LCDs (Liquid Crystal Displays) are widely used in various electronic applications for displaying complex graphics and text. To control these displays with a microcontroller, several steps...

Preprogrammed single-chip microcontroller
Twenty-five musical keys and 25 LEDs are provided to denote F to F" with half notes in between. Memory can store a played tune. There are ten preprogrammed tunes (each has an average of 55 notes) masked in the chip....
Talking Yoda head
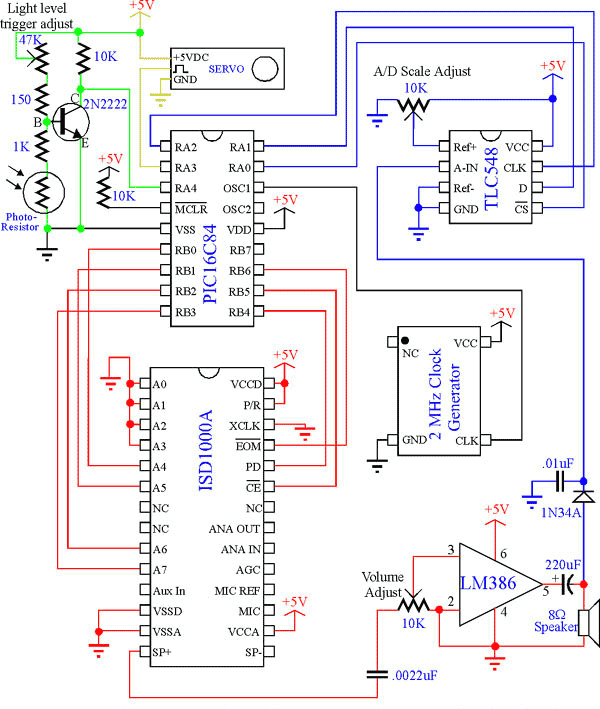
The talking Yoda head consists of a Yoda mask and a microcontroller system to achieve the desired operation/effect. The basic operation of the project was specified as follows: The head was to be placed inside a closed box. Upon opening...

Studio of Bill Ooms Computerized Ornamental Lathe
Currently, a Gecko G540 drive module is employed to control stepper motors. This module can drive up to four stepper motors, with connections labeled as XYZA. The C-axis stepper will be connected to the A output, while the Y output...
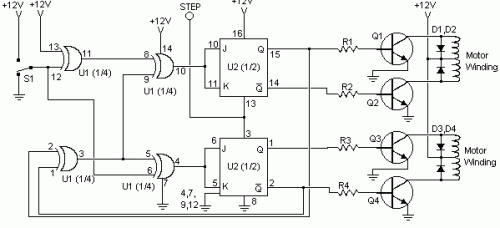
Stepper Motor Controller
This circuit is constructed using standard components and can be easily adapted for computer control. By utilizing inexpensive surplus transistors and a stepper motor, the overall cost of the circuit can be maintained at under $10.
The described circuit is a...
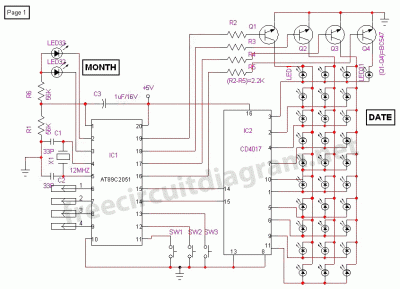
Digital Calender Circuit
This is a digital calendar circuit that utilizes a microcontroller to display the date, day, and month on an LED display. The entire system is managed by an 8-bit microcontroller, which operates based on a program embedded in its ROM....
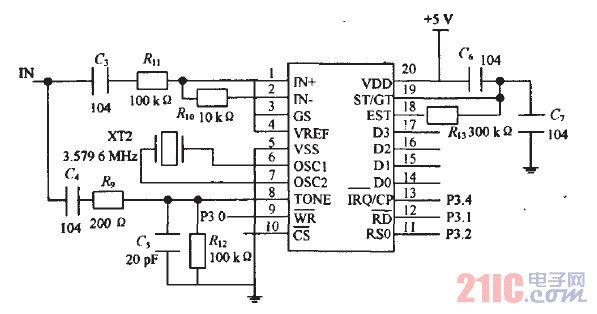
the remote intellectual pronunciation anti-theft alarm system design of the one-chip computer
Precautions must be taken against low safety coefficients, as the applicable space for security measures continues to shrink. With advancements in science and technology, innovations such as magnetic door sensors, touch-type systems, radar monitoring, and infrared detection have emerged, leading...
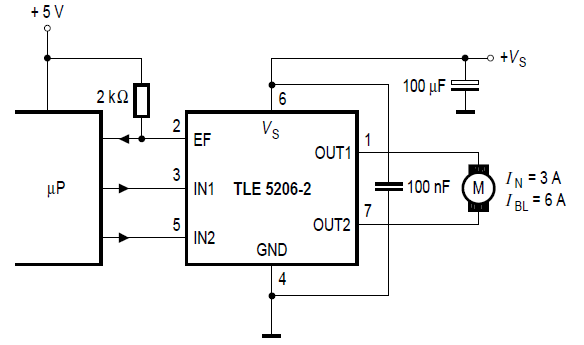
stepper remote control car
Stepper motor control circuit diagram using TLE5206 for remote control car.
The stepper motor control circuit is designed to manage the operation of a stepper motor, specifically utilizing the TLE5206 integrated circuit. This circuit is particularly suitable for applications in remote...