


driving stepper motor using uln2003
#stepper motor
#ULN2003
#darlington transistors
#motor driver
#inductive loads
#voltage spikes
#current rating
#clamp diodes
Description: The simplest method to drive a stepper motor with a lower current rating is by utilizing the ULN2003. The ULN2003 consists of seven Darlington transistors and can handle up to 500mA per channel, with an internal voltage drop of approximately 1V when activated. It includes internal clamp diodes to manage voltage spikes when driving inductive loads. A circuit diagram for driving a stepper motor using the ULN2003 is provided below. For stepper motors requiring higher current torque, the TIP120 can be employed. The TIP120 has the advantage of being able to pass greater current, especially when used with a heat sink. However, it requires more wiring and necessitates the use of four TIP120 devices to control the motor.
The ULN2003 is a versatile component commonly used in driving stepper motors, particularly those with lower current ratings. This integrated circuit serves as a relay driver and is particularly advantageous due to its ability to handle inductive loads. The internal Darlington transistor configuration allows for high current gain, providing sufficient drive capability for small to medium-sized stepper motors.
In applications where a stepper motor requires more torque and operates at higher currents, the TIP120 power transistor can be utilized. The TIP120 is a Darlington pair that is capable of managing currents significantly higher than the ULN2003, making it suitable for applications where the motor's power demand exceeds 500mA per channel. It is important to note that while the TIP120 allows for higher current handling, it also introduces additional complexity to the circuit design, as it requires multiple components to achieve the desired control.
When implementing a stepper motor driver circuit using the ULN2003, it is crucial to ensure proper connection of the stepper motor phases to the output pins of the ULN2003. Each output pin corresponds to a specific phase of the motor, and the sequence of activation must be carefully controlled to enable smooth rotation. The internal clamp diodes are particularly beneficial in protecting the circuit from back EMF generated by the inductive loads, ensuring reliable operation.
In contrast, when utilizing TIP120 transistors for higher current applications, a careful layout and sufficient heat sinking are essential to prevent overheating. The wiring complexity increases as four TIP120 transistors are generally required to control a bipolar stepper motor, necessitating additional consideration for signal integrity and power distribution in the circuit design.
In summary, both the ULN2003 and TIP120 offer unique advantages for driving stepper motors, and the choice between them should be based on the specific current requirements and operational conditions of the application. Proper circuit design and component selection are critical to achieving optimal performance and reliability in stepper motor control systems.The simplest way to drive stepper motor having lower current rating is using ULN2003. The ULN2003 contains seven darlington transistors. The ULN2003 can pass upto 500mA per channel and has an internal voltage drop of about 1V when on. It also contains internal clamp diodes to dissipate voltage spikes when driving inductive loads. The circuit for driving stepper motor using ULN2003 is shown below. For higher current torque motors, you can use TIP120. The advantage is that the TIP120 can pass more current along with heat sink. The disadvantages are that the more wiring is required and four TIP120 is used to control the motor.
The ULN2003 is a versatile component commonly used in driving stepper motors, particularly those with lower current ratings. This integrated circuit serves as a relay driver and is particularly advantageous due to its ability to handle inductive loads. The internal Darlington transistor configuration allows for high current gain, providing sufficient drive capability for small to medium-sized stepper motors.
In applications where a stepper motor requires more torque and operates at higher currents, the TIP120 power transistor can be utilized. The TIP120 is a Darlington pair that is capable of managing currents significantly higher than the ULN2003, making it suitable for applications where the motor's power demand exceeds 500mA per channel. It is important to note that while the TIP120 allows for higher current handling, it also introduces additional complexity to the circuit design, as it requires multiple components to achieve the desired control.
When implementing a stepper motor driver circuit using the ULN2003, it is crucial to ensure proper connection of the stepper motor phases to the output pins of the ULN2003. Each output pin corresponds to a specific phase of the motor, and the sequence of activation must be carefully controlled to enable smooth rotation. The internal clamp diodes are particularly beneficial in protecting the circuit from back EMF generated by the inductive loads, ensuring reliable operation.
In contrast, when utilizing TIP120 transistors for higher current applications, a careful layout and sufficient heat sinking are essential to prevent overheating. The wiring complexity increases as four TIP120 transistors are generally required to control a bipolar stepper motor, necessitating additional consideration for signal integrity and power distribution in the circuit design.
In summary, both the ULN2003 and TIP120 offer unique advantages for driving stepper motors, and the choice between them should be based on the specific current requirements and operational conditions of the application. Proper circuit design and component selection are critical to achieving optimal performance and reliability in stepper motor control systems.The simplest way to drive stepper motor having lower current rating is using ULN2003. The ULN2003 contains seven darlington transistors. The ULN2003 can pass upto 500mA per channel and has an internal voltage drop of about 1V when on. It also contains internal clamp diodes to dissipate voltage spikes when driving inductive loads. The circuit for driving stepper motor using ULN2003 is shown below. For higher current torque motors, you can use TIP120. The advantage is that the TIP120 can pass more current along with heat sink. The disadvantages are that the more wiring is required and four TIP120 is used to control the motor.
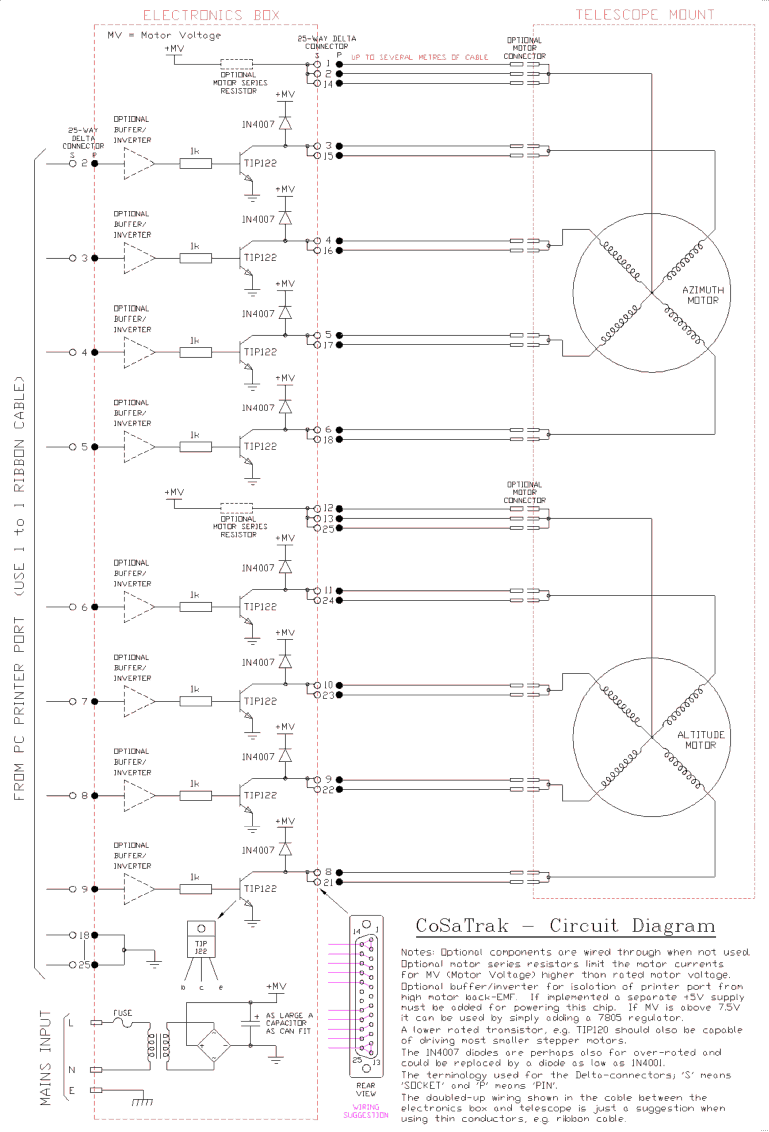
CoSaTrak drive satellite tracking circuit
The back EMF voltage spikes produced by stepper motors, especially higher voltage motors, can damage a PC's printer port if connections are made incorrectly, flyback diodes are absent, or connected in reverse. The safest options are opto-isolated or buffered/inverted circuits....
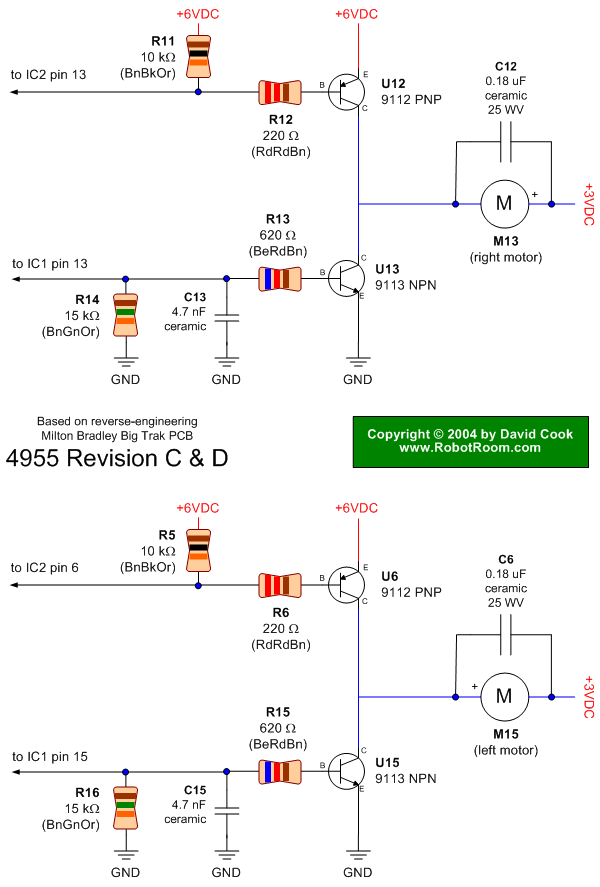
Big Trak Motor Driver Schematic
Schematic of Big Trak's motor driver circuit. The toy includes 9112 and 9113 transistors (and sometimes 2N6715) because the 75494 chip cannot supply enough current to run the Big Trak's motors by itself.
The motor driver circuit for the Big Trak...
Stepper Motor Control Circuit
This circuit is not visually appealing nor easy to implement, requiring considerable effort. The stepper motor consists of two coils, necessitating the use of two LMD18245 chips to manage the current flow through these coils. It is noteworthy that motor...
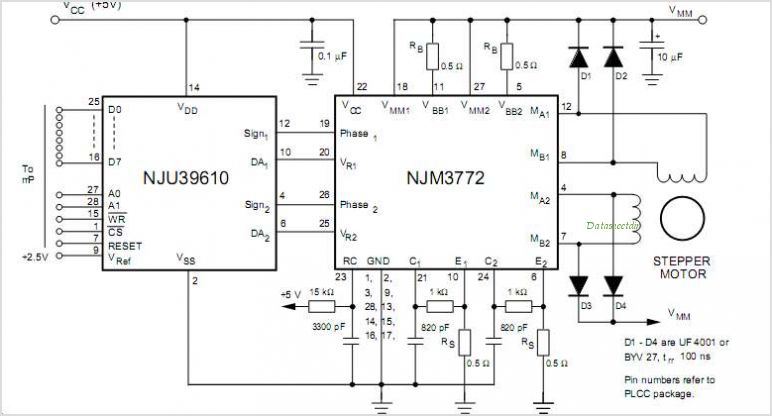
NJM3772 NJM3772 DUAL STEPPER MOTOR DRIVER
This device is a two-line audio EMI filter array designed for speaker applications. It provides greater than 35 dB attenuation at frequencies ranging from 800 MHz to 3.0 GHz. Additionally, this device offers ESD protection by clamping transients from static...
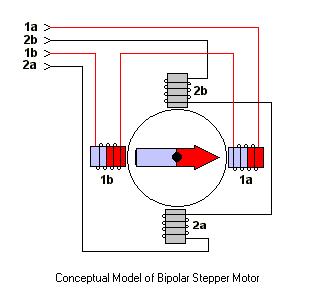
stepper motor controlling using uln2003
The ULN2003 features high voltage, high current Darlington arrays, each consisting of seven open collector Darlington pairs with common emitters.
The ULN2003 is a versatile integrated circuit designed for driving high-current loads such as relays, motors, and lamps. It operates...
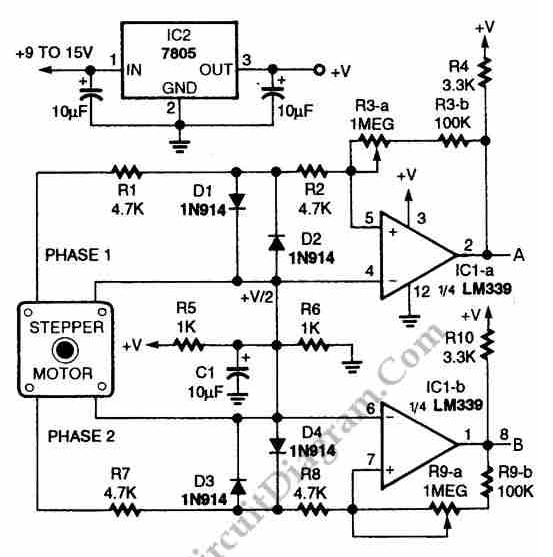
Digital Encoder Circuit diagram Using Stepper Motor
The circuit illustrated in the schematic diagram below allows for the visualization of the direction and shaft rotation of a stepper motor on an LED display. Instead of utilizing a digital rotation encoder as an input, this circuit employs a...
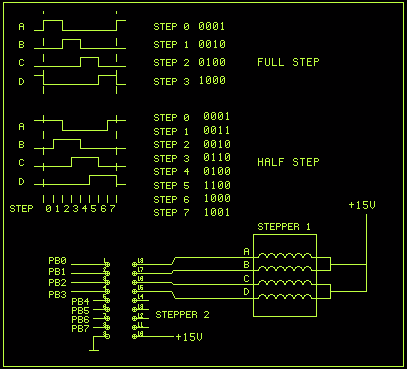
Stepper Motor controller with HC11
PID-Control with 68HC11. STEPPER CONTROL. 68HC11 read encoder. High accuracy RPM-measurement with 68HC11. The encoder is connected to PORTA PA0 and PA1. The board must be in BOOTSTRAP MODE (tested with Loggyboard).
The circuit utilizes a 68HC11 microcontroller for implementing a...
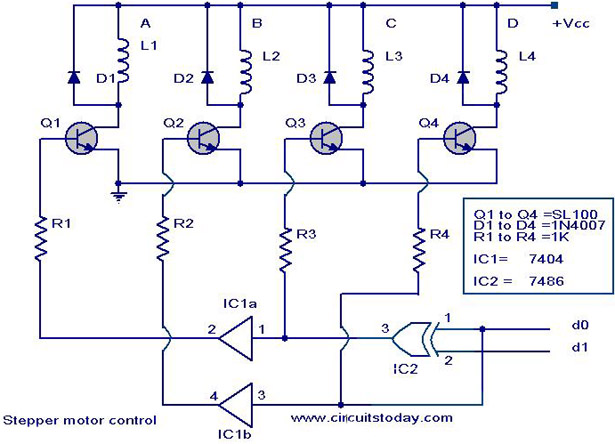
Stepper motor controller - Driver circuit with circuit design
The circuit diagram illustrates a simple stepper motor controller utilizing basic components. The driver circuit employs four SL100 transistors to control the motor windings, along with two NOT gates and one XOR gate to decode the two-bit control logic needed...
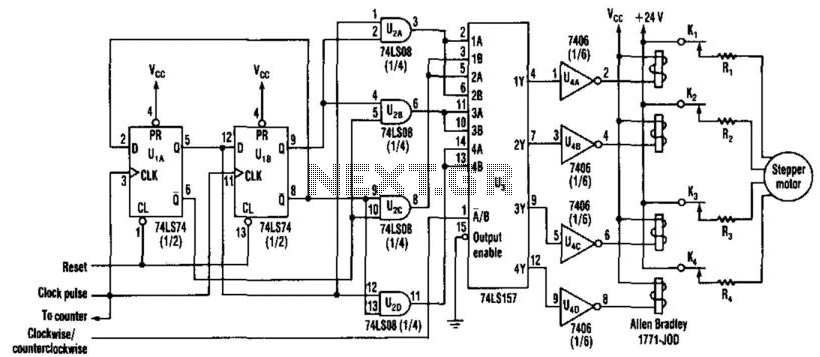
Stepper Motor Speed And Direction Controller
This new circuit utilizes four integrated circuits, with the option to operate with just three by combining the flip-flops and AND gates. The frequency of clock pulses dictates the revolutions per minute (RPM) of the motor. The circuit can enhance...