


Digital Encoder Circuit diagram Using Stepper Motor
#stepper motor
#digital encoder
#LED display
#rotation control
#schematic diagram
#direction control
#shaft rotation
#motor driver
#circuit design
#encoder input
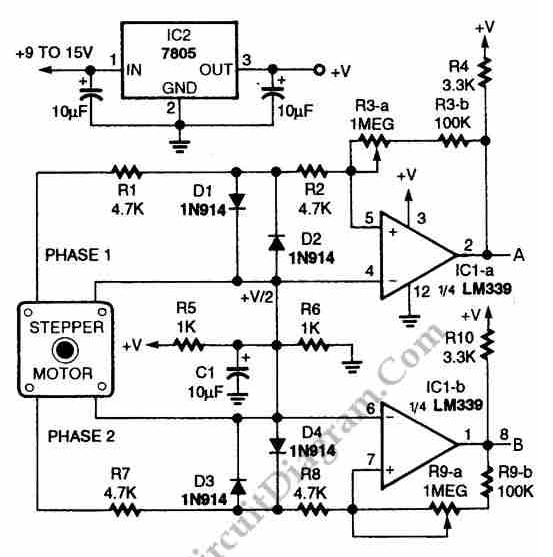
Description: The circuit illustrated in the schematic diagram below allows for the visualization of the direction and shaft rotation of a stepper motor on an LED display. Instead of utilizing a digital rotation encoder as an input, this circuit employs a stepper motor. The schematic diagram of the circuit is provided below.
The described circuit integrates a stepper motor with an LED display to provide real-time feedback on the motor's rotational direction and position. The stepper motor operates through a series of discrete steps, allowing for precise control of its rotation. In this configuration, the motor's rotation is monitored by a microcontroller, which interprets the signals from the motor and translates them into visual information displayed on the LED screen.
The schematic typically includes the stepper motor, a microcontroller (such as an Arduino or similar device), and the LED display. The microcontroller is programmed to control the stepper motor's operation, sending pulse signals to the motor driver, which in turn energizes the motor coils in a specific sequence. This sequential energization causes the motor to rotate in defined steps, either clockwise or counterclockwise.
The LED display is interfaced with the microcontroller to show the current position of the motor shaft. The display can represent the rotation direction with indicators such as arrows or numerical values indicating degrees of rotation. The circuit may also include additional components such as resistors, capacitors, and possibly a power supply to ensure stable operation.
In summary, this circuit is an effective solution for applications requiring precise motor control and visual feedback, allowing users to monitor and adjust the motor's performance in real-time. The schematic diagram serves as a crucial reference for understanding the connections and components involved in the setup.Using circuit depicted in the schematic diagram below, the direction and shaft rotation of stepper motor can be seen on the LED display. Alternative to digital rotation encoder as a digital encoder input, this circuit uses a stepper motor.
Here is the schematic diagram of the circuit:..
The described circuit integrates a stepper motor with an LED display to provide real-time feedback on the motor's rotational direction and position. The stepper motor operates through a series of discrete steps, allowing for precise control of its rotation. In this configuration, the motor's rotation is monitored by a microcontroller, which interprets the signals from the motor and translates them into visual information displayed on the LED screen.
The schematic typically includes the stepper motor, a microcontroller (such as an Arduino or similar device), and the LED display. The microcontroller is programmed to control the stepper motor's operation, sending pulse signals to the motor driver, which in turn energizes the motor coils in a specific sequence. This sequential energization causes the motor to rotate in defined steps, either clockwise or counterclockwise.
The LED display is interfaced with the microcontroller to show the current position of the motor shaft. The display can represent the rotation direction with indicators such as arrows or numerical values indicating degrees of rotation. The circuit may also include additional components such as resistors, capacitors, and possibly a power supply to ensure stable operation.
In summary, this circuit is an effective solution for applications requiring precise motor control and visual feedback, allowing users to monitor and adjust the motor's performance in real-time. The schematic diagram serves as a crucial reference for understanding the connections and components involved in the setup.Using circuit depicted in the schematic diagram below, the direction and shaft rotation of stepper motor can be seen on the LED display. Alternative to digital rotation encoder as a digital encoder input, this circuit uses a stepper motor.
Here is the schematic diagram of the circuit:..
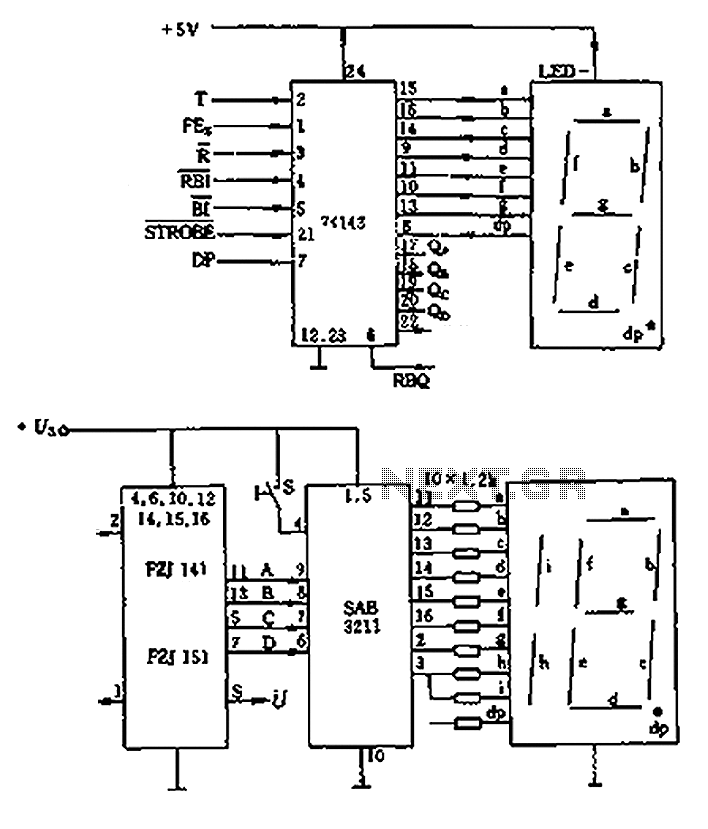
LED display control circuit diagram of a counter
The decimal seven-segment storage decoding drive unit 74HC143 provides a constant output for all segments, each at a voltage of 5V and a current ranging from approximately 15mA to 22mA. The BCD data for the seven-segment decoder can be accessed...
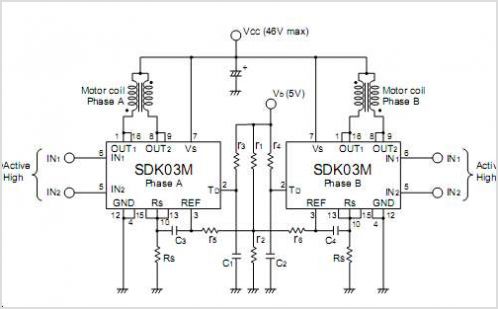
SDK03M 2-Phase Stepper Motor Unipolar Driver ICs
The SM5023 series consists of 3rd overtone crystal oscillator module integrated circuits (ICs). These ICs are equipped with built-in oscillator capacitors that provide excellent frequency response. The cutoff frequency can be configured using an external feedback resistor (Rfo), allowing for...
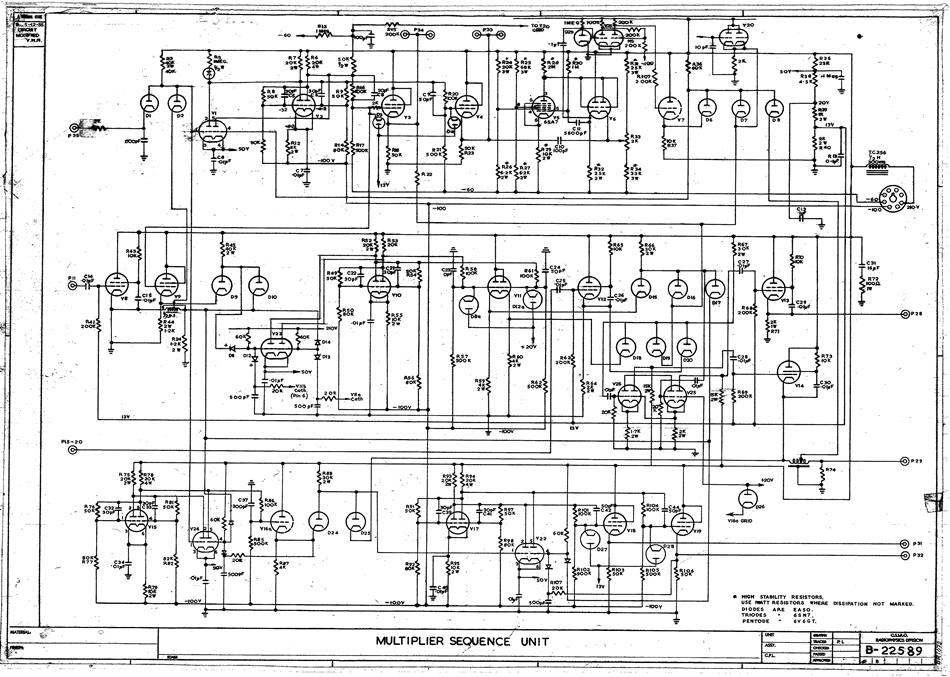
schematic computer multiplier sequence
A hard copy schematic diagram pertaining to the computer CSIRAC. This diagram illustrates the intricate connections among all the components within the circuit. Such diagrams were utilized for circuit construction and subsequent testing. In the case of CSIRAC, the primary...
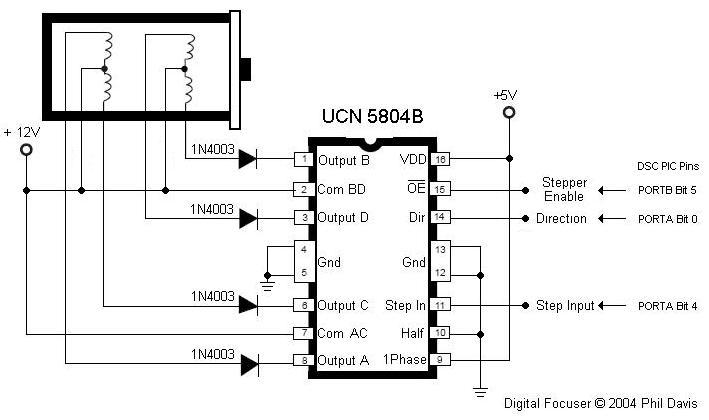
Focusser
Create an electronic focuser to assist with astrophotography. This electronic focuser project enables precise focusing under computer control, which is particularly beneficial for eyepiece projection astrophotography. It was observed that even minor contact with the focuser could displace the object...
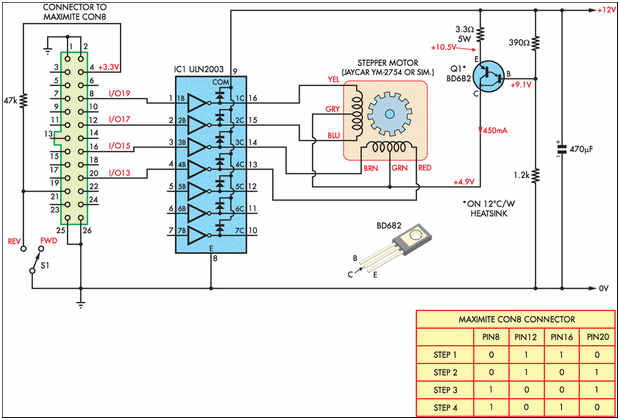
Rotate a stepper motor using a computer
Designing and implementing this circuit was an exciting endeavor. The design of the interface involved learning how to control a device from a computer. A parallel port cable was utilized for this purpose, enabling instant control of the stepper motor....
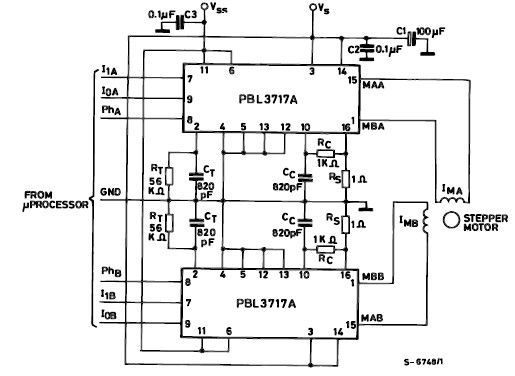
PBL3717A motor stepper driver circuit design electronic project
The PBL3717A stepper motor driver is a monolithic integrated circuit that controls and drives one phase of a bipolar stepper motor utilizing chopper control for phase current regulation. Current levels can be selected in three increments using two logic inputs,...
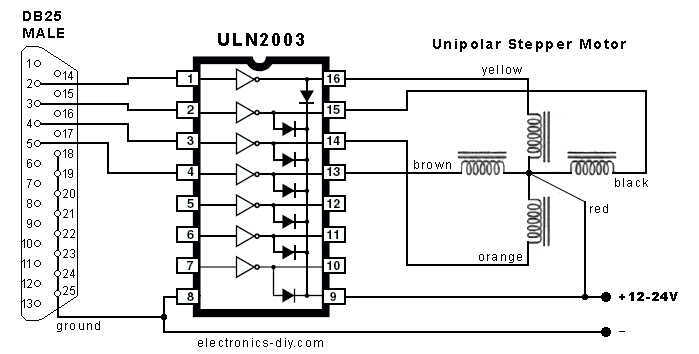
Controlling Stepper Motor with a Parallel Port
This is an easy to build stepper motor driver that will allow you to precisely control a unipolar stepper motor through your computer's parallel port. With a stepper motor you can build a lot of interesting gadgets such as robots,...
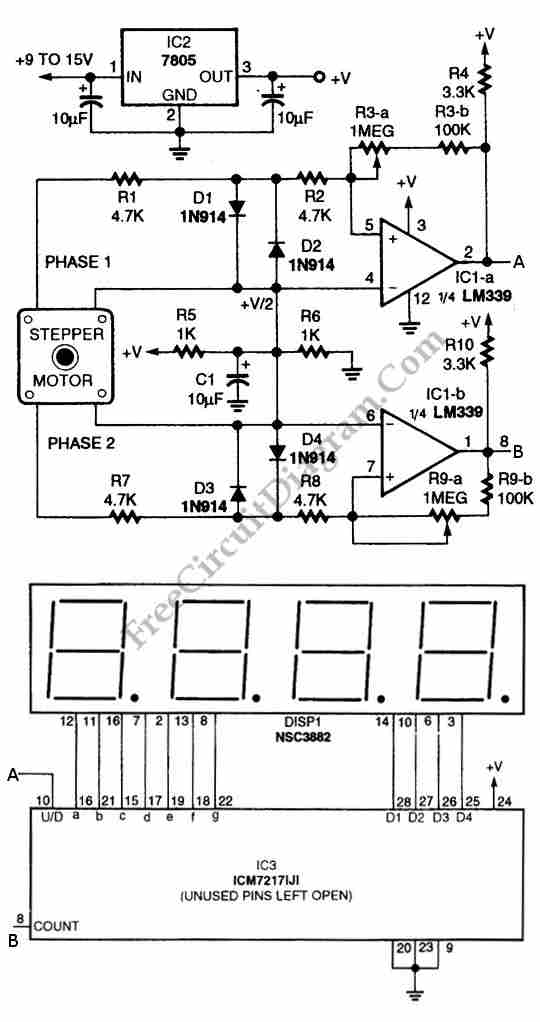
Digital Encoder Circuit Using Stepper Motor
The circuit illustrated in the schematic diagram below allows for the visualization of the direction and shaft rotation of a stepper motor on an LED display. Instead of employing a digital rotation encoder as an input, this circuit utilizes a...
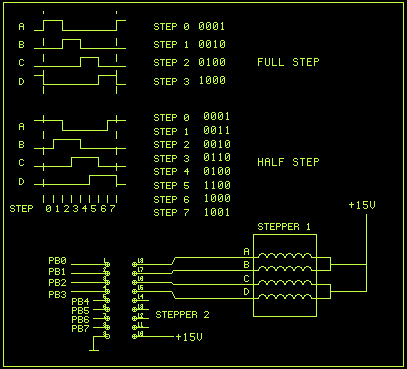
Stepper Motor controller with HC11
PID-Control with 68HC11. STEPPER CONTROL. 68HC11 read encoder. High accuracy RPM-measurement with 68HC11. The encoder is connected to PORTA PA0 and PA1. The board must be in BOOTSTRAP MODE (tested with Loggyboard).
The circuit utilizes a 68HC11 microcontroller for implementing a...