


PBL3717A motor stepper driver circuit design electronic project
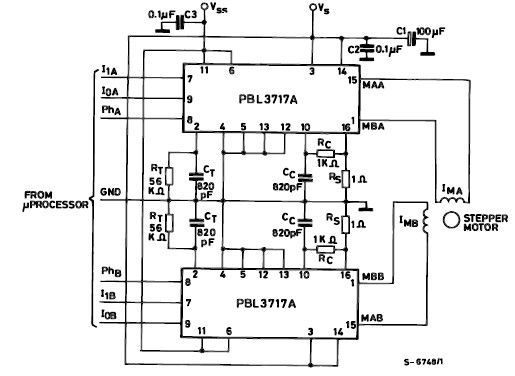
Description: The PBL3717A stepper motor driver is a monolithic integrated circuit that controls and drives one phase of a bipolar stepper motor utilizing chopper control for phase current regulation. Current levels can be selected in three increments using two logic inputs, which determine one of three current comparators. When both inputs are set to high, the device is disabled. An additional logic input governs the direction of current flow. The logic inputs I0 and I1 set the current amplitude in the motor winding at three different levels. A high signal on the "PHASE" logic input directs the current from output A to output B, while a low signal reverses the flow from output B to output A. In this bipolar stepper motor driver configuration, Vss represents the logic power supply, which should be approximately 5 volts, and VS is the motor power supply, required to be between 10 and 46 volts.
The PBL3717A stepper motor driver is designed for precision control of bipolar stepper motors, facilitating a wide range of applications in robotics, automation, and CNC machinery. This integrated circuit employs a chopper control mechanism to regulate the phase current, ensuring smooth operation and reducing the risk of overheating.
The current selection feature, managed by the logic inputs I0 and I1, allows for adaptability to various motor specifications and performance requirements. By selecting one of three current comparators, the user can define the optimal current level for the motor, enhancing efficiency and performance based on the specific load conditions.
The direction control is implemented through the "PHASE" logic input, which effectively reverses the current flow in the motor winding. This capability is crucial for applications requiring bi-directional movement, enabling the motor to step forward or backward as needed. The design also incorporates safety features, as the device disables itself when both current selection inputs are high, preventing accidental activation.
Power supply considerations are vital for the operation of the PBL3717A. The logic power supply, Vss, should be maintained at around 5 volts to ensure proper operation of the logic circuits. Meanwhile, the motor power supply, VS, must be carefully selected within the range of 10 to 46 volts, providing adequate voltage for motor operation while accommodating different motor specifications.
In summary, the PBL3717A stepper motor driver is a robust solution for controlling bipolar stepper motors, combining flexibility in current control with precise direction management, making it suitable for a variety of demanding applications in the field of electronics and automation.The PBL3717A motor stepper driveris a monolithic IC which controls and drives one phase of a bipolar stepper motor with chopper control of the phase current. Current levels may be selected in three steps by means of two logic inputs which select one of three current comparators.
When both of these inputs are high the device is disabled. A separate logic input controls the direction of current flow. The logic inputs I0 and I1 set at three different levels the amplitude of the current flowing in the motor winding. A high level on the "PHASE" logic input sets the direction of that current from output A to output B and a low level from output B to output A.
In this bipolar stepper motor driver project, the Vss is the logic power and must be around 5 volt and VS is the motor power and must be between 10 and 46 volts.
The PBL3717A stepper motor driver is designed for precision control of bipolar stepper motors, facilitating a wide range of applications in robotics, automation, and CNC machinery. This integrated circuit employs a chopper control mechanism to regulate the phase current, ensuring smooth operation and reducing the risk of overheating.
The current selection feature, managed by the logic inputs I0 and I1, allows for adaptability to various motor specifications and performance requirements. By selecting one of three current comparators, the user can define the optimal current level for the motor, enhancing efficiency and performance based on the specific load conditions.
The direction control is implemented through the "PHASE" logic input, which effectively reverses the current flow in the motor winding. This capability is crucial for applications requiring bi-directional movement, enabling the motor to step forward or backward as needed. The design also incorporates safety features, as the device disables itself when both current selection inputs are high, preventing accidental activation.
Power supply considerations are vital for the operation of the PBL3717A. The logic power supply, Vss, should be maintained at around 5 volts to ensure proper operation of the logic circuits. Meanwhile, the motor power supply, VS, must be carefully selected within the range of 10 to 46 volts, providing adequate voltage for motor operation while accommodating different motor specifications.
In summary, the PBL3717A stepper motor driver is a robust solution for controlling bipolar stepper motors, combining flexibility in current control with precise direction management, making it suitable for a variety of demanding applications in the field of electronics and automation.The PBL3717A motor stepper driveris a monolithic IC which controls and drives one phase of a bipolar stepper motor with chopper control of the phase current. Current levels may be selected in three steps by means of two logic inputs which select one of three current comparators.
When both of these inputs are high the device is disabled. A separate logic input controls the direction of current flow. The logic inputs I0 and I1 set at three different levels the amplitude of the current flowing in the motor winding. A high level on the "PHASE" logic input sets the direction of that current from output A to output B and a low level from output B to output A.
In this bipolar stepper motor driver project, the Vss is the logic power and must be around 5 volt and VS is the motor power and must be between 10 and 46 volts.
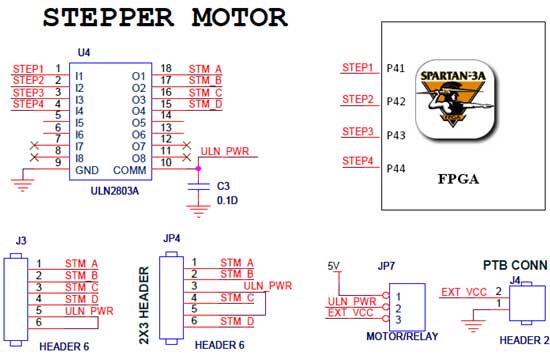
stepper motor interfacing with spartan 3an fpga
The Spartan-3an board features external interfacing for stepper motors, as illustrated in the accompanying figure. The stepper motor is driven by the ULN2803A, which is a high-voltage, high-current Darlington transistor array. The ULN2803 serves as a driver for the port...
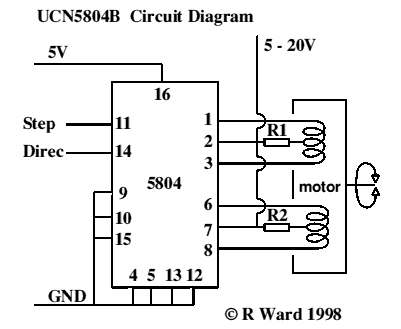
Unipolar Stepper Motor Controller Circuit
This integrated circuit is highly efficient and does not require any external glue logic for operation. It features two pins to control a motor: one for direction and the other for stepping pulse triggers. The design is compact and compatible...
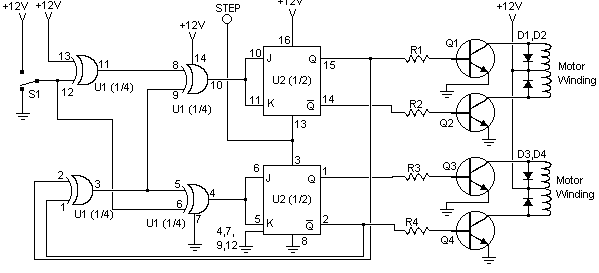
Stepper Motor Controllers
The circuit is straightforward and cost-effective. This is advantageous since most commercially available stepper motor controller ICs tend to be quite pricey. It is constructed using standard components and can be easily modified for computer control. By utilizing inexpensive surplus...
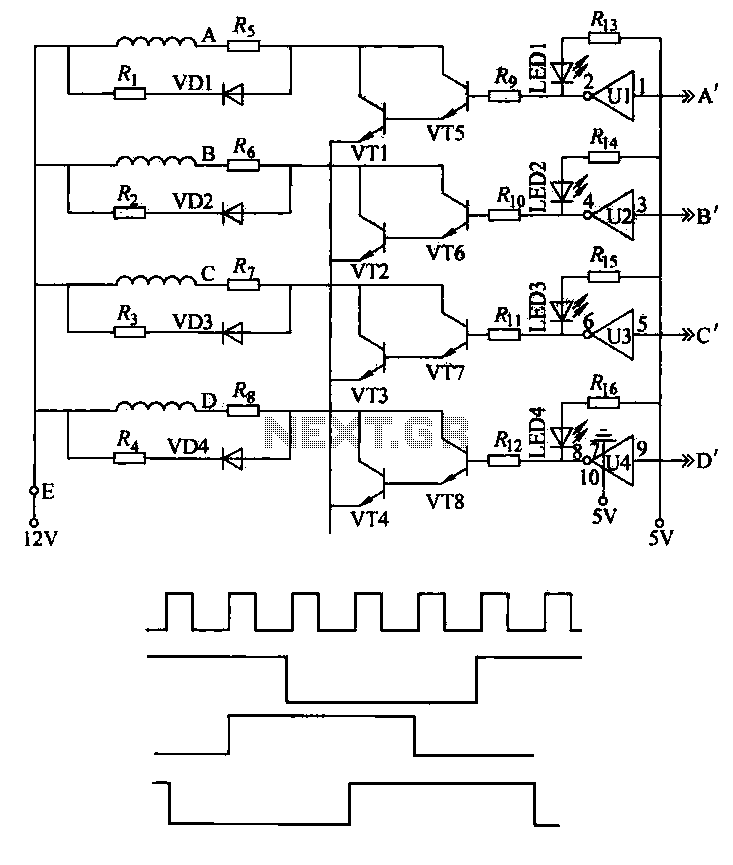
Stepper motor control circuit
This machine utilizes the FD-CAS-923 1-stepper motor control experiment board with a 4-phase stepper motor to avoid its schematic shown in Figure 4-42a. The JK1 cop 40 core flat cable connector allows for signal arrangements compatible with EICE51 simulation interfaces,...
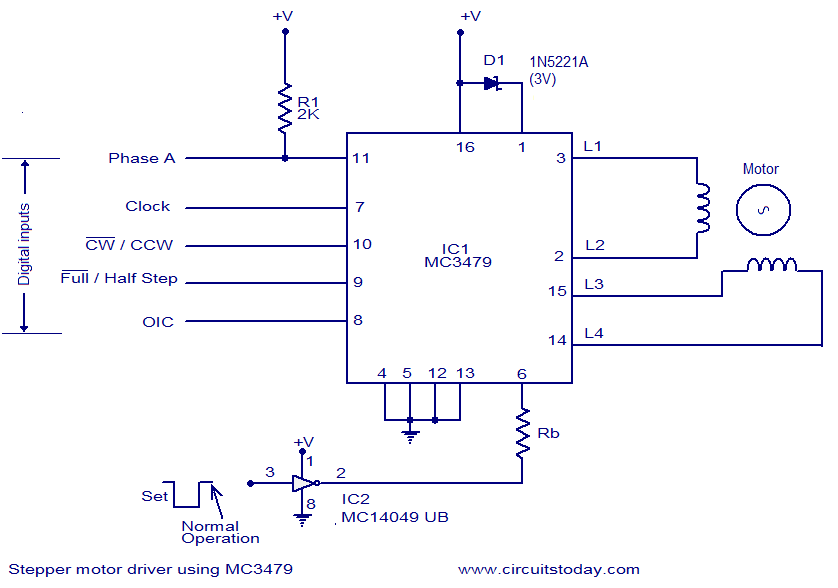
Stepper motor driver using MC3479
The circuit diagram presented is for a stepper motor driver utilizing the MC3479 integrated circuit from Motorola. The MC3479 is specifically engineered for driving a two-phase stepper motor in bipolar mode and is available in both standard DIP and surface...
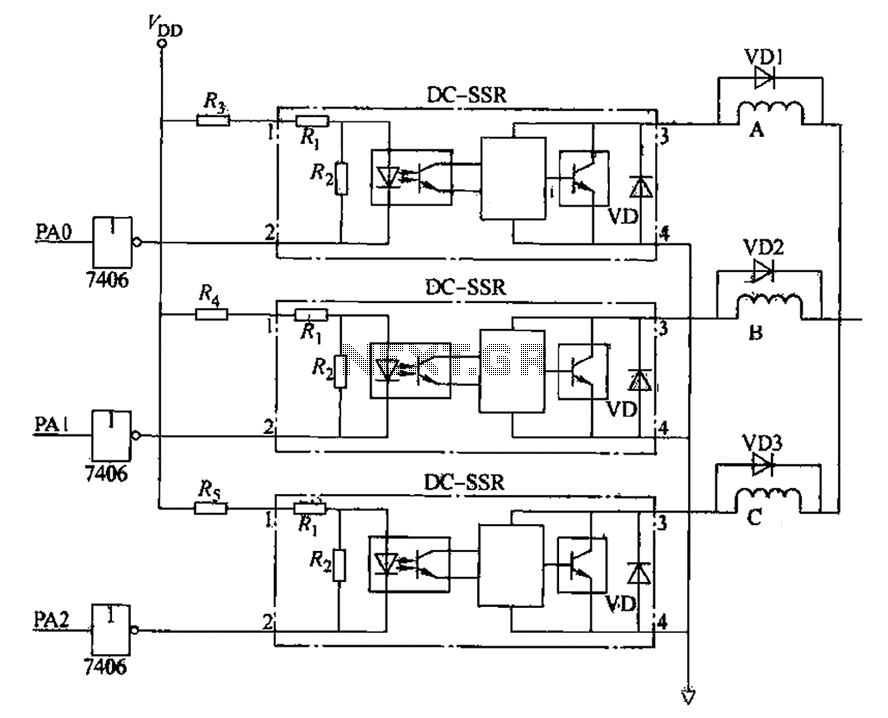
Three-phase stepper motor control circuit
The figure illustrates that the DC Solid State Relay (SSR) in the input stage functions as an opto-isolator. When the switch output is high, the driver circuit inverts this signal to low. This process involves a light-emitting diode (LED) where...
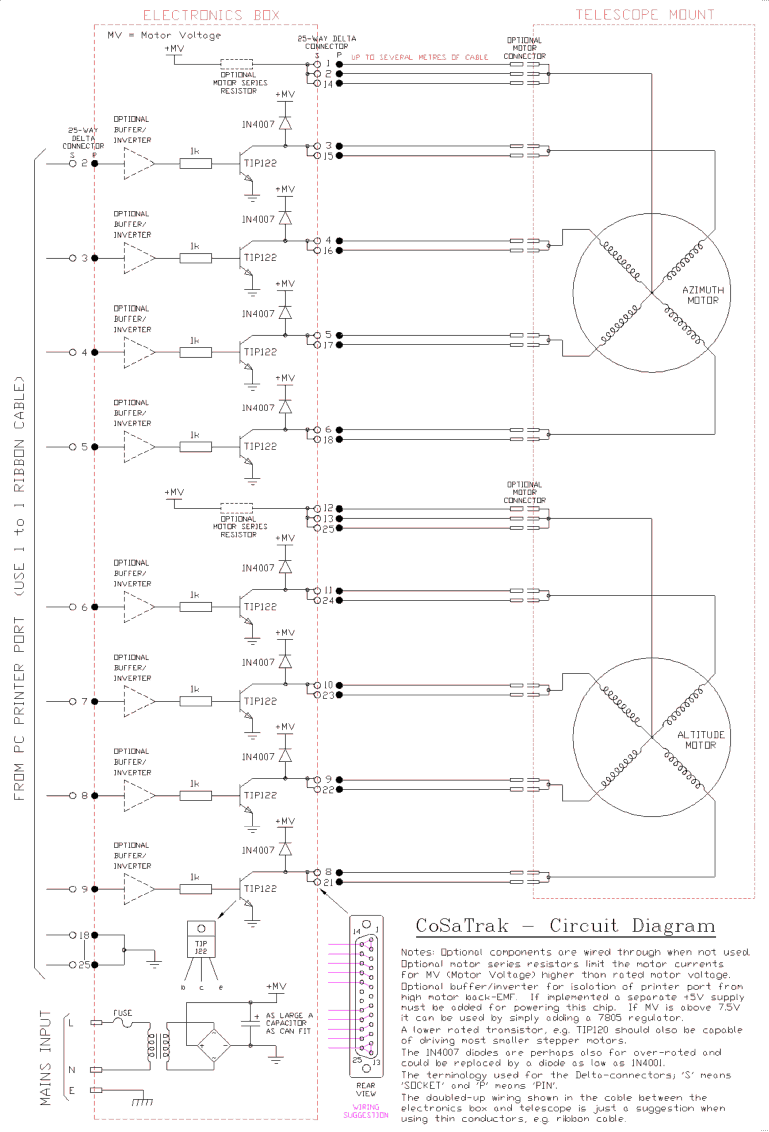
CoSaTrak drive satellite tracking circuit
The back EMF voltage spikes produced by stepper motors, especially higher voltage motors, can damage a PC's printer port if connections are made incorrectly, flyback diodes are absent, or connected in reverse. The safest options are opto-isolated or buffered/inverted circuits....
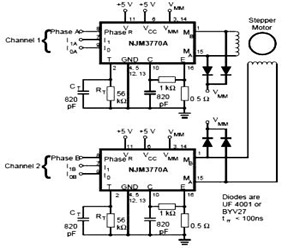
Synchronizing NJM3770A Stepper Motor Driver
The schematic below represents a typical stepper motor driver application utilizing the NJM3770A. As illustrated in the diagram, the single-channel stepper motor drivers NJM3717 and NJM3770A operate independently and are not synchronized.
The circuit design features the NJM3770A, a dedicated stepper...
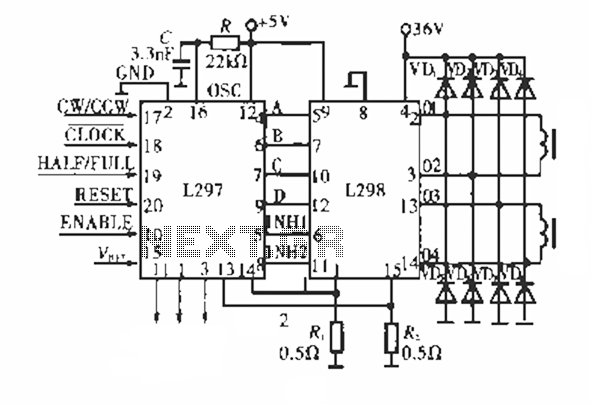
Bipolar stepper motor driver module circuit
The circuit operates using a dedicated stepping motor controller, the L297. Pin 17 (CW/CCW) is utilized to control the rotation direction of the stepper motor. Pin 18 (CLOCK) regulates the speed of the stepper motor, while pin 19 (HALF/FULL) allows...