


Unipolar Stepper Motor Controller Circuit
#stepper motor
#motor driver
#compact design
#direction control
#stepping pulses
#integrated circuit
#5-wire
#6-wire
#8-wire
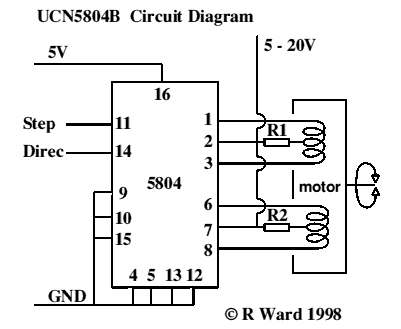
Description: This integrated circuit is highly efficient and does not require any external glue logic for operation. It features two pins to control a motor: one for direction and the other for stepping pulse triggers. The design is compact and compatible with 5, 6, or 8 wire stepper motors. The 5 and 8 wire motors are variations of the 6 wire motor, where the 5 wire motor has its two common wires from the coil center taps connected internally, eliminating the need for external connections. Some confusion may arise regarding which ends of the coils to connect; however, experimentation will not cause any damage. For the 8 wire motors, identifying the joined center taps requires user determination, and experimentation may be necessary to establish polarity. Resistors R1 and R2 are required only if the supply voltage exceeds approximately 10 volts and are primarily used for tuning motor response times at high speeds. Refer to the datasheets for further details. Six wire motors are widely available, making connections straightforward. These motors are commonly used in applications requiring significant power, such as printers. Non-functional dot matrix printers are often available and provide excellent opportunities for experimentation, along with additional components like belts, pulleys, gears, and possibly a power supply.
The integrated circuit operates as a stepper motor driver, capable of controlling motor functions with minimal external components. The two pins dedicated to motor control simplify the design and reduce the need for complex circuitry. The ability to drive 5, 6, or 8 wire stepper motors makes this circuit versatile for various applications. In 5 wire motors, the internal joining of common wires streamlines setup, while the 8 wire motors offer flexibility but require careful identification of coil connections.
The resistors R1 and R2 play a critical role in ensuring optimal performance when operating at higher voltages. They help in managing the current flow, which is essential for maintaining the integrity of the motor's operation at elevated speeds. The use of datasheets is crucial for understanding the specific requirements and limitations of the circuit, particularly regarding voltage ratings and resistance values.
The prevalence of six wire stepper motors in the market ensures accessibility for prototyping and experimentation. These motors are particularly suited for applications that demand reliable torque and precision, making them ideal for robotics, CNC machines, and various automation tasks. Repurposing components from obsolete dot matrix printers not only provides an economical solution for hobbyists and engineers but also contributes to sustainable practices by reusing electronic waste. The availability of additional components such as belts and gears enhances the potential for creating functional prototypes, facilitating hands-on learning and innovation in stepper motor applications.This is a very good integrated circuit. There is no need for any external glue logic to drive the circuit, there is only 2 pins to drive the motor, one for controlling the direction and the other to trigger the stepping pulses. It provides a very compact design that drives 5 or 6 or 8 wire stepper motors. The 5 or 8 wire stepper motors are treated as a variation on the 6 wire motor. That is, the 5 has the two common wires from the coils center taps joined inside the motor (saves joining them outside the motor), however some confusion may occur with the ends of the other coils as to which joins with which, however trial and error to determine this will not hurt anything. In the 8 wire motor case the joined center taps will have to worked out by you. You will know which coil is joined to which coil, however experimentation may be required to determine polarity.
The resistors R1 & R2 are only necessary if the supply voltage to the motors is above 10 volts or so, and are really only necessary near max voltages and tuning the response times of the motor for high speeds. See data sheets for details. There should be very little problem getting hold of six wire motors that make the connections obvious.
These motors are by far the most common where any degree of power is required, e. g. in printers. Non-working dot matrix printers are fairly common now-a-days and the motors in them are excellent starting points for experimentation. You will also get belts, pulleys and gears thrown in (may be even a power supply if your are adventurous).
The integrated circuit operates as a stepper motor driver, capable of controlling motor functions with minimal external components. The two pins dedicated to motor control simplify the design and reduce the need for complex circuitry. The ability to drive 5, 6, or 8 wire stepper motors makes this circuit versatile for various applications. In 5 wire motors, the internal joining of common wires streamlines setup, while the 8 wire motors offer flexibility but require careful identification of coil connections.
The resistors R1 and R2 play a critical role in ensuring optimal performance when operating at higher voltages. They help in managing the current flow, which is essential for maintaining the integrity of the motor's operation at elevated speeds. The use of datasheets is crucial for understanding the specific requirements and limitations of the circuit, particularly regarding voltage ratings and resistance values.
The prevalence of six wire stepper motors in the market ensures accessibility for prototyping and experimentation. These motors are particularly suited for applications that demand reliable torque and precision, making them ideal for robotics, CNC machines, and various automation tasks. Repurposing components from obsolete dot matrix printers not only provides an economical solution for hobbyists and engineers but also contributes to sustainable practices by reusing electronic waste. The availability of additional components such as belts and gears enhances the potential for creating functional prototypes, facilitating hands-on learning and innovation in stepper motor applications.This is a very good integrated circuit. There is no need for any external glue logic to drive the circuit, there is only 2 pins to drive the motor, one for controlling the direction and the other to trigger the stepping pulses. It provides a very compact design that drives 5 or 6 or 8 wire stepper motors. The 5 or 8 wire stepper motors are treated as a variation on the 6 wire motor. That is, the 5 has the two common wires from the coils center taps joined inside the motor (saves joining them outside the motor), however some confusion may occur with the ends of the other coils as to which joins with which, however trial and error to determine this will not hurt anything. In the 8 wire motor case the joined center taps will have to worked out by you. You will know which coil is joined to which coil, however experimentation may be required to determine polarity.
The resistors R1 & R2 are only necessary if the supply voltage to the motors is above 10 volts or so, and are really only necessary near max voltages and tuning the response times of the motor for high speeds. See data sheets for details. There should be very little problem getting hold of six wire motors that make the connections obvious.
These motors are by far the most common where any degree of power is required, e. g. in printers. Non-working dot matrix printers are fairly common now-a-days and the motors in them are excellent starting points for experimentation. You will also get belts, pulleys and gears thrown in (may be even a power supply if your are adventurous).
Stepper
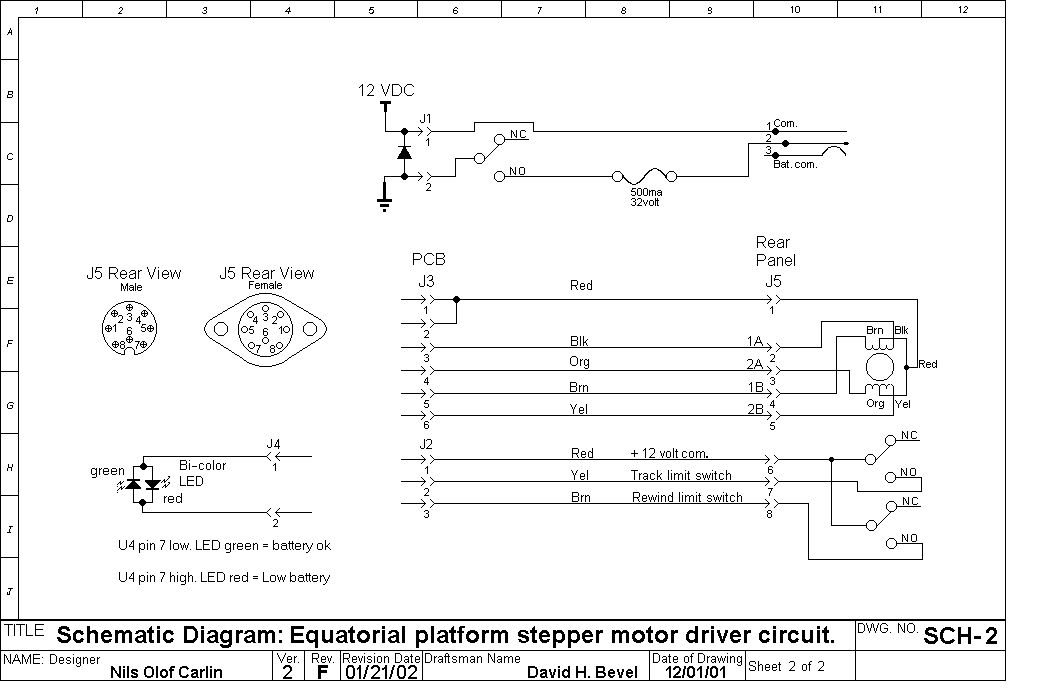
The resistors R18 and R22, which were intended to be connected to pin 8 of U4, were incorrectly connected to pin 9. The current versions have been corrected. There is a minor error in the component layout where two versions...
Stepper Motor Driver
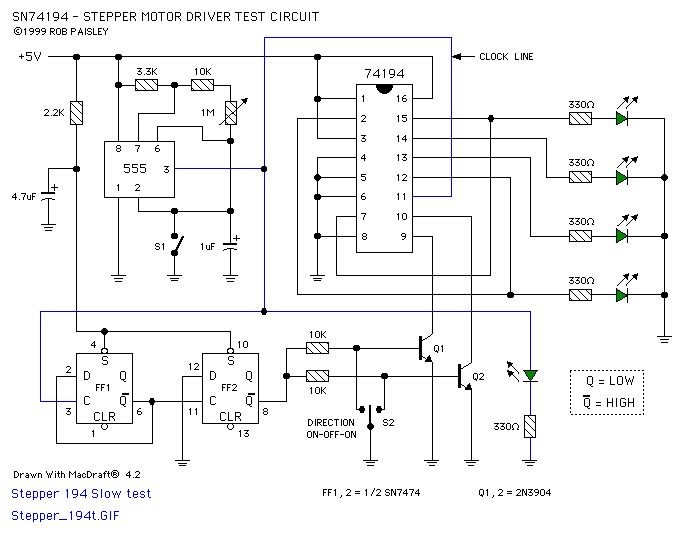
The circuit is based on the SN74LS194 Bidirectional Universal Shift Register and is designed to drive unipolar stepper motors, providing basic control functions such as forward, reverse, stop, and speed adjustment. Direction control is selected by an ON-OFF-ON type toggle...
SDK03M 2-Phase Stepper Motor Unipolar Driver ICs
The SM5023 series consists of 3rd overtone crystal oscillator module integrated circuits (ICs). These ICs are equipped with built-in oscillator capacitors that provide excellent frequency response. The cutoff frequency can be configured using an external feedback resistor (Rfo), allowing for...
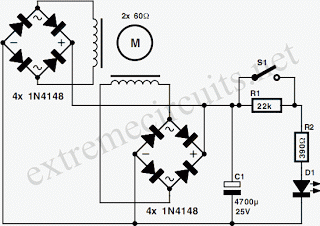
Stepper Motor Generator
Any stepper motor can be utilized as a generator. Unlike other types of generators, a stepper motor generates a significant induced voltage even at low rotational speeds.
A stepper motor operates by converting electrical energy into mechanical motion through a series...
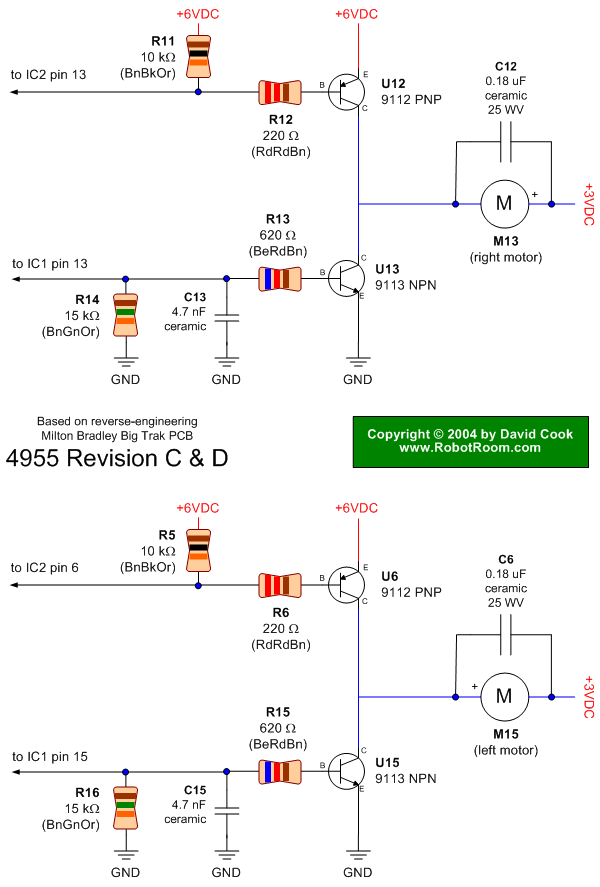
Big Trak Motor Driver Schematic
Schematic of Big Trak's motor driver circuit. The toy includes 9112 and 9113 transistors (and sometimes 2N6715) because the 75494 chip cannot supply enough current to run the Big Trak's motors by itself.
The motor driver circuit for the Big Trak...
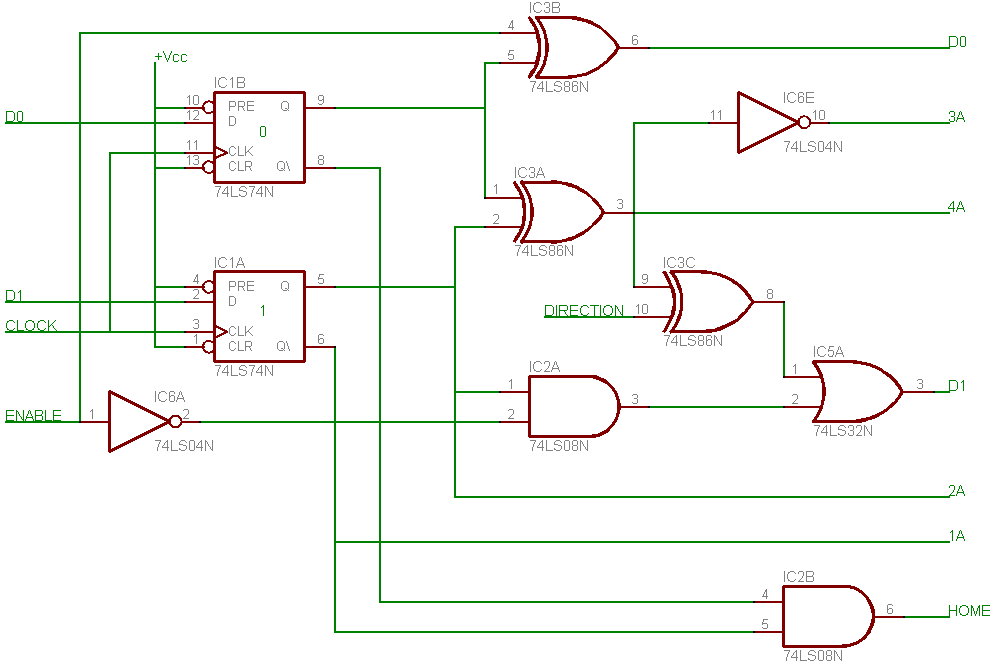
This paper describes the process by which a control circuit for a stepper-motor was designed
This document outlines the design process of a control circuit for a stepper motor. Given the characteristics of the stepper motor, the control circuit was developed as a state machine that transitions through four output states depending on two input...
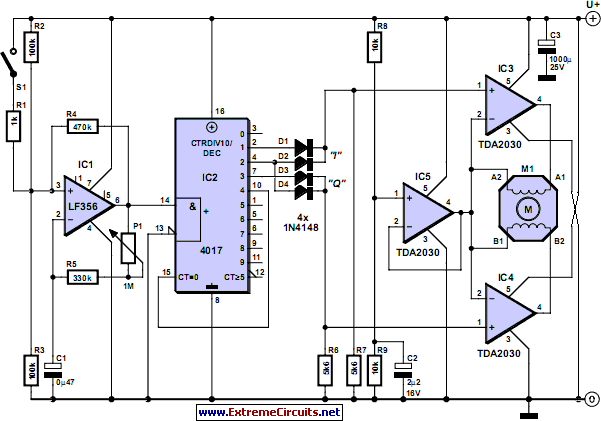
stepper motor controller
Stepper motors come in various versions and sizes, accommodating a range of operating voltages. This general-purpose controller is capable of functioning with voltages from approximately 5 V to 18 V, driving the motor with a peak voltage equal to half...
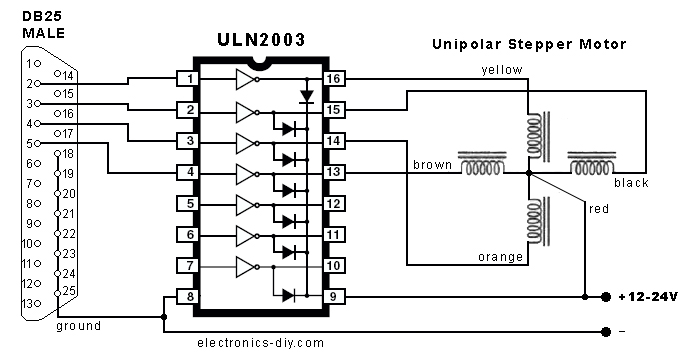
Current amplification for driving stepper motor
In the search for stepper drivers, the ULN2003 chip was discovered, which facilitates motor operation with minimal circuitry through the parallel port of a PC. However, the current output from the ULN2003 is limited to 500mA, resulting in low torque,...
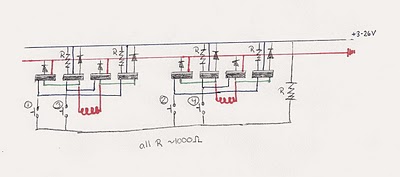
Bipolar Stepper Motor circuit
There was difficulty in understanding that the Source pin connects to low voltage (source of electrons) and the Drain pin connects to high voltage (absorbs electrons). This concept is fundamental to basic electricity, but it required some time to comprehend.
In...