


This paper describes the process by which a control circuit for a stepper-motor was designed
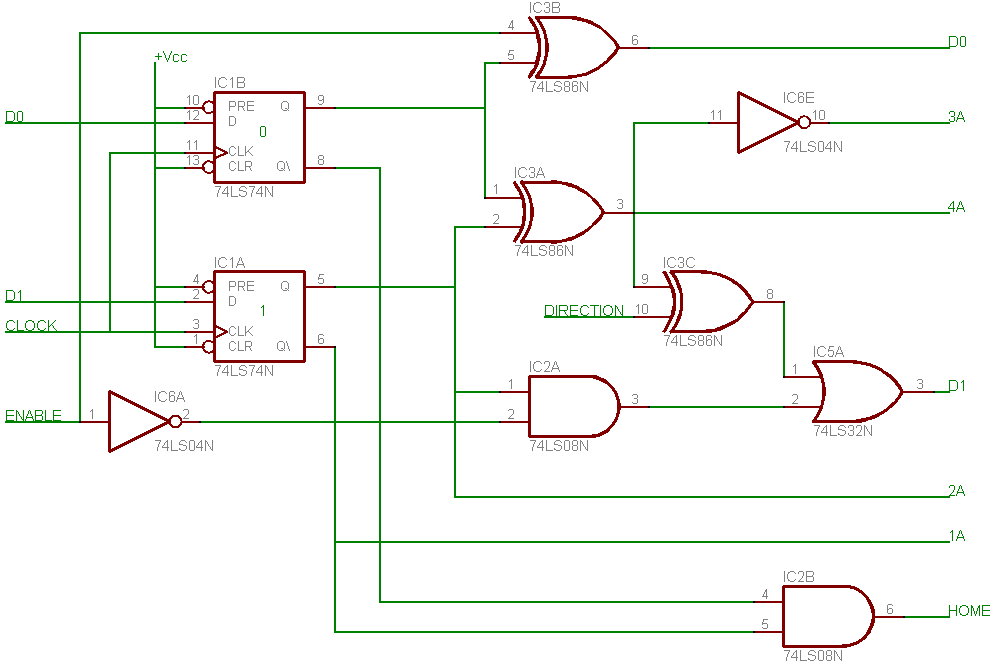
Description: This document outlines the design process of a control circuit for a stepper motor. Given the characteristics of the stepper motor, the control circuit was developed as a state machine that transitions through four output states depending on two input conditions: direction and enable.
The control circuit for the stepper motor is fundamentally structured as a finite state machine (FSM), which effectively manages the sequencing of the motor's movements. The state machine architecture allows for precise control over the motor's stepping behavior, crucial for applications requiring high accuracy and repeatability.
In this design, the two input conditions play a vital role. The "direction" input determines the rotational direction of the stepper motor, allowing it to move either clockwise or counterclockwise. The "enable" input serves to activate or deactivate the motor control, ensuring that the motor only operates when required.
The state machine comprises four distinct states, each corresponding to a specific step in the motor's operation. These states are typically labeled as State 0, State 1, State 2, and State 3. Each state transition is triggered by the combination of the input signals, which dictates the next state based on the current state.
For example, if the motor is in State 0 and the direction input indicates a clockwise movement while the enable input is active, the state machine transitions to State 1. This process continues through the states, with each transition resulting in a specific output signal sent to the motor driver, which ultimately controls the motor's coils to achieve the desired movement.
The design of the control circuit may utilize various electronic components, including microcontrollers or dedicated state machine ICs, to implement the logic required for state transitions. Additionally, feedback mechanisms can be integrated into the circuit to monitor the motor's position, further enhancing the control precision.
Overall, this stepper motor control circuit design exemplifies the application of state machine principles in electronic engineering, providing a robust solution for controlling stepper motors in a variety of automation and robotics applications.This paper describes the process by which a control circuit for a stepper-motor was designed. Due to the nature of the stepper motor, the control circuit had to be a state machine that cycled through four output states based on two input conditions (direction and enable)
The control circuit for the stepper motor is fundamentally structured as a finite state machine (FSM), which effectively manages the sequencing of the motor's movements. The state machine architecture allows for precise control over the motor's stepping behavior, crucial for applications requiring high accuracy and repeatability.
In this design, the two input conditions play a vital role. The "direction" input determines the rotational direction of the stepper motor, allowing it to move either clockwise or counterclockwise. The "enable" input serves to activate or deactivate the motor control, ensuring that the motor only operates when required.
The state machine comprises four distinct states, each corresponding to a specific step in the motor's operation. These states are typically labeled as State 0, State 1, State 2, and State 3. Each state transition is triggered by the combination of the input signals, which dictates the next state based on the current state.
For example, if the motor is in State 0 and the direction input indicates a clockwise movement while the enable input is active, the state machine transitions to State 1. This process continues through the states, with each transition resulting in a specific output signal sent to the motor driver, which ultimately controls the motor's coils to achieve the desired movement.
The design of the control circuit may utilize various electronic components, including microcontrollers or dedicated state machine ICs, to implement the logic required for state transitions. Additionally, feedback mechanisms can be integrated into the circuit to monitor the motor's position, further enhancing the control precision.
Overall, this stepper motor control circuit design exemplifies the application of state machine principles in electronic engineering, providing a robust solution for controlling stepper motors in a variety of automation and robotics applications.This paper describes the process by which a control circuit for a stepper-motor was designed. Due to the nature of the stepper motor, the control circuit had to be a state machine that cycled through four output states based on two input conditions (direction and enable)
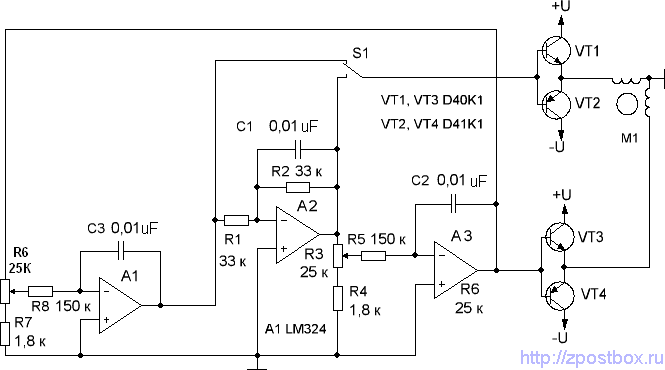
Bipolar stepper motor driver circuit diagram
This circuit generates the power required to operate a bipolar stepper motor. It allows for adjustments in both the rotation speed and direction of the motor. The design includes two integrator circuits (A1, A3) and an amplifier (A2) connected in...
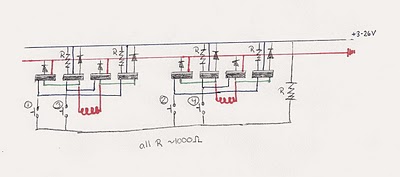
Bipolar Stepper Motor circuit
There was difficulty in understanding that the Source pin connects to low voltage (source of electrons) and the Drain pin connects to high voltage (absorbs electrons). This concept is fundamental to basic electricity, but it required some time to comprehend.
In...
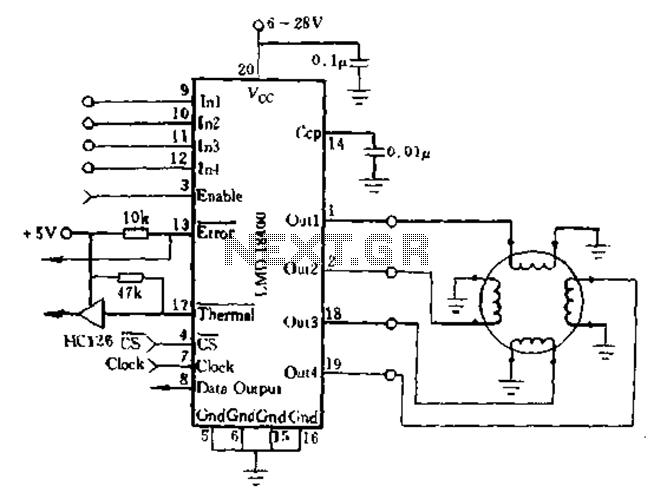
LMD18400 for four-phase stepper motor drive
The DMOS power switch exhibits an ON-state resistance with a positive temperature coefficient, allowing for the parallel connection of four switches to increase load current, resulting in a monolithic design. The LMD18400 can drive one, two, or four small DC...
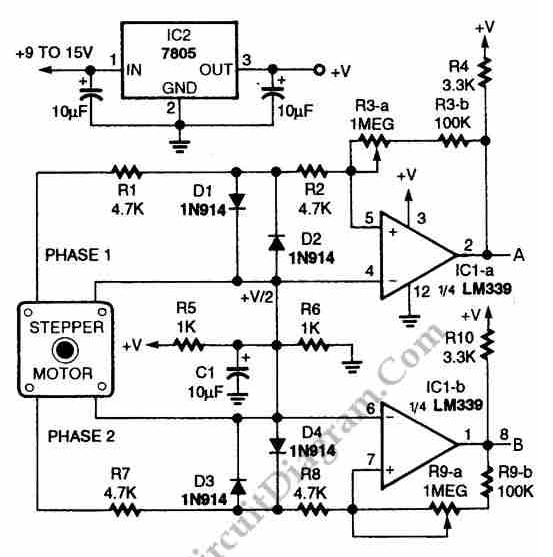
Digital Encoder Circuit diagram Using Stepper Motor
The circuit illustrated in the schematic diagram below allows for the visualization of the direction and shaft rotation of a stepper motor on an LED display. Instead of utilizing a digital rotation encoder as an input, this circuit employs a...
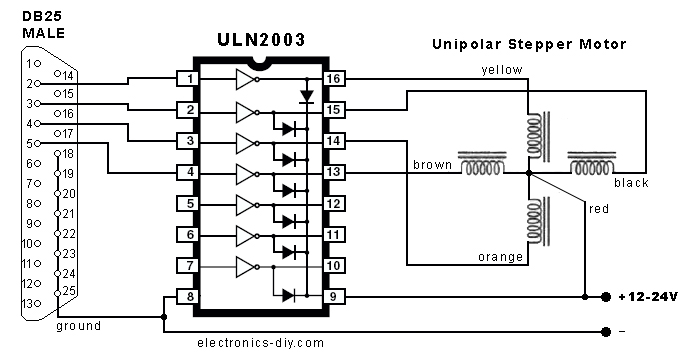
Current amplification for driving stepper motor
In the search for stepper drivers, the ULN2003 chip was discovered, which facilitates motor operation with minimal circuitry through the parallel port of a PC. However, the current output from the ULN2003 is limited to 500mA, resulting in low torque,...
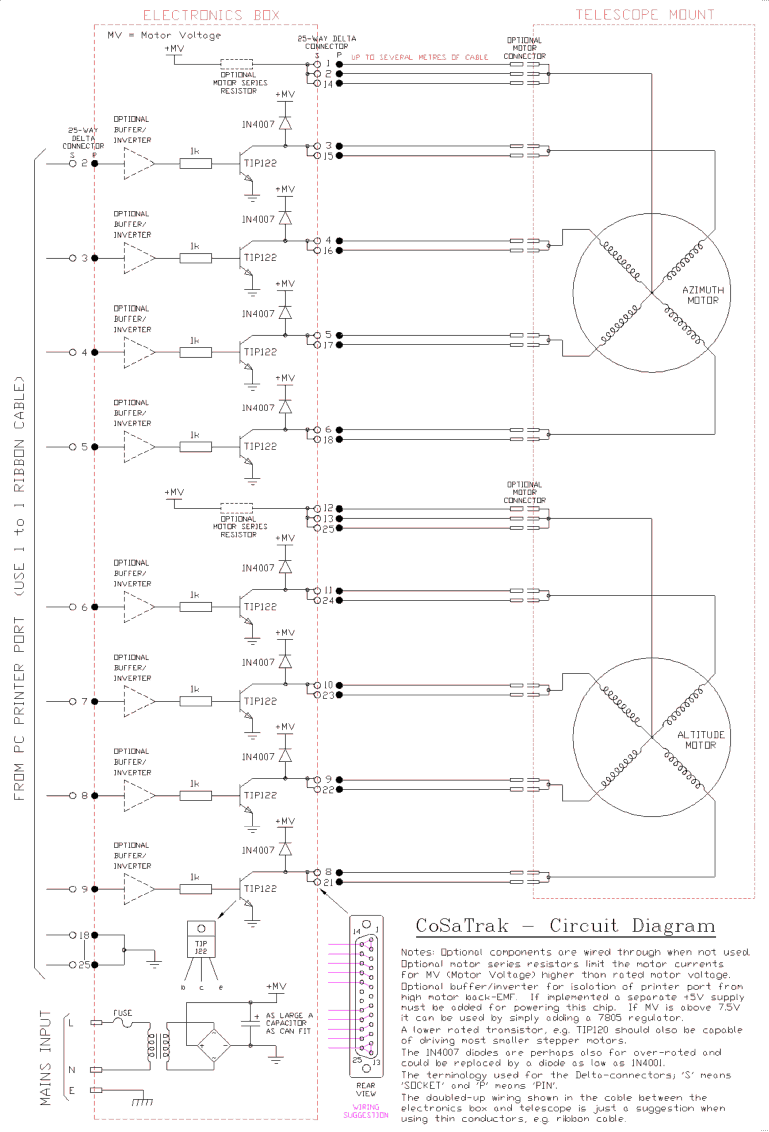
CoSaTrak drive satellite tracking circuit
The back EMF voltage spikes produced by stepper motors, especially higher voltage motors, can damage a PC's printer port if connections are made incorrectly, flyback diodes are absent, or connected in reverse. The safest options are opto-isolated or buffered/inverted circuits....
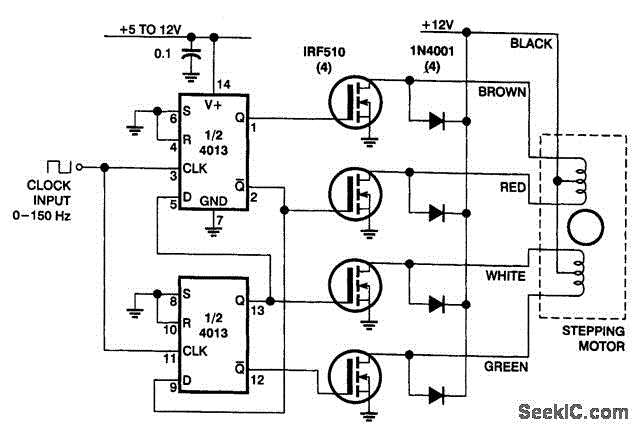
STEPPER MOTOR DRIVER
This circuit utilizes four IRF510 power FETs driven by a CMOS counter to produce the required two-phase drive quadrature. While integrated circuits (ICs) can perform this function, this method is beneficial for experimenters as it employs widely available components. The...
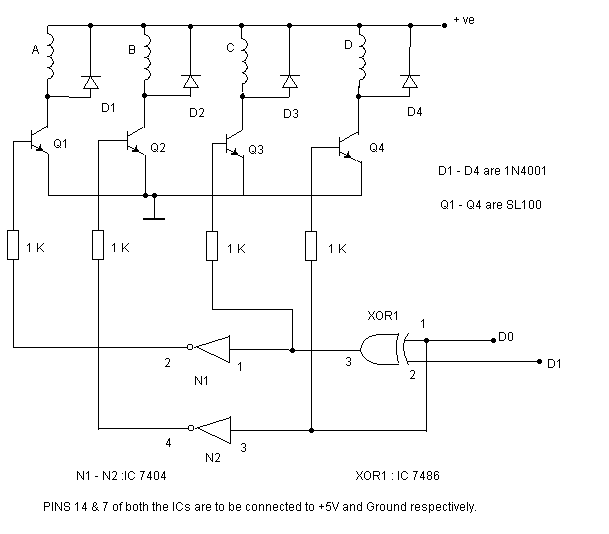
Simple stepper motor controller
The circuit shown above can be used to control a unipolar stepper motor which has FOUR coils. The above circuit can be for a motor current of up to about 500mA per winding with suitable heat sinks for the SL100....
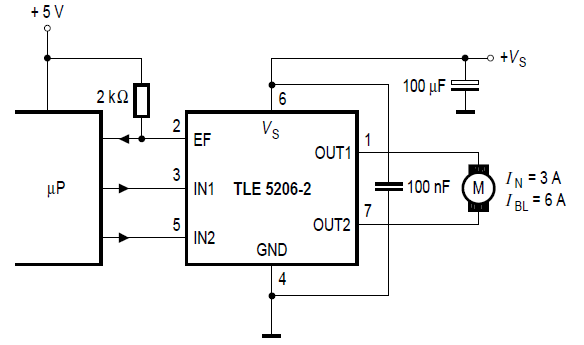
stepper remote control car
Stepper motor control circuit diagram using TLE5206 for remote control car.
The stepper motor control circuit is designed to manage the operation of a stepper motor, specifically utilizing the TLE5206 integrated circuit. This circuit is particularly suitable for applications in remote...