


Howto Design a Stepper Motor System Using an 8-bit Freescale microcontroller MCU - MC68HC11E9
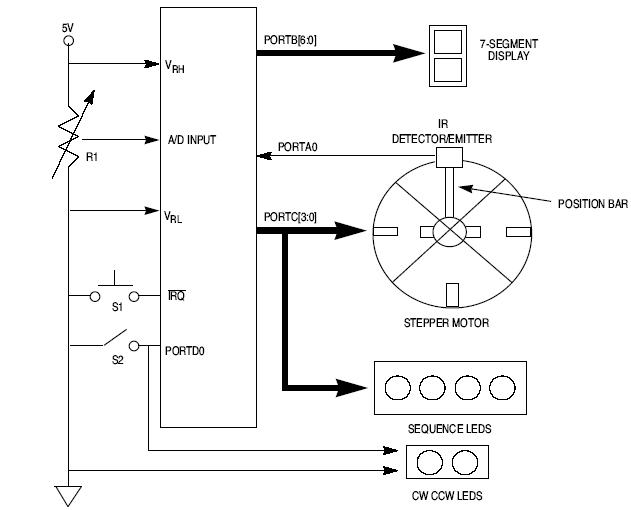
Description: This article explains how to design a stepper motor system using an 8-bit Freescale microcontroller - MC68HC11E9.
The design of a stepper motor system utilizing the 8-bit Freescale microcontroller MC68HC11E9 involves several key components and considerations to ensure effective control and operation of the stepper motor. The MC68HC11E9 is a versatile microcontroller that features integrated peripherals, including timers and input/output ports, which are essential for motor control applications.
The system typically comprises the following elements:
1. **Microcontroller**: The MC68HC11E9 serves as the central processing unit, executing the control algorithms necessary for stepper motor operation. It processes input signals and generates the appropriate output signals to drive the motor.
2. **Stepper Motor**: The stepper motor itself is the actuator that converts electrical pulses into mechanical movement. The motor type (e.g., unipolar or bipolar) will dictate the driving method and circuit configuration.
3. **Driver Circuit**: A driver circuit is required to interface the microcontroller with the stepper motor. This circuit can be built using transistors or dedicated motor driver ICs. The driver circuit amplifies the control signals from the microcontroller to provide sufficient current to the motor coils.
4. **Power Supply**: An appropriate power supply is necessary to provide the required voltage and current to the stepper motor and the microcontroller. The voltage rating should match the specifications of the motor, while the current capacity should accommodate the maximum load.
5. **Control Algorithm**: The control algorithm implemented in the microcontroller determines the sequence of pulses sent to the motor. This sequence controls the direction and speed of the motor. Common methods include half-stepping and full-stepping techniques, which affect the resolution and torque of the motor.
6. **Feedback Mechanism**: For precision applications, a feedback mechanism, such as an encoder, can be utilized to provide real-time position information to the microcontroller. This allows for closed-loop control, improving accuracy and performance.
7. **Programming Environment**: The software development environment for the MC68HC11E9 should support assembly or C programming languages. This environment is used to write, compile, and upload the control code to the microcontroller.
In summary, the design of a stepper motor system with the MC68HC11E9 microcontroller requires careful integration of hardware and software components. Proper selection of the motor type, driver circuit, and control algorithms is crucial for achieving desired performance characteristics. Additionally, consideration of power supply requirements and potential feedback systems enhances the overall functionality and precision of the stepper motor application.This article explains how to design a stepper motor system using an 8-bit Freescale microcontroller - MC68HC11E9
The design of a stepper motor system utilizing the 8-bit Freescale microcontroller MC68HC11E9 involves several key components and considerations to ensure effective control and operation of the stepper motor. The MC68HC11E9 is a versatile microcontroller that features integrated peripherals, including timers and input/output ports, which are essential for motor control applications.
The system typically comprises the following elements:
1. **Microcontroller**: The MC68HC11E9 serves as the central processing unit, executing the control algorithms necessary for stepper motor operation. It processes input signals and generates the appropriate output signals to drive the motor.
2. **Stepper Motor**: The stepper motor itself is the actuator that converts electrical pulses into mechanical movement. The motor type (e.g., unipolar or bipolar) will dictate the driving method and circuit configuration.
3. **Driver Circuit**: A driver circuit is required to interface the microcontroller with the stepper motor. This circuit can be built using transistors or dedicated motor driver ICs. The driver circuit amplifies the control signals from the microcontroller to provide sufficient current to the motor coils.
4. **Power Supply**: An appropriate power supply is necessary to provide the required voltage and current to the stepper motor and the microcontroller. The voltage rating should match the specifications of the motor, while the current capacity should accommodate the maximum load.
5. **Control Algorithm**: The control algorithm implemented in the microcontroller determines the sequence of pulses sent to the motor. This sequence controls the direction and speed of the motor. Common methods include half-stepping and full-stepping techniques, which affect the resolution and torque of the motor.
6. **Feedback Mechanism**: For precision applications, a feedback mechanism, such as an encoder, can be utilized to provide real-time position information to the microcontroller. This allows for closed-loop control, improving accuracy and performance.
7. **Programming Environment**: The software development environment for the MC68HC11E9 should support assembly or C programming languages. This environment is used to write, compile, and upload the control code to the microcontroller.
In summary, the design of a stepper motor system with the MC68HC11E9 microcontroller requires careful integration of hardware and software components. Proper selection of the motor type, driver circuit, and control algorithms is crucial for achieving desired performance characteristics. Additionally, consideration of power supply requirements and potential feedback systems enhances the overall functionality and precision of the stepper motor application.This article explains how to design a stepper motor system using an 8-bit Freescale microcontroller - MC68HC11E9
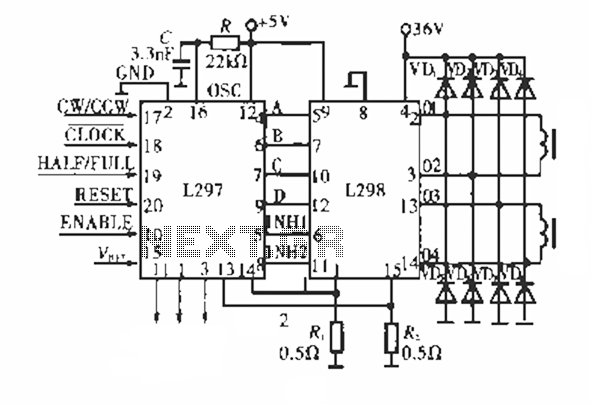
Bipolar stepper motor driver module circuit
The circuit operates using a dedicated stepping motor controller, the L297. Pin 17 (CW/CCW) is utilized to control the rotation direction of the stepper motor. Pin 18 (CLOCK) regulates the speed of the stepper motor, while pin 19 (HALF/FULL) allows...
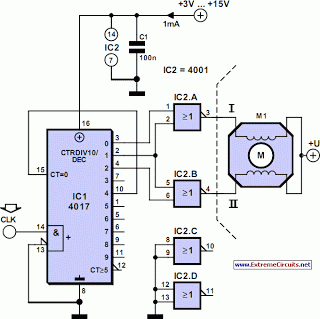
Motor Generator Stepper
Stepper motors are a frequently discussed topic. This circuit converts a clock signal from a square wave generator into signals that have a 90-degree phase difference, which are necessary for driving the stepper motor windings. The trade-off for this simplicity...
CO2 Laser
The motor controller is a custom-built unit that integrates custom printed circuit boards, the Pico Systems Universal Stepper Controller card, Gecko G320 motor drives, and an internal power supply. It also interfaces with servos requiring DC power and motor encoders,...
Small Stepper Motor
The objective is to operate a motor using an L293D Motor Drive Shield, which can handle 600mA per coil. The motor consumes 400mA per coil, suggesting compatibility. However, the datasheet does not clearly indicate the pinouts, only labeling them as...
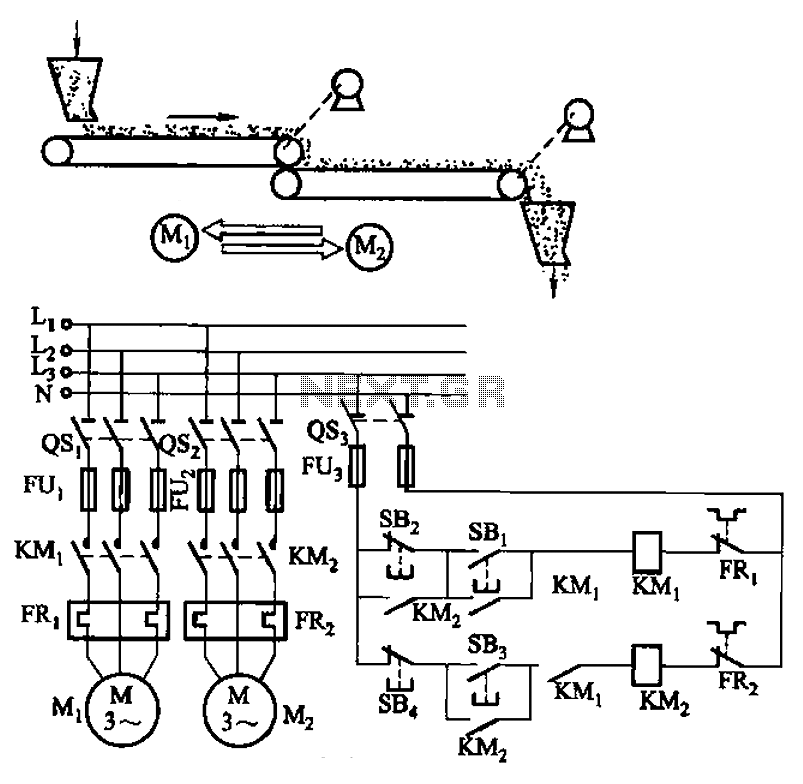
Belt conveyor interlock motor operation sequence control circuit
The circuit depicted in Figure 3-86 utilizes a line utilization time relay to control two motors, starting one before the other after an initial stall. The time relay KTi can be adjusted to modify the starting interval of the two...
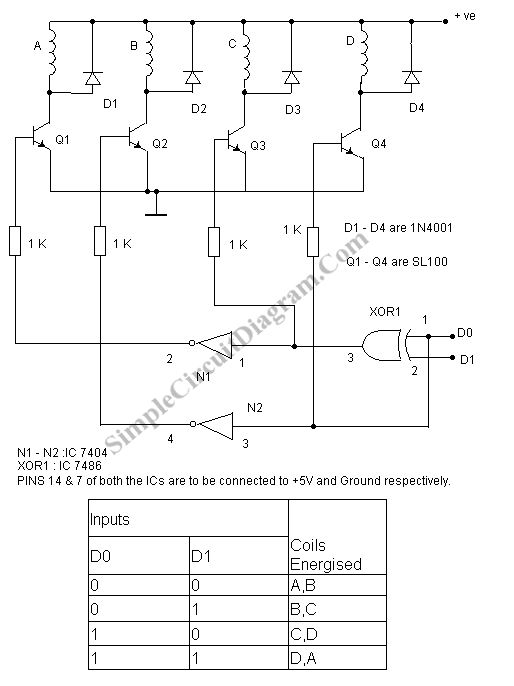
Stepper Motor Control No Microcontroller Needed
A stepper motor is an effective solution for achieving high-precision motion control. To operate a stepper motor, a corresponding control circuit is required.
A stepper motor control circuit typically consists of several key components that facilitate the precise movement of the...
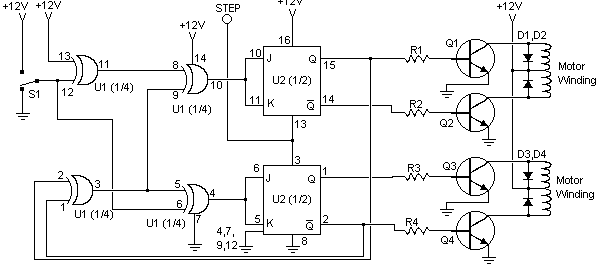
Stepper Motor Controller
I found this circuit in my files. I don't know where it came from, but it looks like I photocopied it from somewhere years ago. I have been told that it came from "The Robot Builder's Bonanza", by Gordan McComb....
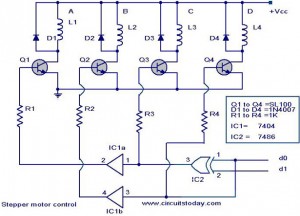
Stepper Motor ControllerCircuit Based On The 7404 IC
The following circuit illustrates a Stepper Motor Controller Circuit Diagram. This circuit is based on the 7404 IC. Features include a simple stepper motor.
The stepper motor controller circuit utilizing the 7404 IC is designed to drive a stepper motor with...
stepper motor controller schematic
A pulse motor, commonly known as a stepper motor, is defined as a motor that changes its excitation state according to input pulse signals, allowing it to move forward at a specific angle or distance. If the excitation state remains...