


Motor Generator Stepper
#stepper motor
#clock signal
#square wave generator
#phase difference
#motor windings
#frequency reduction
#driver circuit
#motor control
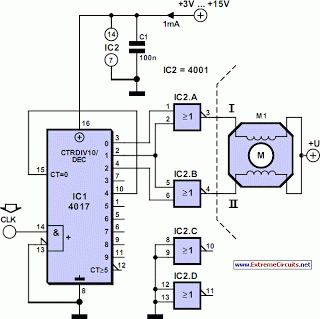
Description: Stepper motors are a frequently discussed topic. This circuit converts a clock signal from a square wave generator into signals that have a 90-degree phase difference, which are necessary for driving the stepper motor windings. The trade-off for this simplicity is a reduction in frequency by a factor of four. However, this is not problematic, as it is possible to increase the input frequency to compensate. The timing diagram illustrates that the counter outputs of the 4017 are combined using inverting OR gates to generate two square waves with a phase difference. This arrangement creates the correct sequence for energizing the windings: first, the first winding is negative while the second is positive; then both windings are negative; next, the first winding is positive while the second is negative; and finally, both windings are positive. The 4017 IC features a divide-by-10 counter followed by a decoder. Output 0 is active (logic high) while the internal counter is at zero. Upon the next positive edge of the clock signal, the counter increments to 1, activating output 1. This process continues until output 4 becomes logic high, at which point this signal is connected to the reset input, immediately resetting the counter to the zero state. Observing this output with an oscilloscope requires precise setup due to the short duration of the pulse. The output of an OR gate can supply only several milliamperes, which is insufficient to drive a stepper motor directly; therefore, a suitable driver circuit is required between the generator and the stepper motor.
The described circuit utilizes the 4017 decade counter IC, which operates by counting the pulses received from a clock signal. The counter outputs are utilized to generate the necessary phase-shifted signals for the stepper motor. The inverting OR gates play a crucial role in ensuring that the outputs are correctly phased for the operation of the motor. The circuit's design inherently limits the frequency output due to the division by four, necessitating an adjustment in the input frequency to maintain the desired motor speed.
The timing sequence for the stepper motor is critical for its operation, as it determines the direction and smoothness of the motor's movement. The transitions between the different states of the windings must be executed in a precise order to prevent stalling or erratic behavior. The connection of the reset pin to output 4 ensures that the counter cycles through its states in a continuous loop, allowing for sustained operation.
To drive a stepper motor effectively, a dedicated driver circuit is essential. This circuit typically employs transistors or MOSFETs to handle the higher current requirements of the motor, allowing it to be controlled by the low-power signals generated by the 4017. The driver circuit interfaces with the motor windings and provides the necessary power to achieve the required torque and speed. The design of the driver circuit should consider the specifications of the stepper motor, including its rated voltage and current, to ensure optimal performance and prevent damage to both the driver and the motor.
In summary, the combination of the 4017 decade counter, inverting OR gates, and a suitable driver circuit forms a robust solution for controlling stepper motors, enabling precise movement and control in various applications.Stepper motors are a subject that keeps recurring. This little circuit changes a clock signal (from a square wave generator) into signals with a 90-degree phase difference, which are required to drive the stepper motor windings. The price we pay for the simplicity is that the frequency is reduced by a factor of four. This isn`t really a problem, s ince we just have to increase the input frequency to compensate. The timing diagram clearly shows that the counter outputs of the 4017 are combined using inverting OR gates to produce two square waves with a phase difference. This creates the correct sequence for powering the windings: the first winding is negative and the second positive, both windings are negative, the first winding is positive and the second negative, and finally both windings are positive.
Internally, the 4017 has a divide-by-10 counter followed by a decoder. Output 0` is active (logic one) as long as the internal counter is at zero. At the next positive edge of the clock signal the counter increments to 1 and output 1` becomes active. This continues until output 4` becomes a logic one. This signal is connected to the reset input, which immediately resets the counter to the zero` state.
If you were to use an oscilloscope to look at this output, you would have to set it up very precisely before you would be able to see this pulse; that`s how short it is. The output of an OR gate can only supply several mA, which is obviously much too little to drive a stepper motor directly.
A suitable driver circuit, which goes between the generator and stepper motor.
The described circuit utilizes the 4017 decade counter IC, which operates by counting the pulses received from a clock signal. The counter outputs are utilized to generate the necessary phase-shifted signals for the stepper motor. The inverting OR gates play a crucial role in ensuring that the outputs are correctly phased for the operation of the motor. The circuit's design inherently limits the frequency output due to the division by four, necessitating an adjustment in the input frequency to maintain the desired motor speed.
The timing sequence for the stepper motor is critical for its operation, as it determines the direction and smoothness of the motor's movement. The transitions between the different states of the windings must be executed in a precise order to prevent stalling or erratic behavior. The connection of the reset pin to output 4 ensures that the counter cycles through its states in a continuous loop, allowing for sustained operation.
To drive a stepper motor effectively, a dedicated driver circuit is essential. This circuit typically employs transistors or MOSFETs to handle the higher current requirements of the motor, allowing it to be controlled by the low-power signals generated by the 4017. The driver circuit interfaces with the motor windings and provides the necessary power to achieve the required torque and speed. The design of the driver circuit should consider the specifications of the stepper motor, including its rated voltage and current, to ensure optimal performance and prevent damage to both the driver and the motor.
In summary, the combination of the 4017 decade counter, inverting OR gates, and a suitable driver circuit forms a robust solution for controlling stepper motors, enabling precise movement and control in various applications.Stepper motors are a subject that keeps recurring. This little circuit changes a clock signal (from a square wave generator) into signals with a 90-degree phase difference, which are required to drive the stepper motor windings. The price we pay for the simplicity is that the frequency is reduced by a factor of four. This isn`t really a problem, s ince we just have to increase the input frequency to compensate. The timing diagram clearly shows that the counter outputs of the 4017 are combined using inverting OR gates to produce two square waves with a phase difference. This creates the correct sequence for powering the windings: the first winding is negative and the second positive, both windings are negative, the first winding is positive and the second negative, and finally both windings are positive.
Internally, the 4017 has a divide-by-10 counter followed by a decoder. Output 0` is active (logic one) as long as the internal counter is at zero. At the next positive edge of the clock signal the counter increments to 1 and output 1` becomes active. This continues until output 4` becomes a logic one. This signal is connected to the reset input, which immediately resets the counter to the zero` state.
If you were to use an oscilloscope to look at this output, you would have to set it up very precisely before you would be able to see this pulse; that`s how short it is. The output of an OR gate can only supply several mA, which is obviously much too little to drive a stepper motor directly.
A suitable driver circuit, which goes between the generator and stepper motor.
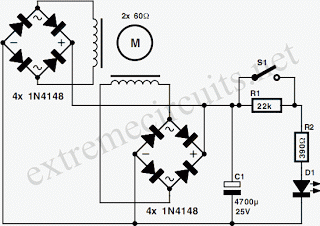
Stepper Motor Generator
Any stepper motor can be utilized as a generator. Unlike other types of generators, a stepper motor generates a significant induced voltage even at low rotational speeds.
A stepper motor operates by converting electrical energy into mechanical motion through a series...
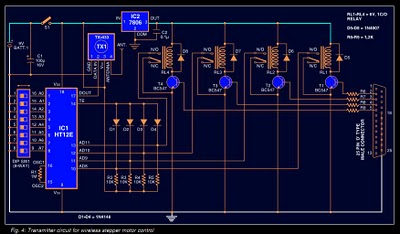
PC Based Wireless Stepper Motor control Circuit PCB
Stepper motors are widely used in applications such as process control, machine tools, and robotics. In particular, remote control of stepper motors is essential in robotics and process control. This document provides the circuit diagrams for both the transmitter and...
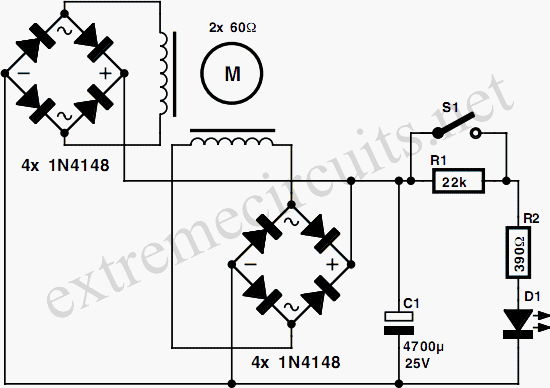
Stepper Motor Generator
Any stepper motor can function as a generator. Unlike other types of generators, a stepper motor generates a significant induced voltage even at low rotational speeds. The specific model used here has a DC resistance ranging from 2 ohms to...
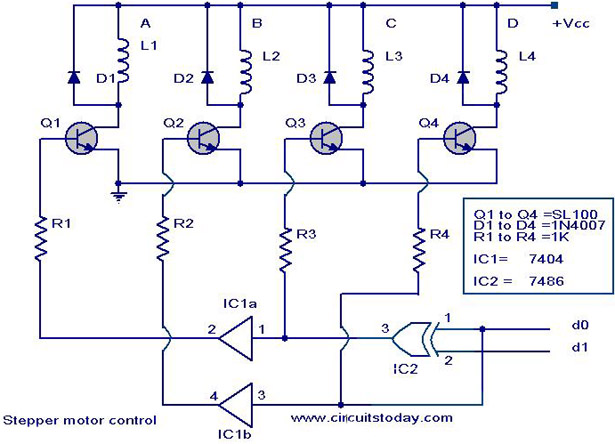
Stepper motor controller - Driver circuit with circuit design
The circuit diagram illustrates a simple stepper motor controller utilizing basic components. The driver circuit employs four SL100 transistors to control the motor windings, along with two NOT gates and one XOR gate to decode the two-bit control logic needed...
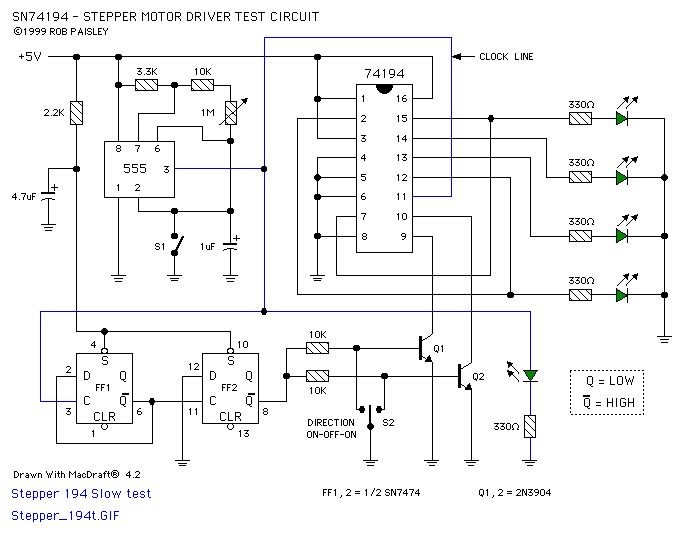
Stepper Motor Driver
The circuit is based on the SN74LS194 Bidirectional Universal Shift Register and is designed to drive unipolar stepper motors, providing basic control functions such as forward, reverse, stop, and speed adjustment. Direction control is selected by an ON-OFF-ON type toggle...
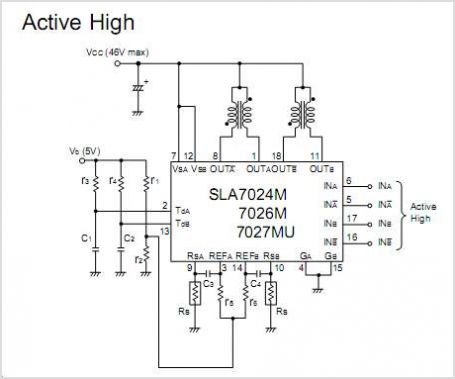
SLA7070MPR 2-Phase Stepper Motor Unipolar Driver ICs
The SC1088 is a bipolar integrated circuit designed for use in mono portable and pocket radios. It is particularly beneficial when a minimal number of peripheral components, which are compact and cost-effective, is essential. The circuit features a frequency-locked loop...
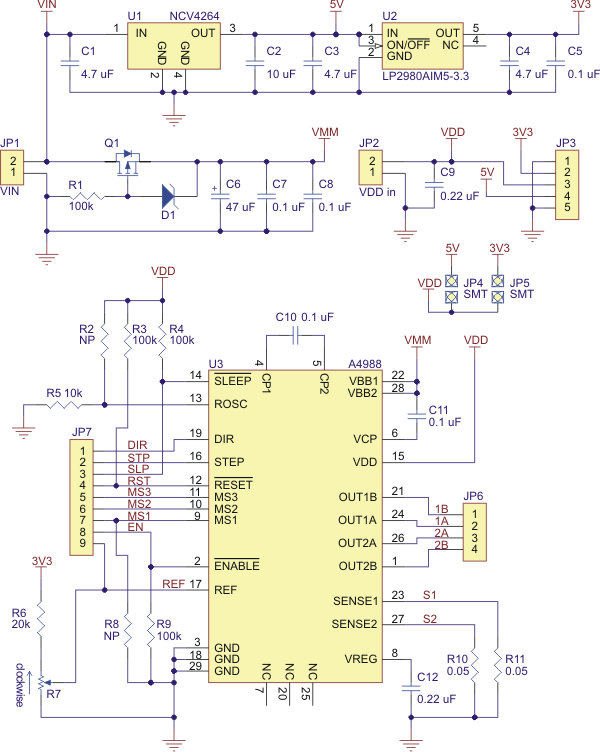
Stepper Motor Driver Carrier with Voltage Regulator
Best 1183 - A4988 Stepper Motor Driver Carrier with Voltage Regulator in Robot Italy. The A4988 stepper motor driver carrier with voltage regulators is a breakout board for Allegro's easy-to-use A4988 microstepping bipolar stepper motor driver. The board has two...
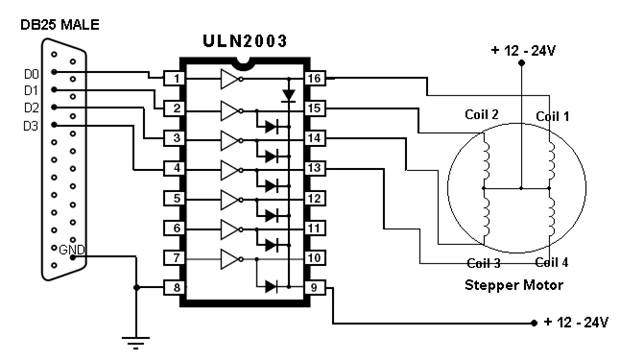
Computer Controlled Stepper Motor
This article outlines the process of connecting a stepper motor to a computer's parallel port and writing code to control it using the scroll wheel of a mouse. For those unfamiliar with stepper motors, this project offers an engaging introduction....
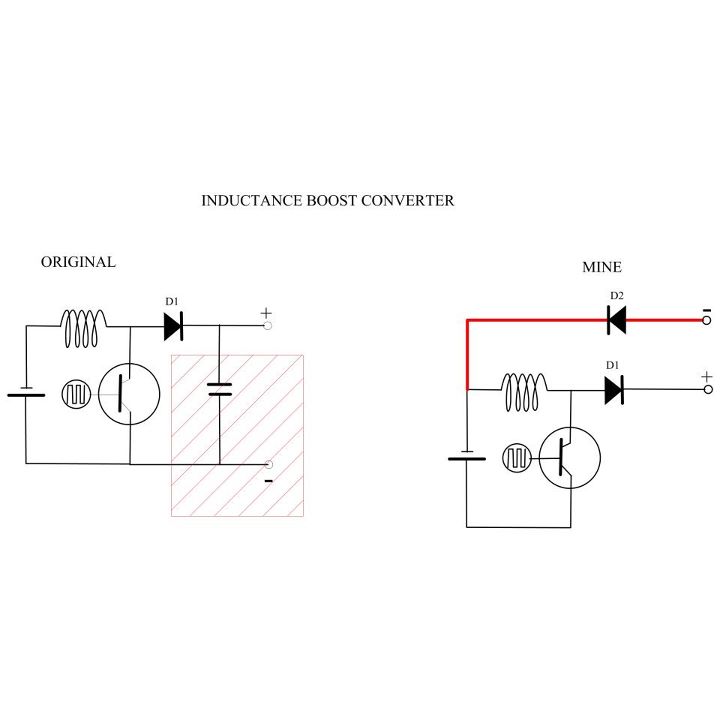
My Motors got me to Tap into Radiant Energy
A new user is seeking to share information about their experiences on this platform.
The user expresses a desire to communicate and engage with the community regarding their experiences. This indicates an interest in exchanging knowledge and possibly seeking assistance or...