


Small Stepper Motor
#stepper motor
#L293D
#motor driver
#Arduino
#coil
#current rating
#pinout
#data sheet
#motor shield
Description: The objective is to operate a motor using an L293D Motor Drive Shield, which can handle 600mA per coil. The motor consumes 400mA per coil, suggesting compatibility. However, the datasheet does not clearly indicate the pinouts, only labeling them as coil A and coil B without specifying which wires correspond to each coil. The truth table is confusing, but it has been inferred that the yellow and orange wires represent one coil, while the brown and black wires represent another coil. There is unexpected connectivity/resistance between the orange and brown wires, which raises concerns when attempting to connect them according to the presumed pinout (Yellow/Orange as coil B and Brown/Black as coil A). The motor is programmed for one full rotation (48 pulses, calculated as 360/7.5) at a speed setting of 10, but it only achieves a quarter rotation, and the H-bridge chip overheats rapidly.
The L293D Motor Drive Shield is designed to control DC motors and stepper motors, providing the necessary current and voltage levels for effective operation. It can drive up to two DC motors simultaneously, with each output capable of supplying up to 600mA. In this case, the motor in question draws 400mA per coil, which is within the shield's specifications, allowing for safe operation under normal conditions.
The confusion with the pinouts is a common issue when dealing with motors and motor drivers. Typically, stepper motors consist of two coils, each requiring a specific sequence of energization to achieve rotation. The L293D shield requires the correct identification of these coils to ensure proper functionality. The yellow and orange wires are likely connected to one coil, while the brown and black wires are connected to the other. It is crucial to ensure that these connections are made correctly to prevent unexpected behavior.
The observation of resistance between the orange and brown wires is concerning, as it suggests a possible short circuit or incorrect wiring. This condition can lead to excessive current draw, causing the H-bridge to overheat, which may explain the rapid temperature increase during operation. It is advisable to double-check all connections and ensure that the motor is wired in accordance with the intended configuration.
When programming the motor to perform a full rotation, the calculation for the number of pulses (48) is based on the step angle of 7.5 degrees per step. However, if the motor is only completing a quarter rotation, it may indicate an issue with the control signals or the wiring configuration. Adjustments to the pulse sequence, timing, or speed settings may be necessary to achieve the desired full rotation.
In summary, careful attention to the wiring configuration, verification of connections, and proper programming of the control signals are essential for the successful operation of the motor with the L293D Motor Drive Shield. Addressing the resistance issue and ensuring correct coil identification will help prevent overheating and achieve the intended motor performance.Trying to get this motor to work with a L293D Motor Drive Shield the shield is capable of handling 600mA per coil, this motor according to the data here takes 400mA (presumable per coil) so should be good there. However the data sheet here does not relay explain the pin outs only coil A and coil B but not which wires are which coil, the truth t
able is also a bit confusing, I am a programmer and i cant read it. i tried to do my own truth table and it seems to confirm my guess that yellow and orange is one coil, and brown and black is another coil, . however I am also showing connectivity/resistance between orange and brown, . that should not happen correct when i hook it up in what should be (as far as i can tell) the correct pin out, (Yellow/Orange as coil B) and (Brown/Black as coil A).
and setting full rotation to 48 (360/7. 5=48) then tell the motor to do one full rotation (48 pulses) (speed 10). All i get is a quarter rotation and a Hbridge chip that`s getting way to hot very quickly,
The L293D Motor Drive Shield is designed to control DC motors and stepper motors, providing the necessary current and voltage levels for effective operation. It can drive up to two DC motors simultaneously, with each output capable of supplying up to 600mA. In this case, the motor in question draws 400mA per coil, which is within the shield's specifications, allowing for safe operation under normal conditions.
The confusion with the pinouts is a common issue when dealing with motors and motor drivers. Typically, stepper motors consist of two coils, each requiring a specific sequence of energization to achieve rotation. The L293D shield requires the correct identification of these coils to ensure proper functionality. The yellow and orange wires are likely connected to one coil, while the brown and black wires are connected to the other. It is crucial to ensure that these connections are made correctly to prevent unexpected behavior.
The observation of resistance between the orange and brown wires is concerning, as it suggests a possible short circuit or incorrect wiring. This condition can lead to excessive current draw, causing the H-bridge to overheat, which may explain the rapid temperature increase during operation. It is advisable to double-check all connections and ensure that the motor is wired in accordance with the intended configuration.
When programming the motor to perform a full rotation, the calculation for the number of pulses (48) is based on the step angle of 7.5 degrees per step. However, if the motor is only completing a quarter rotation, it may indicate an issue with the control signals or the wiring configuration. Adjustments to the pulse sequence, timing, or speed settings may be necessary to achieve the desired full rotation.
In summary, careful attention to the wiring configuration, verification of connections, and proper programming of the control signals are essential for the successful operation of the motor with the L293D Motor Drive Shield. Addressing the resistance issue and ensuring correct coil identification will help prevent overheating and achieve the intended motor performance.Trying to get this motor to work with a L293D Motor Drive Shield the shield is capable of handling 600mA per coil, this motor according to the data here takes 400mA (presumable per coil) so should be good there. However the data sheet here does not relay explain the pin outs only coil A and coil B but not which wires are which coil, the truth t
able is also a bit confusing, I am a programmer and i cant read it. i tried to do my own truth table and it seems to confirm my guess that yellow and orange is one coil, and brown and black is another coil, . however I am also showing connectivity/resistance between orange and brown, . that should not happen correct when i hook it up in what should be (as far as i can tell) the correct pin out, (Yellow/Orange as coil B) and (Brown/Black as coil A).
and setting full rotation to 48 (360/7. 5=48) then tell the motor to do one full rotation (48 pulses) (speed 10). All i get is a quarter rotation and a Hbridge chip that`s getting way to hot very quickly,
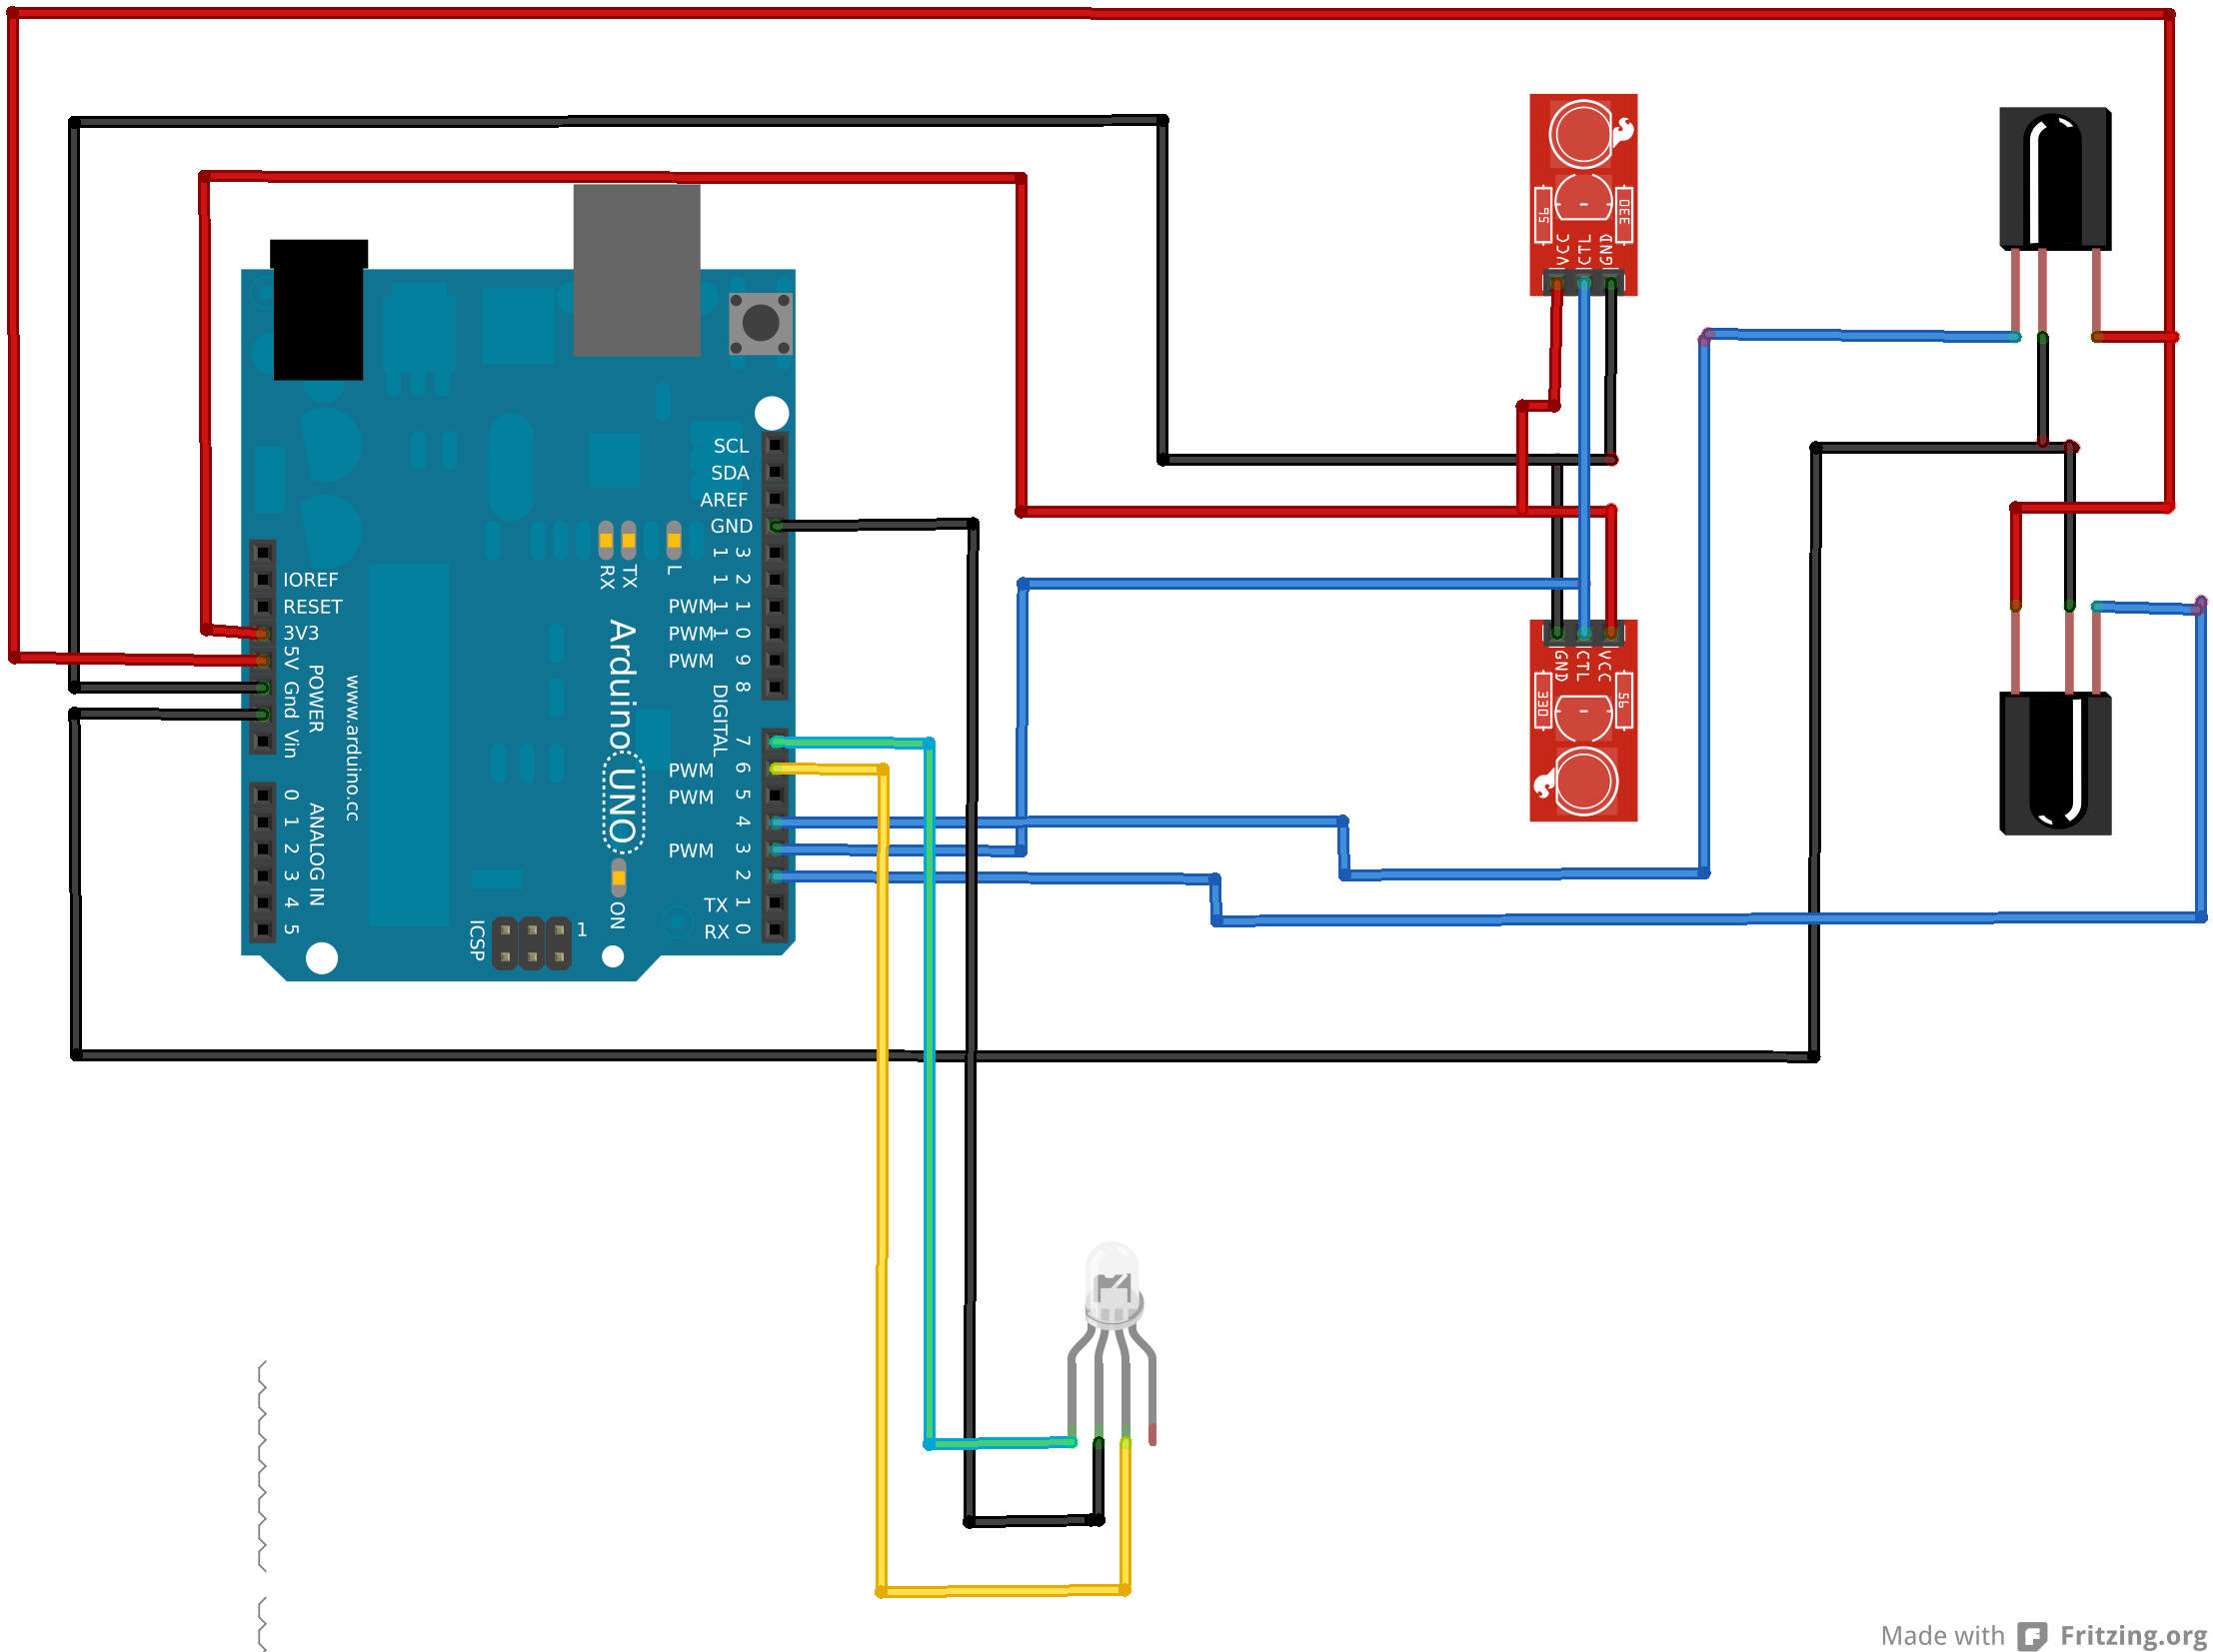
Arduino IR Transmitter & Receiver w/ LEDs Flickering Issue (Whats wrong with this circuit?)
An Arduino Uno is connected to two infrared (IR) transmitters and their respective receivers. When one of the receivers detects a beam break, a strand of LEDs displays a pattern. While this setup functions correctly in principle, an issue arises...
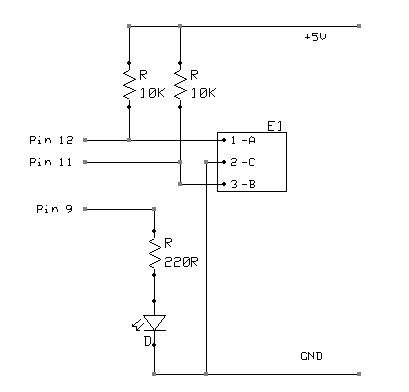
Arduino UNO Tutorial Rotary Encoder
A rotary encoder generates two square wave outputs (A and B) that are 90 degrees out of phase. The number of pulses or steps produced per full rotation varies by model; for instance, the Sparkfun Rotary Encoder has 12 steps,...
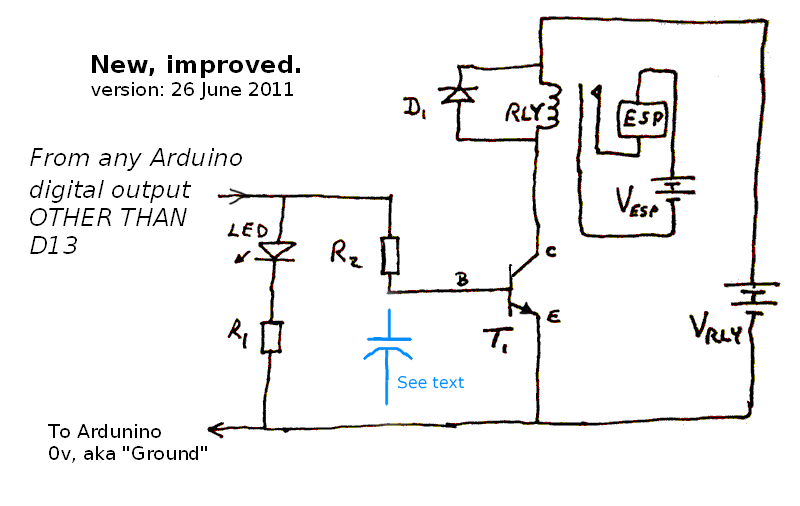
arduino circuit
This page is browser-friendly. To enhance readability, adjust your browser window to be narrower than the full screen. The page consists of two parts: the first part features a basic program demonstrating the RFID reader's functionality, while the second part...
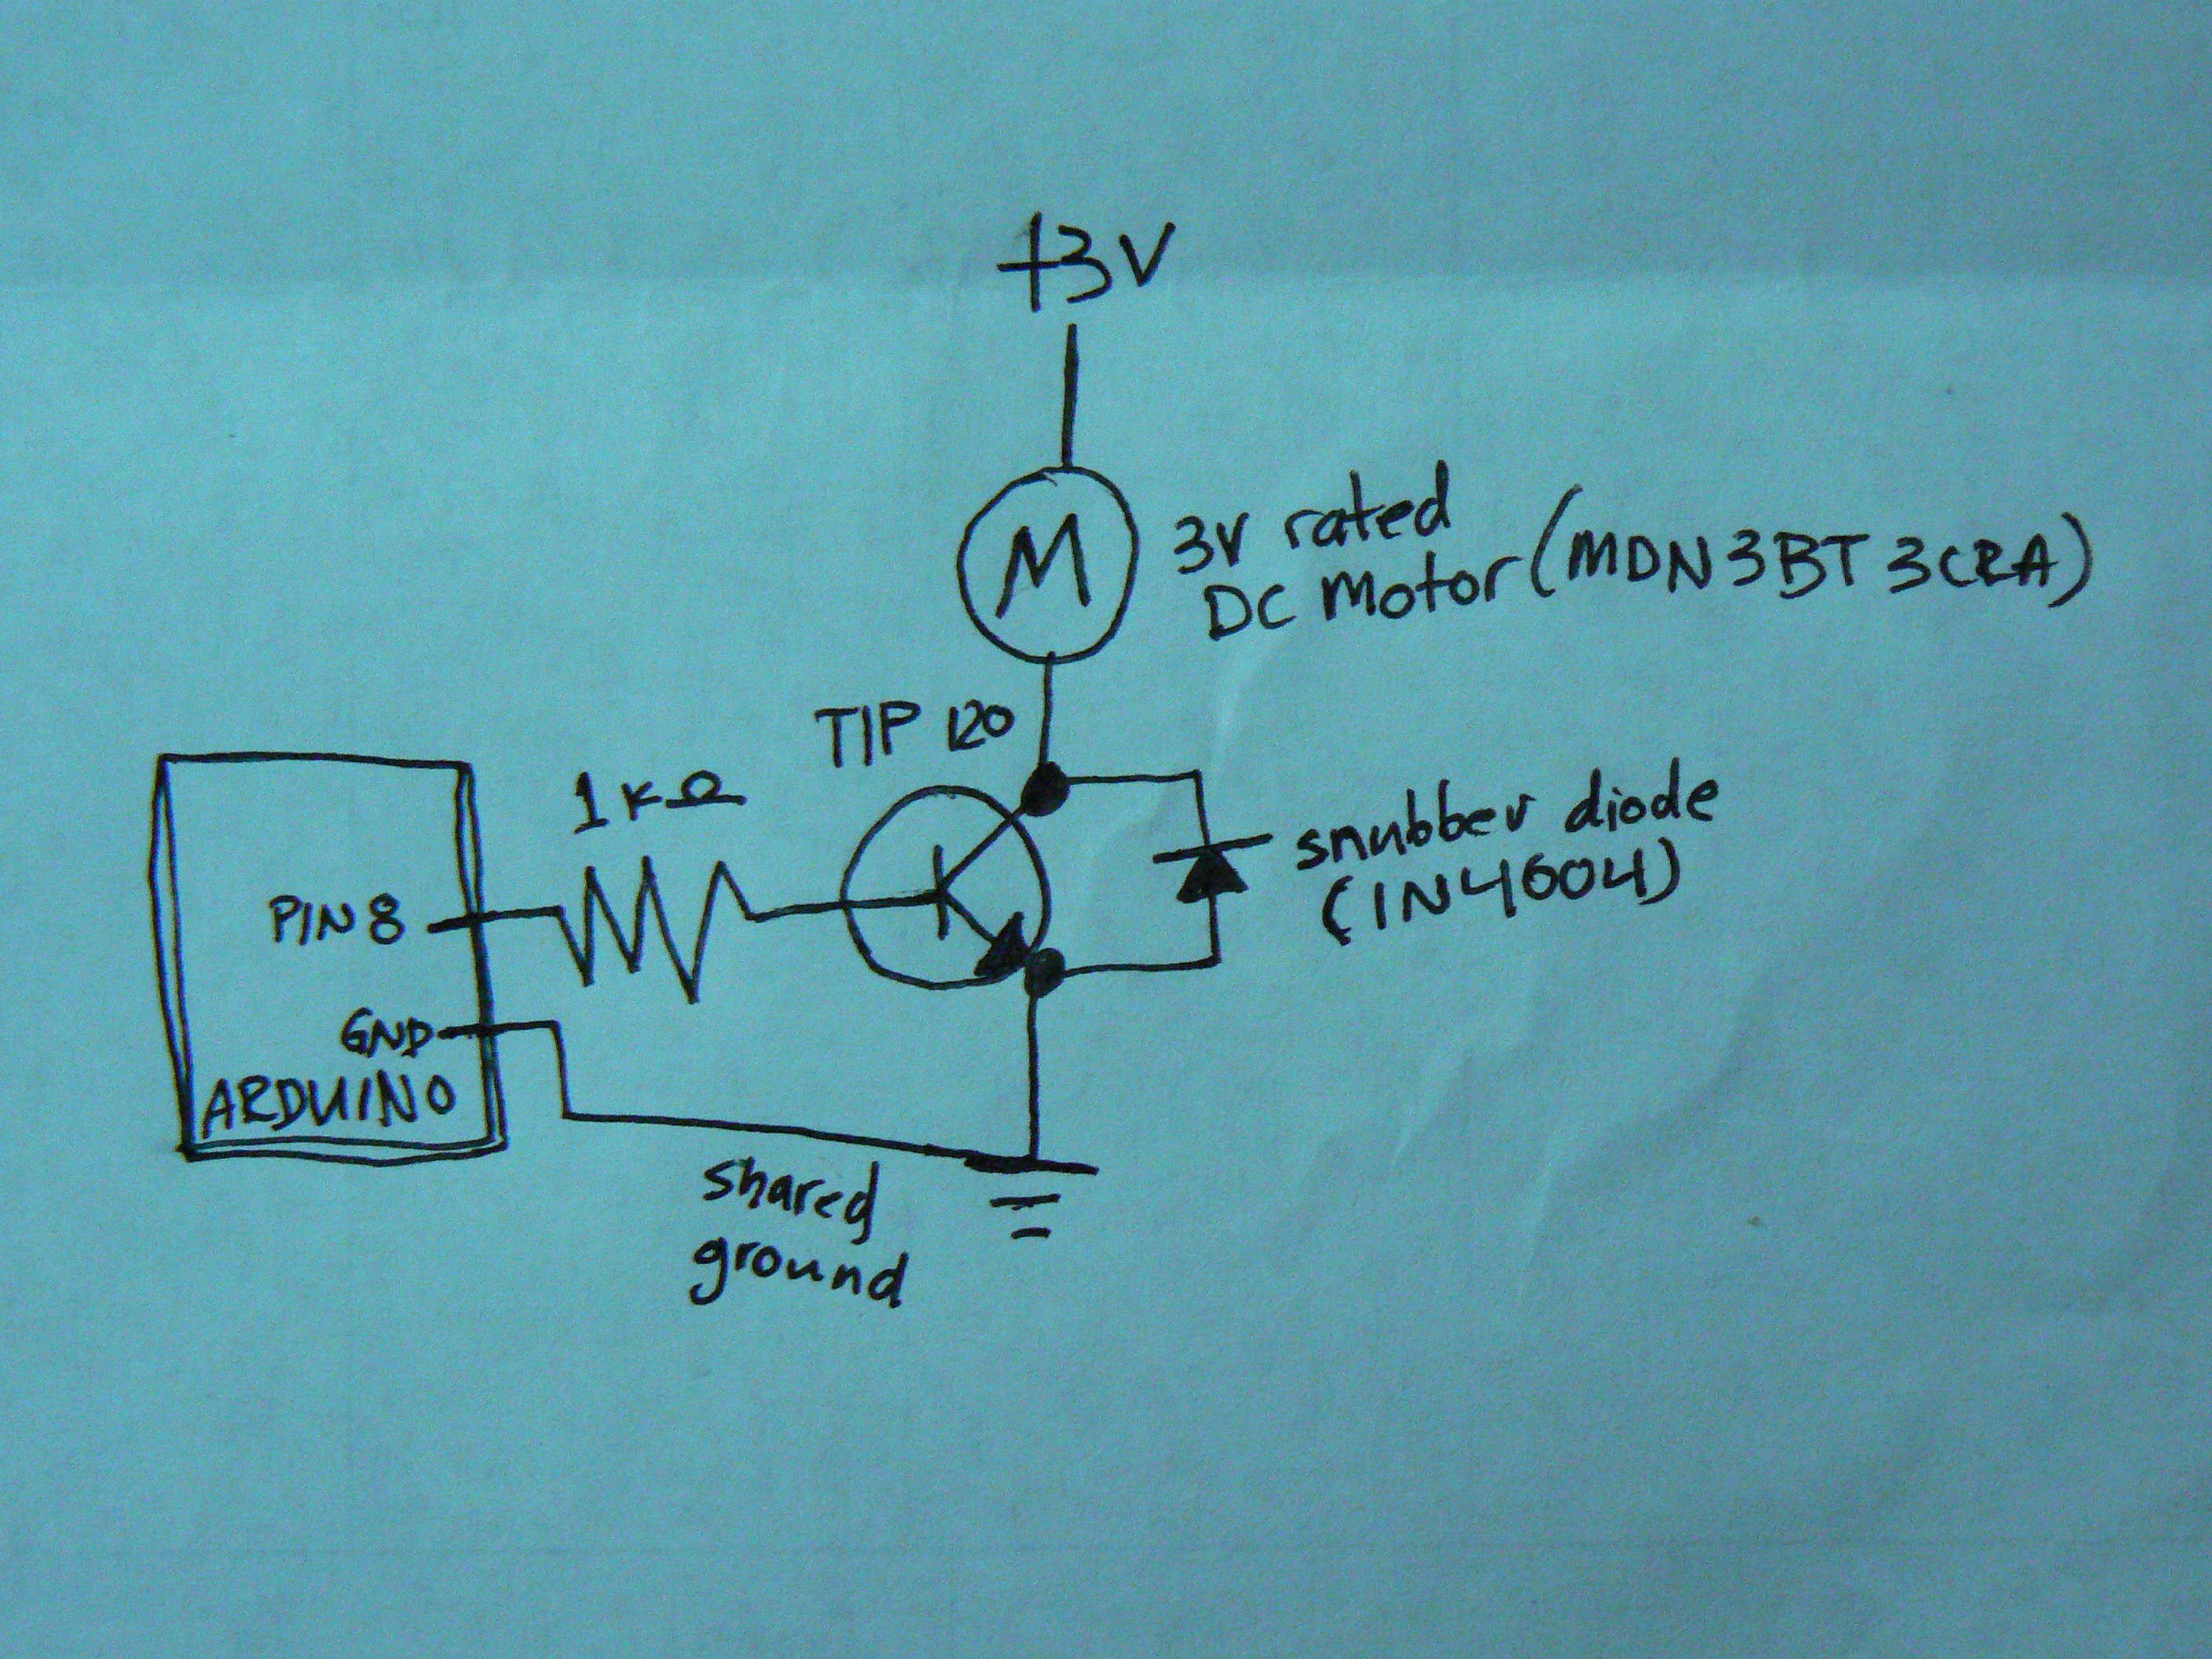
Arduino controlling a DC Motor
When controlling motors with a microcontroller, the snubber is quite important. This configuration is not commonly seen, as the snubber is typically placed across the motor itself. The general concept is that charge builds up on the motor coil, and...
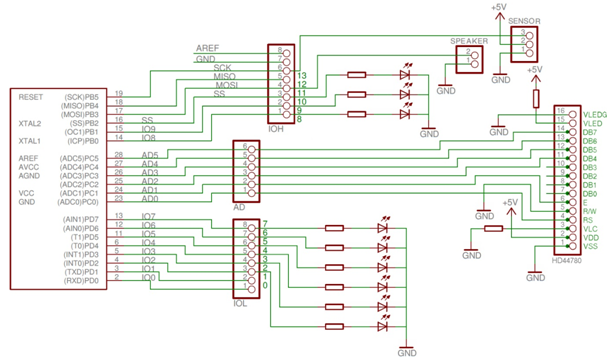
arduino uno parking sensor
Required components include an Arduino Uno, an HD44780 Character LCD, a PING))) Ultrasonic Distance Sensor, a speaker cone from an old computer, a breadboard, wires, resistors, colored LEDs, and Arduino software. The provided schematic illustrates the parking sensor circuit. A...
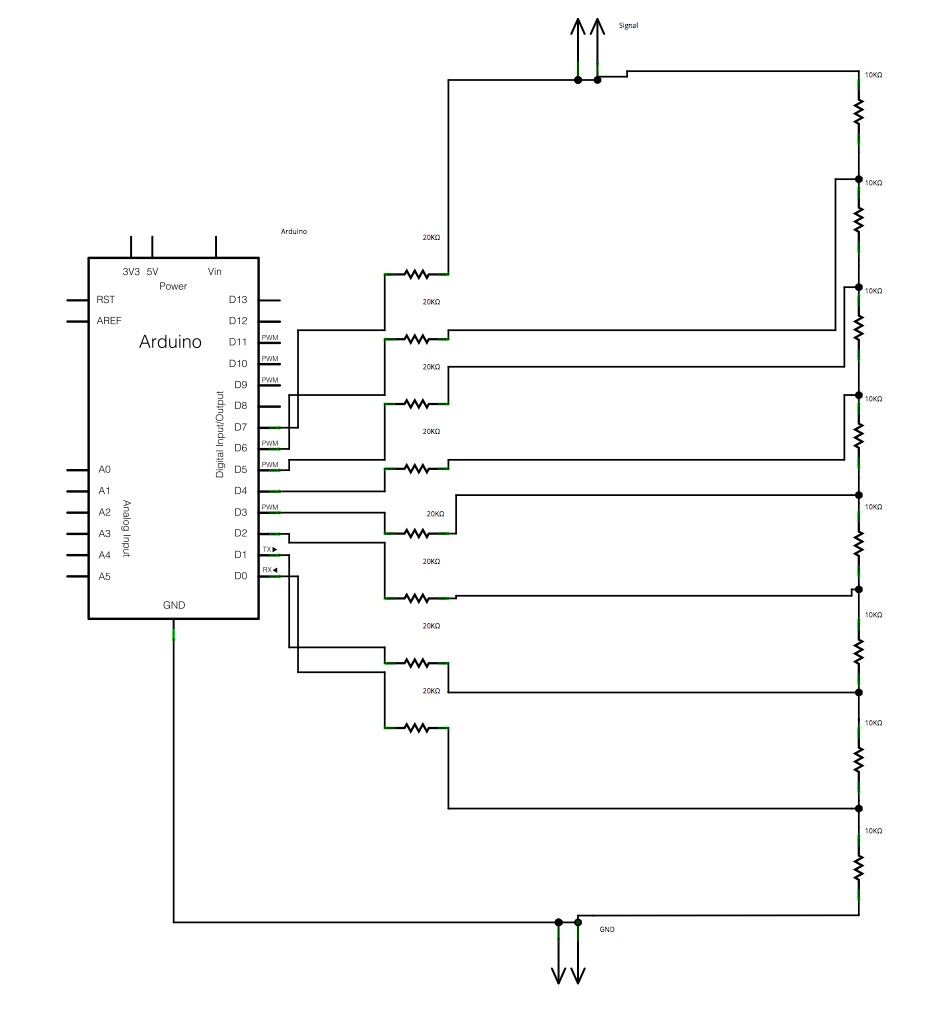
ramped magnetic field circuit for a miniature mass spectrometer
The main concept is to space the time intervals to increment the DAC output values. There are 256 levels since there are 8 digital outputs from the Arduino board. Therefore, for an 8-bit resolution and a 50-second ramp time, the...
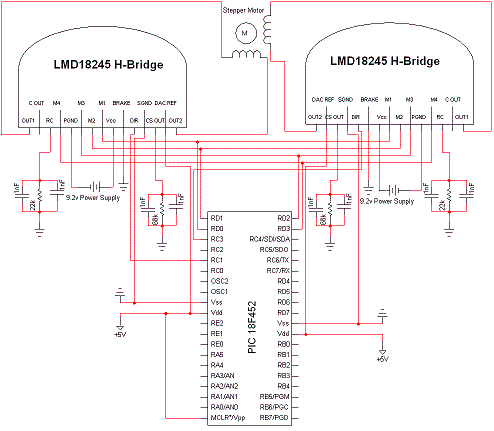
stepper motor controller
Two stepper motors are to be controlled by a dsPIC microcontroller. The programming of the microcontroller has been completed, but there is confusion regarding the use of the L298 driver. Assistance is needed with the circuit design.
To control two stepper...
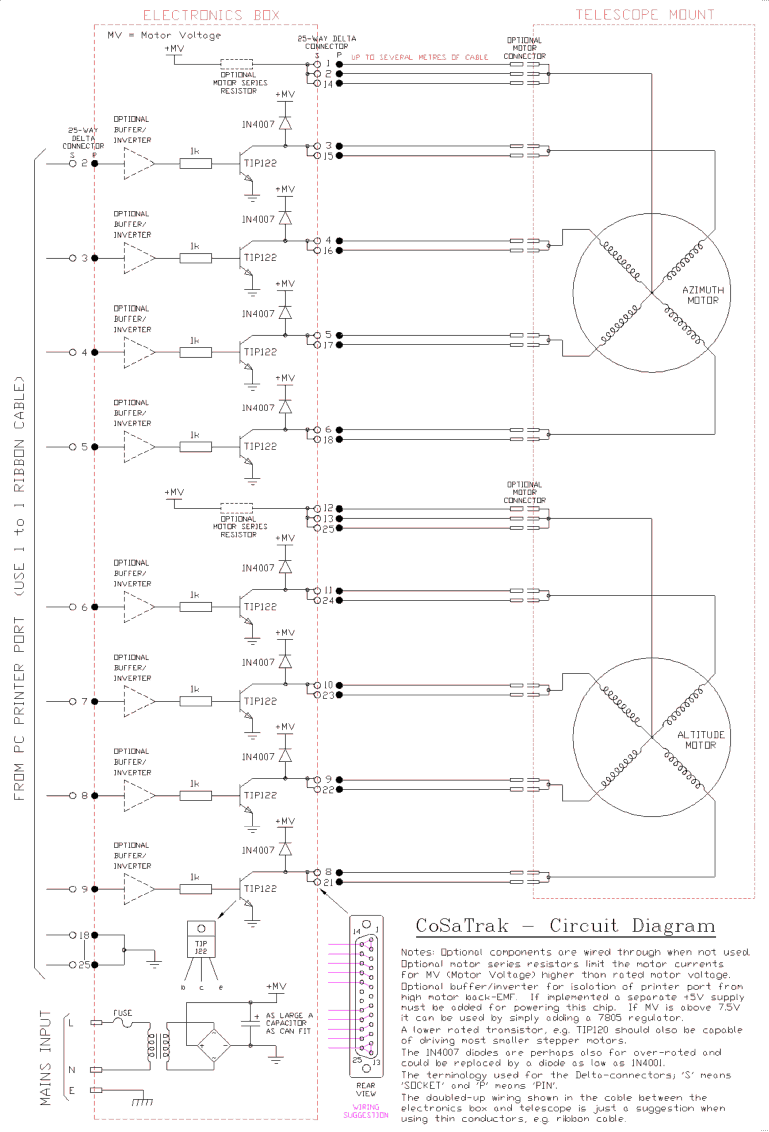
CoSaTrak drive satellite tracking circuit
The back EMF voltage spikes produced by stepper motors, especially higher voltage motors, can damage a PC's printer port if connections are made incorrectly, flyback diodes are absent, or connected in reverse. The safest options are opto-isolated or buffered/inverted circuits....
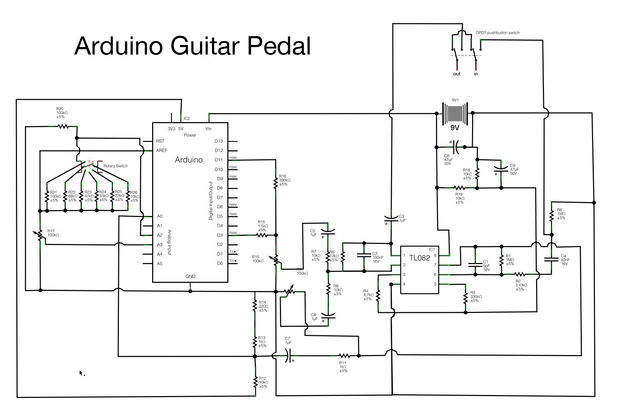
Arduino Guitar Pedal
Begin constructing the circuit as illustrated in the schematic. To view the schematic in a larger format, click the small "i" icon located in the upper right corner of the image.
The schematic serves as a visual representation of the circuit...