


Line follower with atmega 16
#ATmega16
#line follower
#sensor module
#DC motor
#robot
#microcontroller
#automation
#embedded systems
#motor control
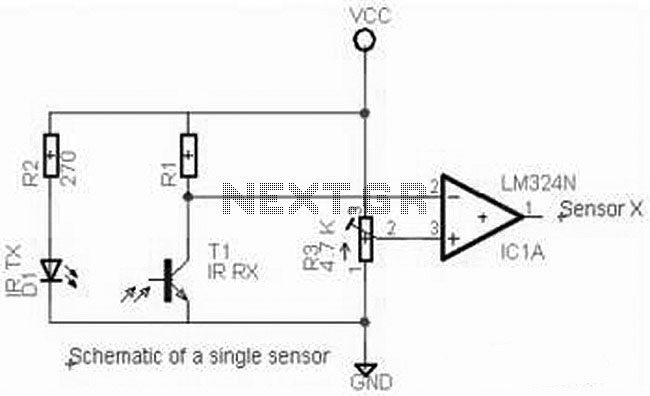
Description: The complete electrical circuit diagram of a line follower robot is based on the ATmega16 microcontroller. This circuit consists of three main modules: the sensor module, the microcontroller module, and the DC motor module.
The line follower robot circuit operates by using infrared (IR) sensors in the sensor module to detect the presence of a line on the ground. Typically, these sensors are positioned on the underside of the robot and are responsible for distinguishing between the line and the surrounding surface. When the sensors detect the line, they send signals to the microcontroller module, which is the central processing unit of the robot. The ATmega16 microcontroller processes the input from the sensors and determines the necessary actions to keep the robot on track.
The microcontroller module is programmed to interpret the sensor data and control the outputs to the DC motor module. Depending on the input from the sensors, the microcontroller adjusts the speed and direction of the DC motors, allowing the robot to follow the line accurately. For instance, if the left sensor detects the line, the microcontroller may reduce the speed of the left motor or stop it entirely, while maintaining or increasing the speed of the right motor to steer the robot back onto the line.
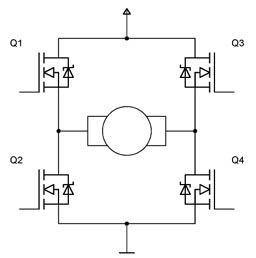
The DC motor module consists of two DC motors that drive the wheels of the robot. Each motor is connected to a motor driver circuit, which allows the microcontroller to control the motors' speed and direction through PWM (Pulse Width Modulation) signals. This configuration enables smooth and responsive movement of the robot, ensuring that it can navigate curves and intersections effectively.
Overall, the combination of the sensor module, microcontroller module, and DC motor module creates an efficient and responsive line follower robot capable of autonomously navigating along a predetermined path. The design can be further enhanced by incorporating additional features such as speed control, obstacle detection, and more sophisticated algorithms for improved performance.Here the complete electrical circuit diagram of line follower robot which built based on ATmega16. There are three modules of line follower robot circuit that are sensor module, microcontroller module and DC motor module.
The line follower robot circuit operates by using infrared (IR) sensors in the sensor module to detect the presence of a line on the ground. Typically, these sensors are positioned on the underside of the robot and are responsible for distinguishing between the line and the surrounding surface. When the sensors detect the line, they send signals to the microcontroller module, which is the central processing unit of the robot. The ATmega16 microcontroller processes the input from the sensors and determines the necessary actions to keep the robot on track.
The microcontroller module is programmed to interpret the sensor data and control the outputs to the DC motor module. Depending on the input from the sensors, the microcontroller adjusts the speed and direction of the DC motors, allowing the robot to follow the line accurately. For instance, if the left sensor detects the line, the microcontroller may reduce the speed of the left motor or stop it entirely, while maintaining or increasing the speed of the right motor to steer the robot back onto the line.
The DC motor module consists of two DC motors that drive the wheels of the robot. Each motor is connected to a motor driver circuit, which allows the microcontroller to control the motors' speed and direction through PWM (Pulse Width Modulation) signals. This configuration enables smooth and responsive movement of the robot, ensuring that it can navigate curves and intersections effectively.
Overall, the combination of the sensor module, microcontroller module, and DC motor module creates an efficient and responsive line follower robot capable of autonomously navigating along a predetermined path. The design can be further enhanced by incorporating additional features such as speed control, obstacle detection, and more sophisticated algorithms for improved performance.Here the complete electrical circuit diagram of line follower robot which built based on ATmega16. There are three modules of line follower robot circuit that are sensor module, microcontroller module and DC motor module.
Motor circuits
The project involves a DC geared motor intended for use in a suitcase carrier. Two motors were purchased from Pololu at a cost of approximately $100. The selection process included discussions among team members, followed by consultation with Dr. Leo...
Map Bot
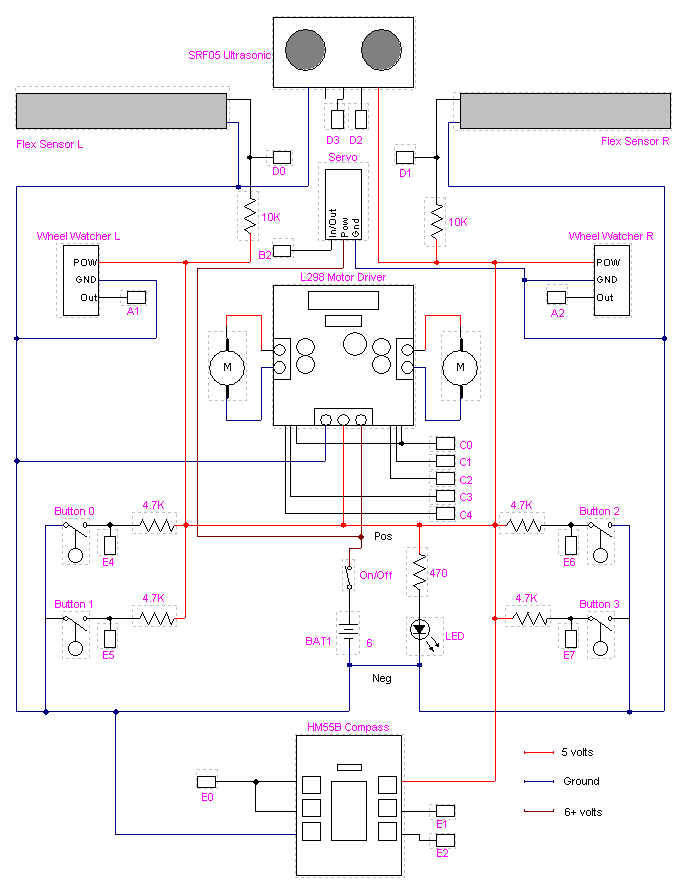
The purpose of this robot is to navigate and map a single floor of a house, using the created map to intelligently traverse the area. Diagnostic software has been developed to verify that all subsystems of the robot are functioning...
DC motor armature series resistance one way operation start dynamic braking circuit
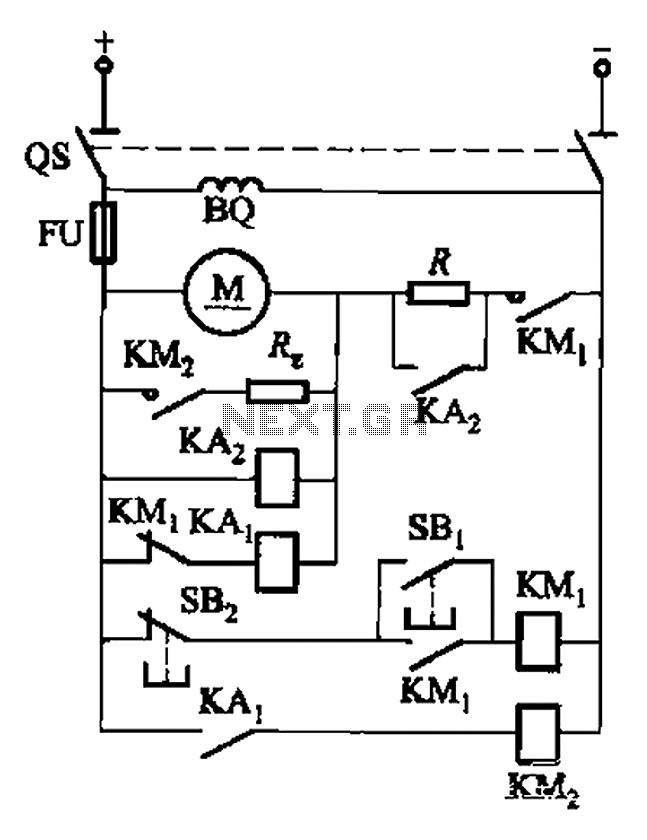
The circuit illustrated in Figure 3-196 features a starting resistance level and an undervoltage relay (KAz) that is controlled by the removal of the startup resistor. It also includes dynamic braking for shutdown purposes. The undervoltage relay (KAL) operates in...
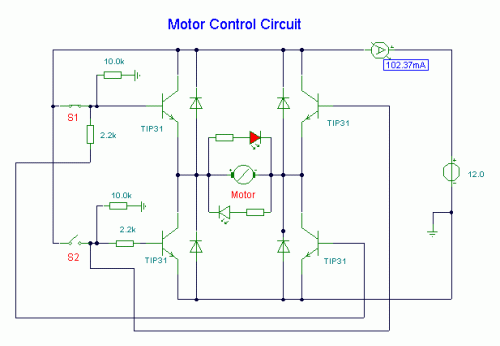
DC Motor Control Circuit
S1 and S2 are normally open, push-to-close, momentary switches. The diodes, which can be either red or green, serve solely to indicate the direction of operation. The TIP31 transistors may need to be adjusted based on the specifications of the...
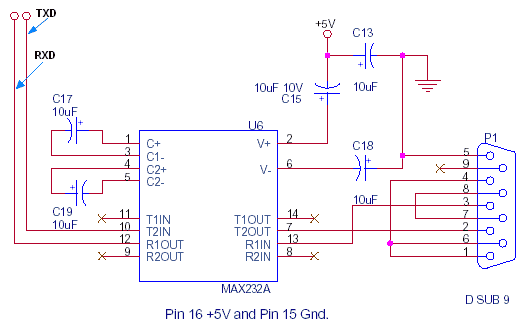
Interface a uC to PC RS232 with MAX232A
This document outlines the standard configuration for interfacing a microcontroller, such as the 8051, with a PC using RS232 through the MAX232A. The UART or serial port was absent in the 8049 and 8749 microcontrollers, which were predecessors to the...
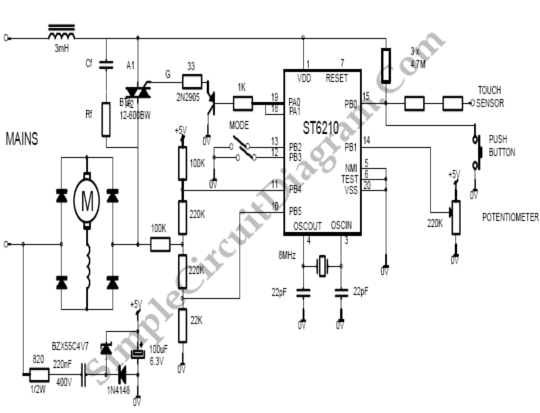
Universal DC Mode Motor Drive
A DC drive for a universal motor is depicted in the figure below. To provide DC current to the motor, a diode bridge has been integrated around the motor. The motor...
The schematic illustrates a DC drive system designed for a...
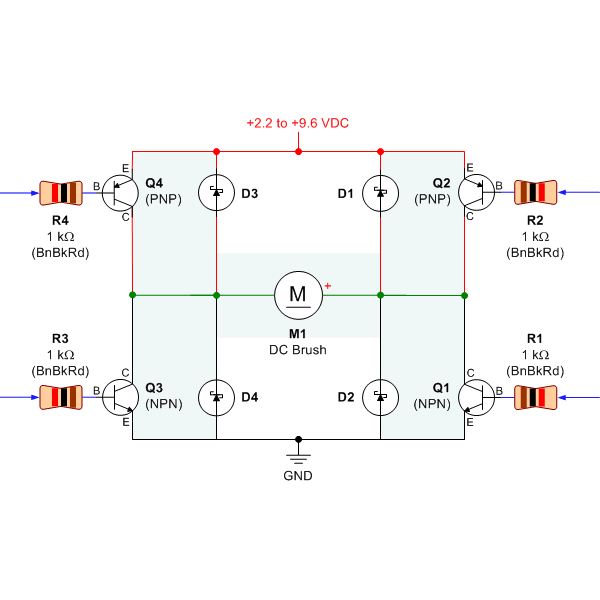
the dc motor circuit
Selecting the appropriate DC motor is essential for constructing mobile robots. Testing DC motors is straightforward and can be accomplished by assembling a basic DC motor circuit. The components needed for this circuit include a DC motor, a battery power...
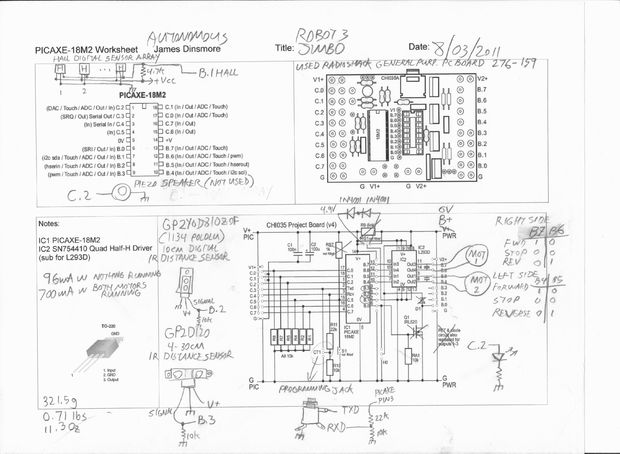
Robot Autonomous Sensor Platform
This is an autonomous robot designed to explore the interfacing of various sensors with a PICAXE processor. Its mission is to search for a magnet.
The autonomous robot operates based on a microcontroller architecture centered around the PICAXE processor, which is...
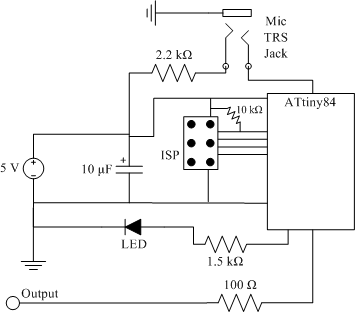
clap sensor construction
The clap sensor is a straightforward circuit that consists of a PC microphone, a microcontroller, and an output. The circuit design features the ATtiny84 microcontroller, chosen for familiarity with the AVR architecture and accessibility to necessary tools. The ATtiny84 is...