


DC motor armature series resistance one way operation start dynamic braking circuit
#DC motor
#armature resistance
#dynamic braking
#startup resistor
#under voltage relay
#motor braking
#series resistance
#one-way operation
#motor shutdown
#relay control
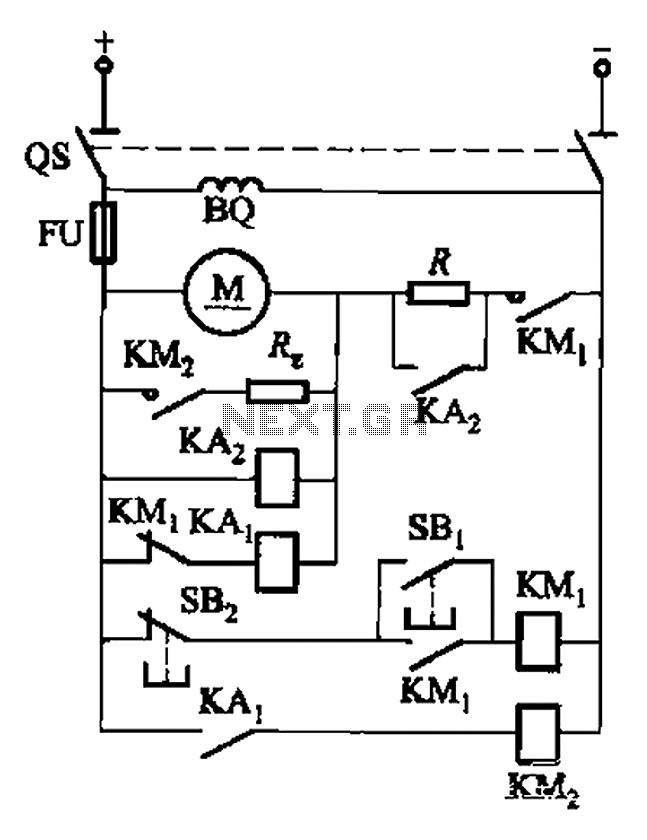
Description: The circuit illustrated in Figure 3-196 features a starting resistance level and an undervoltage relay (KAz) that is controlled by the removal of the startup resistor. It also includes dynamic braking for shutdown purposes. The undervoltage relay (KAL) operates in parallel with the motor armature, reflecting the voltage across the motor armature as the speed changes. This circuit is utilized for controlling the speed variations.
The circuit design integrates several key components that contribute to its functionality. The starting resistance level is crucial for limiting the initial current during motor startup, preventing excessive inrush current that could damage the motor or associated circuitry. The undervoltage relay (KAz) serves as a protective mechanism, ensuring that the motor operates within safe voltage limits. When the startup resistor is removed, the relay activates, allowing the motor to run at its rated voltage.
During shutdown, dynamic braking is employed to quickly reduce the motor's speed. This is achieved by reversing the motor's field current, which generates a counter torque that decelerates the motor effectively. The dynamic braking feature is vital for applications requiring rapid stopping, enhancing safety and operational efficiency.
The second undervoltage relay (KAL) operates concurrently with the motor armature. It monitors the armature voltage, providing feedback on the motor's operational status. As the motor speed varies, KAL responds to changes in voltage, enabling precise control over the motor's speed. This feedback mechanism is essential for applications that demand variable speed control, allowing for adjustments based on load conditions or operational requirements.
Overall, the circuit exemplifies an effective design for motor control, combining starting resistance, undervoltage protection, and dynamic braking to achieve reliable and efficient operation. The integration of these elements ensures that the system can adapt to varying operational conditions while maintaining safety and performance standards. Circuit shown in Figure 3-196. The circuit has a resistance level start, under voltage relay KAz controlled by the startup resistor removed; shutdown, the use of dynamic brakin g. Undervoltage relay KAL, when KA2 coil operating in parallel with the motor armature, they reflect the motor armature voltage, speed changes. It can be said that the circuit is used to control the speed of change.
The circuit design integrates several key components that contribute to its functionality. The starting resistance level is crucial for limiting the initial current during motor startup, preventing excessive inrush current that could damage the motor or associated circuitry. The undervoltage relay (KAz) serves as a protective mechanism, ensuring that the motor operates within safe voltage limits. When the startup resistor is removed, the relay activates, allowing the motor to run at its rated voltage.
During shutdown, dynamic braking is employed to quickly reduce the motor's speed. This is achieved by reversing the motor's field current, which generates a counter torque that decelerates the motor effectively. The dynamic braking feature is vital for applications requiring rapid stopping, enhancing safety and operational efficiency.
The second undervoltage relay (KAL) operates concurrently with the motor armature. It monitors the armature voltage, providing feedback on the motor's operational status. As the motor speed varies, KAL responds to changes in voltage, enabling precise control over the motor's speed. This feedback mechanism is essential for applications that demand variable speed control, allowing for adjustments based on load conditions or operational requirements.
Overall, the circuit exemplifies an effective design for motor control, combining starting resistance, undervoltage protection, and dynamic braking to achieve reliable and efficient operation. The integration of these elements ensures that the system can adapt to varying operational conditions while maintaining safety and performance standards. Circuit shown in Figure 3-196. The circuit has a resistance level start, under voltage relay KAz controlled by the startup resistor removed; shutdown, the use of dynamic brakin g. Undervoltage relay KAL, when KA2 coil operating in parallel with the motor armature, they reflect the motor armature voltage, speed changes. It can be said that the circuit is used to control the speed of change.
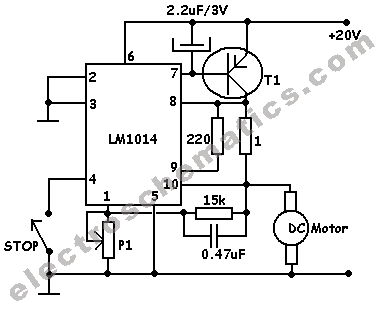
DC Motor Speed Controller Circuit
This motor speed controller utilizes a single IC, the LM1014, to regulate the speed of a DC motor. It detects the increase in motor current as the rotation of the motor increases.
The motor speed controller is designed around the LM1014...
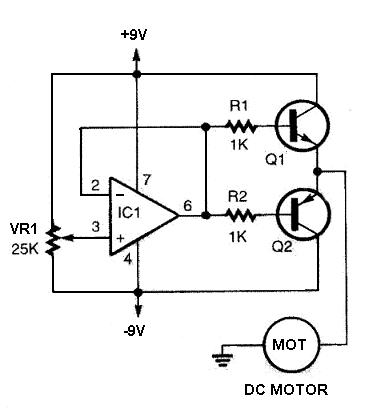
bidirectional dc motor driver schematic
The DC motor driver circuit depicted in the images can be utilized for controlling DC motors, allowing for bidirectional rotation and adjustable speed. This straightforward circuit is constructed using a 741 operational amplifier (op-amp) as a voltage comparator, along with...
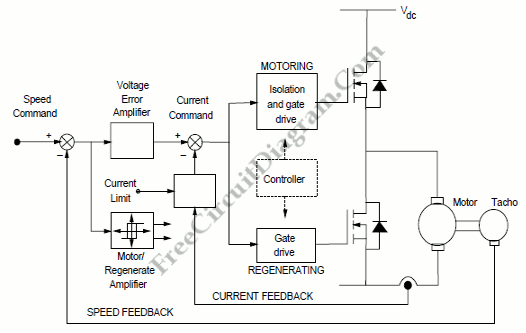
DC Motor Control System Block Diagram
A schematic arrangement for a two-quadrant controller is shown in the figure below. This figure illustrates the outer speed control loop and the inner current control loop. The tachogenerator derives the speed feedback signal; alternatively, an approximation of the motor...
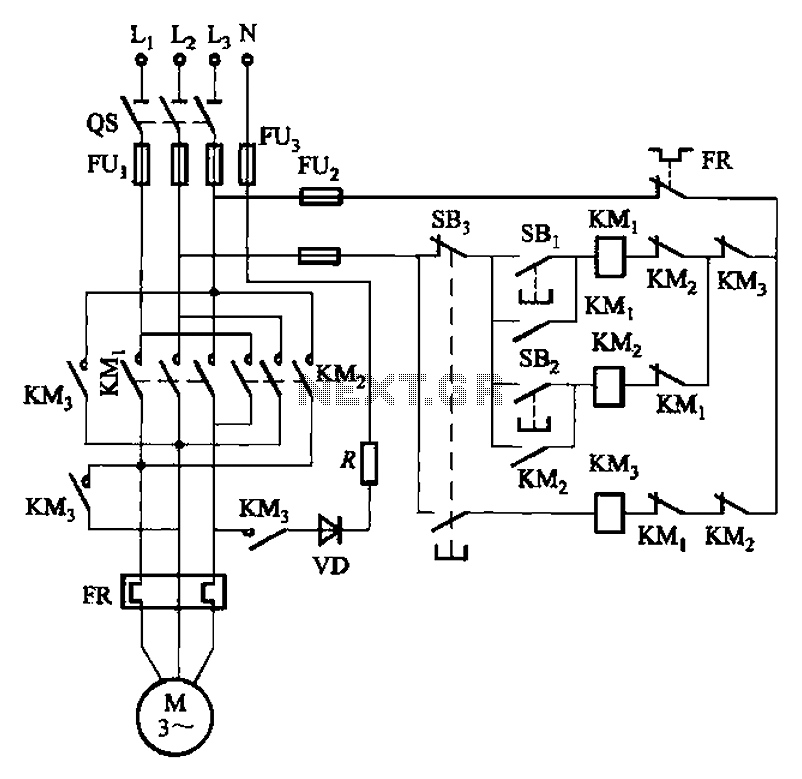
Forward and reverse operation of the dynamic braking circuit 2
The circuit illustrated in Figure 3-145 employs a rectifier diode brake for neutral grounding in a three-phase, four-wire power supply system.
This circuit design incorporates a rectifier diode brake, which plays a crucial role in ensuring the safety and reliability of...
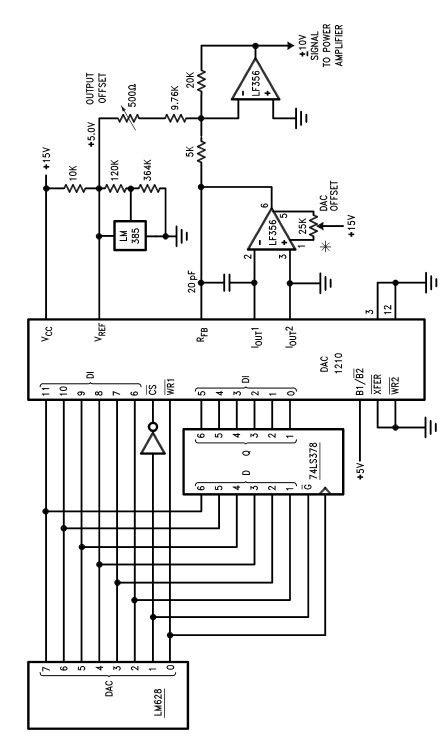
DC motor driver circuit design using LM628 LM629 dedicated motion-control processors
The LM628 and LM629 dedicated motion-control processors can be utilized to design various applications involving DC and brushless DC servo motors, as well as other servomechanisms. The power path of this electronic project, which functions as a motor driver, is...
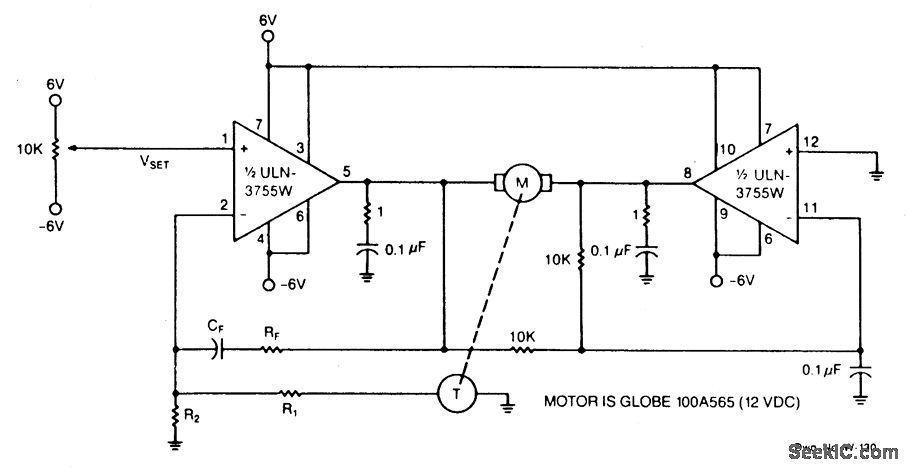
DC MOTOR SPEED CONTROL
Power operational amplifiers provide precise speed control for DC motors. The circuit enables bidirectional speed control. The amplifiers' push-pull configuration guarantees a full rail-to-rail voltage swing (excluding the saturation drops of the output stages) across the motor in both directions....
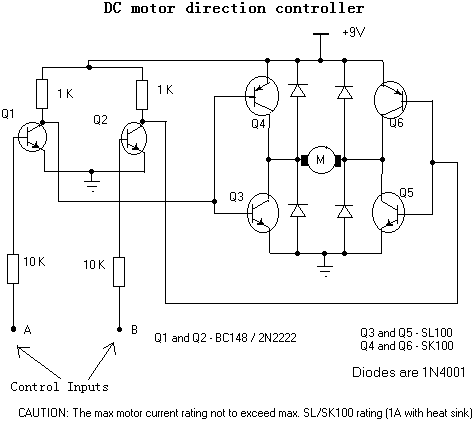
Motor direction controller
This circuit can control a small DC motor, like the one in a tape recorder. When both the points A & B are "HIGH" Q1 and Q2 are in saturation. Hence the bases of Q3 to Q6 are grounded. Hence...
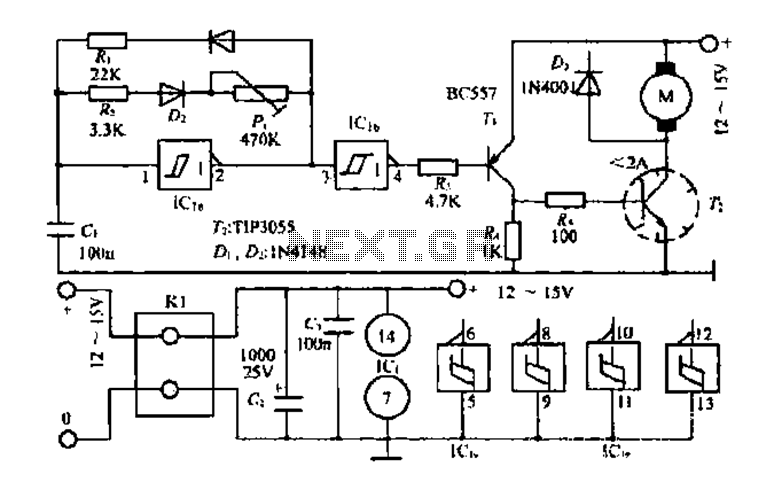
A small DC motor control circuit a
The core multi-resonant circuit 40 L06 has a collapse time of 1C. An auxiliary electric signal operates below its low threshold, opening Icl. The output is provided through two terminals for business use. The circuit includes components such as CI,...
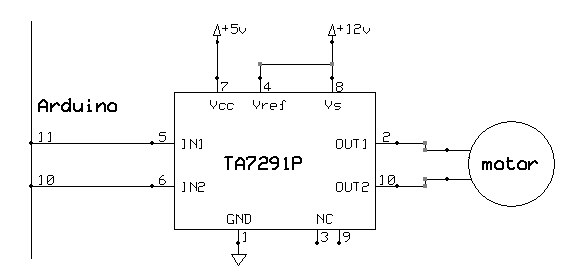
DC Motor Control
Buffer ICs (7417, 7414) were utilized to isolate the signals to and from the Arduino. This setup protected the board and provided power for external devices without drawing it from the Arduino. An H-bridge serves a similar purpose as it...