


DC motor driver circuit design using LM628 LM629 dedicated motion-control processors
#DC motor
#LM628
#LM629
#motion-control
#servo motor
#LM12
#operational amplifier
#motor driver
#brushless DC
#servomechanisms
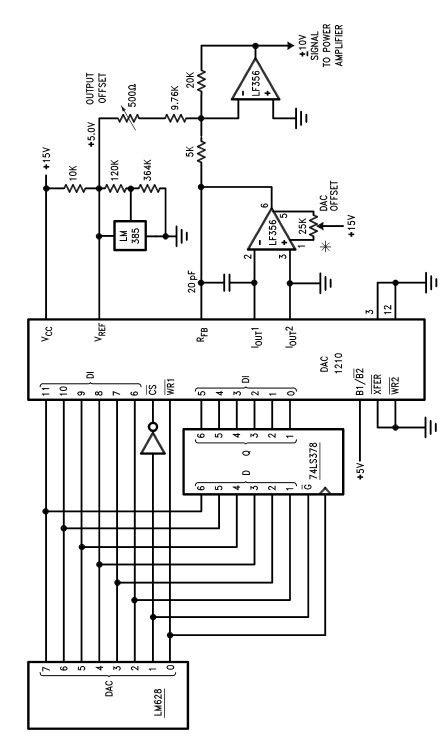
Description: The LM628 and LM629 dedicated motion-control processors can be utilized to design various applications involving DC and brushless DC servo motors, as well as other servomechanisms. The power path of this electronic project, which functions as a motor driver, is based on the LM12 high-power operational amplifier. This amplifier can also be employed in other power applications, such as motor controllers and audio amplifiers. Resistors R1 and R2 must be selected to establish the gain that provides the maximum output voltage in accordance with the maximum input voltage. This circuit is configured to achieve a gain of 2.2, enabling amplifier output saturation at ±22V with a ±10V input, assuming the power supply voltages are ±30V. It is essential to limit the amplifier gain to avoid unnecessary non-linear behavior when saturated, as the gain should be regulated by the LM628.
The circuit utilizes the LM628 and LM629 processors, which are specifically designed for motion control applications, making them suitable for managing both DC and brushless DC servo motors. The integration of the LM12 high-power operational amplifier within the motor driver circuit allows for efficient control of motor functions, providing the necessary power handling capabilities.
In the schematic, the gain-setting resistors R1 and R2 play a critical role in determining the overall gain of the amplifier circuit. By carefully selecting their values, the desired amplification can be achieved while ensuring that the output remains within the limits of the power supply. The specified gain of 2.2 is optimal for maintaining linearity in the output, particularly under conditions that approach saturation. This is crucial because exceeding the linear range can lead to distortion and inefficiencies in motor control.
The power supply configuration of ±30V is essential for achieving the required output levels, allowing the circuit to deliver ±22V at the output. This voltage range is particularly advantageous for applications requiring high torque and precise control over the motor's performance. The non-linear characteristics of the amplifier when saturated necessitate careful design considerations to ensure that the system remains stable and responsive during operation.
Overall, this motor driver circuit, leveraging the capabilities of the LM628, LM629, and LM12, presents a robust solution for various servomechanism applications, facilitating effective control of DC and brushless DC motors with high precision and reliability.Using the LM628 LM629 dedicated motion-control processors can be designed a variety of DC and brushless DC servo motors, and other servomechanisms applications. The power path of this electronic project, motor driver is based on the LM12 high power operational amplifier that can be used in some other power applications like : motor controller,
audio amplifiers or some other power applications. Resistors R1 and R2 should be chosen to set the gain to provide maximum output voltage consistent with maximum input voltage. This circuit provides a gain of 2. 2, which allows for amplifier output saturation at ±22V with a ±10V input, assuming power supply voltages of ±30V.
The amplifier gain should not be higher than necessary because the system is non-linear when saturated, and because gain should be controlled by the LM628.
The circuit utilizes the LM628 and LM629 processors, which are specifically designed for motion control applications, making them suitable for managing both DC and brushless DC servo motors. The integration of the LM12 high-power operational amplifier within the motor driver circuit allows for efficient control of motor functions, providing the necessary power handling capabilities.
In the schematic, the gain-setting resistors R1 and R2 play a critical role in determining the overall gain of the amplifier circuit. By carefully selecting their values, the desired amplification can be achieved while ensuring that the output remains within the limits of the power supply. The specified gain of 2.2 is optimal for maintaining linearity in the output, particularly under conditions that approach saturation. This is crucial because exceeding the linear range can lead to distortion and inefficiencies in motor control.
The power supply configuration of ±30V is essential for achieving the required output levels, allowing the circuit to deliver ±22V at the output. This voltage range is particularly advantageous for applications requiring high torque and precise control over the motor's performance. The non-linear characteristics of the amplifier when saturated necessitate careful design considerations to ensure that the system remains stable and responsive during operation.
Overall, this motor driver circuit, leveraging the capabilities of the LM628, LM629, and LM12, presents a robust solution for various servomechanism applications, facilitating effective control of DC and brushless DC motors with high precision and reliability.Using the LM628 LM629 dedicated motion-control processors can be designed a variety of DC and brushless DC servo motors, and other servomechanisms applications. The power path of this electronic project, motor driver is based on the LM12 high power operational amplifier that can be used in some other power applications like : motor controller,
audio amplifiers or some other power applications. Resistors R1 and R2 should be chosen to set the gain to provide maximum output voltage consistent with maximum input voltage. This circuit provides a gain of 2. 2, which allows for amplifier output saturation at ±22V with a ±10V input, assuming power supply voltages of ±30V.
The amplifier gain should not be higher than necessary because the system is non-linear when saturated, and because gain should be controlled by the LM628.
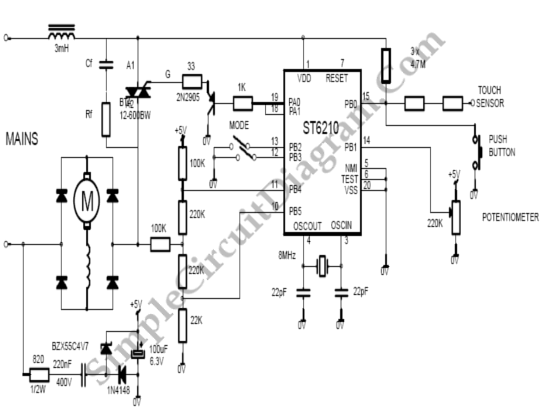
Universal DC Mode Motor Drive
A DC drive for a universal motor is depicted in the figure below. To provide DC current to the motor, a diode bridge has been integrated around the motor. The motor...
The schematic illustrates a DC drive system designed for a...
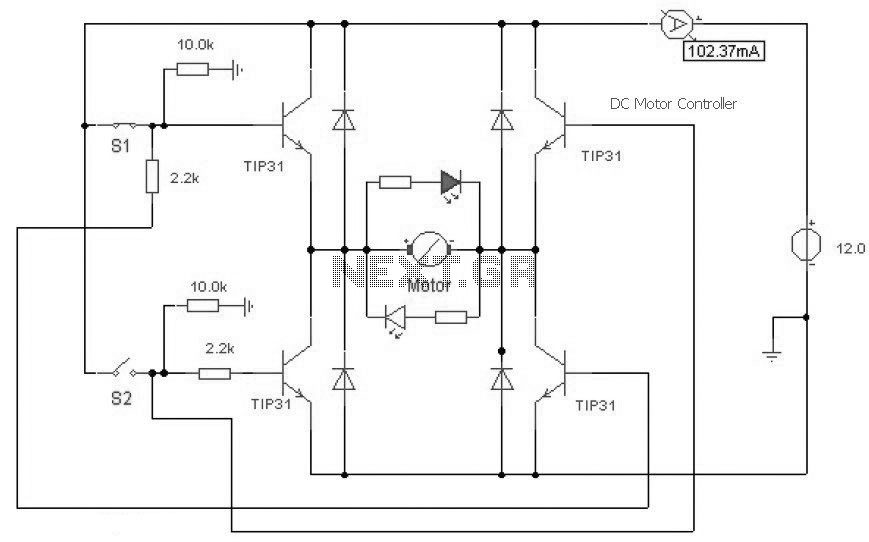
DC Motor Controller using Transistor TIP31
This is a DC motor controller circuit built using a TIP31 transistor based on the H-Bridge concept. The switches S1 and S2 are normally open, push-to-close buttons. The LED serves to indicate the direction of motor rotation.
The described DC motor...
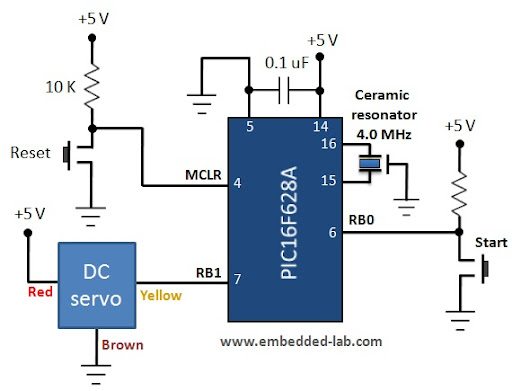
Servo motor control
A servo motor is a specialized geared DC motor that includes an electronic circuit for controlling the direction and position of the motor shaft. Due to its capability for precise angular positioning, servo motors are widely utilized in robotics, as...
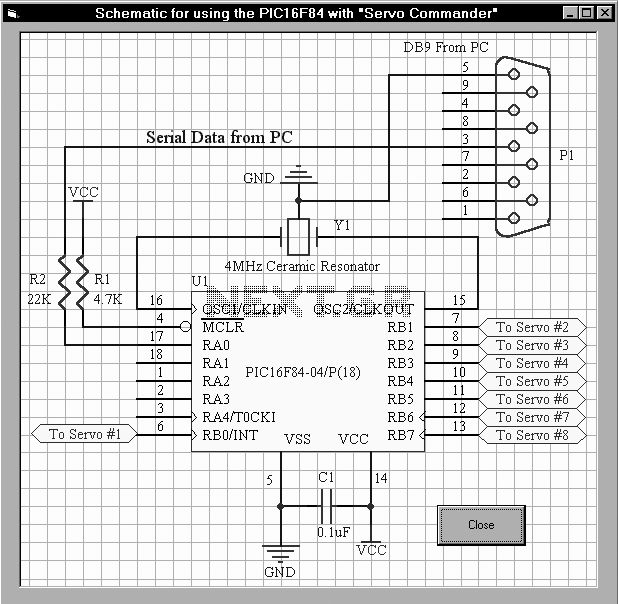
Serial Servo Motor Controller
The first servo controller project at http://www.rentron.com/servo.htm had the com port fixed at com1. This new version will seek out the available com ports on your PC and then let you select the desired port and baud rates. It has...
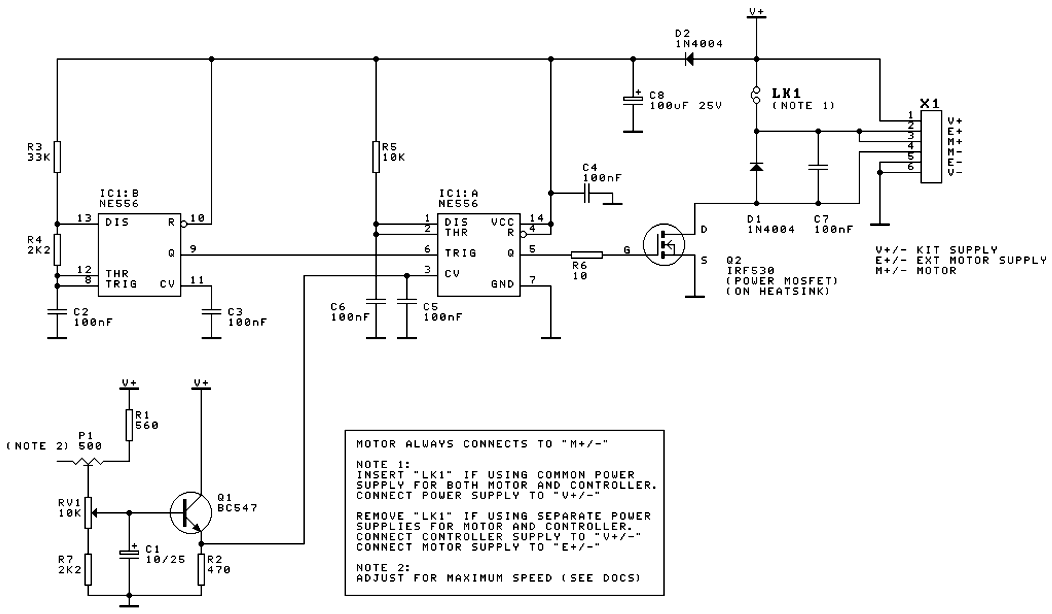
DC Motor Speed Controller
A DC motor speed controller circuit utilizes two timers configured as a Pulse Width Modulator (PWM). The integrated circuit employed for this purpose is the NE556, which is a dual timer/oscillator using NMOS technology.
The DC motor speed controller circuit operates...
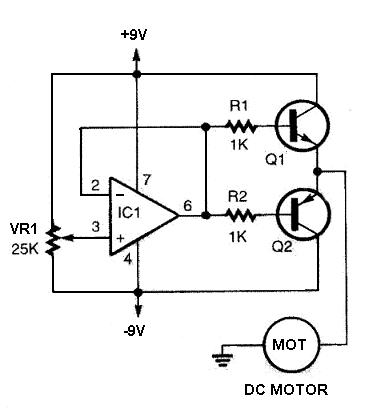
bidirectional dc motor driver schematic
The DC motor driver circuit depicted in the images can be utilized for controlling DC motors, allowing for bidirectional rotation and adjustable speed. This straightforward circuit is constructed using a 741 operational amplifier (op-amp) as a voltage comparator, along with...
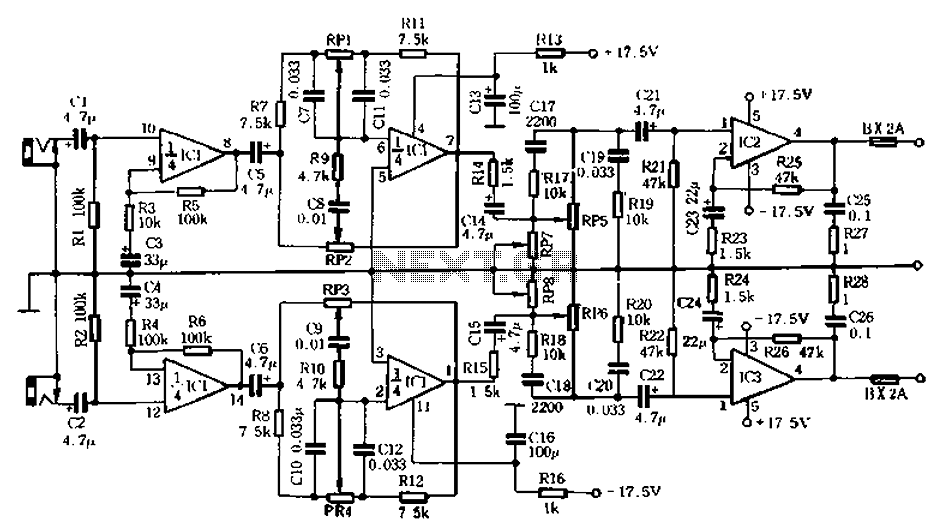
Homemade whole integrated circuit amplifiers 01
The circuit depicted in Figure 5-60 and Figure 6 utilizes an operational amplifier (op-amp) configured as a channel pre-amplifier to address the signal loss introduced by the tone control circuit. Additionally, another group of op-amps forms a channel-driven stage amplifier...
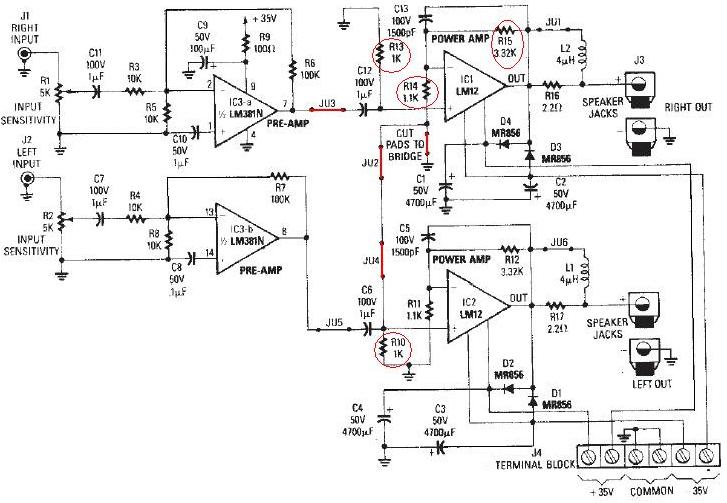
LM12 audio amplifier circuit diagram electronic project
The LM12 audio amplifier circuit is designed to deliver high output power for 8 ohm or 4 ohm load impedances. The maximum output power provided by the LM12 audio amplifier is approximately 60 watts for a 4 ohm load and...
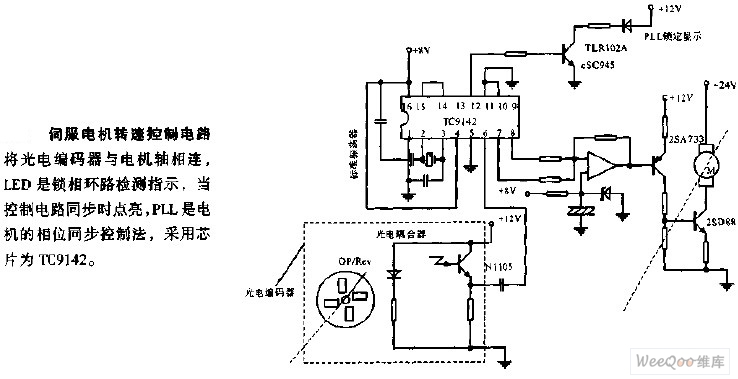
Servo motor speed control circuit
The servo motor speed control circuit connects the photoelectric encoder to the motor shaft. The LED serves as an indicator light for the phase-locked loop (PLL) detection, illuminating when the control circuit is synchronized. The PLL employs a phase synchronous...