


Serial Servo Motor Controller
#servo motor
#PC control
#serial communication
#baud rate
#com port
#hobby servo
#microcontroller
#automation
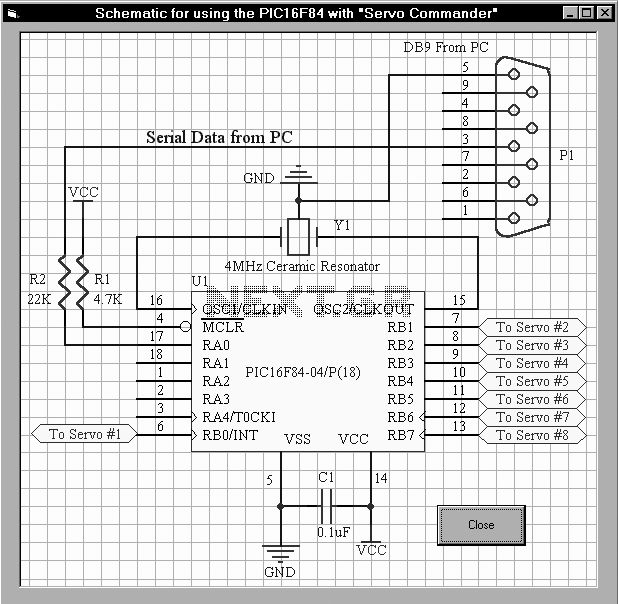
Description: The first servo controller project at http://www.rentron.com/servo.htm had the com port fixed at com1. This new version will seek out the available com ports on your PC and then let you select the desired port and baud rates. It has 1 additional servo port as well to let you control a total of 8 hobby servo motors from the PC.
The servo controller described is an advanced interface designed for controlling multiple hobby servo motors through a personal computer (PC). This project builds upon previous iterations by introducing enhanced capabilities for port selection and communication speed, thereby improving user experience and flexibility.
The core functionality of this servo controller involves interfacing with the PC's serial communication ports. The system is programmed to automatically detect available COM ports, which allows users to select their desired port dynamically. This feature is particularly beneficial in environments where multiple devices may be connected to the PC, as it eliminates the need for manual configuration of the COM port.
In addition to the improved port selection, the controller also allows users to set baud rates, which are critical for ensuring reliable communication between the PC and the servo motors. The ability to adjust baud rates accommodates a variety of setups and ensures compatibility with different hardware configurations.
The controller supports up to eight hobby servo motors, providing an additional servo port beyond the standard configuration. This expanded capability allows for more complex projects, such as robotic arms or automated systems, where multiple servos must be coordinated simultaneously.
The circuit design likely includes a microcontroller that manages communication with the PC and controls the output signals to the servo motors. The microcontroller interprets commands received from the PC and generates the appropriate pulse-width modulation (PWM) signals required to control the position of each servo motor.
Power management is also a crucial aspect of the design, as hobby servos can draw significant current. The circuit should incorporate power regulation components to ensure stable operation without overloading the system. Additionally, proper isolation and protection circuits are recommended to safeguard the microcontroller and other sensitive components from voltage spikes or noise generated by the servos.
Overall, this servo controller project provides a comprehensive solution for hobbyists and engineers looking to implement servo motor control in their applications, combining ease of use with robust functionality.The first servo controller project at http://www.rentron.com/servo.htm had the com port fixed at com1. This new version will seek out the available com ports on your PC and then let you select the desired port and baud rates.
It has 1 additional servo port as well to let you control a total of 8 hobby servo motors from the PC.
The servo controller described is an advanced interface designed for controlling multiple hobby servo motors through a personal computer (PC). This project builds upon previous iterations by introducing enhanced capabilities for port selection and communication speed, thereby improving user experience and flexibility.
The core functionality of this servo controller involves interfacing with the PC's serial communication ports. The system is programmed to automatically detect available COM ports, which allows users to select their desired port dynamically. This feature is particularly beneficial in environments where multiple devices may be connected to the PC, as it eliminates the need for manual configuration of the COM port.
In addition to the improved port selection, the controller also allows users to set baud rates, which are critical for ensuring reliable communication between the PC and the servo motors. The ability to adjust baud rates accommodates a variety of setups and ensures compatibility with different hardware configurations.
The controller supports up to eight hobby servo motors, providing an additional servo port beyond the standard configuration. This expanded capability allows for more complex projects, such as robotic arms or automated systems, where multiple servos must be coordinated simultaneously.
The circuit design likely includes a microcontroller that manages communication with the PC and controls the output signals to the servo motors. The microcontroller interprets commands received from the PC and generates the appropriate pulse-width modulation (PWM) signals required to control the position of each servo motor.
Power management is also a crucial aspect of the design, as hobby servos can draw significant current. The circuit should incorporate power regulation components to ensure stable operation without overloading the system. Additionally, proper isolation and protection circuits are recommended to safeguard the microcontroller and other sensitive components from voltage spikes or noise generated by the servos.
Overall, this servo controller project provides a comprehensive solution for hobbyists and engineers looking to implement servo motor control in their applications, combining ease of use with robust functionality.The first servo controller project at http://www.rentron.com/servo.htm had the com port fixed at com1. This new version will seek out the available com ports on your PC and then let you select the desired port and baud rates.
It has 1 additional servo port as well to let you control a total of 8 hobby servo motors from the PC.
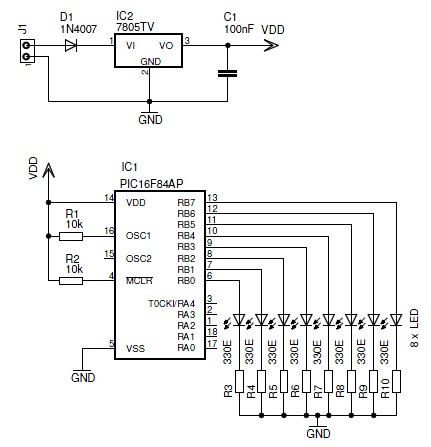
knight Rider
A light computer has been developed that simulates the scanning effect seen in the KITT car from the TV series Knight Rider. The design utilizes a microcontroller, specifically the PIC16F84A, instead of the commonly used CD4017 counter IC. This choice...
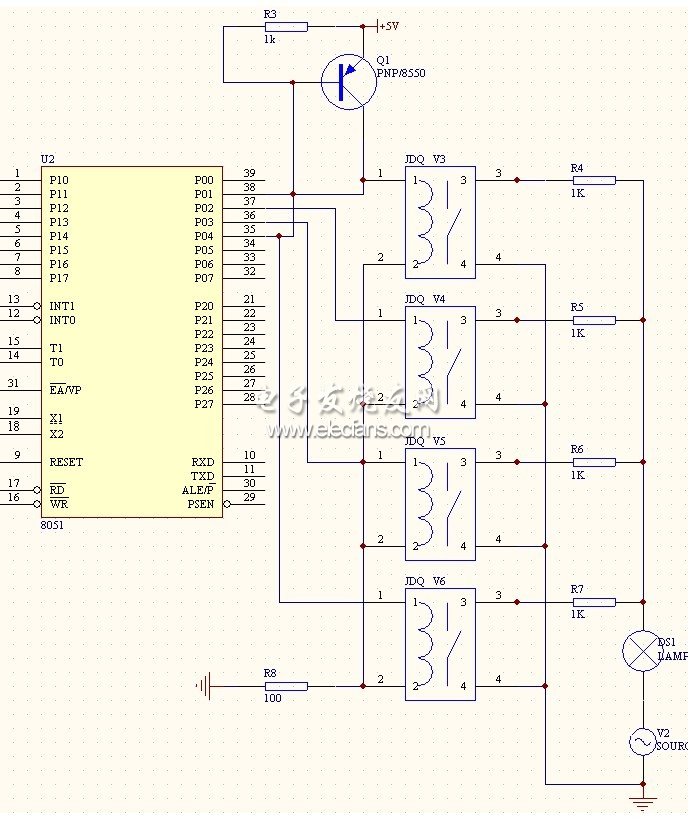
Cipher scheme of the module of infrared remote-control between two parties of intellectual family
This system is a control system based on a single-chip computer that allows for remote operation of lighting. The scheme primarily addresses the transmission and reception of signals, as well as program manipulation of various signals once they are processed...
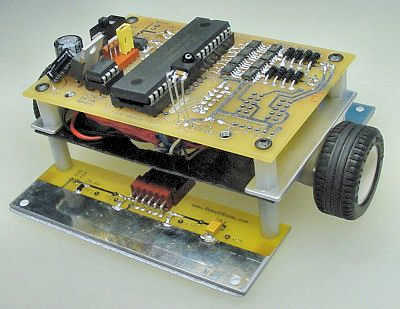
Jet
The microcontroller is able to make about 7000 complete line-following decisions per second, which is almost 7 decisions per millimeter when the robot is going full speed. By upping the clock, unrolling loops, and removing my wireless debugging and extraneous...
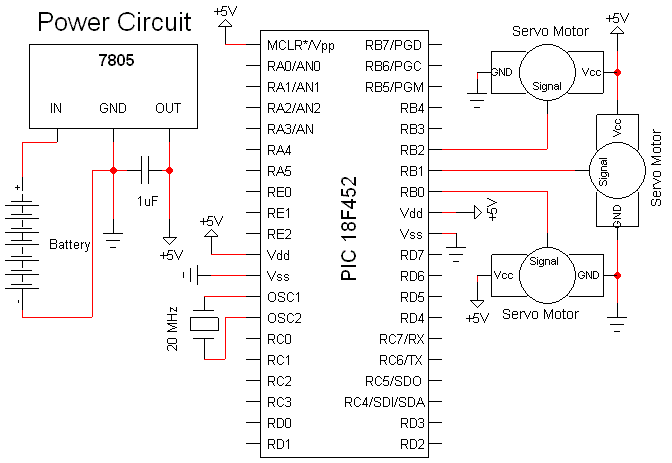
Servo Motor Control Circuit
The Olimex P-40 development board will be utilized, though the circuit can also be constructed on a breadboard due to its simplicity. The schematic for the initial implementation of servo control is provided below. Servos, like any motors, can draw...
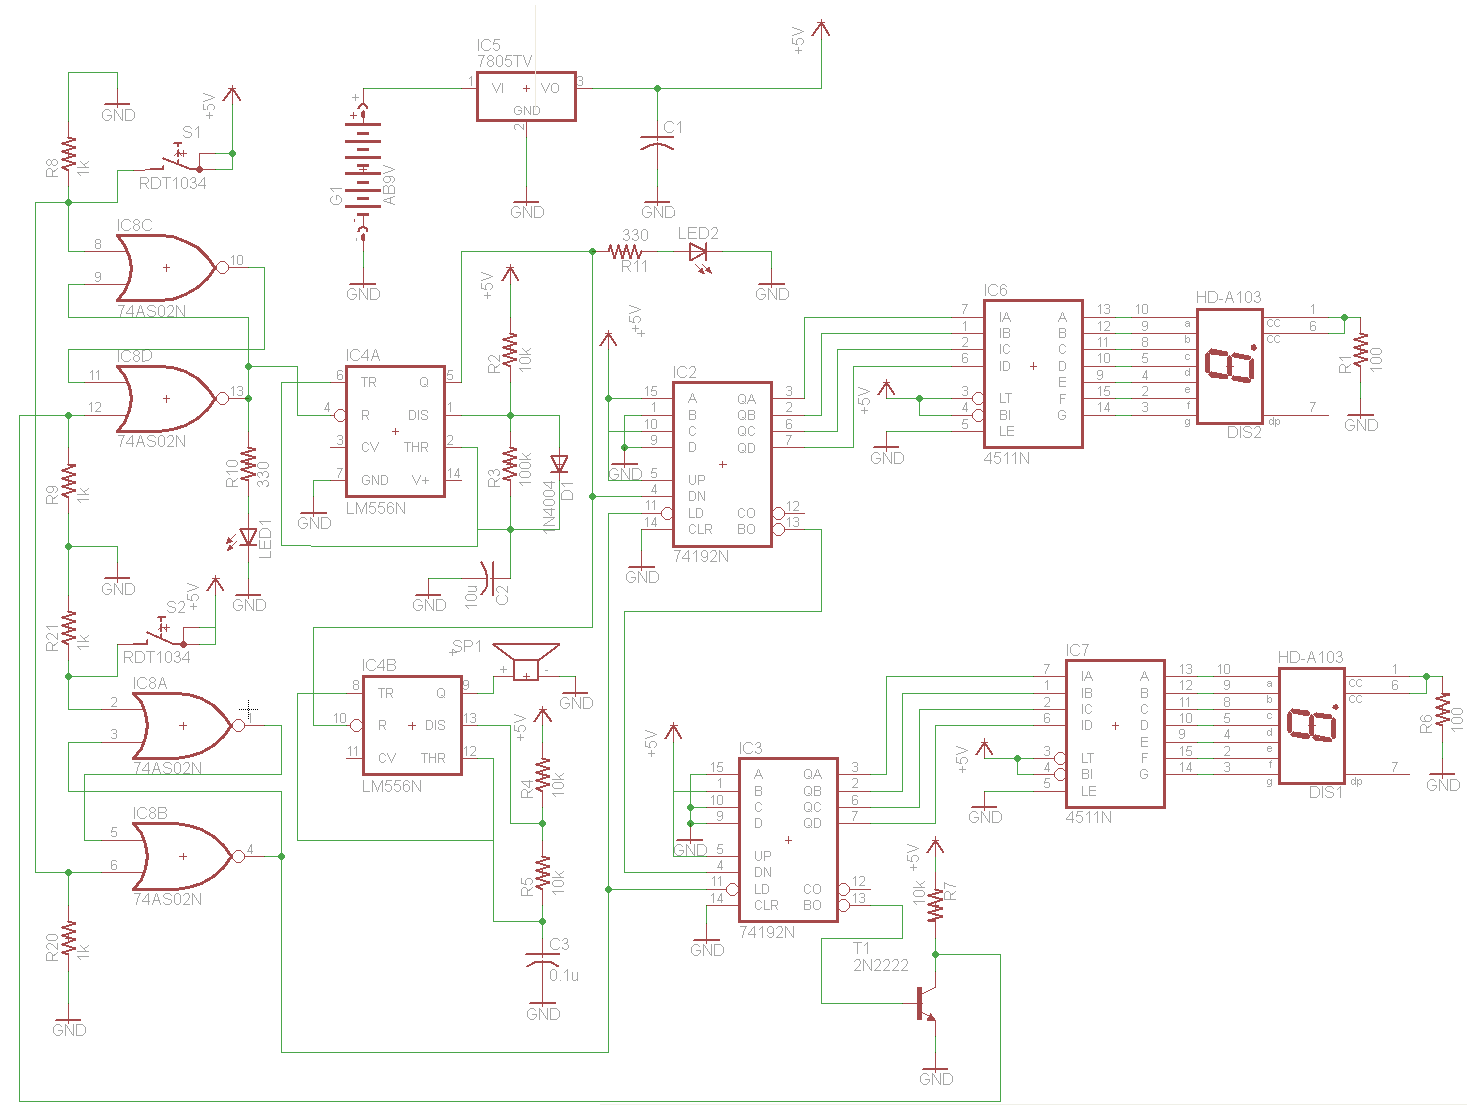
Robot Motor Control Schematic
The schematic for controlling the motors is divided into three main sections, each serving a distinct function. The primary components featured in the schematic include the PIC 18F252 microcontroller, the SN754410 motor driver, and 2N2222 transistors. At the top of...
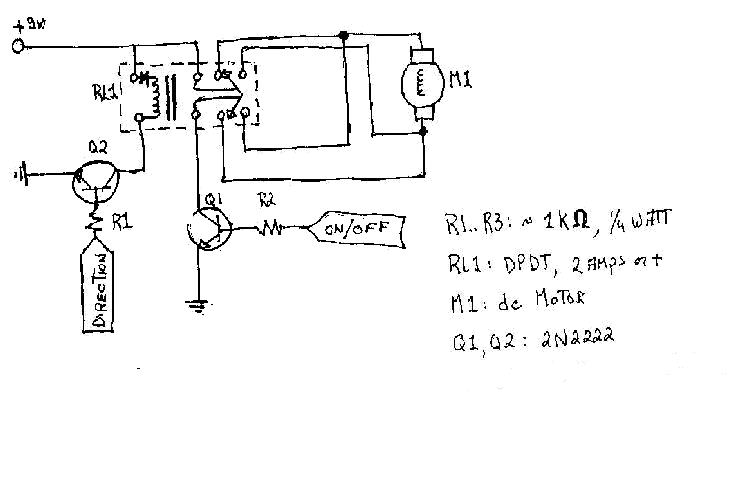
PC based Robot Circuit
To create the circuitry described, a computer software capable of controlling a parallel port is required, with an estimated cost of approximately $30. For instance, a transistor (model number 2N2222) is priced around $0.50, while a DPDT relay costs about...
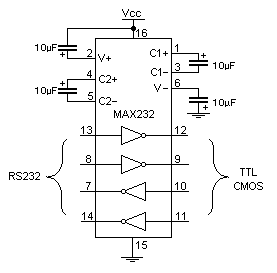
Microcontroller interfacing with RS 232
Standard serial interfacing of a microcontroller (TTL) with a PC or any RS232C standard device requires a TTL to RS232 level converter. A MAX232 is used for this purpose. It provides a 2-channel RS232C port and requires external 10µF capacitors.
The...
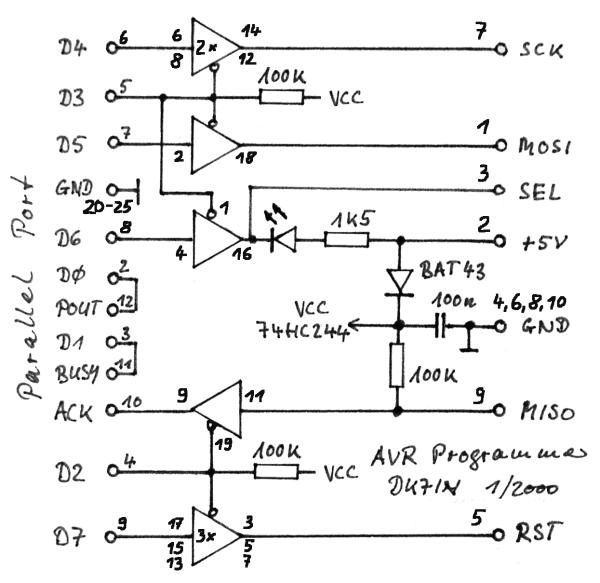
Microcontroller
The gap between TTL (Transistor-Transistor Logic) devices and personal computers can be effectively bridged with modern microcontrollers. These microcontrollers not only incorporate a central processing unit (CPU) but also include program and data memory, EEPROM, input/output (I/O) ports, timers, and...
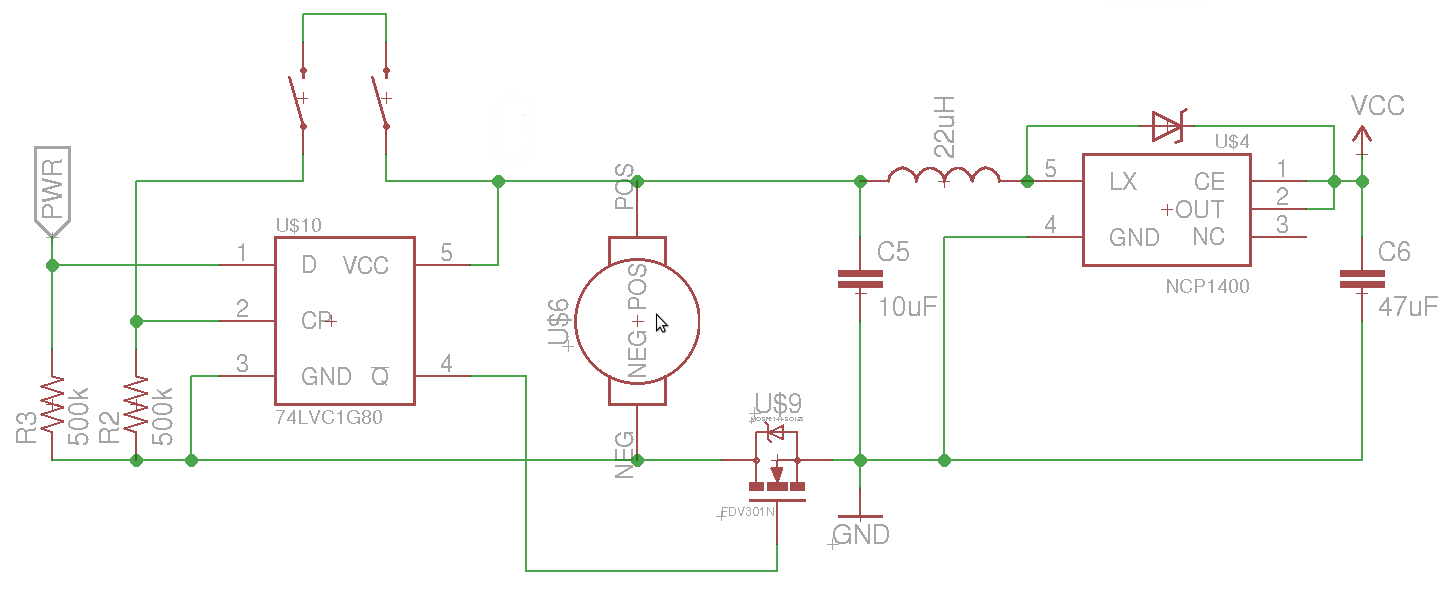
mosfet Turning a microcontroller on with a flip flop
The objective is to control the power to a load, specifically an 8051-based microcontroller (uC), using two switches. When the uC is powered on, it sets the PWR pin high. Upon pressing the switches again, pin 4 of the flip-flop...