


Servo Motor Control Circuit
#servo motor
#Olimex P-40
#breadboard
#high current
#battery
#motor driver
#PWM
#control circuit
#development board
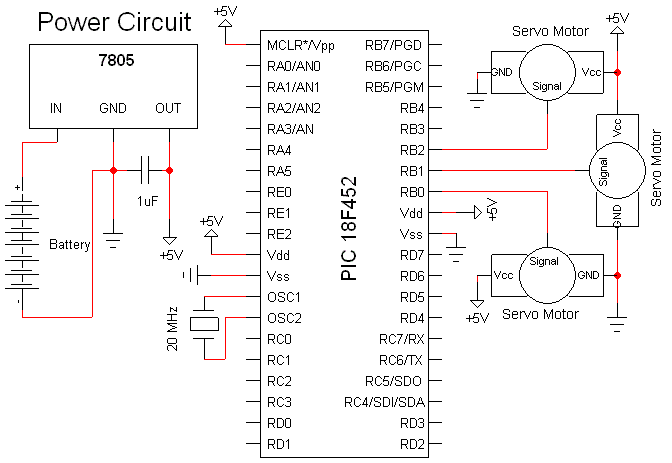
Description: The Olimex P-40 development board will be utilized, though the circuit can also be constructed on a breadboard due to its simplicity. The schematic for the initial implementation of servo control is provided below. Servos, like any motors, can draw significant current; therefore, it is essential to ensure that the power supply can accommodate high currents. In this case, only one or two servos are being used, so current should not pose a problem. The servos in use are rated for 4.8V to 6V, and for the purposes of this tutorial, a 5V supply is being used, which will not damage the servos. Operation within the range of 4.8V to 6V is safe, and the higher voltage can enhance the torque of the servos. In robotics, it is common to operate multiple servos simultaneously; thus, the multi-servo schematic closely resembles the single servo schematic, but the software method for controlling three servos at once differs significantly. Three pins, RB0, RB1, and RB2, are designated for outputting PWM control signals to the three servos. These pin names will be referenced again in the following section.
The described circuit utilizes the Olimex P-40 development board as a platform for controlling servos, which are critical components in various robotic applications. The schematic diagram illustrates the connection between the development board and the servos, with particular attention paid to power supply considerations. Given that servos can draw substantial current, it is advisable to select a power source capable of delivering sufficient current without voltage drop, especially when multiple servos are in operation.
The servos specified operate effectively within a voltage range of 4.8V to 6V, with a nominal supply of 5V being used in this implementation. This choice simplifies the circuit design while ensuring safe operation. The increased voltage supply can enhance the servos' torque, which is advantageous for applications requiring more force.
In scenarios where multiple servos are involved, the circuit design must accommodate simultaneous control. The schematic for controlling three servos demonstrates the use of pulse-width modulation (PWM) signals emitted from three designated pins on the development board—RB0, RB1, and RB2. Each pin corresponds to a specific servo, allowing for coordinated movement and control. The software controlling these pins must be designed to handle concurrent signals, which may involve implementing a timing mechanism to ensure that each servo receives the correct PWM signal at the appropriate intervals.
This setup is particularly beneficial in robotics, where multiple actions often occur simultaneously, necessitating precise control over each servo's position and movement. The integration of multiple servos into a single control scheme exemplifies the complexity and versatility required in robotic design, making it crucial to understand both the hardware and software components involved in such systems.Although we`ll be using the Olimex P-40 development board, you can also breadboard out the circuit as it is very simple. The schematic for our first pass at controlling a servo is shown below. Servos can start to sink alot of current like any motors so it is wise to be sure that your batteries can handle high currents.
Since we`re only using 1 or 2 servos, current won`t be an issue. You may have noticed that the servos we`re using are rated at 4. 8v & 6v. We`re hooking 5v to the servos in this tutorial just to make things easier. This will not harm the servos in any way. They can be safely operated between 4. 8 and 6 volts. The increase in voltage gives the servos more torque. One thing about robotics is that you are never ever doing only 1 thing at a time. When it comes to using servos in robotics it is very common that your project will have 2, 3 or even 4 servos that need to be operated at once. The multi servo schematic below is not very different from the single servo schematic above, but the software method for controlling the 3 servos simultaneously is intuitively different.
We`ll go over this in detail in the next section. 3 Pins are used to output control PWM signals to the 3 servos. RB0, RB1 & RB2. Don`t forget these names because in the next section we`ll see them again.
The described circuit utilizes the Olimex P-40 development board as a platform for controlling servos, which are critical components in various robotic applications. The schematic diagram illustrates the connection between the development board and the servos, with particular attention paid to power supply considerations. Given that servos can draw substantial current, it is advisable to select a power source capable of delivering sufficient current without voltage drop, especially when multiple servos are in operation.
The servos specified operate effectively within a voltage range of 4.8V to 6V, with a nominal supply of 5V being used in this implementation. This choice simplifies the circuit design while ensuring safe operation. The increased voltage supply can enhance the servos' torque, which is advantageous for applications requiring more force.
In scenarios where multiple servos are involved, the circuit design must accommodate simultaneous control. The schematic for controlling three servos demonstrates the use of pulse-width modulation (PWM) signals emitted from three designated pins on the development board—RB0, RB1, and RB2. Each pin corresponds to a specific servo, allowing for coordinated movement and control. The software controlling these pins must be designed to handle concurrent signals, which may involve implementing a timing mechanism to ensure that each servo receives the correct PWM signal at the appropriate intervals.
This setup is particularly beneficial in robotics, where multiple actions often occur simultaneously, necessitating precise control over each servo's position and movement. The integration of multiple servos into a single control scheme exemplifies the complexity and versatility required in robotic design, making it crucial to understand both the hardware and software components involved in such systems.Although we`ll be using the Olimex P-40 development board, you can also breadboard out the circuit as it is very simple. The schematic for our first pass at controlling a servo is shown below. Servos can start to sink alot of current like any motors so it is wise to be sure that your batteries can handle high currents.
Since we`re only using 1 or 2 servos, current won`t be an issue. You may have noticed that the servos we`re using are rated at 4. 8v & 6v. We`re hooking 5v to the servos in this tutorial just to make things easier. This will not harm the servos in any way. They can be safely operated between 4. 8 and 6 volts. The increase in voltage gives the servos more torque. One thing about robotics is that you are never ever doing only 1 thing at a time. When it comes to using servos in robotics it is very common that your project will have 2, 3 or even 4 servos that need to be operated at once. The multi servo schematic below is not very different from the single servo schematic above, but the software method for controlling the 3 servos simultaneously is intuitively different.
We`ll go over this in detail in the next section. 3 Pins are used to output control PWM signals to the 3 servos. RB0, RB1 & RB2. Don`t forget these names because in the next section we`ll see them again.
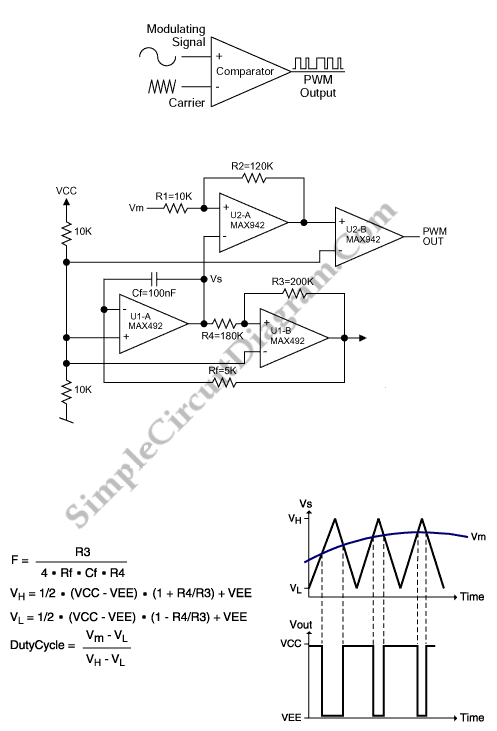
PWM Modulator Using Op-Amp
This is a simple PWM modulator circuit. Comparing the message signal to a ramp or triangular waveform is the simplest way to produce a PWM signal. When the...
The PWM (Pulse Width Modulation) modulator circuit operates by comparing a modulating signal,...

Can produce circuits within the range of 1-99% duty cycle of the digital set-precision PWM wave
The circuit described is a crystal oscillation circuit using a CM OS inverting configuration, designed to ensure accurate operation. It employs a BCD counter (IC2) capable of achieving a maximum oscillation frequency of 2 MHz, which is 100 times the...
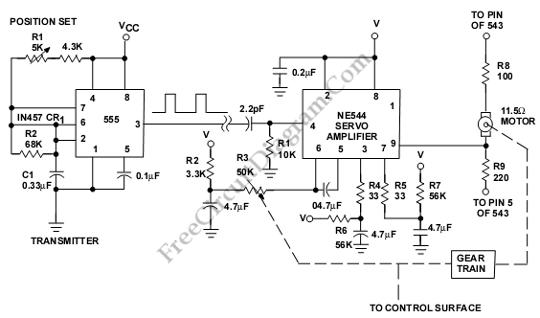
Servo Motor System Controller
This is a servo system controller circuit designed for remote control of a servo motor. The circuit utilizes a 555 timer and requires only six additional components.
The servo system controller circuit operates by generating a pulse-width modulation (PWM) signal, which...
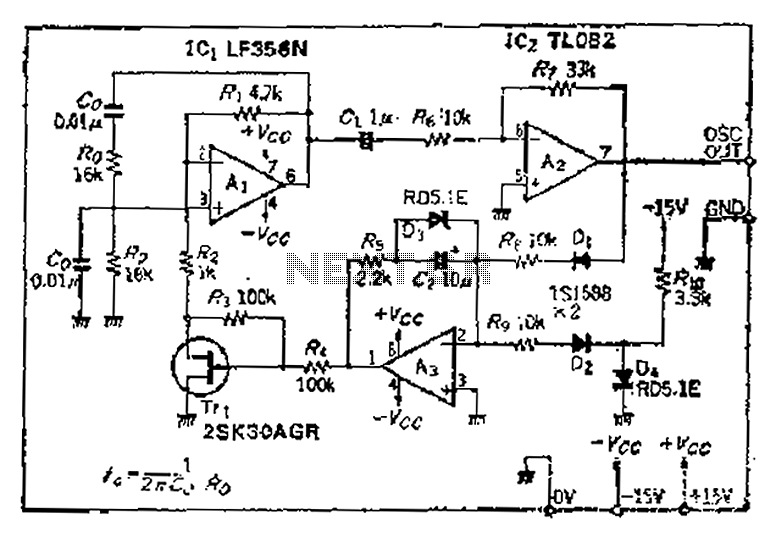
And put the intermodal server preamplifier circuit diagram
The intermodal servo preamplifier circuit operates at 115V and 60Hz, designed to provide a differential output for a servo motor amplifier. It features an inverting connection using an operational amplifier (op-amp), along with an additional op-amp configured to create a...
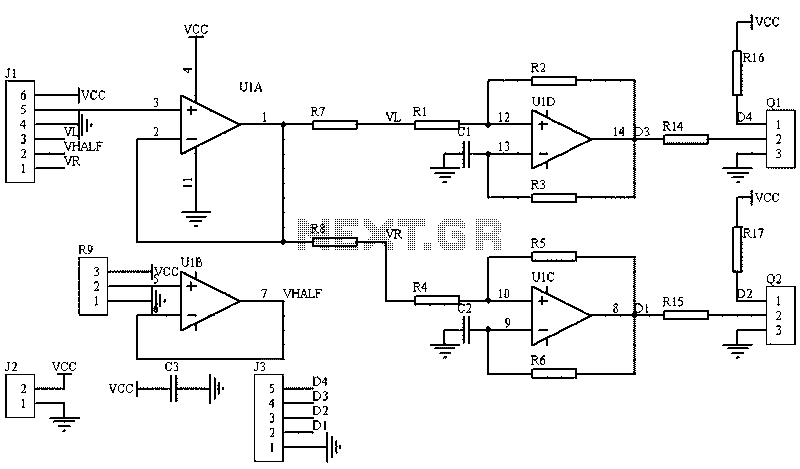
Circuit diagram of an analog circuit PWM
The image illustrates a circuit that utilizes a linear potentiometer (or linear Hall element) to control the PWM generation for two chassis drive motors in a gamepad or joystick used in model aircraft. J1 represents the handle of the potentiometer,...
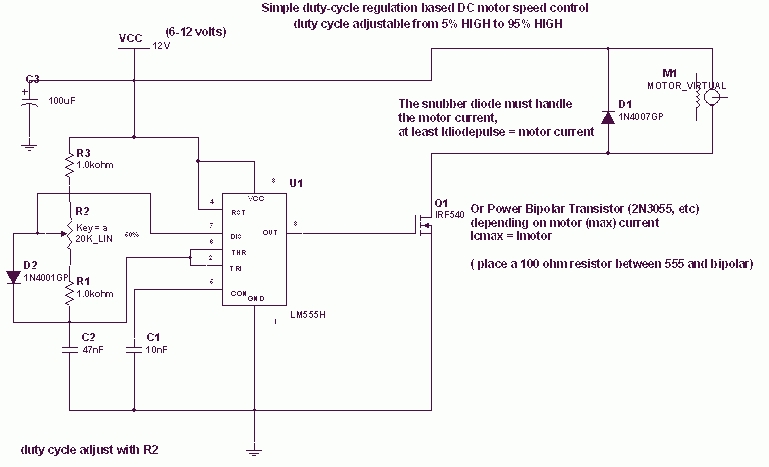
DC motor PWM speed control
The 555 IC is wired as an astable and the frequency is constant and independent of the duty cycle, as the total resistance (R charge + R discharge, notice the diode) is constant and equal to 22Kohm (giving a frequency...
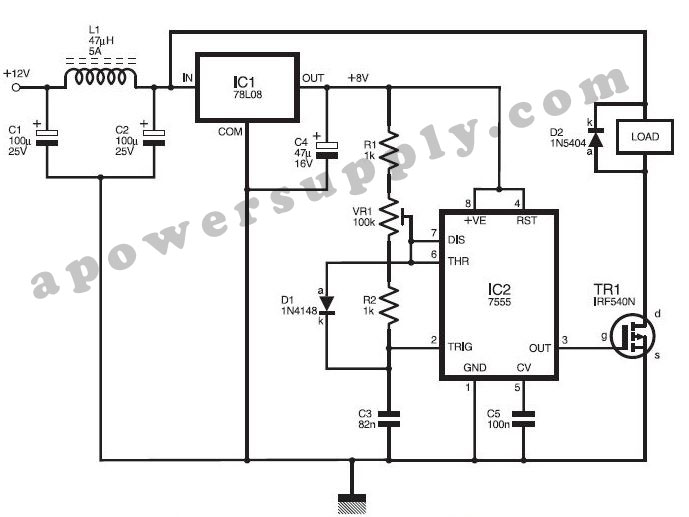
PWM DC Power Controller
This DC power supply controller is regulated by pulse width modulation (PWM), which is generated by a circuit utilizing timer IC2 7555 according to a specific duty cycle formula.
The described DC power supply controller employs a timer IC, specifically the...
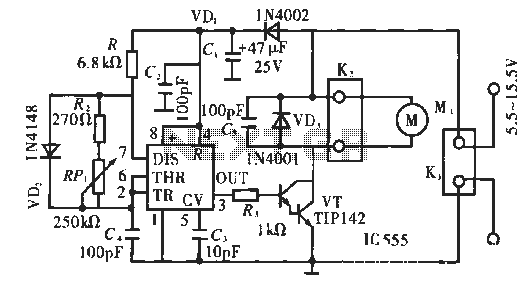
PWM DC motor speed control circuit
The circuit operates using pulse position modulation, which is a method distinct from the more commonly utilized pulse width modulation for speed control. A 555 timer is employed as a square wave modulator, generating output pulses with a fixed width...
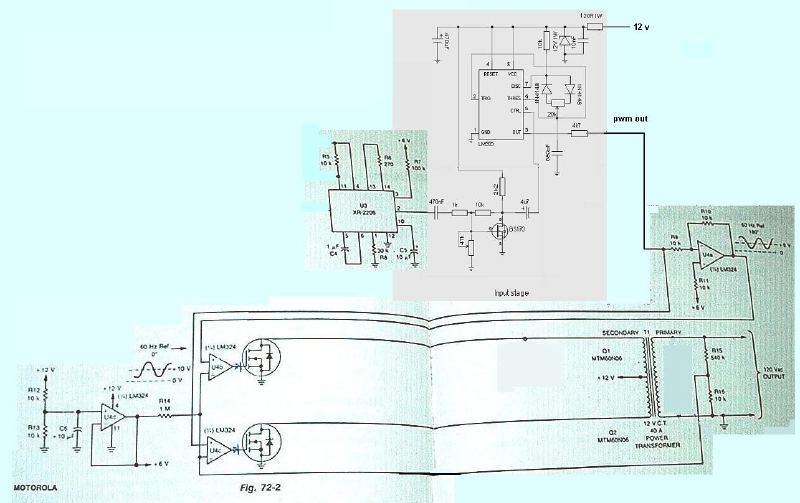
About a PWM power inverter
A few months ago, a search was conducted for an easy-to-build PWM inverter that does not require any PIC programming. The investigation led to a consideration of a 555 PWM amplifier circuit.
The 555 timer IC is widely used in various...