


Robot Motor Control Schematic
#microcontroller
#PIC 18F252
#SN754410
#2N2222
#motor driver
#crystal oscillator
#LED indicators
#circuit schematic
Description: The schematic for controlling the motors is divided into three main sections, each serving a distinct function. The primary components featured in the schematic include the PIC 18F252 microcontroller, the SN754410 motor driver, and 2N2222 transistors. At the top of the schematic, the microcontroller circuit is represented by the PIC 18F252, accompanied by its 40 MHz crystal oscillator, several LEDs, and the enable lines that connect to the motor controller. Additionally, pulse-width modulation (PWM) signals are directed to both the PWM inversion circuit and the motor controller. Two 2N2222 transistors are utilized to invert the two PWM signals sent to the motor controller. This inversion is necessary because the motor controller requires both a positive and a negative PWM signal, forming what is known as a differential pair. The absence of either signal would prevent the motor controller from effectively managing the DC motors. The primary component responsible for motor control in this circuit is the SN754410, a quad half H-bridge motor controller integrated circuit (IC). To operate this motor controller, a differential PWM signal must be supplied, along with appropriate power and ground connections, and the enable pin must be activated to initiate motor operation. Control signals from the PIC microcontroller are responsible for managing these functions.
The motor control schematic is designed to facilitate the operation of DC motors using a microcontroller-based system. The PIC 18F252 serves as the central processing unit, executing control algorithms that dictate motor behavior based on input conditions. The 40 MHz crystal oscillator ensures stable timing for PWM generation, which is crucial for speed and direction control of the motors.
The SN754410 motor driver IC is a critical component in this design, capable of driving two DC motors independently. Its H-bridge configuration allows for bidirectional control, enabling the motors to rotate in both clockwise and counterclockwise directions. The differential PWM signals generated by the PIC are essential for controlling the speed and direction of the motors. By modulating the duty cycle of these PWM signals, the effective voltage applied to the motors can be adjusted, thereby controlling their speed.
The inclusion of the 2N2222 transistors for PWM signal inversion is a strategic choice that ensures the motor driver receives the necessary signals in the correct format. The transistors act as switches that invert the PWM signals, creating the required positive and negative outputs for the motor controller. This configuration is vital for achieving precise control over the motors, as it allows for rapid switching between the high and low states of the PWM signals.
In summary, this motor control schematic effectively integrates a microcontroller, motor driver, and signal inversion circuitry to provide a robust solution for controlling DC motors. The design emphasizes the importance of differential PWM signals, ensuring that the motors can be operated efficiently and reliably under various conditions.The schematic for controlling the motors is split up into three main parts, with each part having a unique functionality. The main parts used and seen in the schematic below are the 18F252, SN754410 and 2N2222 Transistors. Seen at the very top, the microcontroller circuit consists of the PIC 18F252, its 40 MHz crystal, a few LEDs, the enable l
ines going to the motor controller and the PWM signals going to the PWM inversion circuit and the motor controller. Two transistors ( 2n2222 ) are used to invert the two PWM signals that are travelling to the motor controller.
This is done because the motor controller needs to have both the `positive` PWM signal and the `negative` PWM signal in what is called a differential pair. The motor controller cannot control our DC motors without both the positive and negative PWM signals.
The main part used for the motor control circuit is the SN754410. This is a quadrule half h-bridge motor controller IC. To use this motor controller, you must input a differential PWM signal, provide power and ground and enable the bank to start-up your motors. The control signals that will tell the motor controller to do all this will be sent from the PIC.
The motor control schematic is designed to facilitate the operation of DC motors using a microcontroller-based system. The PIC 18F252 serves as the central processing unit, executing control algorithms that dictate motor behavior based on input conditions. The 40 MHz crystal oscillator ensures stable timing for PWM generation, which is crucial for speed and direction control of the motors.
The SN754410 motor driver IC is a critical component in this design, capable of driving two DC motors independently. Its H-bridge configuration allows for bidirectional control, enabling the motors to rotate in both clockwise and counterclockwise directions. The differential PWM signals generated by the PIC are essential for controlling the speed and direction of the motors. By modulating the duty cycle of these PWM signals, the effective voltage applied to the motors can be adjusted, thereby controlling their speed.
The inclusion of the 2N2222 transistors for PWM signal inversion is a strategic choice that ensures the motor driver receives the necessary signals in the correct format. The transistors act as switches that invert the PWM signals, creating the required positive and negative outputs for the motor controller. This configuration is vital for achieving precise control over the motors, as it allows for rapid switching between the high and low states of the PWM signals.
In summary, this motor control schematic effectively integrates a microcontroller, motor driver, and signal inversion circuitry to provide a robust solution for controlling DC motors. The design emphasizes the importance of differential PWM signals, ensuring that the motors can be operated efficiently and reliably under various conditions.The schematic for controlling the motors is split up into three main parts, with each part having a unique functionality. The main parts used and seen in the schematic below are the 18F252, SN754410 and 2N2222 Transistors. Seen at the very top, the microcontroller circuit consists of the PIC 18F252, its 40 MHz crystal, a few LEDs, the enable l
ines going to the motor controller and the PWM signals going to the PWM inversion circuit and the motor controller. Two transistors ( 2n2222 ) are used to invert the two PWM signals that are travelling to the motor controller.
This is done because the motor controller needs to have both the `positive` PWM signal and the `negative` PWM signal in what is called a differential pair. The motor controller cannot control our DC motors without both the positive and negative PWM signals.
The main part used for the motor control circuit is the SN754410. This is a quadrule half h-bridge motor controller IC. To use this motor controller, you must input a differential PWM signal, provide power and ground and enable the bank to start-up your motors. The control signals that will tell the motor controller to do all this will be sent from the PIC.
Single IC chip Motor Driver for robots
A motor driver is required in pretty much all walkers including all of my CW series walkers. You need to use it any time you need to supply more current to the motors because the circuit can't supply enough. This...
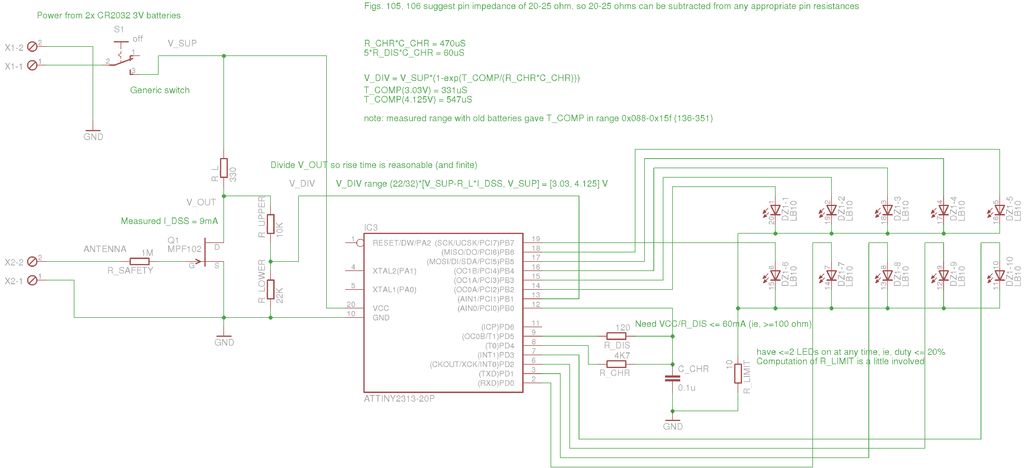
Microcontroller interface electrometer
A method for measuring static electricity for a science project was sought. An old copy of "Getting Started in Electronics" by Forrest M. Mims III was referenced for guidance.
To create a static electricity measurement circuit, a simple design can be...
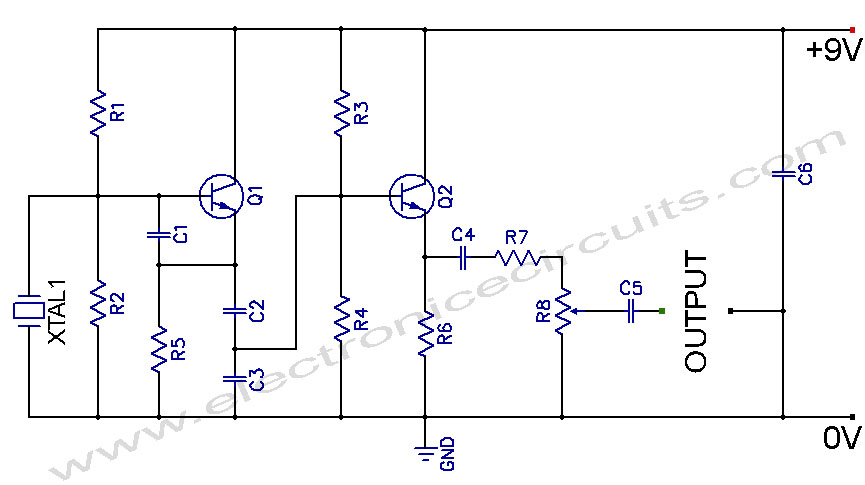
Crystal Controlled Oscillator Circuit
Crystal Controlled Oscillator Circuit. This general-purpose signal source is highly effective in signal-tracing applications. The output level is adjustable.
The crystal-controlled oscillator circuit is designed to provide a stable and precise frequency output, which is essential for various electronic applications, particularly...
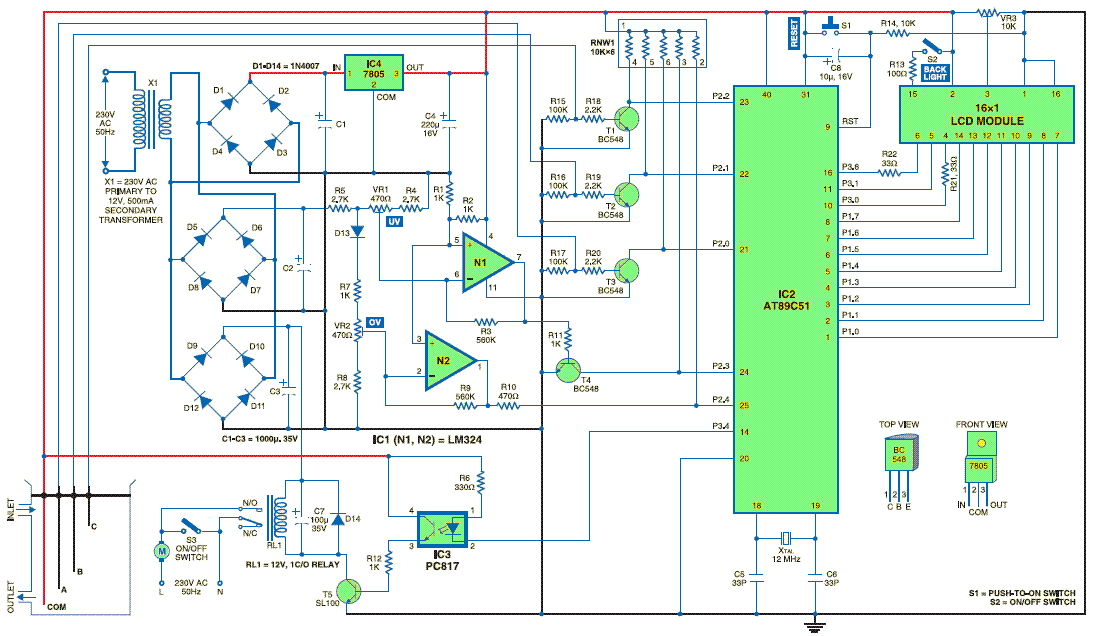
Water Level controller
The microcontroller-based water level controller and motor protector manages the on and off states of the motor based on the water level in the overhead tank (OHT). It regulates the tank's water level through a microcontroller, thereby providing automatic protection...
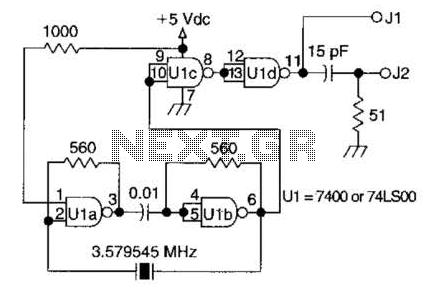
Wide-Range Crystal Oscillator Circuit
A circuit utilizing one 7400 TTL can operate with fundamental type crystals ranging from 1 to approximately 13 MHz. The output is rich in harmonics, making this oscillator suitable for calibration and testing applications.
The circuit in question employs a 7400...
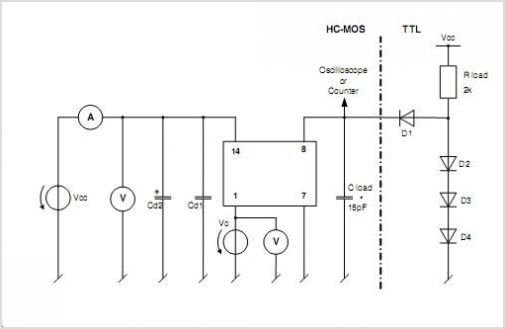
OCXOW-AR1 OCXOW Oven Controlled Crystal Oscillator
The OPB350 series liquid sensor is designed to operate with clear tubes of various outer diameters: 1/16 inch (1.6 mm), 1/8 inch (3.2 mm), 3/16 inch (4.8 mm), and 1/4 inch (6.3 mm). When integrated with output reference circuitry, it...
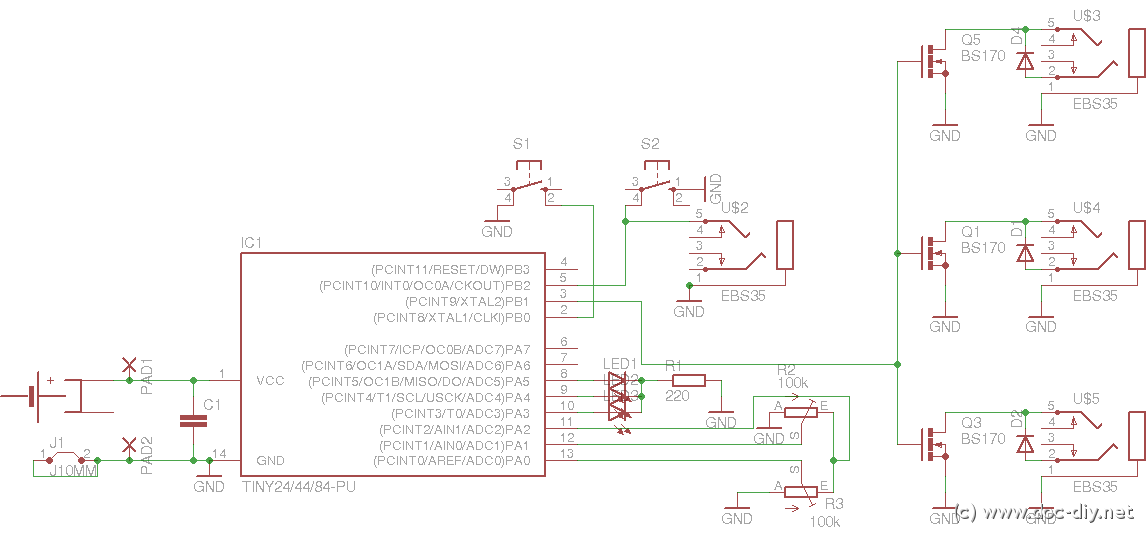
delay
This article outlines the construction of a simple microcontroller-based delay circuit designed for photographic applications, such as drop or high-speed photography. It is capable of controlling the trigger lag for cameras and flash units, generating periodic trigger pulses, or managing...
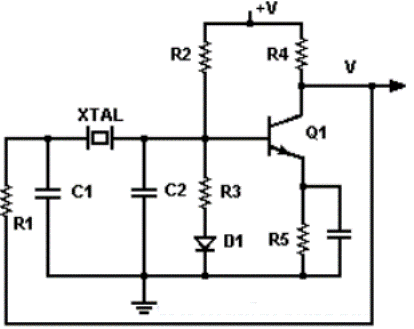
crystal oscillator discreet pierce oscillator
There are various configurations for crystal oscillators, with the most common being discrete and integrated circuits like the Pierce and RLC Bridge. The discrete Pierce oscillator is a suitable choice when good frequency stability and a relatively simple circuit are...
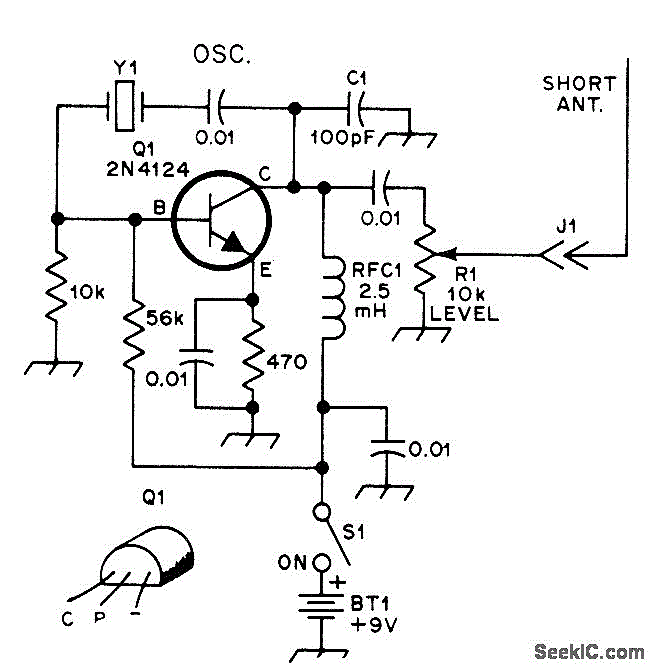
UNIVERSAL TEST OSCILLATOR
The crystal is positioned in the feedback path of a Pierce oscillator, situated between the base and collector of transistor Q1, with a 2.5 mH RF choke replacing the tuned collector circuit. The oscillator operates within a frequency range of...