


Jet
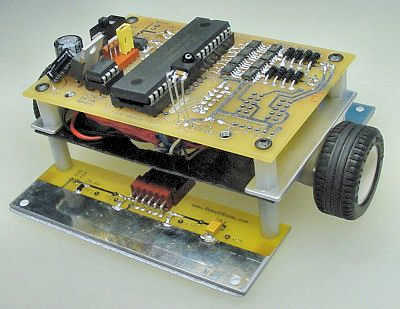
Description: The microcontroller is able to make about 7000 complete line-following decisions per second, which is almost 7 decisions per millimeter when the robot is going full speed. By upping the clock, unrolling loops, and removing my wireless debugging and extraneous code, I could increase the number of decisions per second.
The described system utilizes a microcontroller optimized for high-speed decision-making in a line-following robotic application. The microcontroller's capability to make approximately 7000 decisions per second indicates a high level of processing efficiency, essential for real-time navigation and control. This translates to nearly 7 decisions per millimeter, highlighting the precision required for effective line tracking.
To achieve such performance, several techniques are employed. Increasing the clock speed of the microcontroller enhances its processing capability, allowing for faster execution of the control algorithms that dictate the robot's movement. Additionally, unrolling loops in the code can reduce the overhead associated with loop control, thereby increasing the execution speed of critical decision-making routines. This optimization is particularly beneficial in applications where rapid responses to sensor inputs are necessary.
The removal of wireless debugging and other extraneous code is another crucial factor in maximizing performance. By streamlining the codebase, the microcontroller can allocate more resources to the primary task of line following, thus improving overall responsiveness and decision-making speed.
In a practical implementation, the microcontroller would interface with various sensors, such as infrared or optical sensors, to detect the line's position. The processed data would then be used to adjust the robot's motors accordingly, ensuring smooth and efficient navigation along the designated path. The integration of these elements forms a cohesive system that exemplifies the principles of embedded system design in robotics.The microcontroller is able to make about 7000 complete line-following decisions per second, which is almost 7 decisions per millimeter when the robot is going full speed. By upping the clock, unrolling loops, and removing my wireless debugging and extraneous code, I could increase the number of decisions per second.
The described system utilizes a microcontroller optimized for high-speed decision-making in a line-following robotic application. The microcontroller's capability to make approximately 7000 decisions per second indicates a high level of processing efficiency, essential for real-time navigation and control. This translates to nearly 7 decisions per millimeter, highlighting the precision required for effective line tracking.
To achieve such performance, several techniques are employed. Increasing the clock speed of the microcontroller enhances its processing capability, allowing for faster execution of the control algorithms that dictate the robot's movement. Additionally, unrolling loops in the code can reduce the overhead associated with loop control, thereby increasing the execution speed of critical decision-making routines. This optimization is particularly beneficial in applications where rapid responses to sensor inputs are necessary.
The removal of wireless debugging and other extraneous code is another crucial factor in maximizing performance. By streamlining the codebase, the microcontroller can allocate more resources to the primary task of line following, thus improving overall responsiveness and decision-making speed.
In a practical implementation, the microcontroller would interface with various sensors, such as infrared or optical sensors, to detect the line's position. The processed data would then be used to adjust the robot's motors accordingly, ensuring smooth and efficient navigation along the designated path. The integration of these elements forms a cohesive system that exemplifies the principles of embedded system design in robotics.The microcontroller is able to make about 7000 complete line-following decisions per second, which is almost 7 decisions per millimeter when the robot is going full speed. By upping the clock, unrolling loops, and removing my wireless debugging and extraneous code, I could increase the number of decisions per second.
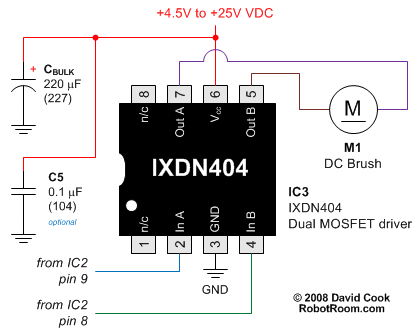
Simple Robot That Drives Forward and Back
The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an...
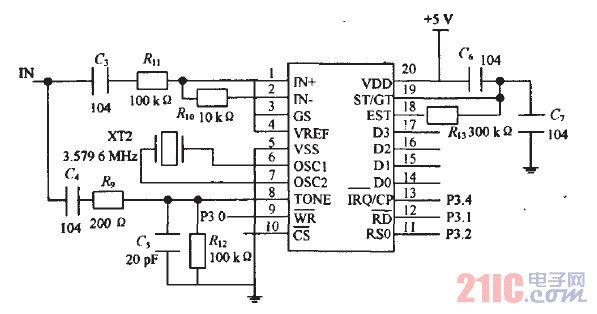
the remote intellectual pronunciation anti-theft alarm system design of the one-chip computer
Precautions must be taken against low safety coefficients, as the applicable space for security measures continues to shrink. With advancements in science and technology, innovations such as magnetic door sensors, touch-type systems, radar monitoring, and infrared detection have emerged, leading...
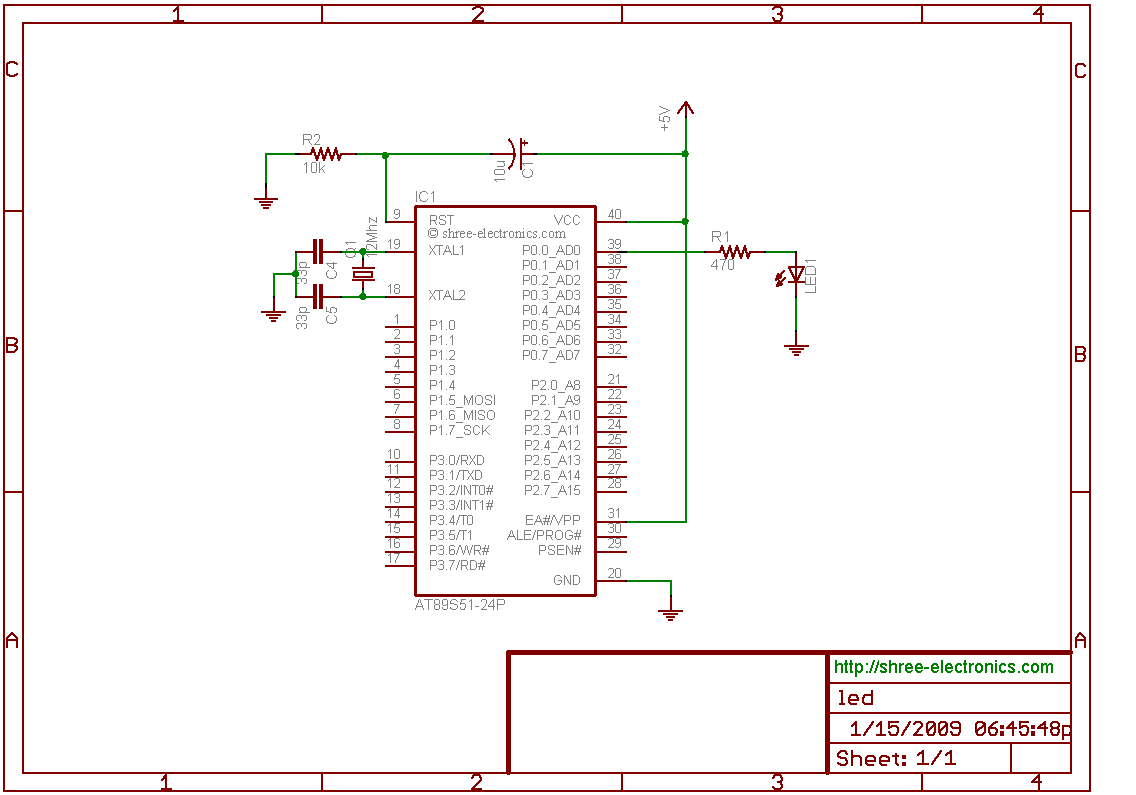
microcontroller led interfacing
The initial step often taken when learning about any microcontroller or embedded system is to make an LED blink. The circuit presented below illustrates the setup for interfacing an LED. Note: Due to the large dimensions of the circuit diagram,...
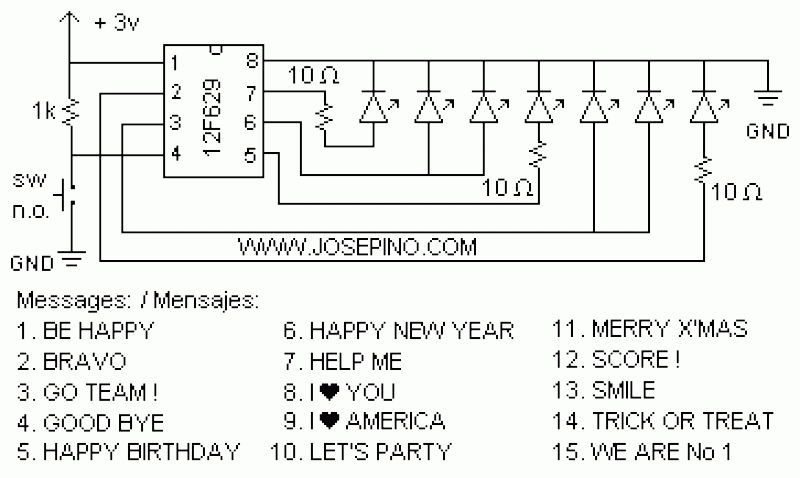
ON/OFF button using Microcontrollers
Using a switch to power up your microcontroller projects may not be a good idea if you need to "wake" the PIC during some events. For example: A metal detector sends a pulse indicating a car is ready to enter...
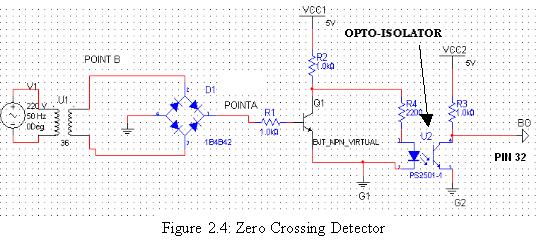
Industrial Building Automation System (IBAS) - 4
The two optical sensors will provide a count of individuals to the microcontroller, which will relay this value to MCU-II. The microcontroller will detect the entrance of any person through high-to-low pulse transitions on input pins A3 and A4.
The circuit...
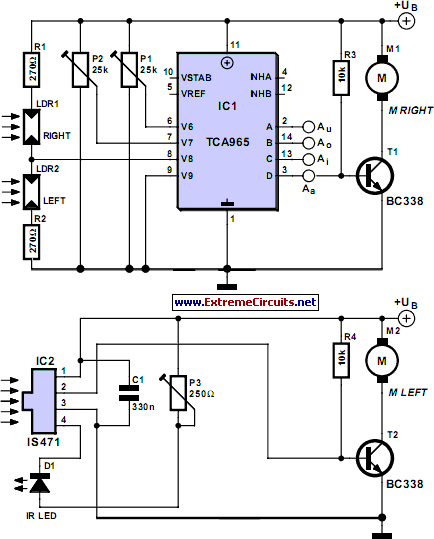
Discrete Robot
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The only unique component in the circuit is a window discriminator, which functions similarly to a window comparator. Resistors R1 and R2,...
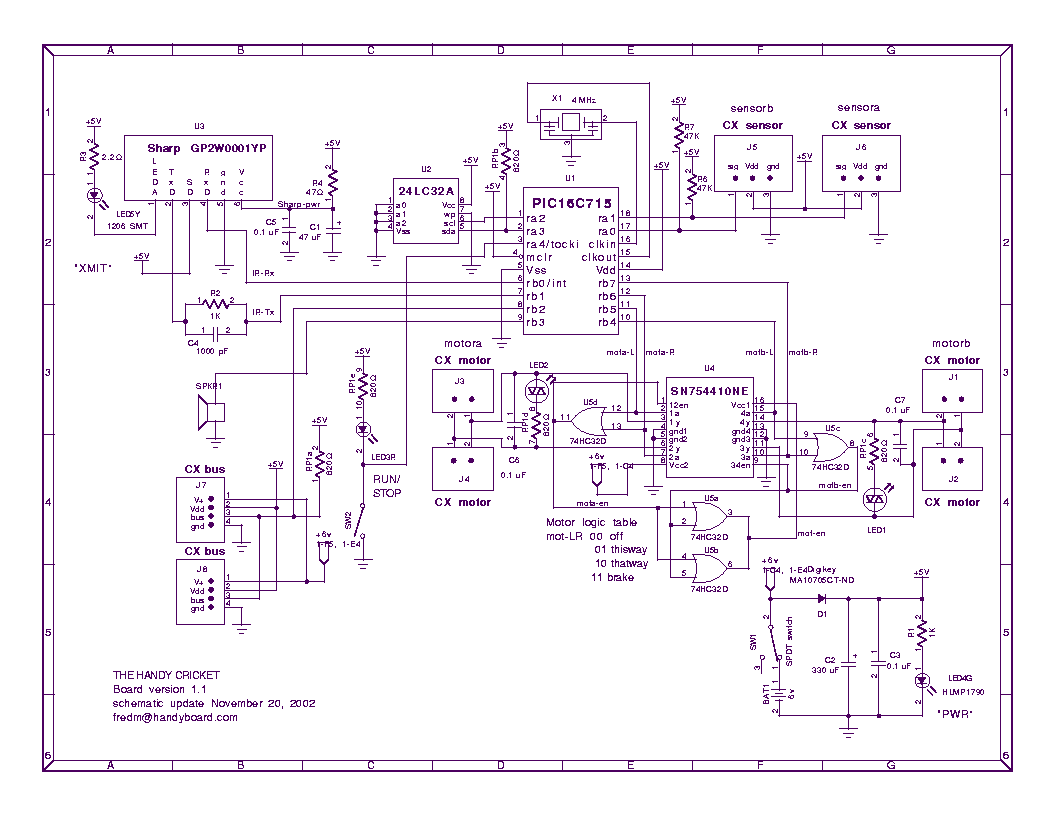
Handy Cricket Hardware Description
This document presents an overview of the hardware design of the Handy Cricket.
The Handy Cricket is a compact electronic device designed for educational and recreational purposes, primarily aimed at children. The hardware design incorporates various components that work together to...
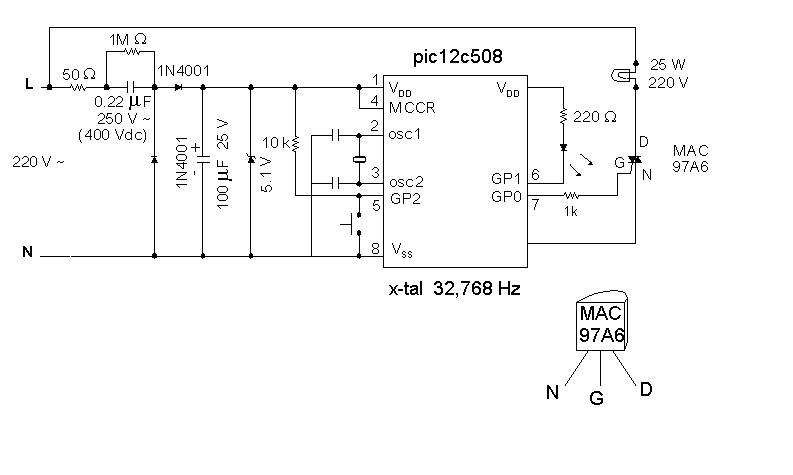
Night Light Saver
A Microchip PIC12C508 8-pin CMOS microcontroller controls a night light, turning it on and off at preset times every day. It is designed to save energy, produce no electromagnetic interference (EMI), and operate without batteries, featuring a built-in lamp fixture...
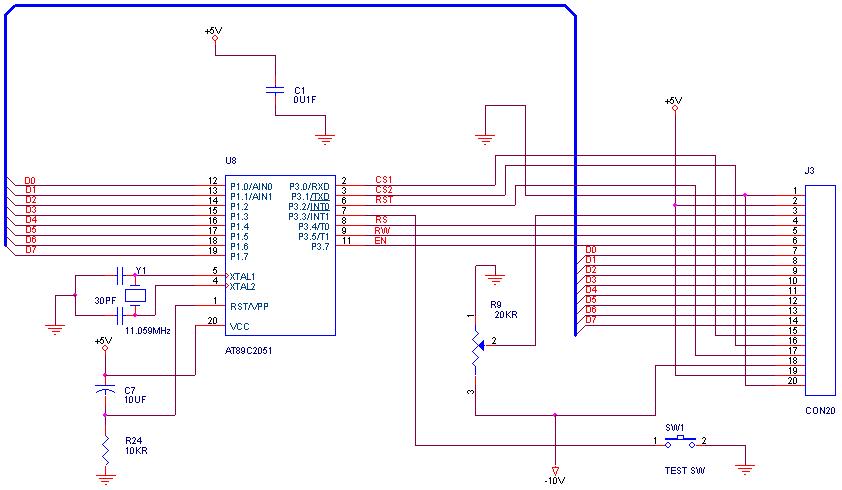
graphical LCDs with a microcontroller
How can graphical LCDs be controlled using a microcontroller? Is there any datasheet available?
Graphical LCDs (Liquid Crystal Displays) are widely used in various electronic applications for displaying complex graphics and text. To control these displays with a microcontroller, several steps...