


Simple Robot That Drives Forward and Back
#robot
#obstacle avoidance
#motor control
#flip-flop
#simple circuit
#back-and-forth
#off-the-shelf chip
#rudimentary behavior
#educational
#automotive
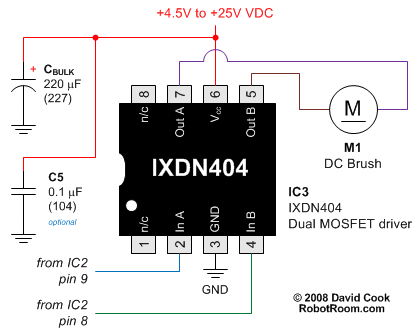
Description: The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an off-the-shelf chip rather than a complex microcontroller. Consequently, it serves as an excellent project for beginners. Enthusiasts of Robot Room may recognize the 7474 chip from the Laser Control project. This chip features two independent one-bit memory cells. The operational details can be found in the referenced article. In summary, the 7474 has a set pin (pin 10) and a clear pin (pin 13). The rear bumper switches are connected to the clear pin. When the rear bumper is activated, the chip's output (pin 9) is cleared to 0V, which connects to the motor driver chip, causing the robot to move forward. The 7474 retains the output state even after the bumper is released. The front bumper switches are linked to the set pin. When the front bumper is pressed, the output (pin 9) is set to 5V, prompting the motor driver chip to drive the motor backward. The chip retains this new output state. Notably, the set and clear pins of the 7474 are activated by a low (GND 0V) signal. Resistors R4 and R5 supply a high (5V) signal by default, preventing the chip from erroneously activating the set or clear pins. The bumper switches connect the respective pin to 0V when pressed, activating the set or clear function. The power switch (SW1) connects the circuit to the battery when turned on. Diode D1 prevents current from flowing in the reverse direction, protecting the chips from damage if the batteries are installed incorrectly. Capacitors C2 and C3 ensure a stable local power source, smoothing out fluctuations in battery voltage due to varying power consumption. This stability helps prevent the chip from resetting or behaving erratically due to electrical noise. Additionally, the laser project requires only the bottom half of the 7474 flip-flop chip, while this project utilizes the top half. The circuits can be combined to create a robot that starts and stops with a laser pointer and moves forward and backward based on bumper activation. To adapt the motor driver for this application, the FAN8200 motor driver chip should be used. The laser output (pin 6) of the 7474 connects to the enable pin (pin 2) on the FAN8200, and the direction output (pin 9) connects to input pin (6) on the FAN8200. The snap-action switches can be configured to activate when pressed (normally-open pin) or when not pressed (normally-closed pin). In this design, the 0V (GND) wire is soldered to the normally-open pin, while the signal wire connects to the common. Both front bumper switches are wired together, connecting to GND and the input pin 10 of the 7474. This configuration allows for activation regardless of which switch is pressed or if both are pressed simultaneously. The same wiring approach applies to the rear bumper switches. Although the IXDN604 chip is primarily a power MOSFET driver and not specifically a motor driver chip, it effectively supplies power to small motors. A similar setup is described on the H-bridge page. The IXDN604 is also featured in Intermediate Robot Building, which provides additional information. While it is common to place four diodes on the motor outputs, this is optional for low-end projects, as MOSFETs typically include built-in body diodes. It should be noted that using a MOSFET driver chip for a 4.5V-6V voltage level is not ideal, as MOSFETs generally perform better at higher voltages. This observation does not reflect poorly on the IXDN604 chip.The Flip-Flop Robot drives forward until it hits an obstacle, and then reverses until it hits another obstacle. This back-and-forth process continues indefinitely. By limiting the functionality to this very rudimentary behavior, it can be generated from an off-the-shelf chip instead of requiring a fancy microcontroller.
Thus, this is a good robot project for beginners. Avid fans of Robot Room will recognize the 7474 chip from the Laser Control project. This chip has two independent one-bit memory cells. You can read all of the operational details and see a movie in that article. Briefly, the 7474 has a set (pin 10) and a clear (pin 13). The rear bumper switches are connected to the clear pin. When the rear bumper is pressed, the chip`s output (pin 9) is cleared (0V). This output connects to the motor driver chip and makes the robot drive forward. The function of the 7474 is to remember the output state even after the bumper is released. The front bumper switches are connected to the set pin. When the front bumper is pressed, the chip`s output (pin 9) is set (5V), rather than clear (0V). This commands the motor driver chip to drive the motor backwards. The 7474 remembers this new output. An oddity of the 7474 chip is that the set and clear pins are activated by a low (GND 0V) signal. Therefore, resistors R4 and R5 provide a high (5V) signal by default, so that the chip will not normally think that the set or clear pins are being activated. The bumper switches connect the appropriate pin to 0V when pressed, to activate the set or clear feature.
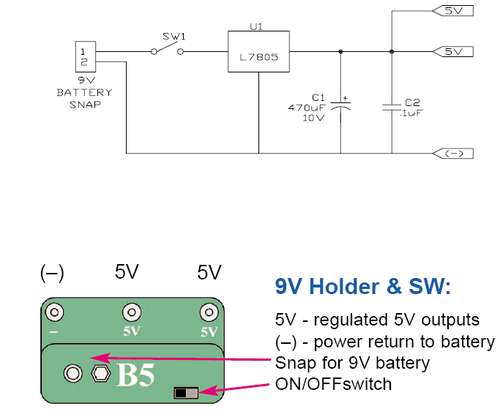
The power switch (SW1) connects the circuit to the battery when turned on. The diode (D1) prevents electricity from flowing in the wrong direction if the batteries are inserted backwards. Current is only allowed to flow in the direction of the arrow on the diode symbol. Backwards batteries would otherwise destroy the chips. Capacitors C2 and C3 provide a smooth, local power source as the battery voltage goes up and down with power consumption.
This helps prevent the chip from resetting or randomizing due to random electrical noise. Bonus: The laser project only needs the bottom half of the 7474 flip-flop chip, and this project only needs the top half. You can combine the circuits to make a robot that starts and stops with a laser pointer, and that goes forward and reverse based on bumpers.
You`ll need to substitute the motor driver on this page for the FAN8200 motor driver chip. Simply connect the laser output (pin 6) of the 7474 to the enable pin (2) on the FAN8200, and the direction output (pin 9) of the 7474 to the input pin (6) on the FAN8200. Snap-action switches have a nice feature where they can activate when the switch is pressed (normally-open pin) or when not pressed (normally-closed pin).
In this case, we only want the 7474 chip to receive 0V when a switch is pressed, so the 0V (GND) wire is soldered to normally-open and the signal wire is soldered to common. Notice that the front bumper switches are wired together (both connect to GND and both connect to the 7474 input pin 10).
It doesn`t matter which switch is pressed - or even if both are pressed at the same time. In any case, the input pin gets connected to ground. The same goes for the rear bumper switches. The IXDN604 chip isn`t officially a motor driver chip. It`s actually a power MOSFET driver chip. However, it does an acceptable job supplying power to small motors. A similar setup is described on my H-bridge page. The IXDN604 is featured in Intermediate Robot Building. Both are good sources of information if you want more details. I usually place four diodes on the motor outputs, but that`s optional for a low-end project since MOSFETs have built-in body diodes. Admittedly, a MOSFET driver chip is a borderline poor choice for the 4. 5V-6V voltage level of this robot. MOSFETs perform better at higher voltages. This is not a criticism of the IXDN604 chip. The
Thus, this is a good robot project for beginners. Avid fans of Robot Room will recognize the 7474 chip from the Laser Control project. This chip has two independent one-bit memory cells. You can read all of the operational details and see a movie in that article. Briefly, the 7474 has a set (pin 10) and a clear (pin 13). The rear bumper switches are connected to the clear pin. When the rear bumper is pressed, the chip`s output (pin 9) is cleared (0V). This output connects to the motor driver chip and makes the robot drive forward. The function of the 7474 is to remember the output state even after the bumper is released. The front bumper switches are connected to the set pin. When the front bumper is pressed, the chip`s output (pin 9) is set (5V), rather than clear (0V). This commands the motor driver chip to drive the motor backwards. The 7474 remembers this new output. An oddity of the 7474 chip is that the set and clear pins are activated by a low (GND 0V) signal. Therefore, resistors R4 and R5 provide a high (5V) signal by default, so that the chip will not normally think that the set or clear pins are being activated. The bumper switches connect the appropriate pin to 0V when pressed, to activate the set or clear feature.
The power switch (SW1) connects the circuit to the battery when turned on. The diode (D1) prevents electricity from flowing in the wrong direction if the batteries are inserted backwards. Current is only allowed to flow in the direction of the arrow on the diode symbol. Backwards batteries would otherwise destroy the chips. Capacitors C2 and C3 provide a smooth, local power source as the battery voltage goes up and down with power consumption.
This helps prevent the chip from resetting or randomizing due to random electrical noise. Bonus: The laser project only needs the bottom half of the 7474 flip-flop chip, and this project only needs the top half. You can combine the circuits to make a robot that starts and stops with a laser pointer, and that goes forward and reverse based on bumpers.
You`ll need to substitute the motor driver on this page for the FAN8200 motor driver chip. Simply connect the laser output (pin 6) of the 7474 to the enable pin (2) on the FAN8200, and the direction output (pin 9) of the 7474 to the input pin (6) on the FAN8200. Snap-action switches have a nice feature where they can activate when the switch is pressed (normally-open pin) or when not pressed (normally-closed pin).
In this case, we only want the 7474 chip to receive 0V when a switch is pressed, so the 0V (GND) wire is soldered to normally-open and the signal wire is soldered to common. Notice that the front bumper switches are wired together (both connect to GND and both connect to the 7474 input pin 10).
It doesn`t matter which switch is pressed - or even if both are pressed at the same time. In any case, the input pin gets connected to ground. The same goes for the rear bumper switches. The IXDN604 chip isn`t officially a motor driver chip. It`s actually a power MOSFET driver chip. However, it does an acceptable job supplying power to small motors. A similar setup is described on my H-bridge page. The IXDN604 is featured in Intermediate Robot Building. Both are good sources of information if you want more details. I usually place four diodes on the motor outputs, but that`s optional for a low-end project since MOSFETs have built-in body diodes. Admittedly, a MOSFET driver chip is a borderline poor choice for the 4. 5V-6V voltage level of this robot. MOSFETs perform better at higher voltages. This is not a criticism of the IXDN604 chip. The
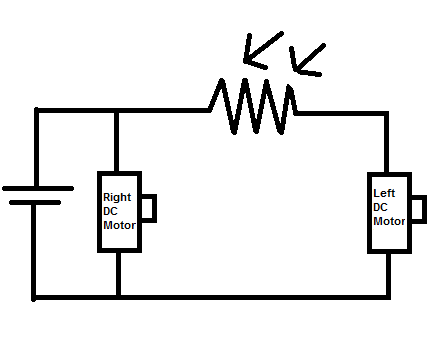
circuit Making an obstruction avoiding device without microcontroller
Construct a toy device that spins to the left whenever there is an obstruction in front of it, without utilizing a microcontroller. The proposed design involves using two DC motors as the rear wheels. An LDR (Light Dependent Resistor) is...
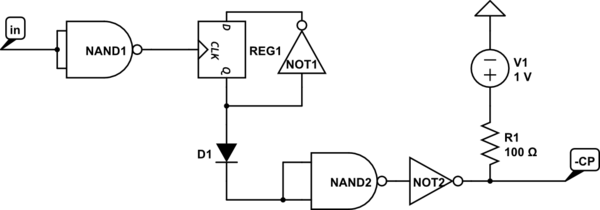
flipflop Purpose of the logic gate configurations on the Kenbak-1
This text discusses the functionality of a flip-flop, specifically focusing on the role of two NAND gates and the presence of an additional inverter. It suggests allowing time for others to analyze the question and formulate their theories, emphasizing that...
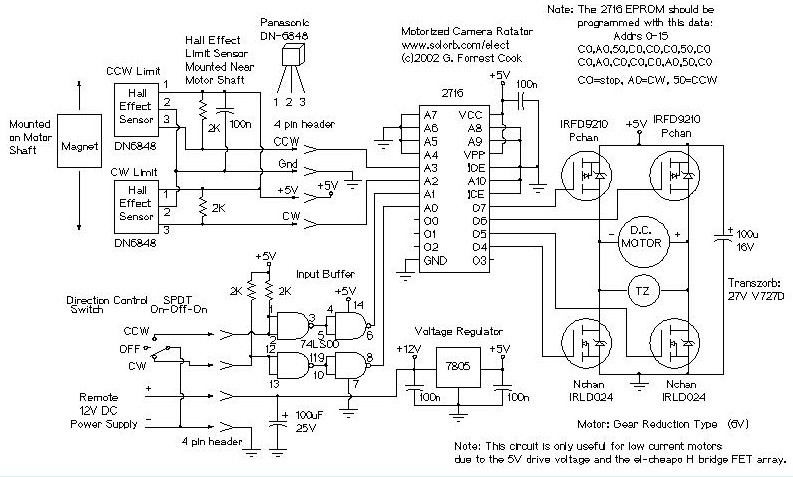
Motorized Video Camera Mount
The camera rotator circuit utilizes a 2716 EPROM to store a logic value table that governs the motor driver (H-bridge) circuit. The schematic illustrates the EPROM data. By employing the EPROM, a significant number of discrete gates are eliminated. The...
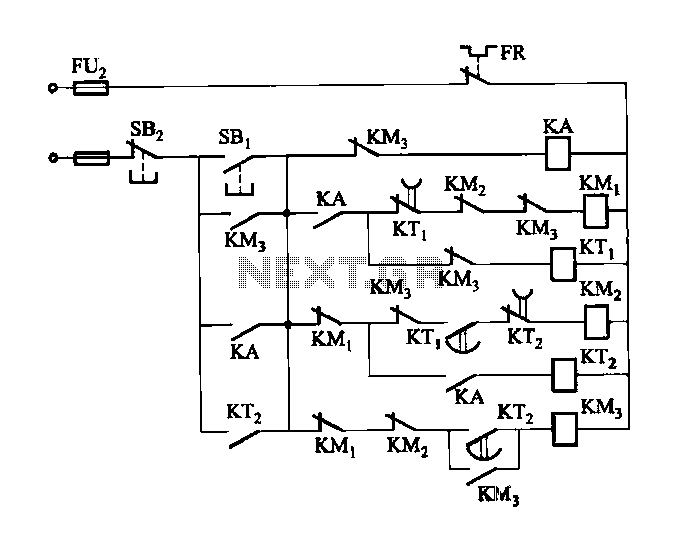
2 -Y- connection automatic three-speed motor acceleration control circuit
Figure 3-118 illustrates an automatic acceleration control circuit. This circuit employs a male contactor time relay, enabling the motor to start automatically at a low speed before transitioning to high-speed operation.
The automatic acceleration control circuit depicted in Figure 3-118 is...
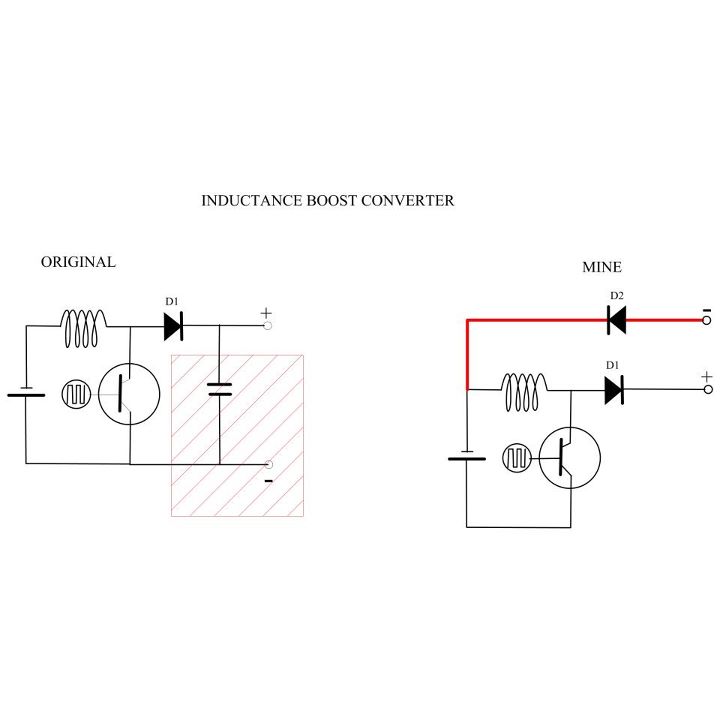
My Motors got me to Tap into Radiant Energy
A new user is seeking to share information about their experiences on this platform.
The user expresses a desire to communicate and engage with the community regarding their experiences. This indicates an interest in exchanging knowledge and possibly seeking assistance or...
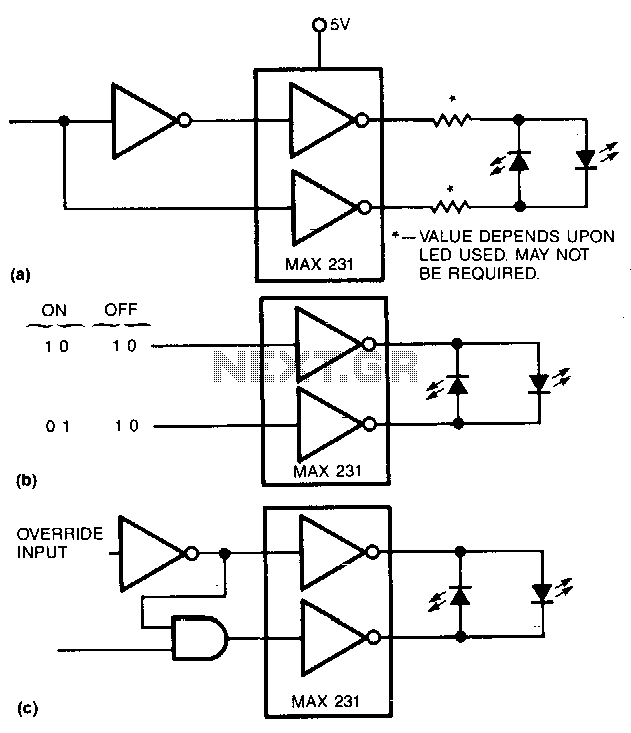
Spare-flip-flop-inverter
The circuit utilizes one-half of a dual D flip-flop as an inverter. When the input signal decreases, the flip-flop resets, causing its Q output to increase. Conversely, when the input signal increases, the reset line is released, and the Q...
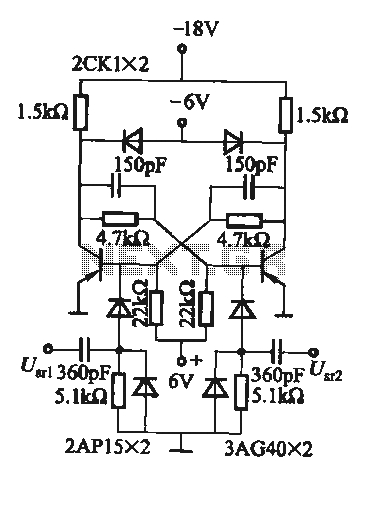
Practical flip-flop circuit
A flip-flop circuit with a memory function for pulse signals. It features two stable states: one where transistor VTi is off and VTZ is conducting, and another where VTi is conducting and VT2 is off. An external signal is sufficient...
Roverbot circuit
1. A robot may not injure a human being or, through inaction, allow a human being to come to harm. 2. A robot must obey the orders given to it by human beings, except where such orders would conflict with...
Automotive charger for ni-cad battery packs
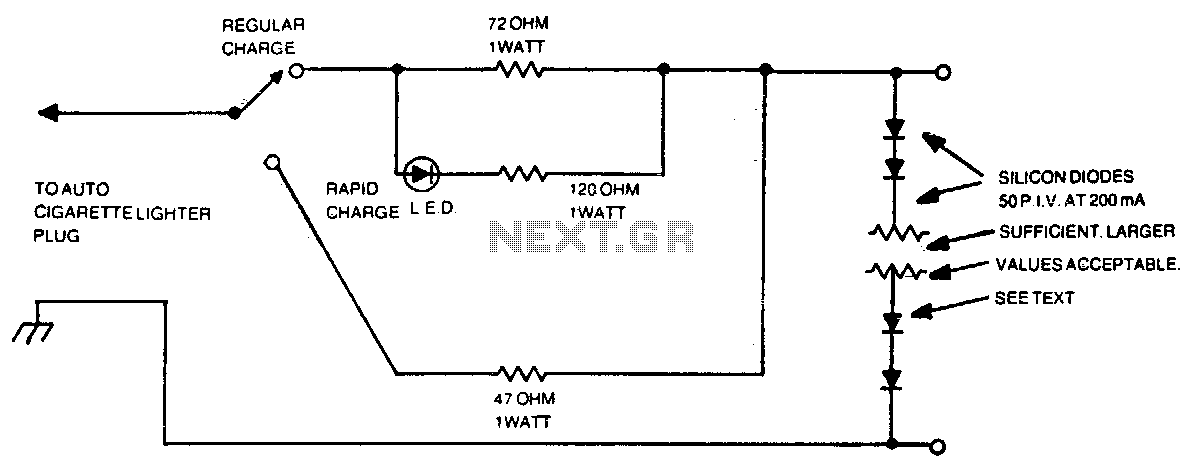
The number of silicon diodes across the output is determined by the voltage of the battery pack. Each diode is considered at 0 volts. For example, a 10-volt pack would require 10/0 = 157, or 16 diodes.
In the context of...