


Roverbot circuit
#robot
#arduino
#motor control
#sensors
#autonomous
#obstacle avoidance
#programmable
#educational
#robotics
#AI
Description: 1. A robot may not injure a human being or, through inaction, allow a human being to come to harm. 2. A robot must obey the orders given to it by human beings, except where such orders would conflict with the First Law. 3. A robot must protect its own existence as long as such.
The provided text outlines the foundational principles governing robotic behavior, often referred to as the Three Laws of Robotics. These laws are designed to ensure that robots operate safely and ethically in relation to humans.
In a practical application, these principles can be integrated into the design of robotic systems through various electronic components and programming methodologies. For instance, safety mechanisms can be implemented using sensors and actuators that monitor human proximity and environmental conditions.
1. **Safety Mechanisms**: To adhere to the first law, a robot can be equipped with infrared sensors or LIDAR systems to detect human presence. If a human is detected within a predefined safety zone, the robot can automatically reduce its speed or halt operations to prevent injury.
2. **Command Processing**: The second law can be implemented through a command and control system, where the robot's microcontroller processes input from users. This can be achieved using a combination of a user interface, such as buttons or voice recognition systems, and a central processing unit (CPU) that interprets commands. The programming logic must include conditional statements that prioritize the first law over any commands that could potentially cause harm to humans.
3. **Self-Preservation**: The third law can be addressed by incorporating self-diagnostic routines within the robot's firmware. This allows the robot to monitor its own systems, such as battery levels, motor functions, and structural integrity. If any critical failure is detected, the robot can execute a safe shutdown procedure or enter a standby mode to prevent further damage.
Overall, the integration of these laws into robotic design requires a careful balance of hardware and software components, ensuring that safety, obedience, and self-preservation are effectively managed in real-time operational scenarios.1. A robot may not injure a human being or, through inaction, allow a human being to come to harm. 2. A robot must obey the orders given to it by human beings, except where such orders would conflict with the First Law. 3. A robot must protect its own existence as long as such..
The provided text outlines the foundational principles governing robotic behavior, often referred to as the Three Laws of Robotics. These laws are designed to ensure that robots operate safely and ethically in relation to humans.
In a practical application, these principles can be integrated into the design of robotic systems through various electronic components and programming methodologies. For instance, safety mechanisms can be implemented using sensors and actuators that monitor human proximity and environmental conditions.
1. **Safety Mechanisms**: To adhere to the first law, a robot can be equipped with infrared sensors or LIDAR systems to detect human presence. If a human is detected within a predefined safety zone, the robot can automatically reduce its speed or halt operations to prevent injury.
2. **Command Processing**: The second law can be implemented through a command and control system, where the robot's microcontroller processes input from users. This can be achieved using a combination of a user interface, such as buttons or voice recognition systems, and a central processing unit (CPU) that interprets commands. The programming logic must include conditional statements that prioritize the first law over any commands that could potentially cause harm to humans.
3. **Self-Preservation**: The third law can be addressed by incorporating self-diagnostic routines within the robot's firmware. This allows the robot to monitor its own systems, such as battery levels, motor functions, and structural integrity. If any critical failure is detected, the robot can execute a safe shutdown procedure or enter a standby mode to prevent further damage.
Overall, the integration of these laws into robotic design requires a careful balance of hardware and software components, ensuring that safety, obedience, and self-preservation are effectively managed in real-time operational scenarios.1. A robot may not injure a human being or, through inaction, allow a human being to come to harm. 2. A robot must obey the orders given to it by human beings, except where such orders would conflict with the First Law. 3. A robot must protect its own existence as long as such..
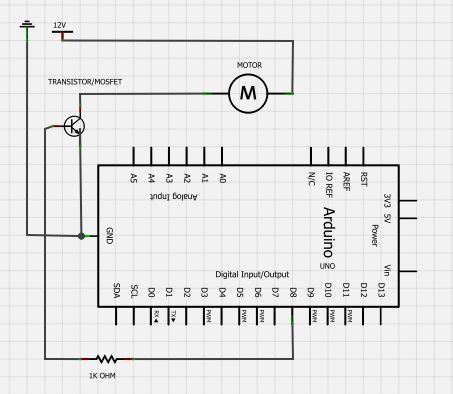
Arduino Running A DC Motor and High Current Lamp
The BC547 transistor has a maximum operating current of 100 mA and a maximum voltage rating of 65 volts. When oriented with the label facing the viewer, the three terminals from left to right are collector, base, and emitter. It...
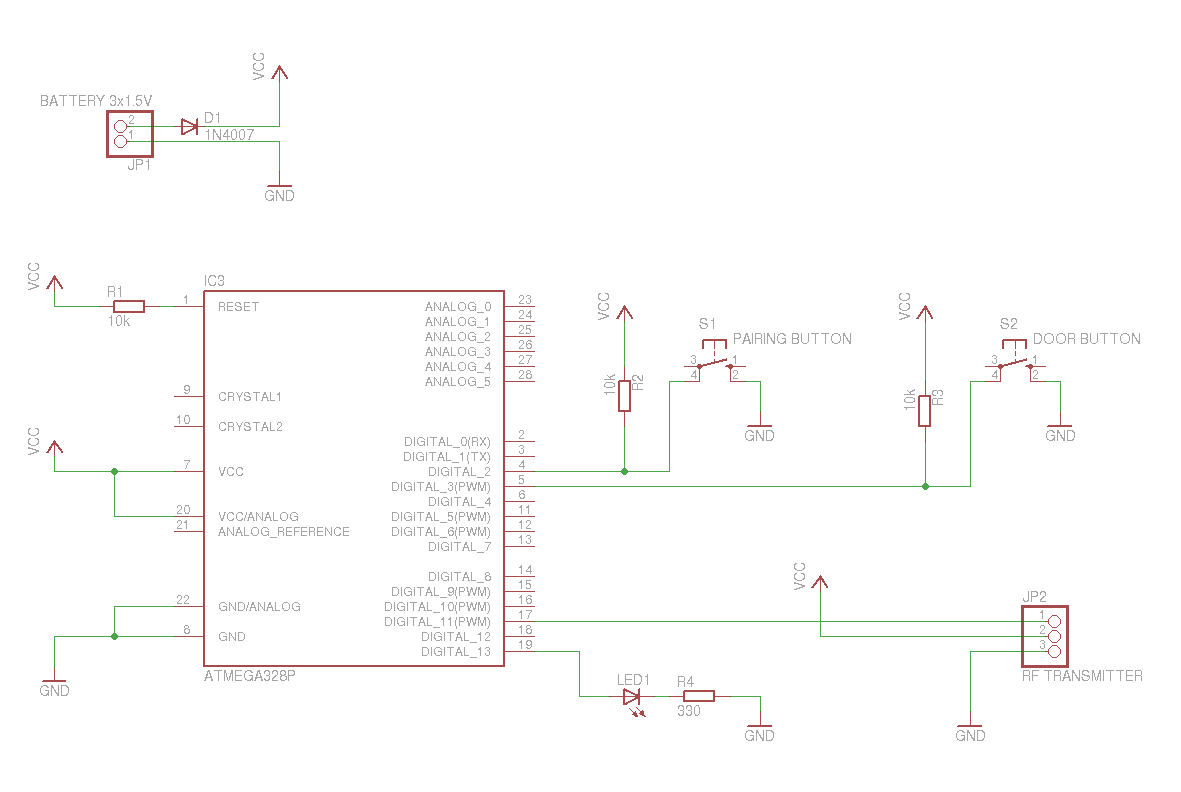
arduino based remote control for electric door
A replacement remote control system for an electric garage door was constructed after the original remote failed multiple times. Although the old remote could have been repaired, it was 35 years old and not particularly enjoyable to use.
The replacement...
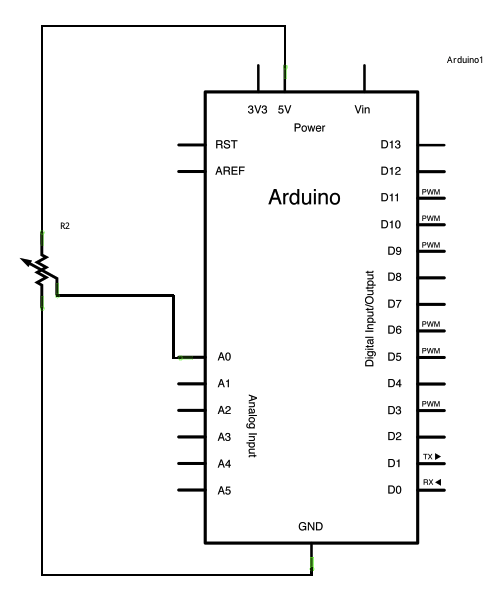
Arduino Analog Input
A potentiometer is a simple knob that provides variable resistance, which can be read into the Arduino board as an analog value. In this example, a potentiometer is connected to one of the Arduino's analog inputs to control the rate...
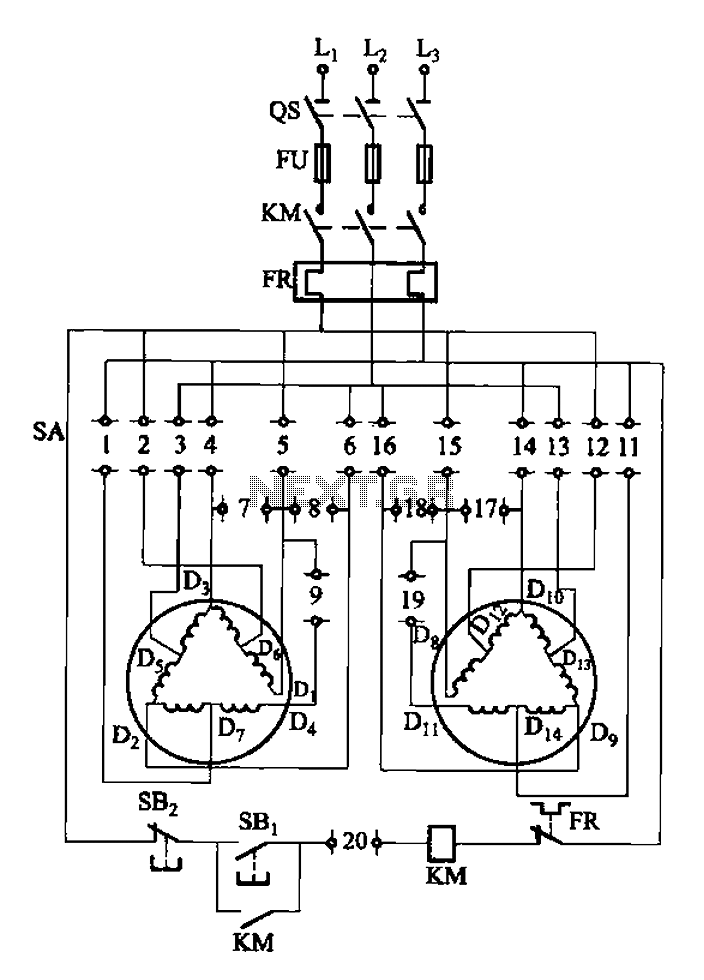
2Y-Y-2 - connection four-speed motor switch control circuit
The 3-119 circuit shown in the figure combines switch SA to realize the stator windings, specifically the 2, Y, and 2Y connections, which correspond to the motor speed n1.
The 3-119 circuit is designed to facilitate the control of motor speed...
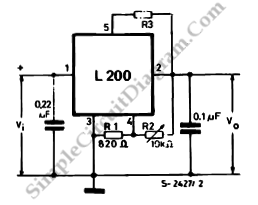
Programmable Current and Voltage Regulator for Battery Charger
This is a programmable current and voltage regulator circuit. It consists of a voltage regulator with external current limitation. The variable resistor R2 is...
The programmable current and voltage regulator circuit is designed to provide precise control over output voltage and...
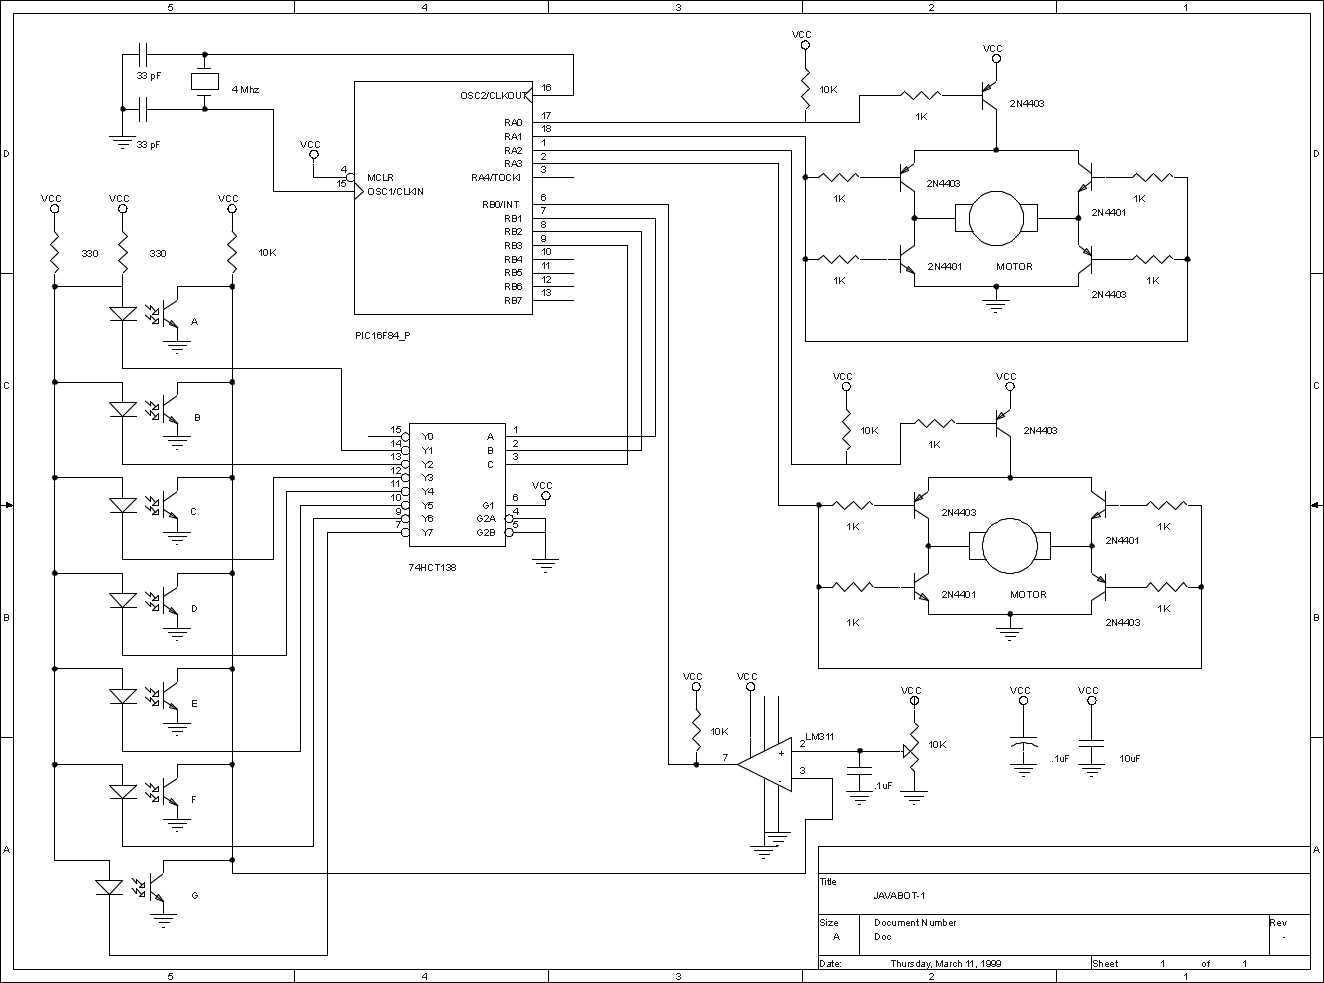
JavaBot1
The JavaBot1 is a small line following robot designed to follow a black line drawn on a dry erase board. It is designed to follow very tight curves. The software still has lots of room for improvement but works well...
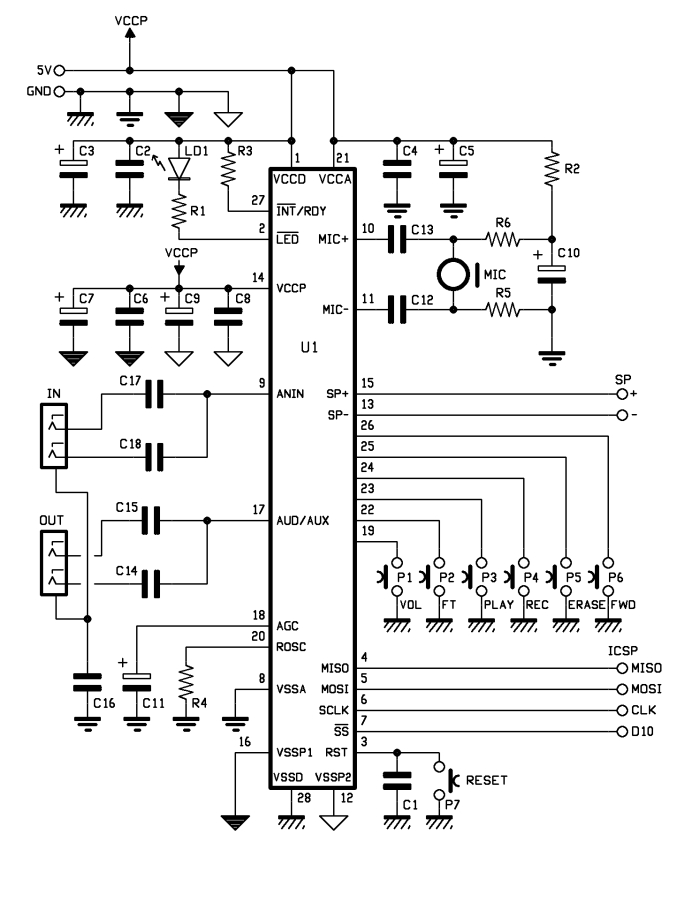
Voice Shield for Arduino
The aim of this project is to create an Arduino voice shield that facilitates numerous voice-related applications, primarily utilizing an integrated ISD1790PY chip. This voice and text-to-speech (TTS) functionality can be beneficial for integrating voice messages into alarm systems, implementing...
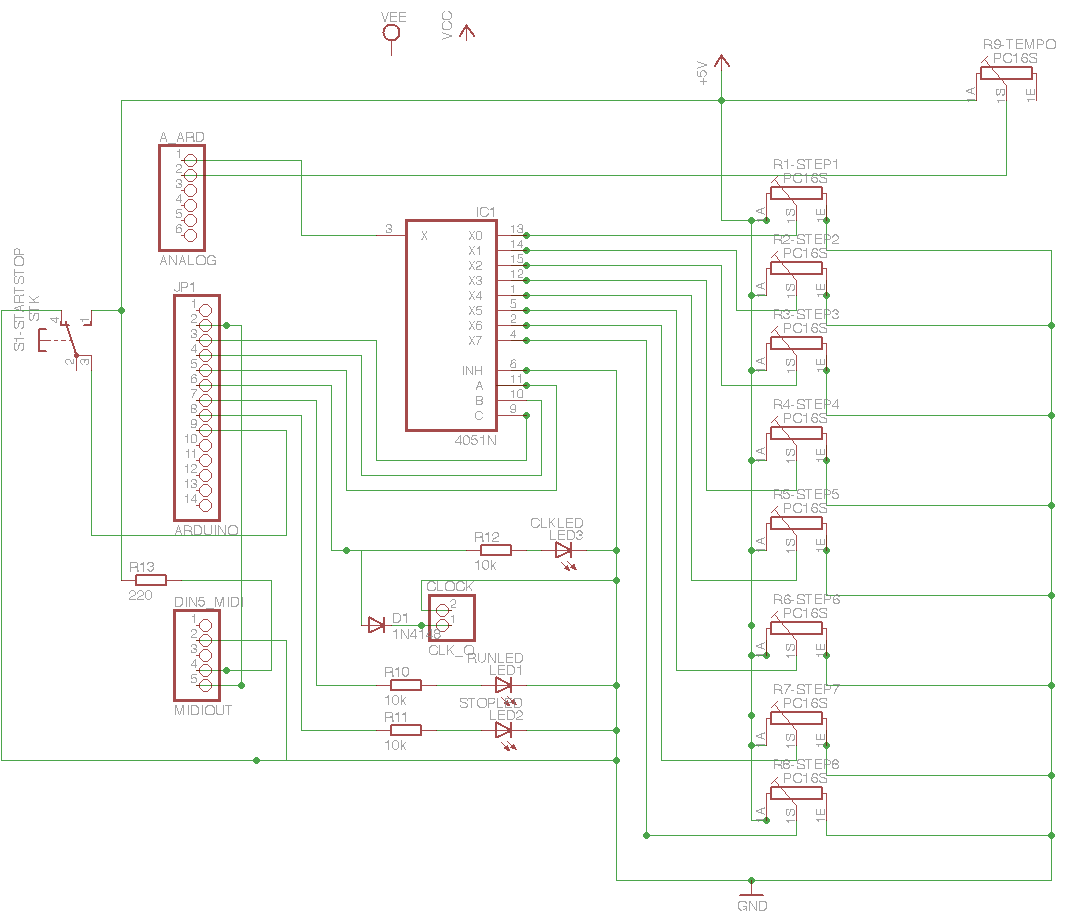
arduino Glacial Communications
A custom Lo-fi Arduino Guitar Pedal has been developed, utilizing a repurposed enclosure and twisted pair converters. Currently, it features a single output, with potential for future expansion. The design includes a digital delay effect, which was initially intended to...
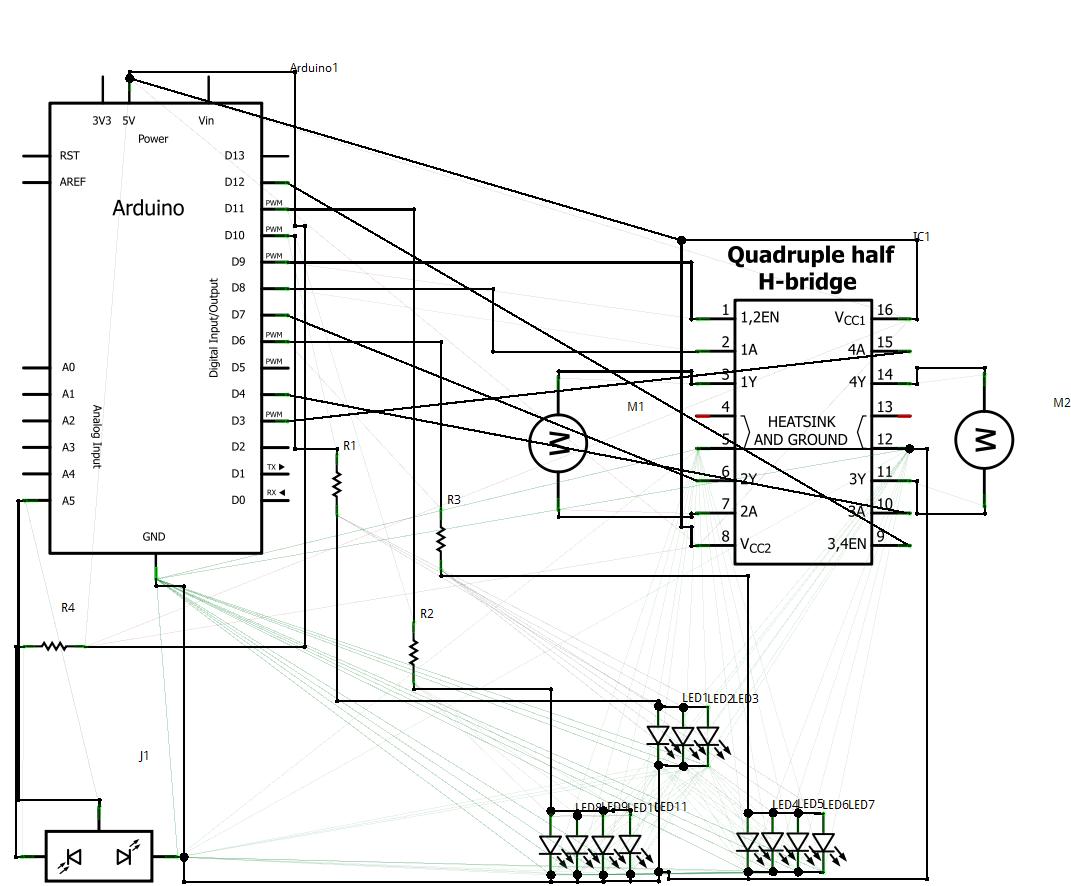
wet garden circuit
1. Abstract Wet-garden is an interactive flower garden and an ambient indoor sculpture. When people walk around it, it changes motion and LED blinking speed. Wet-design is designed for everyone who wants a tangible interaction object and an interesting indoor...