


JavaBot1
#robot
#line following
#servo motors
#gear motors
#automation
#educational
#DIY
#small robots
#modification
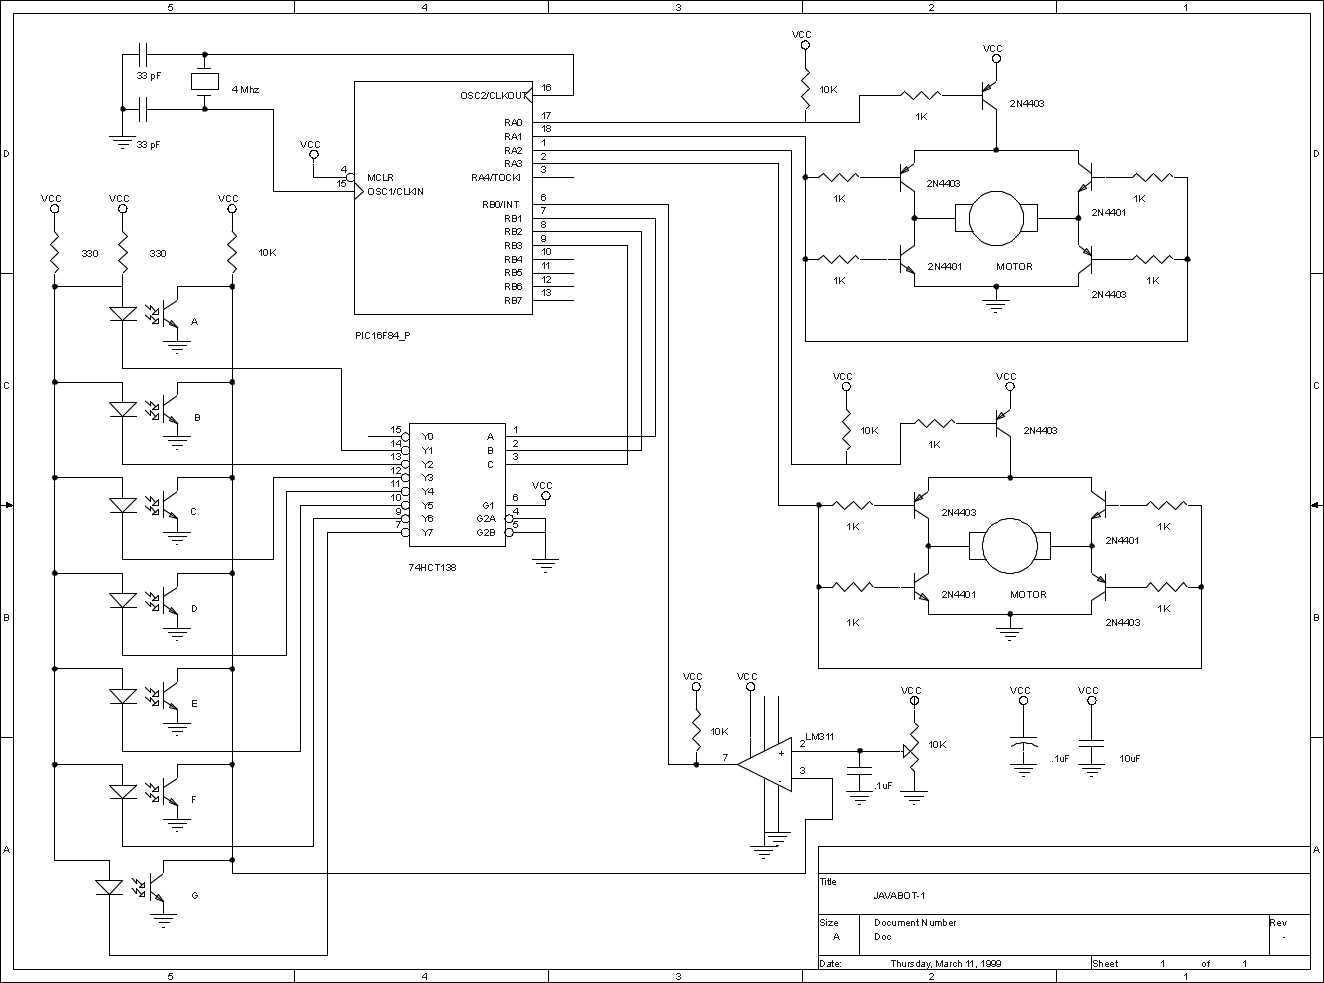
Description: The JavaBot1 is a small line following robot designed to follow a black line drawn on a dry erase board. It is designed to follow very tight curves. The software still has lots of room for improvement but works well as is. The JavaBot1 uses 2 Cirrus CS-70 servos that have been modified for full rotation and have had their controller boards removed to convert them from servos to gear motors. Servos are a common motive power for small robots due to their low cost, ready availability.
The JavaBot1 is an autonomous mobile robot that utilizes differential steering for navigation along a defined path, specifically a black line on a contrasting surface. The primary components of the robot include two modified Cirrus CS-70 servos, which have been adapted for continuous rotation by removing their internal position control mechanisms. This modification allows the servos to function as gear motors, providing more flexibility in movement and enabling tighter turns, which are essential for following curves in the line.
The robot's control system is likely based on a microcontroller, which processes input from line sensors. These sensors typically consist of infrared (IR) emitters and detectors that can distinguish between the black line and the surrounding surface. When the sensors detect a deviation from the line, the microcontroller adjusts the speed and direction of the servos to correct the robot's path. This feedback loop is crucial for maintaining accurate line following, especially when navigating sharp turns.
In terms of power supply, the JavaBot1 would require a battery pack capable of providing sufficient voltage and current to drive the servos and the microcontroller. The choice of battery is important, as it impacts the robot's operational time and weight.
Further improvements to the software could include enhanced line detection algorithms, the addition of obstacle avoidance capabilities, and the implementation of more complex movement patterns. These enhancements would increase the robot's versatility and performance in various environments.
Overall, the JavaBot1 exemplifies a practical application of basic robotics principles, utilizing readily available components to create a functional and educational line-following robot.The JavaBot1 is a small line following robot designed to follow a black line drawn on a dry erase board. It is designed to follow very tight curves. The software still has lot`s of room for improvement but works well as is. The JavaBot1 uses 2 Cirrus CS-70 servos that have been modified for full rotation and have had their controller boards removed to convert them from servos to gear motors.
Servos are a common motive power for small robots due to their low cost, ready availability,
The JavaBot1 is an autonomous mobile robot that utilizes differential steering for navigation along a defined path, specifically a black line on a contrasting surface. The primary components of the robot include two modified Cirrus CS-70 servos, which have been adapted for continuous rotation by removing their internal position control mechanisms. This modification allows the servos to function as gear motors, providing more flexibility in movement and enabling tighter turns, which are essential for following curves in the line.
The robot's control system is likely based on a microcontroller, which processes input from line sensors. These sensors typically consist of infrared (IR) emitters and detectors that can distinguish between the black line and the surrounding surface. When the sensors detect a deviation from the line, the microcontroller adjusts the speed and direction of the servos to correct the robot's path. This feedback loop is crucial for maintaining accurate line following, especially when navigating sharp turns.
In terms of power supply, the JavaBot1 would require a battery pack capable of providing sufficient voltage and current to drive the servos and the microcontroller. The choice of battery is important, as it impacts the robot's operational time and weight.
Further improvements to the software could include enhanced line detection algorithms, the addition of obstacle avoidance capabilities, and the implementation of more complex movement patterns. These enhancements would increase the robot's versatility and performance in various environments.
Overall, the JavaBot1 exemplifies a practical application of basic robotics principles, utilizing readily available components to create a functional and educational line-following robot.The JavaBot1 is a small line following robot designed to follow a black line drawn on a dry erase board. It is designed to follow very tight curves. The software still has lot`s of room for improvement but works well as is. The JavaBot1 uses 2 Cirrus CS-70 servos that have been modified for full rotation and have had their controller boards removed to convert them from servos to gear motors.
Servos are a common motive power for small robots due to their low cost, ready availability,
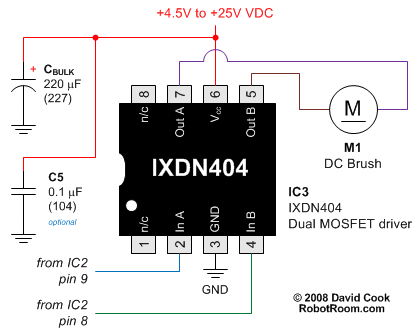
Simple Robot That Drives Forward and Back
The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an...
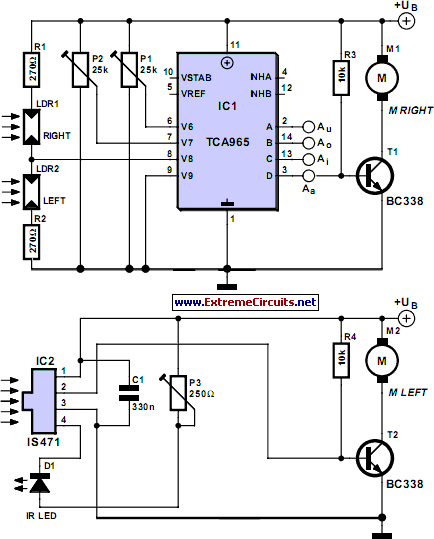
Discrete Robot
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The only unique component in the circuit is a window discriminator, which functions similarly to a window comparator. Resistors R1 and R2,...
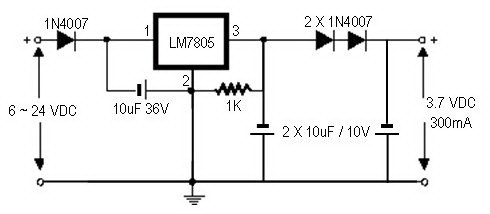
how to convert a 9v battery to 3.7v
A regulator circuit is needed for this DIY project. Familiarity with electronic components, circuitry, the use of a multitester, and a soldering iron is essential. The schematic diagram provided can accept an input voltage ranging from 6 to 24 volts...
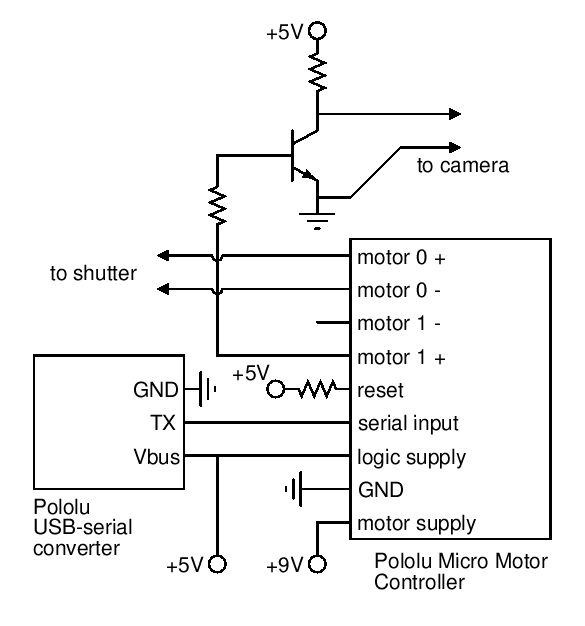
5 Minute Signal
For the past year and a half, a group based in Ann Arbor, Michigan, named GO-Tech has been formed, uniting individuals interested in creating projects using technology, such as hardware, software, metal, and wood. This initiative is referred to as...
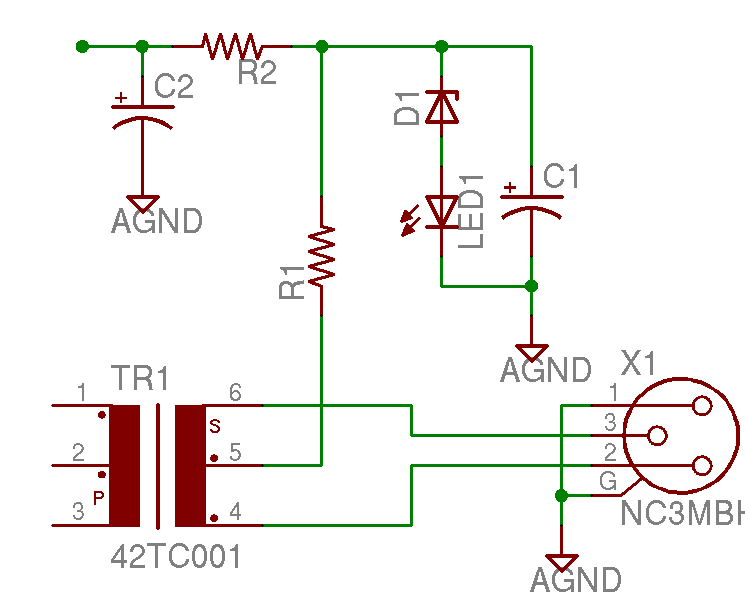
Help with a schematic please
A project is underway to construct the CountryHick DI as illustrated on DIYFactory, incorporating a few minor modifications. The final design aims to be a 1U unit with four inputs.
The CountryHick DI (Direct Injection) box is a crucial tool in...
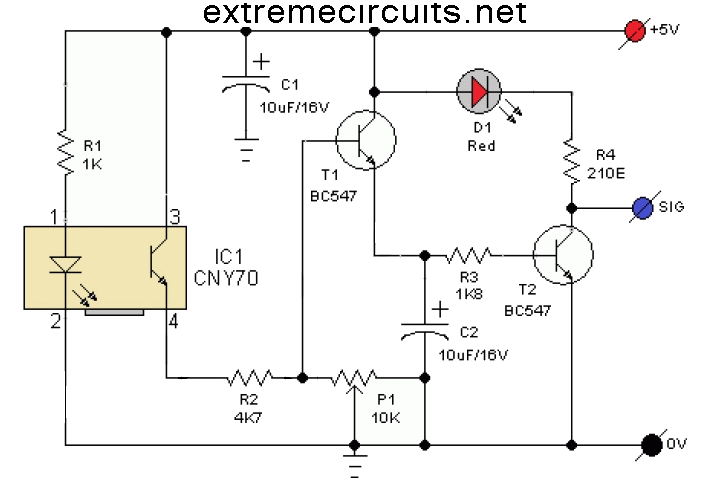
Line Following Robot Sensor
This line-following robot sensor, also known as a surface scanner for robots, is a compact, stamp-sized infrared proximity detector designed for short-range detection, typically within 5 to 10 mm.
The line-following robot sensor operates using infrared light to detect the presence...
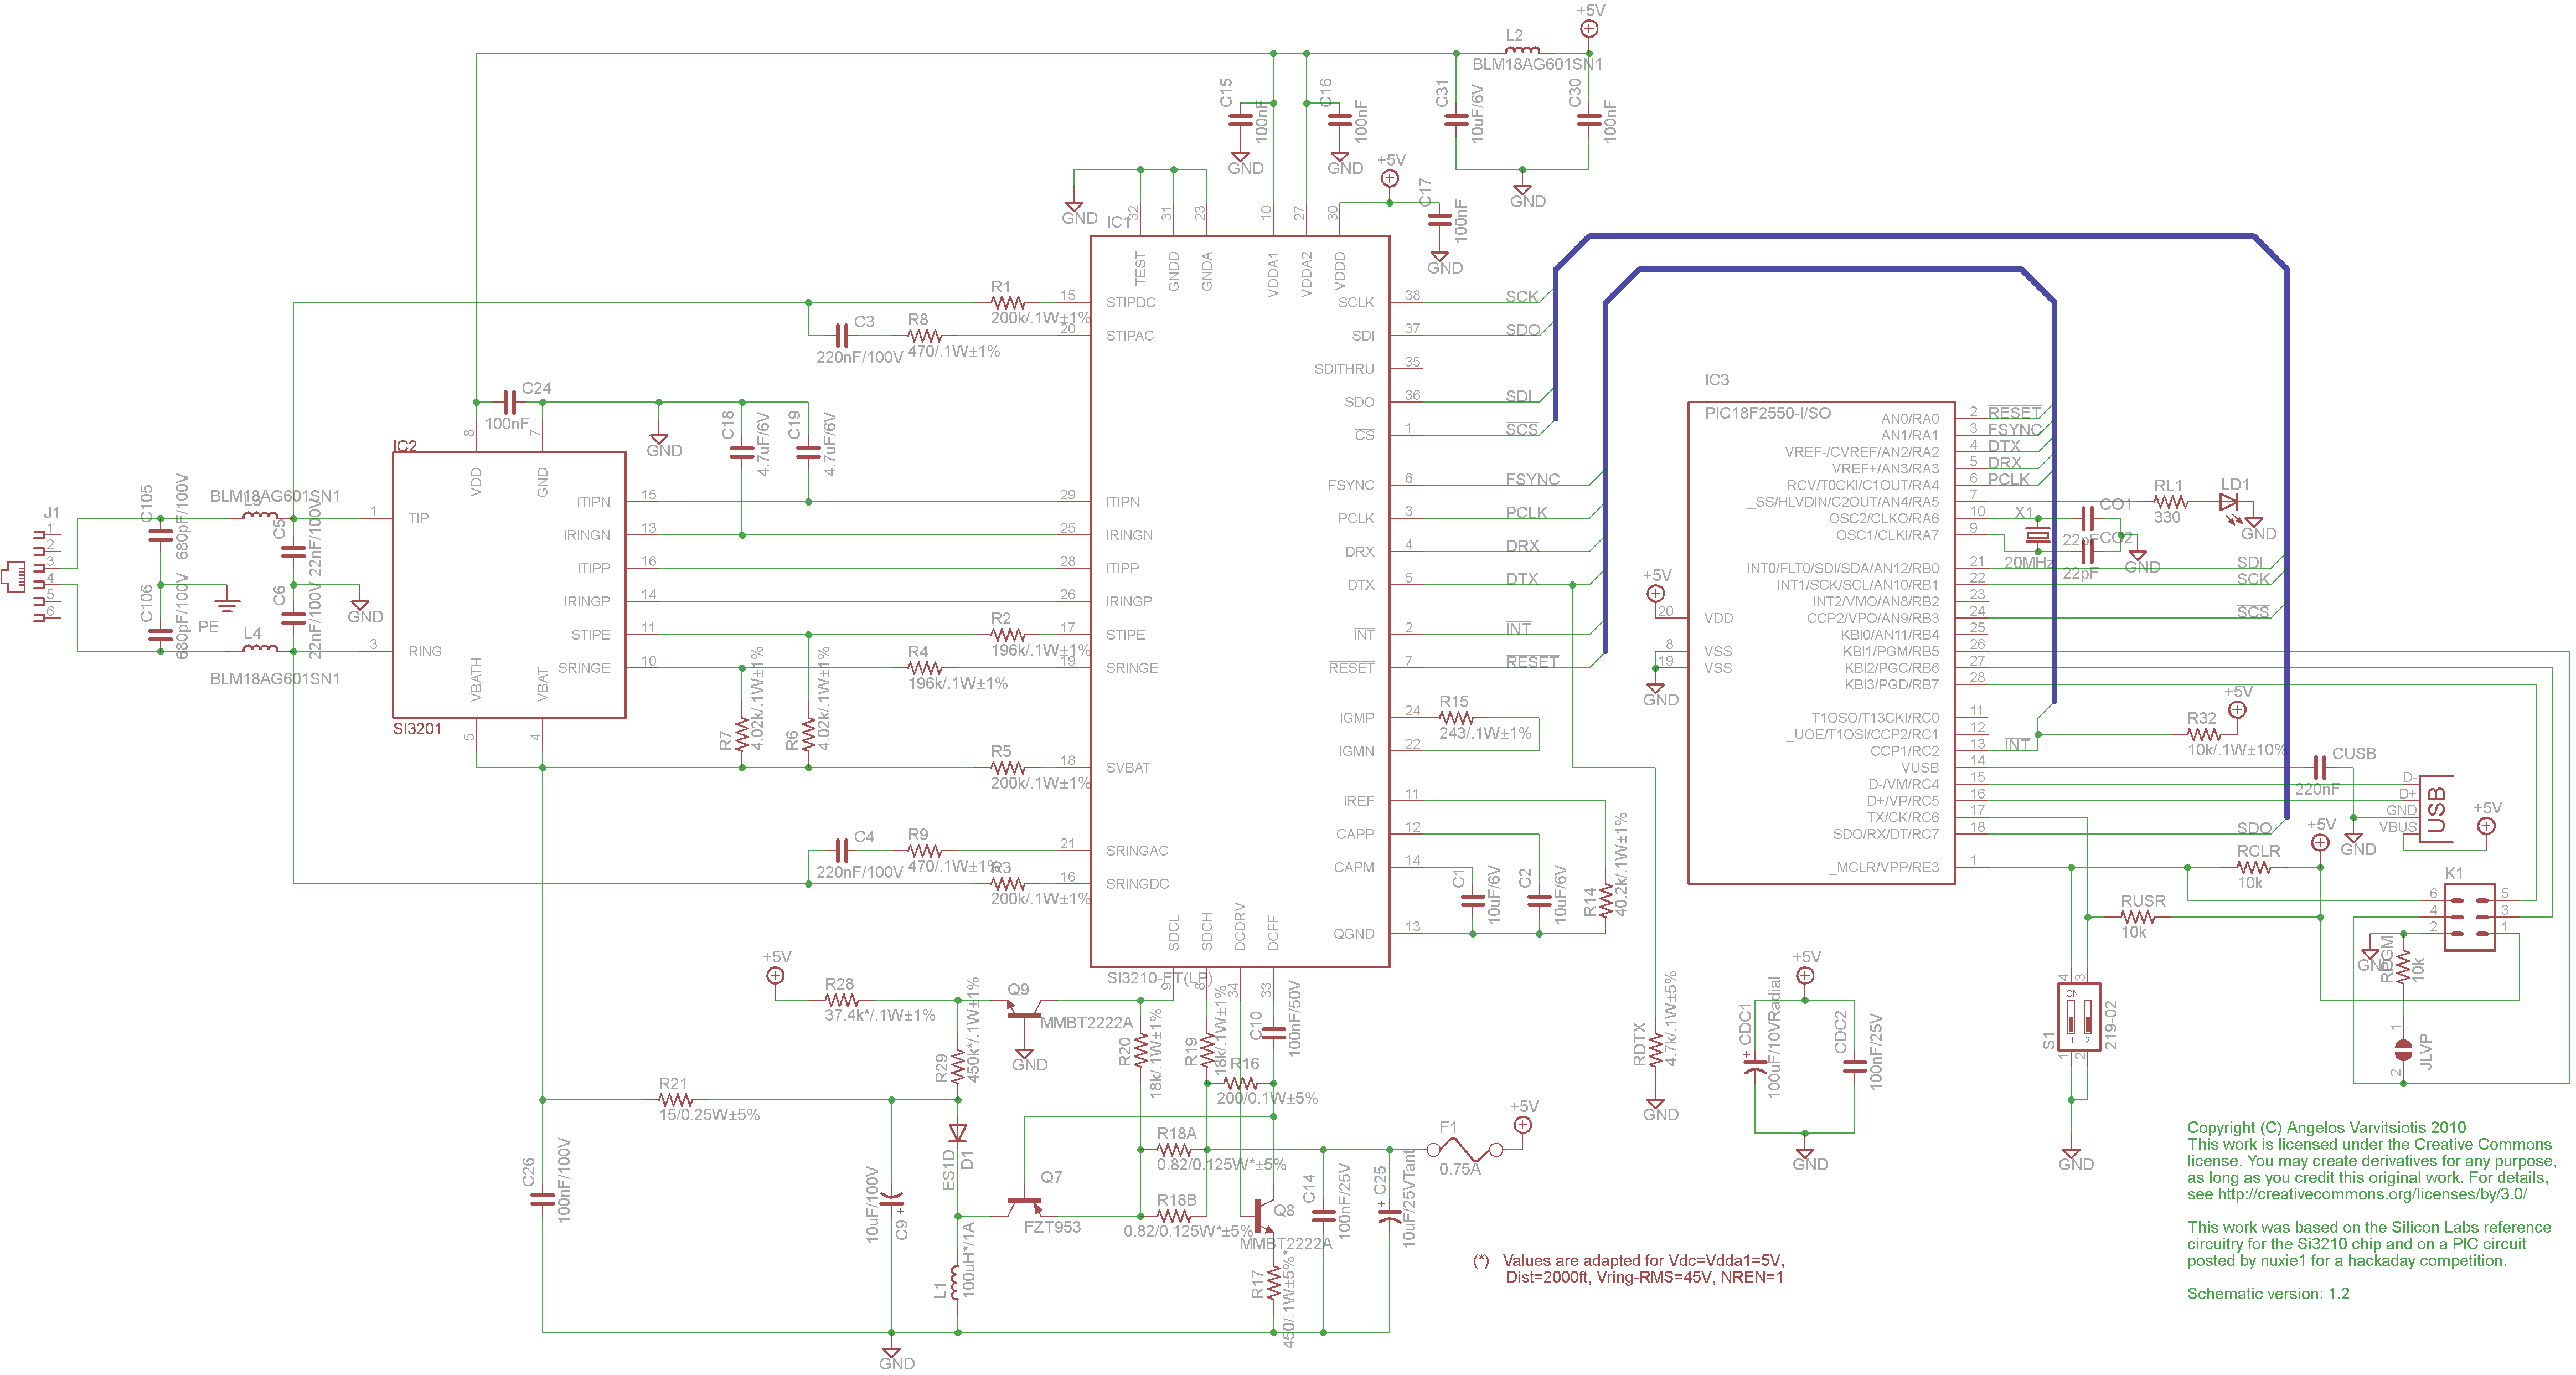
dyi setup and debugging guide
This page discusses the differences between assembled Open USB FXS dongle boards and DIY boards. While the assembled boards are fully tested and quality control approved, DIY boards may encounter various issues during assembly. Fortunately, most of these issues can...
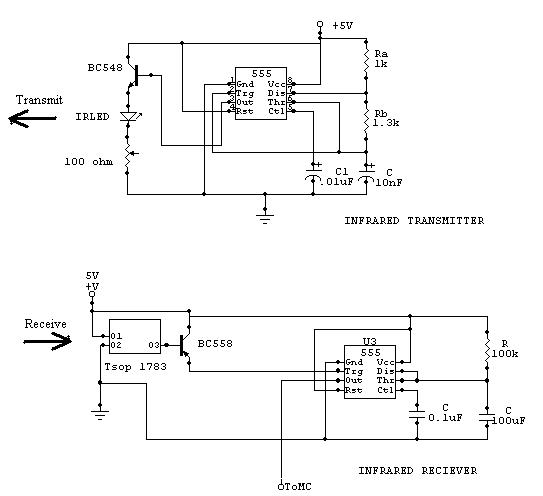
robot circuits
For a robot to perform its assigned tasks, a controller is necessary. This controller may be mechanical, electrical, electronic, or a combination of these. It acts as the brain of the entire system, providing the robot with its intelligence. The...
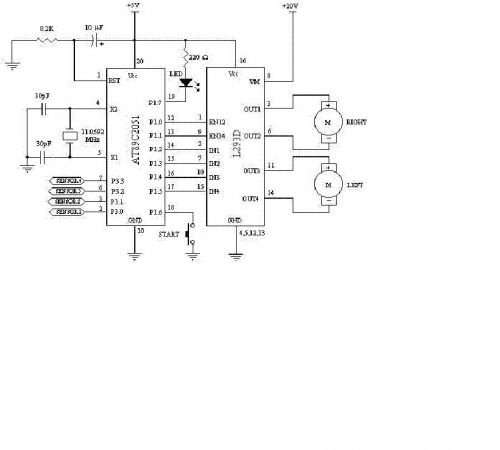
to verify schematics for 2 motor robot
Constructing a robot, or rather a vehicle, that uses two motors. Reference materials regarding the schematics for the circuit design have been obtained, but the current schematics utilize smaller motors that draw less power and operate with a lower power...