


robot circuits
#robot
#controller
#electronics
#automation
#intelligence
#mechanical
#electrical
#brain
#system
#tasks
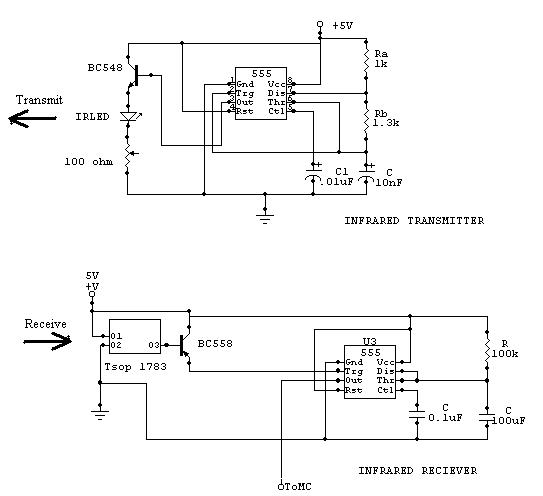
Description: For a robot to perform its assigned tasks, a controller is necessary. This controller may be mechanical, electrical, electronic, or a combination of these. It acts as the brain of the entire system, providing the robot with its intelligence. The additional functionalities of a controller indicate a higher level of intelligence exhibited by the manipulator. The fundamental requirement for any control system is the ability to sense the factors that need to be controlled. Sensing implies feedback, which allows for the realization of the status of a physical occurrence, enabling corrective measures to be taken upon detecting an error. If no path is available on either side, the robot should move back a step and check for available paths on either side, repeating this process until a path is found. The integration of all these components with the manipulator leads to the development of an Autonomous Legged Intelligence Exhibiting Navigator, referred to as Alien. The following sections will detail the various subsystems that constitute the controller. Alien's vision system employs a pair of photovoltaic cells (PVC) with two monocular lenses acting as photoreceptors. The PVC serves as the core sensor of the system, with the voltage across each cell varying according to the inverse square law of luminous intensity; that is, as the distance increases, the intensity decreases. The PVC captures light reflected from an object or obstacle and converts this intensity into a voltage across its terminals (typically in millivolts). This voltage is subsequently amplified using a UA741 operational amplifier. The amplified voltages from the two receptors are subtracted, and this result is compared to a predetermined reference voltage based on experimental values. The comparator outputs a signal indicating the presence of an object that can be climbed or one that cannot be scaled. The two monocular lenses are focused on points resembling the "rise" and "go" of a stair (obstacles that the robot can scale). For an object that can be scaled, the difference in light intensities is significant, whereas for an object that cannot be scaled, the difference is minimal. The final version of the vision system was achieved after extensive experimentation, leading to a reduction in the number of PVCs compared to the system used in ROVIS (a student project at REC Trichy conducted under external supervision in 1998). Various methods of obstacle detection exist; however, a non-contact method was chosen, utilizing ultrasonic waves for obstacle detection by bouncing waves off obstacles and receiving these waves. Although this method was initially experimented with, it was ultimately abandoned due to inconsistent results. The final obstacle detection system for Alien employs infrared waves to detect obstacles in front of it. Limitations of using infrared waves include a restricted range without dispersal and variability in the intensity of reflected waves based on the material and color of the obstacle. The system consists of an infrared transmitter and receiver, both synchronized by the Master Controller. This circuit transmits infrared waves when triggered by the Master Controller, utilizing an infrared LED that emits waves at a predetermined frequency set by a 555 timer. The chosen frequency for transmission is 40,277.7 Hz, established through appropriate resistor values (Ra, Rb) and a capacitor (C) connected to the timer. The frequency is determined by a specific formula. The output from the timer is amplified using a BC548 transistor, with a variable resistance of 100 ohms employed to adjust the transmission distance.
The described controller system integrates both vision and obstacle detection functionalities, enabling the robot to navigate its environment autonomously. The vision system, based on photovoltaic cells, allows the robot to assess the surrounding light conditions and identify potential obstacles that can be scaled. The use of infrared waves for obstacle detection complements this by providing real-time feedback on immediate obstacles, ensuring the robot can make informed navigation decisions.
The architecture of the controller likely includes microcontroller units (MCUs) that process the signals from the PVCs and the infrared system, allowing for seamless coordination between the various components. The MCU can be programmed to execute algorithms that determine the robot's movement based on the feedback received from the sensors. Furthermore, the integration of the UA741 operational amplifier and BC548 transistor ensures that the signals are adequately amplified for processing, allowing for accurate detection and response to the environment.
In summary, the controller for the Autonomous Legged Intelligence Exhibiting Navigator, Alien, is a sophisticated system that leverages various electronic components to provide sensory feedback and control, enabling the robot to navigate and perform tasks effectively in its designated environment.For any robot to perform the tasks it is assigned, a controller is required. The controller may be mechanical, electrical, electronic or a combination of these. It is the brain of the entire system and gives the robot its intelligence. Additional functionalities that a controller may possess will indicate a higher level of intelligence exhibited b y the manipulator. The basic necessity for any control is a capability to sense the factor to be controlled. Sensing implies feedback, which is a means to realize the status of a physical occurrence so that corrective measures can be employed upon the realization of an error. If no path is available on either side, move back a step and check if a path is available on either side.
This step is to be repeated until a path is found. Integration of all these components with the manipulator leads to an Autonomous Legged Intelligence Exhibiting Navigator, Alien. The following sections explain in detail, the various sub-systems that make up the controller. Alien`s vision system involves a pair of photovoltaic cell (PVC) with two monocular lenses as photoreceptors.
This PVC is the core sensor of the system and the voltage across each cell varies according to the 1/(d ²) law of Luminous intensity i. e. , greater the distance lesser the intensity. The PVC receives light reflected from an object or an obstacle under surveillance and represents the intensity in the form of a voltage across the terminals (usually in mV).
This voltage is then amplified through a UA741 IC. The amplified voltages from the two receptors are subtracted and this value is compared with a reference voltage that is predetermined by experimented values. The comparator gives an output to signify the presence of an object that can be climbed or an object that cannot be scaled.
Figure 3. 1 depicts the logic flowchart of the vision system. The two monocular lenses are focused upon points that resemble the rise` and go` of a stair (obstacle that can be scaled by the robot) as shown in figure 3. 2. In the case of an object that can be scaled by the robot, the difference in light intensities is high, while for an object that cannot be scaled the difference is minimal.
The final version of the vision system resulted after a vast amount of experimentation. The number of PVCs used was considerably reduced as compared to the system used in ROVIS (an REC Trichy student project done under our external guide`s supervision in 1998). Several methods of obstacle detection sensing exist. We had opted to use a non contact method of obstacle detection by bouncing off waves from the obstacle and receiving these waves.
Using ultrasonic waves for this purpose is an effective method since its usage is not generally hampered by extraneous ambient noise. We experimented with this method but finally abandoned it since the results obtained were fairly inconsistent.
The obstacle detection system finally devised for Alien uses infrared waves to detect an obstacle in front of it. The drawbacks of using infrared waves are: a limited range that the wave can travel without dispersal, and the inconsistency of the intensity of the reflected waves which is dependent on the material and colour of the obstacle.
The system consists of an infrared transmitter and receiver that are both synchronized by the Master Controller. This circuit is used to transmit Infrared waves when triggerd by the Master Controller. It uses an Infrared LED that sends out a pulse of waves at a predetermined frequency set in the 555-timer.
The frequency of transmission that we selected is 40277. 7 Hz. The frequency was set by using appropriate values of resistances of Ra, R b and capacitor C that are connected to the timer. The frequency is determined by the formula: - The output of the timer is amplified using BC548 and the variable resistance of 100 ohms is used to vary the distance of transmission.
This value of resistance
The described controller system integrates both vision and obstacle detection functionalities, enabling the robot to navigate its environment autonomously. The vision system, based on photovoltaic cells, allows the robot to assess the surrounding light conditions and identify potential obstacles that can be scaled. The use of infrared waves for obstacle detection complements this by providing real-time feedback on immediate obstacles, ensuring the robot can make informed navigation decisions.
The architecture of the controller likely includes microcontroller units (MCUs) that process the signals from the PVCs and the infrared system, allowing for seamless coordination between the various components. The MCU can be programmed to execute algorithms that determine the robot's movement based on the feedback received from the sensors. Furthermore, the integration of the UA741 operational amplifier and BC548 transistor ensures that the signals are adequately amplified for processing, allowing for accurate detection and response to the environment.
In summary, the controller for the Autonomous Legged Intelligence Exhibiting Navigator, Alien, is a sophisticated system that leverages various electronic components to provide sensory feedback and control, enabling the robot to navigate and perform tasks effectively in its designated environment.For any robot to perform the tasks it is assigned, a controller is required. The controller may be mechanical, electrical, electronic or a combination of these. It is the brain of the entire system and gives the robot its intelligence. Additional functionalities that a controller may possess will indicate a higher level of intelligence exhibited b y the manipulator. The basic necessity for any control is a capability to sense the factor to be controlled. Sensing implies feedback, which is a means to realize the status of a physical occurrence so that corrective measures can be employed upon the realization of an error. If no path is available on either side, move back a step and check if a path is available on either side.
This step is to be repeated until a path is found. Integration of all these components with the manipulator leads to an Autonomous Legged Intelligence Exhibiting Navigator, Alien. The following sections explain in detail, the various sub-systems that make up the controller. Alien`s vision system involves a pair of photovoltaic cell (PVC) with two monocular lenses as photoreceptors.
This PVC is the core sensor of the system and the voltage across each cell varies according to the 1/(d ²) law of Luminous intensity i. e. , greater the distance lesser the intensity. The PVC receives light reflected from an object or an obstacle under surveillance and represents the intensity in the form of a voltage across the terminals (usually in mV).
This voltage is then amplified through a UA741 IC. The amplified voltages from the two receptors are subtracted and this value is compared with a reference voltage that is predetermined by experimented values. The comparator gives an output to signify the presence of an object that can be climbed or an object that cannot be scaled.
Figure 3. 1 depicts the logic flowchart of the vision system. The two monocular lenses are focused upon points that resemble the rise` and go` of a stair (obstacle that can be scaled by the robot) as shown in figure 3. 2. In the case of an object that can be scaled by the robot, the difference in light intensities is high, while for an object that cannot be scaled the difference is minimal.
The final version of the vision system resulted after a vast amount of experimentation. The number of PVCs used was considerably reduced as compared to the system used in ROVIS (an REC Trichy student project done under our external guide`s supervision in 1998). Several methods of obstacle detection sensing exist. We had opted to use a non contact method of obstacle detection by bouncing off waves from the obstacle and receiving these waves.
Using ultrasonic waves for this purpose is an effective method since its usage is not generally hampered by extraneous ambient noise. We experimented with this method but finally abandoned it since the results obtained were fairly inconsistent.
The obstacle detection system finally devised for Alien uses infrared waves to detect an obstacle in front of it. The drawbacks of using infrared waves are: a limited range that the wave can travel without dispersal, and the inconsistency of the intensity of the reflected waves which is dependent on the material and colour of the obstacle.
The system consists of an infrared transmitter and receiver that are both synchronized by the Master Controller. This circuit is used to transmit Infrared waves when triggerd by the Master Controller. It uses an Infrared LED that sends out a pulse of waves at a predetermined frequency set in the 555-timer.
The frequency of transmission that we selected is 40277. 7 Hz. The frequency was set by using appropriate values of resistances of Ra, R b and capacitor C that are connected to the timer. The frequency is determined by the formula: - The output of the timer is amplified using BC548 and the variable resistance of 100 ohms is used to vary the distance of transmission.
This value of resistance
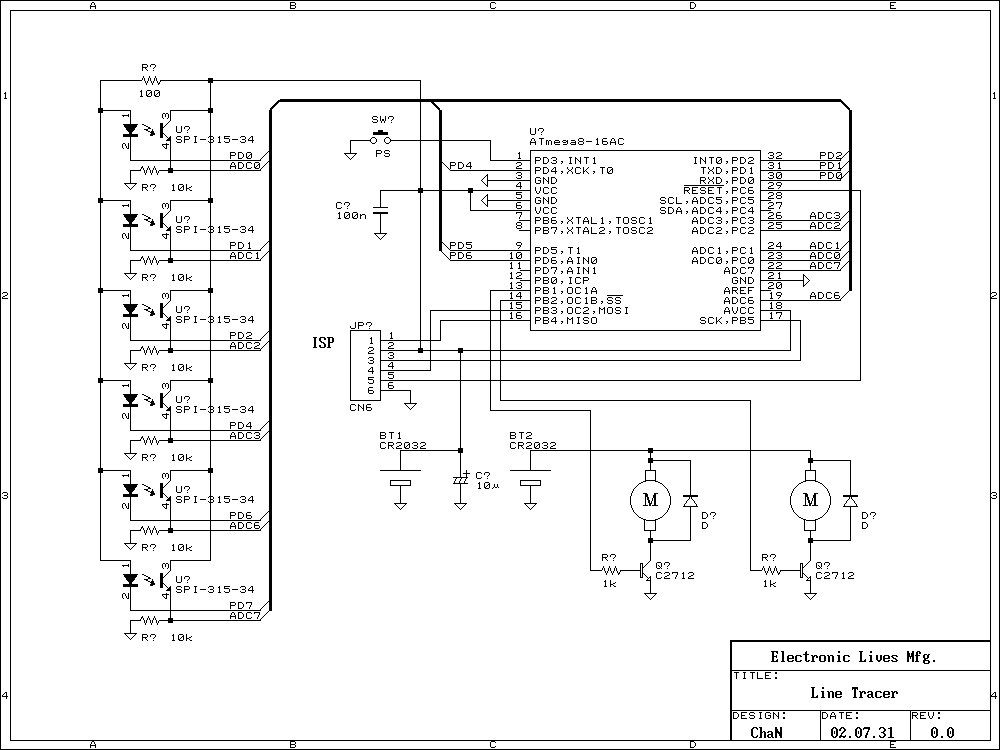
Desktop Line Following Robot
Recently many kind of robot contests have being opened and some interesting reports of the challenge are found on the web. The Line Following is a kind of the robot contests to vie running speed on the line. I build...
Dancing Robots
A robot that dances to music. It would be fascinating to have a small robot on your desk dancing to music from Fatboy Slim. Winamp provides an API for writing music visualization plug-ins. A plug-in was developed that sends signals...
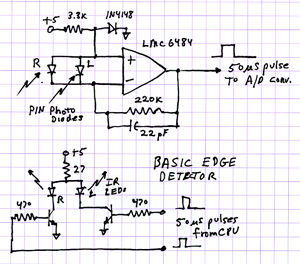
Homemade Robots polymax improvements
The 2009 Robot Rally highlighted the flaws resulting from a rapid three-week engineering and building project. Time-saving shortcuts in both code and hardware led to multiple failures, including edge detectors, beacon trackers, and line follower reversals. Investigations were conducted into...
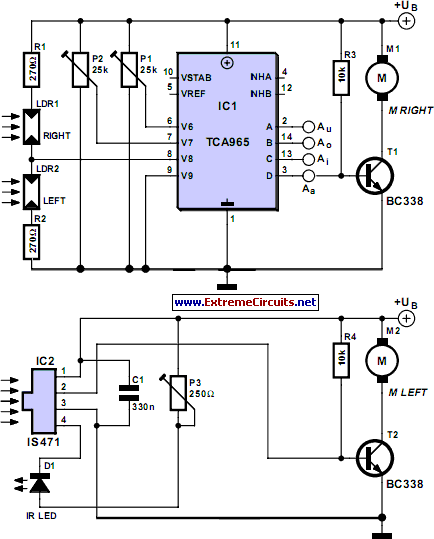
discrete robot schematics
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The primary component in the circuit is a window discriminator, which functions as an advanced window comparator. Resistors R1 and R2, in...
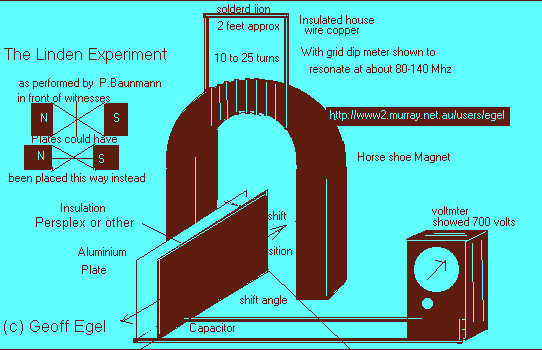
Swiss ML Testakica
The Unit is started by hand by revolving the two disks in opposite directions and continues to move without further input. This device has only two moving parts namely the bearing races at the centre of the disk. The disks...
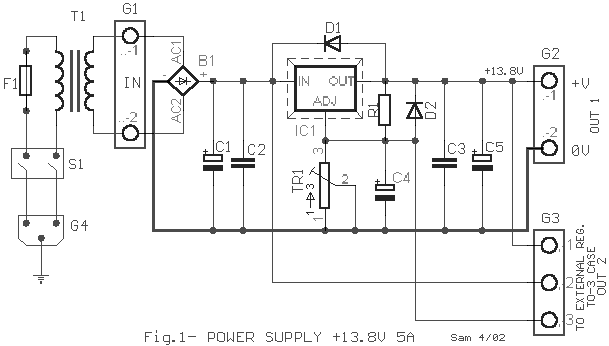
Electronics Projects Circuits
Over 1400 top electronics projects and electronic circuits with photos, datasheets, and easy-to-read schematics, along with explanations of how they work and how to build them.
The collection comprises a vast array of electronics projects suitable for enthusiasts and professionals alike....
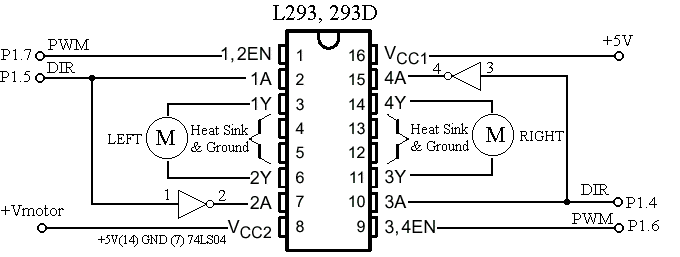
de amst wiskar: robot line folower
One of the students has created a robot that utilizes two stepper motors and a simple IR sensor. The robot, which is depicted in the accompanying image, has some issues such as a lack of battery support and misalignment of...
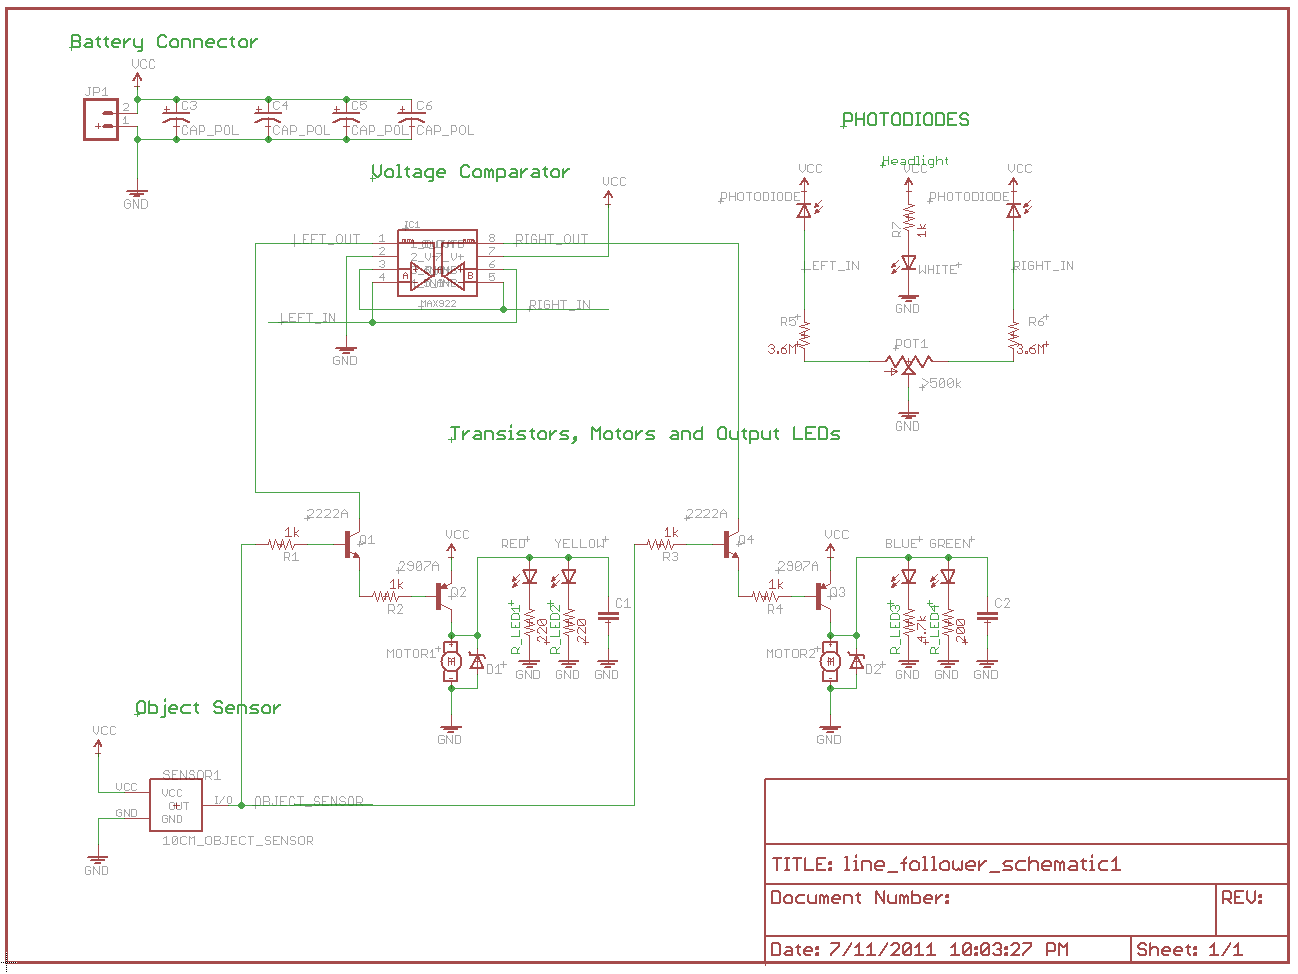
fun robot line followers
When new to electronics and lacking experience or direction, one book provided guidance on building interesting projects: "Robot Building for Beginners" by David Cook. In this book, Cook outlines the fundamental components and design considerations essential for constructing a simple...
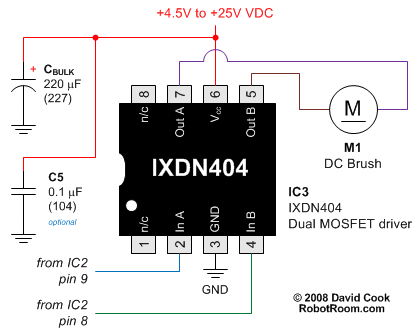
Simple Robot That Drives Forward and Back
The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an...