


Desktop Line Following Robot
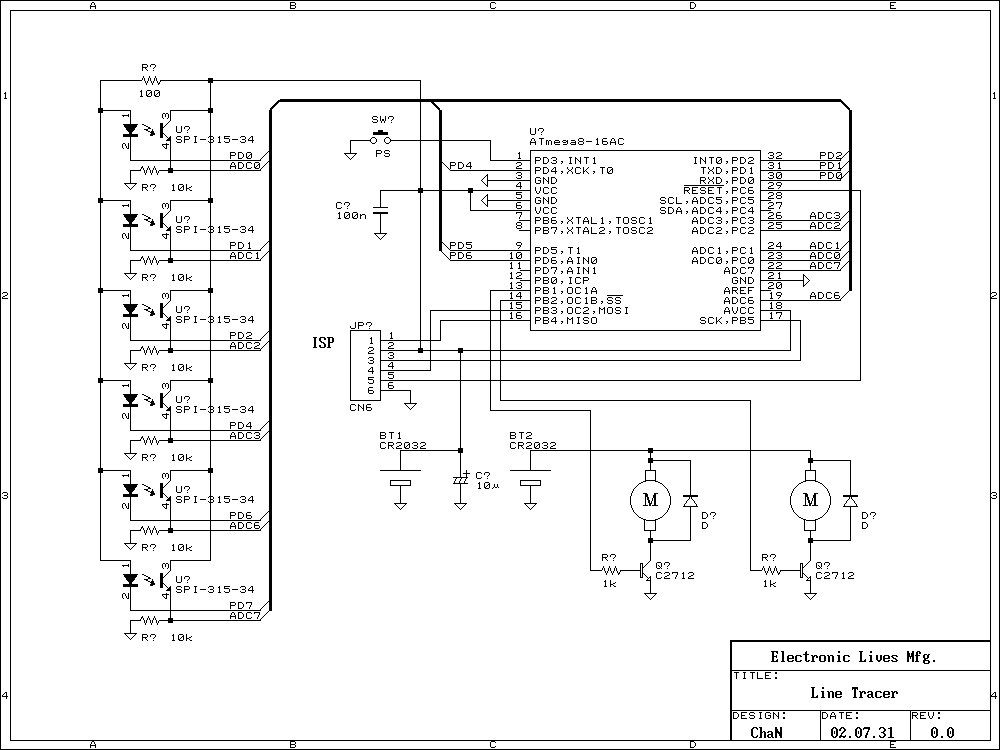
Description: Recently many kind of robot contests have being opened and some interesting reports of the challenge are found on the web. The Line Following is a kind of the robot contests to vie running speed on the line. I build a tiny line following robot which can run on the desk, moving the key board aside will do. It is for only a personal toy reduced its size less than one fifth compared to typical line following robots, not in formura.
The line following robot is a compact, autonomous vehicle designed to detect and follow a predefined path, typically marked by a contrasting line on the ground. This miniature version, reduced to less than one-fifth the size of standard models, employs several key components to achieve its functionality.
At the core of the robot is a microcontroller, which serves as the brain of the system. This microcontroller can be an Arduino Nano or similar, chosen for its small footprint and sufficient processing power to handle sensor inputs and motor controls. The robot is equipped with infrared (IR) sensors, typically two or more, positioned at the front to detect the line. These sensors emit IR light and measure the reflected light to determine whether the surface beneath them is light or dark, thus identifying the path.
The robot's movement is facilitated by two DC motors connected to wheels. The motors are controlled through a motor driver IC, such as the L298N, which allows for direction and speed control based on the microcontroller's signals. The motors are mounted on a lightweight chassis, which can be constructed from materials like plastic or thin plywood to maintain the robot's overall low weight.
Power for the robot is usually supplied by a small rechargeable lithium-polymer (LiPo) battery, which provides a good balance between size, weight, and capacity. A voltage regulator may be included to ensure that the microcontroller and motors receive the appropriate voltage levels for optimal performance.
The control algorithm for the robot is relatively simple, typically involving a basic proportional control loop. When the IR sensors detect that the robot is veering off the line, the microcontroller adjusts the motor speeds accordingly to steer the robot back onto the path. This feedback mechanism allows the robot to maintain a steady course along the line, competing effectively in speed against other participants in the contest.
In summary, this tiny line-following robot exemplifies the principles of robotics and automation, showcasing how compact design and efficient programming can yield a functional and entertaining device suitable for personal use and competition.Recently many kind of robot contests have being opened and some interesting reports of the challenge are found on the web. The Line Following is a kind of the robot contests to vie running speed on the line. I build a tiny line following robot which can run on the desk, moving the key board aside will do. It is for only a personal toy reduced its size less than one fifth compared to typical line following robots, not in formura.
The line following robot is a compact, autonomous vehicle designed to detect and follow a predefined path, typically marked by a contrasting line on the ground. This miniature version, reduced to less than one-fifth the size of standard models, employs several key components to achieve its functionality.
At the core of the robot is a microcontroller, which serves as the brain of the system. This microcontroller can be an Arduino Nano or similar, chosen for its small footprint and sufficient processing power to handle sensor inputs and motor controls. The robot is equipped with infrared (IR) sensors, typically two or more, positioned at the front to detect the line. These sensors emit IR light and measure the reflected light to determine whether the surface beneath them is light or dark, thus identifying the path.
The robot's movement is facilitated by two DC motors connected to wheels. The motors are controlled through a motor driver IC, such as the L298N, which allows for direction and speed control based on the microcontroller's signals. The motors are mounted on a lightweight chassis, which can be constructed from materials like plastic or thin plywood to maintain the robot's overall low weight.
Power for the robot is usually supplied by a small rechargeable lithium-polymer (LiPo) battery, which provides a good balance between size, weight, and capacity. A voltage regulator may be included to ensure that the microcontroller and motors receive the appropriate voltage levels for optimal performance.
The control algorithm for the robot is relatively simple, typically involving a basic proportional control loop. When the IR sensors detect that the robot is veering off the line, the microcontroller adjusts the motor speeds accordingly to steer the robot back onto the path. This feedback mechanism allows the robot to maintain a steady course along the line, competing effectively in speed against other participants in the contest.
In summary, this tiny line-following robot exemplifies the principles of robotics and automation, showcasing how compact design and efficient programming can yield a functional and entertaining device suitable for personal use and competition.Recently many kind of robot contests have being opened and some interesting reports of the challenge are found on the web. The Line Following is a kind of the robot contests to vie running speed on the line. I build a tiny line following robot which can run on the desk, moving the key board aside will do. It is for only a personal toy reduced its size less than one fifth compared to typical line following robots, not in formura.
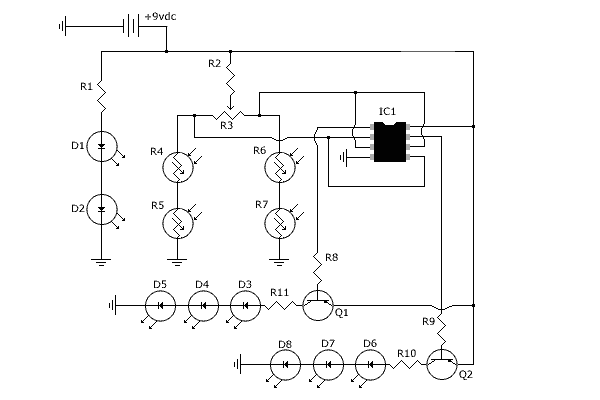
robot guts
The headlights and photo cells are oriented downward, leading to the visualization of the entire circuit as being inverted. The configuration utilizes three LEDs on each side. This choice is likely due to the inability to power three LEDs in...
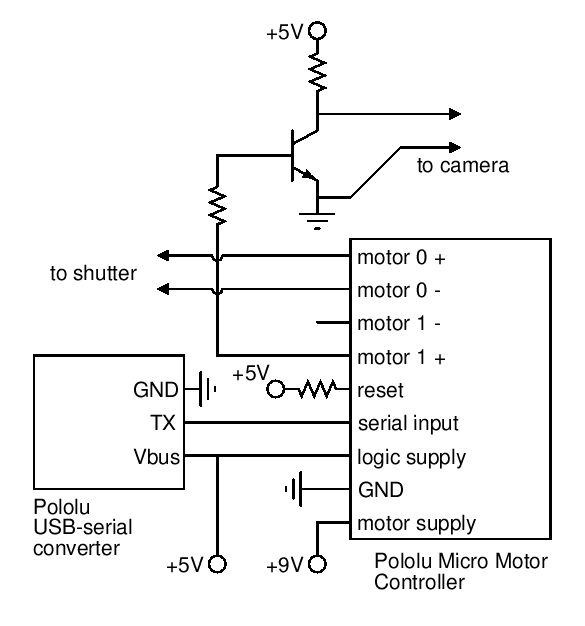
5 Minute Signal
For the past year and a half, a group based in Ann Arbor, Michigan, named GO-Tech has been formed, uniting individuals interested in creating projects using technology, such as hardware, software, metal, and wood. This initiative is referred to as...
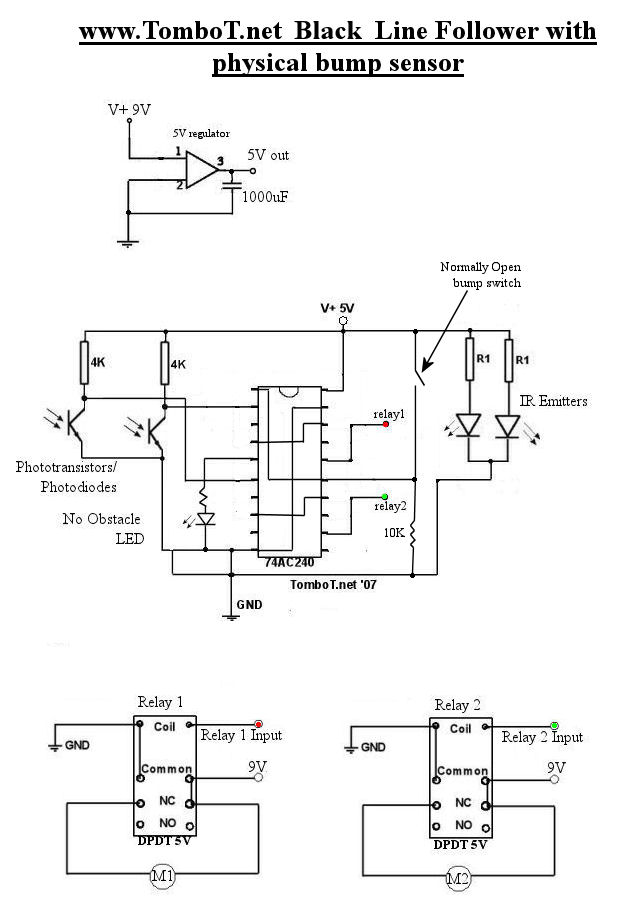
Line Following Robot circuit
The motors will be powered by the full source voltage, so it is important to ensure that this does not cause the robot to operate too quickly. The Firebot utilizes GM3 motors powered by a 9V battery; however, in this...
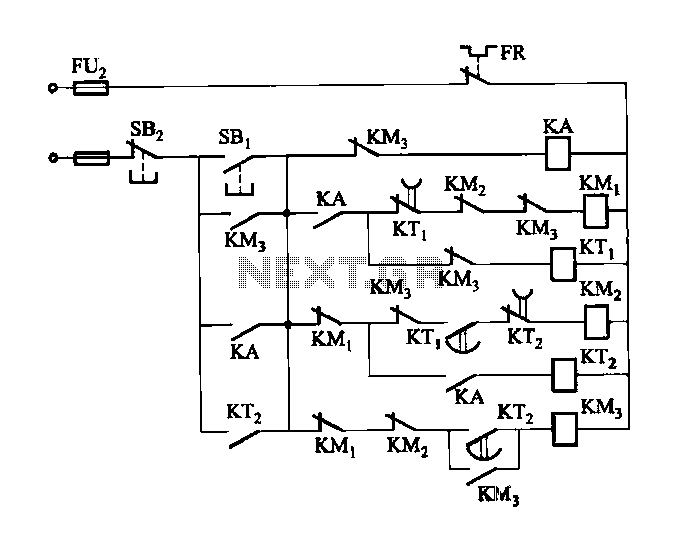
2 -Y- connection automatic three-speed motor acceleration control circuit
Figure 3-118 illustrates an automatic acceleration control circuit. This circuit employs a male contactor time relay, enabling the motor to start automatically at a low speed before transitioning to high-speed operation.
The automatic acceleration control circuit depicted in Figure 3-118 is...
MePADS
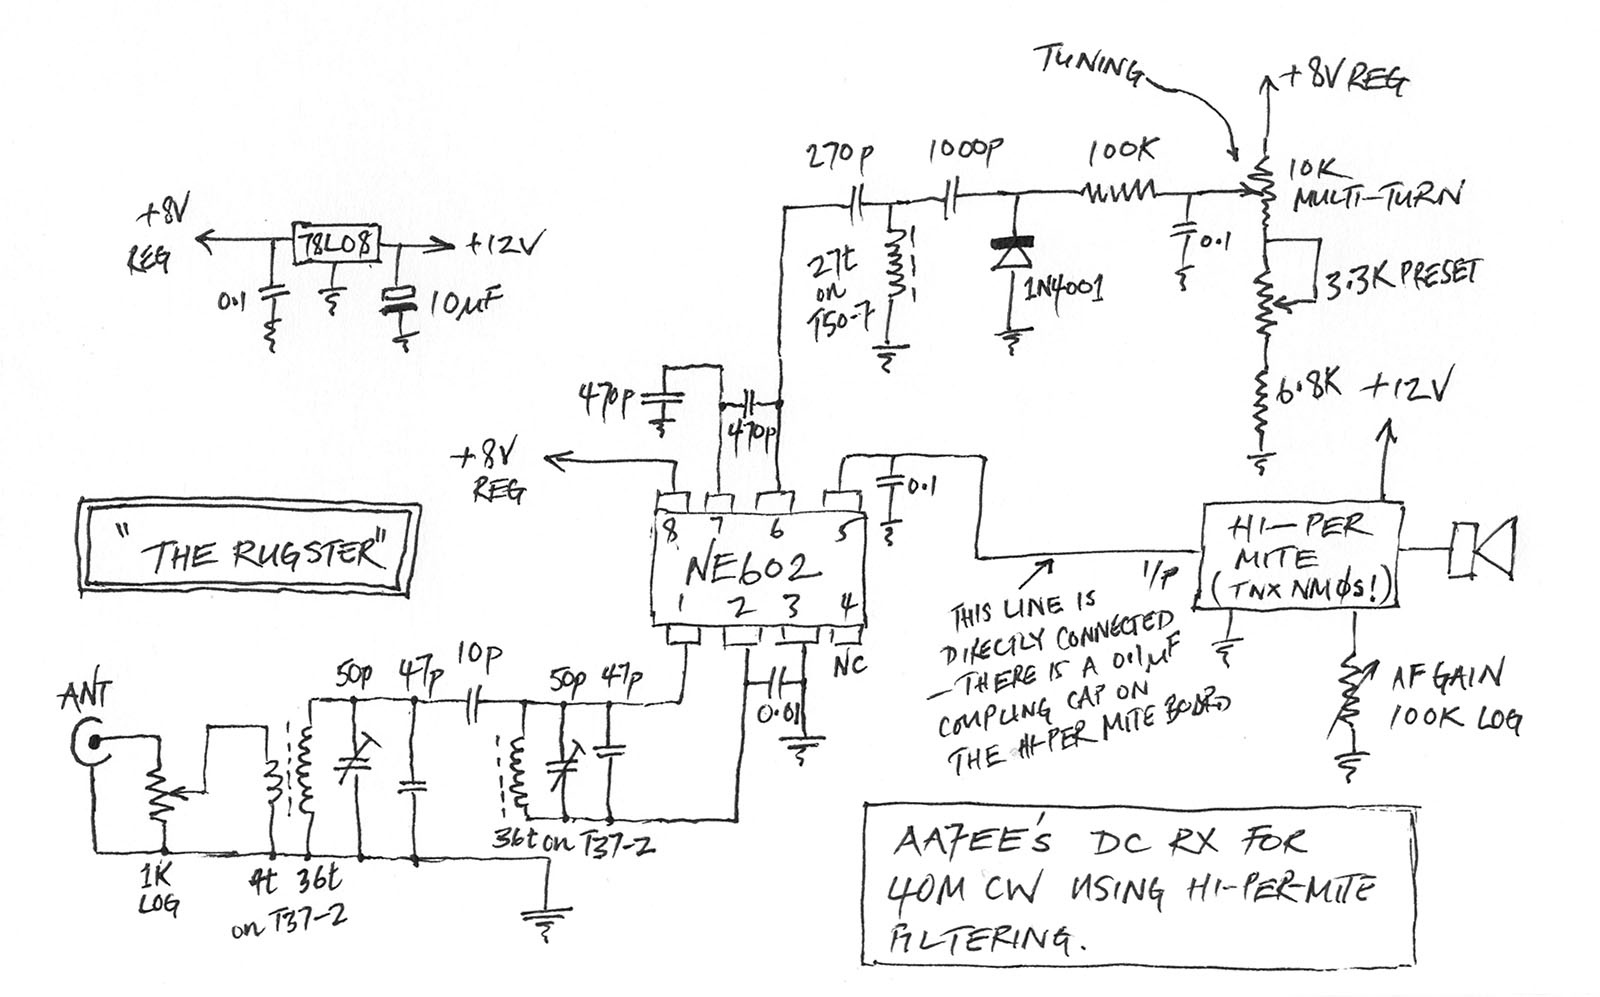
If you are considering building the Desert Ratt 2, it is advisable to read all the accompanying text, as it contains relevant construction details. Engaging with the comments and replies can also provide additional insights, as previous blog posts have...
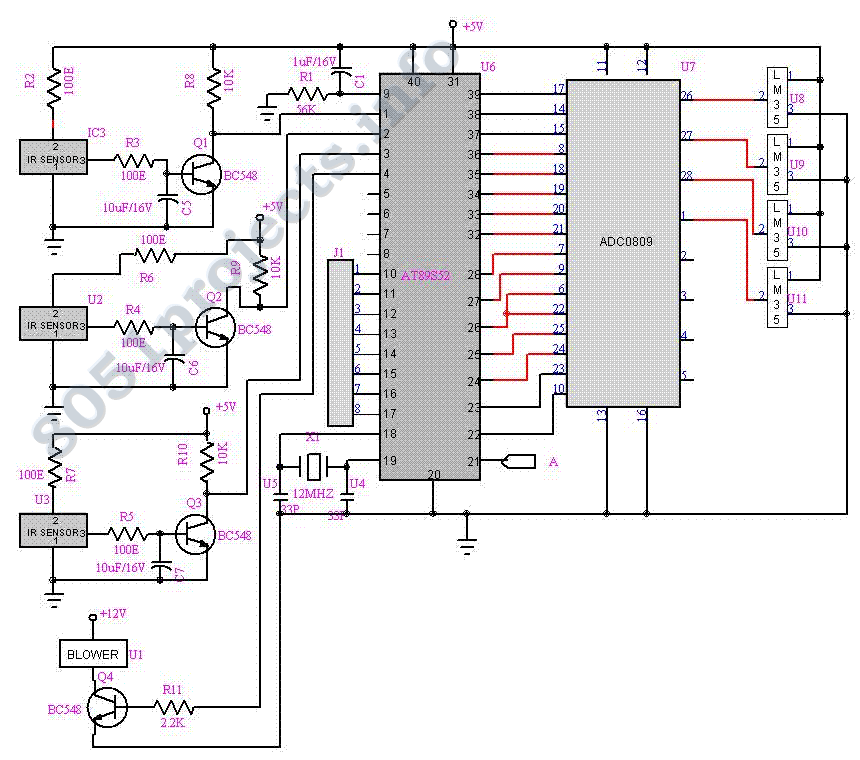
Fighting Robot circuit
The need for a device that can detect and extinguish a fire on its own is long past due. Many house fires originate when someone is either sleeping or not home. With the invention of such a device, people and...
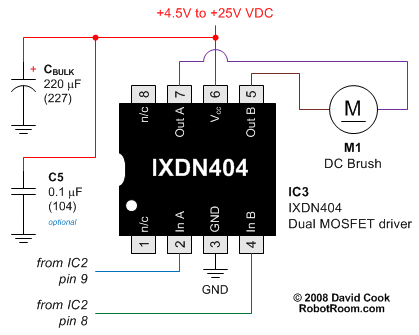
Simple Robot That Drives Forward and Back
The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an...
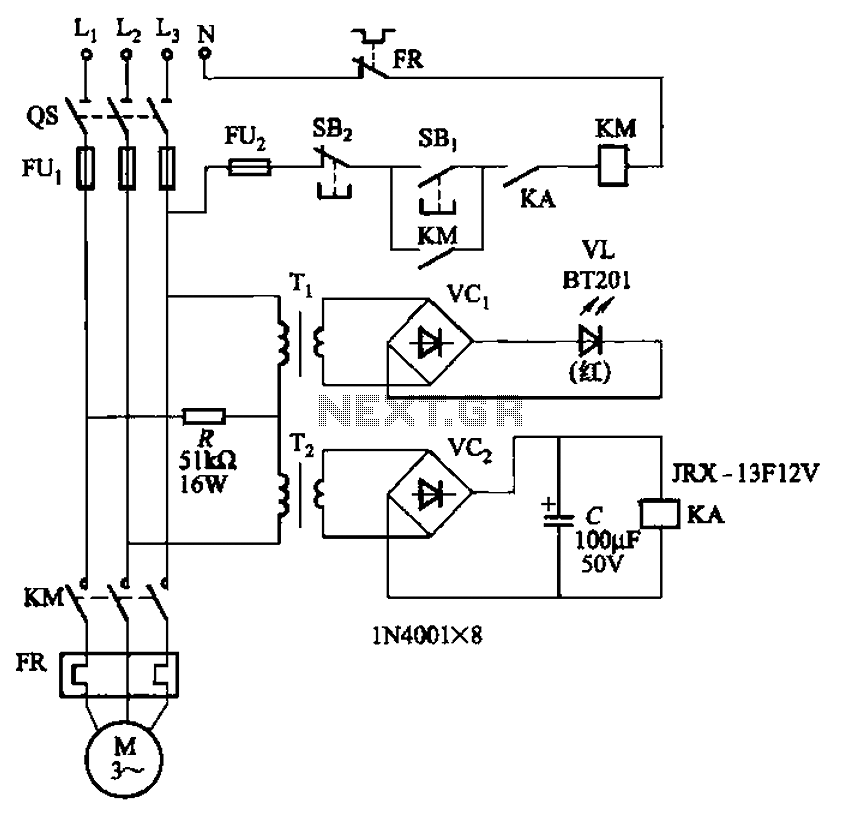
Allowing only one-way operation of the motor-controlled circuit 2
The circuit depicted in Figure 3-92 employs a dual-phase sequence protection relay for sensing. When the power supply exhibits a positive phase sequence (U, V, W), the relay KA is activated. If the power supply maintains the correct phase sequence,...
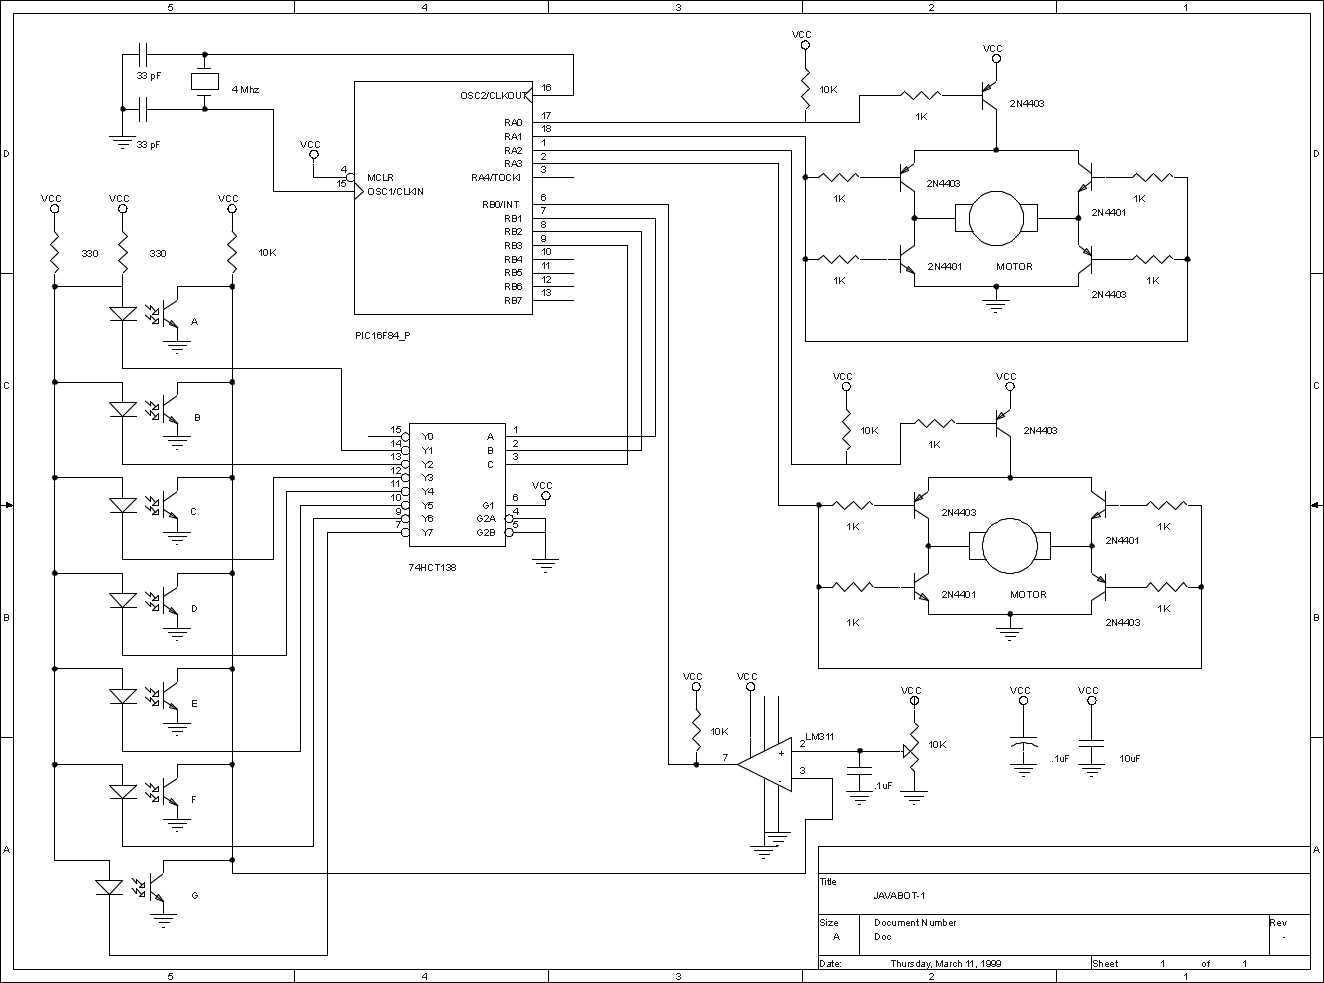
JavaBot1
The JavaBot1 is a small line following robot designed to follow a black line drawn on a dry erase board. It is designed to follow very tight curves. The software still has lots of room for improvement but works well...