


to verify schematics for 2 motor robot
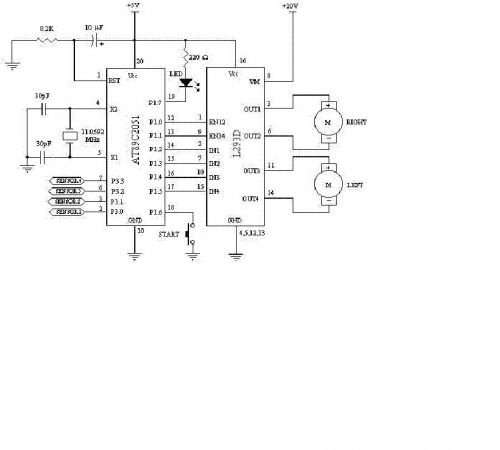
Description: Constructing a robot, or rather a vehicle, that uses two motors. Reference materials regarding the schematics for the circuit design have been obtained, but the current schematics utilize smaller motors that draw less power and operate with a lower power supply. The objective is to incorporate more powerful motors and provide additional power to the circuit. Assistance is requested on how to modify the circuit. Additionally, there is an inquiry about the feasibility of building a Segway using the same circuit, as it also employs two motors. If it is possible, guidance is sought on how to integrate a gyroscope and a Kalman filter to enable self-balancing for the robot.
To modify the circuit for the use of more powerful motors, several steps must be taken. First, it is essential to select motors that match the desired specifications in terms of voltage and current ratings. The power supply must be upgraded to accommodate the increased power requirements of the new motors. This may involve using a higher voltage battery or a more robust power supply unit that can deliver the necessary current without causing voltage drops.
Next, the motor driver circuitry must be evaluated. The existing motor driver may not support the higher current ratings of the new motors. It may be necessary to replace it with a motor driver that can handle the increased load. For example, an H-bridge driver capable of managing the peak current of the new motors should be chosen. Proper heat dissipation mechanisms, such as heat sinks or active cooling, may also be required to prevent overheating during operation.
Regarding the construction of a Segway prototype using the same circuit, it is indeed feasible, as both applications utilize two motors for propulsion. However, additional components will need to be integrated to achieve self-balancing functionality. A gyroscope and accelerometer combination is typically employed for this purpose. The gyroscope provides angular velocity data, while the accelerometer measures linear acceleration. Together, they can give a comprehensive understanding of the vehicle's orientation and motion.
To implement self-balancing, a Kalman filter can be utilized to process the sensor data. The Kalman filter will help in estimating the state of the system, filtering out noise, and providing a more accurate representation of the vehicle's tilt angle. The output from the Kalman filter can then be used to adjust the motor speeds dynamically, ensuring that the vehicle maintains its balance.
In summary, modifying the circuit for more powerful motors involves upgrading the power supply and motor driver, while building a Segway prototype requires the integration of sensors and a Kalman filter for self-balancing capabilities. Proper design considerations must be taken into account to ensure that the system operates effectively and safely.Constructing a robot or should i say a vehicle dat uses 2 motors. I managed to get sum referance regarding d schematics for the circuit design but the current schematics uses a smaller motor. which draws less power and uses a much less power supply. the schematics is in the link below. i need to use a much powerful motor and provide more power to the circuit. cn anyone provide some explanation on howto modify the circuit. thankz a lot! jz another question. cn i build a segway using the same circuit. im planning 2 do a segway prototype. since this circuit also uses 2 motors. izit d same n if it is the sam. how do i add a gyro and a kaplan filter in it. in provide self-balance for the robot.
To modify the circuit for the use of more powerful motors, several steps must be taken. First, it is essential to select motors that match the desired specifications in terms of voltage and current ratings. The power supply must be upgraded to accommodate the increased power requirements of the new motors. This may involve using a higher voltage battery or a more robust power supply unit that can deliver the necessary current without causing voltage drops.
Next, the motor driver circuitry must be evaluated. The existing motor driver may not support the higher current ratings of the new motors. It may be necessary to replace it with a motor driver that can handle the increased load. For example, an H-bridge driver capable of managing the peak current of the new motors should be chosen. Proper heat dissipation mechanisms, such as heat sinks or active cooling, may also be required to prevent overheating during operation.
Regarding the construction of a Segway prototype using the same circuit, it is indeed feasible, as both applications utilize two motors for propulsion. However, additional components will need to be integrated to achieve self-balancing functionality. A gyroscope and accelerometer combination is typically employed for this purpose. The gyroscope provides angular velocity data, while the accelerometer measures linear acceleration. Together, they can give a comprehensive understanding of the vehicle's orientation and motion.
To implement self-balancing, a Kalman filter can be utilized to process the sensor data. The Kalman filter will help in estimating the state of the system, filtering out noise, and providing a more accurate representation of the vehicle's tilt angle. The output from the Kalman filter can then be used to adjust the motor speeds dynamically, ensuring that the vehicle maintains its balance.
In summary, modifying the circuit for more powerful motors involves upgrading the power supply and motor driver, while building a Segway prototype requires the integration of sensors and a Kalman filter for self-balancing capabilities. Proper design considerations must be taken into account to ensure that the system operates effectively and safely.Constructing a robot or should i say a vehicle dat uses 2 motors. I managed to get sum referance regarding d schematics for the circuit design but the current schematics uses a smaller motor. which draws less power and uses a much less power supply. the schematics is in the link below. i need to use a much powerful motor and provide more power to the circuit. cn anyone provide some explanation on howto modify the circuit. thankz a lot! jz another question. cn i build a segway using the same circuit. im planning 2 do a segway prototype. since this circuit also uses 2 motors. izit d same n if it is the sam. how do i add a gyro and a kaplan filter in it. in provide self-balance for the robot.
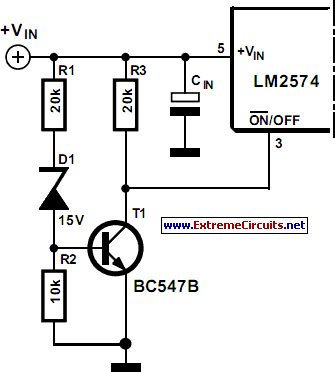
Soft Start For Switching Power Supply
A switching power supply that has an output voltage significantly lower than its input voltage exhibits a unique characteristic: the current drawn from the supply is less than the output current. However, the input power (UI) is, naturally, greater than...
ColonBlow robot
The strategy focused on efficiently navigating complex terrain with superior speed. The objective was to score in the lowest scoring goal by acting quickly to limit the opposing team's points. The mechanical and electrical designs prioritized speed, resulting in an...
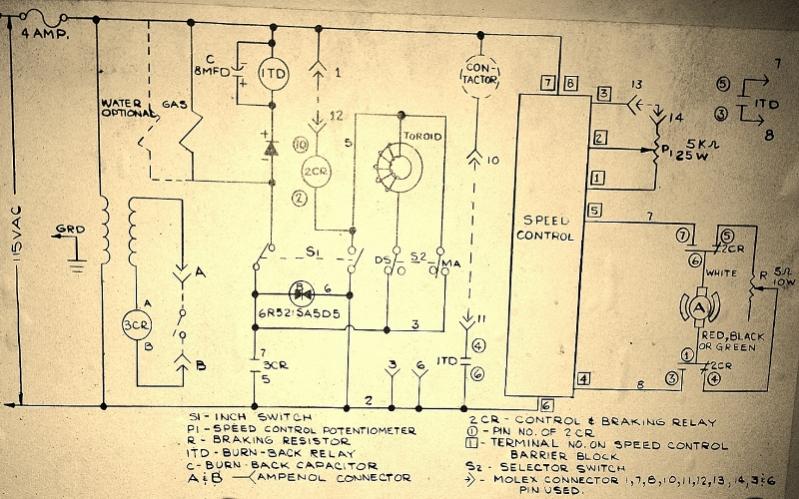
salvage dc motor speed control
A Chemetron wire feeder is being utilized, and there is a desire to use the speed control from the control box to regulate the motor it originally contained.
The Chemetron wire feeder is designed for efficient wire feeding in welding applications....
Various Schematics and Diagrams
This document contains a collection of various useful and interesting electronic schematics. Some of these schematics are referenced or included in other documents on this site. Notably absent from this collection is extremely important safety information, which can be found...
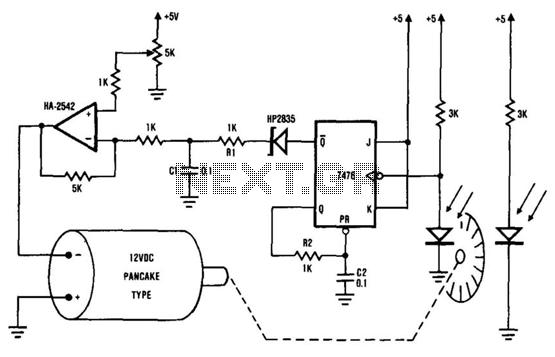
Dc Motor-Speed Control
The system comprises the HA-2542 operational amplifier, a compact 12 V DC motor, and a position encoder. During operation, the encoder generates a series of constant-width pulses that charge capacitor C1. These integrated pulses create a reference voltage proportional to...
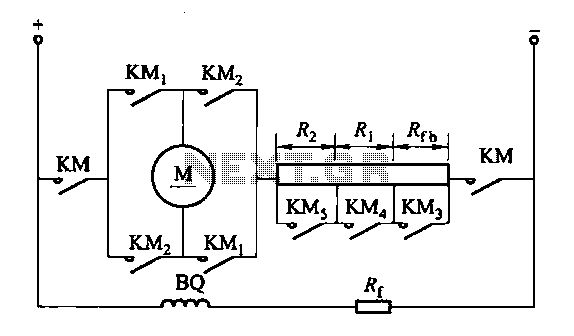
A DC motor reverse brake circuit
The circuit depicted in Figure 3-200 (a) illustrates the operation of a reverse braking system. When reverse braking is initiated, the forward contacts of contactor KMi open, and the reverse brake contactor KM3 disconnects while the reverse contactor KM2 contacts...
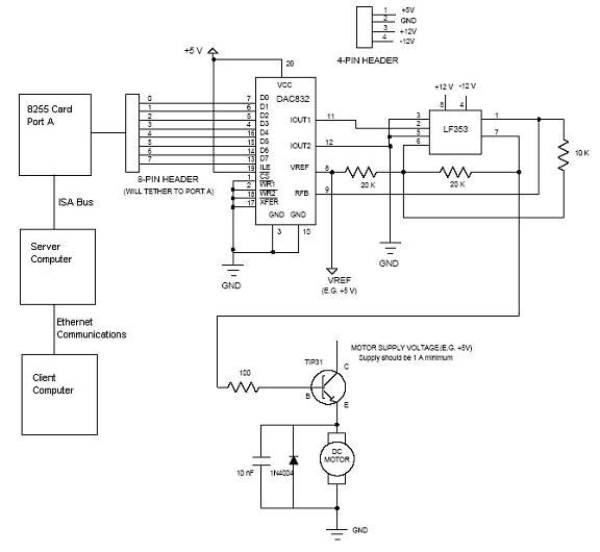
Open Loop Speed Control of a DC Motor via 8255 Controller
Open loop speed control of a DC motor is implemented using the 8255 Digital I/O Controller chip in conjunction with a TCP/IP server-client application programmed in Visual Basic. The DAC0832 chip serves as the Digital to Analog Converter. This project...
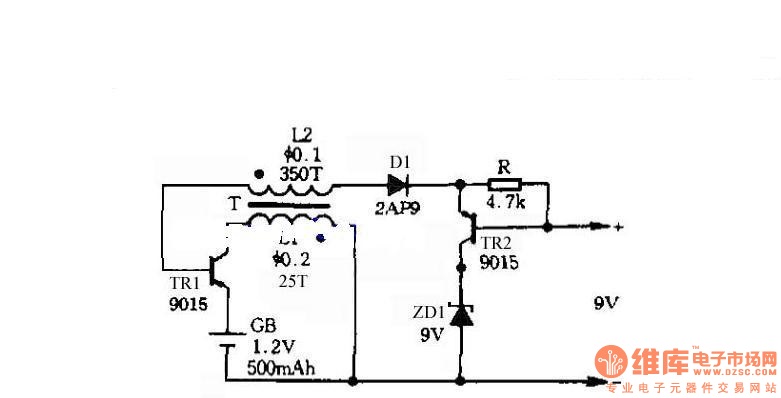
Self-control digital inverter power supply circuit diagram:1.2V rising to 9V
The circuit does not require a separate power switch or transformation to control the switches on the table. It offers advantages such as low power consumption, stability, reliability, and no impact on instrument accuracy. The transformer T in the circuit...
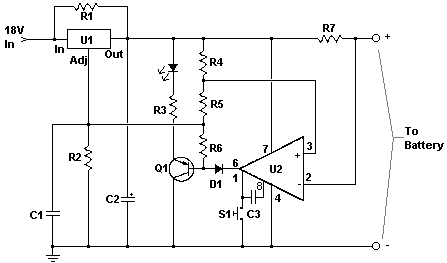
car battery charger circuit
The circuit is designed to be powered directly by a power supply, which is why it does not include a transformer, rectifier, or filter capacitors in the schematic. However, these components can be added if desired. To operate the circuit,...