


A DC motor reverse brake circuit
#DC motor
#reverse brake
#contactor
#motor control
#forward contacts
#reverse contacts
#brake circuit
#electrical circuit
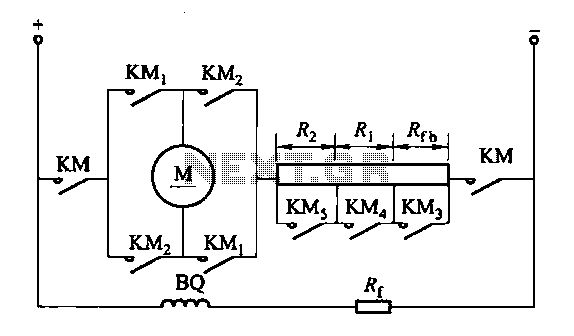
Description: The circuit depicted in Figure 3-200 (a) illustrates the operation of a reverse braking system. When reverse braking is initiated, the forward contacts of contactor KMi open, and the reverse brake contactor KM3 disconnects while the reverse contactor KM2 contacts remain closed. The configuration of the reverse relay KA is shown in Figure 3-200 (h). The reverse relay KA activates when reverse braking begins, connecting the braking resistor Rf to the armature circuit. As the motor speed approaches zero, the reverse braking resistor is shorted. The connection point for the KA relay coil is determined by a resistance value R. This point should equal the total resistance (Rq plus Rf) divided by two. The general pickup voltage setting for the KA relay is typically between 0.4 and 0.45 times the supply voltage (Ue).
The circuit operates by utilizing multiple contactors and relays to manage the reverse braking process efficiently. When the operator engages the reverse braking mechanism, the system ensures that the forward motion is halted by opening the KMi contacts, which prevents any forward current from reaching the motor. Simultaneously, the KM3 contactor is deactivated, effectively isolating the forward drive circuit. The reverse contactor KM2 remains closed, allowing for the necessary current flow to facilitate reverse braking.
The reverse relay KA plays a critical role in this system. It monitors the operational state of the motor and ensures that the braking resistor Rf is introduced into the armature circuit during reverse braking. This resistor serves to dissipate energy generated during the braking process, thus protecting the motor from potential damage due to excessive back EMF. Once the motor speed diminishes to nearly zero, the circuit short-circuits the braking resistor to optimize performance and efficiency, allowing the motor to transition smoothly to a standstill without unnecessary energy loss.
The design stipulates that the resistance value R at the connection point for the KA relay coil should be carefully calculated. This ensures that the total resistance (Rq plus Rf) is halved, providing the correct conditions for the relay to activate reliably. The pickup voltage for the KA relay is set within a range of 0.4 to 0.45 times the supply voltage (Ue), allowing for consistent and dependable operation under varying load conditions. This specification is crucial for ensuring that the relay engages at the appropriate moment during the reverse braking sequence, thereby enhancing the overall safety and effectiveness of the braking system.FIG circuit 3-200 (a) in Fig. When the reverse brake, forward contacts open contacts KMi, reverse brake contactor KM3 contact is disconnected, reverse contactor KM2 contacts ar e closed. Tuning reverse relay KA line shown in Figure 3-200 (h). By reverse relay KA, when the reverse brake open when beginning to reverse braking resistor Rf access armature circuit; and when the brake to the motor speed approaches zero, the reverse braking resistor temple shorted. A connection point KA relay coil by R: resistance value is determined. A point should be the total resistance (Rq ten Rf) at half. KA relay pickup voltage setting in general (0. 4 ~ 0. 45) Ue.
The circuit operates by utilizing multiple contactors and relays to manage the reverse braking process efficiently. When the operator engages the reverse braking mechanism, the system ensures that the forward motion is halted by opening the KMi contacts, which prevents any forward current from reaching the motor. Simultaneously, the KM3 contactor is deactivated, effectively isolating the forward drive circuit. The reverse contactor KM2 remains closed, allowing for the necessary current flow to facilitate reverse braking.
The reverse relay KA plays a critical role in this system. It monitors the operational state of the motor and ensures that the braking resistor Rf is introduced into the armature circuit during reverse braking. This resistor serves to dissipate energy generated during the braking process, thus protecting the motor from potential damage due to excessive back EMF. Once the motor speed diminishes to nearly zero, the circuit short-circuits the braking resistor to optimize performance and efficiency, allowing the motor to transition smoothly to a standstill without unnecessary energy loss.
The design stipulates that the resistance value R at the connection point for the KA relay coil should be carefully calculated. This ensures that the total resistance (Rq plus Rf) is halved, providing the correct conditions for the relay to activate reliably. The pickup voltage for the KA relay is set within a range of 0.4 to 0.45 times the supply voltage (Ue), allowing for consistent and dependable operation under varying load conditions. This specification is crucial for ensuring that the relay engages at the appropriate moment during the reverse braking sequence, thereby enhancing the overall safety and effectiveness of the braking system.FIG circuit 3-200 (a) in Fig. When the reverse brake, forward contacts open contacts KMi, reverse brake contactor KM3 contact is disconnected, reverse contactor KM2 contacts ar e closed. Tuning reverse relay KA line shown in Figure 3-200 (h). By reverse relay KA, when the reverse brake open when beginning to reverse braking resistor Rf access armature circuit; and when the brake to the motor speed approaches zero, the reverse braking resistor temple shorted. A connection point KA relay coil by R: resistance value is determined. A point should be the total resistance (Rq ten Rf) at half. KA relay pickup voltage setting in general (0. 4 ~ 0. 45) Ue.
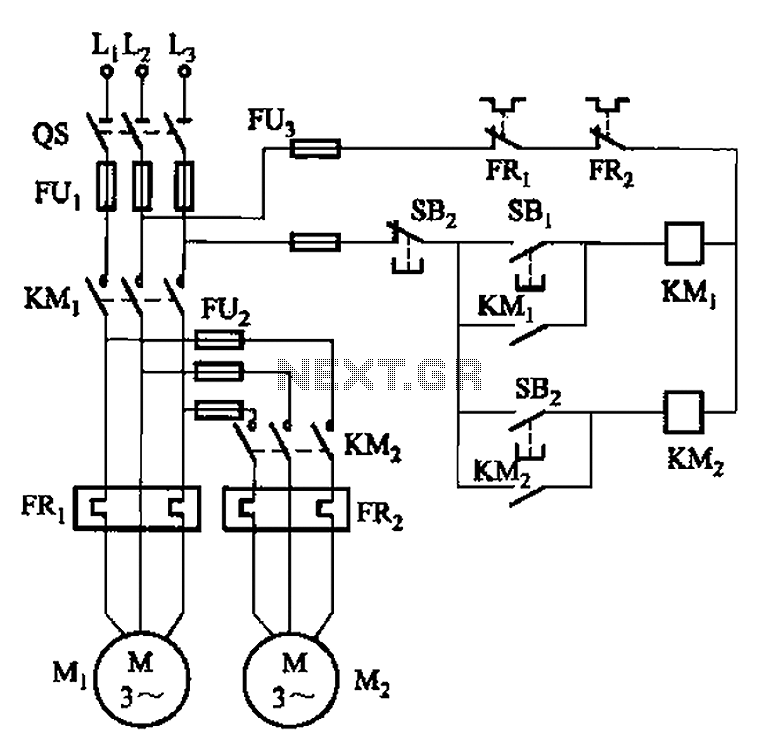
The main circuit in order to start the control circuit
The circuit illustrated in Figure 3-83 demonstrates that the contactor KMi is activated only after it is pulled, which indicates that the motor Mi has started for the first time. Following this, the contactor KM2 is then activated, indicating that...
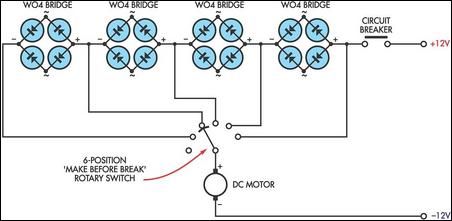
DC Motor Speed Controller
This circuit utilizes the voltage drop across bridge rectifier diodes to create a 5-position variable voltage supply for a DC fan or other small DC motors. While it is not as efficient as a switch-mode circuit, it offers advantages such...
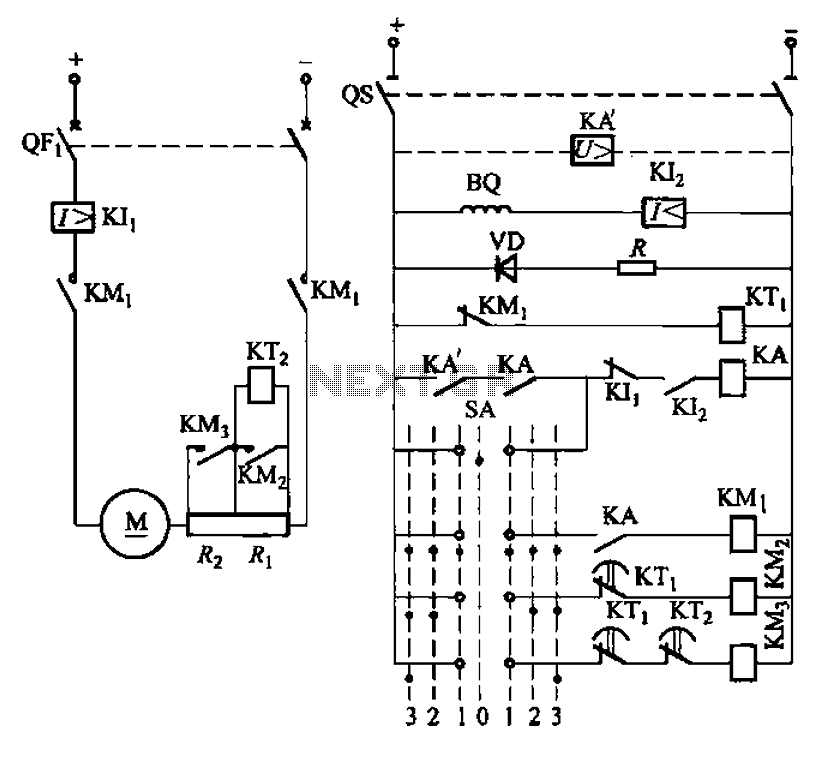
One of debug circuitry DC motor armature resistance in series starting
The circuit depicted in Figure 3-190 includes an armature circuit with two startup resistors, Ri and Rz, connected in series through the main switch SA to facilitate starting, stopping, and speed control. During the startup phase, two relays, KTi and...
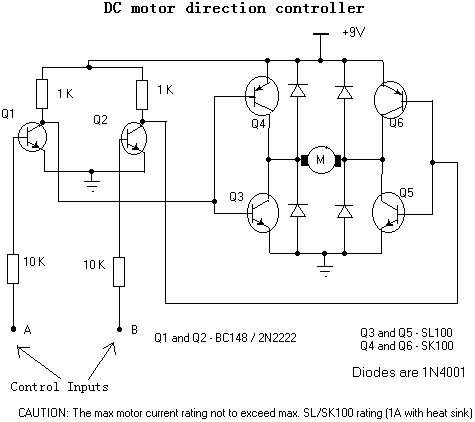
DC Motor Direction Controller
For controlling a small DC motor, such as the one found in a tape recorder, Q1 and Q2 are in saturation when both points A and B are HIGH. Component: ..
To control a small DC motor effectively, a circuit utilizing...
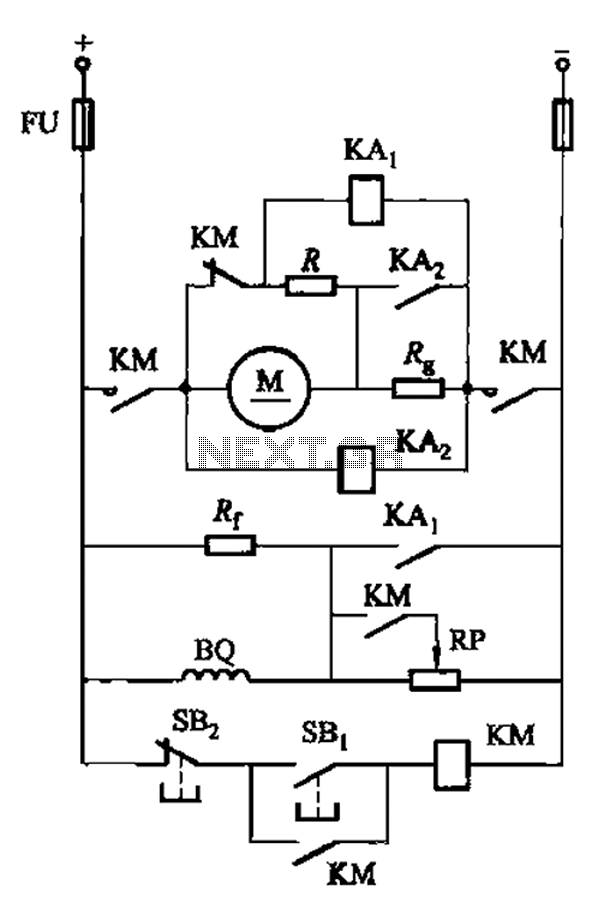
DC motor armature series resistance start dynamic braking circuit of the two-way operation
The circuit illustrated in Figure 3-197 features a dish adjust rheostat (RP) that allows for the adjustment of field current, which in turn modifies the motor speed.
The circuit operates by utilizing a rheostat, which is a variable resistor that can...
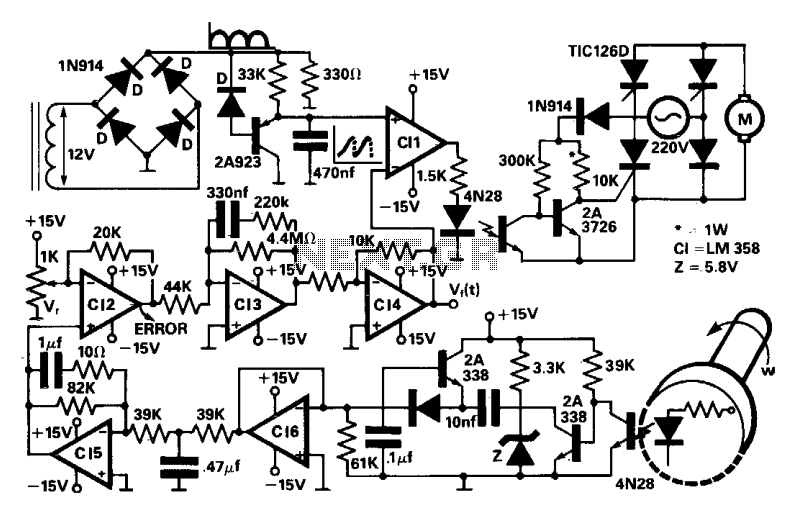
Speed regulator for dc motors
A four thyristor controlled bridge is utilized for operation in two quadrants of the torque-speed characteristics. In the trigger circuits, conventional pulse transformers are substituted with self-biased circuits, which reduce gate power consumption and enhance noise immunity. Electrical isolation is...
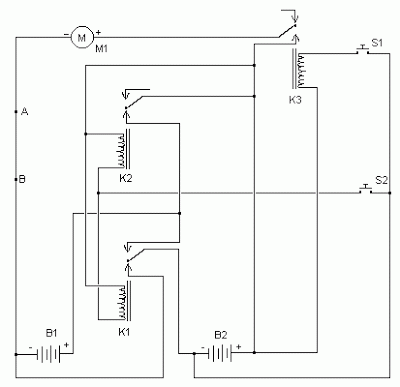
two speed contactor dc motor controller
The simplest form of motor controllers, apart from a basic on/off switch, is the contactor controller. This contactor controller is recommended for use in electric scooter projects. It is based on three 12V relays, two 12V batteries, two switches, and...
Four reverse brake circuits to operate energy
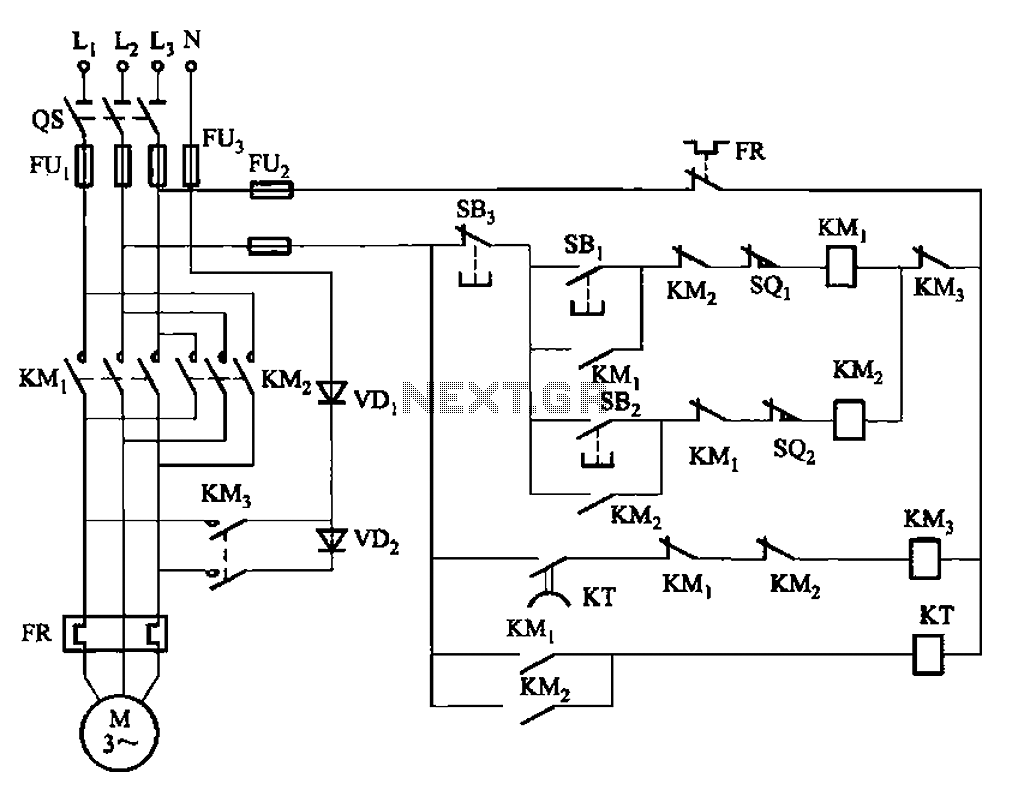
The circuit depicted in Figure 3-147 utilizes a time relay (KT) adjustable between 1 to 2 seconds to ensure adequate braking time. The relay addresses instances where the actual brake stop time may be insufficient. Additionally, SQ1 and SQ2 serve...
DC Motor-Driver H-Bridge Circuit
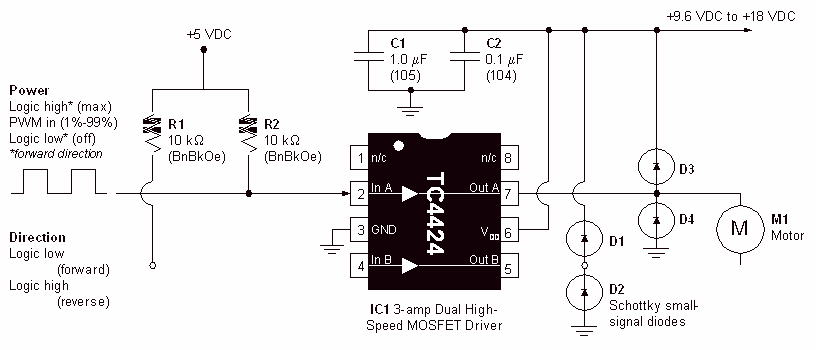
Physical motion of some form helps differentiate a robot from a computer. It would be nice if a motor could be attached directly to a chip that controlled the movement. But, most chips can't pass enough current or voltage to...