


ColonBlow robot
Description: The strategy focused on efficiently navigating complex terrain with superior speed. The objective was to score in the lowest scoring goal by acting quickly to limit the opposing team's points. The mechanical and electrical designs prioritized speed, resulting in an autonomous robot that collected balls, held them, and released them into goal #1. A piece of foam core was positioned at the front to activate the ball request button. Balls dropped from a dispenser were funneled into a hole leading to a PVC pipe, where a door motor functioned as an electro-mechanical switch to retain the balls. The chassis comprised a ¼-inch thick laser-cut acrylic piece (10 x 3 inches) and a 1/8-inch thick laser-cut masonite piece (10 x 10 inches with fillets). The acrylic piece was positioned two inches from the front edge of the masonite, allowing the drive wheels to be closer to the front for better maneuverability. Two spherical caster wheels were placed at the back, spaced 4.67 inches apart for stability without hindering speed. Three QRB1134 reflective object sensors were installed to detect tape on the playing field, positioned 0.5625 inches apart. The middle sensor was designed to activate while the robot traveled in a straight line. Additional QRB1134 sensors were positioned at each corner for robustness against walls, with L-shaped holes in the chassis for adjustable mounting. The funnel, made from foam core, directed balls into the PVC pipe, with a hole slightly larger than the ball’s diameter to avoid jams. Electrical tape was used to attach the funnel for easy adjustments. The PVC pipe could hold five to six balls, and a door motor above a drilled hole enabled ball release. Two identical masonite pieces elevated the motor, and multiple holes were laser-cut for circuit and microcontroller mounting.
The autonomous robot design emphasizes a streamlined approach to ball collection and goal scoring. The choice of materials, such as laser-cut acrylic and masonite, provides a lightweight yet sturdy framework, optimizing the robot’s overall performance. The integration of a foam core funnel serves to guide the balls effectively, minimizing the risk of jams during collection. The use of a door motor as an electro-mechanical switch enhances the control over the ball release mechanism, ensuring that balls are only released at the appropriate times.
The chassis design, featuring strategically placed caster wheels and a low center of gravity, contributes to stability during movement, allowing the robot to navigate quickly across the playing field. The placement of reflective object sensors is critical for maintaining alignment with the tape markings, facilitating precise movement and enhancing the robot's ability to follow predetermined paths. The adjustable mounting for these sensors allows for fine-tuning during testing phases, ensuring optimal performance.
Incorporating a microcontroller board and well-defined circuit paths ensures that the robot can process sensor inputs and control motors effectively, enabling real-time adjustments based on environmental feedback. Overall, the design prioritizes efficiency, speed, and adaptability, making it well-suited for competitive scenarios where quick decision-making and rapid execution are essential. The combination of mechanical ingenuity and electrical design creates a robust autonomous system capable of achieving its objectives while minimizing potential errors during operation.Our strategy was based on our ability to traverse complex, tape ridden terrain in the most efficient way possible: with superior speed. Even though we only went for goal #1, which was the lowest scoring goal, by acting quickly and finishing the game early, we hoped to limit the other team`s points.
Our mechanical and electrical designs were cen tered around our need for speed. We designed an autonomous robot that implemented a simple strategy to collect balls, hold them, and release them into goal #1. To collect balls, we placed a piece of foam core in the front of our robot to depress the ball request button.
As each ball dropped from the dispenser onto our robot, a funnel-like device channeled the balls into a hole, which led to a PVC pipe with a door motor acting as an electro-mechanical switch to prevent balls from leaving our robot. Our robot`s chassis consisted of a -thick piece of laser-cut acrylic (10 x 3 ) and a 1/8 -thick piece of laser-cut masonite (10 x 10 with fillets).
We placed the front edge of the acrylic piece two inches from the front edge of the masonite, which was also the front edge of our robot. This decision was based on our desire to place the drive wheels closer to the front of our robot rather than in the middle.
To provide our robot excellent stability while driving, we placed two spherical caster wheels at the back side of our robot. We placed these two casters 4. 67 apart center-to-center, which was long enough for stability, yet not significantly long to prevent our robot from moving too slowly at a given duty cycle.
To track the various pieces of tape on the playing fields, we implemented a set of three QRB1134 reflective object sensors. Each adjacent pair of tape sensors was placed 0. 5625 apart center-to-center based on this measurement of the tape`s width. We desired to have only the middle tape sensor activated while traveling in a perfectly-straight line.
To provide our robot a precisely-manufactured part on which to mount our tape sensors, we used a 1/8 -thick laser-cut piece of masonite. To provide our robot greater robustness in dealing with the possibility of encountering the playing fields` walls, we implemented four QRB1134 reflective object sensors, one at each corner of our robot.
To allow for tweaking the direction and location of these proximity sensors, we designed our masonite chassis to have L-shaped holes at each of the four corners, with the width and/or diameter of these holes slightly larger than the width/diameter of the tape sensor slots (about 0. 15 ). As each ball dropped from the ball dispenser onto our robot, it fell onto a funnel made from foam-core.
The funnel was sloped in two different directions to prevent balls from getting stuck en route to our PVC pipe and ball release mechanism. We cut a hole at the nadir of our funnel with a diameter slightly larger than the ball`s diameter of 1.
75 . To attach the funnel to our robot, we used some electrical tape instead of hot glue to allow us the ability to tweak various components inside our robot. We collected five balls at each trip to the ball dispenser because our PVC pipe could hold five to six balls without the possibility of balls getting stuck in the hole of our funnel.
To provide an electro-mechanical ball release mechanism, we drilled a hole on the top surface of the PVC pipe near the end of the pipe. A door motor was placed directly above this hole, which opened for releasing balls and closed for preventing balls from leaving our robot at inappropriate times.
To elevate the door motor above the PVC pipe, we designed two identical 1/8 -thick pieces of masonite with slots for the door motor`s mounting holes and placed this on both sides of the PVC pipe. To adequately incorporate our electrical circuits and E128 microcontroller board, we laser-cut several sets of four holes through which we mounted various circuits.
In addition, a
The autonomous robot design emphasizes a streamlined approach to ball collection and goal scoring. The choice of materials, such as laser-cut acrylic and masonite, provides a lightweight yet sturdy framework, optimizing the robot’s overall performance. The integration of a foam core funnel serves to guide the balls effectively, minimizing the risk of jams during collection. The use of a door motor as an electro-mechanical switch enhances the control over the ball release mechanism, ensuring that balls are only released at the appropriate times.
The chassis design, featuring strategically placed caster wheels and a low center of gravity, contributes to stability during movement, allowing the robot to navigate quickly across the playing field. The placement of reflective object sensors is critical for maintaining alignment with the tape markings, facilitating precise movement and enhancing the robot's ability to follow predetermined paths. The adjustable mounting for these sensors allows for fine-tuning during testing phases, ensuring optimal performance.
Incorporating a microcontroller board and well-defined circuit paths ensures that the robot can process sensor inputs and control motors effectively, enabling real-time adjustments based on environmental feedback. Overall, the design prioritizes efficiency, speed, and adaptability, making it well-suited for competitive scenarios where quick decision-making and rapid execution are essential. The combination of mechanical ingenuity and electrical design creates a robust autonomous system capable of achieving its objectives while minimizing potential errors during operation.Our strategy was based on our ability to traverse complex, tape ridden terrain in the most efficient way possible: with superior speed. Even though we only went for goal #1, which was the lowest scoring goal, by acting quickly and finishing the game early, we hoped to limit the other team`s points.
Our mechanical and electrical designs were cen tered around our need for speed. We designed an autonomous robot that implemented a simple strategy to collect balls, hold them, and release them into goal #1. To collect balls, we placed a piece of foam core in the front of our robot to depress the ball request button.
As each ball dropped from the dispenser onto our robot, a funnel-like device channeled the balls into a hole, which led to a PVC pipe with a door motor acting as an electro-mechanical switch to prevent balls from leaving our robot. Our robot`s chassis consisted of a -thick piece of laser-cut acrylic (10 x 3 ) and a 1/8 -thick piece of laser-cut masonite (10 x 10 with fillets).
We placed the front edge of the acrylic piece two inches from the front edge of the masonite, which was also the front edge of our robot. This decision was based on our desire to place the drive wheels closer to the front of our robot rather than in the middle.
To provide our robot excellent stability while driving, we placed two spherical caster wheels at the back side of our robot. We placed these two casters 4. 67 apart center-to-center, which was long enough for stability, yet not significantly long to prevent our robot from moving too slowly at a given duty cycle.
To track the various pieces of tape on the playing fields, we implemented a set of three QRB1134 reflective object sensors. Each adjacent pair of tape sensors was placed 0. 5625 apart center-to-center based on this measurement of the tape`s width. We desired to have only the middle tape sensor activated while traveling in a perfectly-straight line.
To provide our robot a precisely-manufactured part on which to mount our tape sensors, we used a 1/8 -thick laser-cut piece of masonite. To provide our robot greater robustness in dealing with the possibility of encountering the playing fields` walls, we implemented four QRB1134 reflective object sensors, one at each corner of our robot.
To allow for tweaking the direction and location of these proximity sensors, we designed our masonite chassis to have L-shaped holes at each of the four corners, with the width and/or diameter of these holes slightly larger than the width/diameter of the tape sensor slots (about 0. 15 ). As each ball dropped from the ball dispenser onto our robot, it fell onto a funnel made from foam-core.
The funnel was sloped in two different directions to prevent balls from getting stuck en route to our PVC pipe and ball release mechanism. We cut a hole at the nadir of our funnel with a diameter slightly larger than the ball`s diameter of 1.
75 . To attach the funnel to our robot, we used some electrical tape instead of hot glue to allow us the ability to tweak various components inside our robot. We collected five balls at each trip to the ball dispenser because our PVC pipe could hold five to six balls without the possibility of balls getting stuck in the hole of our funnel.
To provide an electro-mechanical ball release mechanism, we drilled a hole on the top surface of the PVC pipe near the end of the pipe. A door motor was placed directly above this hole, which opened for releasing balls and closed for preventing balls from leaving our robot at inappropriate times.
To elevate the door motor above the PVC pipe, we designed two identical 1/8 -thick pieces of masonite with slots for the door motor`s mounting holes and placed this on both sides of the PVC pipe. To adequately incorporate our electrical circuits and E128 microcontroller board, we laser-cut several sets of four holes through which we mounted various circuits.
In addition, a
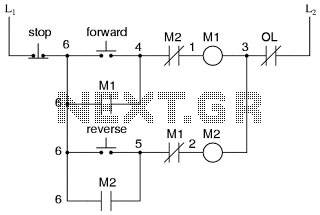
Motor control circuit for forward and reverse phase induction
This is the power diagram for motor forward and reverse operation. To change the motor direction, one polarity must be altered, for example, changing R to S. For detailed information, please refer to the following.
The described power diagram illustrates a...
Gray Projects
After learning to operate the device, it became evident that inertia posed a significant challenge. The constructed system is notably heavy, making it difficult to initiate motor operation at full speed. Despite having some understanding of physics, practical experience is...
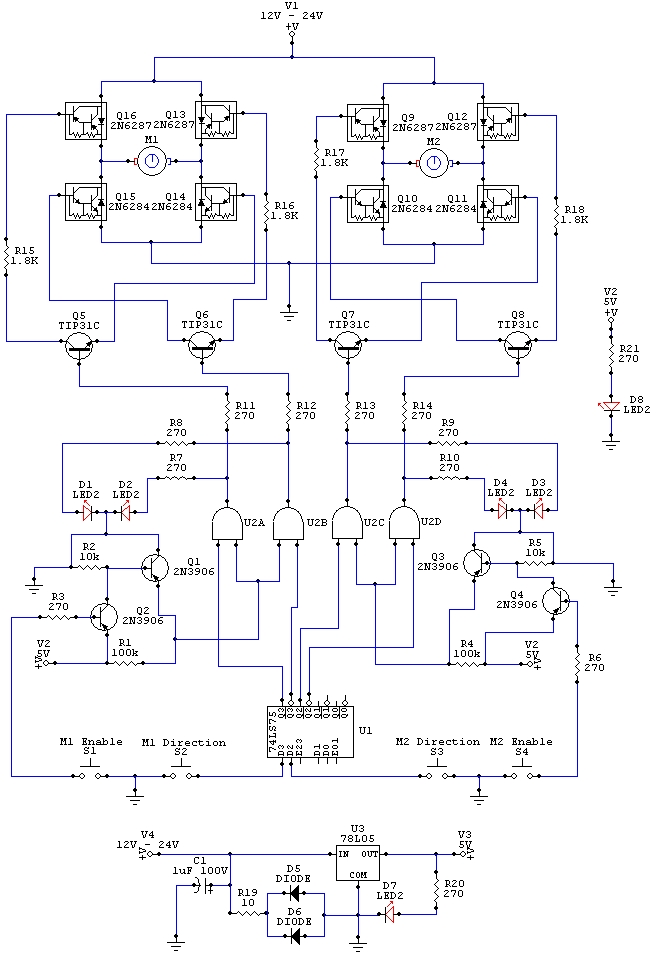
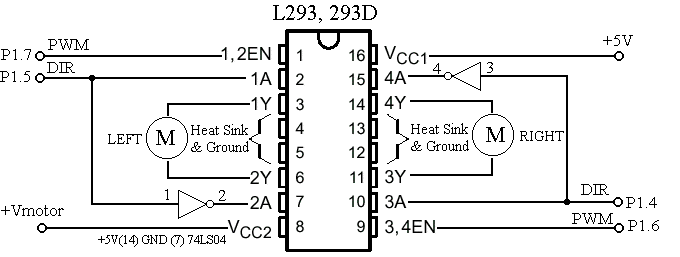
Electronic robot wiring schematic
The wiring schematic played a significant role in the robot. This diagram is used to graphically display all the wiring of the motor-controlling micro-components that enabled the robot to physically move forward, backward, left, right, and stop. This diagram was...
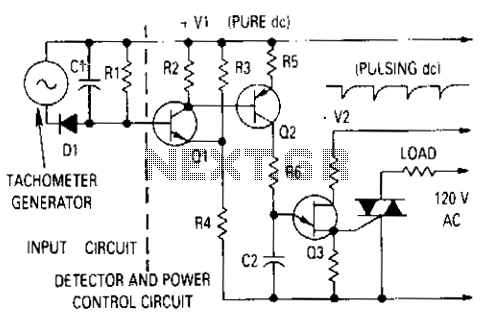
Motor control with tachometer
The generator output is rectified, filtered, and applied between the positive supply voltage and the base of the detector transistor. This configuration provides a negative voltage that reduces the base voltage as the speed increases. During normal operation, if the...
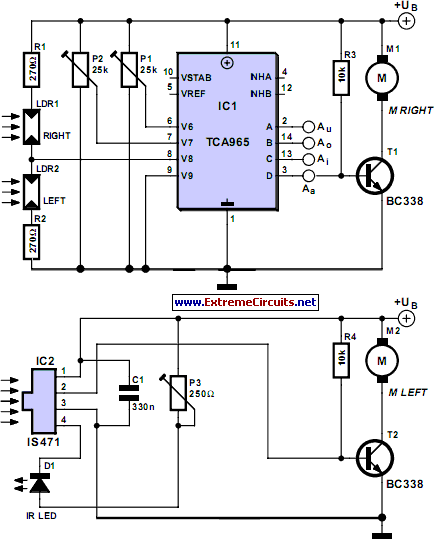
Discrete Robot
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The only specialized component in the circuit is a window discriminator, which functions as a window comparator. Resistors R1 and R2, in...
de amst wiskar: robot line folower
One of the students has created a robot that utilizes two stepper motors and a simple IR sensor. The robot, which is depicted in the accompanying image, has some issues such as a lack of battery support and misalignment of...
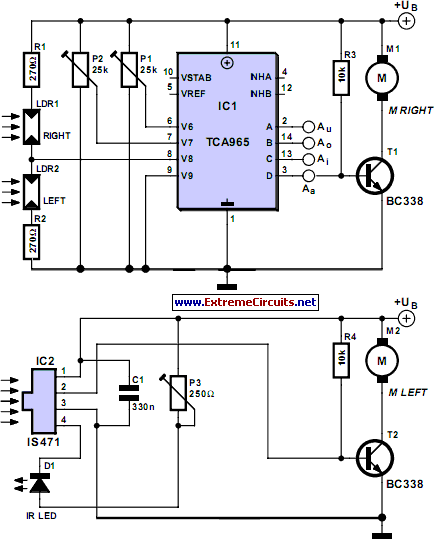
discrete robot schematics
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The primary component in the circuit is a window discriminator, which functions as an advanced window comparator. Resistors R1 and R2, in...
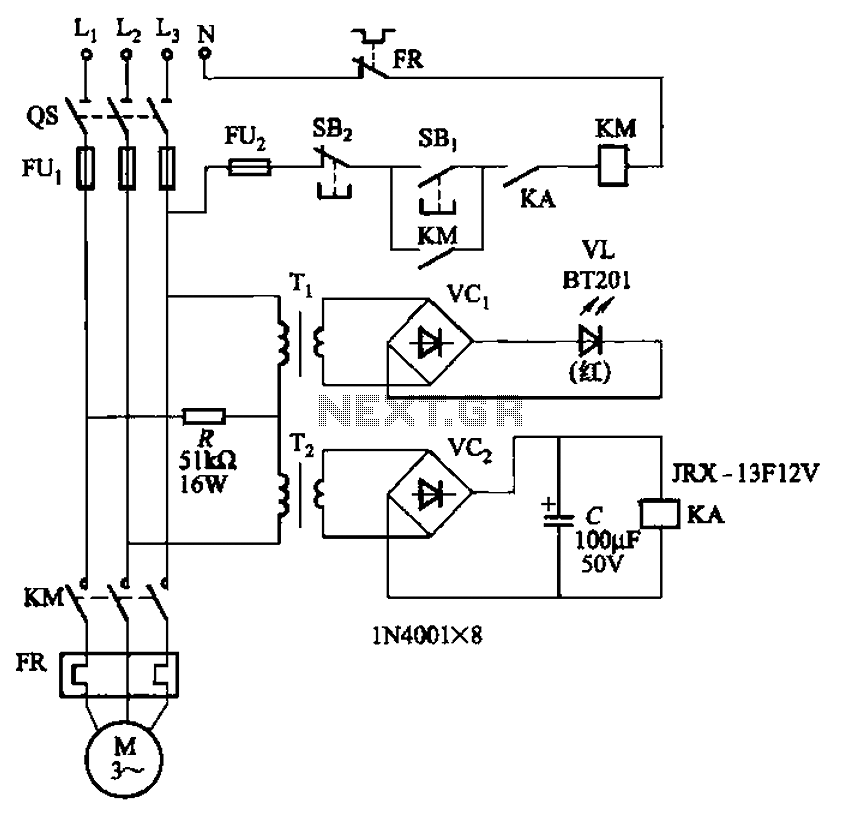
Allowing only one-way operation of the motor-controlled circuit 2
The circuit depicted in Figure 3-92 employs a dual-phase sequence protection relay for sensing. When the power supply exhibits a positive phase sequence (U, V, W), the relay KA is activated. If the power supply maintains the correct phase sequence,...
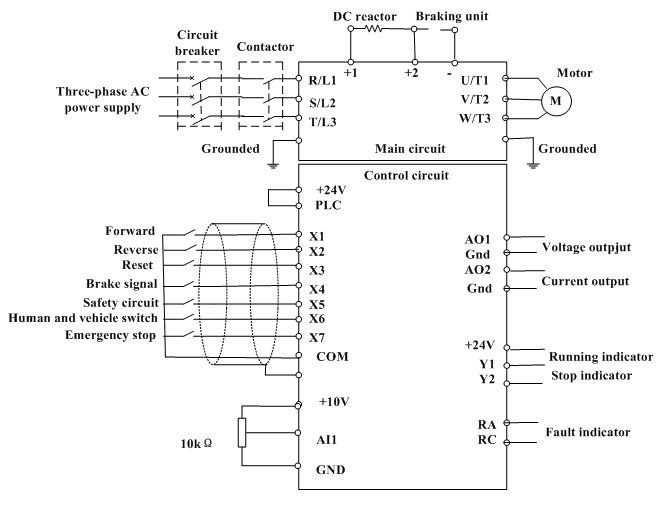
motor control inverter (AC drive) in mine industry
Motor control, energy efficiency of inverter (AC drive) selection, and parameters setting guidance in the mining industry: vector control, open loop or closed loop control, with energy braking unit or energy feedback unit.
In the context of motor control for the...