


Map Bot
#robot
#mapping
#navigation
#diagnostic software
#house mapping
#automation
#sensors
#arduino
#motor control
#home automation
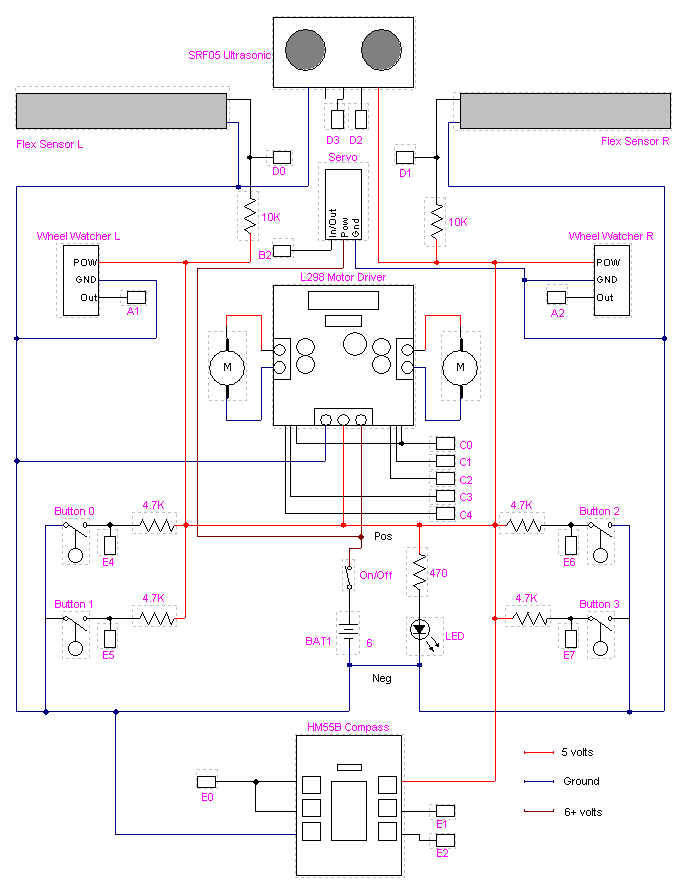
Description: The purpose of this robot is to navigate and map a single floor of a house, using the created map to intelligently traverse the area. Diagnostic software has been developed to verify that all subsystems of the robot are functioning correctly. Once the mapping software is completed, updates will be provided. This project represents a significant advancement compared to the previous Light Bot. Extensive research has been conducted on various sensors and subsystems for this robot, with links to the components available in the materials list. The connections between these subsystems are detailed in the circuit diagram.
The robot's design incorporates a range of sensors and subsystems that work in unison to achieve effective mapping and navigation. Key components likely include ultrasonic distance sensors for obstacle detection, a gyroscope for orientation, and encoders on the wheels to track movement accurately. The robot may utilize a microcontroller, such as an Arduino or Raspberry Pi, as the central processing unit, managing data from the sensors and executing the mapping algorithms.
The mapping process begins with the robot moving systematically across the floor, taking distance measurements at regular intervals. The ultrasonic sensors emit sound waves and measure the time it takes for the echoes to return, allowing the robot to detect walls and obstacles. This data is processed to create a two-dimensional map of the environment. The gyroscope provides orientation data, ensuring that the robot maintains a consistent heading while traversing.
The integration of the components is crucial for the robot's functionality. Power distribution must be carefully managed to ensure that all sensors and the microcontroller receive adequate voltage and current. The circuit diagram illustrates the connections between the microcontroller, sensors, and motors, detailing how signals are routed and processed. Additionally, it may include power management components such as voltage regulators and capacitors to smooth out fluctuations in power supply.
Once the mapping is complete, the robot can utilize algorithms such as SLAM (Simultaneous Localization and Mapping) to navigate the environment intelligently. This involves continuously updating its map and position as it moves, allowing for dynamic adjustments in its path based on real-time data. The combination of software and hardware in this robot represents a sophisticated approach to autonomous navigation and environmental mapping.The purpose of this robot is have a bot that can go around and map out a single floor of my house and then use that map to intelligently traverse the mapped area. So far I`ve only written some diagnostic software to verify all the subsystems of this robot are functioning properly.
Once I`ve gotten the software to do this mapping written, I`ll upda te this page. This is a huge step up in comparison to my previous Light Bot. I`ve spent months researching various sensors and sub-systems for this robot. You can see in the materials lists all the links to these components. I`m not going to go over how I connected all these sub-systems together because that is all laid out for you in the circuit diagram.
The robot's design incorporates a range of sensors and subsystems that work in unison to achieve effective mapping and navigation. Key components likely include ultrasonic distance sensors for obstacle detection, a gyroscope for orientation, and encoders on the wheels to track movement accurately. The robot may utilize a microcontroller, such as an Arduino or Raspberry Pi, as the central processing unit, managing data from the sensors and executing the mapping algorithms.
The mapping process begins with the robot moving systematically across the floor, taking distance measurements at regular intervals. The ultrasonic sensors emit sound waves and measure the time it takes for the echoes to return, allowing the robot to detect walls and obstacles. This data is processed to create a two-dimensional map of the environment. The gyroscope provides orientation data, ensuring that the robot maintains a consistent heading while traversing.
The integration of the components is crucial for the robot's functionality. Power distribution must be carefully managed to ensure that all sensors and the microcontroller receive adequate voltage and current. The circuit diagram illustrates the connections between the microcontroller, sensors, and motors, detailing how signals are routed and processed. Additionally, it may include power management components such as voltage regulators and capacitors to smooth out fluctuations in power supply.
Once the mapping is complete, the robot can utilize algorithms such as SLAM (Simultaneous Localization and Mapping) to navigate the environment intelligently. This involves continuously updating its map and position as it moves, allowing for dynamic adjustments in its path based on real-time data. The combination of software and hardware in this robot represents a sophisticated approach to autonomous navigation and environmental mapping.The purpose of this robot is have a bot that can go around and map out a single floor of my house and then use that map to intelligently traverse the mapped area. So far I`ve only written some diagnostic software to verify all the subsystems of this robot are functioning properly.
Once I`ve gotten the software to do this mapping written, I`ll upda te this page. This is a huge step up in comparison to my previous Light Bot. I`ve spent months researching various sensors and sub-systems for this robot. You can see in the materials lists all the links to these components. I`m not going to go over how I connected all these sub-systems together because that is all laid out for you in the circuit diagram.
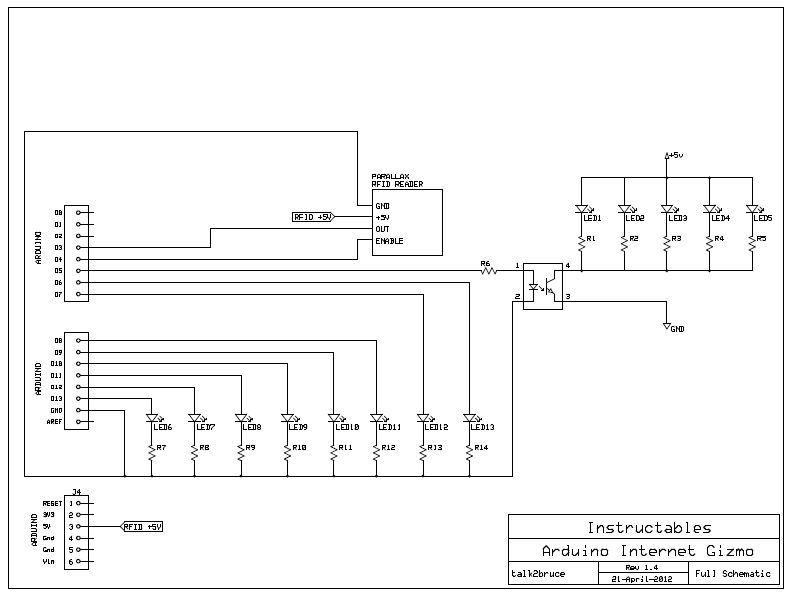
The Arduino Internet Gizmo
The Arduino Internet Gizmo is a USB, Arduino, and RFID device designed for web browsing. It operates by placing an RFID tag on the device, which reads the tag and transmits the tag number via USB to a program running...
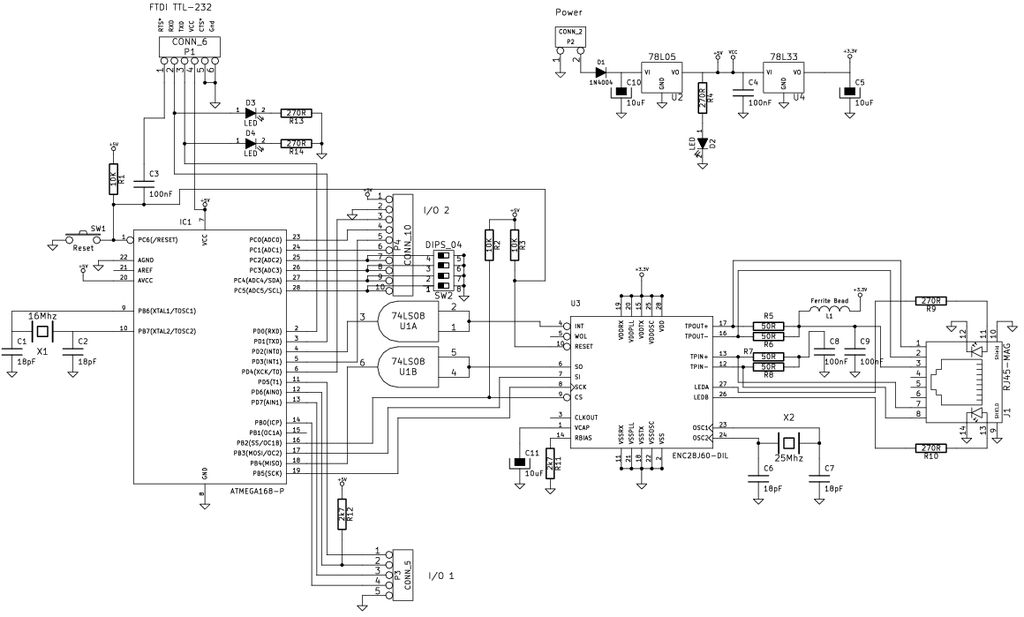
credit card sized Ethernet Arduino compatable controller board
The Arduino is a simple and accessible controller platform suitable for various projects. A few months ago, an Ethernet shield was purchased for it.
The Arduino platform is widely recognized for its user-friendly interface and versatility, making it a popular choice...
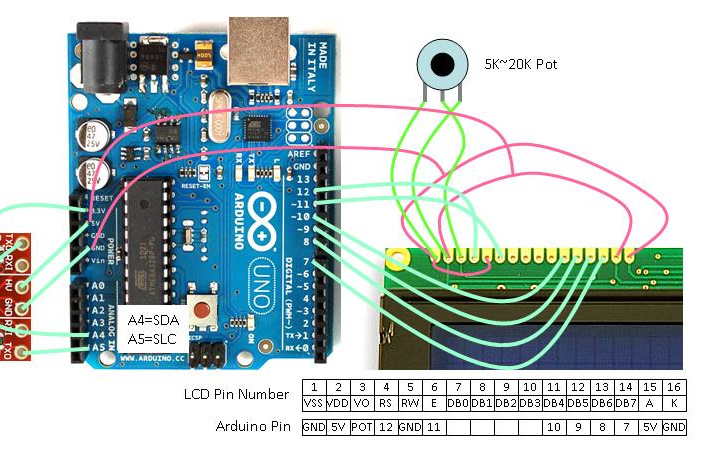
arduino code for buffalo ii dac lcd connection
For an effective tutorial on connecting a standard LCD to an Arduino and utilizing the standard LCD library, refer to the LadyAda Tutorial on LCDs. The diagram illustrates the fundamental connections with a standard LCD that is compatible with the...
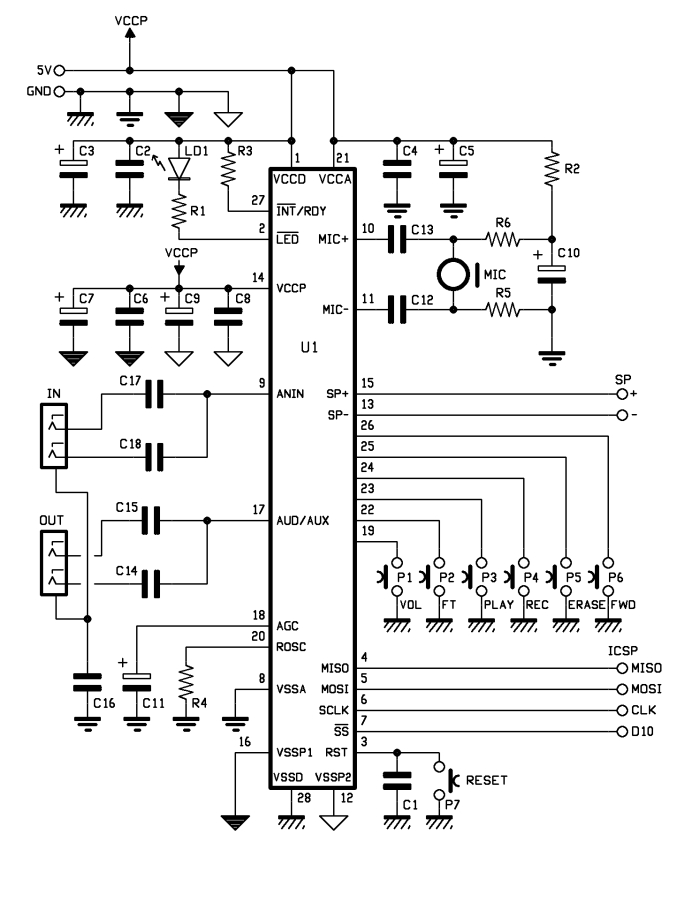
Voice Shield for Arduino
The aim of this project is to create an Arduino voice shield that facilitates numerous voice-related applications, primarily utilizing an integrated ISD1790PY chip. This voice and text-to-speech (TTS) functionality can be beneficial for integrating voice messages into alarm systems, implementing...
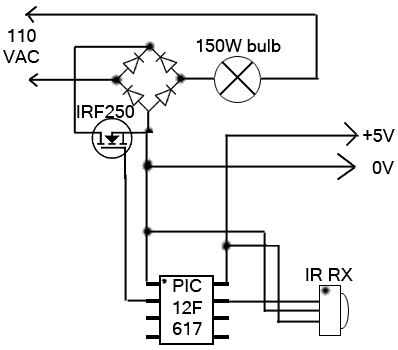
AC Arduino dimming circuit
This circuit is designed for dimming devices powered by transformer-based power supplies, specifically those operating at 12, 24, or 48 volts, rather than standard 120 volts. The project involves various components, including a soldering iron, wire strippers, breadboard or perf...
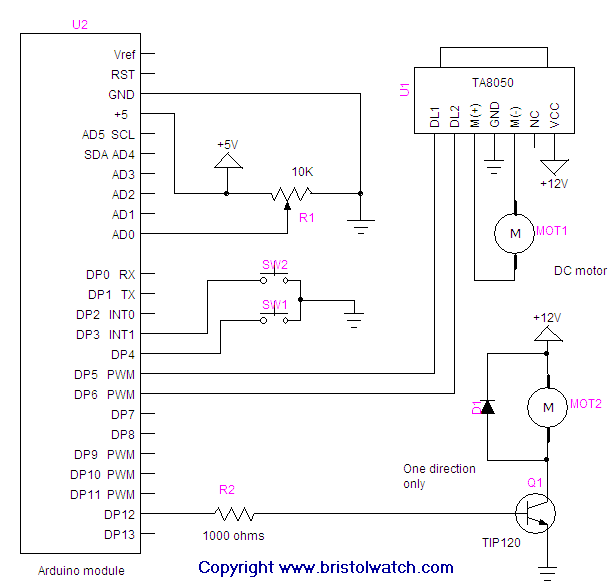
arduino pwm hb
Connecting and programming the TA8050 DC motor controller with the Arduino microcontroller.
The TA8050 is a versatile DC motor controller designed for use with microcontrollers, such as the Arduino. This controller allows for precise control of DC motors, making it suitable...
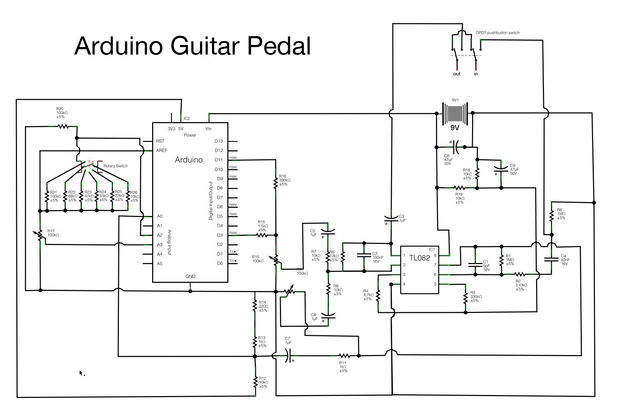
Arduino Guitar Pedal
Begin constructing the circuit as illustrated in the schematic. To view the schematic in a larger format, click the small "i" icon located in the upper right corner of the image.
The schematic serves as a visual representation of the circuit...
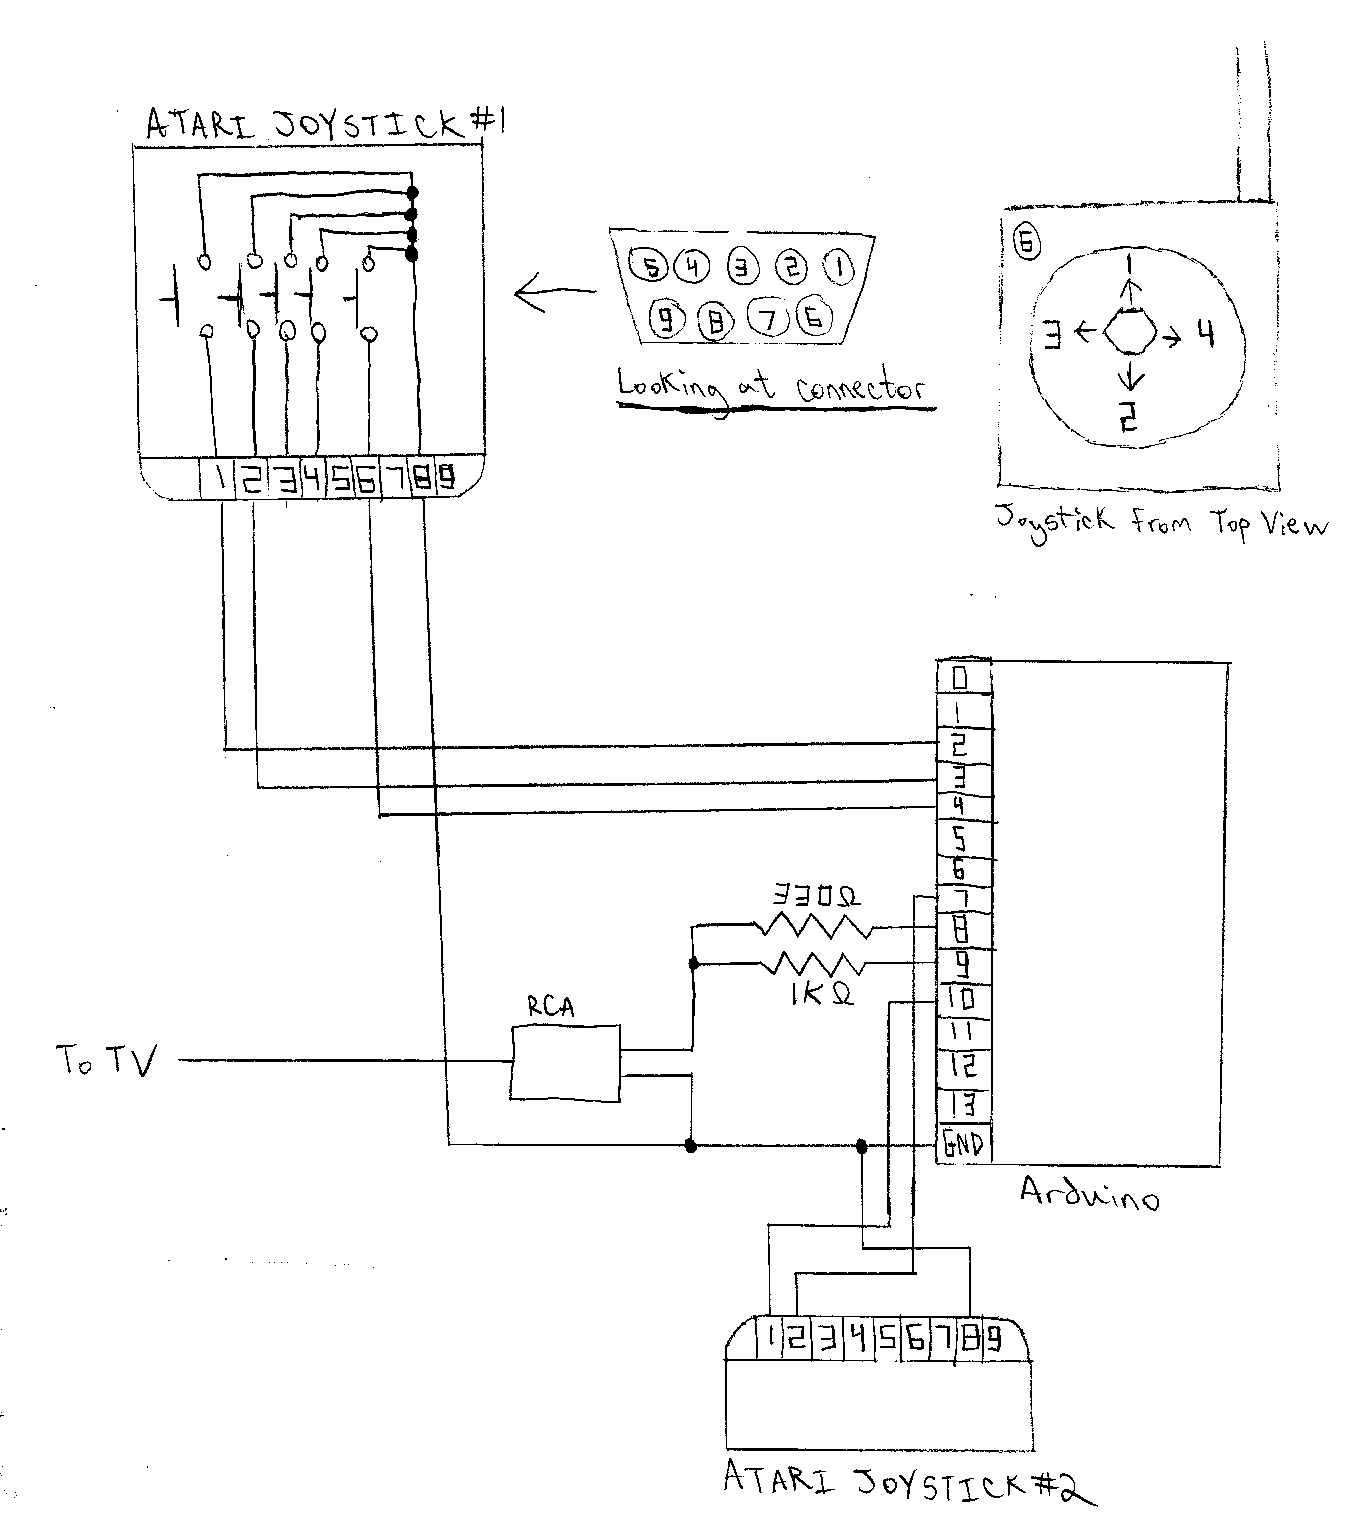
Pong Game Console
A simple game console was created to play Pong and other games using Atari 2600 joysticks. The Arduino processes joystick inputs and outputs the data to a TV using the TVout library. The project was designed to demonstrate that anyone...
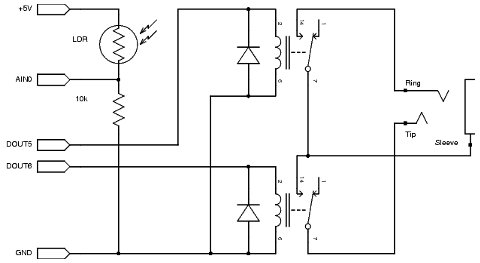
Arduino GH-2 integration for time lapse
A straightforward project involves using an Arduino to rotate a GH-2 camera on a fluid head by specified degrees to capture 360-degree panoramas. The motor control is uncomplicated, and there is a wealth of DIY motor projects available. Assistance is...