


Robot Autonomous Sensor Platform
#robot
#autonomous
#PICAXE
#sensors
#microcontroller
#obstacle avoidance
#motor control
#educational
#DIY
#electronics
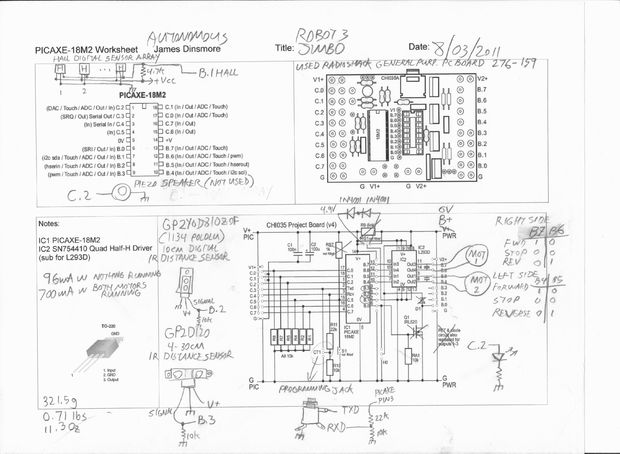
Description: This is an autonomous robot designed to explore the interfacing of various sensors with a PICAXE processor. Its mission is to search for a magnet.
The autonomous robot operates based on a microcontroller architecture centered around the PICAXE processor, which is well-suited for educational and experimental robotic applications. The robot is equipped with an array of sensors that facilitate its navigational and operational capabilities. These sensors may include ultrasonic distance sensors for obstacle detection, infrared sensors for line following, and magnetic sensors for detecting the presence of a magnet.
The design incorporates a power supply circuit that ensures the PICAXE processor and sensors receive stable voltage levels, typically from a battery pack. The robot's movement is controlled by a motor driver circuit that interfaces with the PICAXE, allowing for precise control of the motors that drive its wheels. The motor driver can be an H-bridge configuration, enabling the robot to move forward, reverse, and turn.
The software programming for the PICAXE processor is crucial, as it dictates the robot's behavior and decision-making processes. The code will handle sensor input, process the data, and control the motors based on predefined algorithms. For instance, when the ultrasonic sensor detects an obstacle within a specified range, the robot can be programmed to stop, reverse, or change direction.
To enhance its functionality, the robot may include additional features such as LED indicators for status signaling, a buzzer for auditory feedback, and a communication module for remote control or telemetry. The overall schematic of the robot would illustrate the interconnections between the PICAXE processor, sensors, motor drivers, and other components, providing a clear representation of the system's architecture.
In summary, this autonomous robot serves as a practical platform for exploring sensor interfacing and microcontroller programming, showcasing the integration of hardware and software in robotic applications.This is my first autonomous robot. I built it to explore the interfacing of various sensors to a PICAXE processor. His mission is to search for a magn..
The autonomous robot operates based on a microcontroller architecture centered around the PICAXE processor, which is well-suited for educational and experimental robotic applications. The robot is equipped with an array of sensors that facilitate its navigational and operational capabilities. These sensors may include ultrasonic distance sensors for obstacle detection, infrared sensors for line following, and magnetic sensors for detecting the presence of a magnet.
The design incorporates a power supply circuit that ensures the PICAXE processor and sensors receive stable voltage levels, typically from a battery pack. The robot's movement is controlled by a motor driver circuit that interfaces with the PICAXE, allowing for precise control of the motors that drive its wheels. The motor driver can be an H-bridge configuration, enabling the robot to move forward, reverse, and turn.
The software programming for the PICAXE processor is crucial, as it dictates the robot's behavior and decision-making processes. The code will handle sensor input, process the data, and control the motors based on predefined algorithms. For instance, when the ultrasonic sensor detects an obstacle within a specified range, the robot can be programmed to stop, reverse, or change direction.
To enhance its functionality, the robot may include additional features such as LED indicators for status signaling, a buzzer for auditory feedback, and a communication module for remote control or telemetry. The overall schematic of the robot would illustrate the interconnections between the PICAXE processor, sensors, motor drivers, and other components, providing a clear representation of the system's architecture.
In summary, this autonomous robot serves as a practical platform for exploring sensor interfacing and microcontroller programming, showcasing the integration of hardware and software in robotic applications.This is my first autonomous robot. I built it to explore the interfacing of various sensors to a PICAXE processor. His mission is to search for a magn..
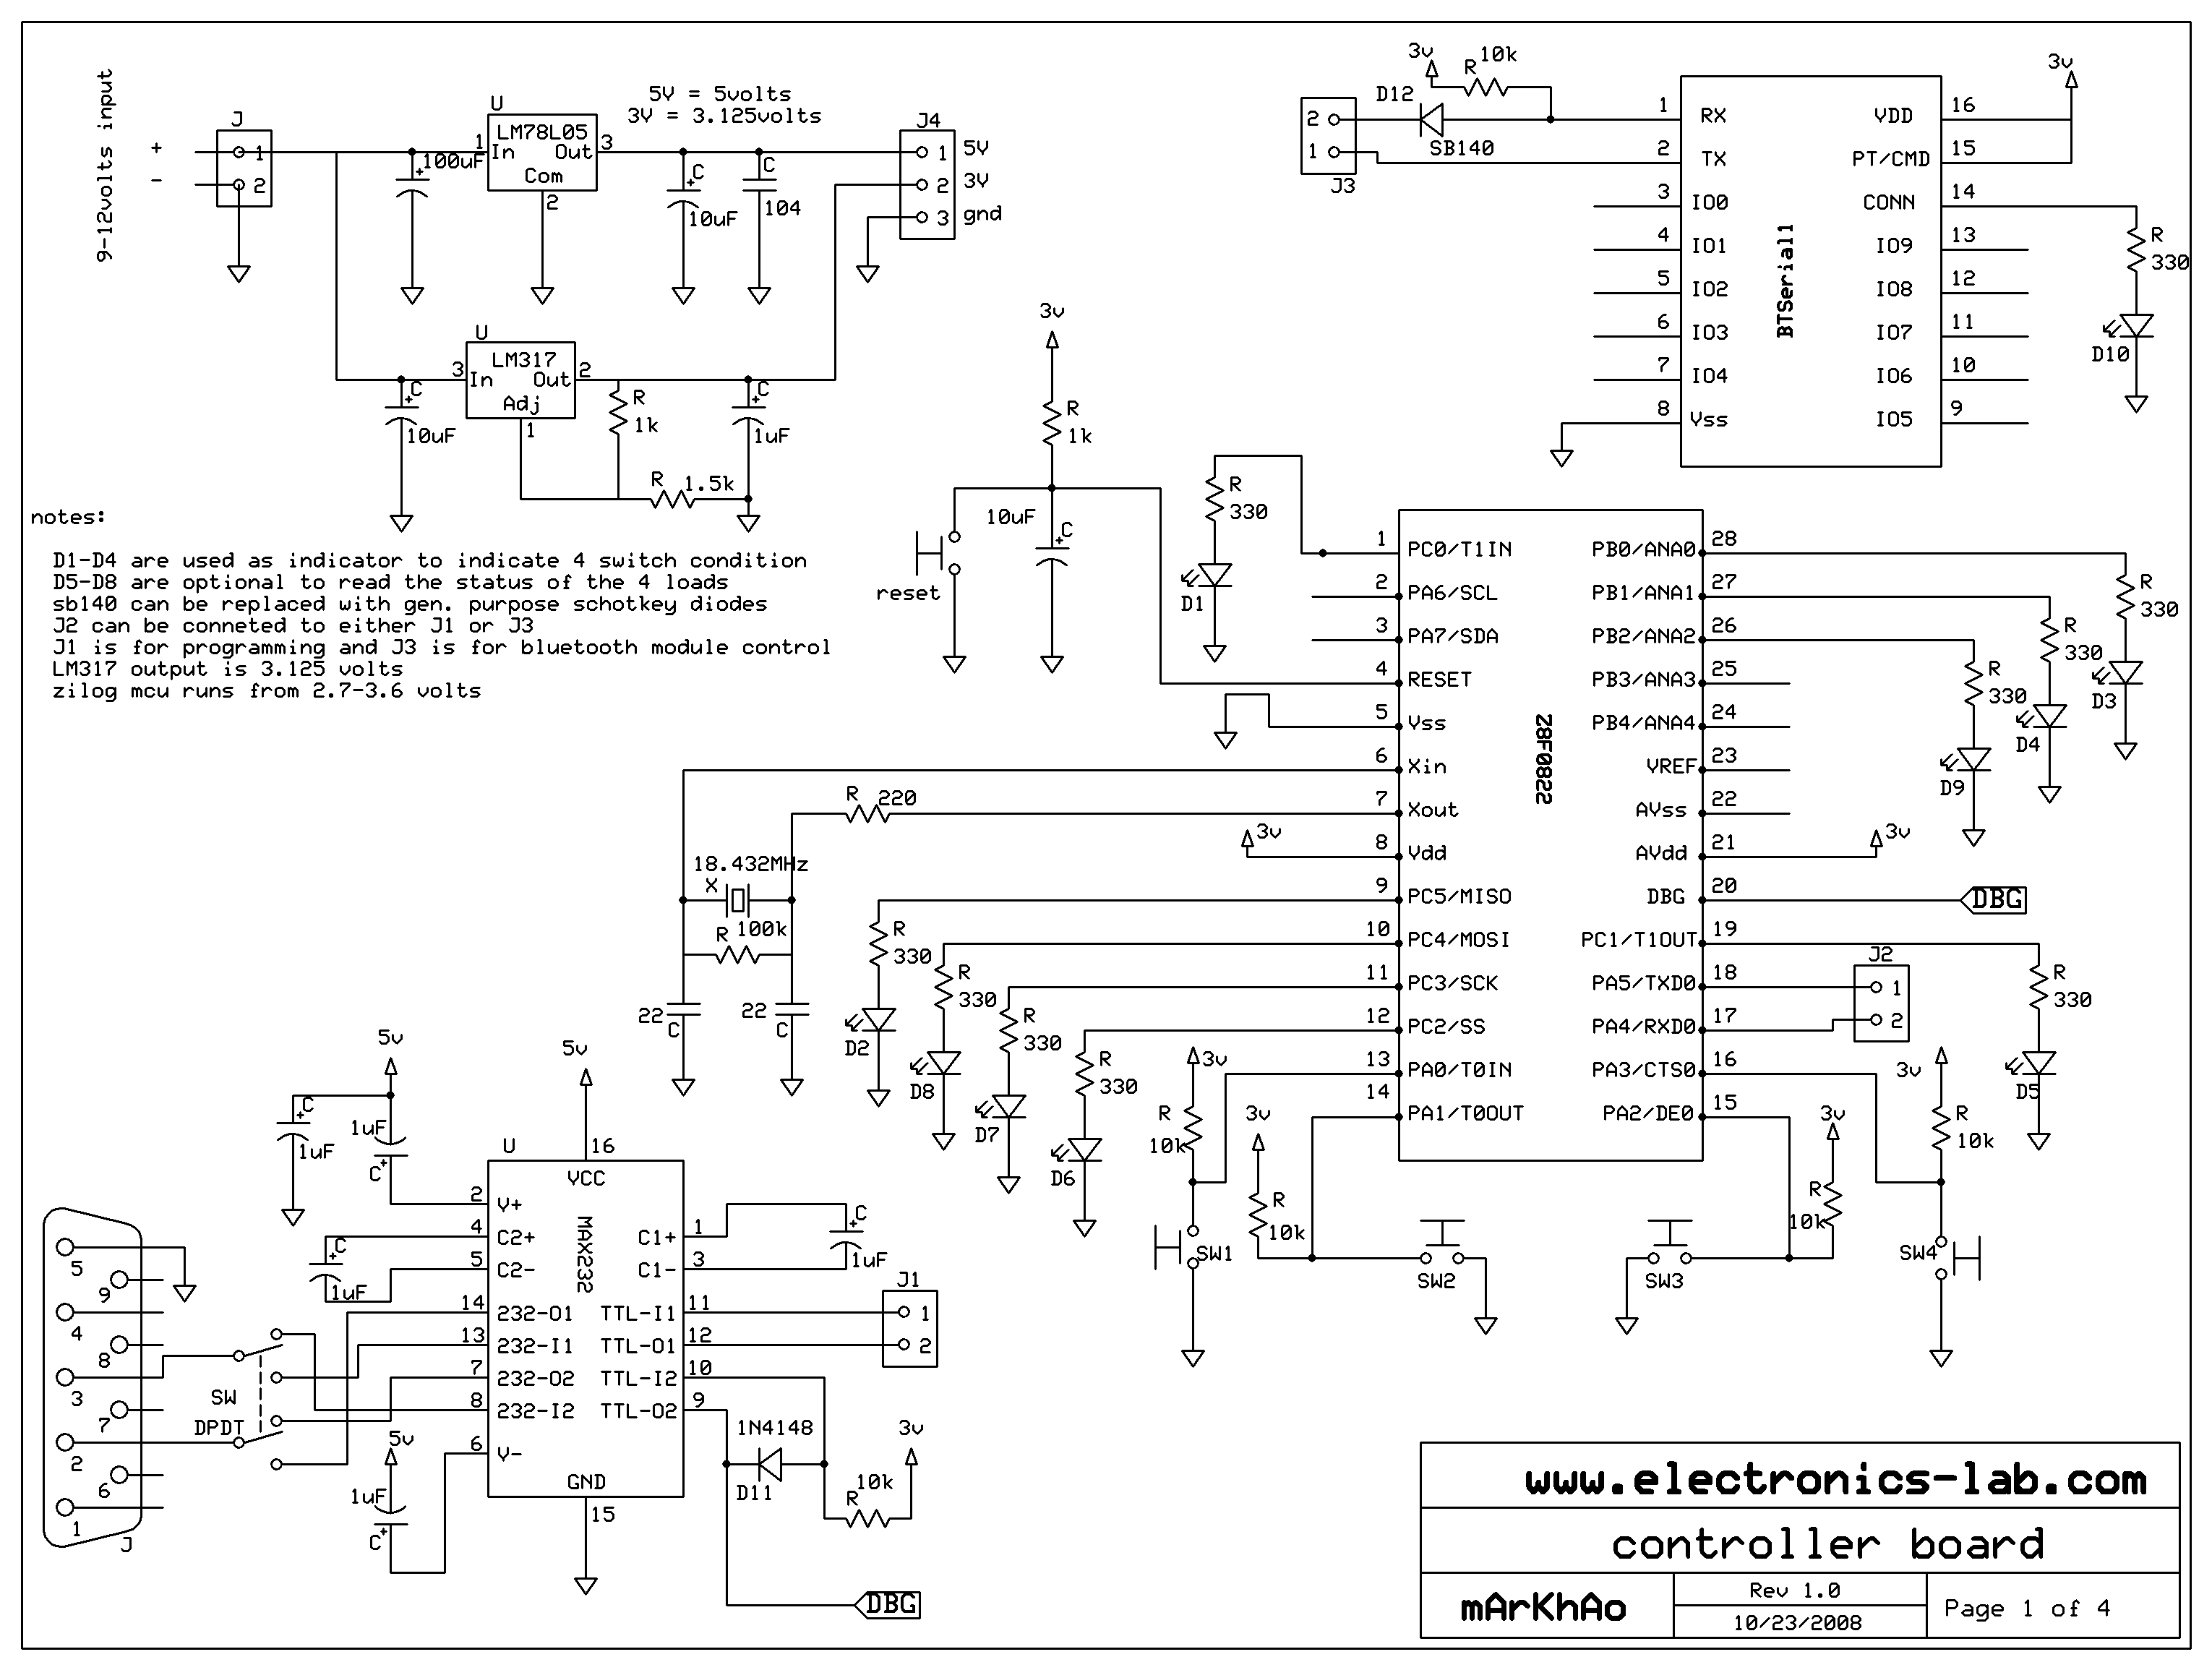
MCU controlled Bluetooth automation
The microcontroller used is 0822 zilog encore! 8k series (soic,28pin) as shown on the figure. Is a programmable microcontroller, the functions used are the GPIO and the UART of the chip. GPIO is used on led indicators, and the UART...
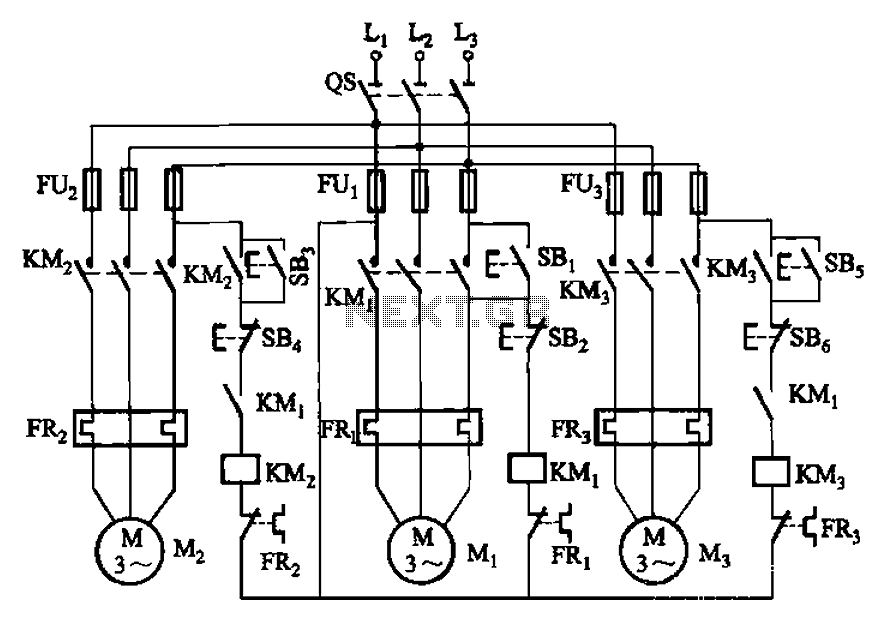
Three motor control circuit start and stop sequence requirements
The circuit shown in Figure 3-89 illustrates a system where starting motor M1 allows motors M2 and M3 to initiate operation. Upon shutdown, motor Mz can be stopped first; however, once motor M1 is stopped (by pressing switch SB2), motors...
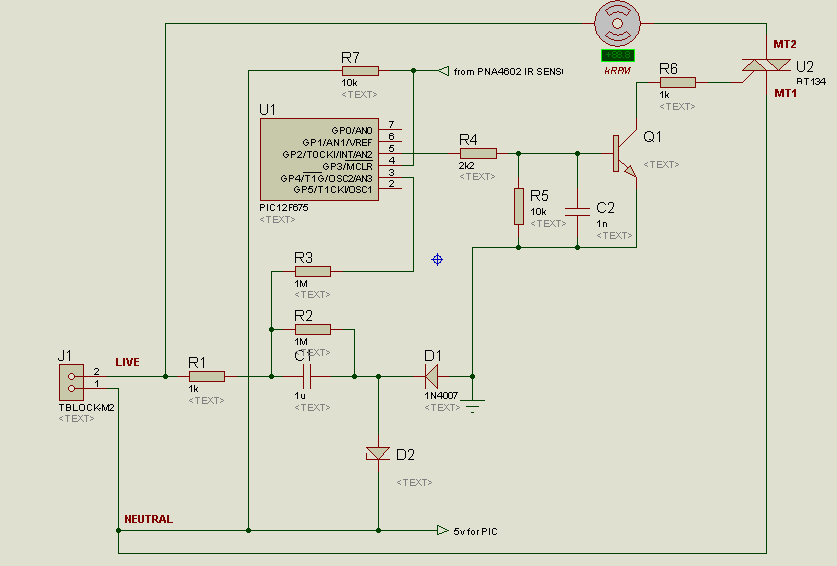
Microcontroller-based: Electric fan switching relay or triac
A project is underway to control the speed of an electric fan (220Vac, 60W, 5A max.) automatically using a microcontroller based on certain parameters.
The circuit design for controlling the speed of an electric fan involves several key components to ensure...
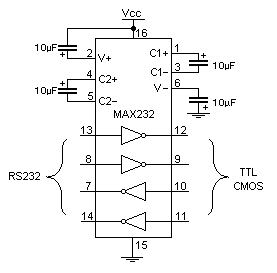
Microcontroller interfacing with RS 232
Standard serial interfacing of a microcontroller (TTL) with a PC or any RS232C standard device requires a TTL to RS232 level converter. A MAX232 is used for this purpose. It provides a 2-channel RS232C port and requires external 10µF capacitors.
The...
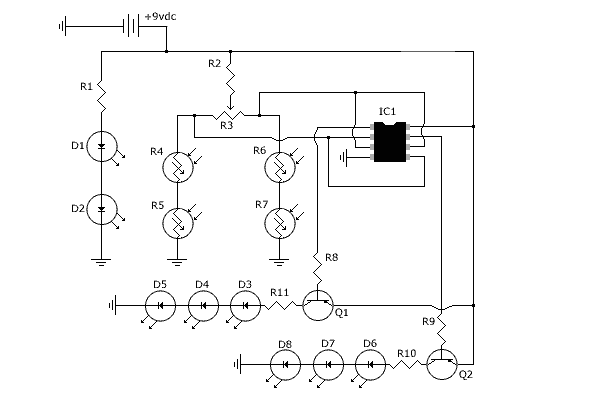
robot guts
The headlights and photo cells are oriented downward, leading to the visualization of the entire circuit as being inverted. The configuration utilizes three LEDs on each side. This choice is likely due to the inability to power three LEDs in...
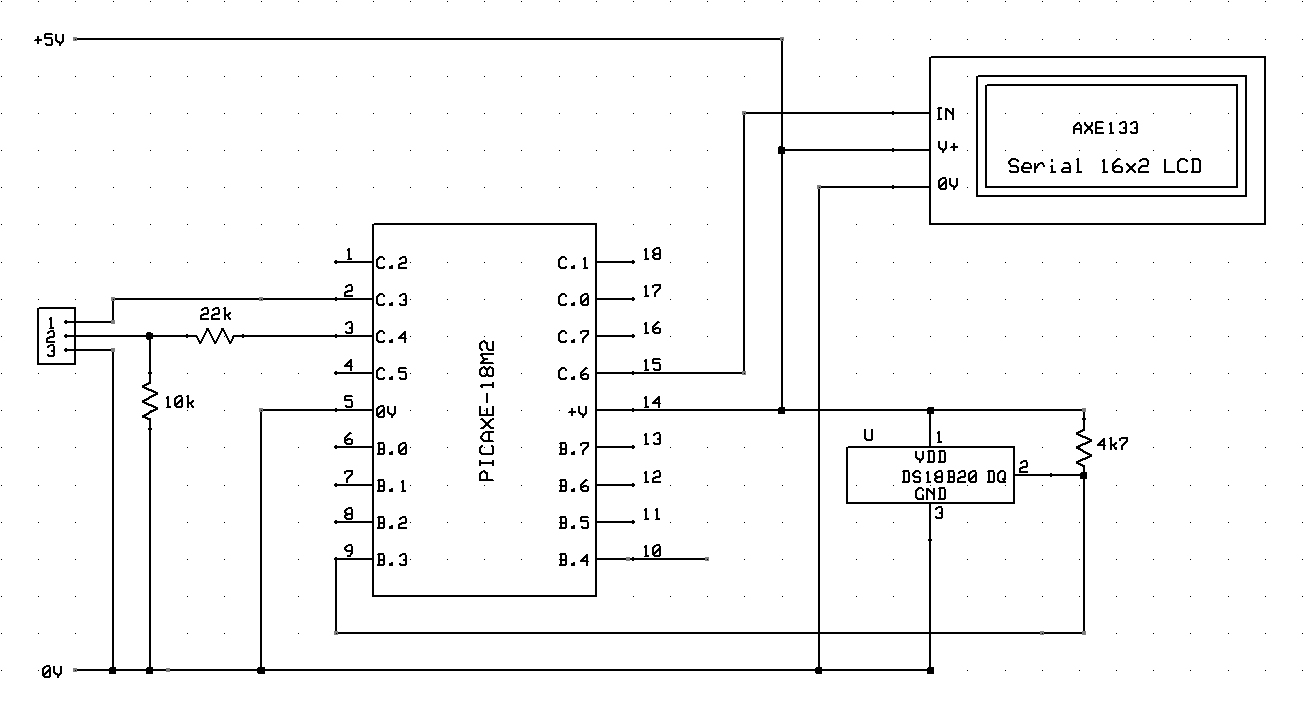
measure temperature with a ds18b20 sensor in picaxe
A circuit diagram and example code to implement and use the DS18B20 temperature sensor in PICAXE, both in rounded and full 12-bit resolution.
The DS18B20 is a digital temperature sensor that communicates over a 1-Wire interface, allowing multiple sensors to be...
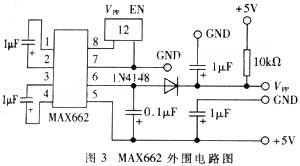
The embedded microcontroller MC68HC912B32 background debugs the mode to design
The widespread application of Flash technology in microprocessors has led to significant advancements in the development and utilization of one-chip computers. Designers have transitioned from traditional in-circuit emulators (ICE) and JTAG interfaces to more cost-effective and user-friendly development methods. While...
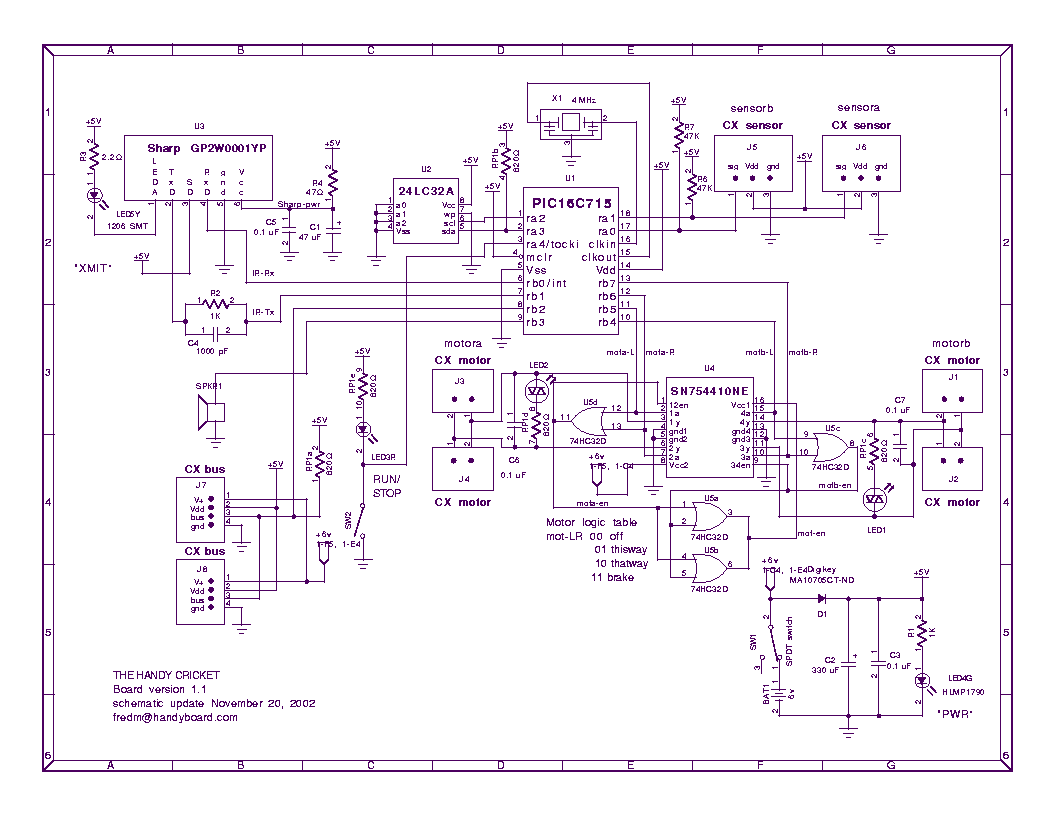
Handy Cricket Hardware Description
This document presents an overview of the hardware design of the Handy Cricket.
The Handy Cricket is a compact electronic device designed for educational and recreational purposes, primarily aimed at children. The hardware design incorporates various components that work together to...
Jet
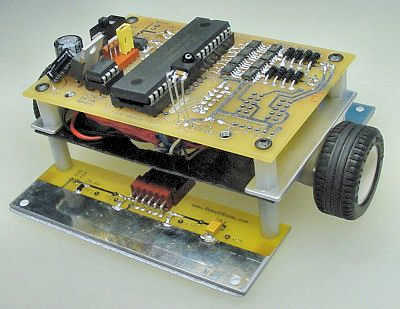
The microcontroller is able to make about 7000 complete line-following decisions per second, which is almost 7 decisions per millimeter when the robot is going full speed. By upping the clock, unrolling loops, and removing my wireless debugging and extraneous...