


the dc motor circuit
#DC motor
#H-bridge
#transistors
#battery
#robot
#motor driver
#control circuit
#power source
#alligator leads
#mobile robots
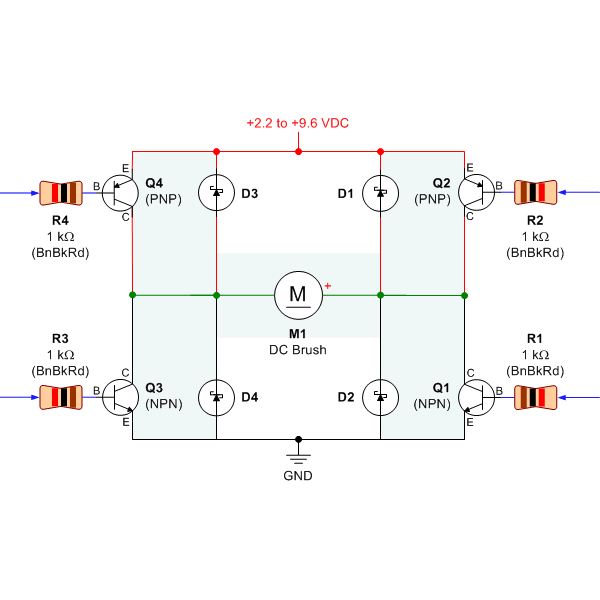
Description: Selecting the appropriate DC motor is essential for constructing mobile robots. Testing DC motors is straightforward and can be accomplished by assembling a basic DC motor circuit. The components needed for this circuit include a DC motor, a battery power source with a minimum voltage of 3 V, and red and black alligator clips. To construct the circuit, the red alligator clip should be connected to the positive terminals of both the battery and the motor, while the black alligator clip connects to the negative terminals of the battery and the motor. For controlling the operation of a DC motor, a specialized circuit such as an H-bridge can be utilized. The H-bridge circuit consists of an arrangement of transistors, along with resistors and diodes, to regulate the operation of a DC motor.
The basic DC motor circuit allows for a simple on/off control of the motor. By connecting the battery to the motor through the alligator leads, the motor can be activated or deactivated based on the connection of the leads. However, for applications requiring direction control and speed modulation, the H-bridge circuit is essential.
An H-bridge consists of four switches (typically transistors) arranged in a bridge configuration. By controlling the states of these switches, the current flow through the motor can be reversed, allowing for bidirectional control. For instance, turning on switches S1 and S4 while turning off S2 and S3 will cause the motor to rotate in one direction. Conversely, activating S2 and S3 while deactivating S1 and S4 will reverse the motor's direction.
In addition to direction control, the H-bridge can also facilitate speed control through pulse-width modulation (PWM). By varying the duty cycle of the PWM signal applied to the transistors, the average voltage and current supplied to the motor can be adjusted, thereby controlling its speed.
In summary, while a basic DC motor circuit suffices for simple applications, an H-bridge circuit provides the necessary functionality for advanced control of DC motors, enabling both direction and speed modulation essential for mobile robotics.Choosing the right DC motor is critical when building mobile robots. Testing DC motors is an easy process and can be done by building a simple DC motor circuit. All that is required to build this circuit is a DC motor, a battery power source of at least 3 V, and red and black alligator leads. To build the circuit, the red alligator lead is connected to the positive terminal of the battery and motor, whereas the black alligator lead is connected to the negative terminal of the battery and motor.
In order to control the functioning of a DC motor, a specialized DC motor circuit can be used, such as an H-bridge. The H-bridge circuit design is an array of transistors that work along with resistors and diodes to command a DC motor..
The basic DC motor circuit allows for a simple on/off control of the motor. By connecting the battery to the motor through the alligator leads, the motor can be activated or deactivated based on the connection of the leads. However, for applications requiring direction control and speed modulation, the H-bridge circuit is essential.
An H-bridge consists of four switches (typically transistors) arranged in a bridge configuration. By controlling the states of these switches, the current flow through the motor can be reversed, allowing for bidirectional control. For instance, turning on switches S1 and S4 while turning off S2 and S3 will cause the motor to rotate in one direction. Conversely, activating S2 and S3 while deactivating S1 and S4 will reverse the motor's direction.
In addition to direction control, the H-bridge can also facilitate speed control through pulse-width modulation (PWM). By varying the duty cycle of the PWM signal applied to the transistors, the average voltage and current supplied to the motor can be adjusted, thereby controlling its speed.
In summary, while a basic DC motor circuit suffices for simple applications, an H-bridge circuit provides the necessary functionality for advanced control of DC motors, enabling both direction and speed modulation essential for mobile robotics.Choosing the right DC motor is critical when building mobile robots. Testing DC motors is an easy process and can be done by building a simple DC motor circuit. All that is required to build this circuit is a DC motor, a battery power source of at least 3 V, and red and black alligator leads. To build the circuit, the red alligator lead is connected to the positive terminal of the battery and motor, whereas the black alligator lead is connected to the negative terminal of the battery and motor.
In order to control the functioning of a DC motor, a specialized DC motor circuit can be used, such as an H-bridge. The H-bridge circuit design is an array of transistors that work along with resistors and diodes to command a DC motor..
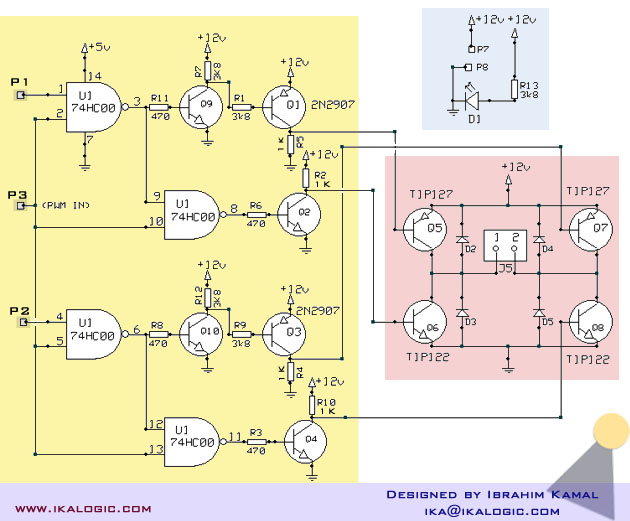
Build a 5A H-bridge Motor driver! Old version
A relatively high-power H-bridge motor controller, which is a common method to control DC motors, utilizes inexpensive TIP transistors. A continuous current of 5 Amperes through an H-bridge module may not seem significant to some, depending on their background and...
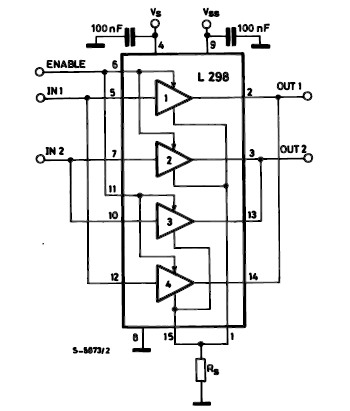
dc motor driver with h bridge ic l293d
The L298 IC H-Bridge DC motor driver features two H-Bridge circuits, allowing it to control two DC motors simultaneously. Each H-Bridge can deliver currents up to 2A, but when used in parallel, the L298 can provide a total current of...
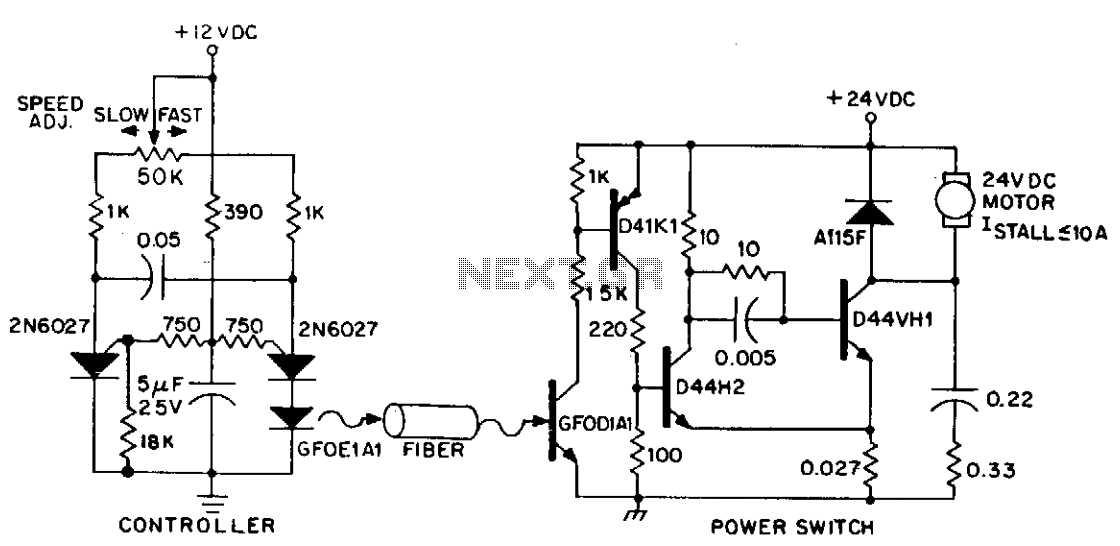
DC variable speed motor control
DC power can also be controlled using fiber optics. The circuit provides an insulated speed control path for a small DC actuator motor (less than Vn hp). The control logic is a self-contained module that requires approximately 300 mW at...
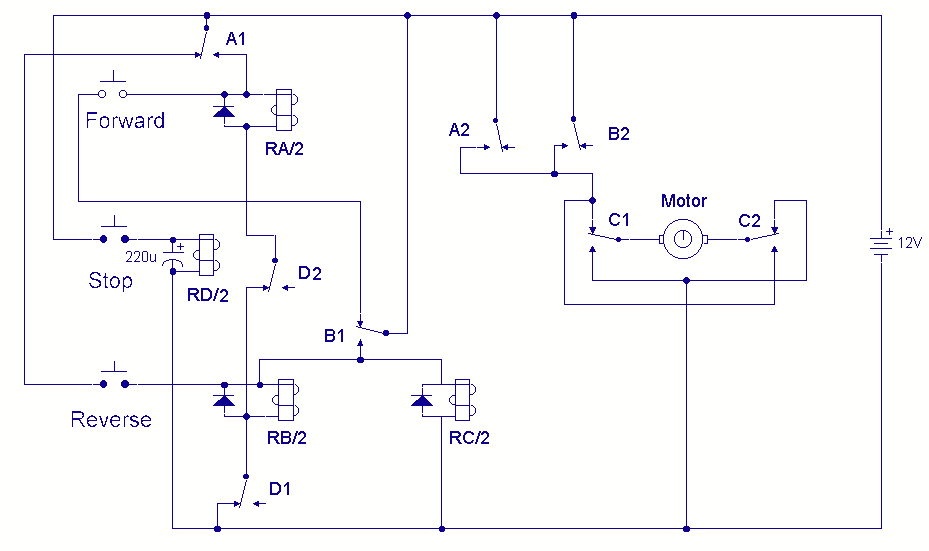
DC Motor Reversing Circuit
A DC motor reversing circuit using non-latching push button switches. Relays control forward, stop, and reverse action, and the motor cannot be switched from forward to reverse unless the stop switch is pressed first.
The described circuit employs a system of...
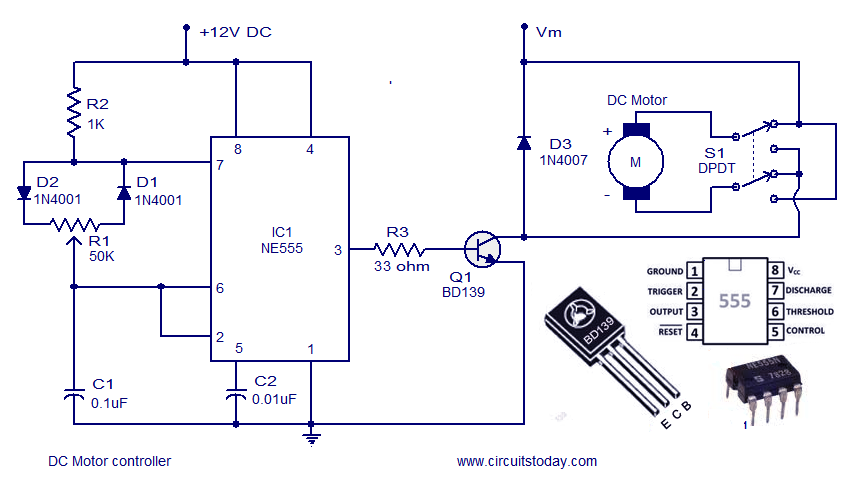
Dc motor speed controller circuit using NE555
A DC motor controller based on an NE555 timer is presented here. The direction of rotation of the DC motor can also be changed using this DC motor speed control circuit.
The described circuit utilizes the NE555 timer IC in astable...
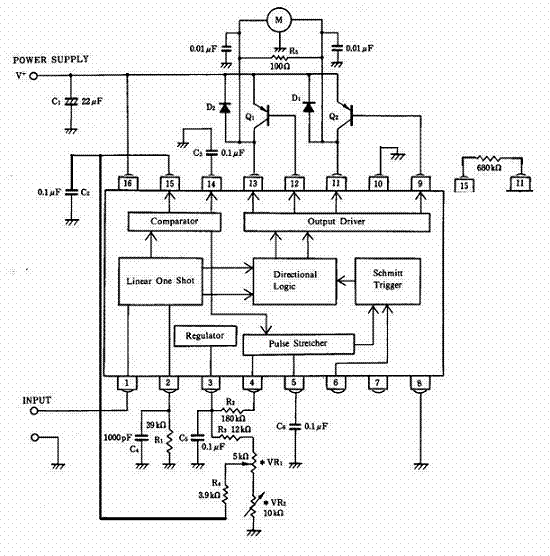
Dome Drive Schematic
A few modifications have been made to the dead band and pulse stretcher resistors, and the position feedback potentiometer has been altered to function as a "zero the speed" or "center your transmitter sticks." Additionally, a traditional PNP-NPN H-bridge has...
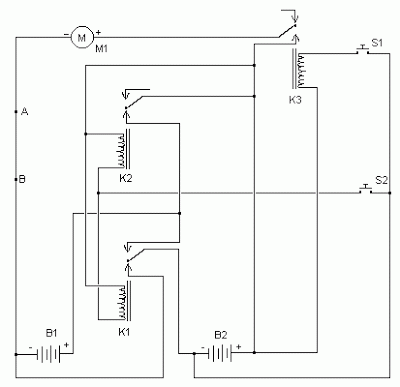
two speed contactor dc motor controller
The simplest form of motor controllers, apart from a basic on/off switch, is the contactor controller. This contactor controller is recommended for use in electric scooter projects. It is based on three 12V relays, two 12V batteries, two switches, and...
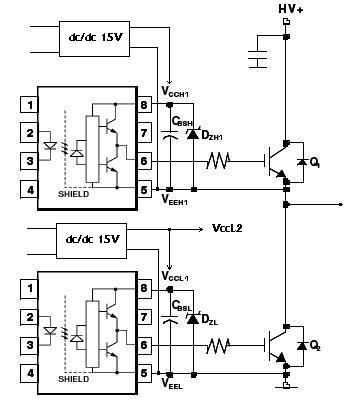
H-bridge using only n-channel mosfets
An H-bridge circuit has been developed utilizing four floating gate drivers and four insulated gate bipolar transistors (IGBTs). The attached schematic illustrates one half of the H-bridge configuration. The circuit operates effectively, but there are additional considerations to address.
The H-bridge...
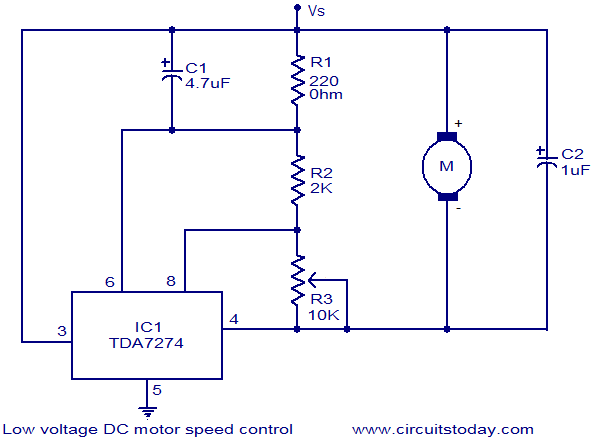
Low voltage DC motor speed control circuit
The circuit diagram illustrates a low voltage/low power DC motor speed controller utilizing the TDA 7274 integrated circuit from ST Microelectronics. The TDA 7274 is designed for low voltage and low power applications, featuring an internal voltage reference, a broad...