


Build a 5A H-bridge Motor driver! Old version
#H-bridge
#DC motor
#TIP transistors
#robotics
#high power
#motor driver
#hobby electronics
#current control
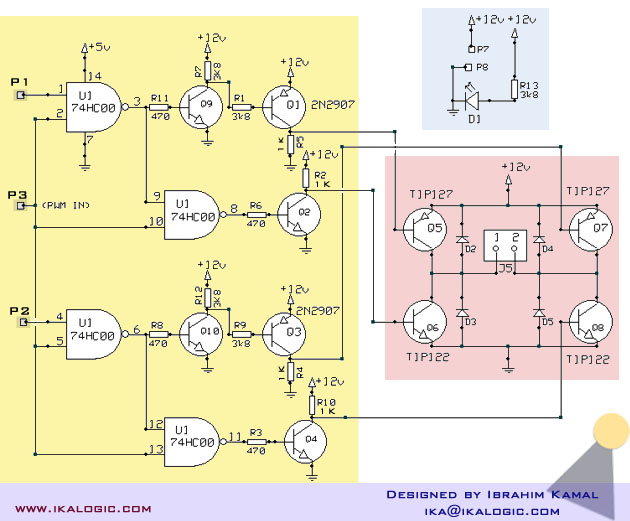
Description: A relatively high-power H-bridge motor controller, which is a common method to control DC motors, utilizes inexpensive TIP transistors. A continuous current of 5 Amperes through an H-bridge module may not seem significant to some, depending on their background and experience; however, in the realm of hobby electronics and robotics, a controller capable of managing motors with currents up to 5A at 24V is regarded as a high-power device. The H-bridge primarily consists of four switches that are operated in a specific sequence to control the current direction through the motor. For brushed DC motors, the armature's rotation direction changes by altering the current's flow direction. It is important to note that the current flowing through a motor correlates with the output torque, while the angular velocity (RPM) of the output shaft is proportional to the voltage across the motor windings. A simplified diagram illustrating the H-bridge configuration is depicted below; the schematic resembles the letter "H," which is the origin of its name. There are two potential current paths in this configuration. The distinction between this basic H-bridge and a real H-bridge module is that the switches are substituted with transistors to electronically regulate the current flow in the motor, enabling speed and direction control from a microcontroller, for instance. For beginners or those unfamiliar with transistors, a forthcoming section will explain the essential concepts regarding transistors necessary for understanding and constructing an H-bridge. Transistors can be used as switches to electronically regulate current flow through other electrical components. While a transistor can also function as a signal amplifier, this aspect is not pertinent to the H-bridge application. Utilizing transistors as switches is referred to as operating them in saturation and cut-off mode. A schematic illustrates the operation of a transistor as a switch. The primary difference between a mechanical switch and a transistor switch lies in the method of activation; a mechanical switch is operated physically, while a transistor switch is controlled by small electrical currents applied to the base, typically less than 20 mA. For an NPN transistor, when a small current enters the base, current flows from the collector to the emitter; otherwise, no current passes through the collector-emitter junction. Conversely, for a PNP transistor, when a small current exits the base, current flows from the emitter to the collector. To utilize a transistor as a switch, the base voltage must be higher than the collector voltage for an NPN transistor or lower for a PNP transistor. To ensure the transistor is in saturation, it is necessary to calculate the appropriate value of Rb, as shown in the schematic. The reason for having two types of transistor switches, NPN and PNP, is to maintain the base voltage at a suitable level for saturation, regardless of whether it is connected to ground or 12V. In the H-bridge, two transistors connect to 12V while the other two connect to ground. Depending on the transistor used, relevant values should be gathered from the datasheet, which can be challenging for beginners.
The H-bridge motor controller is designed to provide efficient control of DC motors by allowing bidirectional rotation and speed regulation. The configuration employs four transistors arranged in a bridge format. The two pairs of transistors on either side of the bridge are responsible for reversing the polarity of the voltage applied to the motor, thus changing its direction of rotation.
When implementing this circuit, it is essential to ensure that the transistors are adequately rated for the current and voltage specifications of the motor being controlled. The TIP transistors typically have a maximum collector current rating that should not be exceeded to prevent overheating and potential damage. Additionally, heat sinks may be required to dissipate excess heat generated during operation.
The control signals for the H-bridge can be generated using a microcontroller, such as an Arduino or Raspberry Pi, which sends PWM (Pulse Width Modulation) signals to the base of the transistors. This technique allows for fine control over the motor speed by varying the duty cycle of the PWM signal. The duty cycle determines the average voltage and current supplied to the motor, thereby controlling its speed and torque output.
In summary, the H-bridge motor controller using TIP transistors is a robust solution for hobbyists and engineers looking to control DC motors with precision. Understanding the operation of transistors and their role in the H-bridge configuration is crucial for building efficient motor control systems. Proper design considerations, including component selection and thermal management, will ensure reliable and effective motor operation.A relatively High power H-bridge motor controller (which is the most common way to control DC motors) With cheap TIP transistors. 5 Amperes of continuous current through an H-bridge module may not seen high power to someof you, depending on your field and experience, that`s why I used the word relatively.
But in the field of hobby electronics and robotics, yes a controller capable of controlling motors with currents as high as 5A at 24V is considered a high power device. The H-bridge is principally a configuration of four switches, that are switched in a specific manner to control the direction the of the current through the motor. (For brushed DC motors, the direction of rotation of the armature of the motor is changed by changing the direction of the current flowing though it).
While we are talking about DC motors, here is a small useful note to bear in mind: Current flowing though a motor is proportional to the output torque, while the angular velocity (rpm) of the the output shaft is proportional to the the voltage across the motor windings . Below figure 1, is a simplified diagram showing the operation of the H-bridge configuration(you can notice the shape of the schematic, it looks like an H` letter, this is how this famous circuit got this name!).
There are two possible paths for the current: The only difference between this simple H-bridge and the real H-bridge module explained on this page, is that the switches are replaced by Transistors, in order to electronically control the flow of current in the motor, hence, allowing us tocontrol the speed and direction of the motor from a microcontroller, for example. In case you are a beginner or just not familiar with transistors, I am going to explain in the next section most of what you need to know about transistors to understand and build an H-bridge.
One very simple way to use transistors is to use them as switches, to electronically control the flow of current though other electrical elements. The same transistor may be used as a signal amplifier, but this is the messy part of the transistor studies, and we don`t need this for our H-bridge.
Using transistors as a switch is also called using transistors in saturation and cut-off mode. This schematicfigure 2, simply shows the meaning of using a transistor as a switch. The only difference between a mechanical switch and a transistor switch is that a normal switch is turned ON or OFF mechanically while a transistor switch is turned ON and OFF using smallelectrical currents applied on the Base, usually smaller than 20 mA. For an NPN transistor, when a small current flows into the Base of the transistor, current will flow from the Collector to the Emitter, otherwise, no current will through the CE junction (Collector-Emitter junction).
On the other hand, for a PNP transistor, when a small current is allowed out from the base of the transistor, current will flow from the Emitter to the Collector. In order to use the transistor as a switch, the base voltage has to beHigher than the Collector voltage (in case of NPN transistor), or Lower than the collector voltage (in case of PNP transistor).
Also, to ensure the transistor is saturated, you must calculate the suitable value of Rb shown in the schematic (this will be discussed in detail later ). You may wonder why are there two different implementations of the Transistor switch, one with NPN transistor, the other with a PNP one.
The answer is very simple, it is to ensure that the base voltage is at a suitable level to ensure the transistor is saturated whether it is connected to ground or to 12V. (in the H bridge, two transistors are connected to 12V, while the two others are connected to Ground.
) Depending on the transistor you are using, gather from the datasheet the following values. sometimes for beginners, finding those values in the datasheet, or the near
The H-bridge motor controller is designed to provide efficient control of DC motors by allowing bidirectional rotation and speed regulation. The configuration employs four transistors arranged in a bridge format. The two pairs of transistors on either side of the bridge are responsible for reversing the polarity of the voltage applied to the motor, thus changing its direction of rotation.
When implementing this circuit, it is essential to ensure that the transistors are adequately rated for the current and voltage specifications of the motor being controlled. The TIP transistors typically have a maximum collector current rating that should not be exceeded to prevent overheating and potential damage. Additionally, heat sinks may be required to dissipate excess heat generated during operation.
The control signals for the H-bridge can be generated using a microcontroller, such as an Arduino or Raspberry Pi, which sends PWM (Pulse Width Modulation) signals to the base of the transistors. This technique allows for fine control over the motor speed by varying the duty cycle of the PWM signal. The duty cycle determines the average voltage and current supplied to the motor, thereby controlling its speed and torque output.
In summary, the H-bridge motor controller using TIP transistors is a robust solution for hobbyists and engineers looking to control DC motors with precision. Understanding the operation of transistors and their role in the H-bridge configuration is crucial for building efficient motor control systems. Proper design considerations, including component selection and thermal management, will ensure reliable and effective motor operation.A relatively High power H-bridge motor controller (which is the most common way to control DC motors) With cheap TIP transistors. 5 Amperes of continuous current through an H-bridge module may not seen high power to someof you, depending on your field and experience, that`s why I used the word relatively.
But in the field of hobby electronics and robotics, yes a controller capable of controlling motors with currents as high as 5A at 24V is considered a high power device. The H-bridge is principally a configuration of four switches, that are switched in a specific manner to control the direction the of the current through the motor. (For brushed DC motors, the direction of rotation of the armature of the motor is changed by changing the direction of the current flowing though it).
While we are talking about DC motors, here is a small useful note to bear in mind: Current flowing though a motor is proportional to the output torque, while the angular velocity (rpm) of the the output shaft is proportional to the the voltage across the motor windings . Below figure 1, is a simplified diagram showing the operation of the H-bridge configuration(you can notice the shape of the schematic, it looks like an H` letter, this is how this famous circuit got this name!).
There are two possible paths for the current: The only difference between this simple H-bridge and the real H-bridge module explained on this page, is that the switches are replaced by Transistors, in order to electronically control the flow of current in the motor, hence, allowing us tocontrol the speed and direction of the motor from a microcontroller, for example. In case you are a beginner or just not familiar with transistors, I am going to explain in the next section most of what you need to know about transistors to understand and build an H-bridge.
One very simple way to use transistors is to use them as switches, to electronically control the flow of current though other electrical elements. The same transistor may be used as a signal amplifier, but this is the messy part of the transistor studies, and we don`t need this for our H-bridge.
Using transistors as a switch is also called using transistors in saturation and cut-off mode. This schematicfigure 2, simply shows the meaning of using a transistor as a switch. The only difference between a mechanical switch and a transistor switch is that a normal switch is turned ON or OFF mechanically while a transistor switch is turned ON and OFF using smallelectrical currents applied on the Base, usually smaller than 20 mA. For an NPN transistor, when a small current flows into the Base of the transistor, current will flow from the Collector to the Emitter, otherwise, no current will through the CE junction (Collector-Emitter junction).
On the other hand, for a PNP transistor, when a small current is allowed out from the base of the transistor, current will flow from the Emitter to the Collector. In order to use the transistor as a switch, the base voltage has to beHigher than the Collector voltage (in case of NPN transistor), or Lower than the collector voltage (in case of PNP transistor).
Also, to ensure the transistor is saturated, you must calculate the suitable value of Rb shown in the schematic (this will be discussed in detail later ). You may wonder why are there two different implementations of the Transistor switch, one with NPN transistor, the other with a PNP one.
The answer is very simple, it is to ensure that the base voltage is at a suitable level to ensure the transistor is saturated whether it is connected to ground or to 12V. (in the H bridge, two transistors are connected to 12V, while the two others are connected to Ground.
) Depending on the transistor you are using, gather from the datasheet the following values. sometimes for beginners, finding those values in the datasheet, or the near
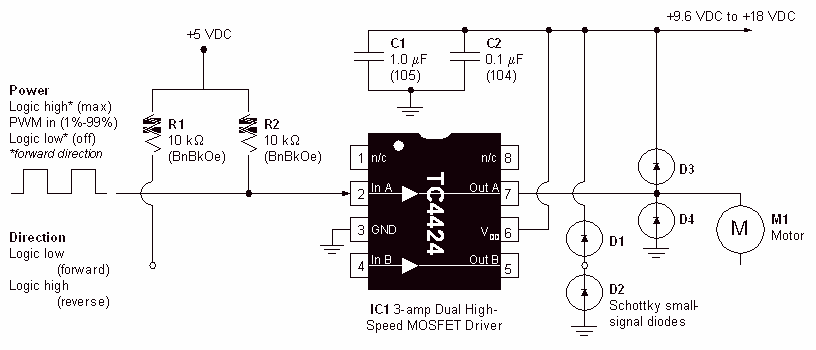
DC Motor-Driver H-Bridge Circuit
Physical motion of some form helps differentiate a robot from a computer. It would be nice if a motor could be attached directly to a chip that controlled the movement. But, most chips can't pass enough current or voltage to...
When page is bookmarked text here is referenced verbatim
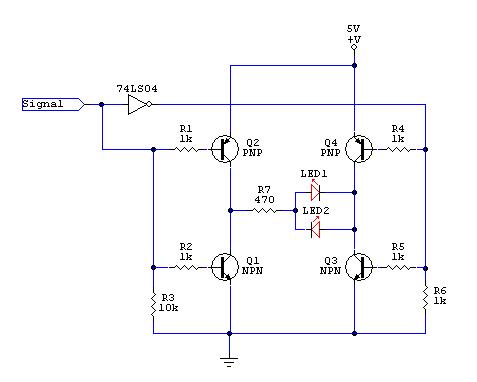
The image shows a completed locked anti-phase motor controller built on a breadboard, utilizing general-purpose transistors to control small DC motors for robotics applications. A typical DC motor controller lacks a braking function, which is essential for precise control. Addressing...
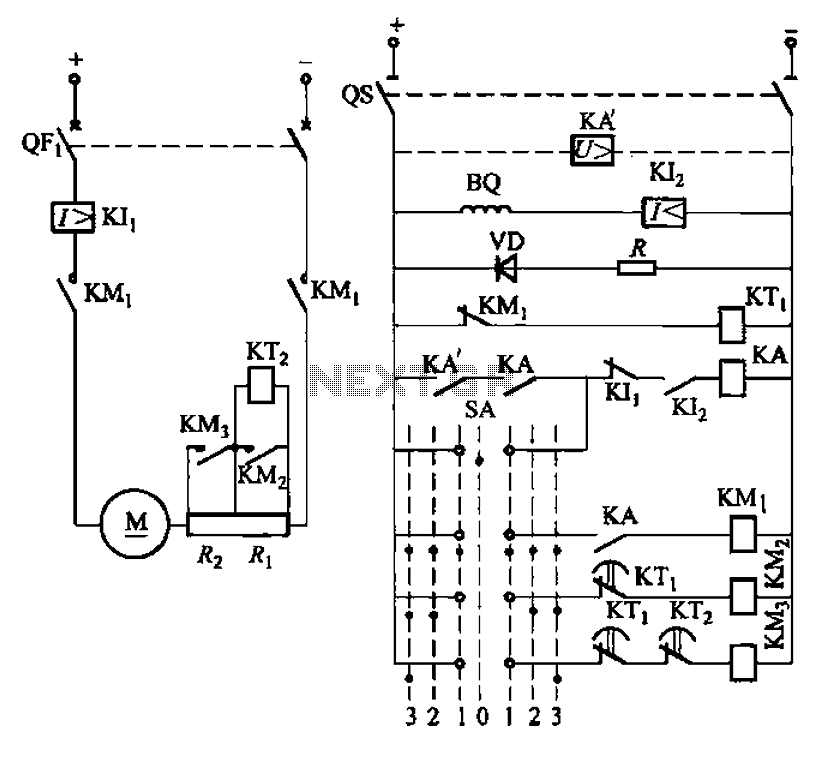
One of debug circuitry DC motor armature resistance in series starting
The circuit depicted in Figure 3-190 includes an armature circuit with two startup resistors, Ri and Rz, connected in series through the main switch SA to facilitate starting, stopping, and speed control. During the startup phase, two relays, KTi and...
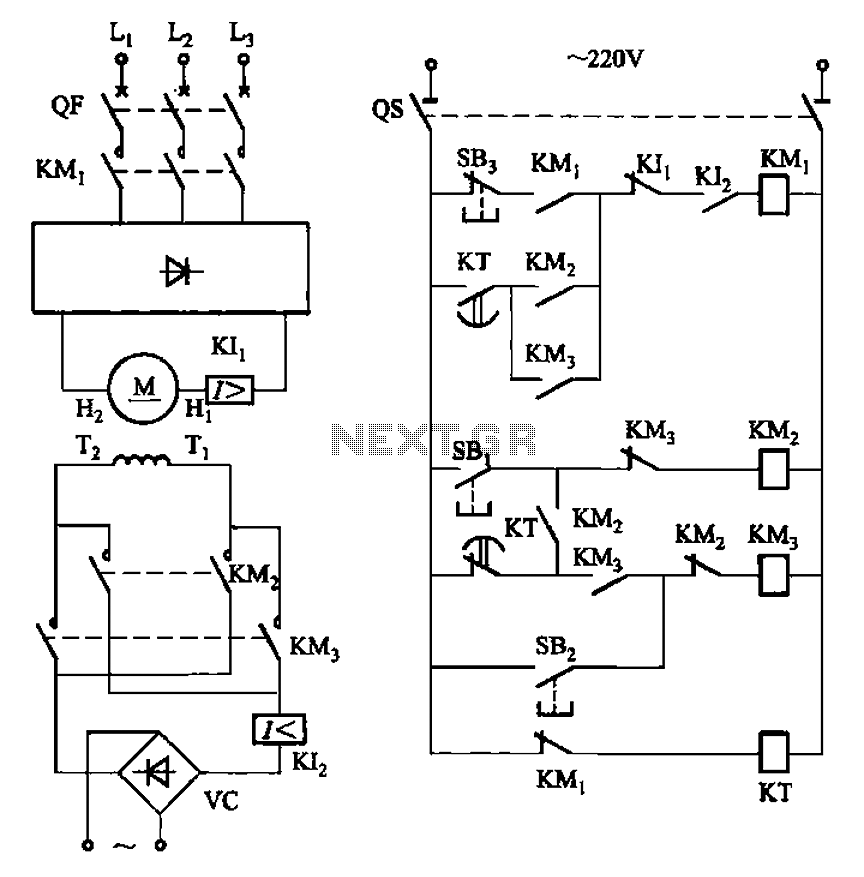
Separately excited DC motor reversing circuit
The circuit depicted in Figure 3-193 illustrates a separately excited DC motor. The brake circuit is not activated; therefore, positive reversals occur alternately using a delay action relay, ensuring that the motor reverses direction after coming to a stop.
The schematic...
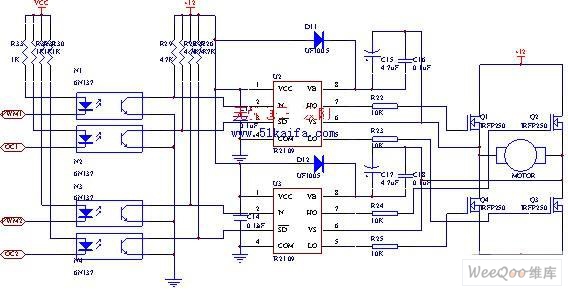
Using IRFP250 power tube H-bridge motor drive circuit
The drive circuit for the electromotor comprises a FET bridge circuit, a FET base drive circuit, a current sensor for the motor drive circuit, and a relay. The FET bridge circuit primarily consists of four high-power MOSFETs, which must possess...
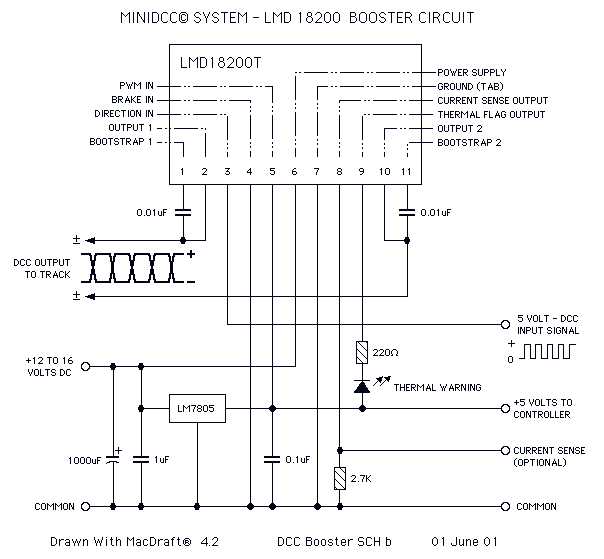
H Bridge Direct Current Motor Control Circuits
This page features H-Bridge circuits used for controlling direct current motors. Several designs are shown using both CMOS and Bi-Polar power devices. These circuits could be used as the basis for Model Railroad DCC Boosters or PWM motor controllers. The...
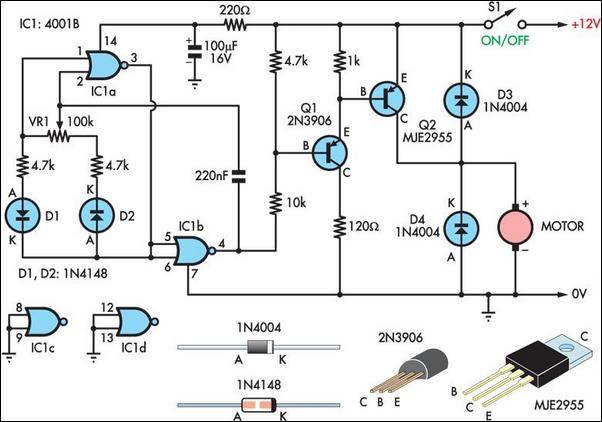
Two Basic Motor Speed Controllers
Two simple 12V DC motor speed controllers can be constructed for a minimal cost. These controllers take advantage of the principle that the rotational speed of a DC motor is directly proportional to the average value of its supply voltage....
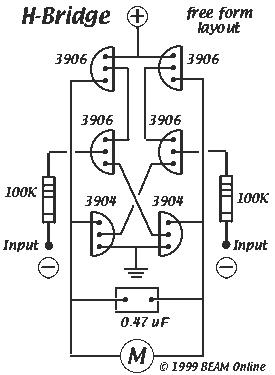
6-transistor H-bridge
Mark Tilden's 6-transistor H-bridge Design, limitations, usage
This is the six transistor "Tilden style" H-bridge; while not as old as the original "basic H-bridge," this goes "way back," and is the basis for many BEAM driver circuits.
* Up to 800 mA...
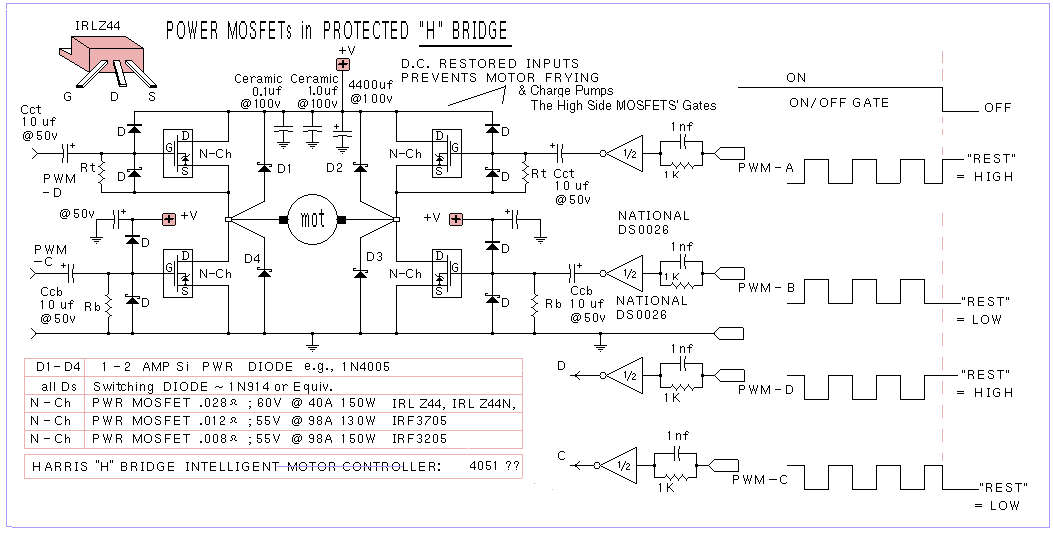
h bridge driver circuit
The regenerative effect of a 4-quadrant inverter necessitates power dissipation in some form. In large industrial drives, this power is typically re-inverted back onto the national grid. However, for smaller applications, implementing a braking circuit is advisable. For low-power applications...