


Dc motor speed control 2
#dc motor
#speed control
#op-amp
#bidirectional
#tachometer
#feedback
#potentiometer
#push-pull
#RFCF
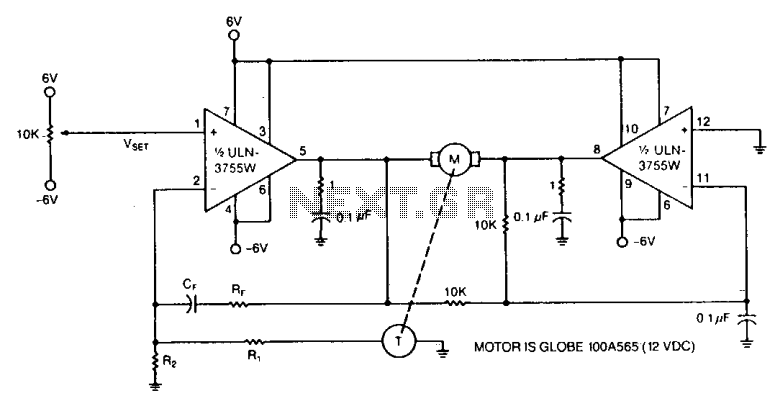
Description: Power operational amplifiers provide precise speed control for DC motors. The circuit enables bidirectional speed control. The push-pull configuration of the amplifiers ensures a full rail-to-rail voltage swing (minus the saturation drops of the output stages) across the motor in both directions. A mechanically-coupled tachometer is used to deliver speed-stabilizing feedback to the first amplifier section. The motor's speed and direction of rotation are determined by adjusting the 10 kΩ potentiometer at the non-inverting input of the amplifier. The RFCF feedback network prevents oscillation by compensating for the motor's inherent dynamic mechanical lag. The RFCF time constant should be selected to align with the specific characteristics of the motor.
Power operational amplifiers are integral components in circuits designed for the precise control of DC motor speed. This specific circuit configuration allows for bidirectional control, enabling the motor to rotate in both clockwise and counterclockwise directions. The push-pull configuration of the operational amplifiers is critical, as it allows for a full rail-to-rail voltage swing across the motor terminals, ensuring that the motor receives adequate power for efficient operation in either direction, while taking into account the output stage saturation drops.
The inclusion of a mechanically-coupled tachometer serves a pivotal role in maintaining speed stability. The tachometer generates feedback that is fed into the first amplifier section, allowing for real-time adjustments to the motor's speed based on its current performance. This feedback loop is essential for achieving consistent motor operation, particularly in applications where speed variations can lead to performance issues.
The adjustment of the motor's speed and direction is facilitated by a 10 kΩ potentiometer connected to the non-inverting input of the operational amplifier. This potentiometer allows for fine-tuning of the input signal, thereby directly influencing the output voltage and, consequently, the speed and direction of the motor.
To ensure the stability of the control loop, an RFCF feedback network is employed. This network is designed to prevent oscillations that can arise due to the dynamic mechanical lag inherent in motor systems. The selection of the RFCF time constant is crucial, as it must be tailored to match the specific characteristics of the motor being used. By doing so, the circuit can effectively compensate for delays in response, ensuring smooth and stable operation across a range of operating conditions.Power op amps provide accurate speed control for dc motors. The circuit provides bidirectional speed control. The amplifiers' push-pull configuration ensures a full rail-to-rail voltage swing (minus the output stages' saturation drops) across the motor in either direction. The circuit uses a mechanically-coupled tachometer to provide speed-stabilizing feedback to the first amplifier section.
The motor's speed and direction of rotation is set by adjusting the 10 k ohm potentiometer at the amplifier's noninverting input. The RFCF feedback network prevents oscillation by compensating for the inherent dynamic mechanical lag of the motor.
Select the RFCF time constant to match the particular motor's characteristics.
Power operational amplifiers are integral components in circuits designed for the precise control of DC motor speed. This specific circuit configuration allows for bidirectional control, enabling the motor to rotate in both clockwise and counterclockwise directions. The push-pull configuration of the operational amplifiers is critical, as it allows for a full rail-to-rail voltage swing across the motor terminals, ensuring that the motor receives adequate power for efficient operation in either direction, while taking into account the output stage saturation drops.
The inclusion of a mechanically-coupled tachometer serves a pivotal role in maintaining speed stability. The tachometer generates feedback that is fed into the first amplifier section, allowing for real-time adjustments to the motor's speed based on its current performance. This feedback loop is essential for achieving consistent motor operation, particularly in applications where speed variations can lead to performance issues.
The adjustment of the motor's speed and direction is facilitated by a 10 kΩ potentiometer connected to the non-inverting input of the operational amplifier. This potentiometer allows for fine-tuning of the input signal, thereby directly influencing the output voltage and, consequently, the speed and direction of the motor.
To ensure the stability of the control loop, an RFCF feedback network is employed. This network is designed to prevent oscillations that can arise due to the dynamic mechanical lag inherent in motor systems. The selection of the RFCF time constant is crucial, as it must be tailored to match the specific characteristics of the motor being used. By doing so, the circuit can effectively compensate for delays in response, ensuring smooth and stable operation across a range of operating conditions.Power op amps provide accurate speed control for dc motors. The circuit provides bidirectional speed control. The amplifiers' push-pull configuration ensures a full rail-to-rail voltage swing (minus the output stages' saturation drops) across the motor in either direction. The circuit uses a mechanically-coupled tachometer to provide speed-stabilizing feedback to the first amplifier section.
The motor's speed and direction of rotation is set by adjusting the 10 k ohm potentiometer at the amplifier's noninverting input. The RFCF feedback network prevents oscillation by compensating for the inherent dynamic mechanical lag of the motor.
Select the RFCF time constant to match the particular motor's characteristics.
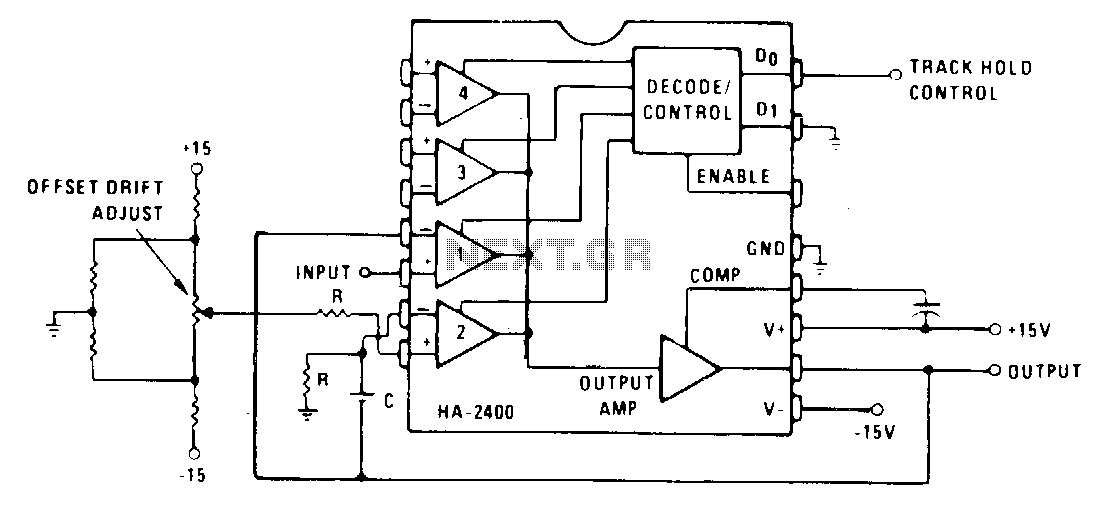
Track-and-hold-sample-and-hold
Channel 1 is configured as a voltage follower and is activated during the track/sample time. If the product of R and C is sufficiently short compared to the period of maximum output frequency or sample time, then C will charge...
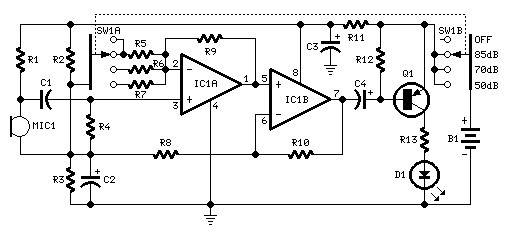
room noise detector
This circuit is designed to indicate, via a flashing LED, when room noise exceeds a predetermined threshold, which can be set to one of three fixed levels: 50, 70, or 85 dB. Two operational amplifiers (op-amps) are utilized to amplify...
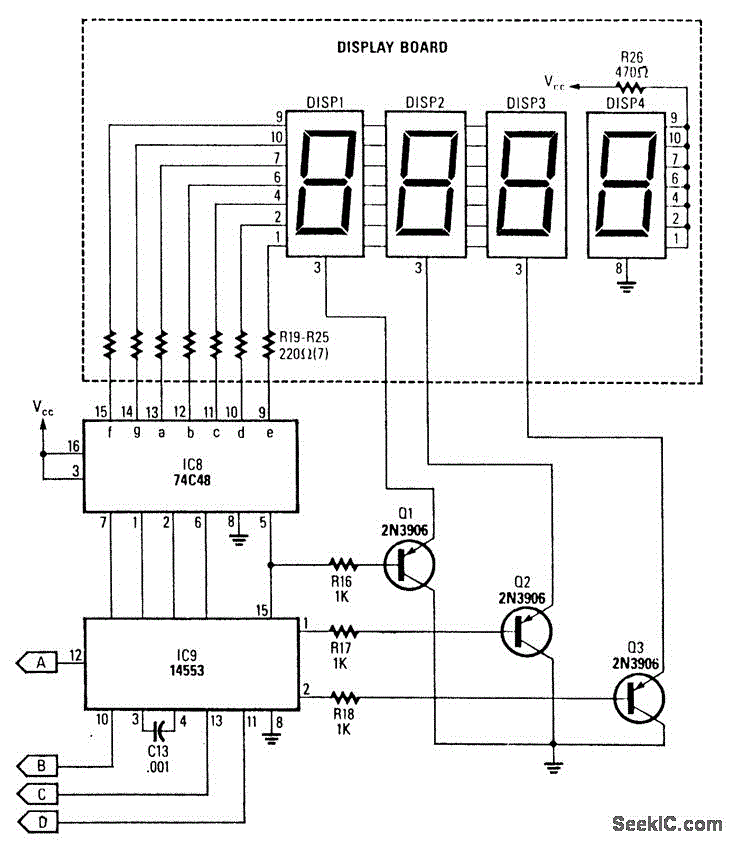
DIGITAL TACHOMETER COUNTER
This circuit generates a readout for a digital tachometer. IC9 functions as a 3-digit LED display driver, counter, and latch. IC8 operates the common cathode LEDs, which are activated by transistors Q1, Q2, and Q3. Refer to page 268, Fig....
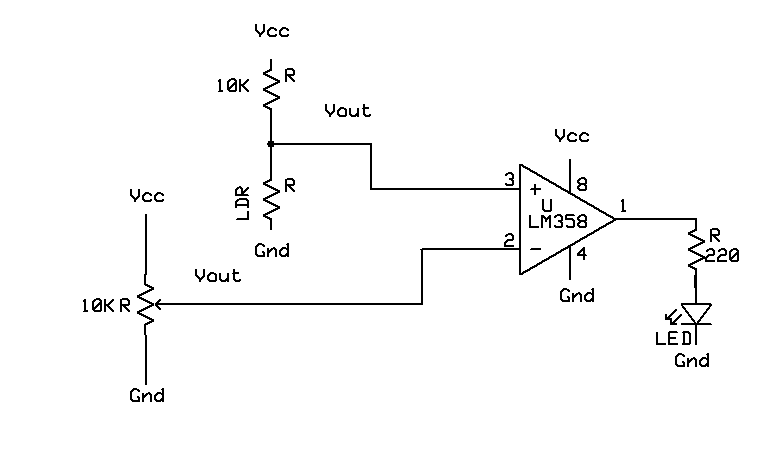
Light sensor using Op Amp
A light-based sensor utilizing an LDR (Light Dependent Resistor) and an operational amplifier (Op Amp). This circuit can be employed for applications such as line followers. The operation of the Op Amp is foundational to this design. It features two...
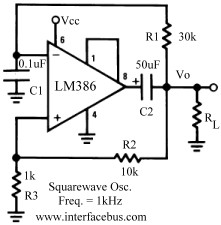
Op-Amp Pulse Generator Circuits
Several operational amplifier circuits are presented here, configured as square wave oscillators. A square wave is a periodic pulse train with a 50 percent duty cycle. The operational amplifier functions as a high-gain amplifier, and oscillation is achieved with minimal...
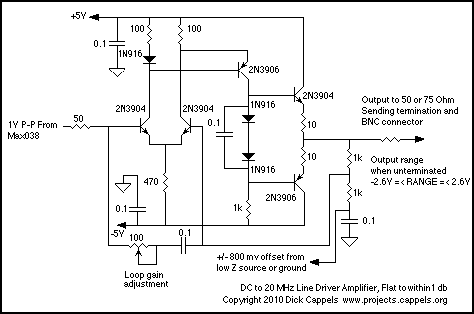
Simple DC to 20 MHz Driver
The output cable from my 20 MHz function/sweep generator dangled over the side of the workbench, the alligator clip hovering over the floor. Deeply engrossed in a project, I moved the power strip on the floor a little closer so...
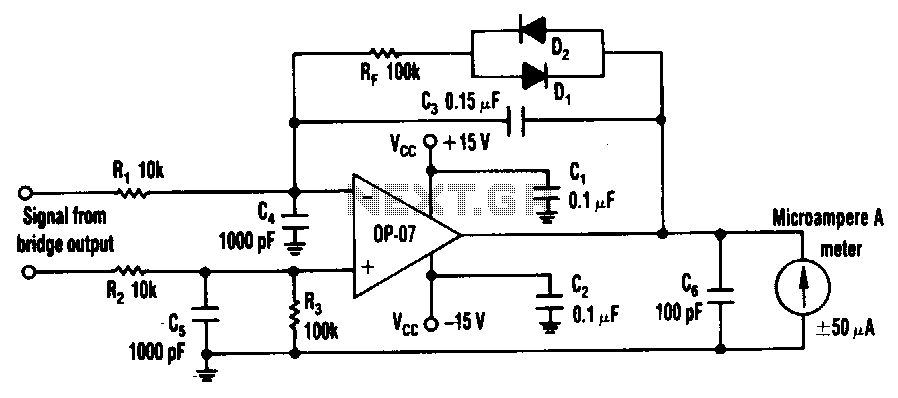
Accurate-variable-gain-circuit
The circuit can utilize any general-purpose, low-offset, low-drift operational amplifier (op amp), such as the OP-07. The differential signal from the bridge feeds into an amplifier that drives a standard, rugged ±50 µA meter. However, near the null point, the...
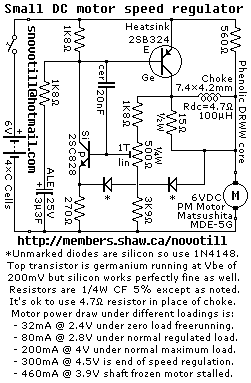
Small DC Motor Speed Regulator
Reverse engineered circuit diagram of a motor speed regulator out of a portable pocket tape recorder containing a single motor for all functions. This circuit works amazingly well, keeping the motor speed constant regardless of shaft load and battery voltage.
The...
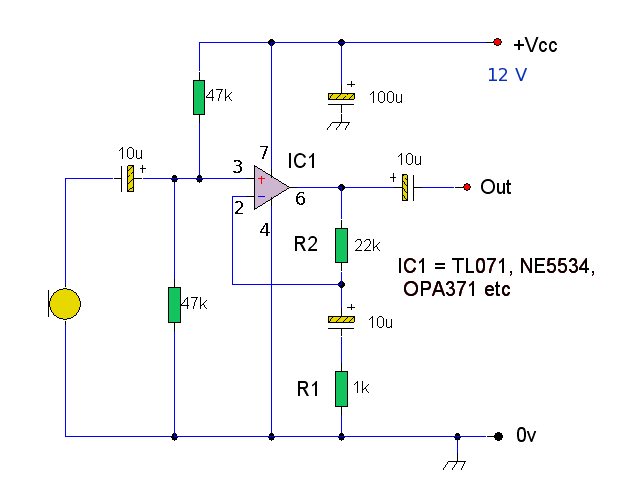
Op-Amp Microphone Preamp
A high-quality microphone preamplifier utilizing a single power supply, suitable for both dynamic and electret microphones. The operational amplifier (op-amp) employed can be any low-noise, high-performance type, such as the NE5534, TL071, or OPA 371. The schematic illustrates the configuration...