


Small DC Motor Speed Regulator
#DC motor
#speed regulator
#constant speed
#battery voltage
#shaft load
#tape recorder
#reverse engineered
#portable device
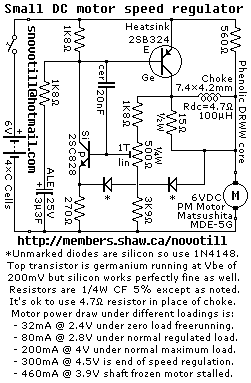
Description: Reverse engineered circuit diagram of a motor speed regulator out of a portable pocket tape recorder containing a single motor for all functions. This circuit works amazingly well, keeping the motor speed constant regardless of shaft load and battery voltage.
The circuit diagram of the motor speed regulator is designed to maintain a consistent motor speed in a portable tape recorder, irrespective of variations in load and supply voltage. The primary components of the circuit typically include an operational amplifier, a variable resistor (potentiometer), a transistor, and feedback mechanisms.
The operational amplifier is configured to monitor the voltage across the motor. It compares the actual speed of the motor, indicated by the voltage, with a reference voltage set by the potentiometer. This reference voltage can be adjusted to set the desired motor speed.
When the load on the motor changes, causing the speed to deviate from the set point, the operational amplifier outputs a control signal. This signal drives the transistor, which acts as a switch to adjust the power supplied to the motor. The transistor's duty cycle is modulated based on the feedback from the operational amplifier, ensuring that the motor receives the appropriate amount of power to maintain the desired speed.
Additionally, the circuit may include protective components such as diodes to prevent back EMF from the motor, which could potentially damage the circuit. Capacitors may also be present to filter noise and stabilize the voltage supply.
The overall design emphasizes efficiency and reliability, allowing the tape recorder to function optimally under various operational conditions. This motor speed regulator circuit exemplifies a robust solution for applications requiring precise speed control in small electronic devices.Reverse engineered circuit diagram of a motor speed regulator out of a portable pocket tape recorder containing a single motor for all functions. This circuit works amazingly well, keeping the motor speed constant regardless of shaft load and battery voltage.
The circuit diagram of the motor speed regulator is designed to maintain a consistent motor speed in a portable tape recorder, irrespective of variations in load and supply voltage. The primary components of the circuit typically include an operational amplifier, a variable resistor (potentiometer), a transistor, and feedback mechanisms.
The operational amplifier is configured to monitor the voltage across the motor. It compares the actual speed of the motor, indicated by the voltage, with a reference voltage set by the potentiometer. This reference voltage can be adjusted to set the desired motor speed.
When the load on the motor changes, causing the speed to deviate from the set point, the operational amplifier outputs a control signal. This signal drives the transistor, which acts as a switch to adjust the power supplied to the motor. The transistor's duty cycle is modulated based on the feedback from the operational amplifier, ensuring that the motor receives the appropriate amount of power to maintain the desired speed.
Additionally, the circuit may include protective components such as diodes to prevent back EMF from the motor, which could potentially damage the circuit. Capacitors may also be present to filter noise and stabilize the voltage supply.
The overall design emphasizes efficiency and reliability, allowing the tape recorder to function optimally under various operational conditions. This motor speed regulator circuit exemplifies a robust solution for applications requiring precise speed control in small electronic devices.Reverse engineered circuit diagram of a motor speed regulator out of a portable pocket tape recorder containing a single motor for all functions. This circuit works amazingly well, keeping the motor speed constant regardless of shaft load and battery voltage.
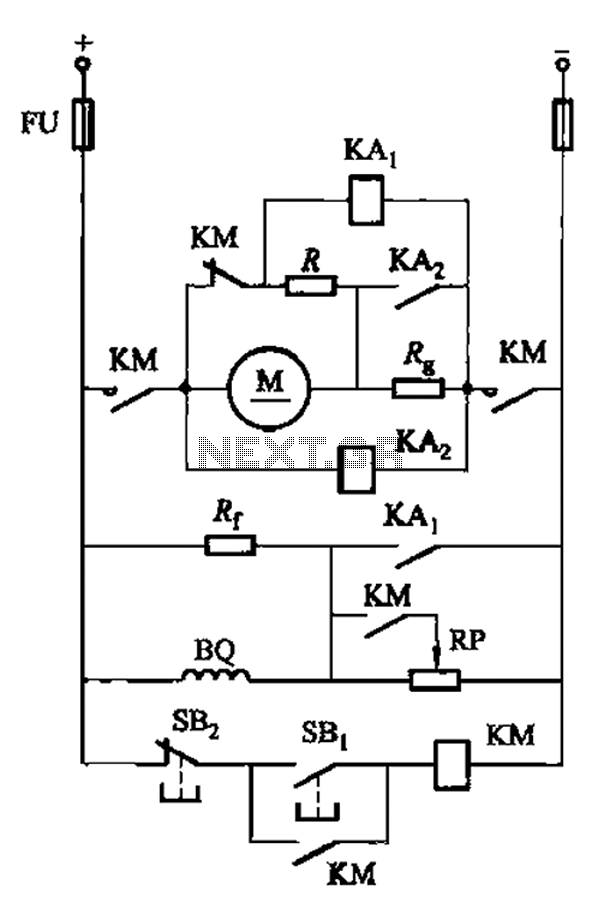
DC motor armature series resistance start dynamic braking circuit of the two-way operation
The circuit illustrated in Figure 3-197 features a dish adjust rheostat (RP) that allows for the adjustment of field current, which in turn modifies the motor speed.
The circuit operates by utilizing a rheostat, which is a variable resistor that can...
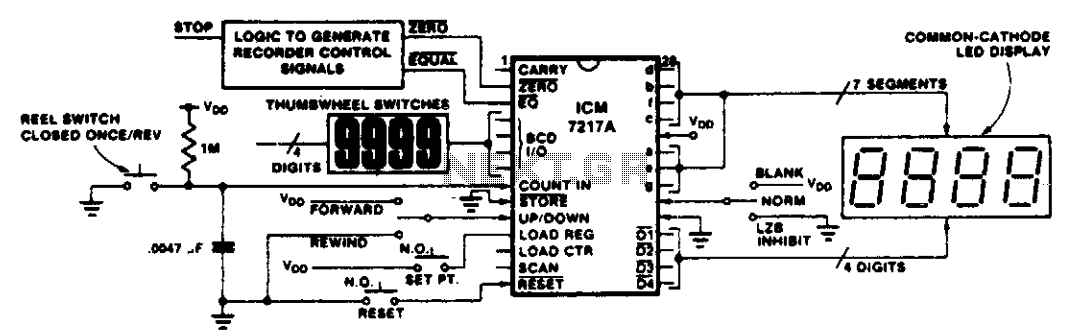
Tape recorder position indicator-controller
This circuit illustrates various applications of up/down counting for monitoring dimensional position. In the tape recorder application, the LOAD REGISTER, EQUAL, and ZERO outputs are utilized to control the recorder. To ensure the recorder stops at a specific point on...
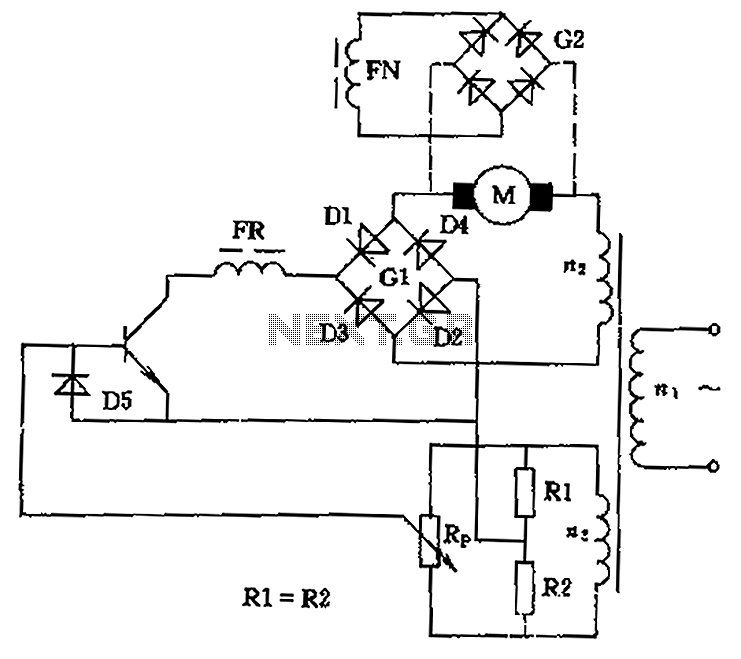
DC motor speed control circuit diagram of a song
The circuit is designed to control the speed and direction of low-power DC motors, including series and shunt motors. It utilizes a rectifier bridge (G1) connected in series with the motor and linked to the secondary winding (n2) of a...
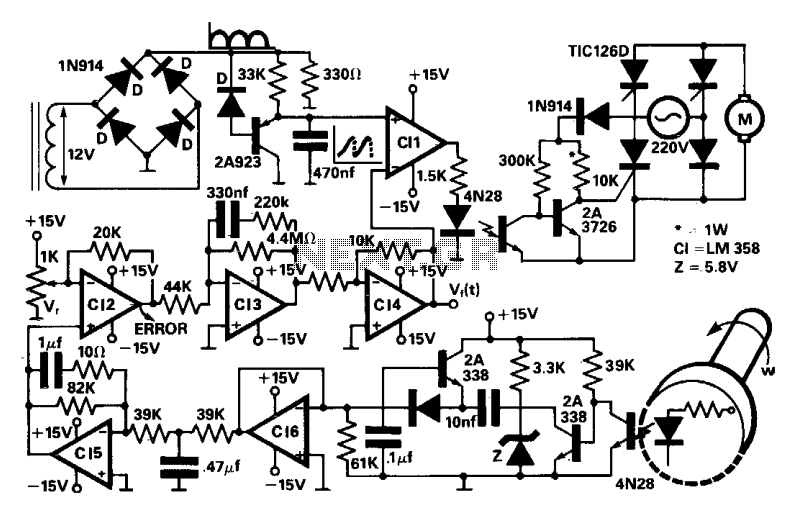
Speed regulator for dc motors
A four thyristor controlled bridge is utilized for operation in two quadrants of the torque-speed characteristics. In the trigger circuits, conventional pulse transformers are substituted with self-biased circuits, which reduce gate power consumption and enhance noise immunity. Electrical isolation is...
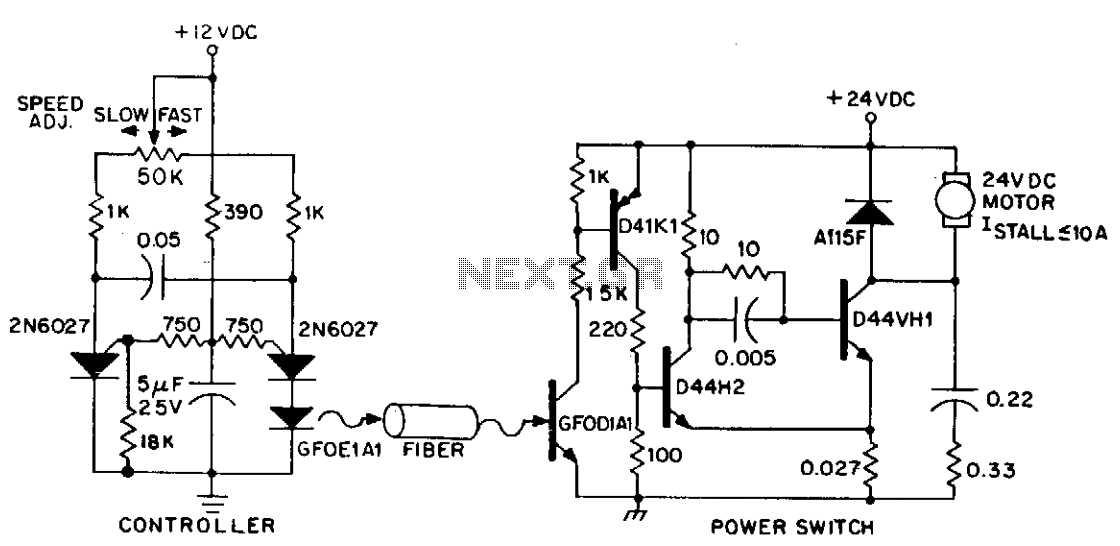
DC variable speed motor control
DC power can also be controlled using fiber optics. The circuit provides an insulated speed control path for a small DC actuator motor (less than Vn hp). The control logic is a self-contained module that requires approximately 300 mW at...
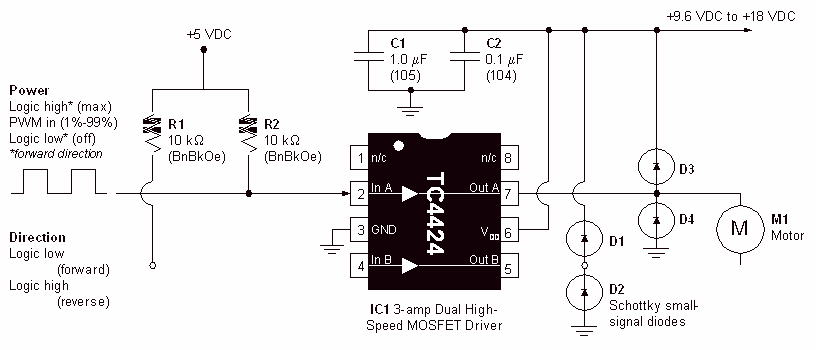
DC Motor-Driver H-Bridge Circuit
Physical motion of some form helps differentiate a robot from a computer. It would be nice if a motor could be attached directly to a chip that controlled the movement. But, most chips can't pass enough current or voltage to...
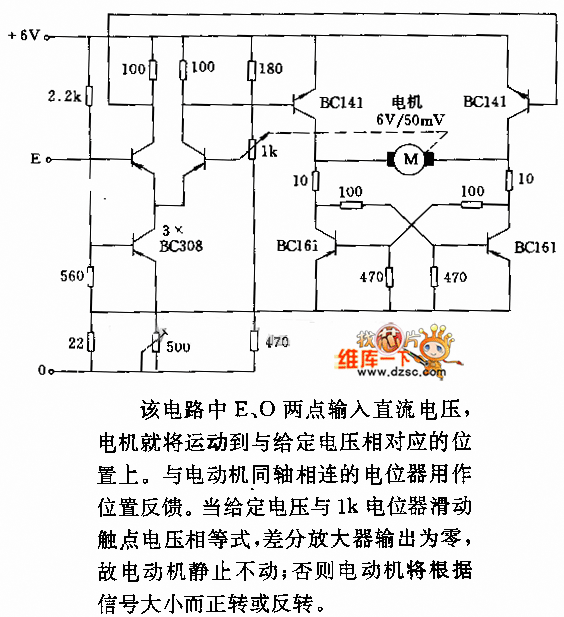
DC motor servo control circuit diagram
In the circuit, when E and O are input DC voltages, the motor moves to a position corresponding to the voltage. A potentiometer, coaxially connected to the motor, is used for position feedback. When the given voltage equals the wiper...
When page is bookmarked text here is referenced verbatim
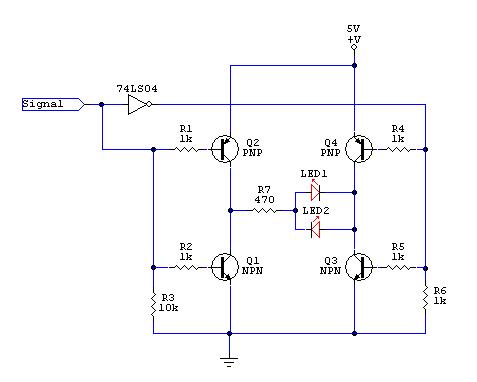
The image shows a completed locked anti-phase motor controller built on a breadboard, utilizing general-purpose transistors to control small DC motors for robotics applications. A typical DC motor controller lacks a braking function, which is essential for precise control. Addressing...
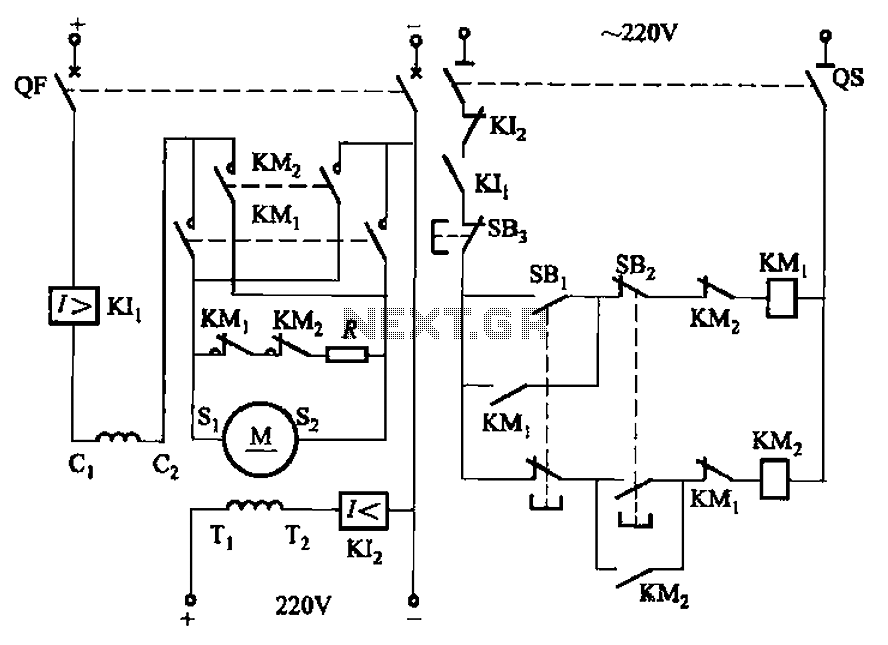
Compound excited DC motor reversing circuit
The circuit depicted in Figure 3-194 features a re-excitation type DC motor with six terminals: S1 and S2 for the armature windings; C1 and C2 for the series excitation (field) windings; and T1 and T2 for the shunt (field) winding....