


Compound excited DC motor reversing circuit
#DC motor
#reversing circuit
#armature windings
#field windings
#compound excitation
#motor terminals
#electrical engineering
#motor driver
#power electronics
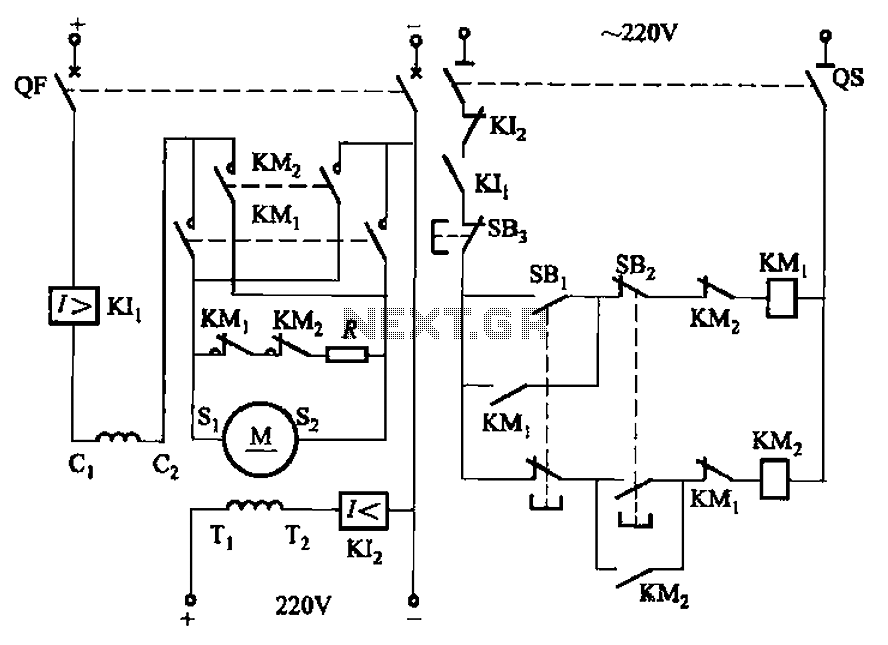
Description: The circuit depicted in Figure 3-194 features a re-excitation type DC motor with six terminals: S1 and S2 for the armature windings; C1 and C2 for the series excitation (field) windings; and T1 and T2 for the shunt (field) winding. To facilitate both positive and negative operation, the direction of the magnetic field generated by C1, C2 and T1, T2 remains fixed while the current direction in the armature windings S1 and S2 is altered. This circuit operates in reverse brake mode. When the motor is stopped, the armature terminals are shorted through a braking resistor R, allowing the motor to come to a rapid halt. The circuit is equipped with overcurrent protection (K1) and weakening protection (K2).
The circuit in question is designed for a re-excitation type DC motor, characterized by its six-terminal configuration which allows for versatile control over both the armature and field windings. The armature windings, connected to terminals S1 and S2, are responsible for converting electrical energy into mechanical energy. The series field windings connected to terminals C1 and C2 provide a magnetic field that is directly proportional to the armature current, enhancing the motor's performance during varying load conditions. The shunt field windings, connected to terminals T1 and T2, provide a more stable magnetic field, which is essential for maintaining consistent motor operation.
In this design, the magnetic field direction is maintained constant for the series and shunt windings, allowing for efficient control of the armature current. By reversing the current direction in the armature windings, the motor can be operated in both forward and reverse directions. The reverse brake mode is particularly beneficial for applications requiring quick stops, as it enables the motor to decelerate rapidly by shorting the armature through a braking resistor R. This method of braking dissipates the kinetic energy of the motor as heat in the resistor, leading to a swift halt.
Furthermore, the circuit includes protective features such as overcurrent protection (K1) and weakening protection (K2). The overcurrent protection device (K1) safeguards the motor from excessive current that could cause overheating or damage, while the weakening protection device (K2) prevents the magnetic field from becoming too weak, which could lead to instability in motor operation. Overall, this circuit design ensures reliable and efficient operation of the re-excitation type DC motor in various applications, while also prioritizing safety and performance stability. Circuit shown in Figure 3-194. Motor is re-excitation type DC motor. The motor has six terminals, sl, S2 for the armature windings; cl, cz for the series excitation (field) win ding; Ti, Tz for the shunt (field) winding. In order to achieve positive and negative to the operation of the cl, C2 and Ti, Tz magnetic field direction is fixed, while changing the current direction of the armature S1, S2 winding. This circuit take reverse brake mode. When stopped, the motor armature ends by short braking resistor R and the motor is stopped soon. The line has overcurrent protection (KIl) and weakening protection (KI2).
The circuit in question is designed for a re-excitation type DC motor, characterized by its six-terminal configuration which allows for versatile control over both the armature and field windings. The armature windings, connected to terminals S1 and S2, are responsible for converting electrical energy into mechanical energy. The series field windings connected to terminals C1 and C2 provide a magnetic field that is directly proportional to the armature current, enhancing the motor's performance during varying load conditions. The shunt field windings, connected to terminals T1 and T2, provide a more stable magnetic field, which is essential for maintaining consistent motor operation.
In this design, the magnetic field direction is maintained constant for the series and shunt windings, allowing for efficient control of the armature current. By reversing the current direction in the armature windings, the motor can be operated in both forward and reverse directions. The reverse brake mode is particularly beneficial for applications requiring quick stops, as it enables the motor to decelerate rapidly by shorting the armature through a braking resistor R. This method of braking dissipates the kinetic energy of the motor as heat in the resistor, leading to a swift halt.
Furthermore, the circuit includes protective features such as overcurrent protection (K1) and weakening protection (K2). The overcurrent protection device (K1) safeguards the motor from excessive current that could cause overheating or damage, while the weakening protection device (K2) prevents the magnetic field from becoming too weak, which could lead to instability in motor operation. Overall, this circuit design ensures reliable and efficient operation of the re-excitation type DC motor in various applications, while also prioritizing safety and performance stability. Circuit shown in Figure 3-194. Motor is re-excitation type DC motor. The motor has six terminals, sl, S2 for the armature windings; cl, cz for the series excitation (field) win ding; Ti, Tz for the shunt (field) winding. In order to achieve positive and negative to the operation of the cl, C2 and Ti, Tz magnetic field direction is fixed, while changing the current direction of the armature S1, S2 winding. This circuit take reverse brake mode. When stopped, the motor armature ends by short braking resistor R and the motor is stopped soon. The line has overcurrent protection (KIl) and weakening protection (KI2).
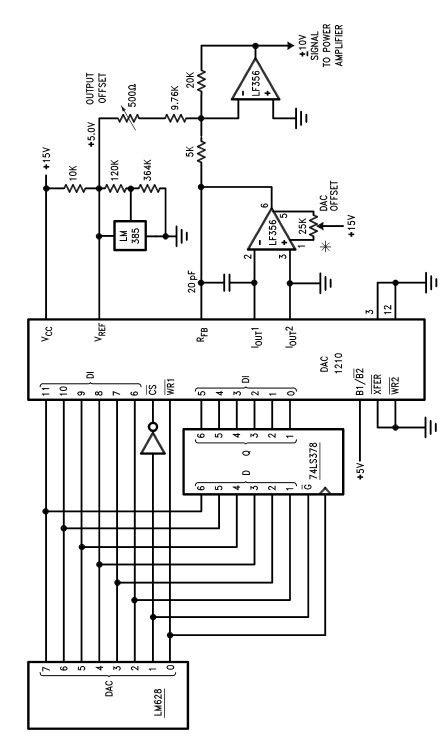
DC motor driver circuit design using LM628 LM629 dedicated motion-control processors
The LM628 and LM629 dedicated motion-control processors can be utilized to design various applications involving DC and brushless DC servo motors, as well as other servomechanisms. The power path of this electronic project, which functions as a motor driver, is...
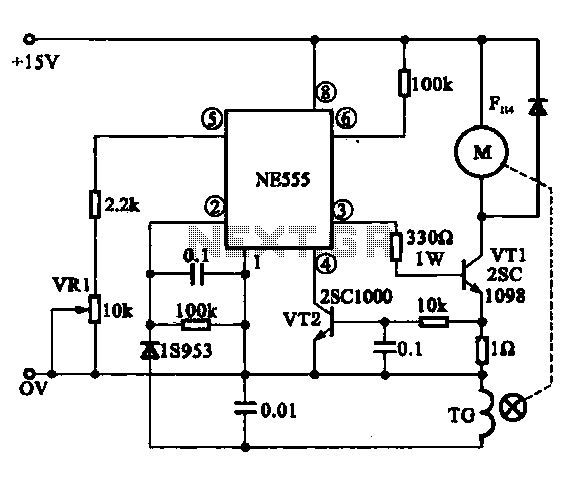
Miniature DC Motor Speed Control circuit
The Miniature DC Motor Speed Control circuit is designed to maintain a steady speed for micro motors, as illustrated in Figure 8-32. The circuit utilizes a voltage feedback mechanism suitable for applications such as tape recording machines that employ miniature...
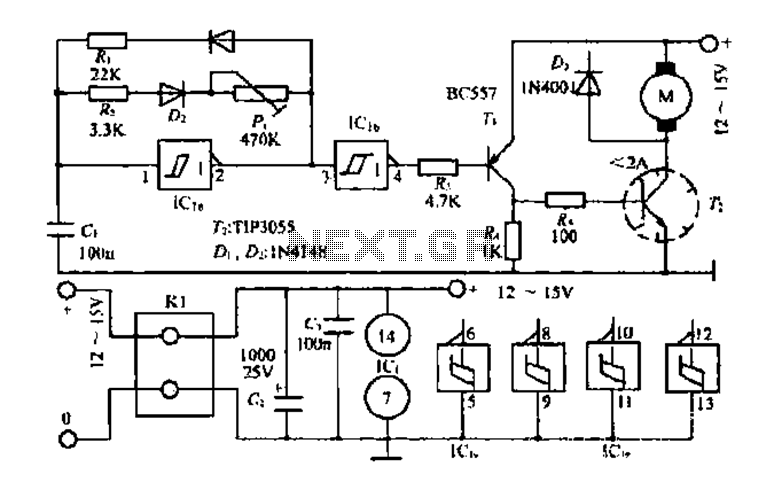
A small DC motor control circuit a
The core multi-resonant circuit 40 L06 has a collapse time of 1C. An auxiliary electric signal operates below its low threshold, opening Icl. The output is provided through two terminals for business use. The circuit includes components such as CI,...
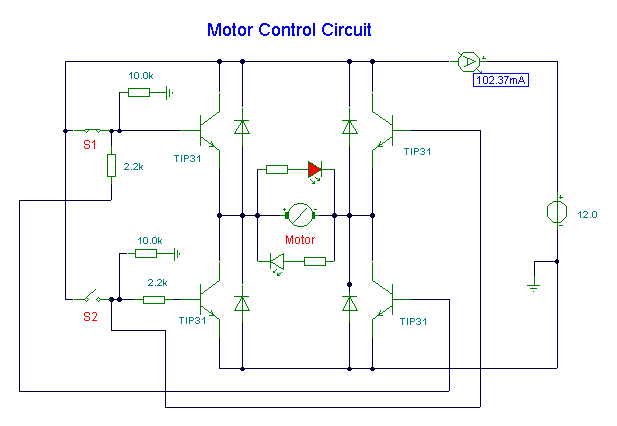
dc motor control circuit
S1 and S2 are normally open, push-to-close, momentary switches. The diodes can be red or green and serve solely as indicators for direction. The TIP31 transistors may need to be adjusted based on the motor specifications. It is important to...
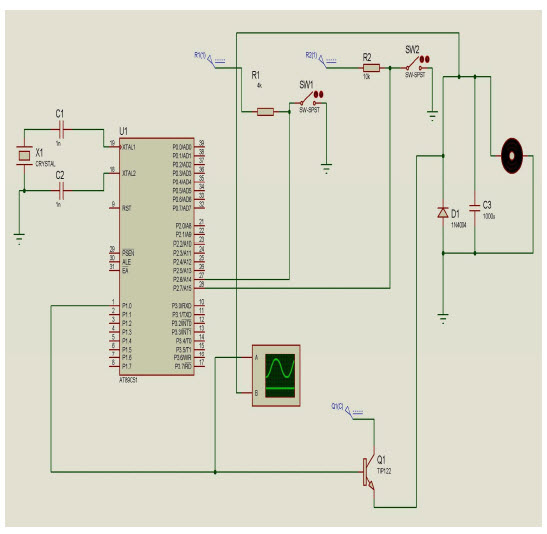
Speed Control of DC Motor using Microcontroller 8051 withCircuit
The objective of this project is to control the speed of a DC motor. The primary benefit of utilizing a DC motor is the ability to modify the Speed-Torque relationship to nearly any desired form. To facilitate speed control, an...
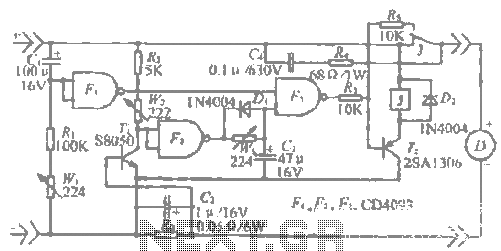
A high-power DC motor overcurrent protection circuit
The "R-h sampling circuit limit order" aims to reduce the sampling resistor. A DC voltage level can be positioned between the components. The circuit includes a line amplifier that allows for magnification adjustments and is designed to protect against current...
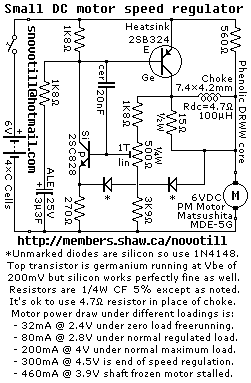
Small DC Motor Speed Regulator
Reverse engineered circuit diagram of a motor speed regulator out of a portable pocket tape recorder containing a single motor for all functions. This circuit works amazingly well, keeping the motor speed constant regardless of shaft load and battery voltage.
The...
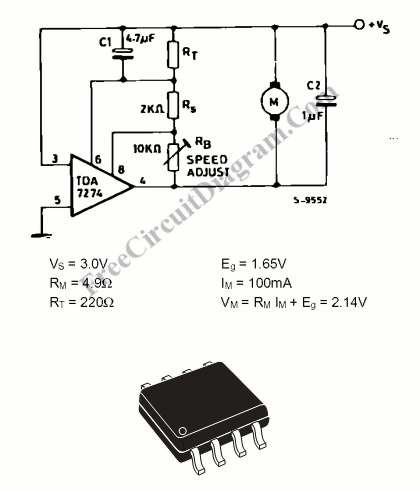
Small DC Motor Speed Controller
Electric motors have been widely used for motion control, and various types of motor controllers have been designed to provide variable speed drives for these motors.
Electric motors are integral to numerous applications requiring precise motion control, ranging from industrial automation...
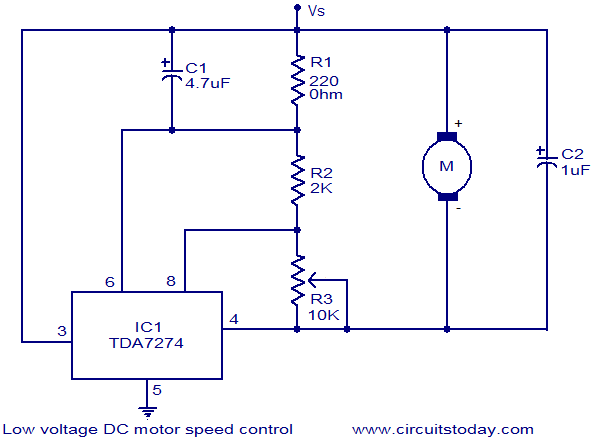
Low voltage DC motor speed control circuit
The circuit diagram illustrates a low voltage/low power DC motor speed controller utilizing the TDA 7274 integrated circuit from ST Microelectronics. The TDA 7274 is designed for low voltage and low power applications, featuring an internal voltage reference, a broad...