


Small DC Motor Speed Controller
#DC motor
#speed control
#PWM
#variable speed
#motor driver
#controller
#motion control
#electric motor
#drive circuit
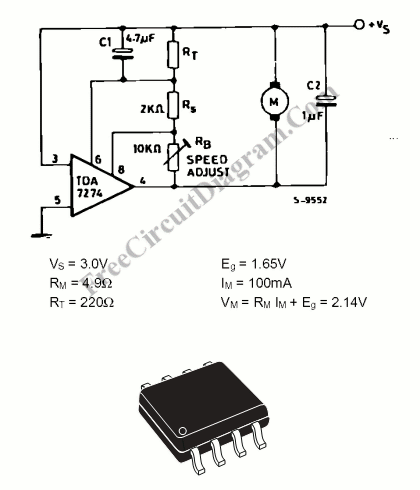
Description: Electric motors have been widely used for motion control, and various types of motor controllers have been designed to provide variable speed drives for these motors.
Electric motors are integral to numerous applications requiring precise motion control, ranging from industrial automation to consumer electronics. The ability to modulate the speed and torque of electric motors is essential for optimizing performance and energy efficiency. Motor controllers serve as the interface between the power supply and the motor, allowing for the adjustment of operational parameters based on the specific requirements of the application.
There are several types of motor controllers, including but not limited to:
1. **DC Motor Controllers**: These controllers utilize pulse width modulation (PWM) techniques to adjust the voltage applied to the motor, thus controlling its speed. They are commonly used in battery-operated devices and applications where variable speed is required.
2. **AC Motor Controllers**: These controllers manage the speed of AC motors by varying the frequency and voltage of the power supplied to the motor. Variable Frequency Drives (VFDs) are a popular example, allowing for smooth acceleration and deceleration, which enhances the longevity of the motor and reduces mechanical stress.
3. **Stepper Motor Controllers**: Designed for stepper motors, these controllers manage the precise positioning of the motor by sending a series of pulses that dictate the motor's movements. They are widely used in applications requiring high precision, such as 3D printers and CNC machines.
4. **Servo Motor Controllers**: These controllers are used in conjunction with feedback systems to maintain the desired position, speed, or torque of the motor. They are essential in robotics and automation, where accuracy and responsiveness are critical.
The design of motor controllers can vary significantly based on the application requirements, including factors such as load characteristics, operating environment, and desired control algorithms. Advanced motor controllers may incorporate microcontrollers or digital signal processors (DSPs) for enhanced control capabilities, allowing for complex algorithms that can adapt to changing load conditions.
In conclusion, the development of motor controllers has evolved to meet the demands of modern applications, providing efficient and precise control of electric motors across various sectors. The choice of motor controller is crucial in achieving optimal performance and reliability in motion control systems.Electric motor has been widely used as motion control, and many? type of motor controllers? have been designed to provide variable speed drives for the motor
Electric motors are integral to numerous applications requiring precise motion control, ranging from industrial automation to consumer electronics. The ability to modulate the speed and torque of electric motors is essential for optimizing performance and energy efficiency. Motor controllers serve as the interface between the power supply and the motor, allowing for the adjustment of operational parameters based on the specific requirements of the application.
There are several types of motor controllers, including but not limited to:
1. **DC Motor Controllers**: These controllers utilize pulse width modulation (PWM) techniques to adjust the voltage applied to the motor, thus controlling its speed. They are commonly used in battery-operated devices and applications where variable speed is required.
2. **AC Motor Controllers**: These controllers manage the speed of AC motors by varying the frequency and voltage of the power supplied to the motor. Variable Frequency Drives (VFDs) are a popular example, allowing for smooth acceleration and deceleration, which enhances the longevity of the motor and reduces mechanical stress.
3. **Stepper Motor Controllers**: Designed for stepper motors, these controllers manage the precise positioning of the motor by sending a series of pulses that dictate the motor's movements. They are widely used in applications requiring high precision, such as 3D printers and CNC machines.
4. **Servo Motor Controllers**: These controllers are used in conjunction with feedback systems to maintain the desired position, speed, or torque of the motor. They are essential in robotics and automation, where accuracy and responsiveness are critical.
The design of motor controllers can vary significantly based on the application requirements, including factors such as load characteristics, operating environment, and desired control algorithms. Advanced motor controllers may incorporate microcontrollers or digital signal processors (DSPs) for enhanced control capabilities, allowing for complex algorithms that can adapt to changing load conditions.
In conclusion, the development of motor controllers has evolved to meet the demands of modern applications, providing efficient and precise control of electric motors across various sectors. The choice of motor controller is crucial in achieving optimal performance and reliability in motion control systems.Electric motor has been widely used as motion control, and many? type of motor controllers? have been designed to provide variable speed drives for the motor
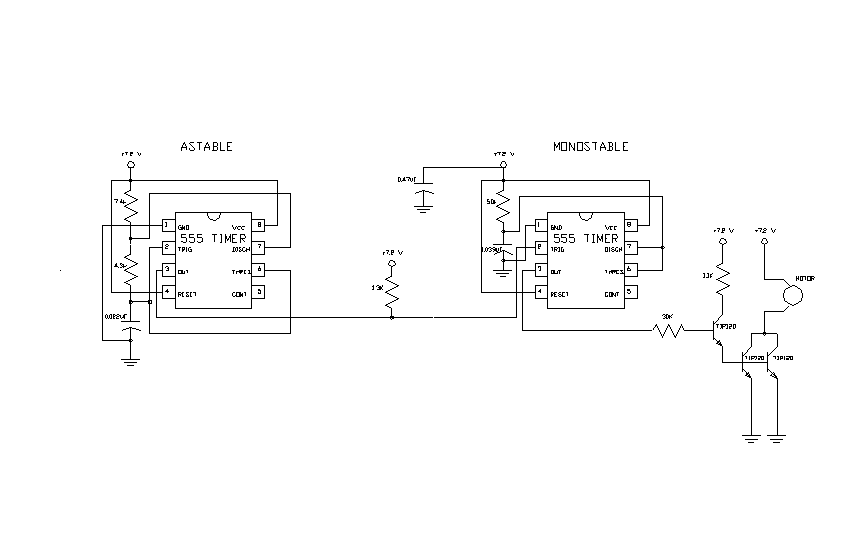
pulse width modulated (PWM) controller for high current
The second 555 timer was configured as a monostable circuit, commonly referred to as a one-shot since an output pulse only occurs if there is a trigger on the input. When this timer is triggered, the potentiometer in the RC...
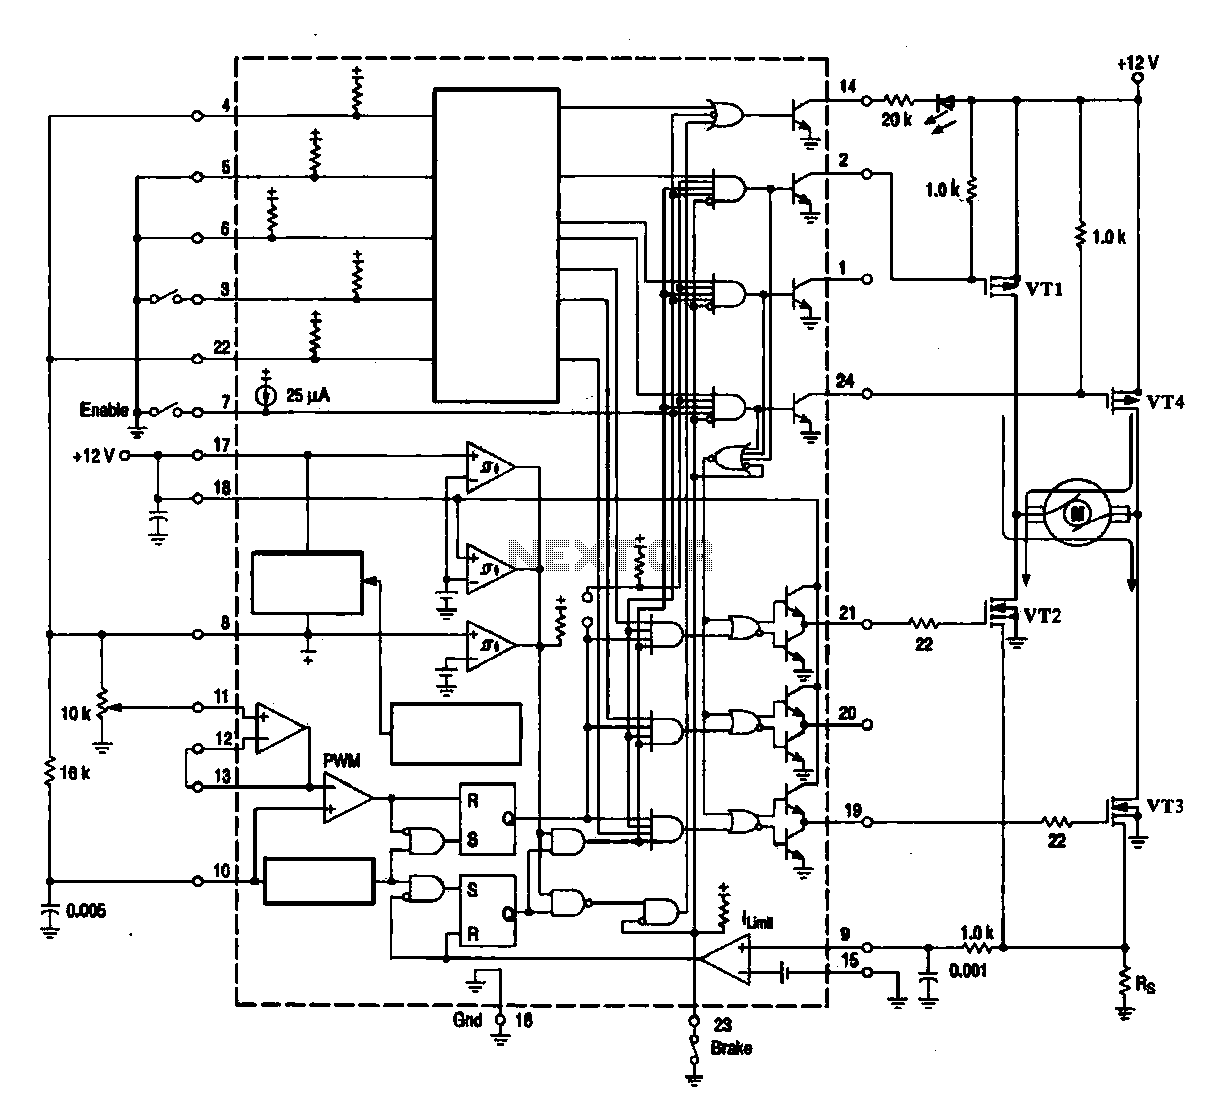
DC brush motor driver circuit diagram
A DC brush motor driver circuit diagram utilizing the MC33035 chip is presented, illustrating a typical configuration for driving a straight DC brush motor. The circuit incorporates a field-effect transistor (FET) bridge driver setup. When transistor VT3 is activated, the...
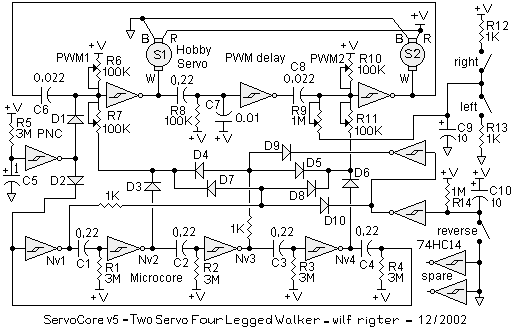
Servocore 2-motor walker circuit
There is an advantage in using continuously active PWM signals. The main reason is that the asynchronous frequencies of the PWM core and microcore can sometimes result in a shortened PWM pulse. The servo recognizes this as a command for...
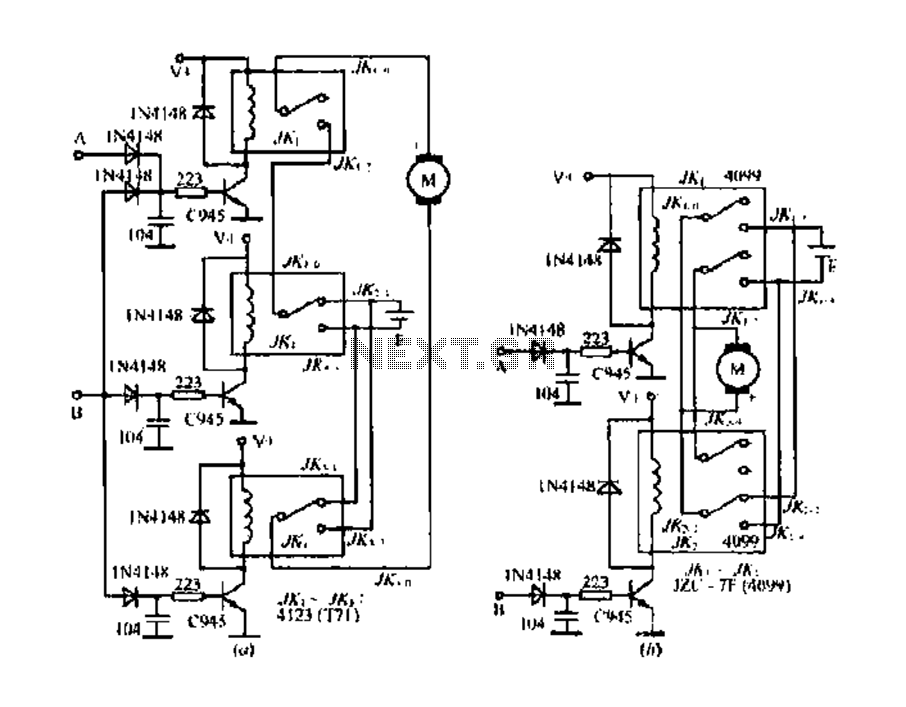
Two models of DC motor reversing control circuit
The DC motor E inversion control circuit utilizes a loop configuration with various relay contacts. It employs a single set of normally open/normally closed relay contacts. When both inputs A and B are low, relay KI is activated. In this...
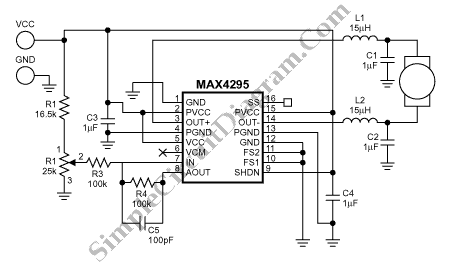
PWM Motor Speed Control Using Class D Audio Amplifier
This is a Class D audio amplifier circuit used to control the PWM motor speed. This circuit has two advantages for battery-powered portable devices. First, it provides high efficiency, which extends battery life.
The Class D audio amplifier operates by modulating...
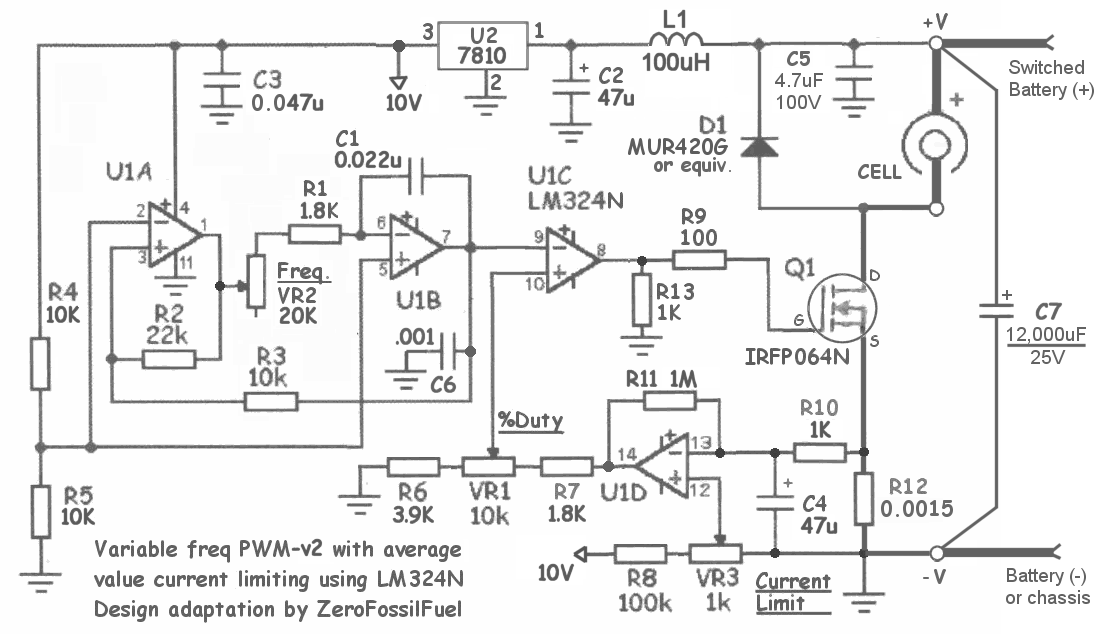
PWM v2.1 plans
Detailed plans to build devices for HHO, HOH, HOD, PWM pulse width modulators, and EFIE electronic fuel injection enhancers.
The schematic for constructing devices related to HHO (Hydrogen-Hydrogen-Oxygen) production, HOH (Water), HOD (Hydrogen-Oxygen-Diatomic), PWM (Pulse Width Modulation) controllers, and EFIE (Electronic...
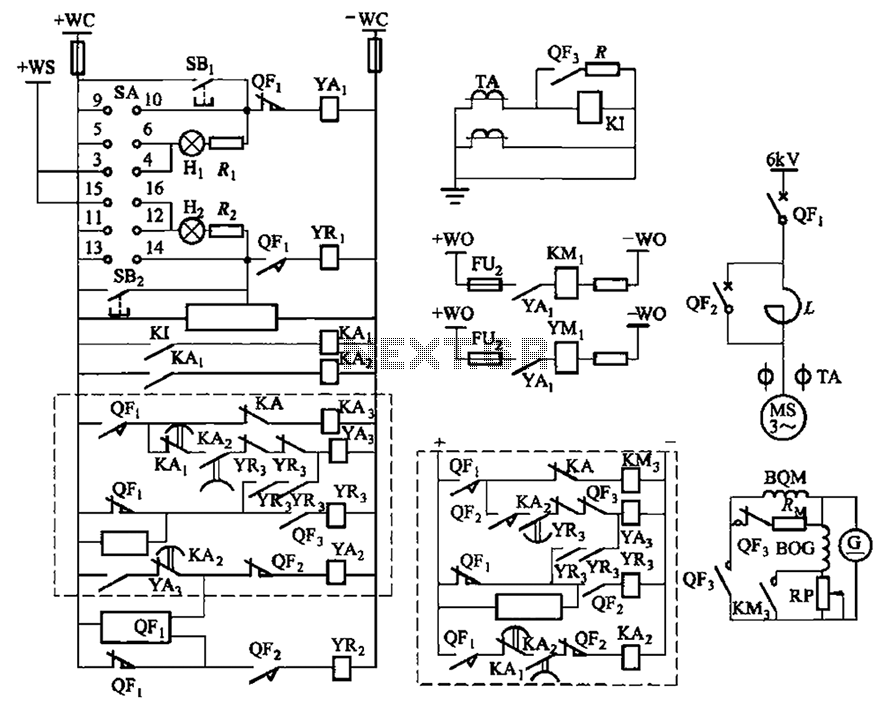
Synchronous electric motor chokes down according to the stator current excitation circuit
The circuit depicted in Figure 3-189 includes various components such as switch SA, closing button SBi, trip button SBz, de-excitation switch Yaa, and off trip coil YR3. The excitation switch contacts are represented by QF3, which serves as a circuit...
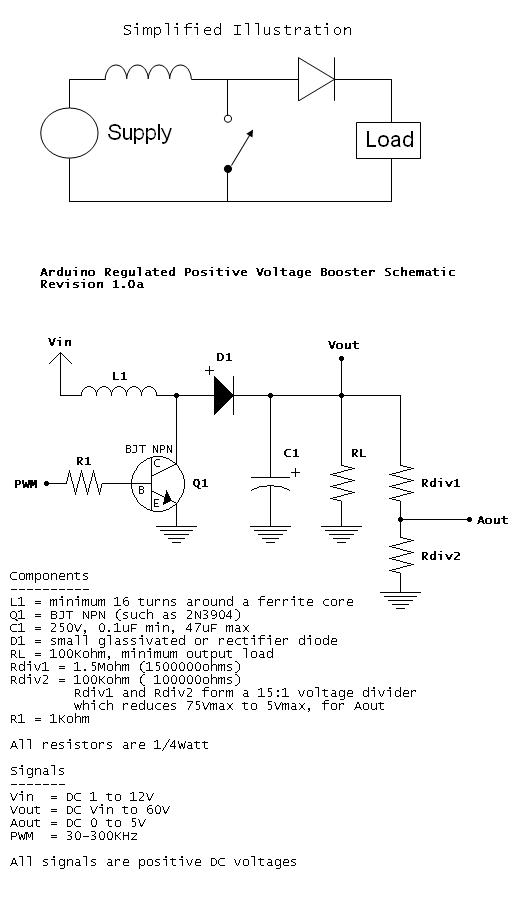
Regulated Positive Voltage Booster
When Q1 is active, a larger current begins to flow through L1 to ground. When Q1 is switched off, the current through L1 tries to remain constant, resulting in an increased voltage. By varying the PWM duty cycle, the current...
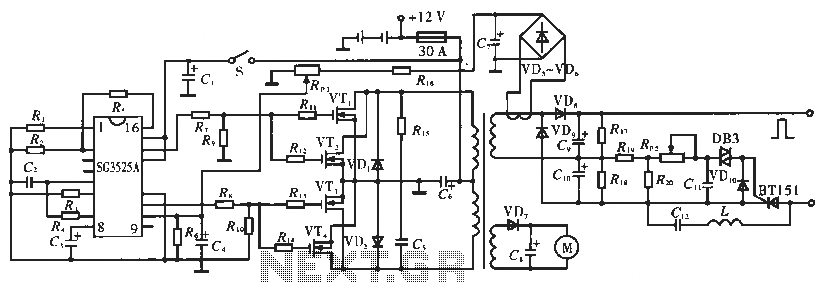
Electronic pulse circuitry fishing
The circuit utilizes the SC3525A, a PWM silicon chip from US General Semiconductor. It features an error amplifier with an inverting input at pin 1. Pin 2 serves as the non-inverting input for the error amplifier. Pins 5 and 6...