


DC motor 12V speed controller circuit with explanation
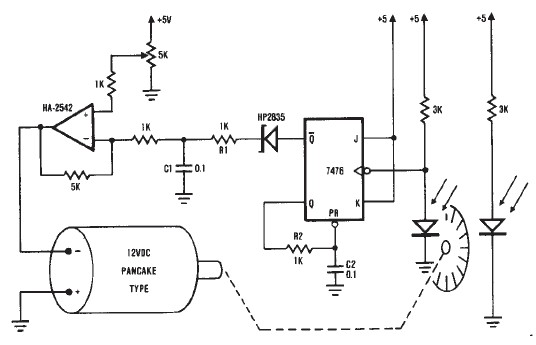
Description: A simple encoder circuit for a DC motor can be constructed using this circuit diagram. The system consists of the HA-2542, a small 12-V DC motor, and a position encoder. During operation, the encoder generates a series of constant-width pulses that charge capacitor CI. These integrated pulses develop a reference voltage proportional to motor speed, which is applied to the inverting input of the HA-2542. The non-inverting input is maintained at a constant voltage representing the desired motor speed. The difference between these two inputs sends a corrected drive signal to the motor, completing the speed control system loop. The circuit requires few external components; however, due to the encoder wheel, it has limitations in use. By placing a pulley under the encoder wheel, the speed of another device can be controlled by connecting the motor and the other device using a belt.
The described encoder circuit operates as a feedback control system for a DC motor, utilizing the HA-2542 operational amplifier to maintain the desired speed efficiently. The position encoder is critical in this setup, as it translates the motor's rotational position into electrical pulses. These pulses are characterized by a consistent width, allowing for precise timing and frequency measurement.
The capacitor CI serves as a charge storage element, integrating the pulses from the encoder to produce a smooth voltage signal that reflects the average speed of the motor. This voltage is then fed into the inverting input of the HA-2542. The non-inverting input is set to a reference voltage, which can be adjusted to represent the target speed of the motor. The operational amplifier compares these two signals, and any difference results in an output that adjusts the motor's drive signal accordingly. This feedback mechanism ensures that the motor operates at the desired speed, compensating for any variations due to load changes or other factors.
In terms of component selection, the HA-2542 is chosen for its high performance in terms of gain and bandwidth, making it suitable for real-time speed control applications. The circuit's simplicity is advantageous, as it minimizes the number of external components required, which can lead to reduced complexity and cost.
The limitations mentioned regarding the encoder wheel can be addressed by employing a pulley system. By attaching a pulley to the encoder wheel, it becomes possible to use the motor's output to drive another device, such as a conveyor belt or a fan. This versatility allows the circuit to be applied in various applications beyond just motor speed control, enhancing its utility in automated systems. The use of a belt to connect the motor to other devices provides a mechanical means to transfer motion and control speed, further expanding the functionality of the circuit.A very simple encoder circuit for a dc motor can be constructed using this circuit diagram. As you can see in the circuit diagram, the system shown consists of the HA-2542, a small 12-Vdc motor, and a position encoder. During operation, the encoder causes a series of ``constant-width" pulses to charge CI. The integrated pulses develop a referenc e voltage, which is propor £ional to motor speed and is applied to the inverting input of HA-2542, The noninverting input is held at a constant voltage, which represents the desired motor speed. A difference between these two inputs will send a corrected drive signal to the motor, which completes the speed control system loop.
As you can see the circuit requires few external components, but because of the encoder wheel it has a limitations of use. If you put a pulley under the encoder wheel you can command the speed of other device, by connecting the (motor and other device ) using a belt
The described encoder circuit operates as a feedback control system for a DC motor, utilizing the HA-2542 operational amplifier to maintain the desired speed efficiently. The position encoder is critical in this setup, as it translates the motor's rotational position into electrical pulses. These pulses are characterized by a consistent width, allowing for precise timing and frequency measurement.
The capacitor CI serves as a charge storage element, integrating the pulses from the encoder to produce a smooth voltage signal that reflects the average speed of the motor. This voltage is then fed into the inverting input of the HA-2542. The non-inverting input is set to a reference voltage, which can be adjusted to represent the target speed of the motor. The operational amplifier compares these two signals, and any difference results in an output that adjusts the motor's drive signal accordingly. This feedback mechanism ensures that the motor operates at the desired speed, compensating for any variations due to load changes or other factors.
In terms of component selection, the HA-2542 is chosen for its high performance in terms of gain and bandwidth, making it suitable for real-time speed control applications. The circuit's simplicity is advantageous, as it minimizes the number of external components required, which can lead to reduced complexity and cost.
The limitations mentioned regarding the encoder wheel can be addressed by employing a pulley system. By attaching a pulley to the encoder wheel, it becomes possible to use the motor's output to drive another device, such as a conveyor belt or a fan. This versatility allows the circuit to be applied in various applications beyond just motor speed control, enhancing its utility in automated systems. The use of a belt to connect the motor to other devices provides a mechanical means to transfer motion and control speed, further expanding the functionality of the circuit.A very simple encoder circuit for a dc motor can be constructed using this circuit diagram. As you can see in the circuit diagram, the system shown consists of the HA-2542, a small 12-Vdc motor, and a position encoder. During operation, the encoder causes a series of ``constant-width" pulses to charge CI. The integrated pulses develop a referenc e voltage, which is propor £ional to motor speed and is applied to the inverting input of HA-2542, The noninverting input is held at a constant voltage, which represents the desired motor speed. A difference between these two inputs will send a corrected drive signal to the motor, which completes the speed control system loop.
As you can see the circuit requires few external components, but because of the encoder wheel it has a limitations of use. If you put a pulley under the encoder wheel you can command the speed of other device, by connecting the (motor and other device ) using a belt
Light Flashing Car 12 Volt using LM3900
If you have ever used a 12V flasher relay system, typically a mechanical type, for general automotive applications, today we will attempt to build a 12V flasher relay circuit.
The 12V flasher relay circuit is a crucial component in automotive lighting...
the dc motor circuit
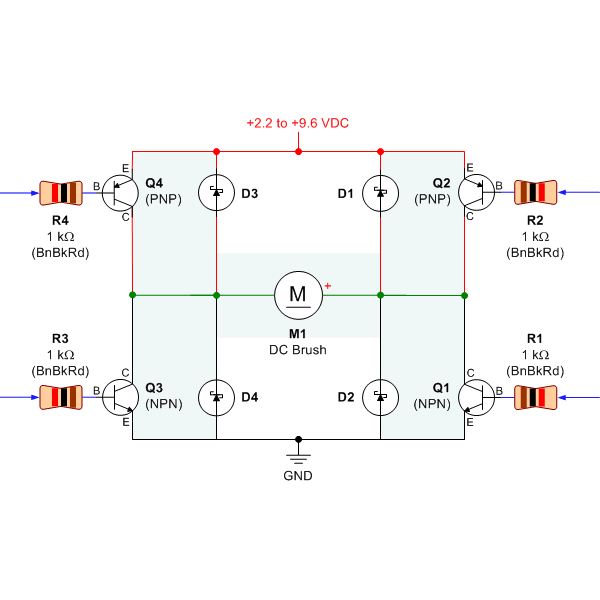
Selecting the appropriate DC motor is essential for constructing mobile robots. Testing DC motors is straightforward and can be accomplished by assembling a basic DC motor circuit. The components needed for this circuit include a DC motor, a battery power...
Dc-motor-drive-with-fixed-speed-control
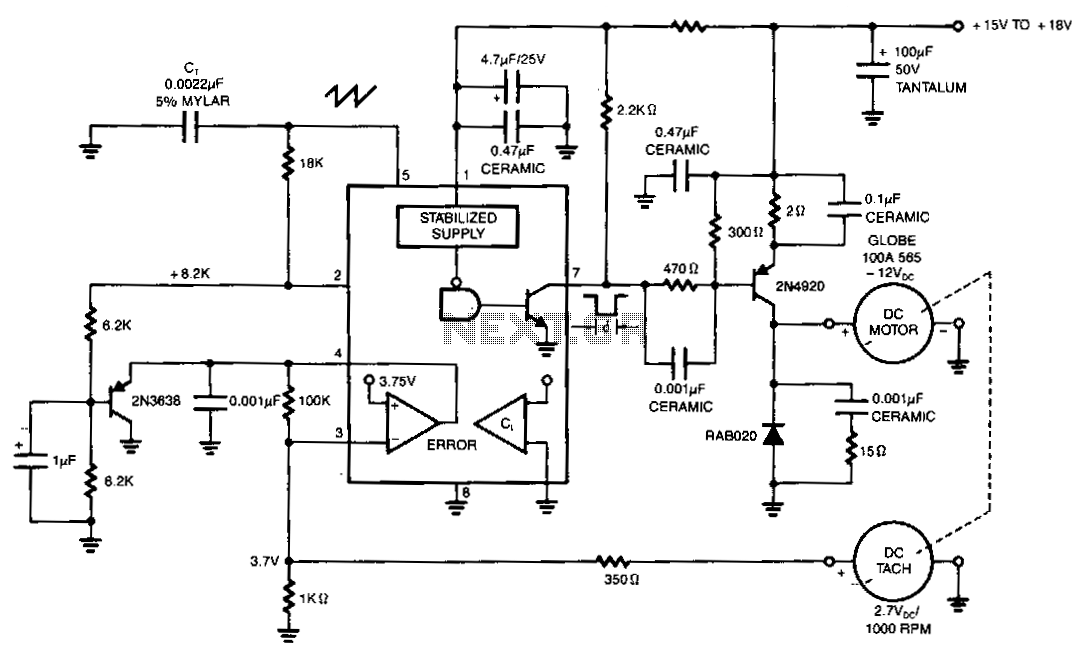
The NE5561 provides pulse-proportional drive and speed control based on DC tachometer feedback. This simple switching circuit consists of a 2N4920 PNP transistor with a commutation diode, which is used to deliver programmed pulse energy to the motor. A frequency...
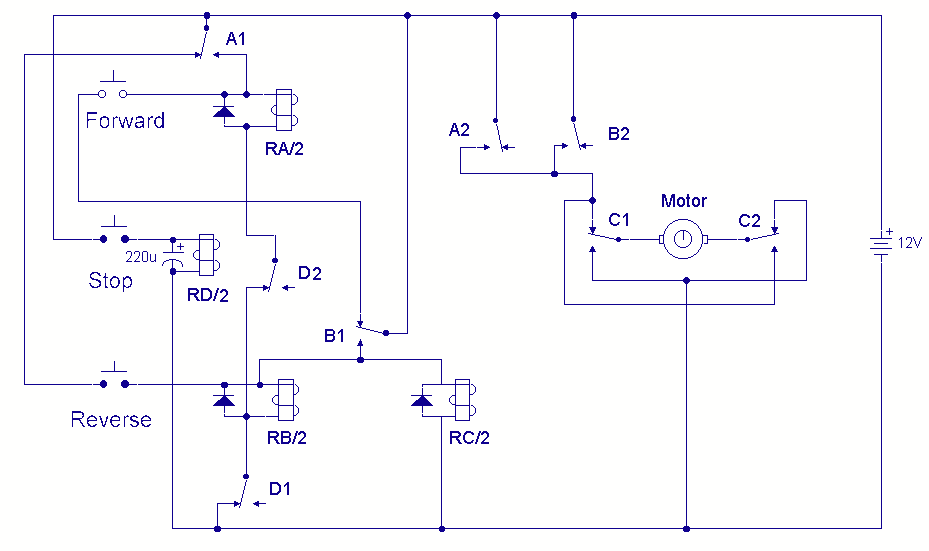
DC Motor Reversing Circuit
A DC motor reversing circuit using non-latching push button switches. Relays control forward, stop, and reverse action, and the motor cannot be switched from forward to reverse unless the stop switch is pressed first.
The described circuit employs a system of...
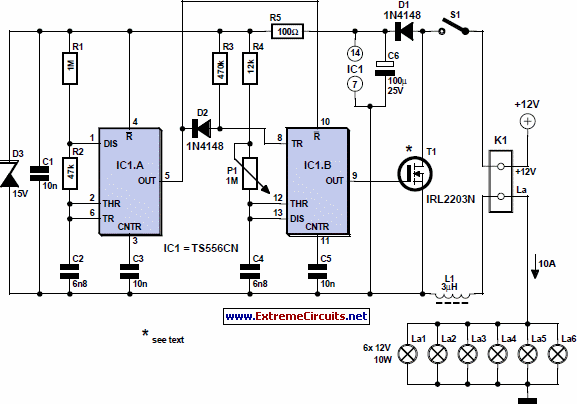
12v dimmer
A dimmer is not commonly found in a caravan or on a boat. This document outlines how to create one. If the goal is to adjust the ambiance while entertaining friends and acquaintances, this circuit allows for that capability. Designing...
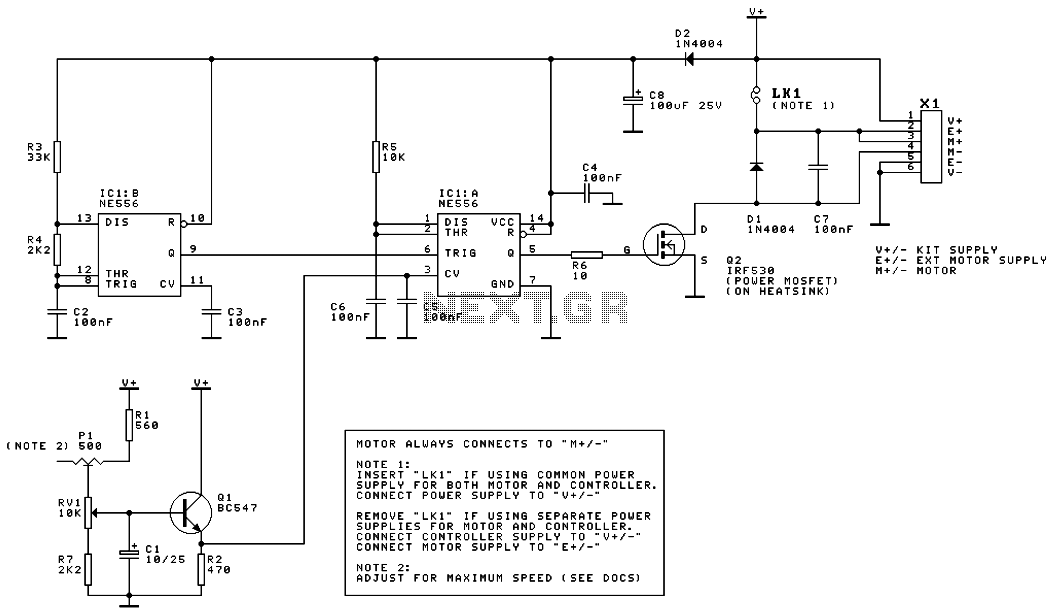
DC Motor Speed Controller
This is the schematic diagram of a DC motor speed controller circuit. The circuit utilizes two oscillators/timers that are configured as a Pulse Width Modulator (PWM). The timer chip used in this circuit is a dual NMOS timer/oscillator.
The DC motor...
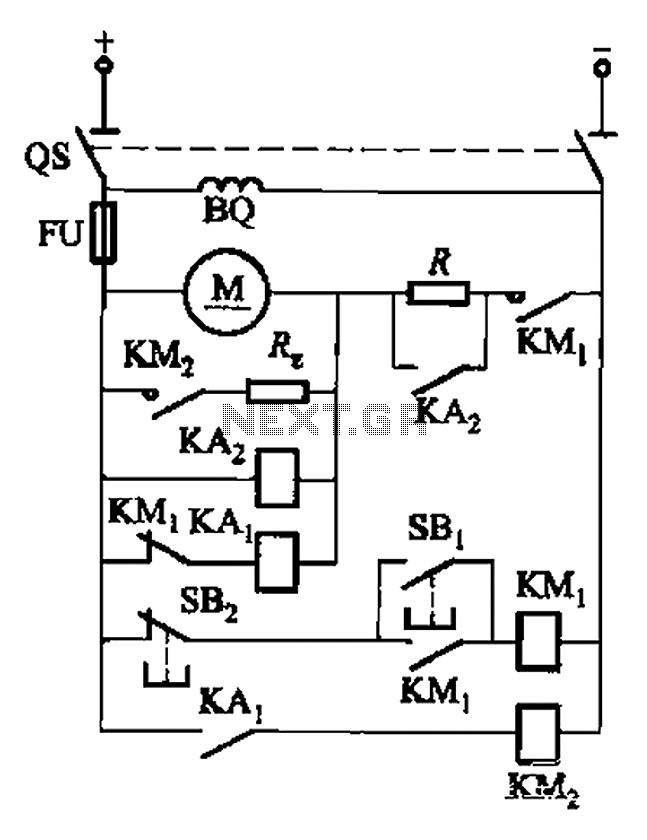
DC motor armature series resistance one way operation start dynamic braking circuit
The circuit illustrated in Figure 3-196 features a starting resistance level and an undervoltage relay (KAz) that is controlled by the removal of the startup resistor. It also includes dynamic braking for shutdown purposes. The undervoltage relay (KAL) operates in...
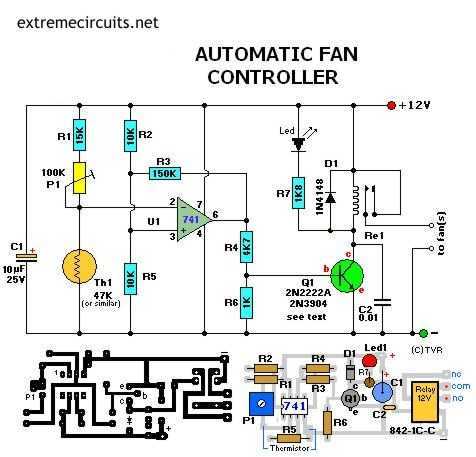
Auto 12V Fan Controller
Transistor Q1 can be a 2N2222(A), 2N3904, NTE123A, ECG123A, etc. Not critical at all. It acts only as a switch for the relay so almost any type will work, as long as it can provide the current needed to activate...
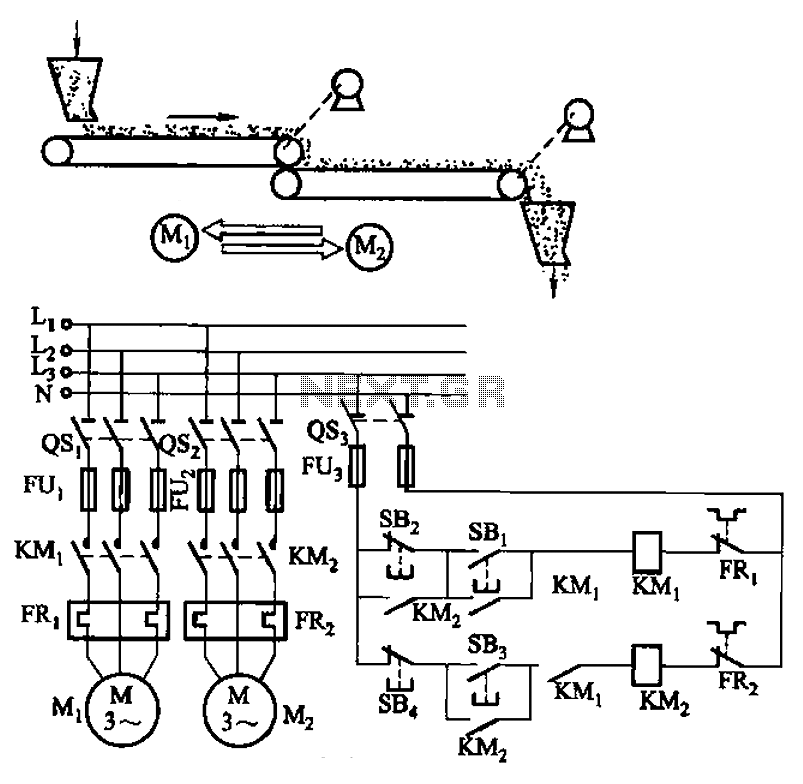
Belt conveyor interlock motor operation sequence control circuit
The circuit depicted in Figure 3-86 utilizes a line utilization time relay to control two motors, starting one before the other after an initial stall. The time relay KTi can be adjusted to modify the starting interval of the two...