


Dc-motor-drive-with-fixed-speed-control
#DC motor
#speed control
#NE5561
#2N4920
#tachometer feedback
#switching circuit
#pulse-proportional drive
#error amplifier
#20 kHz
#commutation diode
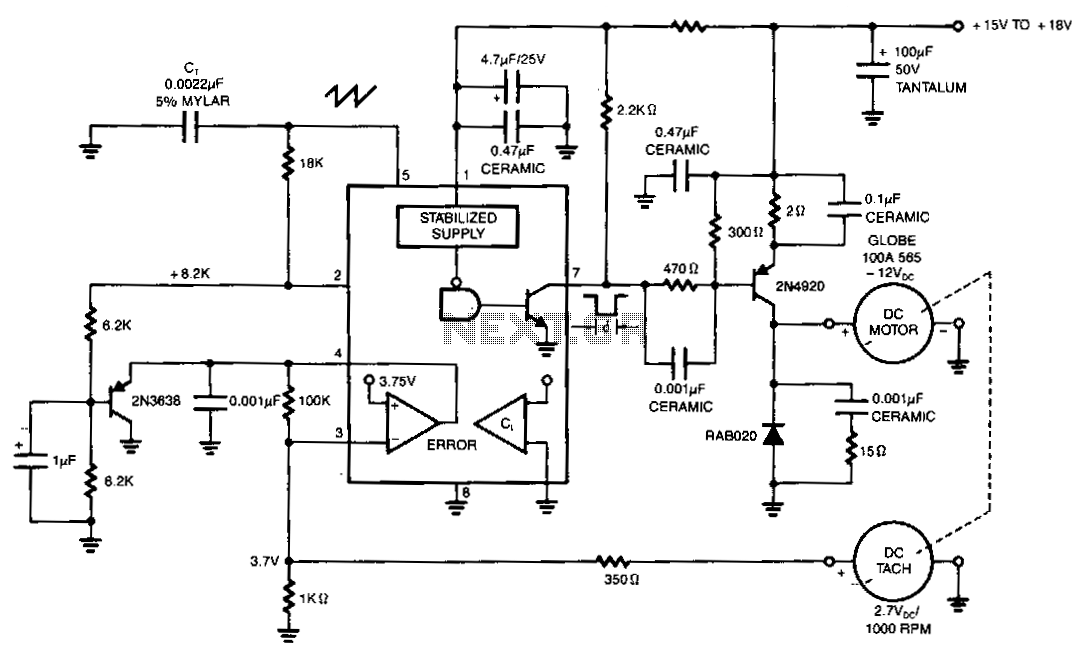
Description: The NE5561 provides pulse-proportional drive and speed control based on DC tachometer feedback. This simple switching circuit consists of a 2N4920 PNP transistor with a commutation diode, which is used to deliver programmed pulse energy to the motor. A frequency of approximately 20 kHz is employed to eliminate audio noise. The DC tachometer delivers 2.7 V per 1000 RPM. Negative feedback occurs when this voltage is applied to the error amplifier of the NE5561. The duty cycle varies directly with load torque demand. The no-load current is 0.3 A, and the full load current is 0.6 A.
The NE5561 integrated circuit is utilized in applications requiring precise control of motor speed and torque through feedback mechanisms. The circuit design incorporates a 2N4920 PNP transistor, which functions as a switch to regulate the power delivered to the motor. The inclusion of a commutation diode is critical as it protects the circuit from voltage spikes generated when the motor is switched off, ensuring stable operation and prolonging the lifespan of the components.
The operational frequency of approximately 20 kHz is chosen to avoid audible noise, which can be a significant issue in motor control applications. By modulating the pulse width of the signal delivered to the motor, the circuit can adjust the power output effectively, allowing for smooth transitions in speed and torque.
The feedback mechanism is facilitated by the DC tachometer, which produces a voltage proportional to the motor's speed. Specifically, it generates 2.7 V for every 1000 RPM. This voltage is fed back into the error amplifier of the NE5561, where it is compared to a reference voltage. The resulting error signal is used to adjust the duty cycle of the output pulse, ensuring that the motor operates at the desired speed and responds dynamically to changes in load torque demand.
Under no-load conditions, the current drawn by the motor is 0.3 A, while under full load, the current increases to 0.6 A. This variation in current is indicative of the motor's operational efficiency and the effectiveness of the control circuit in adapting to different load conditions. By analyzing the current draw alongside the feedback voltage, the circuit can maintain optimal performance across various operational scenarios.
Overall, this configuration provides a robust solution for applications requiring reliable motor control with precise speed and torque adjustments, leveraging the feedback from the DC tachometer to enhance performance and efficiency.The NE5561 provides pulse-proportional drive and speed control based on de tachometer feedback. This simple switching circuit consists of transistor 2N4920 pnp with a commutation diode used to deliver programmed pulse energy to the motor. A frequency of approximately 20 kHz is used to eliminate audio noise. The de tach delivers 2.7 V/1000 RPM. Negative feedback occurs when this voltage is applied to the error amplifier of the NE5561. The duty cycle varies directly with load torque demand. The no-load current is = 0.3 A and full load is 0.6 A.
The NE5561 integrated circuit is utilized in applications requiring precise control of motor speed and torque through feedback mechanisms. The circuit design incorporates a 2N4920 PNP transistor, which functions as a switch to regulate the power delivered to the motor. The inclusion of a commutation diode is critical as it protects the circuit from voltage spikes generated when the motor is switched off, ensuring stable operation and prolonging the lifespan of the components.
The operational frequency of approximately 20 kHz is chosen to avoid audible noise, which can be a significant issue in motor control applications. By modulating the pulse width of the signal delivered to the motor, the circuit can adjust the power output effectively, allowing for smooth transitions in speed and torque.
The feedback mechanism is facilitated by the DC tachometer, which produces a voltage proportional to the motor's speed. Specifically, it generates 2.7 V for every 1000 RPM. This voltage is fed back into the error amplifier of the NE5561, where it is compared to a reference voltage. The resulting error signal is used to adjust the duty cycle of the output pulse, ensuring that the motor operates at the desired speed and responds dynamically to changes in load torque demand.
Under no-load conditions, the current drawn by the motor is 0.3 A, while under full load, the current increases to 0.6 A. This variation in current is indicative of the motor's operational efficiency and the effectiveness of the control circuit in adapting to different load conditions. By analyzing the current draw alongside the feedback voltage, the circuit can maintain optimal performance across various operational scenarios.
Overall, this configuration provides a robust solution for applications requiring reliable motor control with precise speed and torque adjustments, leveraging the feedback from the DC tachometer to enhance performance and efficiency.The NE5561 provides pulse-proportional drive and speed control based on de tachometer feedback. This simple switching circuit consists of transistor 2N4920 pnp with a commutation diode used to deliver programmed pulse energy to the motor. A frequency of approximately 20 kHz is used to eliminate audio noise. The de tach delivers 2.7 V/1000 RPM. Negative feedback occurs when this voltage is applied to the error amplifier of the NE5561. The duty cycle varies directly with load torque demand. The no-load current is = 0.3 A and full load is 0.6 A.
The 4Q2 DC Motor Speed Controller Circuit and Datasheet
This figure represents the 4Q2 DC Motor Speed Controller Circuit Block Diagram, designed for comprehensive control of conventional shunt-wound and permanent magnet motors with a capacity of up to 75 kW, as specified in the datasheet. This type of DC...
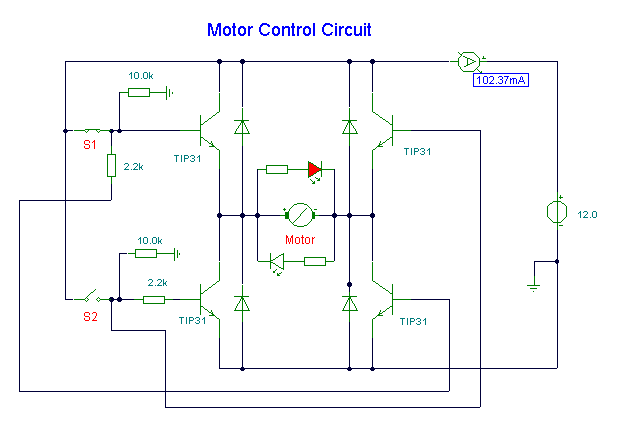
dc motor control circuit
S1 and S2 are normally open, push-to-close, momentary switches. The diodes can be red or green and serve solely as indicators for direction. The TIP31 transistors may need to be adjusted based on the motor specifications. It is important to...
When page is bookmarked text here is referenced verbatim
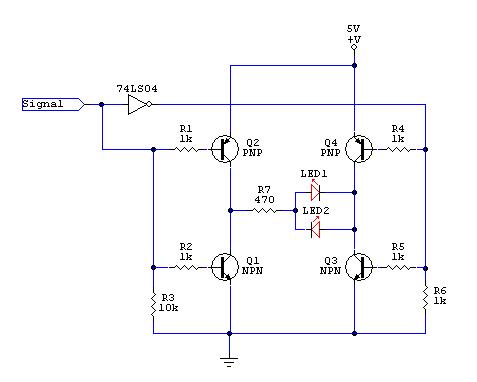
The image shows a completed locked anti-phase motor controller built on a breadboard, utilizing general-purpose transistors to control small DC motors for robotics applications. A typical DC motor controller lacks a braking function, which is essential for precise control. Addressing...
Control circuit keeps dc motor running at constant speed
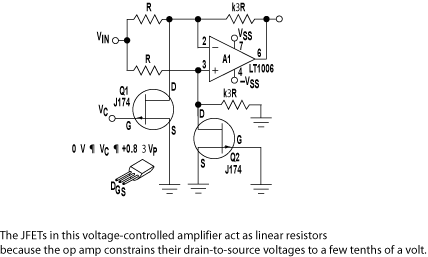
The purpose of this circuit is to maintain a permanent magnet DC motor at a constant speed, which is set externally. This is achieved by monitoring the current flowing through and the voltage across the motor's brushes.
The schematic for this...
Multi-unit slip motor speed control system synchronous operation circuit
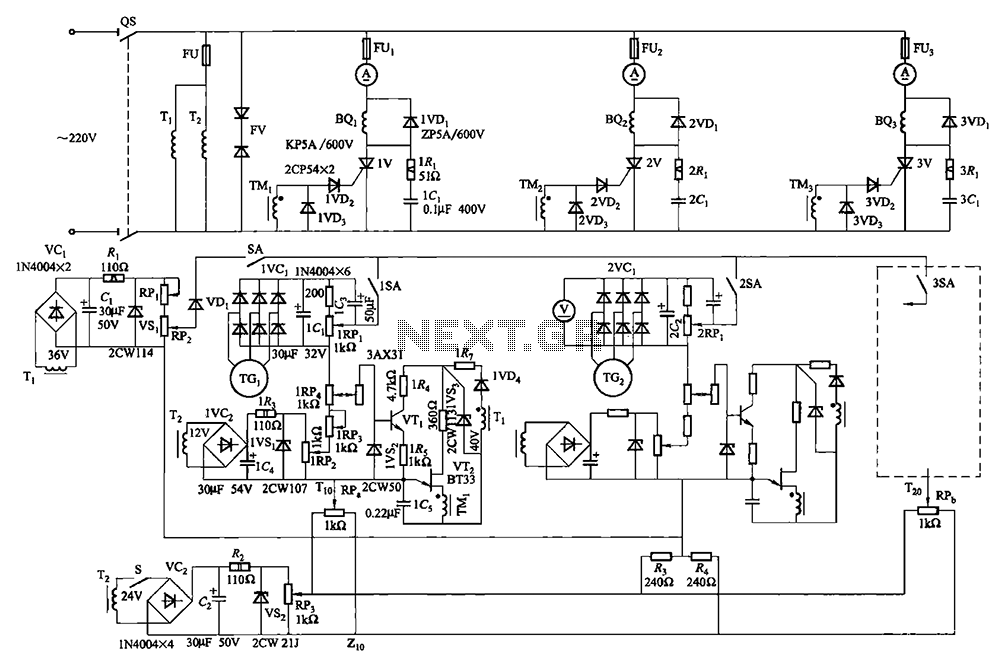
Collaboration with the dancers balanced bridge long on the porcelain unit. A sync adjustment rheostat speed control system is shown in Figure 3. The principle of speed control for electro-magnetic and photoelectric dancers is similar. The main motor (BQ2) allows...
Bi-directional motor
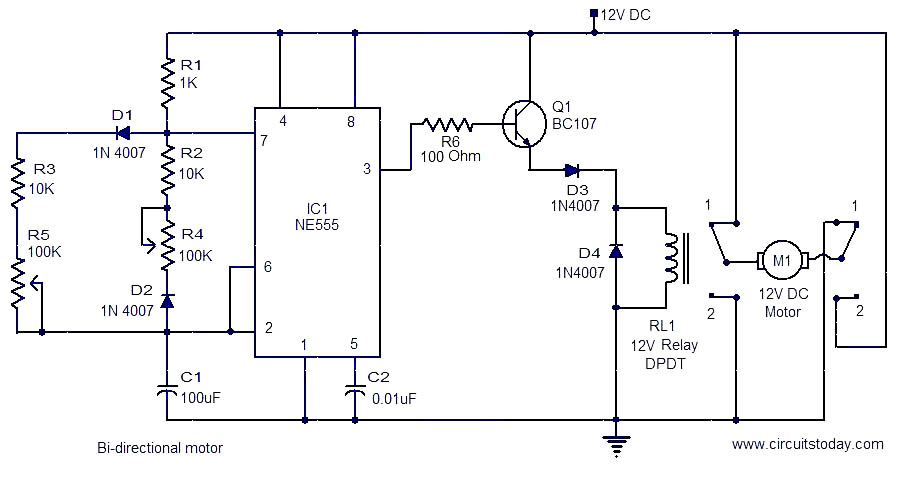
This is a simple and easy-to-construct circuit designed to provide a bidirectional drive for a DC motor. The circuit operates straightforwardly. The output of an astable multivibrator based on IC1 (NE555) is utilized to control the relay RL1 that drives...
Motor circuits
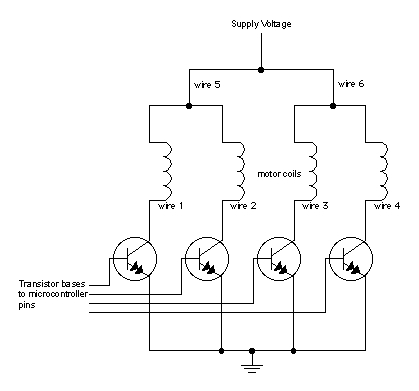
When moving objects with microcontrollers, three types of motors are particularly useful: DC motors, servomotors, and stepper motors. Most motors operate on the electrical principle of induction. When electric current flows through a wire, it generates a magnetic field around...
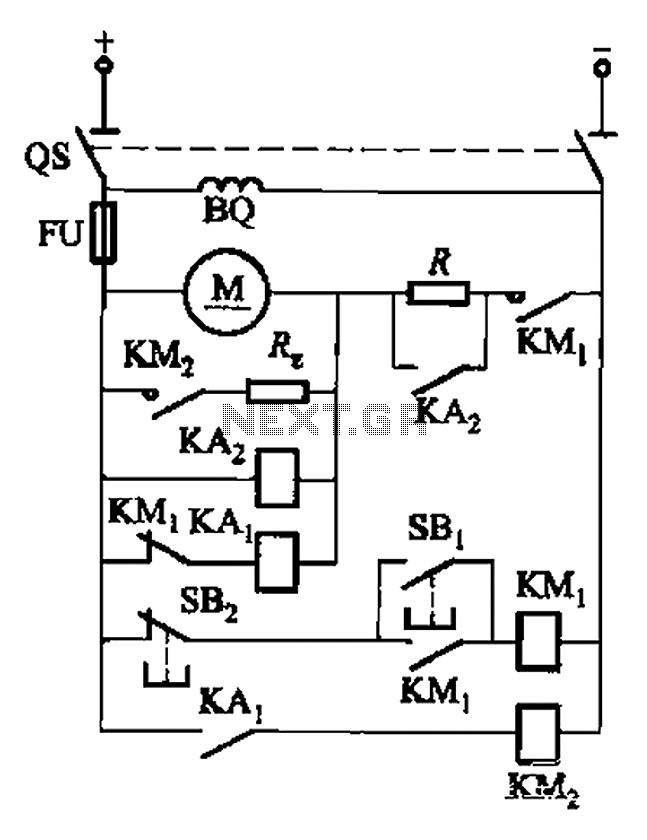
DC motor armature series resistance one way operation start dynamic braking circuit
The circuit illustrated in Figure 3-196 features a starting resistance level and an undervoltage relay (KAz) that is controlled by the removal of the startup resistor. It also includes dynamic braking for shutdown purposes. The undervoltage relay (KAL) operates in...
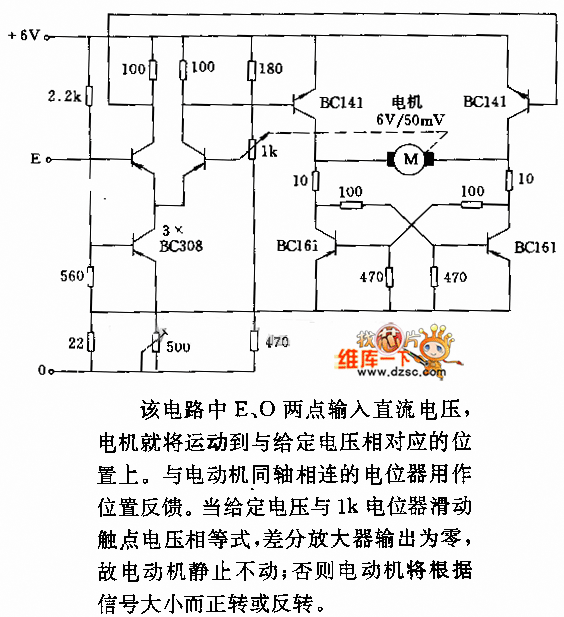
DC motor servo control circuit diagram
In the circuit, when E and O are input DC voltages, the motor moves to a position corresponding to the voltage. A potentiometer, coaxially connected to the motor, is used for position feedback. When the given voltage equals the wiper...