


Bi-directional motor
#DC motor
#NE555
#relay
#bidirectional
#astable multivibrator
#motor drive
#control circuit
#switching
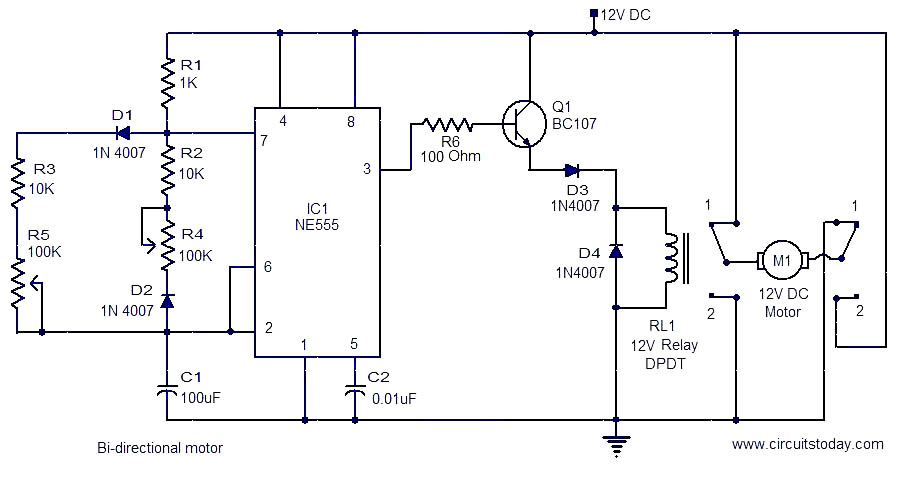
Description: This is a simple and easy-to-construct circuit designed to provide a bidirectional drive for a DC motor. The circuit operates straightforwardly. The output of an astable multivibrator based on IC1 (NE555) is utilized to control the relay RL1 that drives the motor. The motor is connected between the two poles of the relay contacts. The relay contacts are configured to reverse the DC supply to the motor when the contacts change position. The astable multivibrator generates a square wave at the output, with its high time determined by 0.69(R1+R3+R5)C1 and low time determined by 0.69(R1+R2+R4)C1. The high and low times can be adjusted by varying the potentiometers R4 and R5. For the specified values, the high and low times can be individually adjusted between 1 second and 8 seconds. When the output of IC1 is low, the relay is de-energized, and the relay contacts remain in position 1-1, resulting in terminal A of the motor being positive, causing the motor to run in one direction. When the output of IC1 is high, the relay is energized, and the contacts change to position 2-2, making terminal B of the motor positive, which causes the motor to run in the opposite direction. The transistor Q1 is used to drive the relay based on the output from IC1. The diode D4 functions as a freewheeling diode.
The circuit employs an NE555 timer configured in astable mode, generating a continuous square wave output that toggles between high and low states. This output controls the operation of a relay, which in turn manages the direction of the DC motor. The relay acts as a switch, allowing the circuit to reverse the polarity of the voltage applied to the motor, thereby enabling bidirectional control.
The timing components, including resistors R1, R2, R3, R4, R5, and capacitor C1, determine the frequency and duty cycle of the square wave. By adjusting the values of the potentiometers R4 and R5, the user can fine-tune the duration of the motor's operation in either direction, providing flexibility in applications requiring variable speed or run time.
Transistor Q1 serves as a switching device, amplifying the output signal from the NE555 timer to drive the relay coil. This arrangement ensures that the relay operates reliably without drawing excessive current from the timer output. The inclusion of diode D4 is crucial for protecting the circuit from back EMF generated by the relay coil when it is de-energized. This diode allows the inductive kickback to dissipate safely, preventing potential damage to the transistor and other components.
Overall, this circuit is suitable for applications requiring simple motor control, such as in robotics, automated systems, or small-scale machinery, where bidirectional motor operation is necessary. The straightforward design and adjustable timing make it an accessible choice for both hobbyists and professionals in the field of electronics.This is a simple and easy to construct circuit that can be used to provide a bidirectional drive to a DC motor. The circuit operation is straight forward. Output of an astable mutivibrator based on IC1 (NE555) is used to control the relay RL1 driving the motor.
The motor is connected between the two poles of the relay contacts. The relay contacts are so wired as to reverse the DC supply to the motor when the contacts changeover. The astable multivibrator produces a square wave at the output with its high time given by 0. 69(R1+R3+R5)C1 and low time given by 0. 69(R1+R2+R4)C1. The high and low times can be varied by varying potentiometers R4 and R5. For the given values the high and low times can be adjusted between 1S and 8S separately. When the IC1 output is low, the relay is de energised and the relay contacts are in position 1-1 with the result that A terminal of the motor is positive and motor runs in one direction. The IC1 output is high the relay is energised and the contacts changeover to position 2-2. Now the terminal B of the motor becomes positive and motor runs in the opposite direction. The transistor Q1 is used to drive the relay according to the output from IC1. The diode D4 acts as freewheeling diode.
The circuit employs an NE555 timer configured in astable mode, generating a continuous square wave output that toggles between high and low states. This output controls the operation of a relay, which in turn manages the direction of the DC motor. The relay acts as a switch, allowing the circuit to reverse the polarity of the voltage applied to the motor, thereby enabling bidirectional control.
The timing components, including resistors R1, R2, R3, R4, R5, and capacitor C1, determine the frequency and duty cycle of the square wave. By adjusting the values of the potentiometers R4 and R5, the user can fine-tune the duration of the motor's operation in either direction, providing flexibility in applications requiring variable speed or run time.
Transistor Q1 serves as a switching device, amplifying the output signal from the NE555 timer to drive the relay coil. This arrangement ensures that the relay operates reliably without drawing excessive current from the timer output. The inclusion of diode D4 is crucial for protecting the circuit from back EMF generated by the relay coil when it is de-energized. This diode allows the inductive kickback to dissipate safely, preventing potential damage to the transistor and other components.
Overall, this circuit is suitable for applications requiring simple motor control, such as in robotics, automated systems, or small-scale machinery, where bidirectional motor operation is necessary. The straightforward design and adjustable timing make it an accessible choice for both hobbyists and professionals in the field of electronics.This is a simple and easy to construct circuit that can be used to provide a bidirectional drive to a DC motor. The circuit operation is straight forward. Output of an astable mutivibrator based on IC1 (NE555) is used to control the relay RL1 driving the motor.
The motor is connected between the two poles of the relay contacts. The relay contacts are so wired as to reverse the DC supply to the motor when the contacts changeover. The astable multivibrator produces a square wave at the output with its high time given by 0. 69(R1+R3+R5)C1 and low time given by 0. 69(R1+R2+R4)C1. The high and low times can be varied by varying potentiometers R4 and R5. For the given values the high and low times can be adjusted between 1S and 8S separately. When the IC1 output is low, the relay is de energised and the relay contacts are in position 1-1 with the result that A terminal of the motor is positive and motor runs in one direction. The IC1 output is high the relay is energised and the contacts changeover to position 2-2. Now the terminal B of the motor becomes positive and motor runs in the opposite direction. The transistor Q1 is used to drive the relay according to the output from IC1. The diode D4 acts as freewheeling diode.
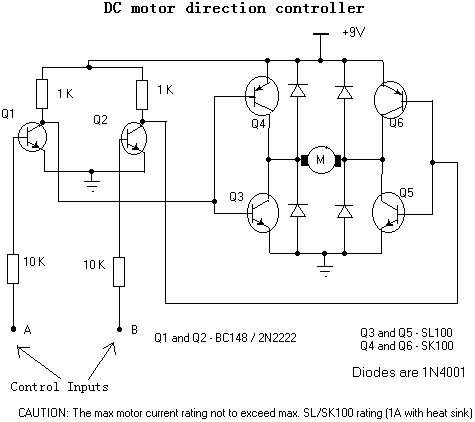
DC Motor Direction Controller
For controlling a small DC motor, such as the one found in a tape recorder, Q1 and Q2 are in saturation when both points A and B are HIGH. Component: ..
To control a small DC motor effectively, a circuit utilizing...
DC Motor Tutorial
A DC motor operates by converting electrical power into mechanical work. This process involves passing current through a coil, which generates a magnetic field that causes the motor to spin. One method to adjust the speed of a DC motor...
DC motor 12V speed controller circuit with explanation
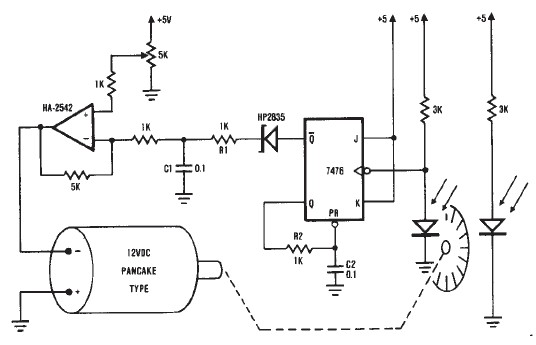
A simple encoder circuit for a DC motor can be constructed using this circuit diagram. The system consists of the HA-2542, a small 12-V DC motor, and a position encoder. During operation, the encoder generates a series of constant-width pulses...
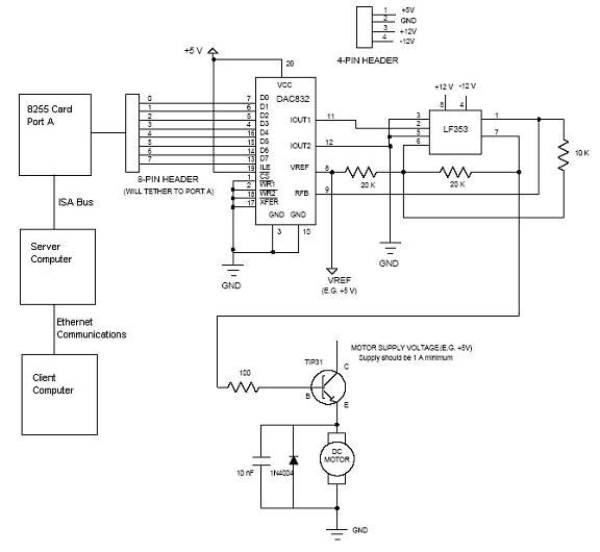
Open Loop Speed Control of a DC Motor via 8255 Controller
Open loop speed control of a DC motor is implemented using the 8255 Digital I/O Controller chip in conjunction with a TCP/IP server-client application programmed in Visual Basic. The DAC0832 chip serves as the Digital to Analog Converter. This project...
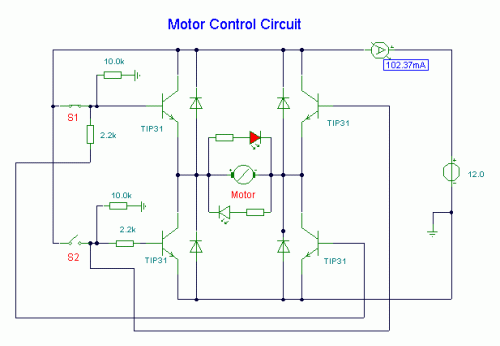
DC Motor Control Circuit
S1 and S2 are normally open, push-to-close, momentary switches. The diodes, which can be either red or green, serve solely to indicate the direction of operation. The TIP31 transistors may need to be adjusted based on the specifications of the...
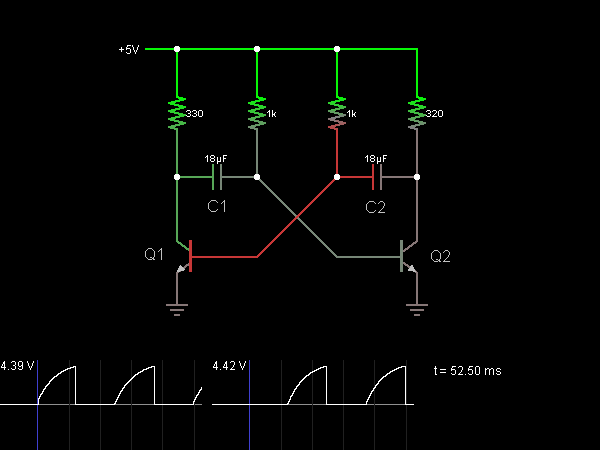
Astable Multivibrator (Oscillator)
This circuit functions as an astable multivibrator, also known as an oscillator. The two transistors are interconnected in a manner that allows the circuit to alternate between two states. In one state, the base of transistor Q1 is approximately one...
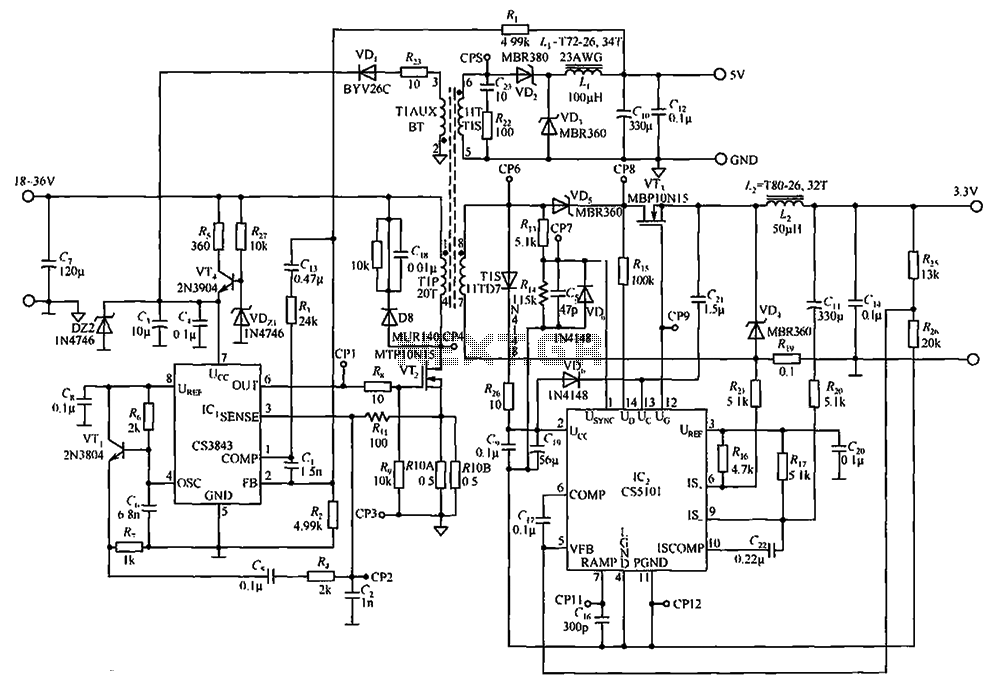
Output by the CS3843 and CS5101 composed of 5V 3.3V switching DC power supply circuit
The CS3843 and CS5101 are components of a 5V/3.3V switching DC power supply circuit. The CS3843 is a fixed frequency PWM controller characterized by a set oscillator that precisely controls the duty cycle. It features a temperature-compensated reference voltage, a...
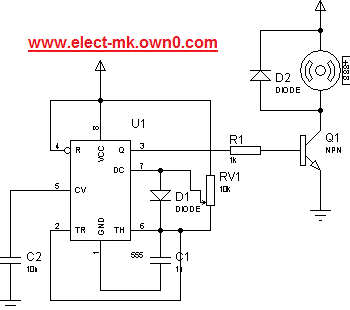
DC Motor speed control circuit
Provision in the speed of a small engine DC motor speed control circuit using a small rheostat for control in the DC motor circuit diagram.
The circuit for controlling the speed of a small DC motor typically incorporates a rheostat as...
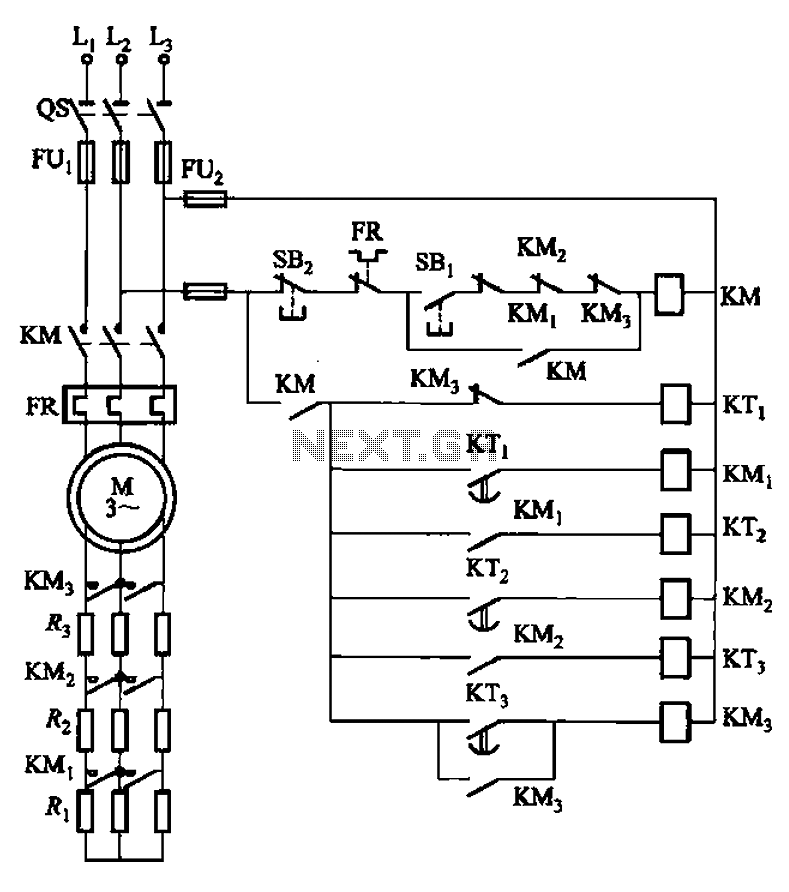
Time relay three-start circuit
The circuit depicted in Figure 3-159 employs complementary operation three times along with three relay contacts. This is followed by the automatic elimination of the rotor circuit resistance levels, ultimately reducing the rotor winding variable resistor to zero (fully shorted),...