


line follower mobile robot
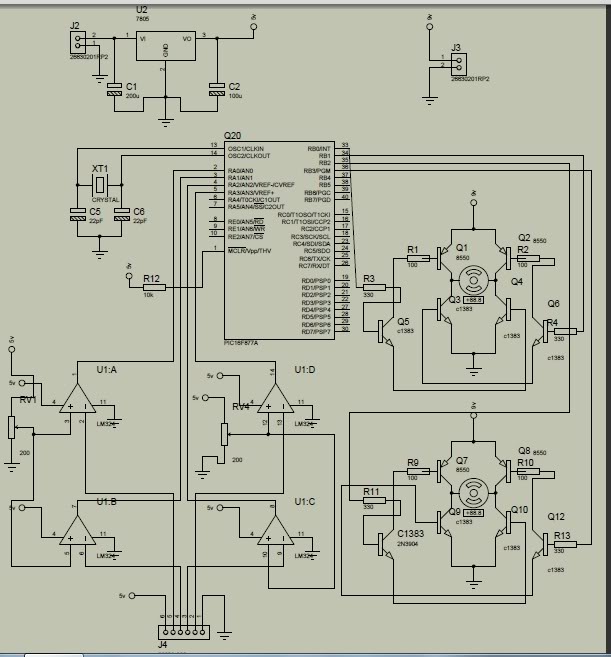
Description: This is a microcontroller hobby project featuring a line-following mobile robot named "Cruddy." The name reflects the somewhat messy structure of the robot. As a first-time builder, the soldering skills may not be fully developed. The chassis was sourced from a remote-controlled vehicle.
The project centers around the development of a line-following mobile robot, which utilizes a microcontroller as its central processing unit. The robot is designed to detect and follow a line on the ground, which is typically represented by a contrasting color to the surface. The essential components of the robot include the chassis, motors, wheels, sensors, and the microcontroller.
The chassis, repurposed from a remote-controlled vehicle, serves as the foundation for the assembly. It provides the necessary structure to house all other components. The motors, typically DC motors, are attached to the wheels and are responsible for propelling the robot forward and enabling it to turn. The control of these motors is managed by the microcontroller, which processes input from the sensors.
The sensors, often infrared or reflectance sensors, are positioned at the front of the robot. Their function is to detect the line by measuring the amount of reflected light. When the sensors identify the line, they send signals to the microcontroller, which then adjusts the motor speeds accordingly to keep the robot aligned with the line.
Programming the microcontroller involves writing a simple control algorithm that interprets the sensor data and determines the appropriate motor actions. This may include turning left or right, speeding up, or slowing down based on the robot's position relative to the line.
Overall, this project serves as an excellent introduction to robotics and microcontroller programming, offering practical experience in circuit design, soldering, and algorithm development. The challenges faced during assembly and programming will contribute to skill development in electronics and robotics.This is my first Microcontroller Hobby Project. He is ""Cruddy"" my line follower mobile robot. I named him Cruddy because he`s quite a mess on his structure. It is my first time on building a robot so expect that my soldering skills are not yet that good. The chassis was from a remote controlled..
The project centers around the development of a line-following mobile robot, which utilizes a microcontroller as its central processing unit. The robot is designed to detect and follow a line on the ground, which is typically represented by a contrasting color to the surface. The essential components of the robot include the chassis, motors, wheels, sensors, and the microcontroller.
The chassis, repurposed from a remote-controlled vehicle, serves as the foundation for the assembly. It provides the necessary structure to house all other components. The motors, typically DC motors, are attached to the wheels and are responsible for propelling the robot forward and enabling it to turn. The control of these motors is managed by the microcontroller, which processes input from the sensors.
The sensors, often infrared or reflectance sensors, are positioned at the front of the robot. Their function is to detect the line by measuring the amount of reflected light. When the sensors identify the line, they send signals to the microcontroller, which then adjusts the motor speeds accordingly to keep the robot aligned with the line.
Programming the microcontroller involves writing a simple control algorithm that interprets the sensor data and determines the appropriate motor actions. This may include turning left or right, speeding up, or slowing down based on the robot's position relative to the line.
Overall, this project serves as an excellent introduction to robotics and microcontroller programming, offering practical experience in circuit design, soldering, and algorithm development. The challenges faced during assembly and programming will contribute to skill development in electronics and robotics.This is my first Microcontroller Hobby Project. He is ""Cruddy"" my line follower mobile robot. I named him Cruddy because he`s quite a mess on his structure. It is my first time on building a robot so expect that my soldering skills are not yet that good. The chassis was from a remote controlled..
synchronizing fireflies ng
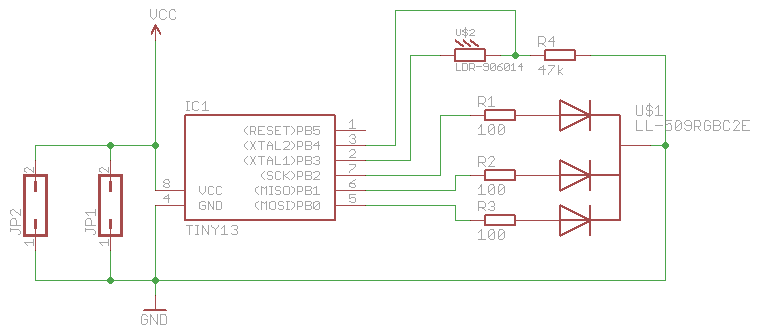
This is a remake of the fireflies project that was created a year ago. The concept revolves around the emergence of patterns, particularly the synchronization of hundreds or thousands of fireflies. Initially, they flash randomly, but over time, influenced by...
Electronic TIC TAC TOE
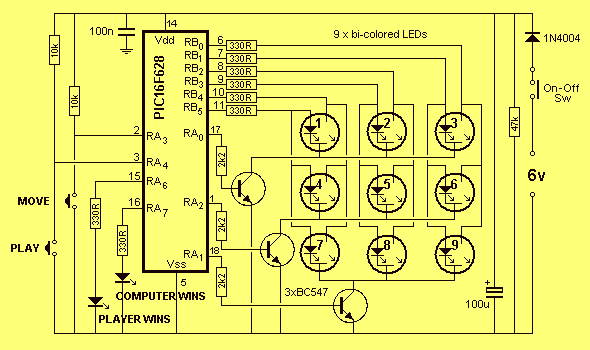
This project is not to introduce Tic Tac Toe. Everyone knows this game. It is to introduce two features: bi-coloured LEDs, microcontrollers, and the skill of writing an ALGORITHM. You can use the project to learn the skills of creating...
Simple Robot That Drives Forward and Back
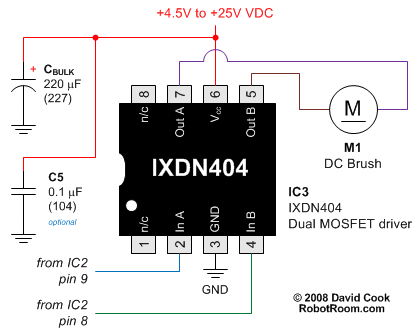
The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an...
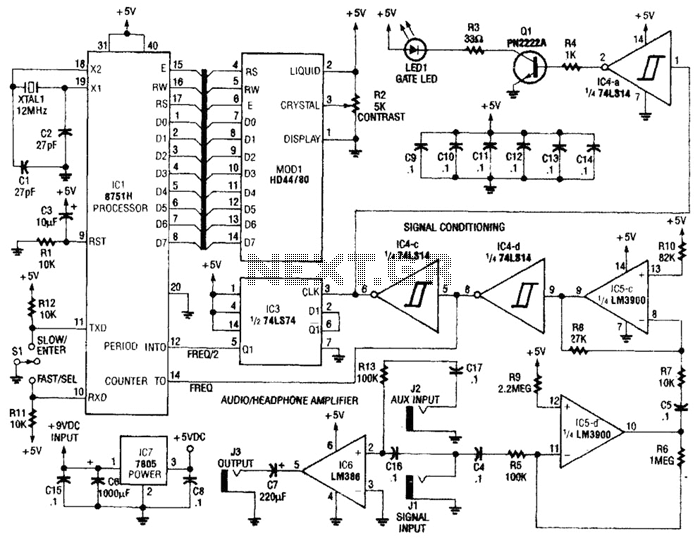
Perfect Pitch Circuit
Perfect Pitch, which is based on the 8751 microprocessor, is an affordable and straightforward instrument tuner and frequency counter that features a built-in headphone amplifier and a visual metronome. Perfect Pitch converts the audio signal from an instrument into a...
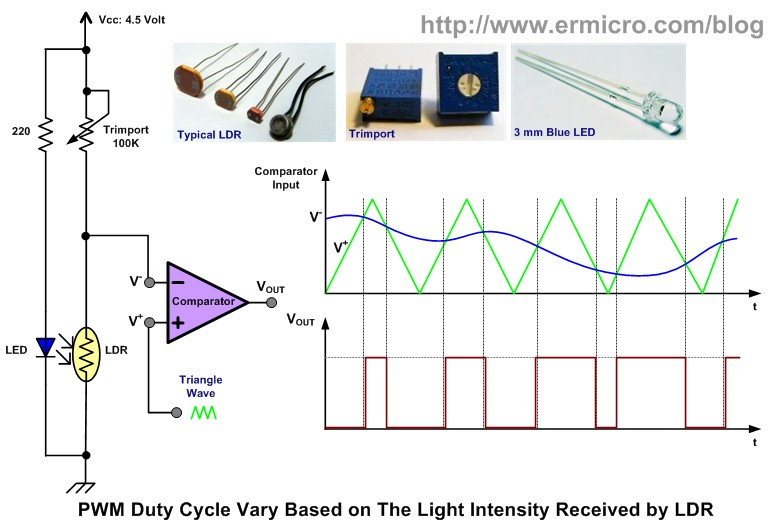
Line Follower Robot
Designing a simple yet functional Line Follower Robot (LFR) is a fascinating and challenging topic. The LFR can be implemented in various ways, ranging from a basic two-transistor design to a sophisticated PID (Proportional, Integral, and Derivative) controller that utilizes...
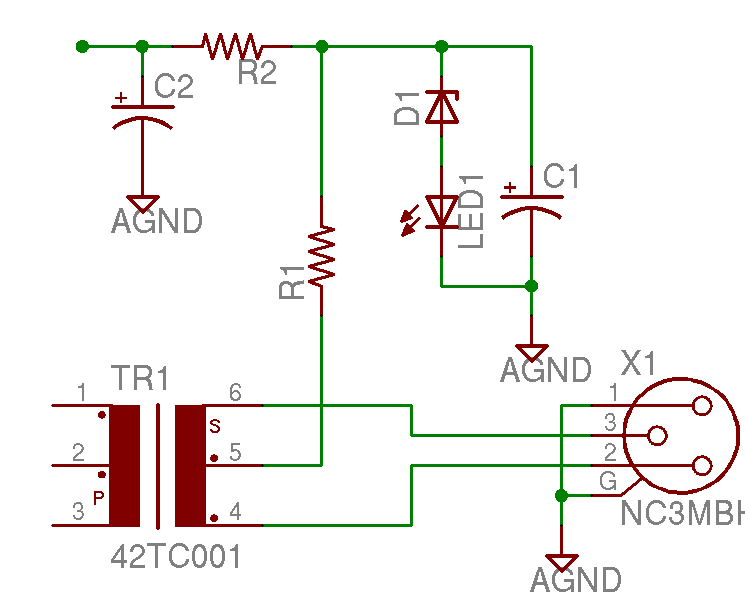
Help with a schematic please
A project is underway to construct the CountryHick DI as illustrated on DIYFactory, incorporating a few minor modifications. The final design aims to be a 1U unit with four inputs.
The CountryHick DI (Direct Injection) box is a crucial tool in...
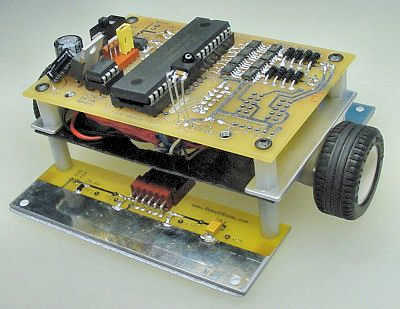
Jet
The microcontroller is able to make about 7000 complete line-following decisions per second, which is almost 7 decisions per millimeter when the robot is going full speed. By upping the clock, unrolling loops, and removing my wireless debugging and extraneous...
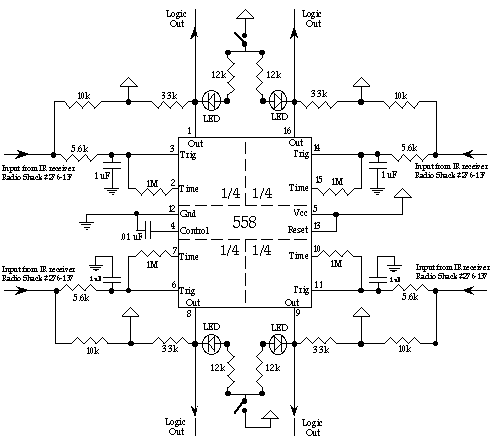
The Hoser Paper
A robot named "Wet Dream" was constructed to roam around, avoid collisions, locate people, and squirt them with an onboard motorized water gun. The robot was designed to maneuver in unstructured environments and react purposefully to various situations. "Wet Dream"...
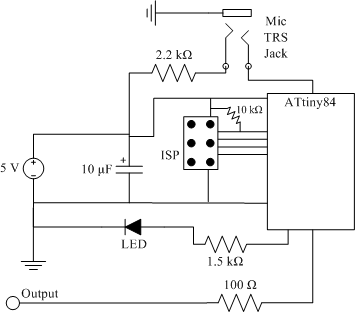
clap sensor construction
The clap sensor is a straightforward circuit that consists of a PC microphone, a microcontroller, and an output. The circuit design features the ATtiny84 microcontroller, chosen for familiarity with the AVR architecture and accessibility to necessary tools. The ATtiny84 is...