


The Hoser Paper
#robot
#collision avoidance
#water gun
#unstructured environment
#toy robot arm
#automation
#sensors
#motorized
#Radio Shack
Description: A robot named "Wet Dream" was constructed to roam around, avoid collisions, locate people, and squirt them with an onboard motorized water gun. The robot was designed to maneuver in unstructured environments and react purposefully to various situations. "Wet Dream" utilized a toy robot arm called the "Mobile Armatron," which consisted of a toy arm mounted on a mobile base controlled manually via a wired remote. The base allowed the Armatron to move forward, backward, and turn right or left, driven by two motors arranged for tank-style steering. Turning was achieved by driving one wheel while allowing the other to skid. The original toy had a third wheel, a passive caster for support, while a fourth passive caster was added to support the weight of the modifications. Due to the weight, the robot struggled to move on carpeting but performed well on tiled floors. The robot's arm featured a motorized "shoulder" capable of raising and lowering the arm, a manually adjustable "elbow," and a motor-controlled "wrist" that could be raised, lowered, and rotated. A simple pincer at the wrist could open and close. Crude position feedback was provided by limit switches at the arm's shoulder and wrist travel limits, and a reed switch allowed for sensing a middle "aiming" position. The limit switches were connected to the onboard computer to automatically deactivate the motors if the arm approached an end-stop. Collision detection was achieved using infrared proximity sensors, specifically the Radio Shack part number 276-137 infrared receiver, paired with generic IR LEDs. This part was designed for infrared remote controls and was sensitive and noise-immune. However, it generated pulsing signals at the edge of its detection range, which was mitigated by a low-pass filter with hysteresis built from a 555 timer IC. Eight infrared proximity sensors were mounted around the robot: five on the base (forward, backward, left, right, and downward) and three at the end of the arm (left, right, and forward). These sensors were tuned to trigger when an object came within six to nine inches. They generally worked well, except for certain non-infrared reflective walls, leading to the downward sensor being ignored on most floors. Additionally, two pyroelectric sensors were installed to detect body heat: one forward-looking at the arm's end and another on top of a Futaba servo on the robot's "head" to scan for people. A pump from a toy motorized water gun was mounted on the arm, with its nozzle attached at the end, and a water reservoir (a bottle from Neutrogena soap) was mounted on the base. Two LEDs were added as "eyes" to enhance the robot's appearance.
The design of the "Wet Dream" robot integrates various electronic and mechanical components to achieve its intended functionality. The Mobile Armatron serves as the foundation for mobility, utilizing a dual-motor drive system for tank-style steering, which allows for precise navigation in diverse environments. The addition of passive casters ensures stability while accommodating the weight of modifications, enhancing the robot's overall maneuverability.
The arm's design incorporates multiple degrees of freedom, with the motorized shoulder enabling vertical movement, while the manually adjustable elbow allows for flexible positioning. The wrist's motor control and pincer functionality facilitate interaction with the environment, allowing the robot to perform tasks such as squirting water. The inclusion of limit switches and a reed switch provides essential feedback for controlling the arm's motion, preventing mechanical damage from overshooting.
Collision avoidance is a critical feature of "Wet Dream," achieved through a network of infrared proximity sensors. The choice of the Radio Shack 276-137 infrared receiver ensures reliable detection of nearby objects, with the low-pass filter addressing issues related to signal noise. The strategic placement of sensors around the robot maximizes its awareness of surroundings, with the downward sensor primarily used for detecting obstacles at ground level.
The integration of pyroelectric sensors enhances the robot's capability to detect human presence, allowing it to respond to heat signatures. This feature is particularly valuable in environments where visual detection may be limited. The water gun mechanism adds an interactive element to the robot's functionality, with the design ensuring that water is effectively dispensed when required.
Overall, the "Wet Dream" robot exemplifies an innovative approach to combining mechanical design with electronic control systems, resulting in a functional and engaging robotic platform capable of navigating and interacting with its environment effectively.A robot named "Wet Dream" was constructed whose purpose was to roam around, avoid collisions, locate people, and squirt people with an onboard motorized water gun. The robot was built to maneuver in an unstructured environment and be able to react purposefully in most situations encountered.
"Wet Dream" utilized a toy robot arm sold by Radio Shack called the "Mobile Armatron. " The Mobile Armatron consisted of a toy robot arm mounted on a mobile base controlled manually via a wired remote. The base enabled the Armatron to move forward, backward, turn right, and turn left. Drive was provided by two motors arranged for tank-style steering. Turning right and left was accomplished by driving only one of the wheels and letting the other skid.
The original toy also had a third wheel, a passive castor to provide support. A fourth wheel, another passive castor, had to be added to support the weight of the modified toy. Because of the weight of the modifications, the toy could not move around on carpeting, but still moved well on tiled floor. In addition to being able to move, the robot had an arm with a "shoulder, " an "elbow, " and a "wrist.
" The shoulder was motorized and could raise and lower the arm. The "elbow" was not active but could be set in a number of positions manually. The "wrist" could also be lowered and raised via motor control. The wrist could also be rotated and a simple pincer at the end of the wrist could be opened and closed. Crude position feedback was provided by limit switches at the bottom and top of the arm`s shoulder and wrist travel.
Also, a reed switch from an alarm was mounted on the robot`s body so that a middle "aiming" position for the arm could be sensed. The limit switches were set up so that they could be read by the onboard computer and would automatically turn off the appropriate motor`s control relay for that direction of travel.
This was done in case the robot`s control program did not stop the arm`s travel in time to prevent it from crashing into an end-stop. Collision detection was performed via infrared proximity sensors. Specifically, the Radio Shack part number 276-137 infrared receiver was used in conjunction with some generic IR LED`s.
The Radio Shack part was intended for use in infrared remote controls. It contained all the circuitry necessary to detect the presence of an infrared signal modulated at 40 KHz and reject other signals. It was ideal because it was extremely sensitive and relatively immune to noise. However, it would generate pulsing signals when a received IR signal was at the edge of its detection range.
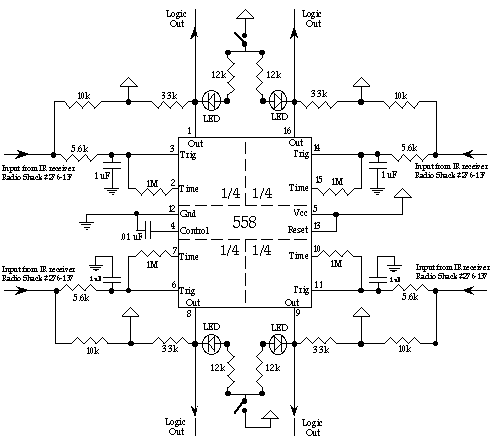
This problem was corrected by a simplistic low pass filter with hysteresis built from a 555. (The actual circuit used two 558`s, four 555`s in one 16 pin DIP package, a schematic of which is included in Appendix B. ) There were eight infrared proximity sensors mounted around the body of the robot. Five were mounted on the base, looking forward, backward, left, right, and downward in front Three more were mounted at the end of the arm looking left, right, and forward.
Their general layout can be seen in Figure 1 below. The sensors were tuned to trigger when an object came within six to nine inches of them. In general, they worked well, failing only in the case of certain walls which were not infrared reflective. Most floors were not to too infrared reflective, so the robot ignored the downward looking front sensor.
Two pyroelectric sensors were also mounted on the robot to detect body heat. One was mounted, forward looking, at the end of the arm. The other was mounted on top of a Futaba servo on the toy`s "head" to scan back and forth looking for people. The pump from a toy motorized water gun was mounted on the arm, pointing forward, its nozzle attached to the end of the arm, and a reservoir for water (a bottle from Neutrogena soap) was mounted on the base.
Two LED`s were added as "eyes" to give the robot per
The design of the "Wet Dream" robot integrates various electronic and mechanical components to achieve its intended functionality. The Mobile Armatron serves as the foundation for mobility, utilizing a dual-motor drive system for tank-style steering, which allows for precise navigation in diverse environments. The addition of passive casters ensures stability while accommodating the weight of modifications, enhancing the robot's overall maneuverability.
The arm's design incorporates multiple degrees of freedom, with the motorized shoulder enabling vertical movement, while the manually adjustable elbow allows for flexible positioning. The wrist's motor control and pincer functionality facilitate interaction with the environment, allowing the robot to perform tasks such as squirting water. The inclusion of limit switches and a reed switch provides essential feedback for controlling the arm's motion, preventing mechanical damage from overshooting.
Collision avoidance is a critical feature of "Wet Dream," achieved through a network of infrared proximity sensors. The choice of the Radio Shack 276-137 infrared receiver ensures reliable detection of nearby objects, with the low-pass filter addressing issues related to signal noise. The strategic placement of sensors around the robot maximizes its awareness of surroundings, with the downward sensor primarily used for detecting obstacles at ground level.
The integration of pyroelectric sensors enhances the robot's capability to detect human presence, allowing it to respond to heat signatures. This feature is particularly valuable in environments where visual detection may be limited. The water gun mechanism adds an interactive element to the robot's functionality, with the design ensuring that water is effectively dispensed when required.
Overall, the "Wet Dream" robot exemplifies an innovative approach to combining mechanical design with electronic control systems, resulting in a functional and engaging robotic platform capable of navigating and interacting with its environment effectively.A robot named "Wet Dream" was constructed whose purpose was to roam around, avoid collisions, locate people, and squirt people with an onboard motorized water gun. The robot was built to maneuver in an unstructured environment and be able to react purposefully in most situations encountered.
"Wet Dream" utilized a toy robot arm sold by Radio Shack called the "Mobile Armatron. " The Mobile Armatron consisted of a toy robot arm mounted on a mobile base controlled manually via a wired remote. The base enabled the Armatron to move forward, backward, turn right, and turn left. Drive was provided by two motors arranged for tank-style steering. Turning right and left was accomplished by driving only one of the wheels and letting the other skid.
The original toy also had a third wheel, a passive castor to provide support. A fourth wheel, another passive castor, had to be added to support the weight of the modified toy. Because of the weight of the modifications, the toy could not move around on carpeting, but still moved well on tiled floor. In addition to being able to move, the robot had an arm with a "shoulder, " an "elbow, " and a "wrist.
" The shoulder was motorized and could raise and lower the arm. The "elbow" was not active but could be set in a number of positions manually. The "wrist" could also be lowered and raised via motor control. The wrist could also be rotated and a simple pincer at the end of the wrist could be opened and closed. Crude position feedback was provided by limit switches at the bottom and top of the arm`s shoulder and wrist travel.
Also, a reed switch from an alarm was mounted on the robot`s body so that a middle "aiming" position for the arm could be sensed. The limit switches were set up so that they could be read by the onboard computer and would automatically turn off the appropriate motor`s control relay for that direction of travel.
This was done in case the robot`s control program did not stop the arm`s travel in time to prevent it from crashing into an end-stop. Collision detection was performed via infrared proximity sensors. Specifically, the Radio Shack part number 276-137 infrared receiver was used in conjunction with some generic IR LED`s.
The Radio Shack part was intended for use in infrared remote controls. It contained all the circuitry necessary to detect the presence of an infrared signal modulated at 40 KHz and reject other signals. It was ideal because it was extremely sensitive and relatively immune to noise. However, it would generate pulsing signals when a received IR signal was at the edge of its detection range.
This problem was corrected by a simplistic low pass filter with hysteresis built from a 555. (The actual circuit used two 558`s, four 555`s in one 16 pin DIP package, a schematic of which is included in Appendix B. ) There were eight infrared proximity sensors mounted around the body of the robot. Five were mounted on the base, looking forward, backward, left, right, and downward in front Three more were mounted at the end of the arm looking left, right, and forward.
Their general layout can be seen in Figure 1 below. The sensors were tuned to trigger when an object came within six to nine inches of them. In general, they worked well, failing only in the case of certain walls which were not infrared reflective. Most floors were not to too infrared reflective, so the robot ignored the downward looking front sensor.
Two pyroelectric sensors were also mounted on the robot to detect body heat. One was mounted, forward looking, at the end of the arm. The other was mounted on top of a Futaba servo on the toy`s "head" to scan back and forth looking for people. The pump from a toy motorized water gun was mounted on the arm, pointing forward, its nozzle attached to the end of the arm, and a reservoir for water (a bottle from Neutrogena soap) was mounted on the base.
Two LED`s were added as "eyes" to give the robot per
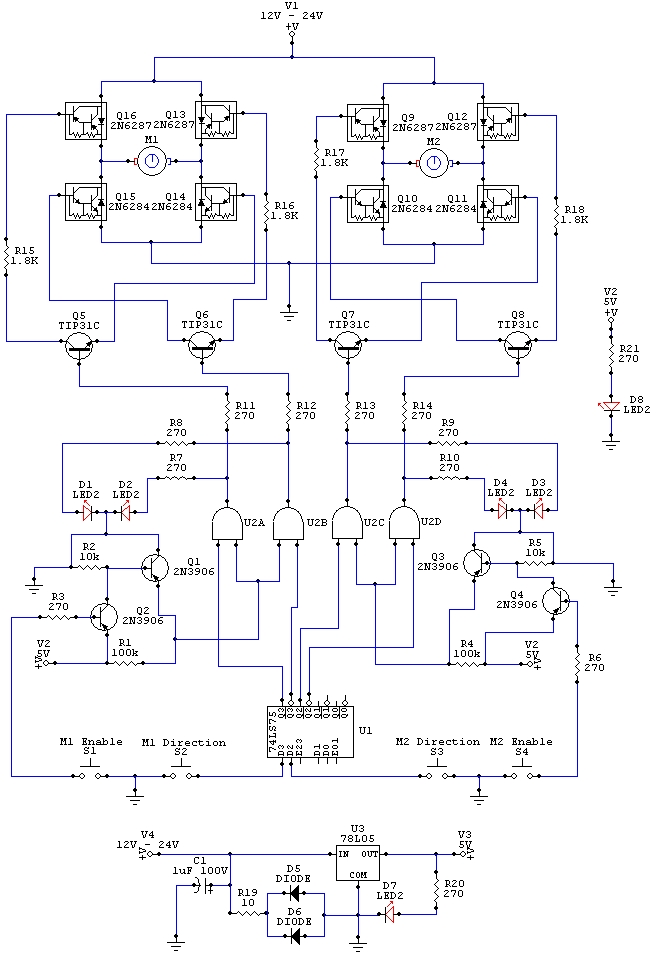
Electronic robot wiring schematic
The wiring schematic played a significant role in the robot. This diagram is used to graphically display all the wiring of the motor-controlling micro-components that enabled the robot to physically move forward, backward, left, right, and stop. This diagram was...
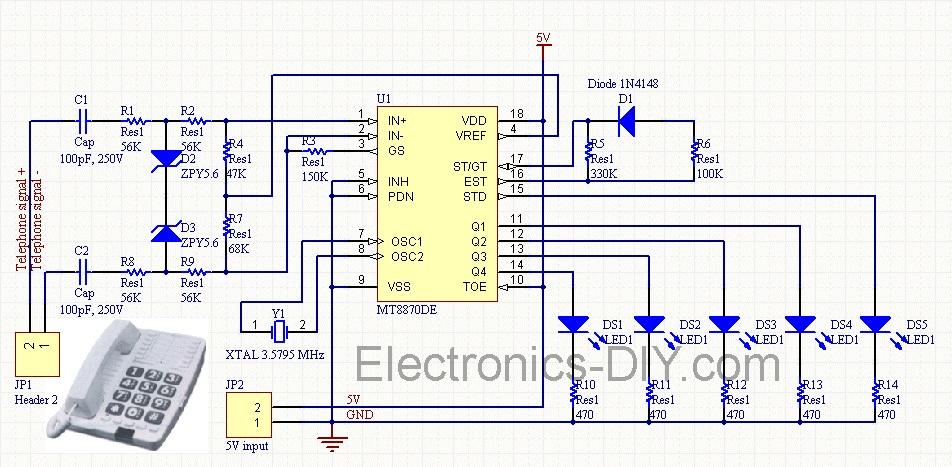
Cellphone Operated Land Rover (Mobile Phone Controlled Robot)
Cellphone Operated Land Rover (Mobile Phone Operated Robot). In this project, the robot is controlled by a mobile phone that makes a call to the mobile phone attached to the robot.
The cellphone operated Land Rover project involves the design and...
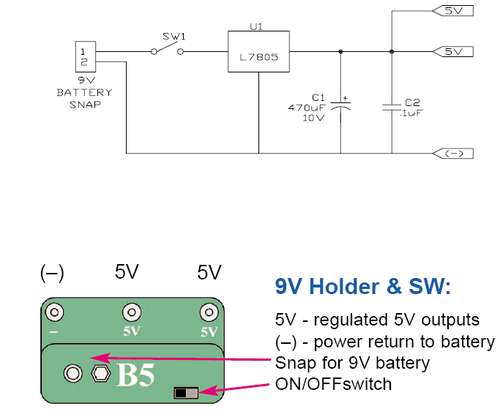
Roverbot circuit
1. A robot may not injure a human being or, through inaction, allow a human being to come to harm. 2. A robot must obey the orders given to it by human beings, except where such orders would conflict with...
Discrete Robot
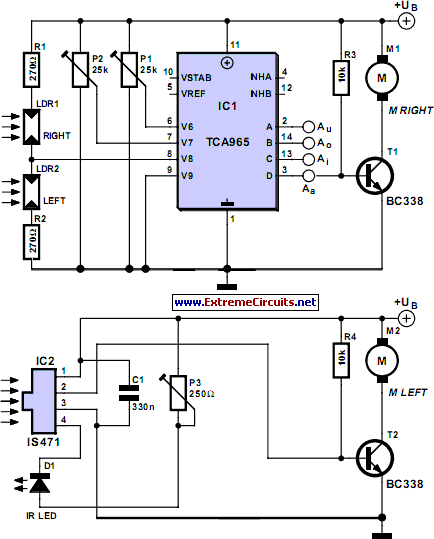
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The only specialized component in the circuit is a window discriminator, which functions as a window comparator. Resistors R1 and R2, in...
The Remote Controlling Circuit
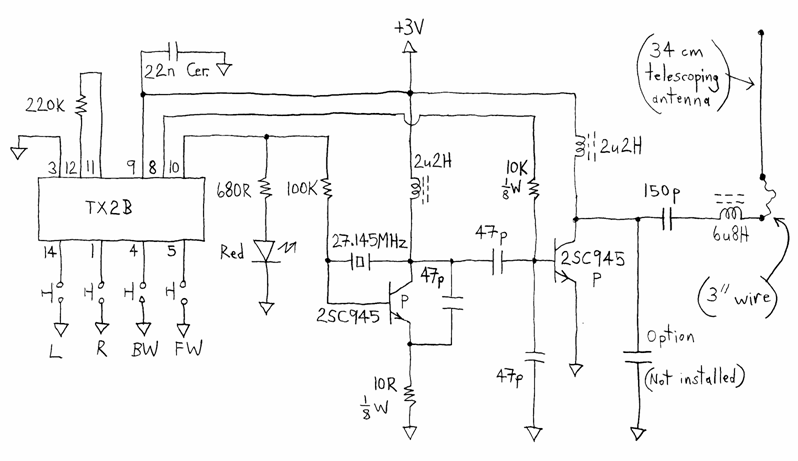
The design of this project relies heavily on sensors, which are present in both the control module and the robot. The computer analyzes the signals from these sensors to determine appropriate output actions. The control unit utilizes potentiometers as its...
discrete robot schematics
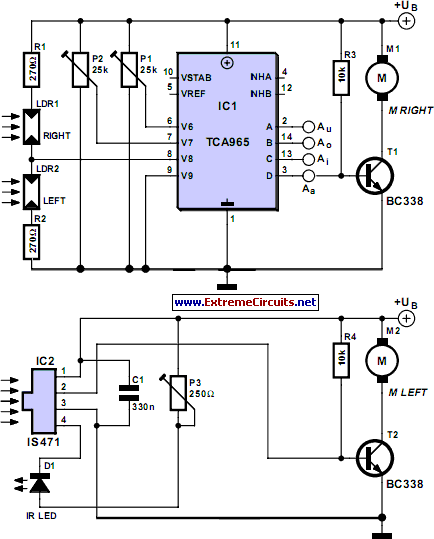
This simple robot responds to light and avoids obstacles without the need for a microcontroller, programmer, or PC. The primary component in the circuit is a window discriminator, which functions as an advanced window comparator. Resistors R1 and R2, in...
Simple Robot That Drives Forward and Back
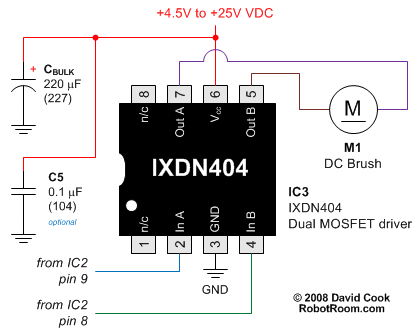
The Flip-Flop Robot drives forward until it encounters an obstacle, at which point it reverses until it strikes another obstacle. This back-and-forth motion continues indefinitely. By simplifying the functionality to this basic behavior, the robot can be constructed using an...
Homemade Robots polymax improvements
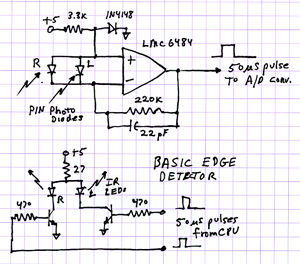
The 2009 Robot Rally highlighted the flaws resulting from a rapid three-week engineering and building project. Time-saving shortcuts in both code and hardware led to multiple failures, including edge detectors, beacon trackers, and line follower reversals. Investigations were conducted into...
robot guts
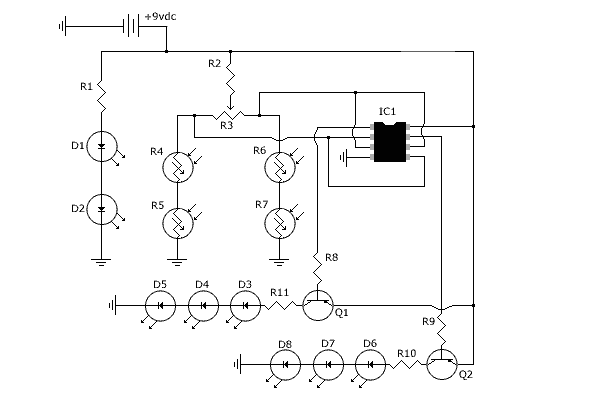
The headlights and photo cells are oriented downward, leading to the visualization of the entire circuit as being inverted. The configuration utilizes three LEDs on each side. This choice is likely due to the inability to power three LEDs in...