


Short Range Personal Radar Circuit
#radar
#servo
#IR proximity sensor
#LED display
#PIC microcontroller
#distance measurement
#short range
#personal radar
#programmable
#sensor array
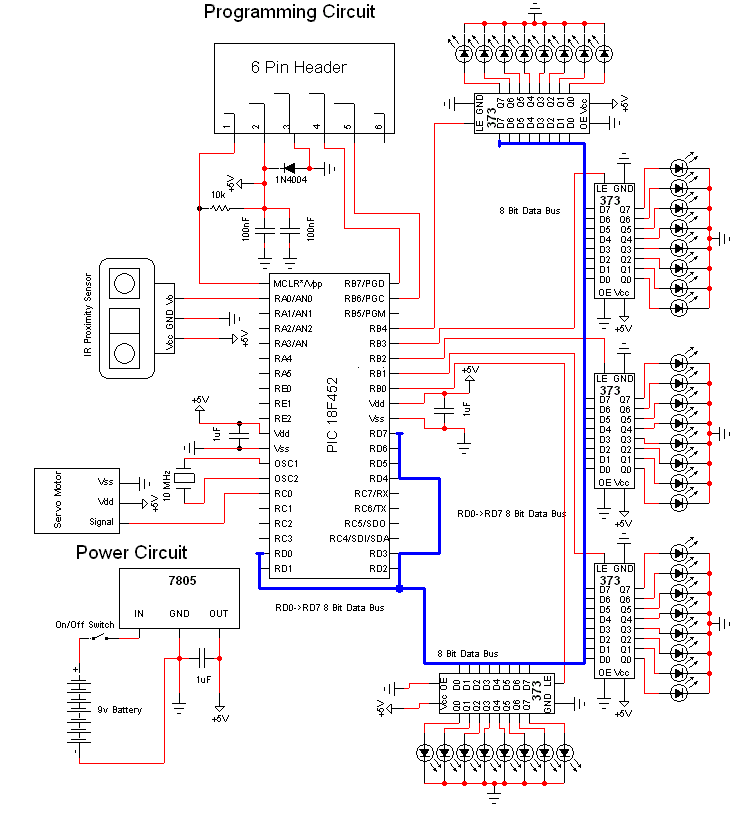
Description: The schematic for this project is significantly more complex than previous designs. There are four primary features in the design: (1) the ability to program the PIC microcontroller on the developed board, (2) control of a servo motor, (3) data input from an IR proximity sensor, and (4) the use of 36 LEDs to visually represent the data detected by the IR sensor. The power circuit consists of a 9V battery connected to an LM7805 voltage regulator, with a 1µF capacitor connected to both the output and ground of the LM7805 to maintain a steady 5V DC output. The programming circuit is established by connecting two pins from the PIC to the programmer, allowing the programmer's pin 1 to access the MCLR*/Vpp-Pin1 on the PIC. A rectifier diode is included for safety. The IR sensor utilizes one pin from the PIC, specifically PIN 2 - RA0, which employs the analog functionality of this pin to obtain an ADC value, as the proximity sensor outputs only analog voltages. This ADC value indicates whether any objects are near the sensor in the environment. A total of 40 LEDs will be used, and since each 74HCT373 can control up to 8 LEDs, five 74HCT373 chips will be necessary to manage all 40 LEDs. It is important to note that a common data bus is shared among all five chips.
The circuit design integrates several components to achieve the desired functionality. The power supply circuit is crucial for providing a stable voltage to the entire system. The LM7805 voltage regulator is selected for its reliability in converting the 9V battery output to a consistent 5V, which is essential for the microcontroller and other components to operate efficiently. The inclusion of a 1µF capacitor at the output ensures that any voltage fluctuations are smoothed out, thereby enhancing the stability of the power supply.
For programming the PIC microcontroller, the design allows for direct connection to a programming device via two designated pins. The connection to the MCLR*/Vpp pin is vital for resetting and programming the microcontroller, while the rectifier diode serves to protect the circuit from potential back EMF or voltage spikes, ensuring the longevity of the components.
The IR proximity sensor is a key element in this project, providing real-time data about the presence of objects in the vicinity. By utilizing the analog input capabilities of PIN 2 - RA0, the microcontroller can convert the analog voltage signal from the sensor into a digital value using the onboard ADC. This value can then be processed to determine the proximity of objects, enabling the system to respond appropriately.
The LED display serves as a visual output mechanism to convey information based on the proximity sensor's readings. With a total of 40 LEDs, the design employs five 74HCT373 chips to manage the LED control. Each chip can handle 8 LEDs, and the common data bus facilitates communication between the microcontroller and the chips, allowing for synchronized control of the LED outputs. This arrangement not only simplifies the wiring but also enhances the overall efficiency of the design, enabling a clear and effective display of the sensor's data.
Overall, this circuit schematic represents a comprehensive approach to integrating various electronic components to achieve a multi-functional system capable of programming, sensing, and visual output.The schematic for this project is much more complicated than previous projects. There are four main features in our design. (1) We will be able to program the pic on the board we develop. (2) We will be controlling a servo. (3) We will be taking data input from an IR Proximity sensor. (4) We will set 36 LEDs to display proper output to respresent what the IR sensor sees. The power circuit is a 9v Battery hooked up to the LM7805 with a 1uF capacitor hooked to output & ground of the LM7805 to keep a steady 5v DC. The programming circuit is made by hooking up two pins from the PIC to the programmer and allowing the programmer`s pin 1 access to the MCLR*/Vpp-Pin1 on the PIC.
We put a rectifier diode in there for safety as well. The IR Sensor only uses 1 pic from the pic, PIN 2 - RA0. It will use the analog feature of this pin to get an ADC value as the proximity sensor only outputs analog voltages. This value will tell us the if anything is near the sensor in our enviornment. There are 40 LEDs in total. Since each 74HCT373 can control up to 8 leds; 40/8 = 5 we`ll need to use 5 74HCT373`s to be able to control all 40 LEDs.
It is important to notice on the schematic that a common data bus is used between all the 5 chips.
The circuit design integrates several components to achieve the desired functionality. The power supply circuit is crucial for providing a stable voltage to the entire system. The LM7805 voltage regulator is selected for its reliability in converting the 9V battery output to a consistent 5V, which is essential for the microcontroller and other components to operate efficiently. The inclusion of a 1µF capacitor at the output ensures that any voltage fluctuations are smoothed out, thereby enhancing the stability of the power supply.
For programming the PIC microcontroller, the design allows for direct connection to a programming device via two designated pins. The connection to the MCLR*/Vpp pin is vital for resetting and programming the microcontroller, while the rectifier diode serves to protect the circuit from potential back EMF or voltage spikes, ensuring the longevity of the components.
The IR proximity sensor is a key element in this project, providing real-time data about the presence of objects in the vicinity. By utilizing the analog input capabilities of PIN 2 - RA0, the microcontroller can convert the analog voltage signal from the sensor into a digital value using the onboard ADC. This value can then be processed to determine the proximity of objects, enabling the system to respond appropriately.
The LED display serves as a visual output mechanism to convey information based on the proximity sensor's readings. With a total of 40 LEDs, the design employs five 74HCT373 chips to manage the LED control. Each chip can handle 8 LEDs, and the common data bus facilitates communication between the microcontroller and the chips, allowing for synchronized control of the LED outputs. This arrangement not only simplifies the wiring but also enhances the overall efficiency of the design, enabling a clear and effective display of the sensor's data.
Overall, this circuit schematic represents a comprehensive approach to integrating various electronic components to achieve a multi-functional system capable of programming, sensing, and visual output.The schematic for this project is much more complicated than previous projects. There are four main features in our design. (1) We will be able to program the pic on the board we develop. (2) We will be controlling a servo. (3) We will be taking data input from an IR Proximity sensor. (4) We will set 36 LEDs to display proper output to respresent what the IR sensor sees. The power circuit is a 9v Battery hooked up to the LM7805 with a 1uF capacitor hooked to output & ground of the LM7805 to keep a steady 5v DC. The programming circuit is made by hooking up two pins from the PIC to the programmer and allowing the programmer`s pin 1 access to the MCLR*/Vpp-Pin1 on the PIC.
We put a rectifier diode in there for safety as well. The IR Sensor only uses 1 pic from the pic, PIN 2 - RA0. It will use the analog feature of this pin to get an ADC value as the proximity sensor only outputs analog voltages. This value will tell us the if anything is near the sensor in our enviornment. There are 40 LEDs in total. Since each 74HCT373 can control up to 8 leds; 40/8 = 5 we`ll need to use 5 74HCT373`s to be able to control all 40 LEDs.
It is important to notice on the schematic that a common data bus is used between all the 5 chips.
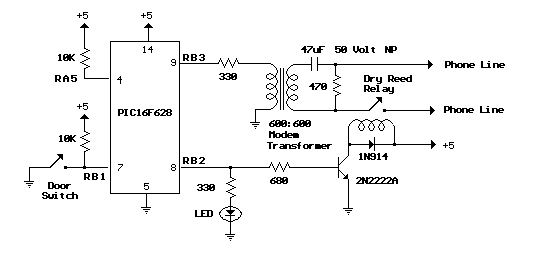
Auto-Phone dialer for alarm security system
The circuit consists of a small PIC microcontroller, assembly program, and a few other parts to detect a switch closure from an open door, window, or manual push button and then dial the cell phone number, and transmit a steady...
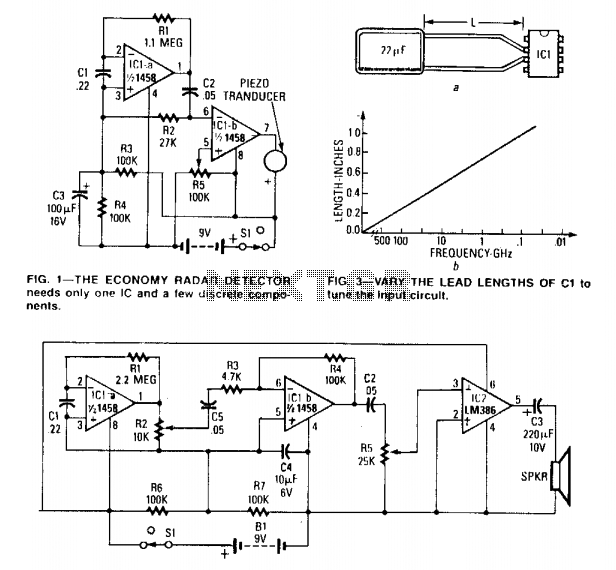
Radar signal detector
The circuit can be tuned to respond to signals between 50 MHz and 500 GHz. The economy model is illustrated in Figure 1, while the deluxe model is depicted in Figure 2. The first operational amplifier (op-amp) in each circuit...
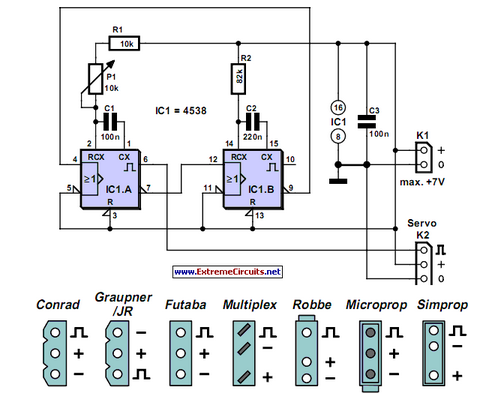
Servo Tester Using A 4538
Individuals who frequently work with servos are likely familiar with situations where a servo tester is beneficial. The primary function of a servo tester is to produce a pulsing signal with a variable positive pulse width ranging from 1 to...
Programmable Current and Voltage Regulator for Battery Charger
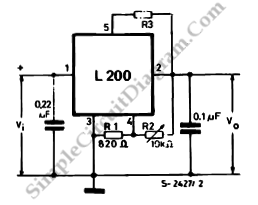
This is a programmable current and voltage regulator circuit. It consists of a voltage regulator with external current limitation. The variable resistor R2 is...
The programmable current and voltage regulator circuit is designed to provide precise control over output voltage and...
Servo Driver
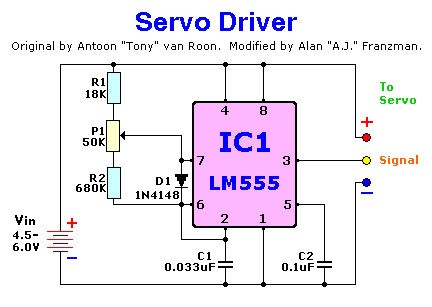
This circuit can be utilized to verify the functionality of servos, assess full travel, detect binding, and identify any drag or rubbing when the servos are integrated into a model. It may also serve as a control circuit in robotics...
USB Servo
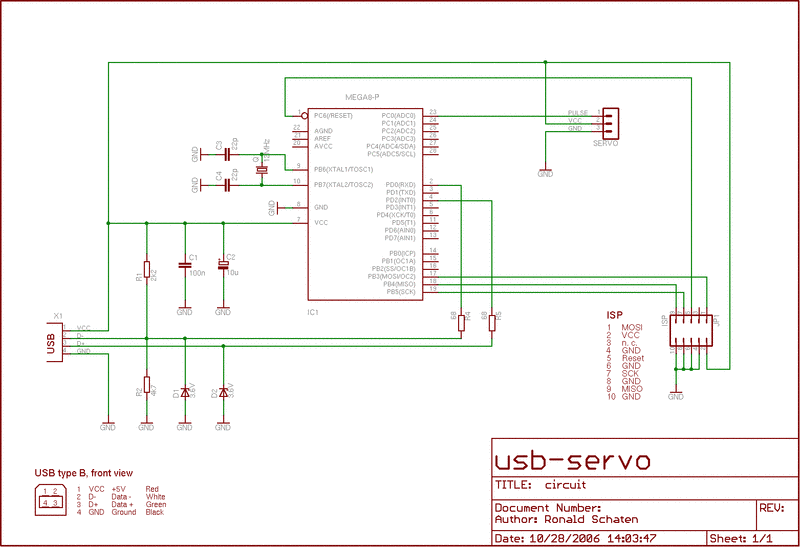
The USB-Servo is a device designed to control a servo motor via a USB connection. Servos are motorized components commonly utilized in remote-controlled cars and airplanes. This specific device was created to activate a toy puppet. The puppet is equipped...
Animation with Servos
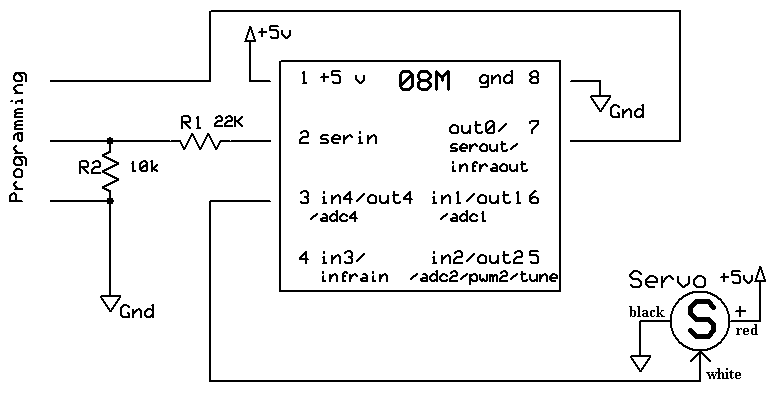
A servo consists of a small motor and gear mechanism that rotates a shaft to a precise location and maintains that position. The image displays a typical servo with its cover removed. The shaft's position is controlled by a digital...
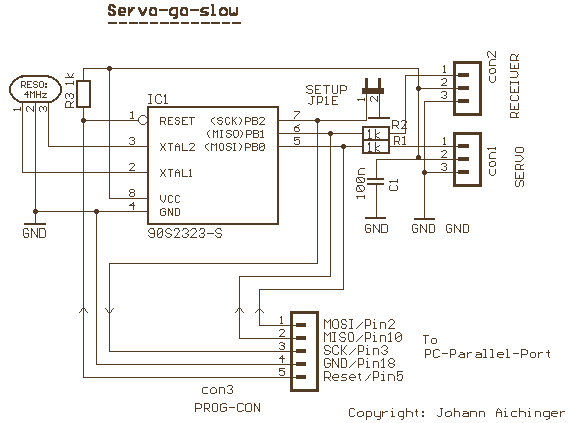
Slow Servo
Realistic flap and landing gear actuation.
This circuit slows the speed of a conventional proportional servo. It regulates the time required for full servo rotation from 1 to 10 seconds without any reduction in the servo's torque, and every servo position...
pic micro multiple servo motor
The program utilizes two pulse width variables, pw1 and pw2, along with two sets of routines—left1 and left2, and right1 and right2—designated for each motor. The schematic illustrates that the first servo is connected according to the previous circuit design....