


pic micro multiple servo motor
#PIC microcontroller
#servo motor
#pulse width modulation
#motor control
#SPDT switch
#CCW/CW sweep
#B3 pin
#B4 pin
#B5 pin
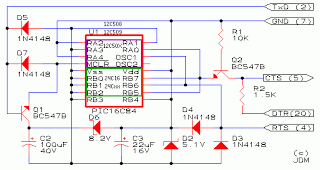
Description: The program utilizes two pulse width variables, pw1 and pw2, along with two sets of routines—left1 and left2, and right1 and right2—designated for each motor. The schematic illustrates that the first servo is connected according to the previous circuit design. The second servo employs B3 as its pulse output, while B4 and B5 are used for the SPDT switch. The servomotor is programmed to sweep from counterclockwise (CCW) to clockwise (CW) and then back. The program is designed to remain straightforward to demonstrate the principles of servo control using the PIC Basic language. The variable pw manages the pulse width, starting at 100 (extreme left, -45 degrees), and increases by increments of 1 until it reaches 200 (extreme right, 45 degrees), at which point the rotation is reversed. This programmer is powered by RS-232 and operates at RS-232 levels of less than ±8.6V. It is compatible with PIC12C5XX, 12C67X, 24CXX, 16C55X, 16C61, 16C62X, 16C71, 16C71X, 16C8X, 16F8X, and ISO-CARDs with ASF, as well as other serial programmable chips via an adapter. The programmer supports In-Circuit Serial Programming (ICSP). The utilities function on DOS, Windows 3.1, Windows 95, Windows 98, and are expected to be compatible with other operating systems. The software includes a modem check feature to prevent the programming of modem flashes if the cable is not swapped between the programmer and the modem. Additionally, it allows for the programming of multiple chips simultaneously using various communication ports while multitasking under Windows. The software automatically optimizes delays based on cable length and supports modem cables up to 100 meters. It utilizes only the RS-232 controller chip without relying on other timers, and short programming pulses are now controlled by hardware. Laptops have been tested only with PIC16C8x and 24Cxx.
The circuit described involves a microcontroller-based system designed for controlling servomotors through pulse width modulation (PWM). The primary components include a microcontroller capable of generating PWM signals, a dual-servo configuration, and an RS-232 interface for programming and communication. The two pulse width variables, pw1 and pw2, are essential for managing the positions of the servos, with specific routines assigned for each direction of rotation.
The first servo is wired according to a previously established circuit design, ensuring compatibility and ease of integration. The second servo's configuration utilizes B3 for its pulse output, while B4 and B5 facilitate the operation of a single-pole double-throw (SPDT) switch, allowing for versatile control of the servomotor's direction. The program logic dictates that the servomotor sweeps from an initial counterclockwise position to a clockwise position, demonstrating the full range of motion.
The pulse width control variable, pw, initiates at a value corresponding to the extreme left position of the servo, translating to -45 degrees. The program incrementally increases this value until the servo reaches the extreme right position at 45 degrees, effectively reversing the direction of rotation. This functionality illustrates the basic principles of servo control using the PIC Basic language, providing a clear example of PWM in action.
The programmer's architecture is powered by an RS-232 interface, operating within specified voltage levels, which is critical for ensuring reliable communication with the microcontroller. The programmer supports a wide range of PIC microcontroller families, facilitating flexibility in application. The inclusion of In-Circuit Serial Programming (ICSP) allows for direct programming of microcontrollers while they are installed in the circuit, enhancing convenience and efficiency.
The software associated with the programmer is designed for compatibility across multiple operating systems, ensuring broad usability. The modem check feature is a critical safeguard, preventing accidental programming errors that could arise from misconfigured connections. Furthermore, the ability to program multiple chips simultaneously and optimize communication parameters based on cable length enhances the system's efficiency, making it suitable for various applications in electronics development.
In summary, this circuit exemplifies an effective implementation of servo control using PWM, supported by a robust programming interface, making it a valuable resource for electronics engineers and hobbyists alike.The program uses two pulsewidth variables, pw1 and pw2; and two sets of routines, left1 and left2, right1 and right2; one for each motor. As you can see in the schematic, the first servo is wired as per the previous circuit. The second servo is now using B3 as it`s pulse out, and B4 and B5 for the SPDT switch. sweep the servomotor from CCW to CW a nd then sweep back. The program will be kept simple as to demonstrate the priniciples of controlling a servo with a the PIC Basic language. The variable pw controls the pulsewidth, and is started at 100 (extreme left, -45 degrees). The program sends the pulse out to the servo, and then is increased by a value of 1 until it reaches 200 (extreme right, 45 degrees), at which point it will reverese the rotation.
This Programmer is powered by the RS-232 and it works with RS-232 levels at only < ±8. 6V. It programs PIC12C5XX, 12C67X, 24CXX, 16C55X, 16C61, 16C62X, 16C71, 16C71X, 16C8X, 16F8X and ISO-CARD`s with ASF. Other serial programmable chips by adapter. The Programmer supports ICSP, In-Circuit Serial Programming. Features: Utilities now work on Dos, Windows 3. 1, Windows 95, Windows 98 and are expected to work on all other operating systems. All software does modemcheck to ensure that modems flash are not programmed by programmer, e. g. if you forgot to swap cable between programmer and modem. It is now possible to program more chips at same time using more of the communication port`s while multitasking under Windows.
The software automatic optimize delay for cable length and works with modem cables up to 100m. It use the RS232 controler chip only, and does not invoke use of other timers. Also short programming pulses are now hardware controled. Laptops only tested with PIC16C8x and 24Cxx.
The circuit described involves a microcontroller-based system designed for controlling servomotors through pulse width modulation (PWM). The primary components include a microcontroller capable of generating PWM signals, a dual-servo configuration, and an RS-232 interface for programming and communication. The two pulse width variables, pw1 and pw2, are essential for managing the positions of the servos, with specific routines assigned for each direction of rotation.
The first servo is wired according to a previously established circuit design, ensuring compatibility and ease of integration. The second servo's configuration utilizes B3 for its pulse output, while B4 and B5 facilitate the operation of a single-pole double-throw (SPDT) switch, allowing for versatile control of the servomotor's direction. The program logic dictates that the servomotor sweeps from an initial counterclockwise position to a clockwise position, demonstrating the full range of motion.
The pulse width control variable, pw, initiates at a value corresponding to the extreme left position of the servo, translating to -45 degrees. The program incrementally increases this value until the servo reaches the extreme right position at 45 degrees, effectively reversing the direction of rotation. This functionality illustrates the basic principles of servo control using the PIC Basic language, providing a clear example of PWM in action.
The programmer's architecture is powered by an RS-232 interface, operating within specified voltage levels, which is critical for ensuring reliable communication with the microcontroller. The programmer supports a wide range of PIC microcontroller families, facilitating flexibility in application. The inclusion of In-Circuit Serial Programming (ICSP) allows for direct programming of microcontrollers while they are installed in the circuit, enhancing convenience and efficiency.
The software associated with the programmer is designed for compatibility across multiple operating systems, ensuring broad usability. The modem check feature is a critical safeguard, preventing accidental programming errors that could arise from misconfigured connections. Furthermore, the ability to program multiple chips simultaneously and optimize communication parameters based on cable length enhances the system's efficiency, making it suitable for various applications in electronics development.
In summary, this circuit exemplifies an effective implementation of servo control using PWM, supported by a robust programming interface, making it a valuable resource for electronics engineers and hobbyists alike.The program uses two pulsewidth variables, pw1 and pw2; and two sets of routines, left1 and left2, right1 and right2; one for each motor. As you can see in the schematic, the first servo is wired as per the previous circuit. The second servo is now using B3 as it`s pulse out, and B4 and B5 for the SPDT switch. sweep the servomotor from CCW to CW a nd then sweep back. The program will be kept simple as to demonstrate the priniciples of controlling a servo with a the PIC Basic language. The variable pw controls the pulsewidth, and is started at 100 (extreme left, -45 degrees). The program sends the pulse out to the servo, and then is increased by a value of 1 until it reaches 200 (extreme right, 45 degrees), at which point it will reverese the rotation.
This Programmer is powered by the RS-232 and it works with RS-232 levels at only < ±8. 6V. It programs PIC12C5XX, 12C67X, 24CXX, 16C55X, 16C61, 16C62X, 16C71, 16C71X, 16C8X, 16F8X and ISO-CARD`s with ASF. Other serial programmable chips by adapter. The Programmer supports ICSP, In-Circuit Serial Programming. Features: Utilities now work on Dos, Windows 3. 1, Windows 95, Windows 98 and are expected to work on all other operating systems. All software does modemcheck to ensure that modems flash are not programmed by programmer, e. g. if you forgot to swap cable between programmer and modem. It is now possible to program more chips at same time using more of the communication port`s while multitasking under Windows.
The software automatic optimize delay for cable length and works with modem cables up to 100m. It use the RS232 controler chip only, and does not invoke use of other timers. Also short programming pulses are now hardware controled. Laptops only tested with PIC16C8x and 24Cxx.
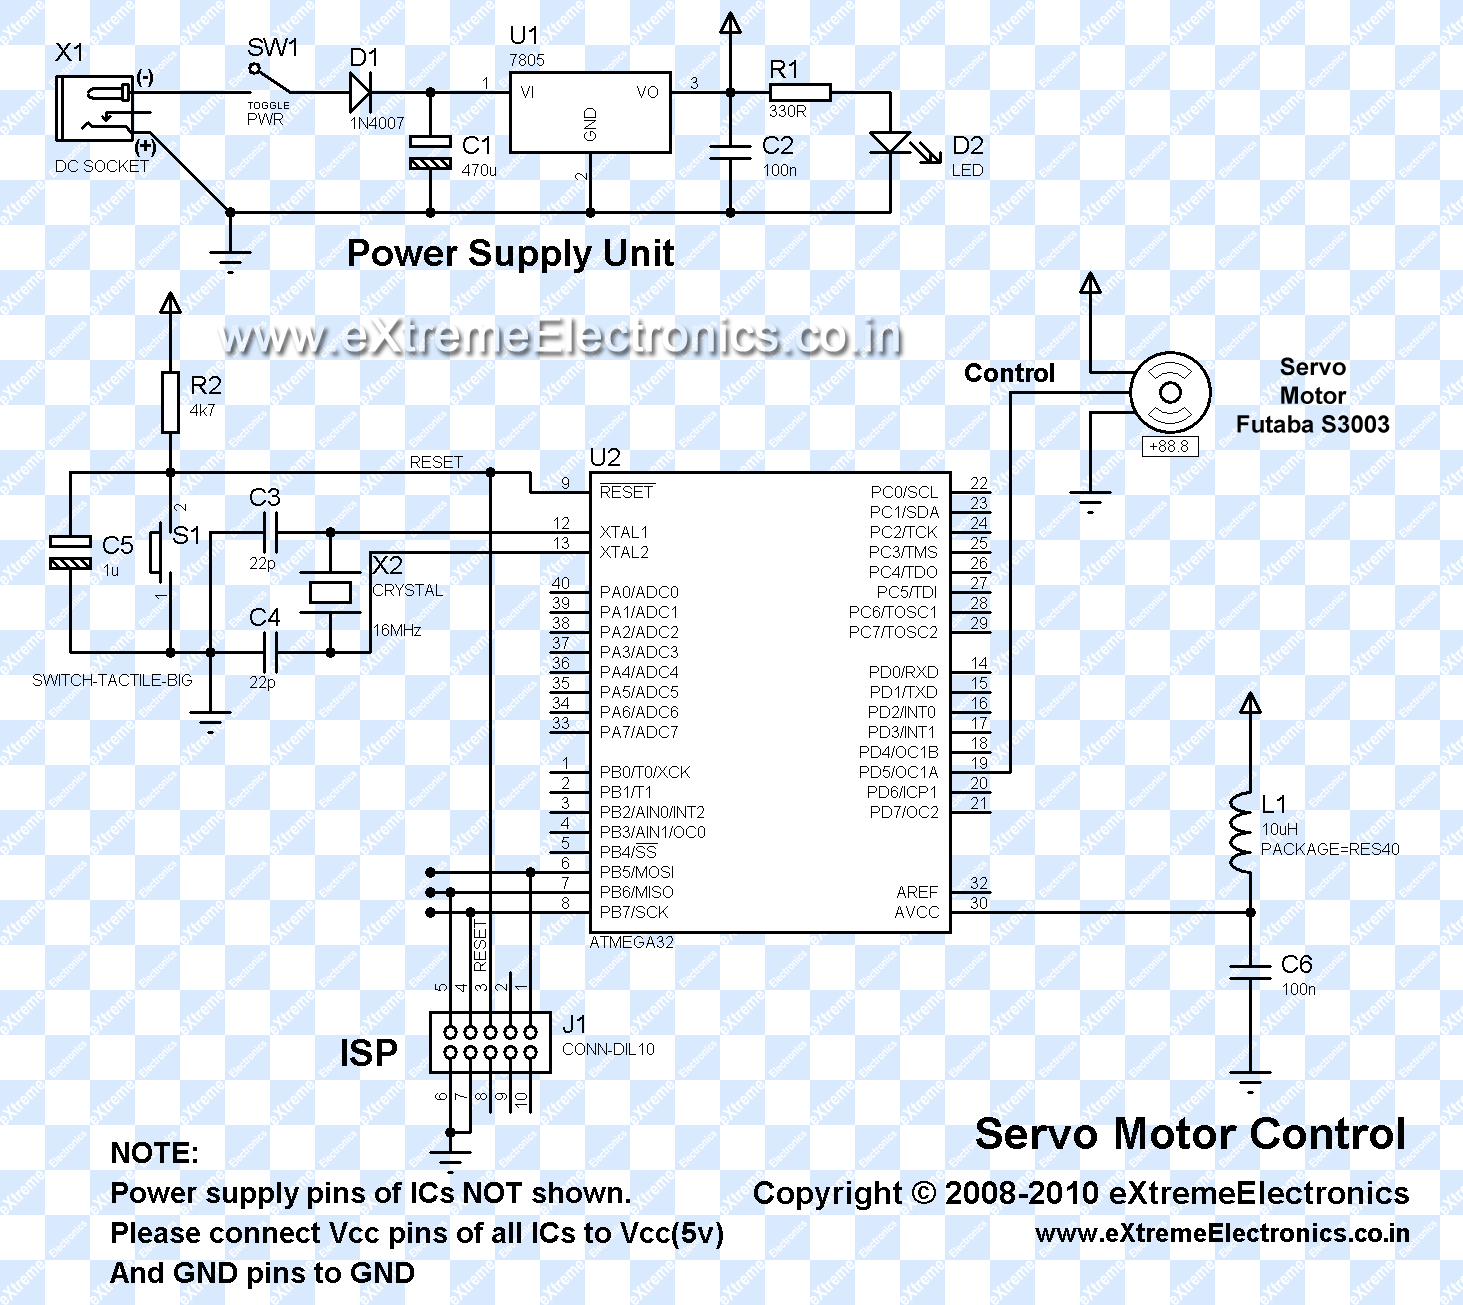
Servo Motor Control by Using AVR ATmega32 Microcontroller
This article is intended for complete beginners with servo motors. It provides an overview of the basic theory behind servo motors and offers detailed instructions on how to utilize them with AVR microcontrollers such as the ATmega32.
Servo motors are electromechanical...
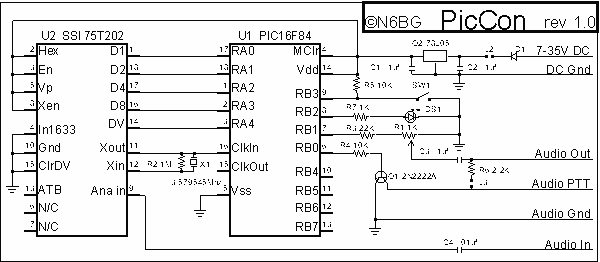
Hidden Radio Transmitter Controller
PicCon is a PIC microcontroller based radio controller designed for hidden transmitter hunting. When combined with a radio transmitter, it will produce tone sequences and Morse code messages at user-programmed times. It is completely field programmable via DTMF tones, utilizes...
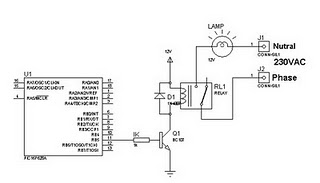
Control A Relay from PIC Microcontroller
A relay can be controlled using a PIC microcontroller. The circuit illustrates how to control a single relay with the PIC 16F628. When the RB5 port of the PIC is set to high, the relay will activate. This circuit is...
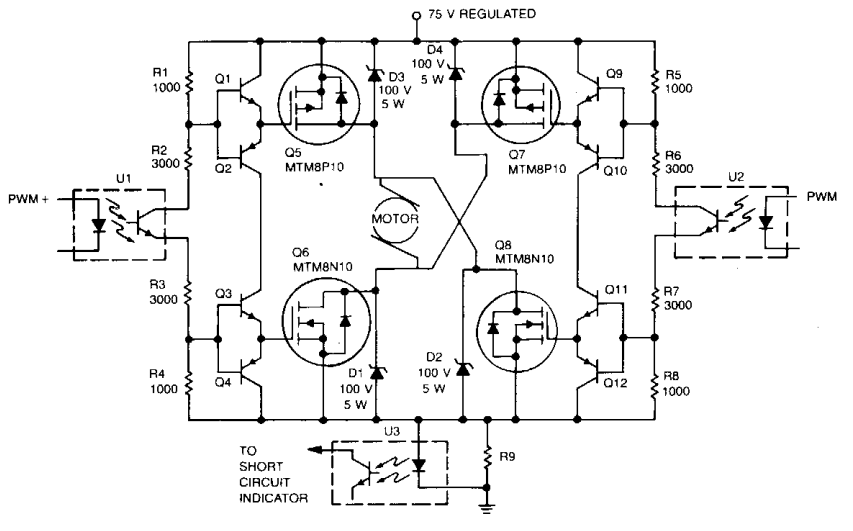
Servo motor drive amplifier
Digital integrated circuits (ICs) and opto-isolators supply the drive for this TMOS servo amplifier, leading to a reduction in analog circuits and minimizing drift. The fast and consistent turn-on and turn-off characteristics facilitate accurate analog output results directly from the...
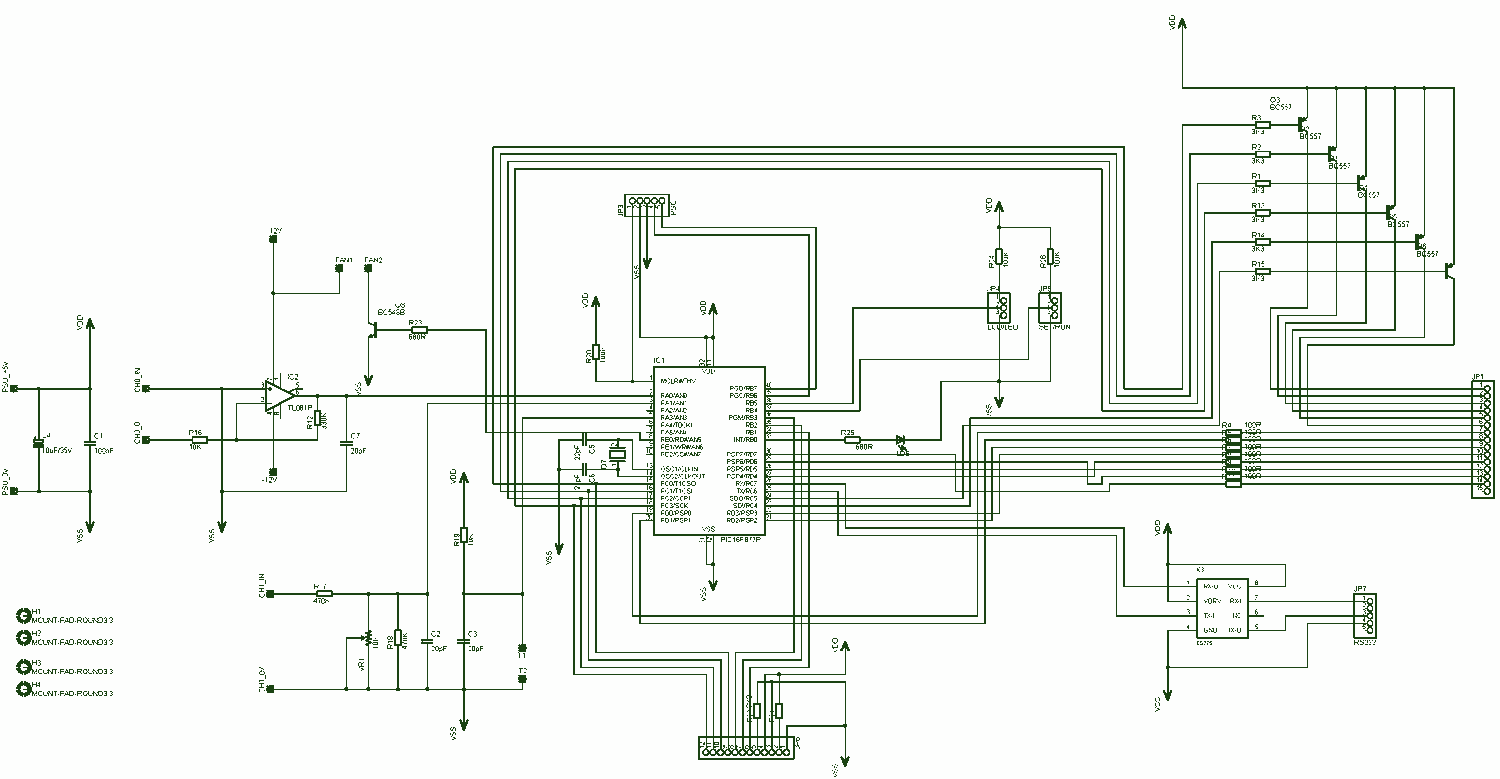
Digital Volt and Amp Meter
The PIC Microchip Processor must be programmed before it will function as a Volt & Amp meter. There are many internet sites and PIC programmers that you can use. I used a Microchip MPLAB ICD 2 during the project. You...
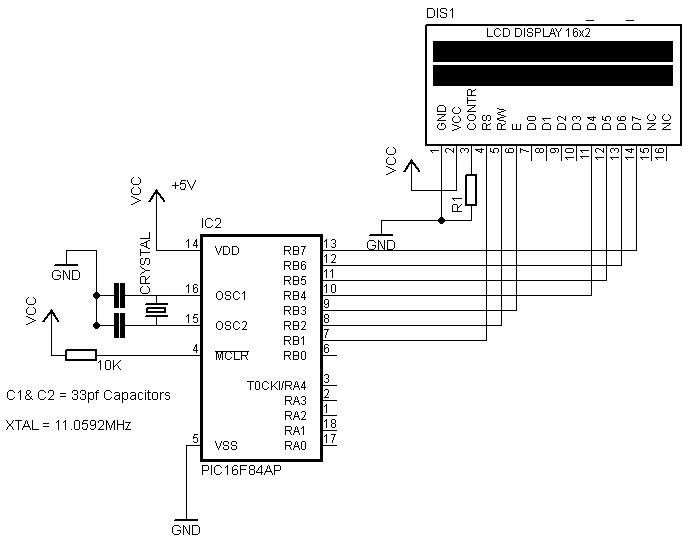
pic lcd interfacing 4 bit mode
This resource provides a variety of PIC Microcontroller tutorials that cater to both beginners and advanced users. These tutorials enable individuals to gain expertise in microcontroller programming and circuit design without the need for costly embedded system courses.
The tutorials cover...
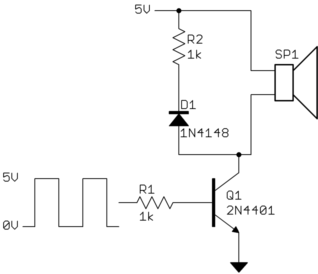
buzzer circuit pic microcontroller
A buzzer circuit utilizes a PIC microcontroller to drive a piezo buzzer. The microcontroller is a low-power processor that is ideal for portable and compact devices where battery conservation is essential.
The buzzer circuit employs a PIC microcontroller, which serves as...
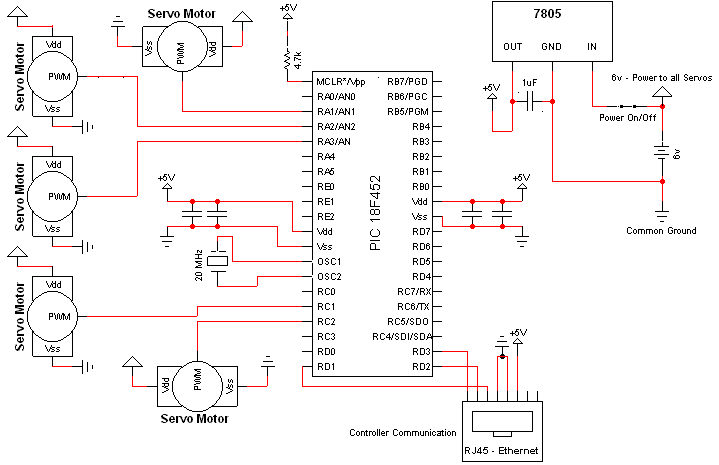
The Wooden Menace Circuit
The hardware schematic for the robotic arm, referred to as the wooden menace, is quite straightforward. The PIC microcontroller has one control line connected to each servo and also connects to an RJ45 connector, which is used to receive input...
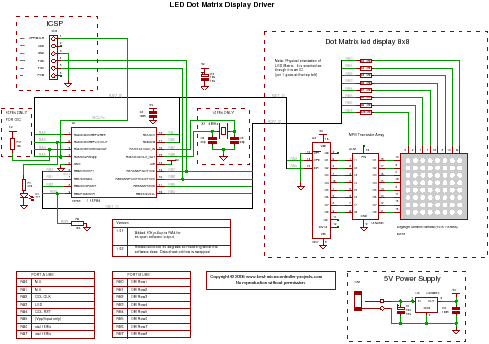
binary clock
How to create a binary clock utilizing a PIC microcontroller with multiplexing to control an LED matrix.
To design a binary clock using a PIC microcontroller, the circuit will primarily consist of the microcontroller, an LED matrix, and multiplexing circuitry. The...