


Servo Motor Control by Using AVR ATmega32 Microcontroller
#servo motor
#AVR
#ATmega32
#PWM
#motor control
#embedded systems
#microcontroller programming
#beginner tutorial
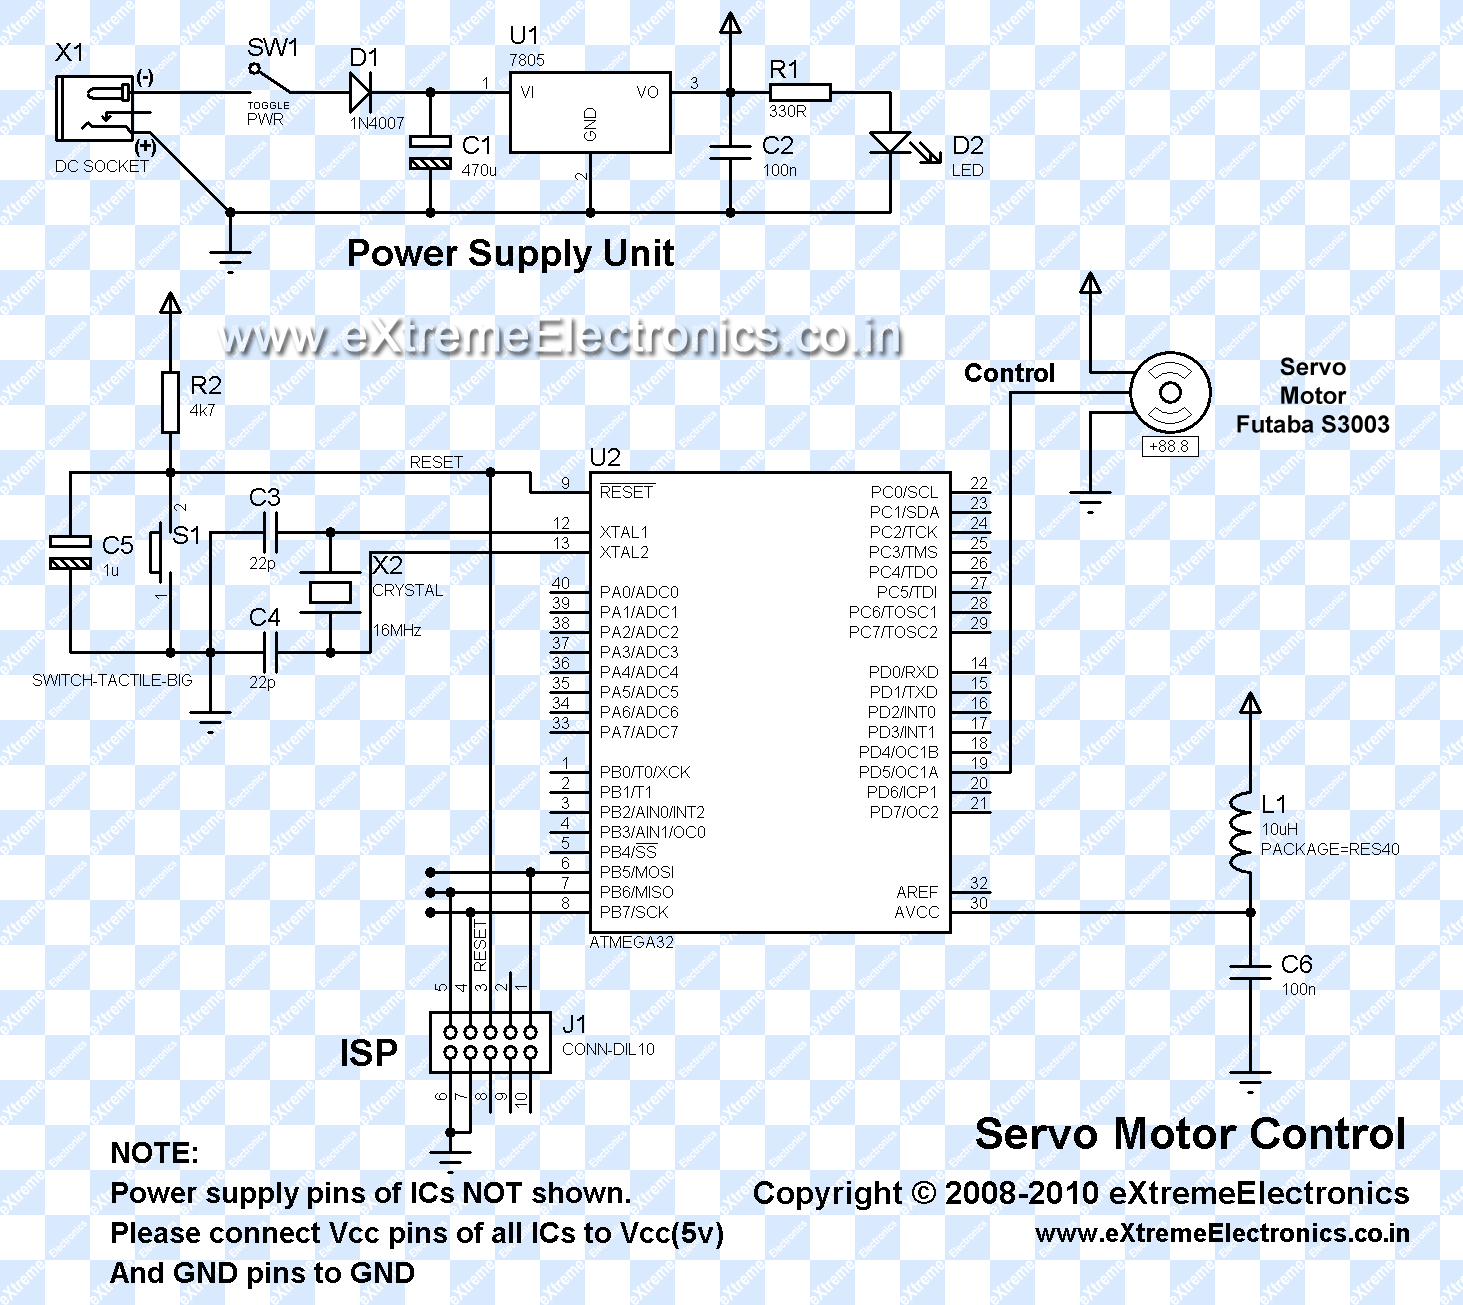
Description: This article is intended for complete beginners with servo motors. It provides an overview of the basic theory behind servo motors and offers detailed instructions on how to utilize them with AVR microcontrollers such as the ATmega32.
Servo motors are electromechanical devices that convert electrical energy into precise angular motion. They are commonly used in robotics, automation, and control systems due to their ability to achieve accurate positioning. The fundamental components of a servo motor include a DC motor, a potentiometer, a control circuit, and a gearbox, which together enable the motor to achieve a specific angle based on input signals.
When interfacing a servo motor with an AVR microcontroller like the ATmega32, it is essential to understand the control signal requirements. Servo motors typically accept a PWM (Pulse Width Modulation) signal, where the width of the pulse determines the angle of rotation. For instance, a pulse width of 1.5 milliseconds usually corresponds to the neutral position (0 degrees), while pulse widths of 1 millisecond and 2 milliseconds correspond to the extreme positions (e.g., -90 degrees and +90 degrees, respectively).
To effectively control a servo motor using an ATmega32, the following steps are generally involved:
1. **Circuit Design**: A basic circuit includes the ATmega32 microcontroller connected to the servo motor. The control pin of the servo is connected to one of the PWM-capable pins of the microcontroller. Additionally, power supply connections must be established, ensuring that the servo receives the appropriate voltage and current.
2. **Programming the Microcontroller**: The firmware for the ATmega32 must be developed to generate the PWM signal. This typically involves configuring the timer registers to produce the correct frequency and pulse width. The microcontroller can be programmed using C or assembly language, with libraries available to simplify the PWM generation process.
3. **Testing and Calibration**: After the circuit is assembled and the program is uploaded to the microcontroller, it is important to test the setup. Calibration may be necessary to ensure that the servo responds accurately to the PWM signals. This can be achieved by adjusting the pulse widths in the code and observing the servo's response.
4. **Application Development**: Once the basic control is established, additional functionalities can be implemented. This may include integrating sensors for feedback, creating user interfaces for manual control, or developing algorithms for automated tasks.
By following these guidelines, beginners can successfully work with servo motors and AVR microcontrollers, opening the door to more complex projects in robotics and automation.This article is for complete beginners with servo motors. It teaches you the servo motor basic theory and gives detailed steps to use them with AVR Microcontrollers like ATmega32..
Servo motors are electromechanical devices that convert electrical energy into precise angular motion. They are commonly used in robotics, automation, and control systems due to their ability to achieve accurate positioning. The fundamental components of a servo motor include a DC motor, a potentiometer, a control circuit, and a gearbox, which together enable the motor to achieve a specific angle based on input signals.
When interfacing a servo motor with an AVR microcontroller like the ATmega32, it is essential to understand the control signal requirements. Servo motors typically accept a PWM (Pulse Width Modulation) signal, where the width of the pulse determines the angle of rotation. For instance, a pulse width of 1.5 milliseconds usually corresponds to the neutral position (0 degrees), while pulse widths of 1 millisecond and 2 milliseconds correspond to the extreme positions (e.g., -90 degrees and +90 degrees, respectively).
To effectively control a servo motor using an ATmega32, the following steps are generally involved:
1. **Circuit Design**: A basic circuit includes the ATmega32 microcontroller connected to the servo motor. The control pin of the servo is connected to one of the PWM-capable pins of the microcontroller. Additionally, power supply connections must be established, ensuring that the servo receives the appropriate voltage and current.
2. **Programming the Microcontroller**: The firmware for the ATmega32 must be developed to generate the PWM signal. This typically involves configuring the timer registers to produce the correct frequency and pulse width. The microcontroller can be programmed using C or assembly language, with libraries available to simplify the PWM generation process.
3. **Testing and Calibration**: After the circuit is assembled and the program is uploaded to the microcontroller, it is important to test the setup. Calibration may be necessary to ensure that the servo responds accurately to the PWM signals. This can be achieved by adjusting the pulse widths in the code and observing the servo's response.
4. **Application Development**: Once the basic control is established, additional functionalities can be implemented. This may include integrating sensors for feedback, creating user interfaces for manual control, or developing algorithms for automated tasks.
By following these guidelines, beginners can successfully work with servo motors and AVR microcontrollers, opening the door to more complex projects in robotics and automation.This article is for complete beginners with servo motors. It teaches you the servo motor basic theory and gives detailed steps to use them with AVR Microcontrollers like ATmega32..
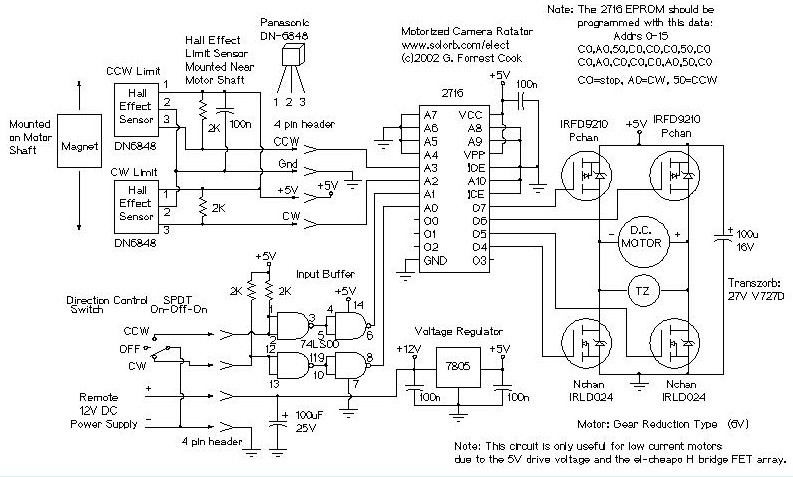
Motorized Video Camera Mount
The camera rotator circuit utilizes a 2716 EPROM to store a logic value table that governs the motor driver (H-bridge) circuit. The schematic illustrates the EPROM data. By employing the EPROM, a significant number of discrete gates are eliminated. The...
Motorized Video Camera Mount
The camera rotator circuit utilizes a 2716 EPROM to store a logic value table that governs the motor driver (H-bridge) circuit. The schematic illustrates the EPROM data. By employing the EPROM, a significant number of discrete gates are eliminated. The...
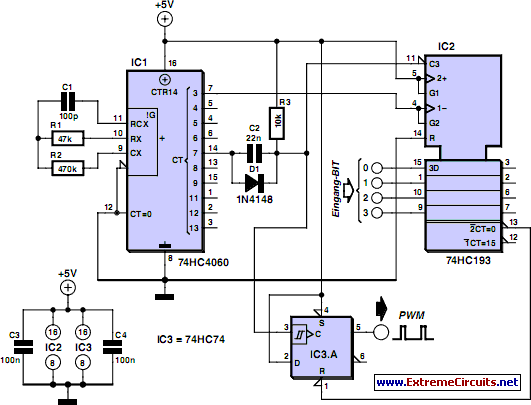
Discrete PWM Generator Circuit
PWM waveforms are widely utilized to regulate the speed of DC motors. The duty cycle of the digital waveform can be established either through an adjustable analog voltage level (as seen in a NE555-based PWM generator) or through digital binary...
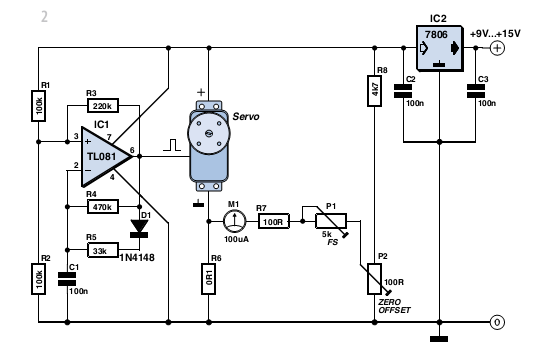
Build an Servo Scales
With some skill, an electronic scale can be constructed using a servo motor. Depending on the servo type, it can measure weights of up to approximately five kilograms (11 lbs) with reasonable accuracy. A detailed examination of the operating principle...
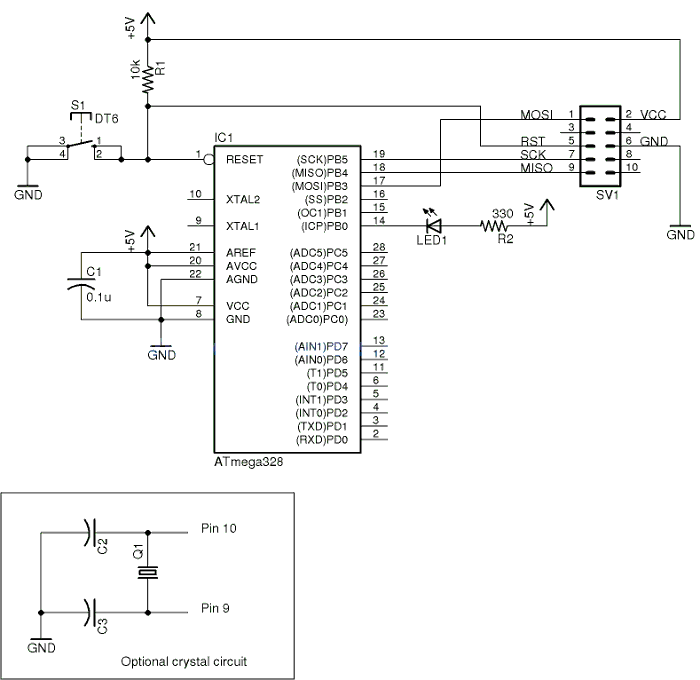
avr microcontroller circuit
The Arduino Uno features an ATMEGA328P-PU microcontroller and various additional components on the board. The objective is to program the microcontroller without relying on the Arduino software, utilizing only the essential components. The goal is to develop projects independently of...
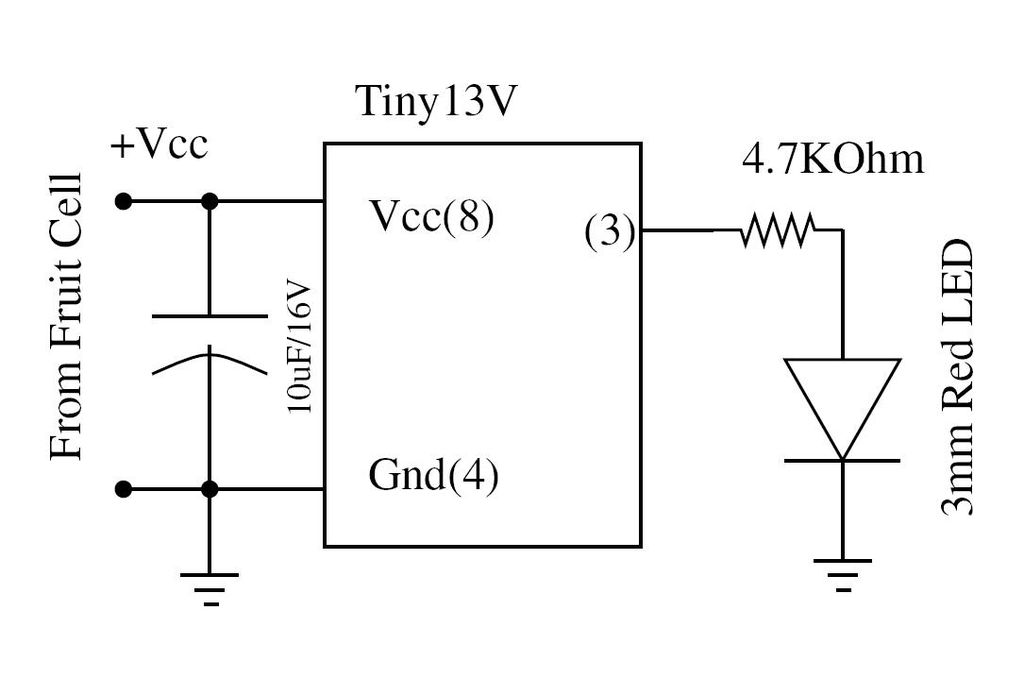
Assemble the AVR Tiny MIcrocontroller Circuit
Wire the circuit diagram shown here on a breadboard. The choice of V type of AVR is important. For example, Tiny13V is very appropriate for such an application.
To successfully implement the circuit diagram on a breadboard, several considerations must be...
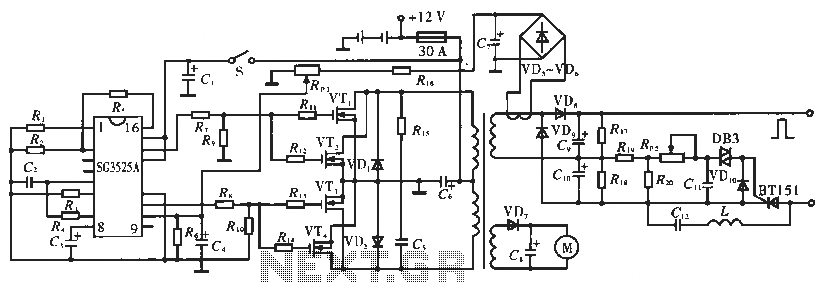
Electronic pulse circuitry fishing
The circuit utilizes the SC3525A, a PWM silicon chip from US General Semiconductor. It features an error amplifier with an inverting input at pin 1. Pin 2 serves as the non-inverting input for the error amplifier. Pins 5 and 6...
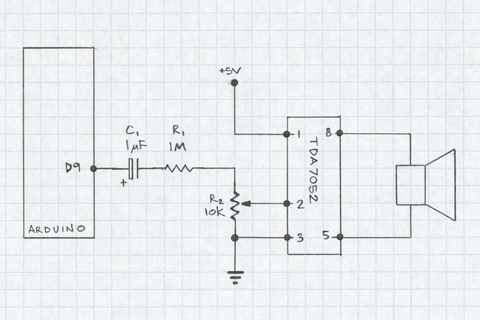
PWM sound Tutorial
This document demonstrates the use of an Arduino PWM output pin to generate sound. The output pin can be toggled rapidly between LOW and HIGH states to create a square wave. If the frequency of this square wave is within...
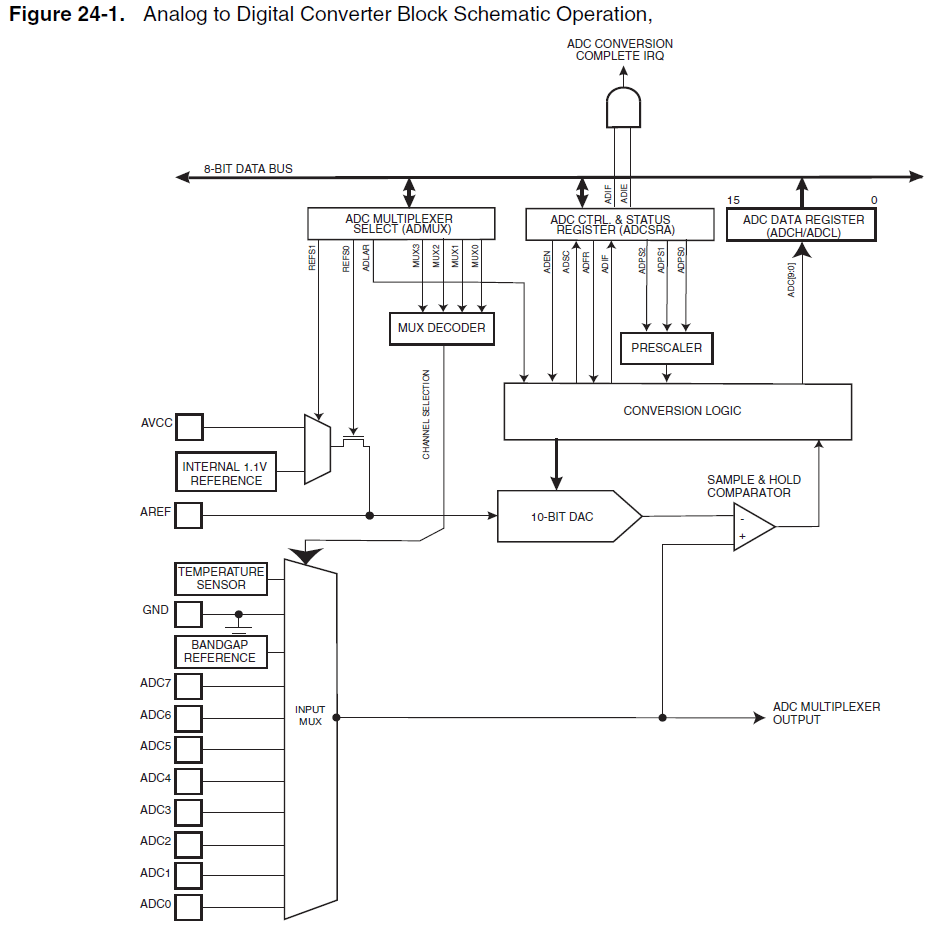
AVR 1.1V Internal ADC Reference Over-Voltage
When using the internal 1.1V reference for the ADC, if the analog input exceeds 1.1V, such as 2.5V, it will not harm the microcontroller. Instead, the ADC value will clip at 0x3FF. Based on practical experience, it has been observed...