


Slow Servo
#servo
#actuation
#proportional control
#speed regulation
#landing gear
#flap control
#torque
#RC models
#position control
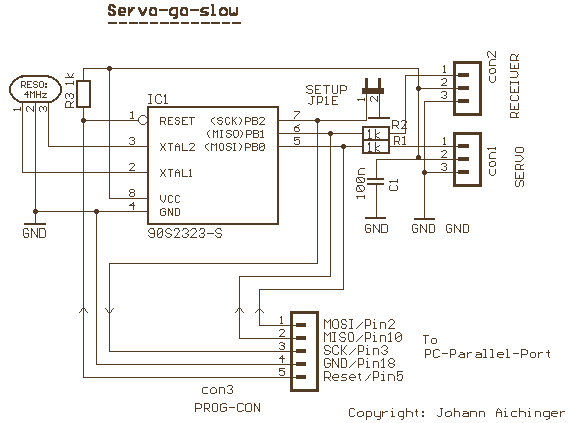
Description: Realistic flap and landing gear actuation.
This circuit slows the speed of a conventional proportional servo. It regulates the time required for full servo rotation from 1 to 10 seconds without any reduction in the servo's torque, and every servo position is possible (proportional). More: It is suitable for:
* Landing gear
* Flaps
* Throttle control of gas-turbine engines
* LMH-110 (with modified hex file, see below) is very simple because it uses a microcontroller. Set-up is also very simple. First program the con
The described circuit is designed to provide smooth and realistic actuation for applications such as landing gear deployment, flap adjustments, and throttle control in gas-turbine engines. The core functionality is achieved through a microcontroller that manages the speed of a conventional proportional servo.
The circuit operates by regulating the pulse width modulation (PWM) signal sent to the servo, which directly influences its rotation speed. By adjusting the duty cycle of the PWM signal, the microcontroller can control the time it takes for the servo to move from one position to another. The design allows for a full range of motion, ensuring that the servo can achieve any position within its operational limits while maintaining its torque characteristics.
The timing for the servo's movement can be configured to range from 1 to 10 seconds, providing flexibility for different applications. This feature is particularly useful in modeling scenarios where realistic motion is required, such as in radio-controlled aircraft or other remote-controlled devices.
The setup process for this circuit is straightforward. Initially, the microcontroller must be programmed with the appropriate firmware, which includes the logic for controlling the servo speed and any specific parameters related to the application (e.g., timing settings for landing gear or flaps). The mention of modifying the hex file for the LMH-110 indicates that specific adjustments may be necessary to tailor the operation of the circuit for different hardware configurations.
In summary, the circuit is an effective solution for achieving realistic actuation in various applications, leveraging the capabilities of a microcontroller to provide precise control over servo movements while ensuring that torque is not compromised. This design is suitable for hobbyists and professionals alike, offering a simple yet powerful means of enhancing the functionality of proportional servos.Realistic flap and landing gear actuation. This circuit slows the speed of a conventional proportional servo. It regulates the time required for full servo rotation from 1 to 10 seconds without any reduction in the servo`s torque, and every servo position is possible (proportional). It is suitable for: * Landing gear * Flaps * Throttle control of gas-turbine engines * LMH-110 (with modified hex file, see below) is very simple because it uses a microcontroller. Set-up is also very simple. First program the con
This circuit slows the speed of a conventional proportional servo. It regulates the time required for full servo rotation from 1 to 10 seconds without any reduction in the servo's torque, and every servo position is possible (proportional). More: It is suitable for:
* Landing gear
* Flaps
* Throttle control of gas-turbine engines
* LMH-110 (with modified hex file, see below) is very simple because it uses a microcontroller. Set-up is also very simple. First program the con
The described circuit is designed to provide smooth and realistic actuation for applications such as landing gear deployment, flap adjustments, and throttle control in gas-turbine engines. The core functionality is achieved through a microcontroller that manages the speed of a conventional proportional servo.
The circuit operates by regulating the pulse width modulation (PWM) signal sent to the servo, which directly influences its rotation speed. By adjusting the duty cycle of the PWM signal, the microcontroller can control the time it takes for the servo to move from one position to another. The design allows for a full range of motion, ensuring that the servo can achieve any position within its operational limits while maintaining its torque characteristics.
The timing for the servo's movement can be configured to range from 1 to 10 seconds, providing flexibility for different applications. This feature is particularly useful in modeling scenarios where realistic motion is required, such as in radio-controlled aircraft or other remote-controlled devices.
The setup process for this circuit is straightforward. Initially, the microcontroller must be programmed with the appropriate firmware, which includes the logic for controlling the servo speed and any specific parameters related to the application (e.g., timing settings for landing gear or flaps). The mention of modifying the hex file for the LMH-110 indicates that specific adjustments may be necessary to tailor the operation of the circuit for different hardware configurations.
In summary, the circuit is an effective solution for achieving realistic actuation in various applications, leveraging the capabilities of a microcontroller to provide precise control over servo movements while ensuring that torque is not compromised. This design is suitable for hobbyists and professionals alike, offering a simple yet powerful means of enhancing the functionality of proportional servos.Realistic flap and landing gear actuation. This circuit slows the speed of a conventional proportional servo. It regulates the time required for full servo rotation from 1 to 10 seconds without any reduction in the servo`s torque, and every servo position is possible (proportional). It is suitable for: * Landing gear * Flaps * Throttle control of gas-turbine engines * LMH-110 (with modified hex file, see below) is very simple because it uses a microcontroller. Set-up is also very simple. First program the con
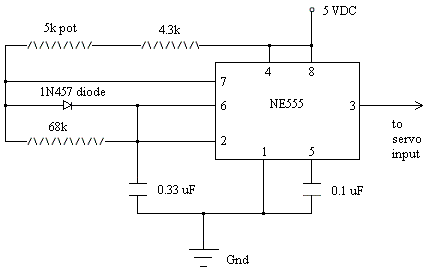
RC Servos
A servo is a general term for an automatic control system, derived from the Latin word "servus," meaning slave. It refers to a mechanism that can be set and forgotten, self-adjusting during operation through feedback. For instance, disk drives utilize...
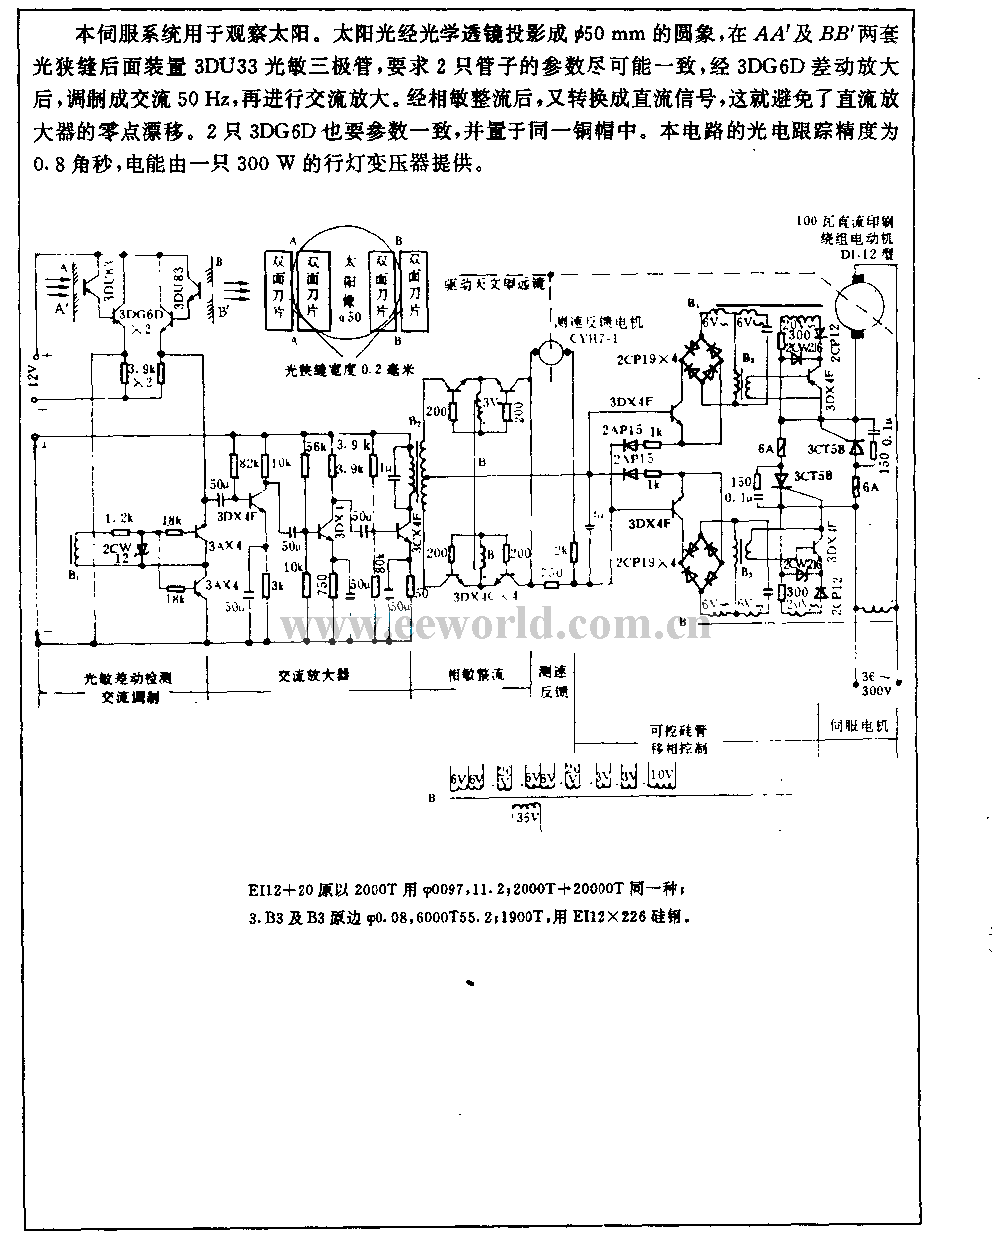
Tracking sun photoelectric servo circuit used in chromospheric telescope
This servo system is designed to track the sun. Sunshine is focused onto a 50mm round image using an optical lens, and a 3DU33 photosensitive transistor is positioned at the light slit of AA' and BB'. It is essential that...
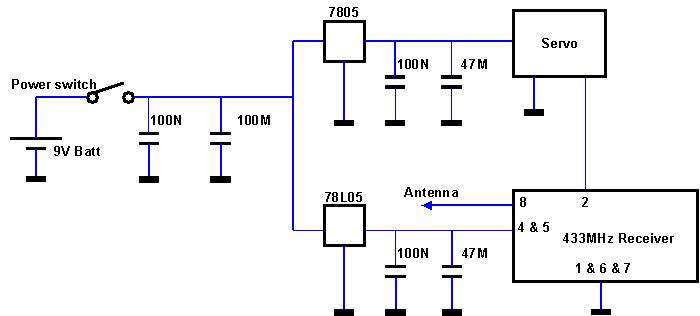
servo
The remote control is designed to allow the user to decide when to deploy the parachute, ideally after reaching apogee in a large open field. The deployment height can be adjusted based on wind conditions, enabling the user to control...
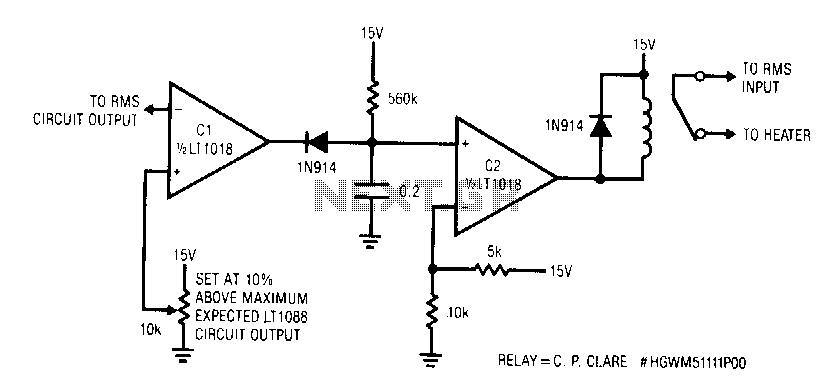
Servo-sensed-heater-protector
This circuit responds quickly enough to prevent damage from most overloads. Capacitor C1's input is connected to the output of the LT1088 servo circuit. If the LT1088 circuit's output exceeds the threshold at C1's other input, C1 trips, discharging the...
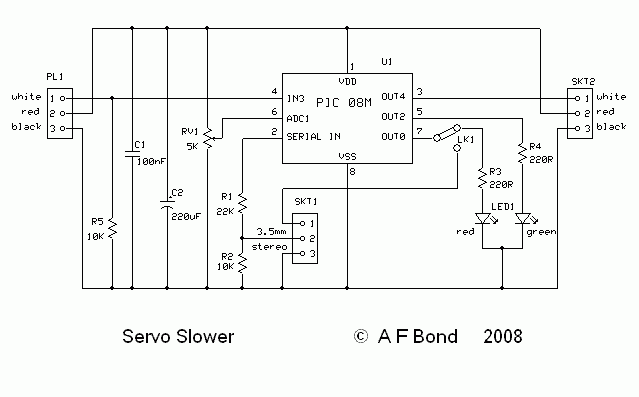
Solent Radio Control Model Boat Club
A servo controller has evolved from a "servo slower" unit, designed to reduce the slew rate (traverse time) of proportional servos. In model boats, this device is commonly used to control the rotation of a servo-driven gun turret, as direct...
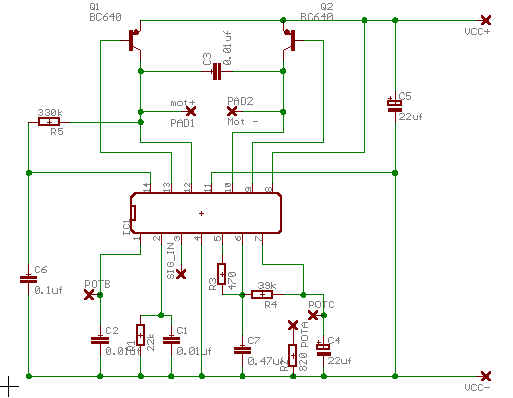
Servo Driver
To connect the three potentiometer (Pot) terminals, it is essential to identify the tags and their respective positions. When examining the back of the potentiometer, ensure the tags are oriented at the top. Incorrect connections will result in the servo...
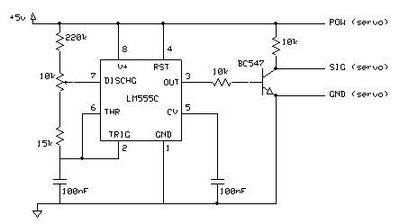
Simple servo controller Schematic
This circuit enables the testing of a servo motor. The angle of the servo can be adjusted using a 10k potentiometer. It is possible that not all positions can be achieved with this circuit; experimenting with different resistors may provide...
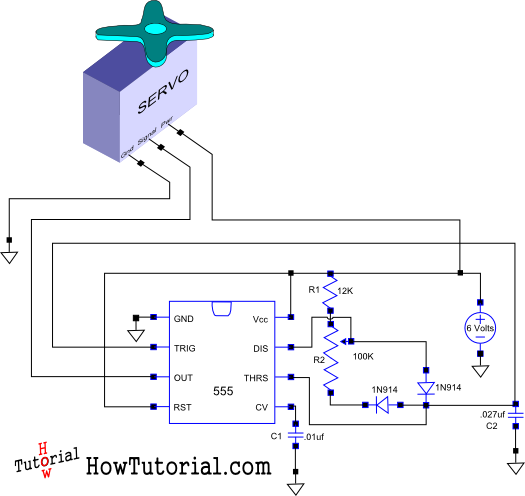
how do you build a simple circuit to control a servo
This document outlines the design of a simple circuit that enables control of a servo motor and allows for testing its functionality.
The circuit for controlling a servo motor typically consists of a microcontroller, a power supply, and the servo motor...
Tracking sun photoelectric servo circuit used in chromospheric telescope
This servo system is designed to track the sun. Sunshine is focused onto a 50mm round image using an optical lens, and a 3DU33 photosensitive transistor is positioned at the light slit of AA' and BB'. It is essential that...