


servo
#servo
#remote control
#parachute deployment
#wireless control
#open field
#wind conditions
#height control
#manual deployment
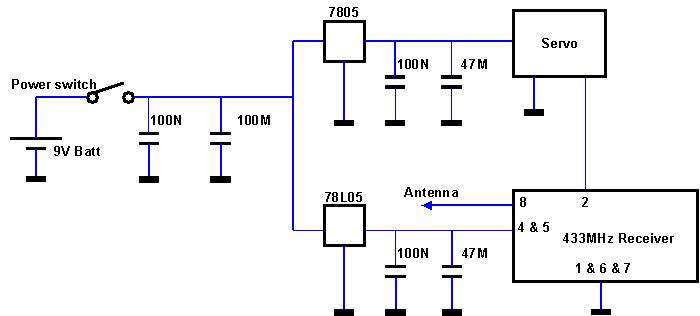
Description: The remote control is designed to allow the user to decide when to deploy the parachute, ideally after reaching apogee in a large open field. The deployment height can be adjusted based on wind conditions, enabling the user to control the effort required to retrieve the rocket. The risk of the rocket getting caught in a tree is acknowledged, and the user can choose not to deploy the parachute if the rocket is descending towards a tree. A commercially available transmitter/receiver combination can be utilized for remote control, such as standard equipment from RC planes or cars. The effective range of the transmitter is typically over 100 meters, with a direct line of sight to the receiver in the rocket. For those new to the RC hobby, basic electronic skills like soldering and voltage measurement are sufficient to create a remote control deployment system. A 433MHz transmitter/receiver pair from Velleman is chosen, which has a small form factor suitable for portability. The transmitter sends a digital code at a low baud rate, and a microcontroller at the receiver decodes this signal to trigger the parachute deployment. The circuit is built around a CMOS quad Schmitt-trigger NAND gate (4093), powered directly from the battery voltage to maximize efficiency. An oscillator generates a frequency of approximately 60Hz, with pulse width and frequency being dependent on the supply voltage.
The remote control parachute deployment system utilizes a 433MHz transmitter and receiver pair, which are compact and designed for applications such as garage door openers. The transmitter is activated by a single button, making it user-friendly. The circuit employs a CMOS quad Schmitt-trigger NAND gate (4093) as its core component. This IC contains four NAND gates, two of which are configured to create a basic oscillator circuit. The oscillator operates at a frequency of approximately 60Hz, producing a square wave output.
The output from the oscillator is processed through capacitive and resistive components to modify the pulse width of the signal sent to the parachute deployment mechanism. The configuration includes two 100nF capacitors and two adjustable 100K potentiometers, allowing the user to fine-tune the pulse width according to their requirements. This adjustability is crucial for ensuring reliable parachute deployment under varying conditions.
Powering the circuit directly from the battery voltage eliminates the need for additional voltage regulation, which simplifies the design and reduces the component count. This approach allows the system to operate effectively even as the battery voltage decreases, extending the operational lifetime of the device. The direct voltage dependency of the pulse width and frequency generated by the 4093 is a design consideration but is generally manageable within the operational parameters of the system.
The receiver is equipped with a microcontroller that decodes the digital signal transmitted by the remote control. Upon receiving the correct code, the microcontroller activates the deployment mechanism, which could be a servo or an electronic release system, ensuring that the parachute is deployed at the desired moment. The system's range of over 200 meters under optimal conditions ensures that the user can maintain control of the rocket during its descent, providing a robust solution for safe and controlled parachute deployment.With the remote control at your fingertips, you are the only one to decide when and if the parachute should deploy. Ideally, in a very large open field, you can wait until after apogee to deploy the parachute. Depending on wind conditions, you can decide yourself at what height the parachute has to open. This way, you are able to determine for yourself how many calories you want to burn chasing and retrieving the drifting rocket. Even when there is only one single tree in sight, we all know by experience that trees are rocket magnets and that your rocket will end up dangling in that tree top. When you see the rocket heading towards the tree upon descent, you may decide to NOT deploy the parachute by forcing away your finger tip from the remote control button.
The easiest way to implement remote control is to use a commercially available transmitter / receiver combination. This may be the standard remote control from a plane or car if you are a RC enthousiast already. However, when using the standard hobby RC equipment, keep in mind that the range between your transmitter on the ground and the rocket may be well over 100 meters.
One big advantage is that you should normally have a direct view path to the receiver in the rocket. Unless you are launching somewhere in the middle of the city center, which is not the best place. When you are not in the RC hobby yet (as in my case) and want to build a remote control deployment for your rocket anyway, this could be the solution for you. All you need are basic electronic skills like soldering and maybe measuring a voltage. The electronics are kept as simple as possible with no exotic components involved. If you are still interested, get yourself a bottle of your favourite regional beer and settle down. For the remote control transmitter / receiver pair, I chose a 433MHz solution from a company here in Belgium called Velleman.
Click on the image to get a link to some more info on the receiver and transmitter. The dimensions of the transmitter and receiver are very small. With direct sight conditions as we typically have with launching water rockets, range should be more than sufficient ( 200 meters is enough for me ). Their original target application is remote control for garage door openers, etc. The transmitter transmits a digital code at low baud rate. At the receiver output, a microcontroller decodes this digital signal and when the code is right, the gate / lock is opened.
One of my primary requirements was that the transmitter should be small enough to fit into your pocket. After all: you only need a single button = eject! Another requirement: simplicity ! The heart of the circuit is a good old CMOS quad Schmitt-trigger NAND gate: the 4093. The NAND gates U1. U4 are the 4 gates inside this single chip. The chip is powered directly from the battery voltage, no extra 5V or 8V stabilizer. This allows us to use the battery until it really drops below acceptable range. Also, with 12V the transmitter range is bigger than with 5V. The disadvantage of this simple power supply is that the pulse width and frequency generated by the 4093 is supply voltage dependent.
In practice this is not so critical. U1 forms a basic oscillator with a frequency of about 60Hz. The square wave at the output is differentiated by 2 x 100nF + the 2 x 100K potmeters. The positive edges of the oscillator result in a negative puls at the output of U2 and U3 with an adjustable pulse width. The pulse width should b
The remote control parachute deployment system utilizes a 433MHz transmitter and receiver pair, which are compact and designed for applications such as garage door openers. The transmitter is activated by a single button, making it user-friendly. The circuit employs a CMOS quad Schmitt-trigger NAND gate (4093) as its core component. This IC contains four NAND gates, two of which are configured to create a basic oscillator circuit. The oscillator operates at a frequency of approximately 60Hz, producing a square wave output.
The output from the oscillator is processed through capacitive and resistive components to modify the pulse width of the signal sent to the parachute deployment mechanism. The configuration includes two 100nF capacitors and two adjustable 100K potentiometers, allowing the user to fine-tune the pulse width according to their requirements. This adjustability is crucial for ensuring reliable parachute deployment under varying conditions.
Powering the circuit directly from the battery voltage eliminates the need for additional voltage regulation, which simplifies the design and reduces the component count. This approach allows the system to operate effectively even as the battery voltage decreases, extending the operational lifetime of the device. The direct voltage dependency of the pulse width and frequency generated by the 4093 is a design consideration but is generally manageable within the operational parameters of the system.
The receiver is equipped with a microcontroller that decodes the digital signal transmitted by the remote control. Upon receiving the correct code, the microcontroller activates the deployment mechanism, which could be a servo or an electronic release system, ensuring that the parachute is deployed at the desired moment. The system's range of over 200 meters under optimal conditions ensures that the user can maintain control of the rocket during its descent, providing a robust solution for safe and controlled parachute deployment.With the remote control at your fingertips, you are the only one to decide when and if the parachute should deploy. Ideally, in a very large open field, you can wait until after apogee to deploy the parachute. Depending on wind conditions, you can decide yourself at what height the parachute has to open. This way, you are able to determine for yourself how many calories you want to burn chasing and retrieving the drifting rocket. Even when there is only one single tree in sight, we all know by experience that trees are rocket magnets and that your rocket will end up dangling in that tree top. When you see the rocket heading towards the tree upon descent, you may decide to NOT deploy the parachute by forcing away your finger tip from the remote control button.
The easiest way to implement remote control is to use a commercially available transmitter / receiver combination. This may be the standard remote control from a plane or car if you are a RC enthousiast already. However, when using the standard hobby RC equipment, keep in mind that the range between your transmitter on the ground and the rocket may be well over 100 meters.
One big advantage is that you should normally have a direct view path to the receiver in the rocket. Unless you are launching somewhere in the middle of the city center, which is not the best place. When you are not in the RC hobby yet (as in my case) and want to build a remote control deployment for your rocket anyway, this could be the solution for you. All you need are basic electronic skills like soldering and maybe measuring a voltage. The electronics are kept as simple as possible with no exotic components involved. If you are still interested, get yourself a bottle of your favourite regional beer and settle down. For the remote control transmitter / receiver pair, I chose a 433MHz solution from a company here in Belgium called Velleman.
Click on the image to get a link to some more info on the receiver and transmitter. The dimensions of the transmitter and receiver are very small. With direct sight conditions as we typically have with launching water rockets, range should be more than sufficient ( 200 meters is enough for me ). Their original target application is remote control for garage door openers, etc. The transmitter transmits a digital code at low baud rate. At the receiver output, a microcontroller decodes this digital signal and when the code is right, the gate / lock is opened.
One of my primary requirements was that the transmitter should be small enough to fit into your pocket. After all: you only need a single button = eject! Another requirement: simplicity ! The heart of the circuit is a good old CMOS quad Schmitt-trigger NAND gate: the 4093. The NAND gates U1. U4 are the 4 gates inside this single chip. The chip is powered directly from the battery voltage, no extra 5V or 8V stabilizer. This allows us to use the battery until it really drops below acceptable range. Also, with 12V the transmitter range is bigger than with 5V. The disadvantage of this simple power supply is that the pulse width and frequency generated by the 4093 is supply voltage dependent.
In practice this is not so critical. U1 forms a basic oscillator with a frequency of about 60Hz. The square wave at the output is differentiated by 2 x 100nF + the 2 x 100K potmeters. The positive edges of the oscillator result in a negative puls at the output of U2 and U3 with an adjustable pulse width. The pulse width should b
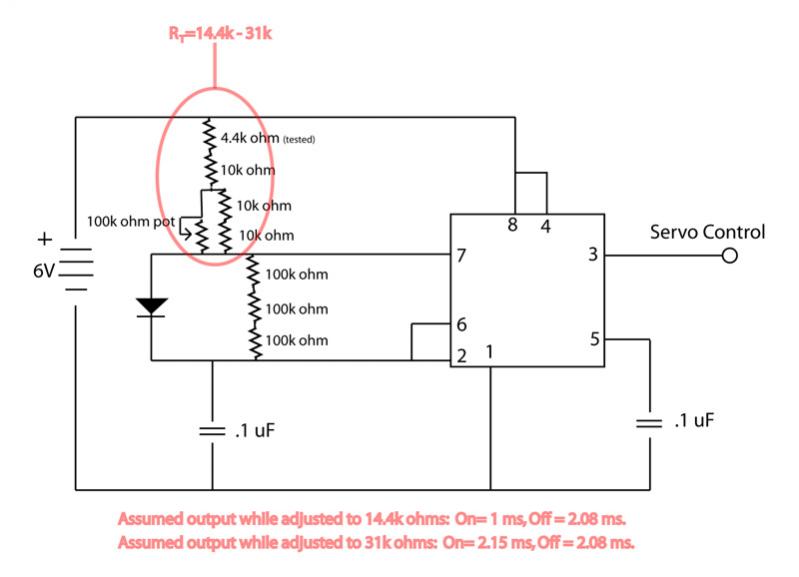
Servo Controller Help
The circuit is not providing the full range of motion for a servo, only achieving approximately 90 degrees. Assistance is requested to review the circuit.
To address the issue of limited servo motion, it is essential to analyze the circuit design...
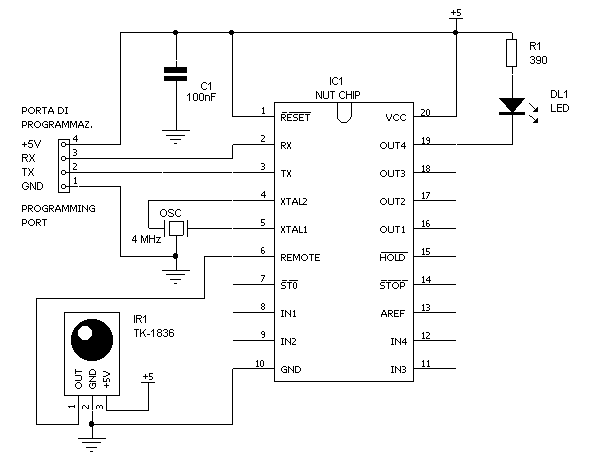
Remote controlled LED
The remote control transmits encoded signals. Each time a key is pressed, the relevant code is transmitted, usually repeating it many times to ensure reception. This encoded signals travels over a radio or infrared-light beam, to eventually get captured by...
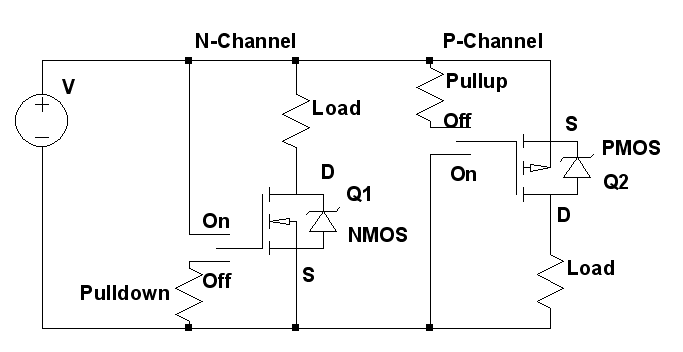
Driving a servo with MOSFET
Construct a compact battery-powered device that incorporates a servo motor. The design should include a mechanism to turn off the servo to conserve battery life. It has been noted that MOSFETs can be utilized for this purpose; however, there is...

Atari Joystick Wired Remote Control for Robots
The simplest solution for implementing joystick control for a robot is to program the actions in software on a microcontroller. However, many users prefer off-the-shelf components, thus this circuit is designed using diodes, resistors, transistors, and a FAN8200 motor driver...
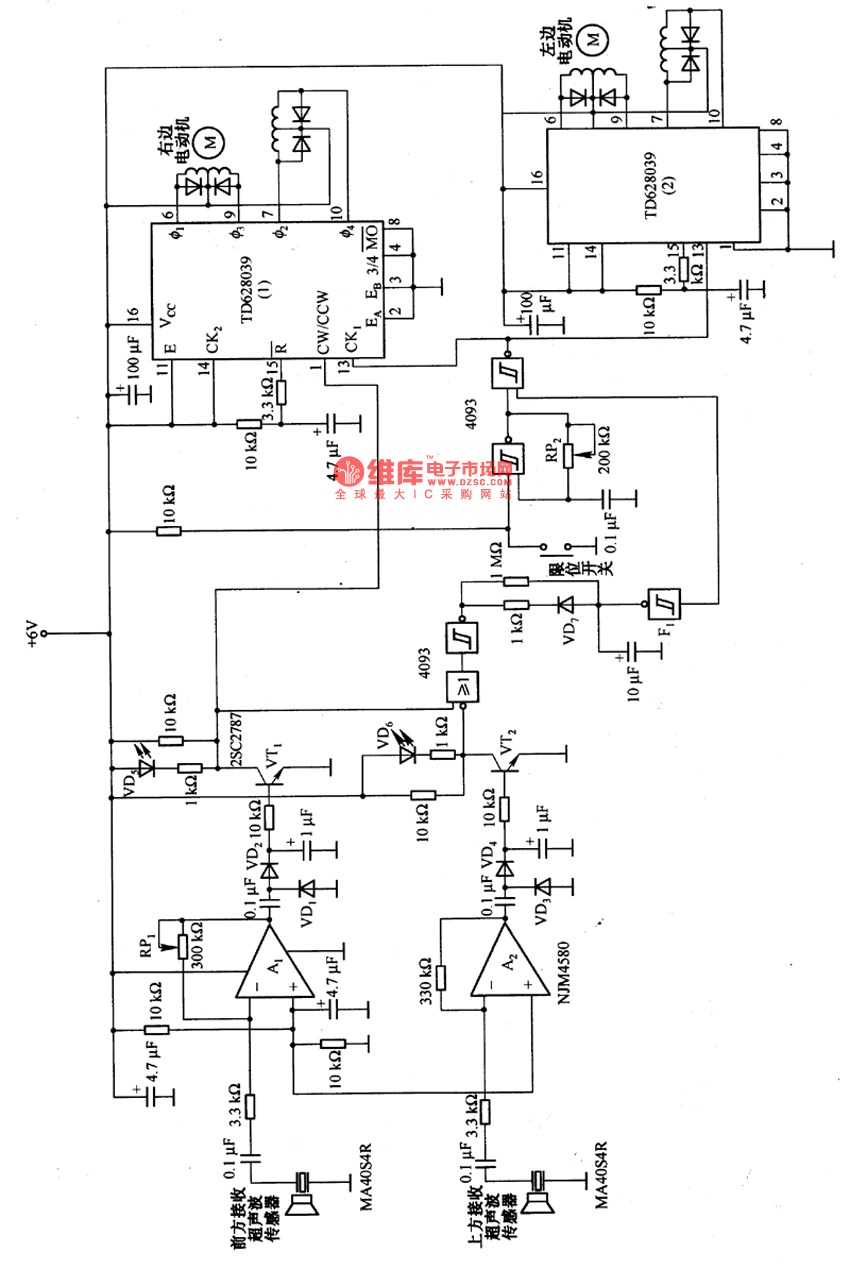
Remote control robot circuit
The remote control robot circuit is illustrated in the accompanying figure. Figure 2-36(a) presents the circuit diagram, while figure 2-36(b) depicts the operating timing diagram. The robot's rotation process involves an ultrasonic launching circuit, which consists of a 40 kHz...
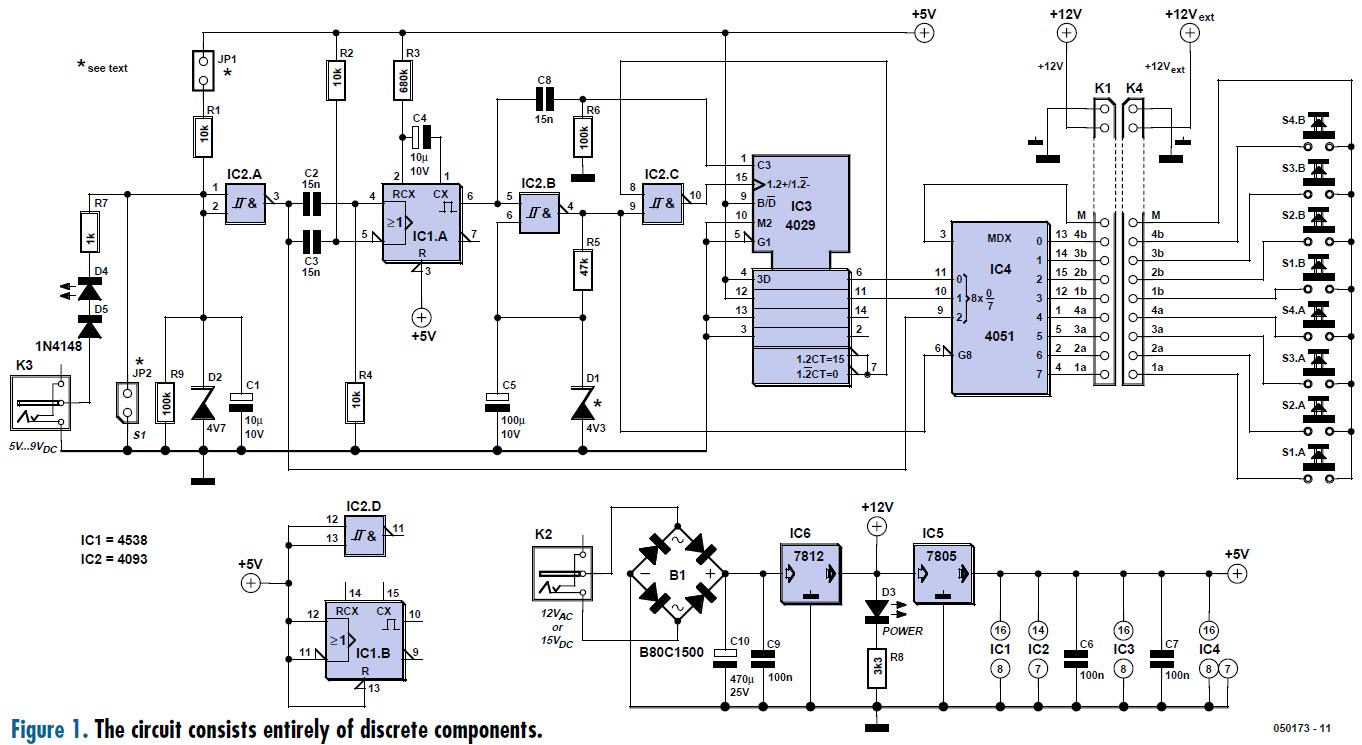
Remote Control Operator
Remote-controlled light switches are increasingly popular. DIY stores offer affordable sets that include multiple light switches and a remote control unit, allowing users to manage lighting from their armchairs. However, controlling the lighting while away from home can be a...
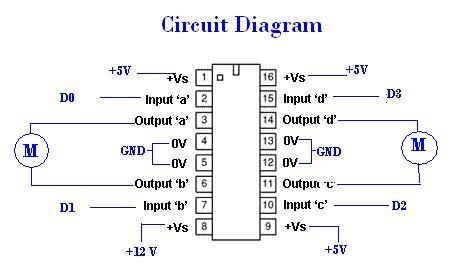
Making a Remote Controlled Car using Sun SPOT
A remote Sun SPOT will transmit data to a Sun SPOT mounted on a car, which will control an integrated circuit (IC) according to the digital input/output pins D0 to D3. The IC will subsequently drive the motors that propel...
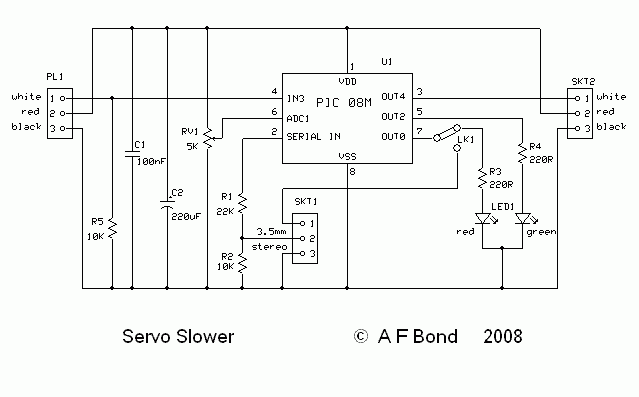
Solent Radio Control Model Boat Club
A servo controller has evolved from a "servo slower" unit, designed to reduce the slew rate (traverse time) of proportional servos. In model boats, this device is commonly used to control the rotation of a servo-driven gun turret, as direct...
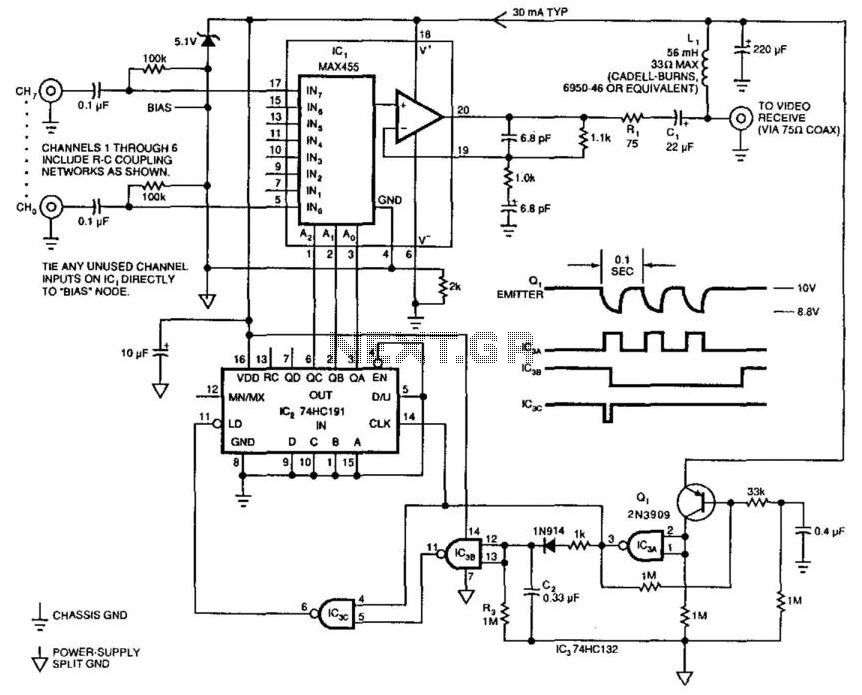
Remote-Controlled Switcher
This single-cable system transmits composite video (NTSC, PAL, or SECAM), power, and channel selection signals. The interface end of the circuit delivers 10 V down the cable, pulses the supply voltage to transmit channel-change commands, and buffers the received video...