


i want help with my project accelerometer controlled robotic arm
#accelerometer
#robotic arm
#RF communication
#RFM70
#RFM22
#motor control
#sensor
#wireless
#microcontroller
#project
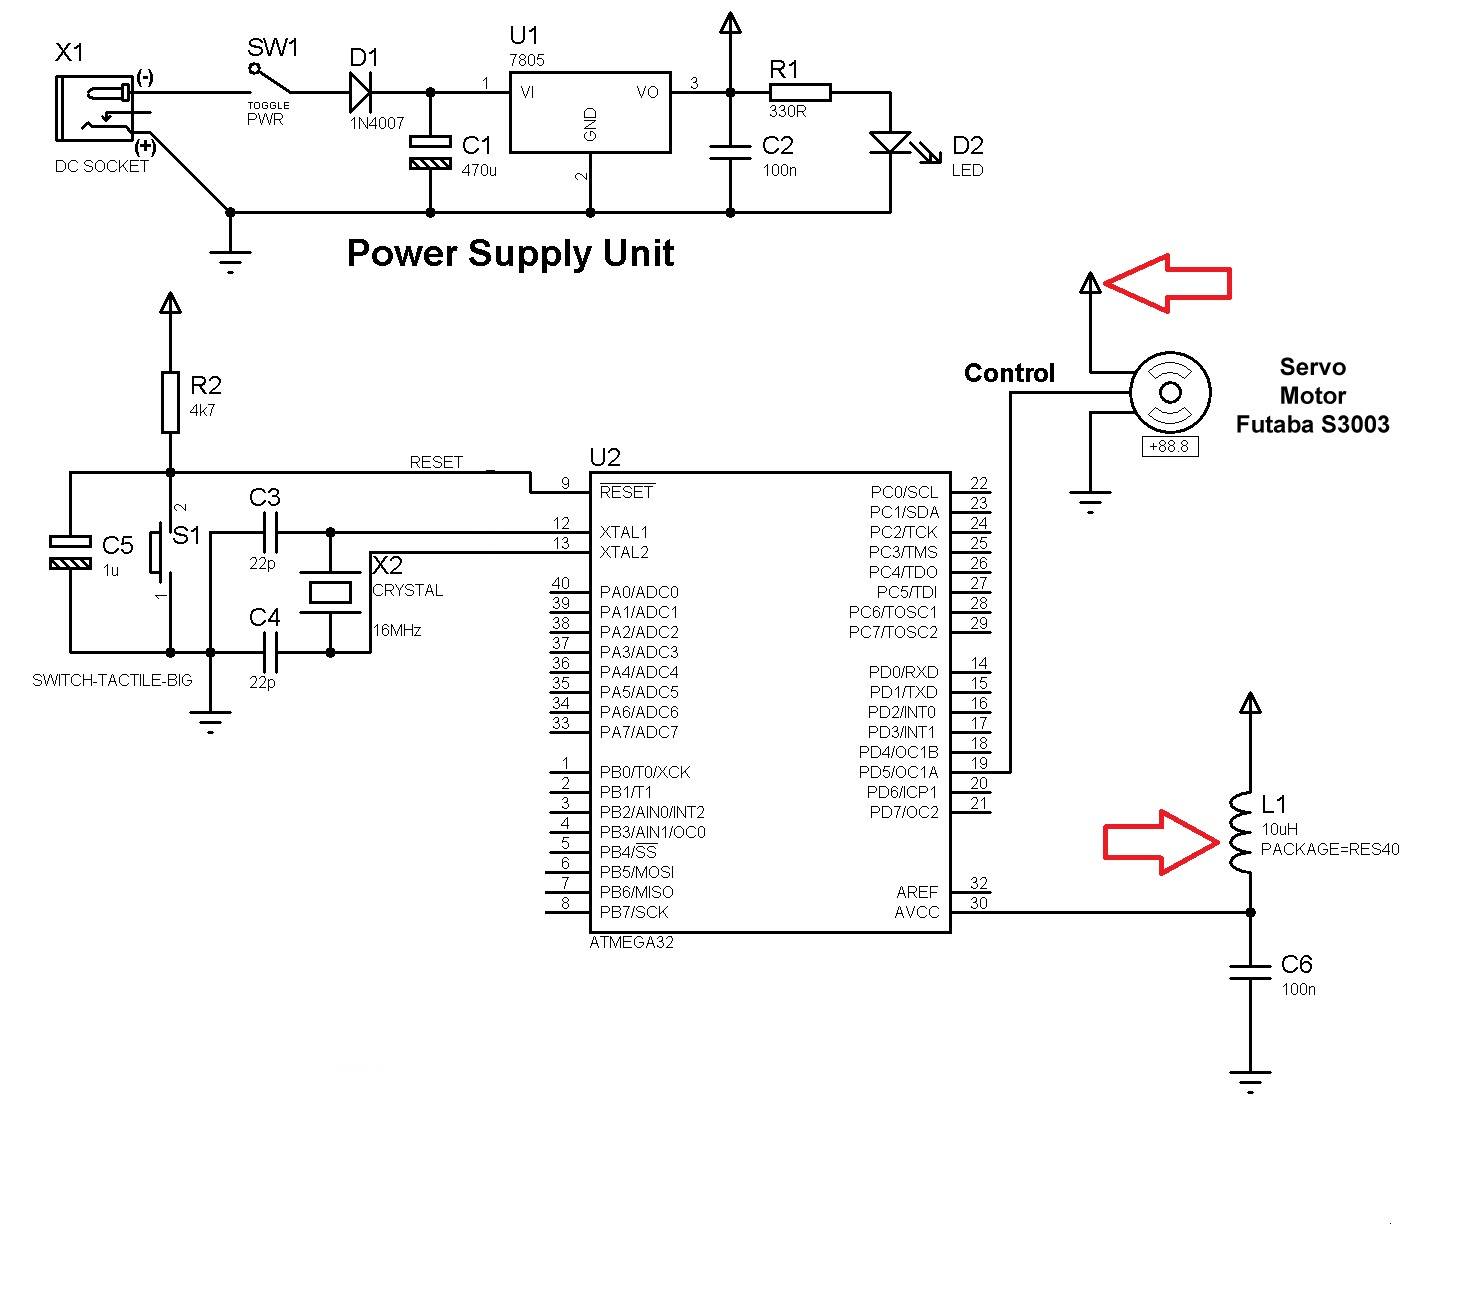
Description: Good preparation. There is one suggestion to use RFM70 or RFM22 for RF communication.
The RFM70 and RFM22 are low-power, high-performance RF transceiver modules designed for wireless communication applications. Both modules operate in the 2.4 GHz ISM band, making them suitable for various projects requiring short-range wireless data transmission.
The RFM70 module is known for its simplicity and ease of integration, featuring a low data rate of up to 250 kbps. It is particularly effective for applications that require a robust communication link with minimal power consumption, making it ideal for battery-operated devices. The module supports various modulation schemes, including GFSK, which enhances its performance in noisy environments.
On the other hand, the RFM22 offers a higher data rate of up to 1 Mbps, which is advantageous for applications needing faster data transfer. It also includes advanced features such as frequency hopping, which improves the reliability of communication by avoiding interference from other devices operating in the same frequency range. The RFM22 is suitable for more complex applications that require higher throughput and better noise immunity.
Both modules can be easily interfaced with microcontrollers via SPI (Serial Peripheral Interface), allowing for straightforward integration into various electronic designs. The choice between the RFM70 and RFM22 will largely depend on the specific requirements of the application, such as data rate, power consumption, and range. Proper selection and implementation of these modules can significantly enhance the performance and reliability of wireless communication systems.Good Preparation. I like this. There is one suggestion you can use RFM70 or RFM22 for RF communication..
The RFM70 and RFM22 are low-power, high-performance RF transceiver modules designed for wireless communication applications. Both modules operate in the 2.4 GHz ISM band, making them suitable for various projects requiring short-range wireless data transmission.
The RFM70 module is known for its simplicity and ease of integration, featuring a low data rate of up to 250 kbps. It is particularly effective for applications that require a robust communication link with minimal power consumption, making it ideal for battery-operated devices. The module supports various modulation schemes, including GFSK, which enhances its performance in noisy environments.
On the other hand, the RFM22 offers a higher data rate of up to 1 Mbps, which is advantageous for applications needing faster data transfer. It also includes advanced features such as frequency hopping, which improves the reliability of communication by avoiding interference from other devices operating in the same frequency range. The RFM22 is suitable for more complex applications that require higher throughput and better noise immunity.
Both modules can be easily interfaced with microcontrollers via SPI (Serial Peripheral Interface), allowing for straightforward integration into various electronic designs. The choice between the RFM70 and RFM22 will largely depend on the specific requirements of the application, such as data rate, power consumption, and range. Proper selection and implementation of these modules can significantly enhance the performance and reliability of wireless communication systems.Good Preparation. I like this. There is one suggestion you can use RFM70 or RFM22 for RF communication..
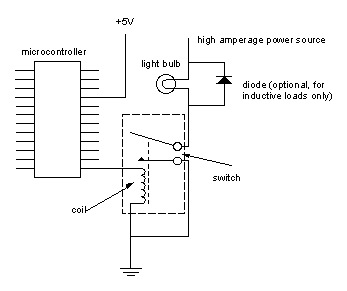
Controlling high-current circuits
Digital output from a microcontroller is typically a low-amperage signal. For example, when a pin is set HIGH on the microcontroller (in Wiring/Arduino, it is digitalWrite(somePin, HIGH);), the voltage from that pin is usually +3.3V or +5V, with the current...
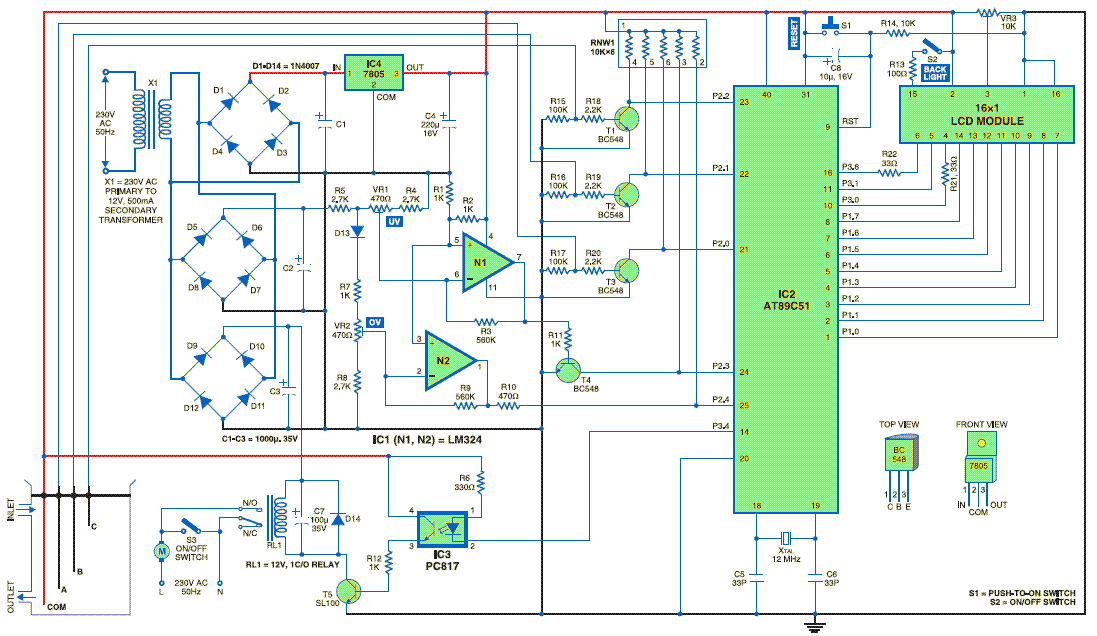
Water Level controller
The microcontroller-based water level controller and motor protector manages the on and off states of the motor based on the water level in the overhead tank (OHT). It regulates the tank's water level through a microcontroller, thereby providing automatic protection...
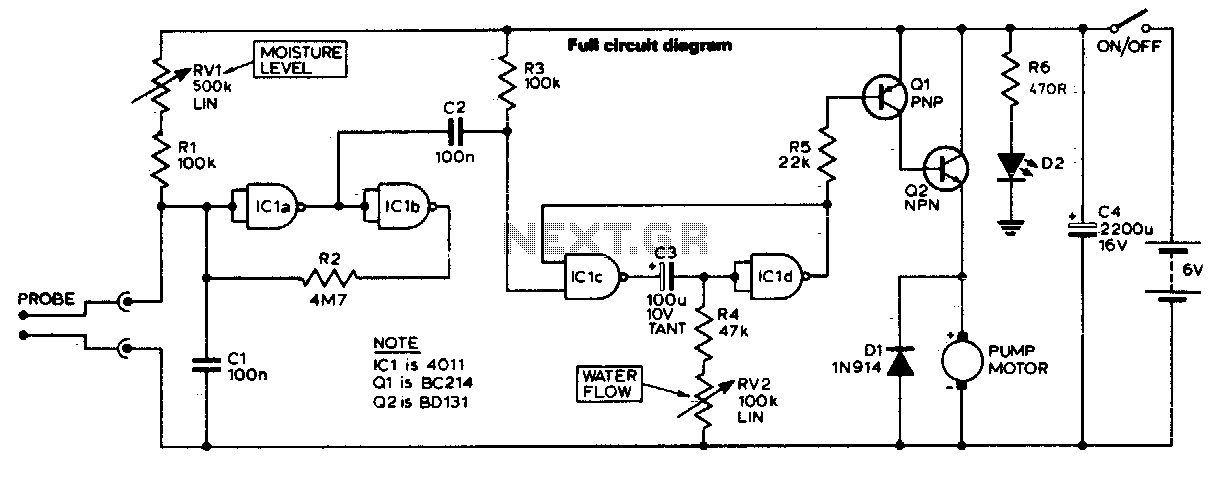
Automatic plant waterer
The unit consists of a sensor, timer, and electric water pump. The sensor is embedded in the soil, and when dry, the electronics operate the water pump for a preset time. The circuit is composed of a level-sensitive Schmitt trigger,...
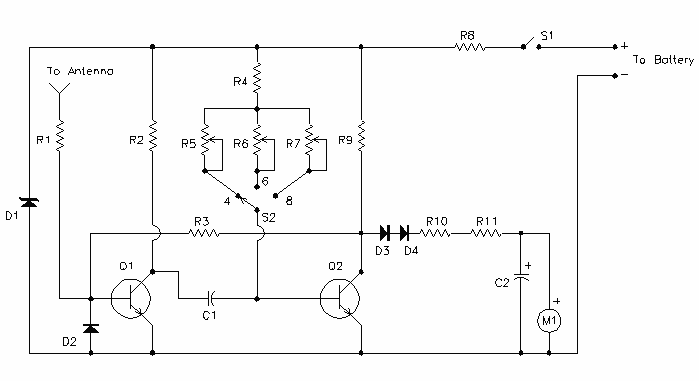
Wireless Auto Tachometer
Anyone performing their own automobile tune-ups knows how important it is to know your engine's speed. With this tachometer, you can measure your engine's speed without any connections or annoying timing lights.
The described tachometer is a non-invasive device designed for...
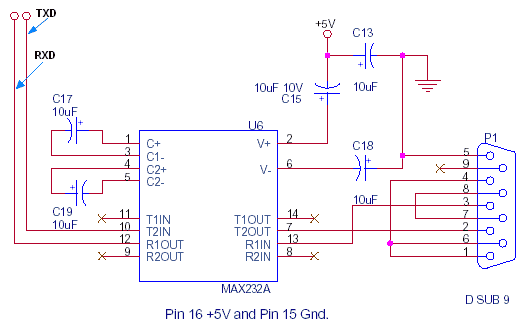
Interface a uC to PC RS232 with MAX232A
This document outlines the standard configuration for interfacing a microcontroller, such as the 8051, with a PC using RS232 through the MAX232A. The UART or serial port was absent in the 8049 and 8749 microcontrollers, which were predecessors to the...
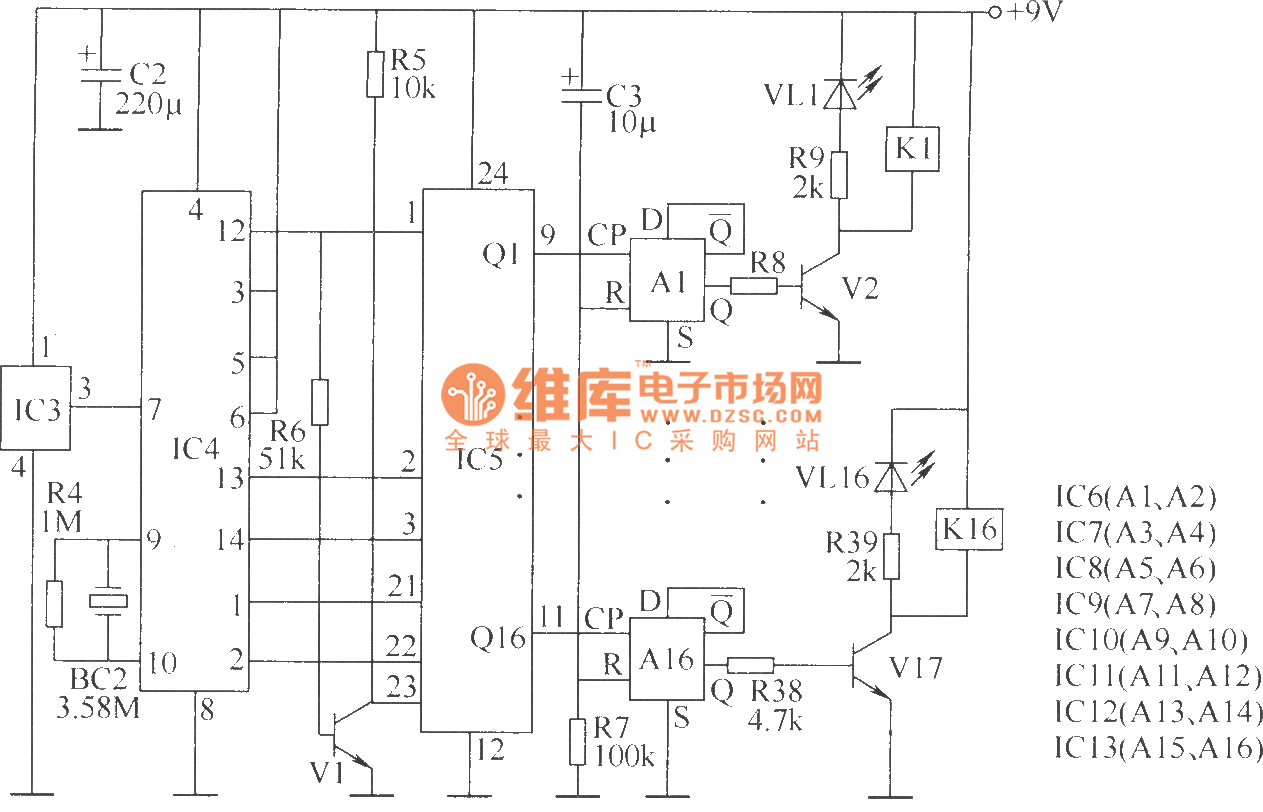
Wireless remote control switch circuit 5
The wireless remote control transmitter circuit consists of control buttons S1 to S16, resistors R1 to R3, a capacitor C1, a regulator diode VS, a crystal oscillator BC1, and DTMF encoder integrated circuits IC1 and IC2. The circuit components are...
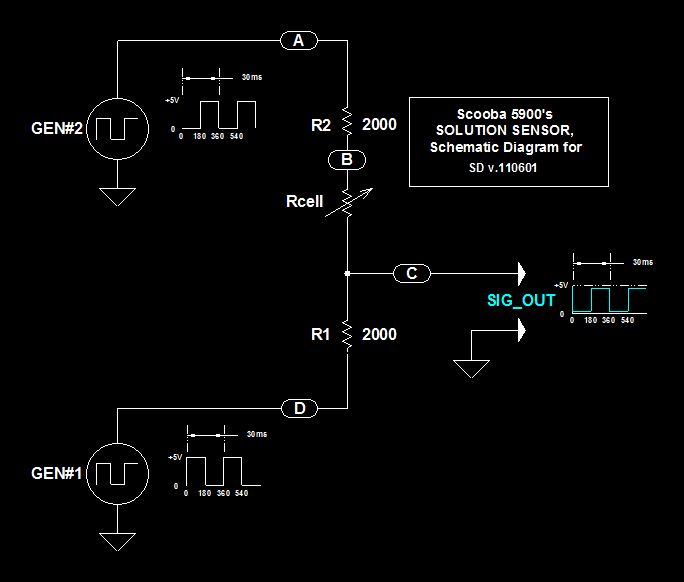
Scoobas Solution Sensing Tactic
This document serves multiple purposes, primarily to document the methods employed by a Scooba robot to detect: a) the presence of an acceptable cleaning solution being delivered to its pump, and b) the excess presence of used solution collected off...
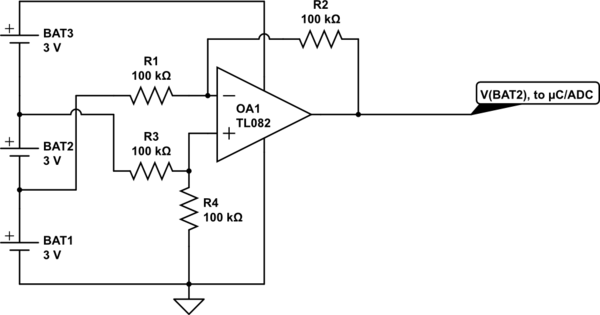
integrated circuit Improving absolute precision of ADC to balance battery voltage
Utilize a high-performance microcontroller (Piccolo TMS320F28035, 12-bit resolution, +/- 4 LSB offset, +/- 60 LSB gain) to measure the voltage across stacked battery cells and control related analog electronics for charge equalization. The microcontroller will also save data in EEPROM...
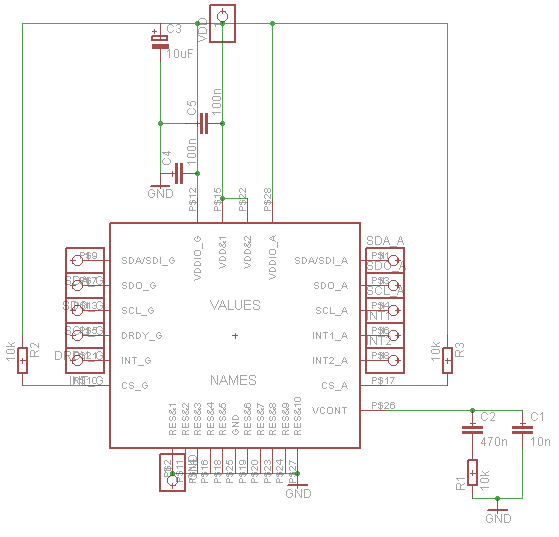
accelerometer Can internal PLL affect control logic in MEMS sensor
Establish communication between the microcontroller unit (MCU) and the accelerometer using either I2C or SPI protocols. It has been noted that shorting the phase-locked loop (PLL) filter input in the device does not affect the readings from the gyroscope or...